

Hi all
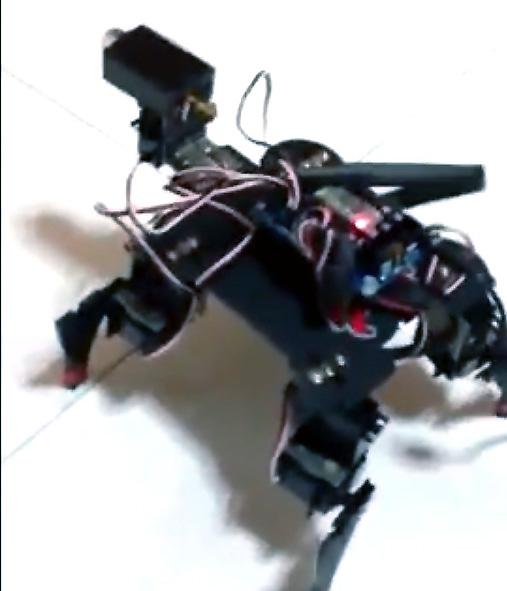
I have a made a new 2 DOF quad.
He is called Crabio 1.
I only have time to add a video about him for the time being.
I will post more pictures soon.
His walking pattern is abit noobish but i will fine tune him later:)
enjoy for the time being:)
By iskandershah
— Last update

Discover more robots
Ptp's Ezb V4 Custom Firmware V2
Custom EZB 4 firmware with AP, client/station, HOST/EZB and ports configuration; beta fixes, polished UI and developing...
DJ's Spider Robot
Control a converted RC spider using its DC motors and Sharp GP2D05 distance sensor; C# autonomous mode adds twitchy,...

Orwnic82's Ez-B Processor Quadrotor
Control a DIY quadrotor with Visual Studio apps: blade/angle monitoring, individual motor control, tilt monitoring and...

Hahah
Wait for my next video.. i am sure it will be as entertaining:)
He can now run, lean, kick a ball and sits:)
This is a very exciting robot! Very good work I know everyone would love to see your ARC Project File if you're willing to share your hard work

Cool robot! Good movements for such low DOF.
Hi guys!
as requested by DJ Sures, here is a overview about my ARCs.
And Crabio One Learns new tricks!
watch it!
Please comment:)
Man you did a great job!!!!!
Hahah Thank you DJ Sures !!!
As you can see on the last part of the video, Crabio Started losing power and falling to the ground.
Does that mean that the board has been over worked? any way to counter this? I am using a DC 12V bench power adapters..
Please advice.
The 12v bench power adapter from EZ-Robot? That should be good - but there are a lot of servos and the voltage regulator may be getting a tad too hot. It'll shut down when it gets too hot.
Amazing ! Good job !