


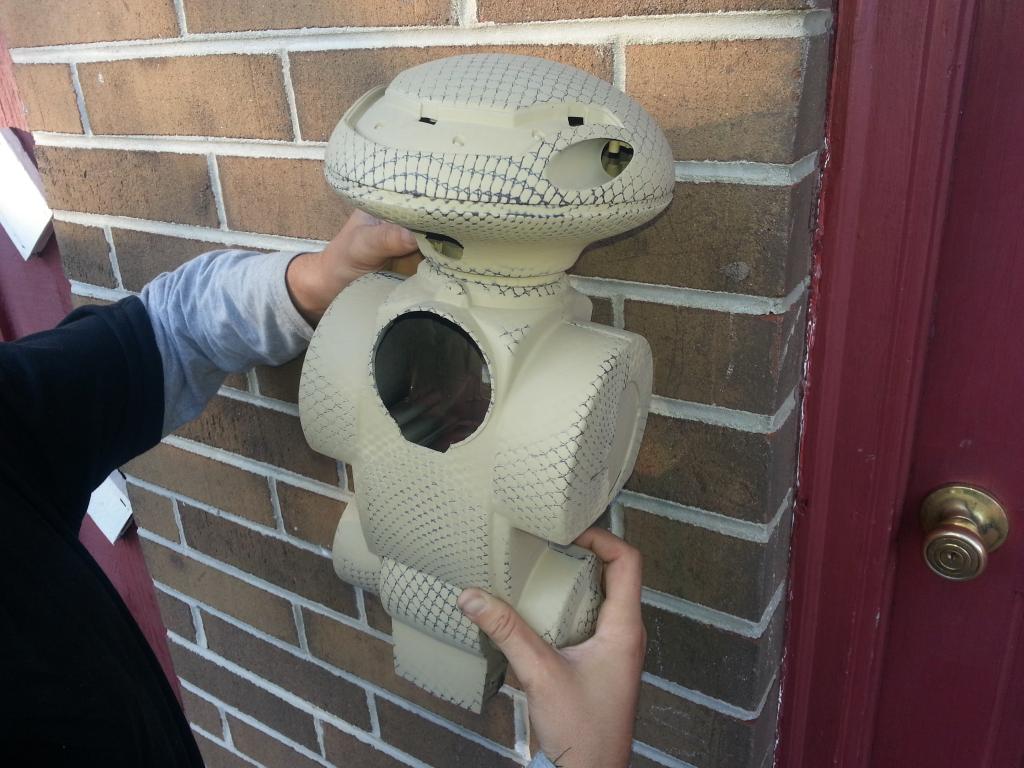

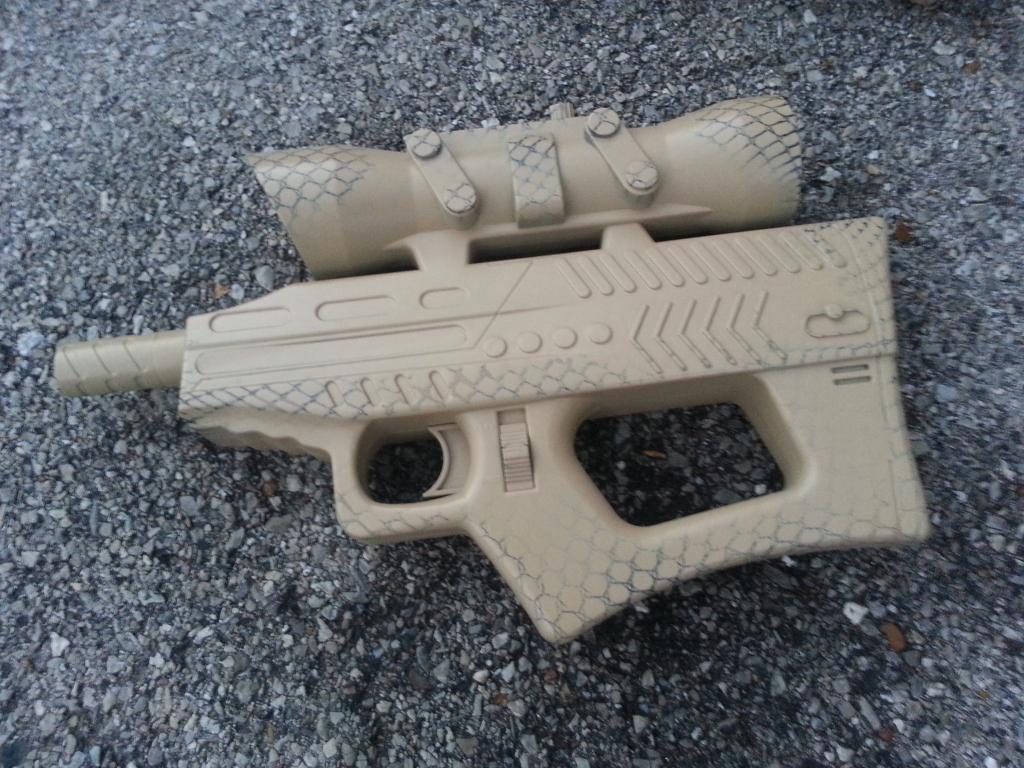
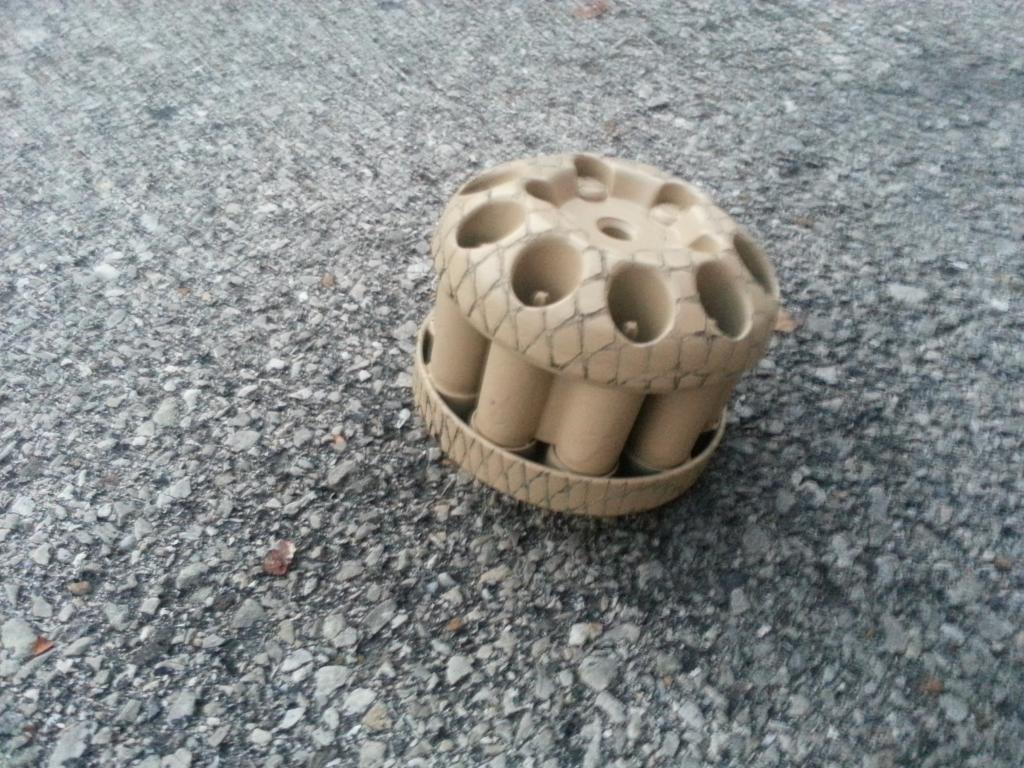

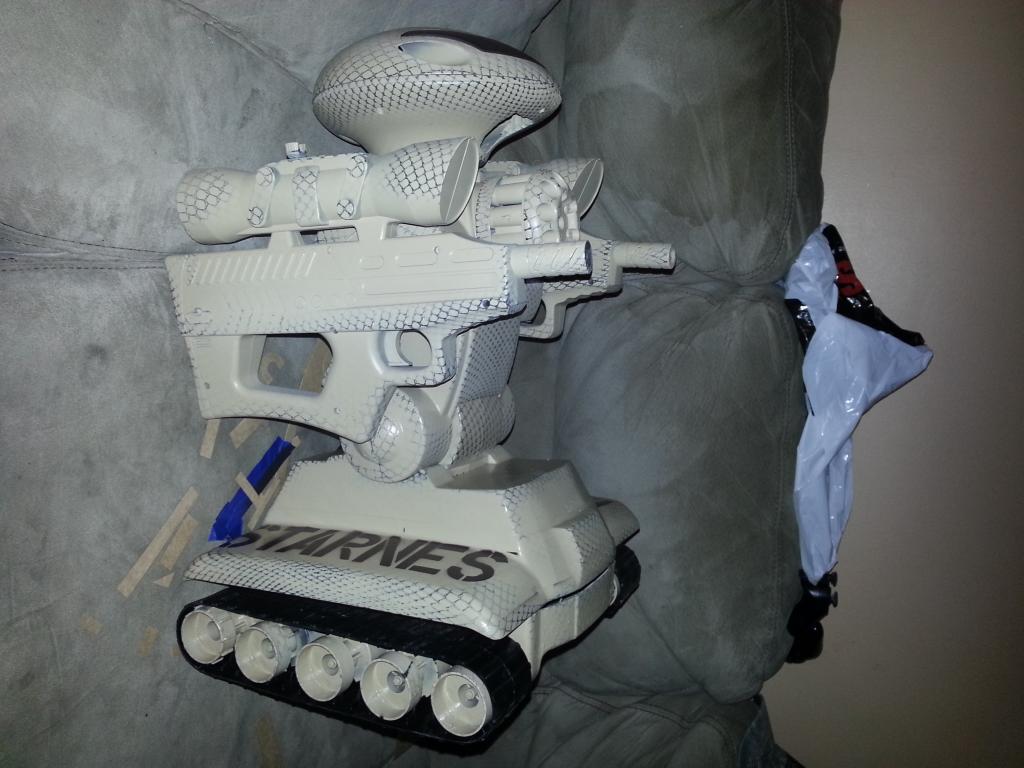
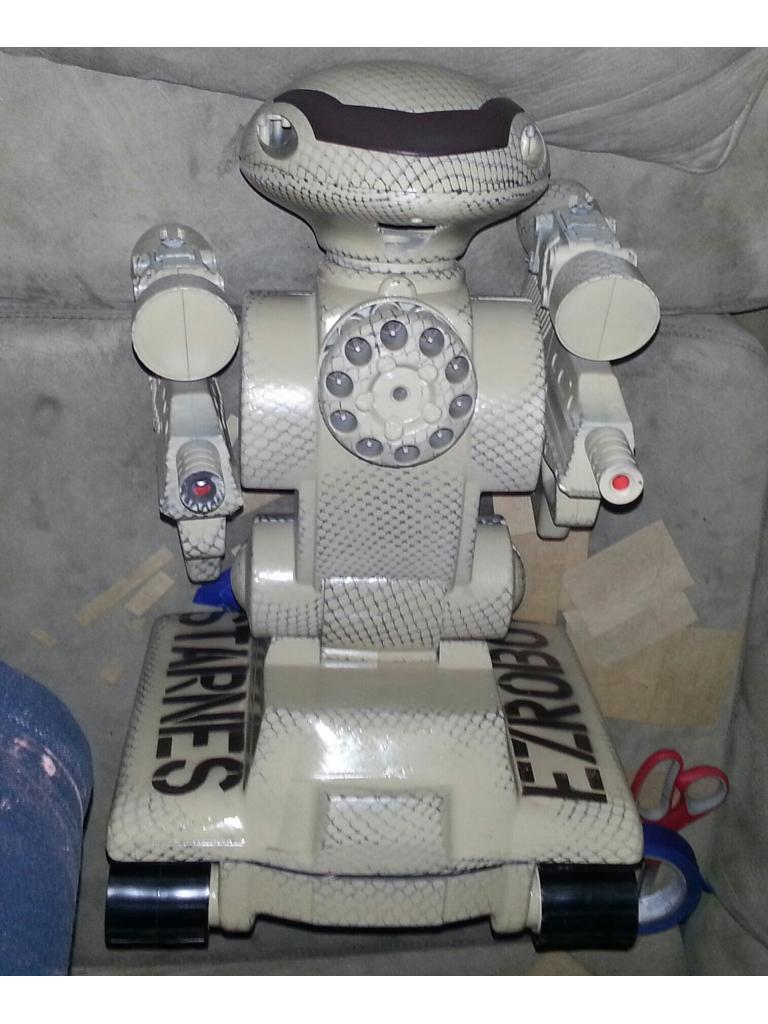
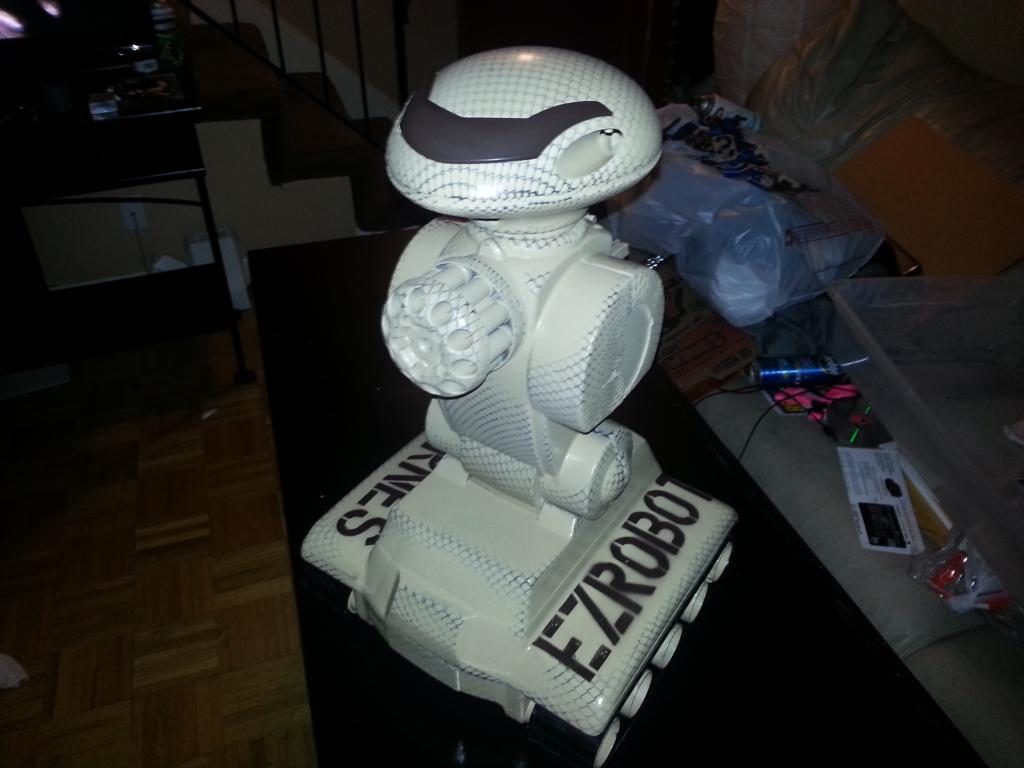
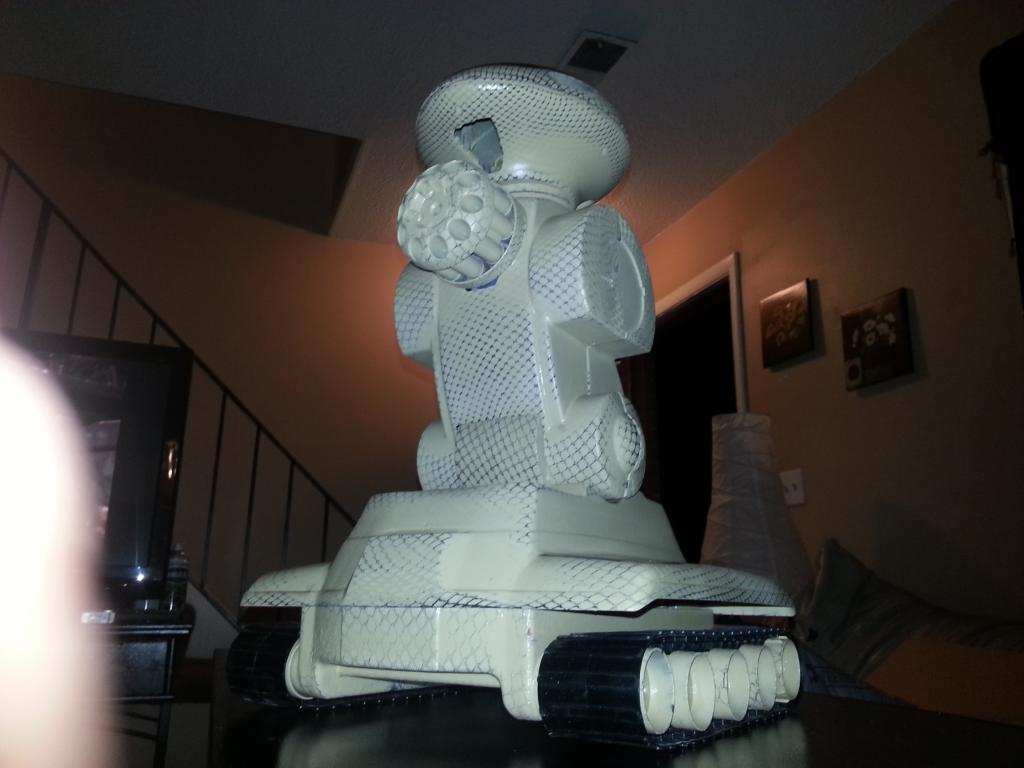
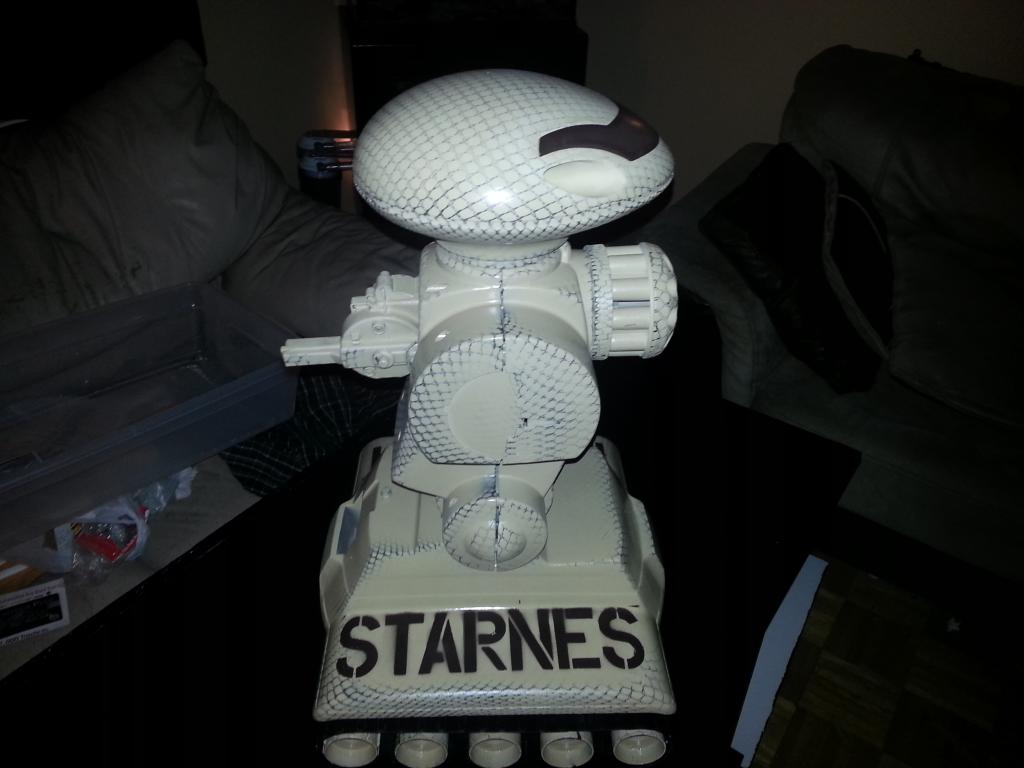
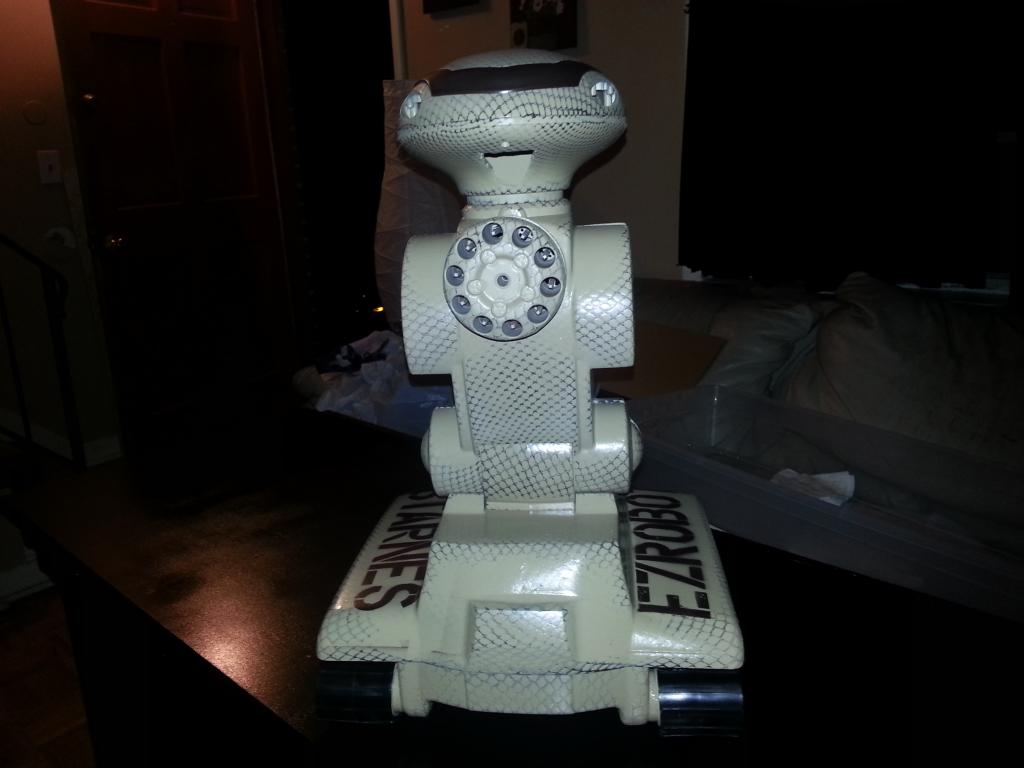
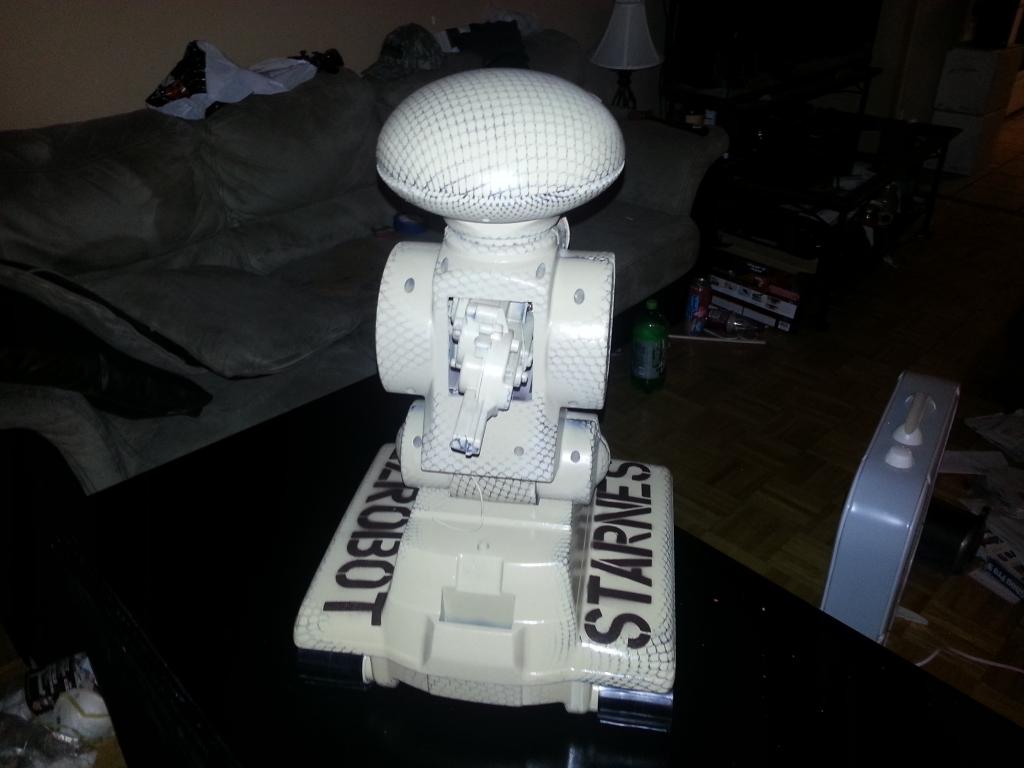


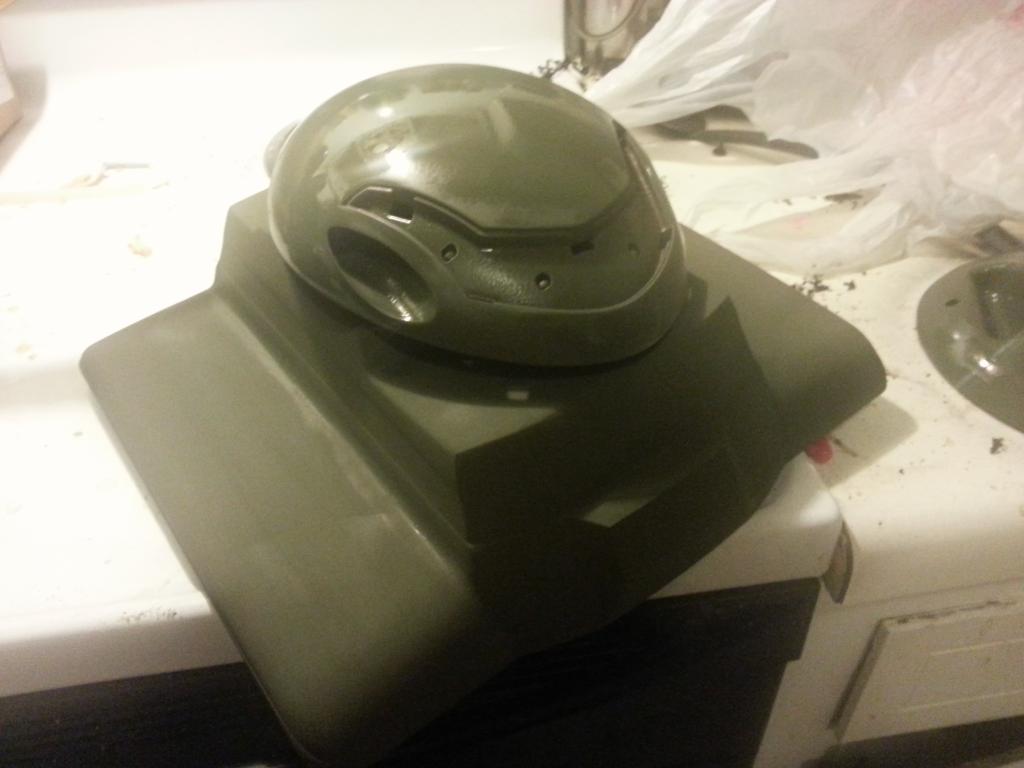


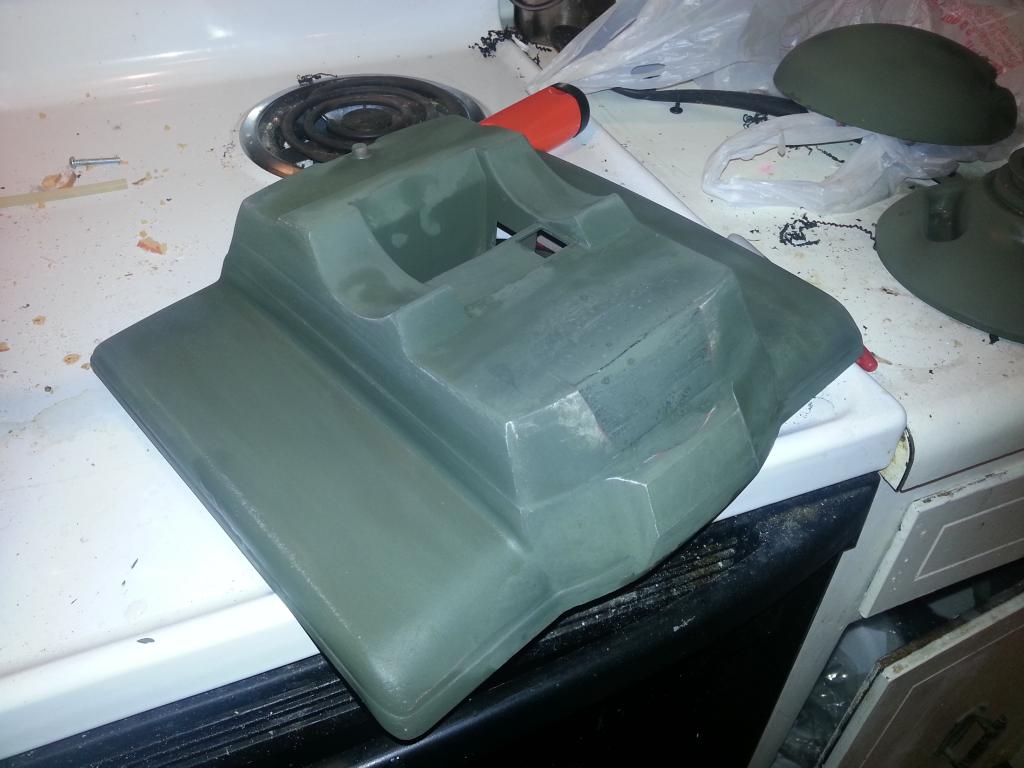
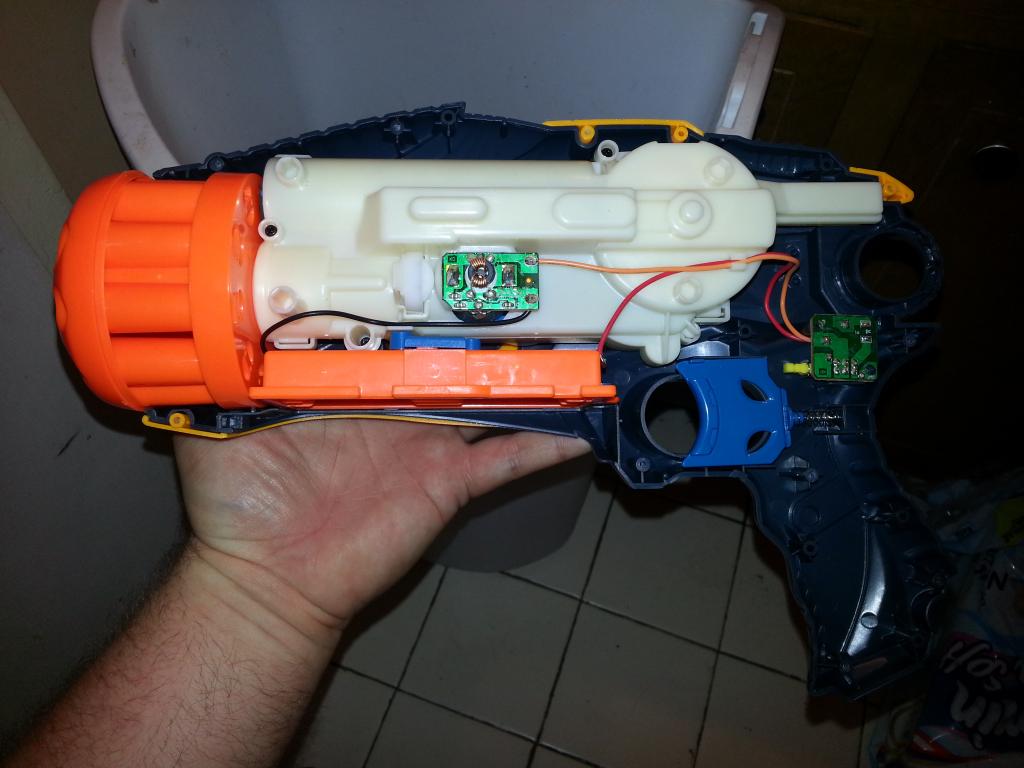
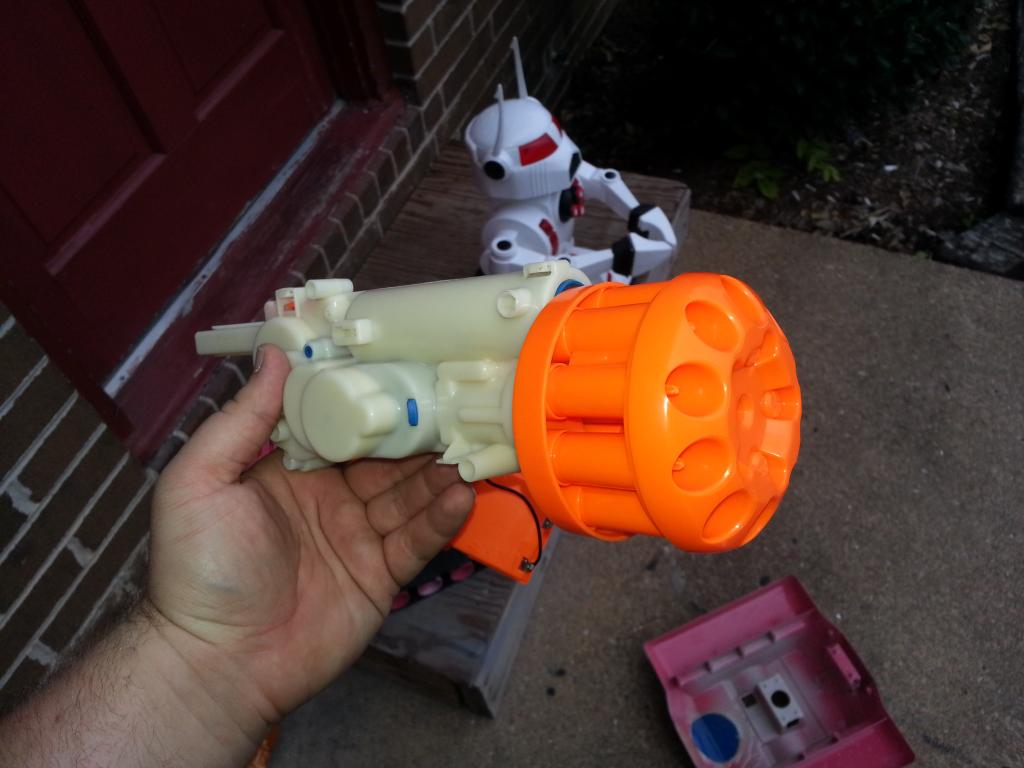

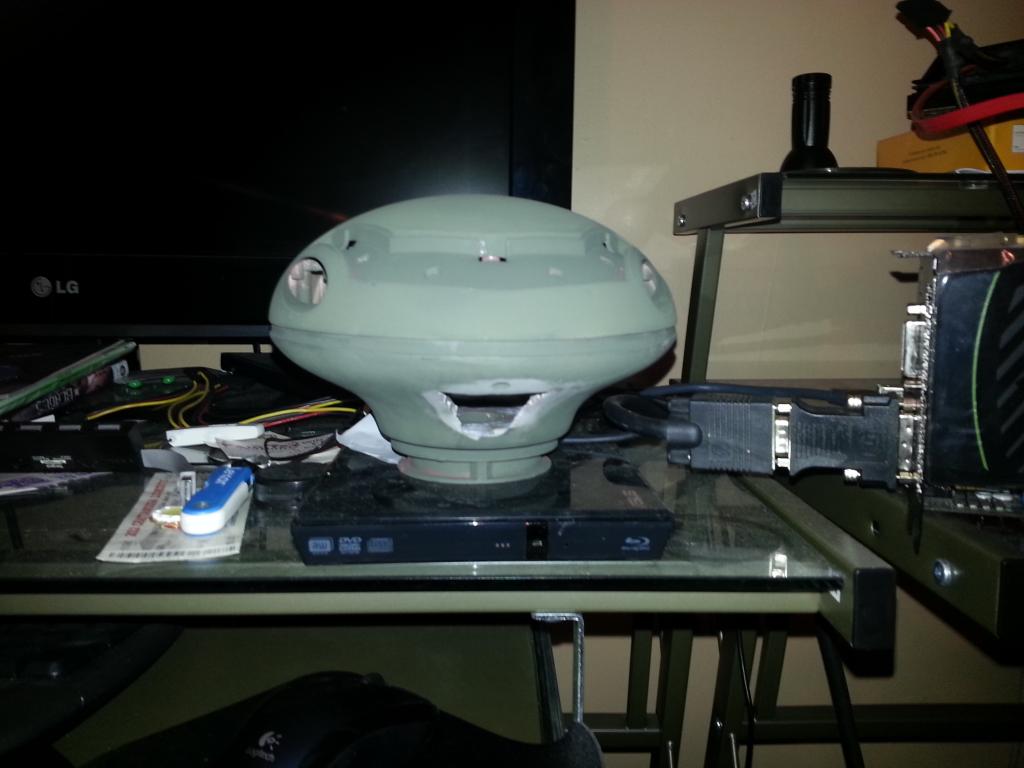
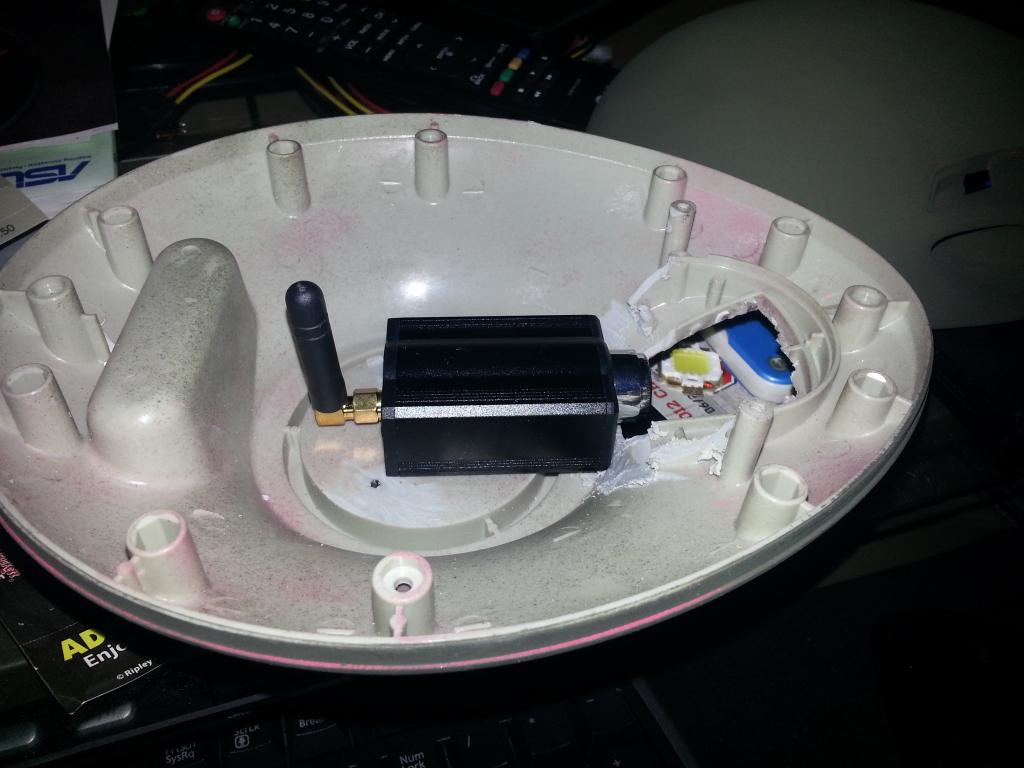
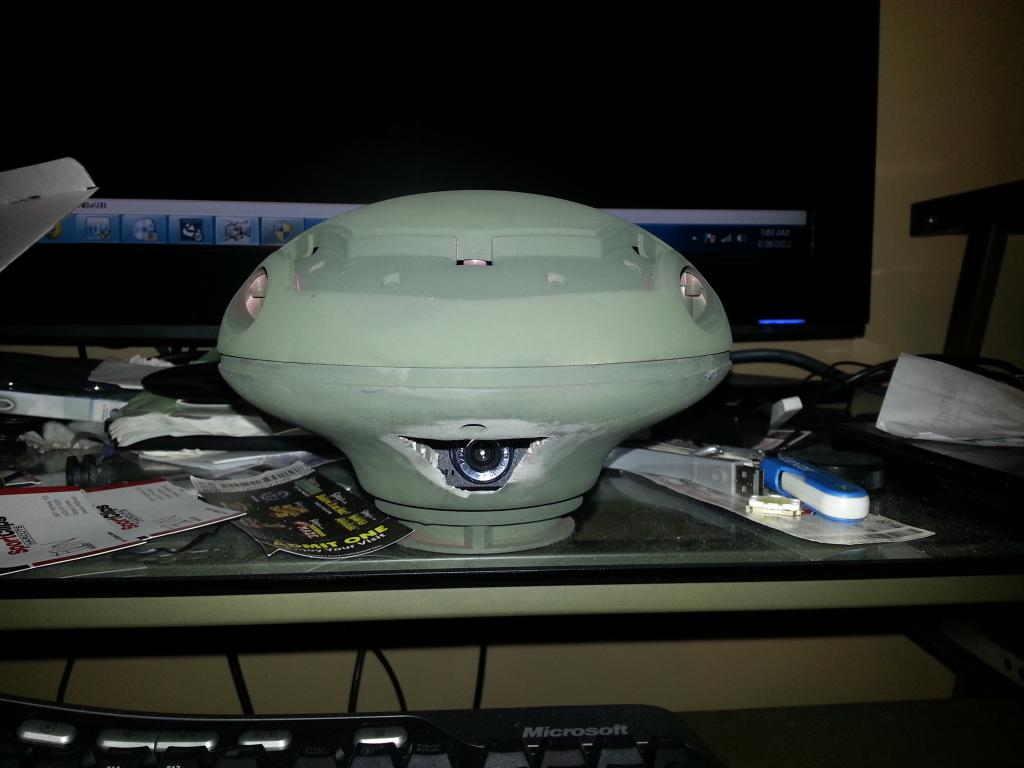

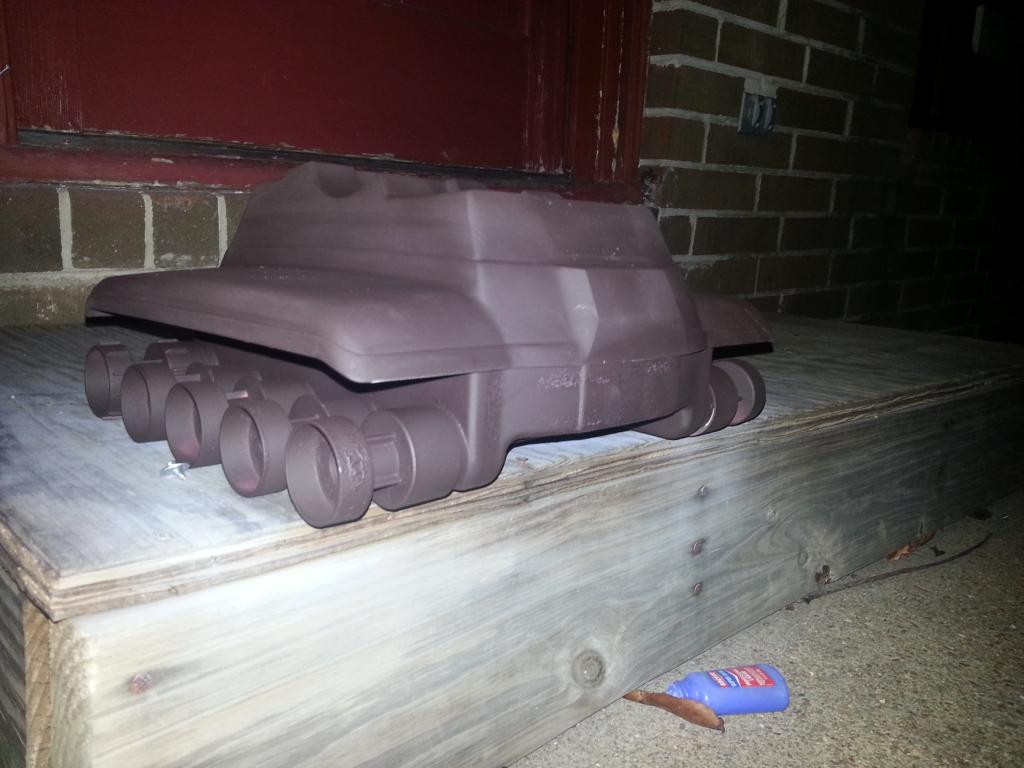
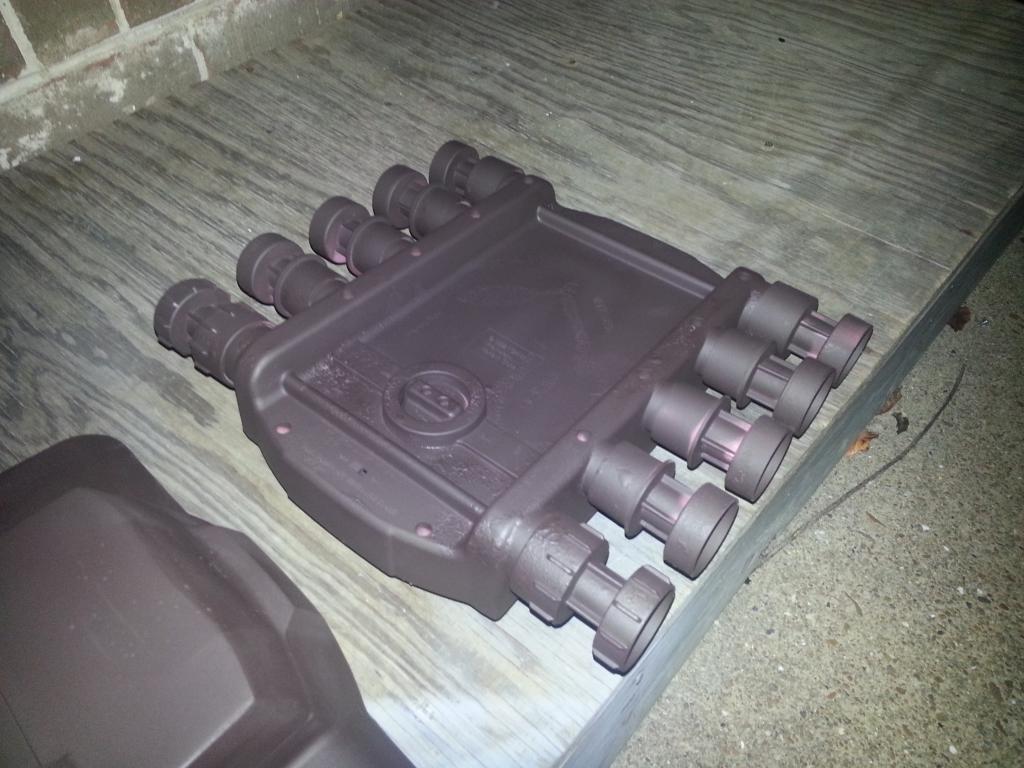
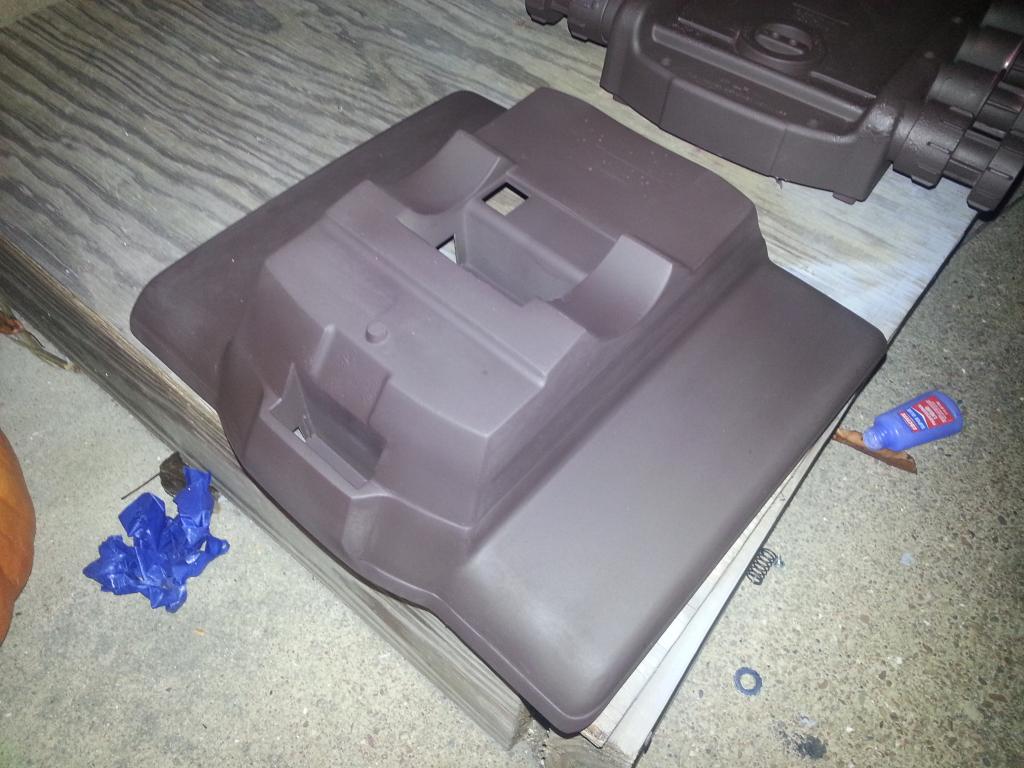
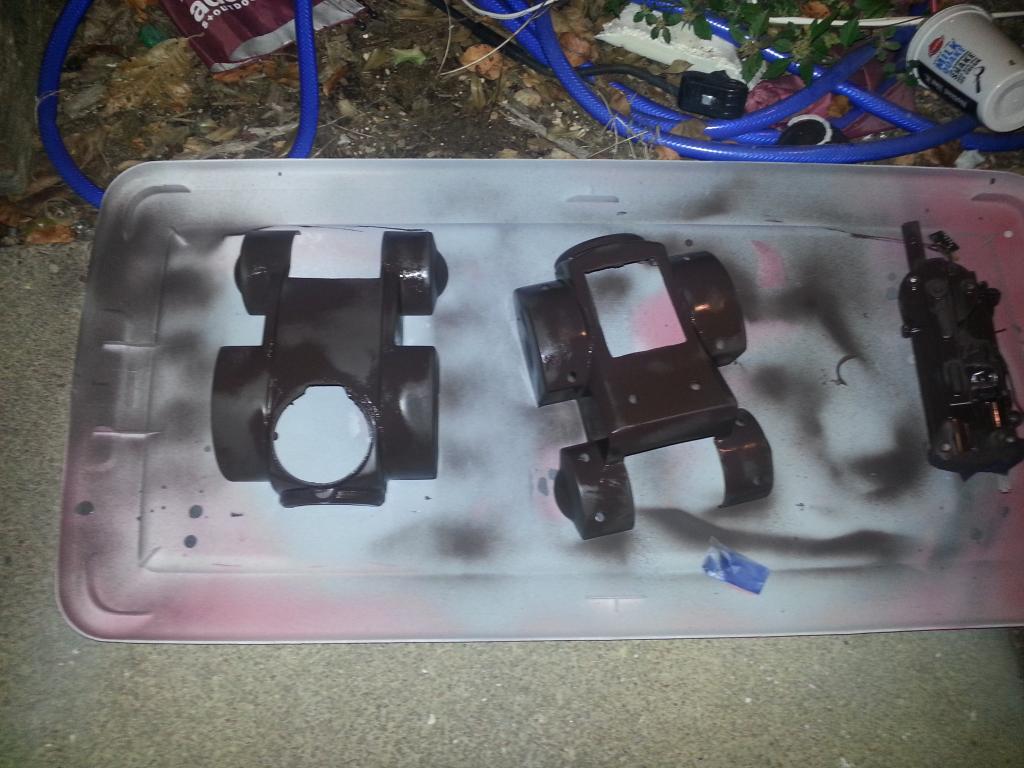
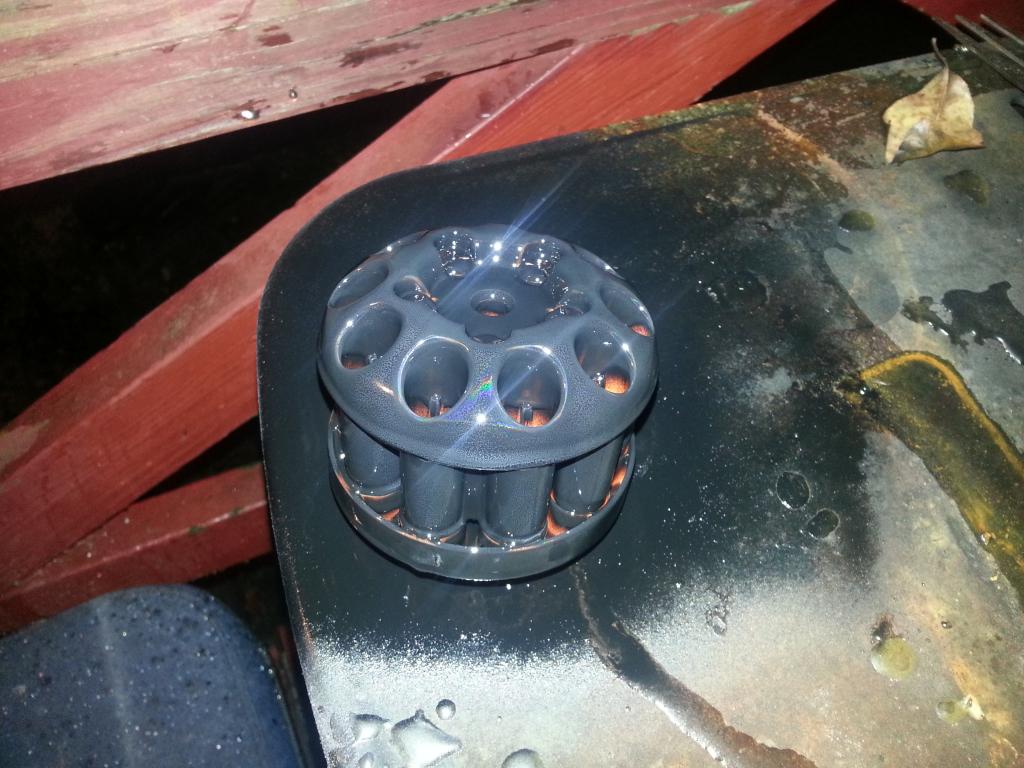
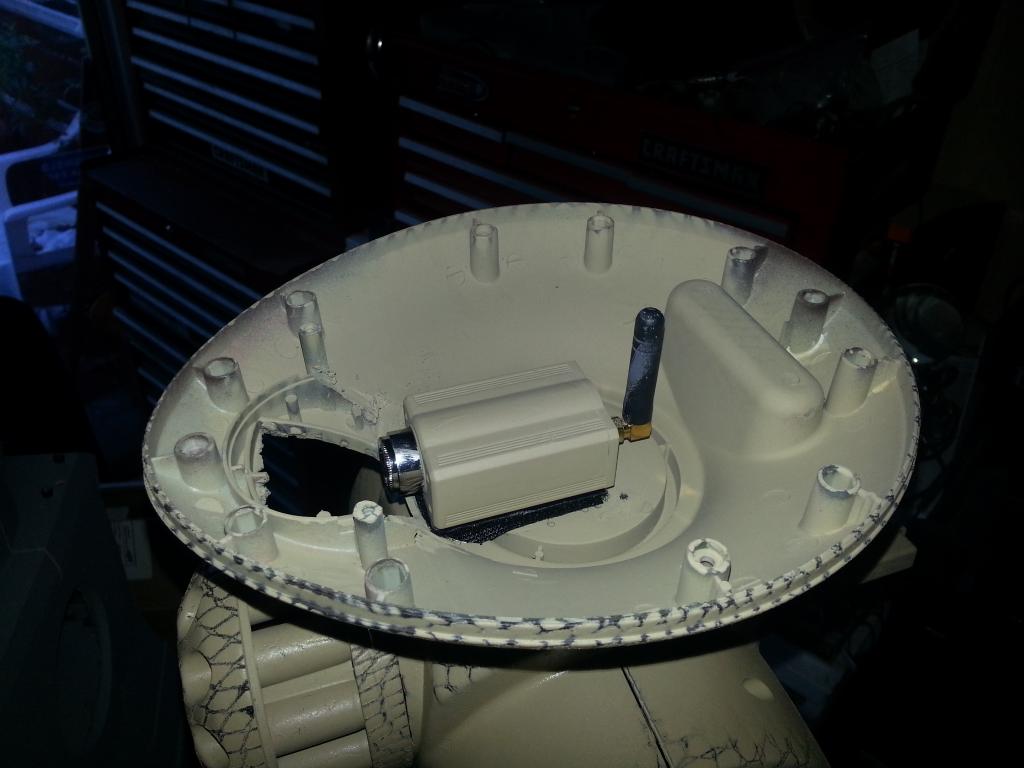

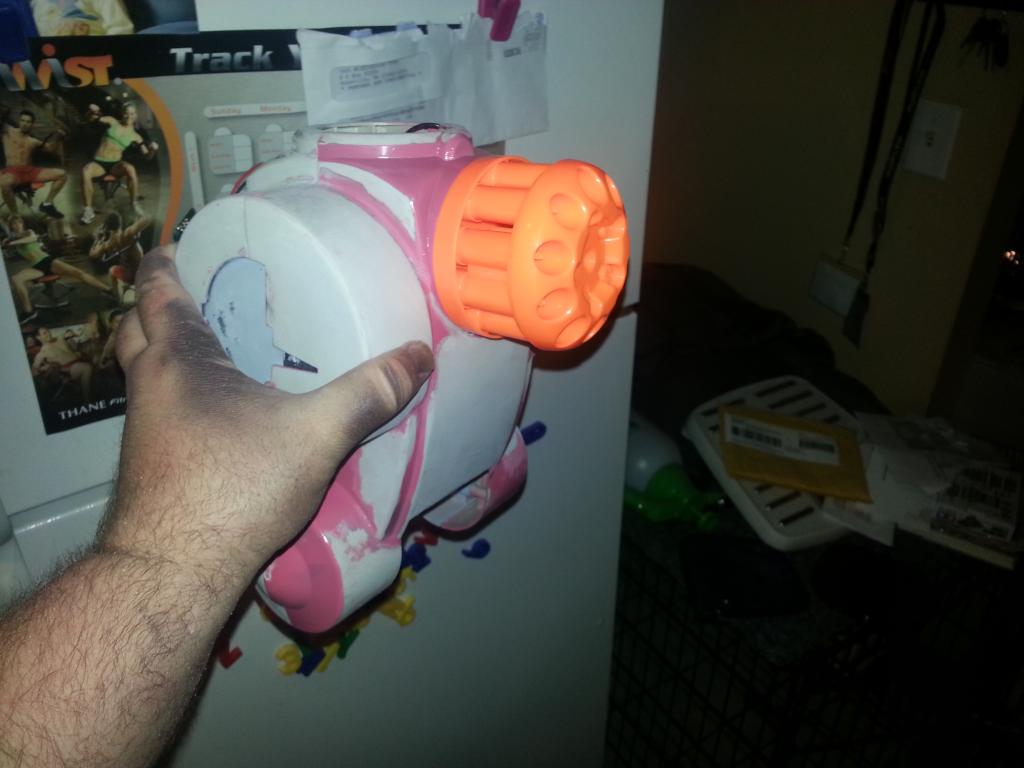
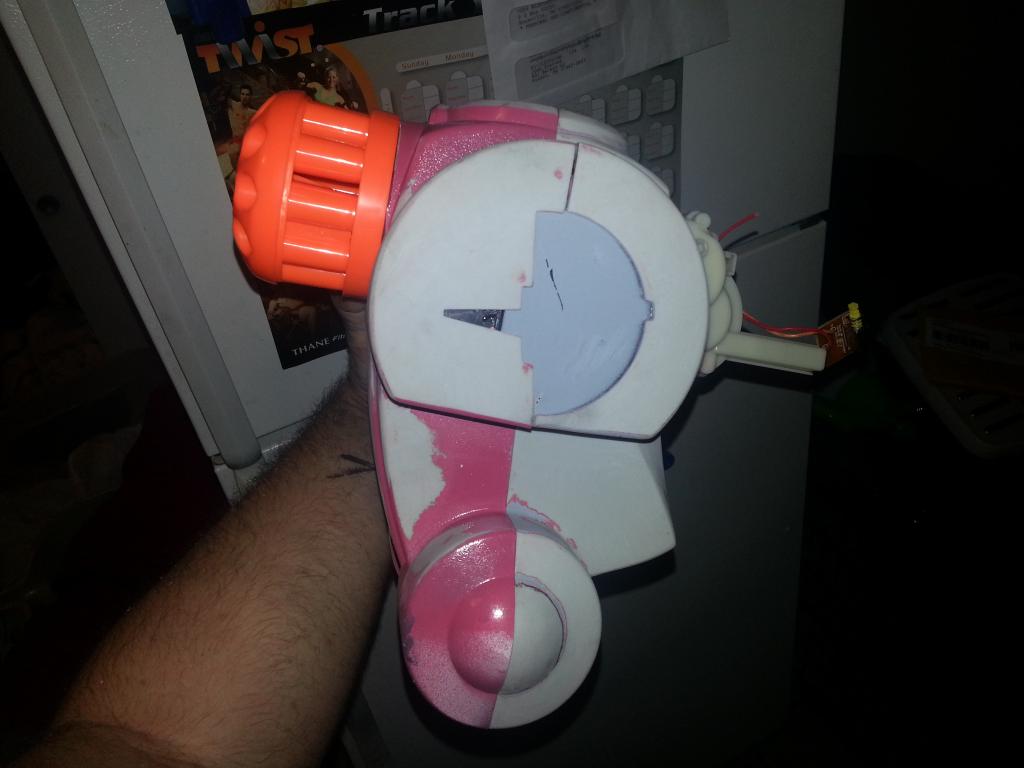

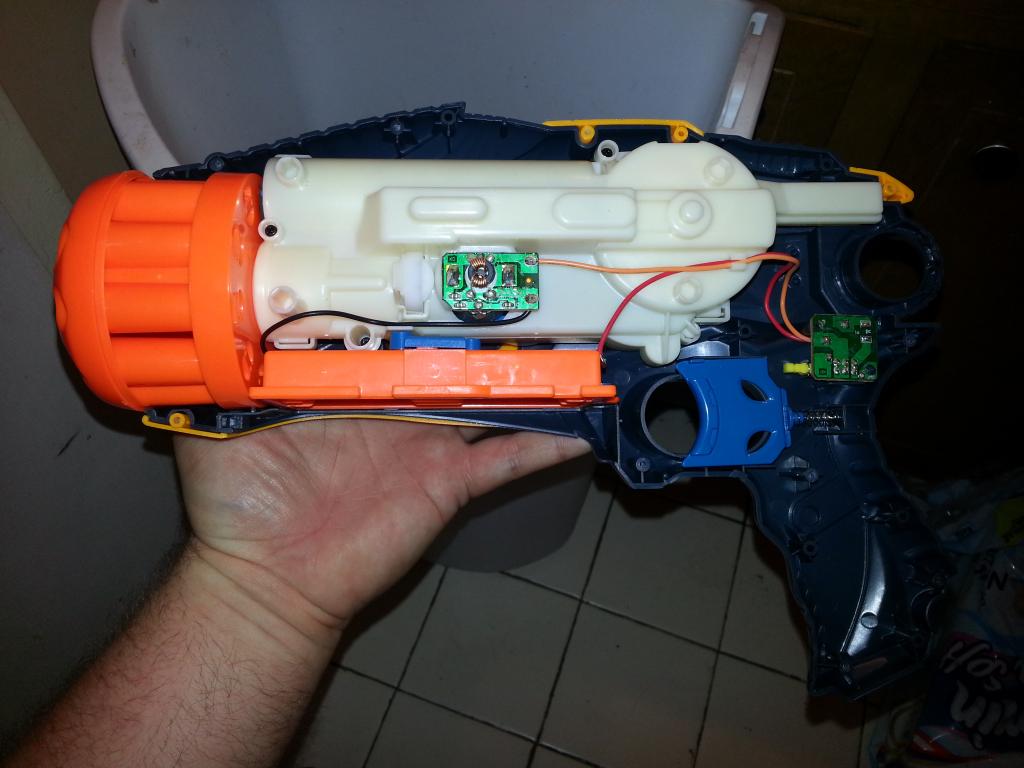
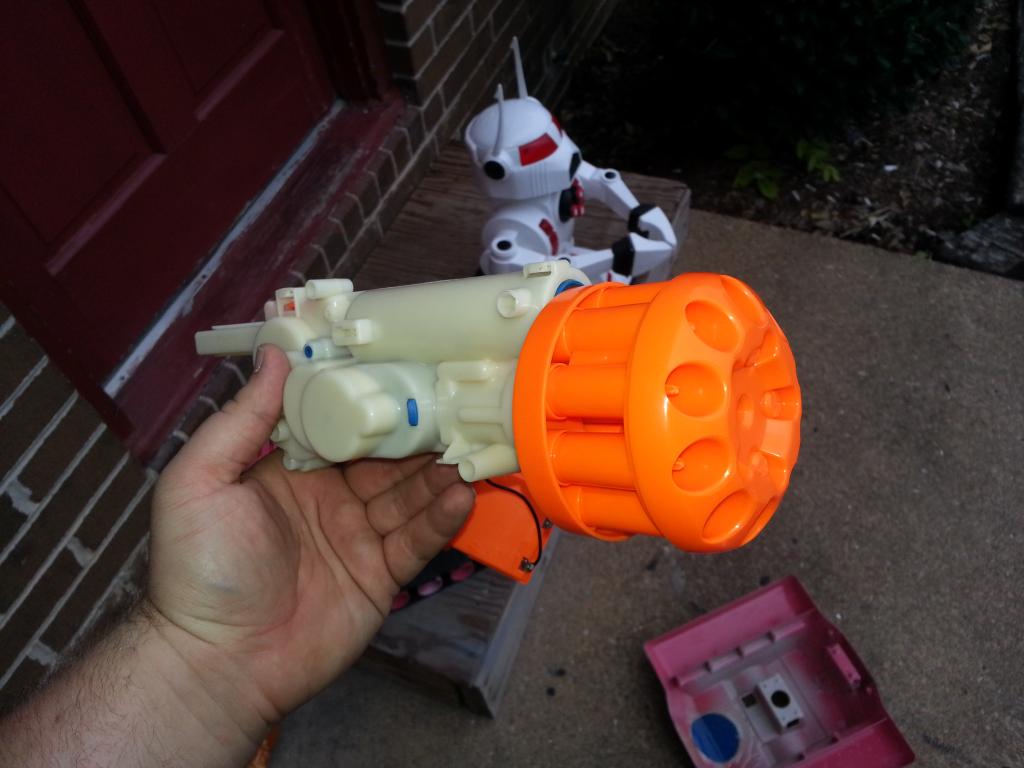

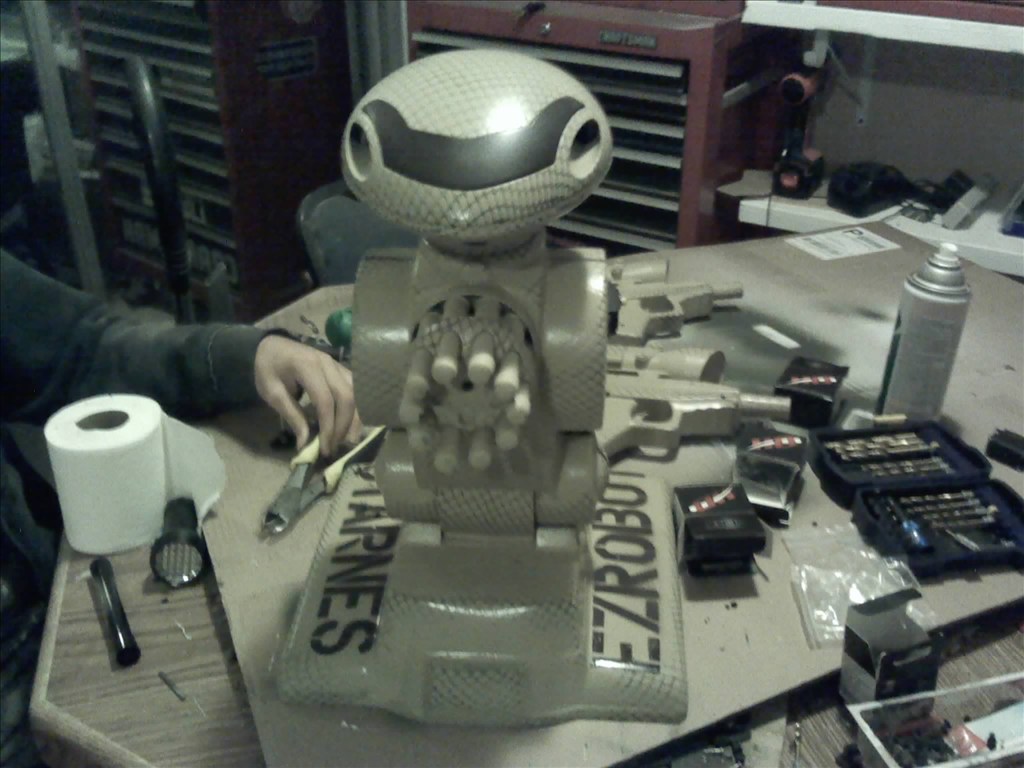

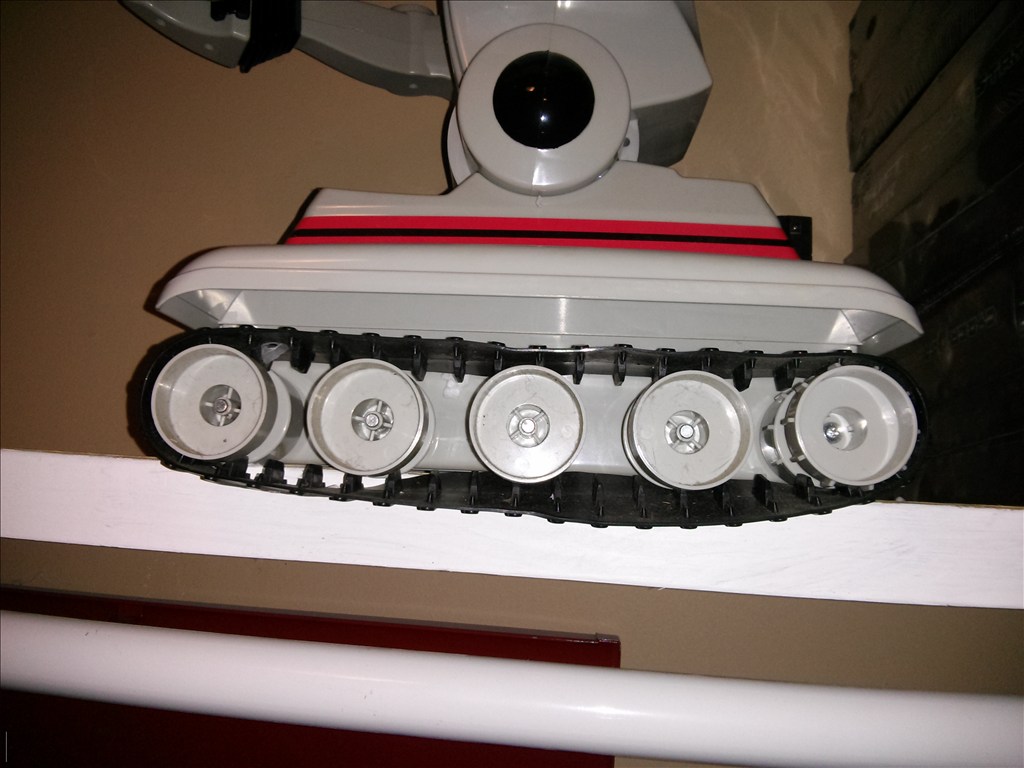
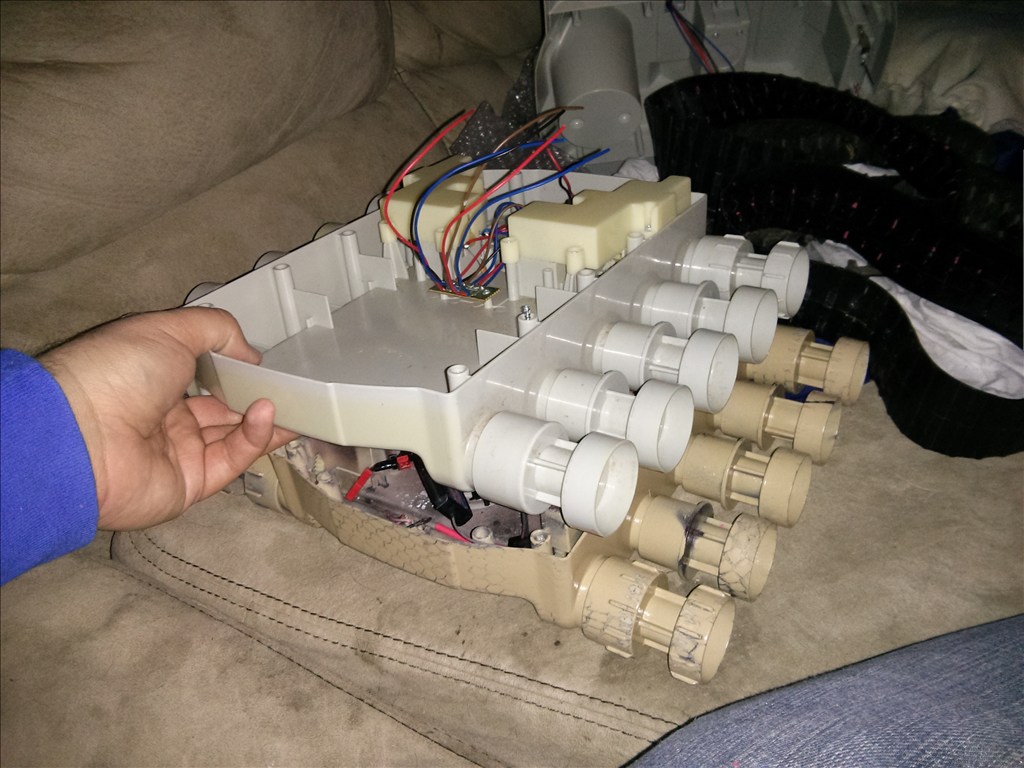
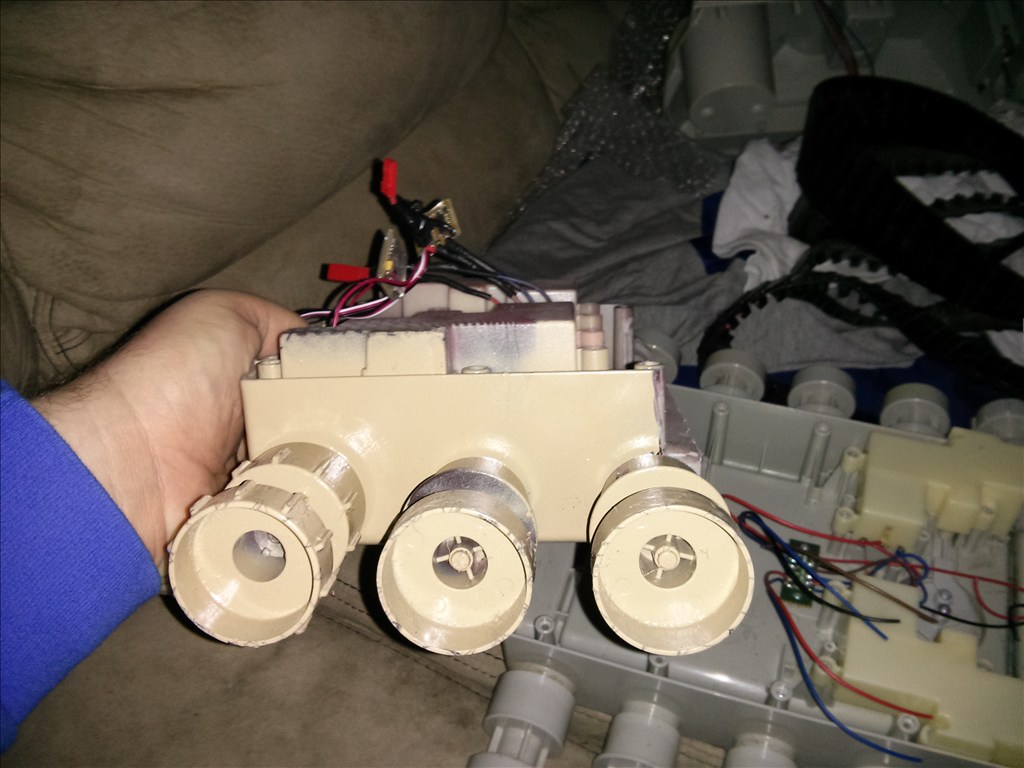




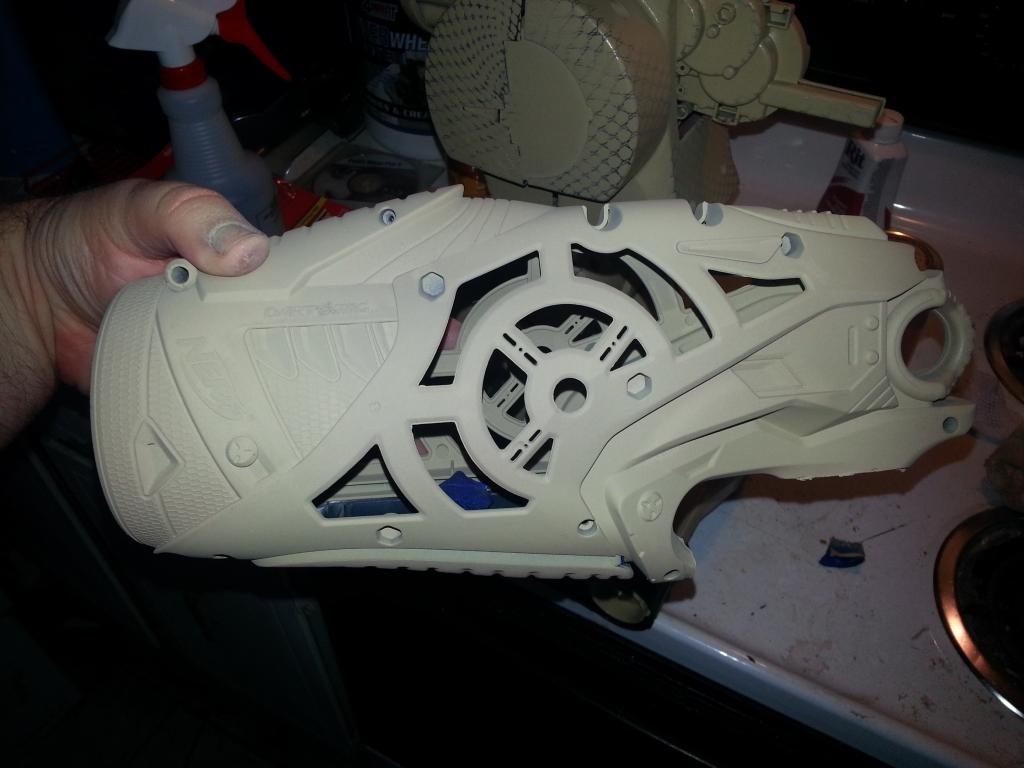
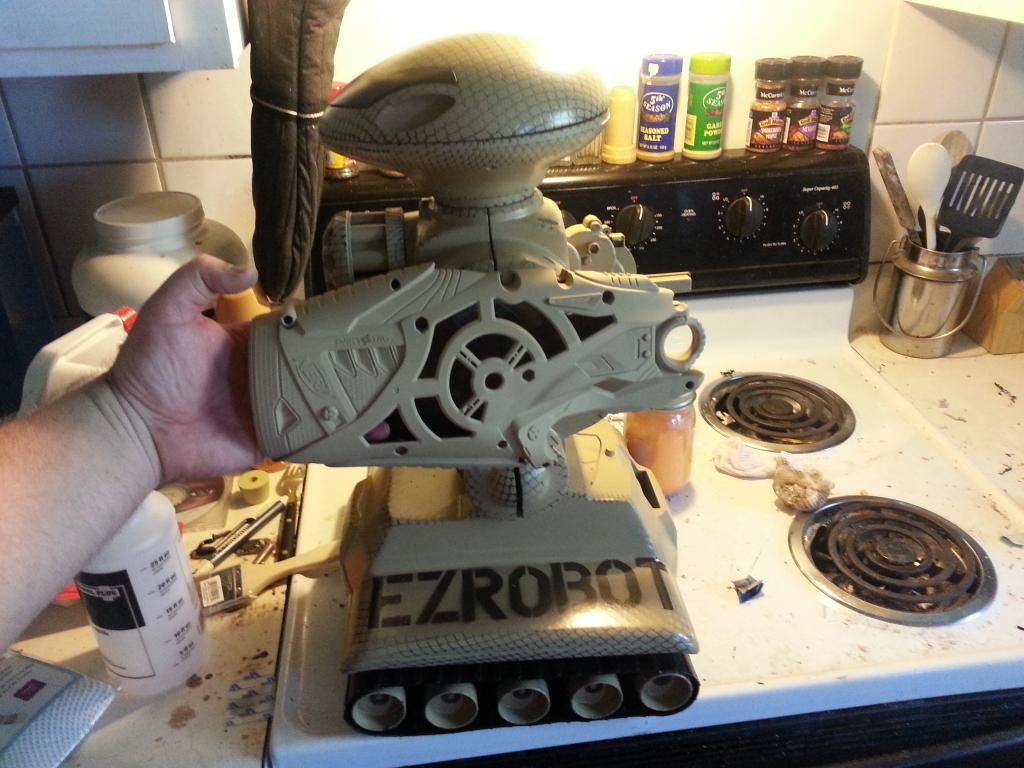



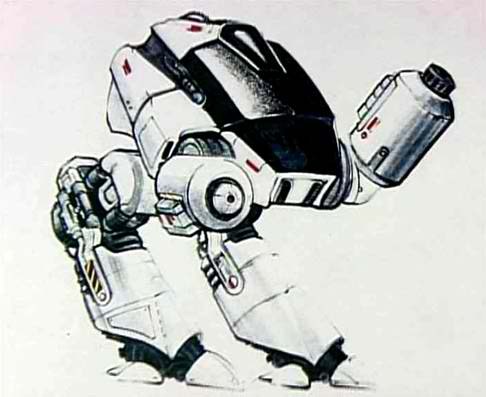


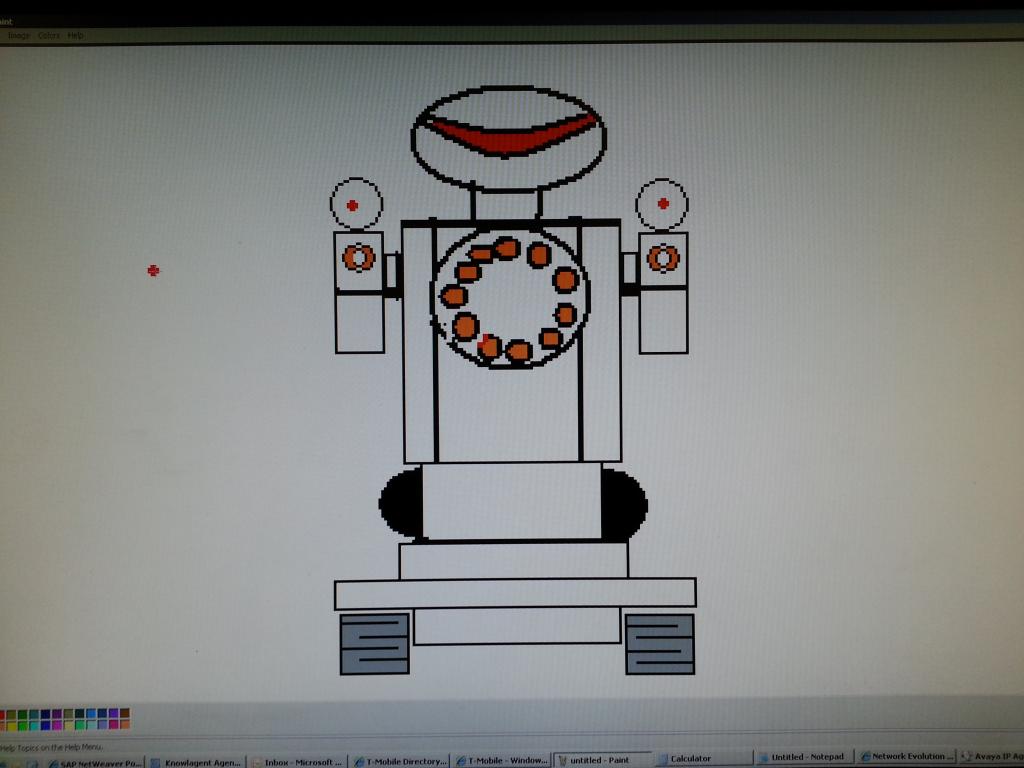

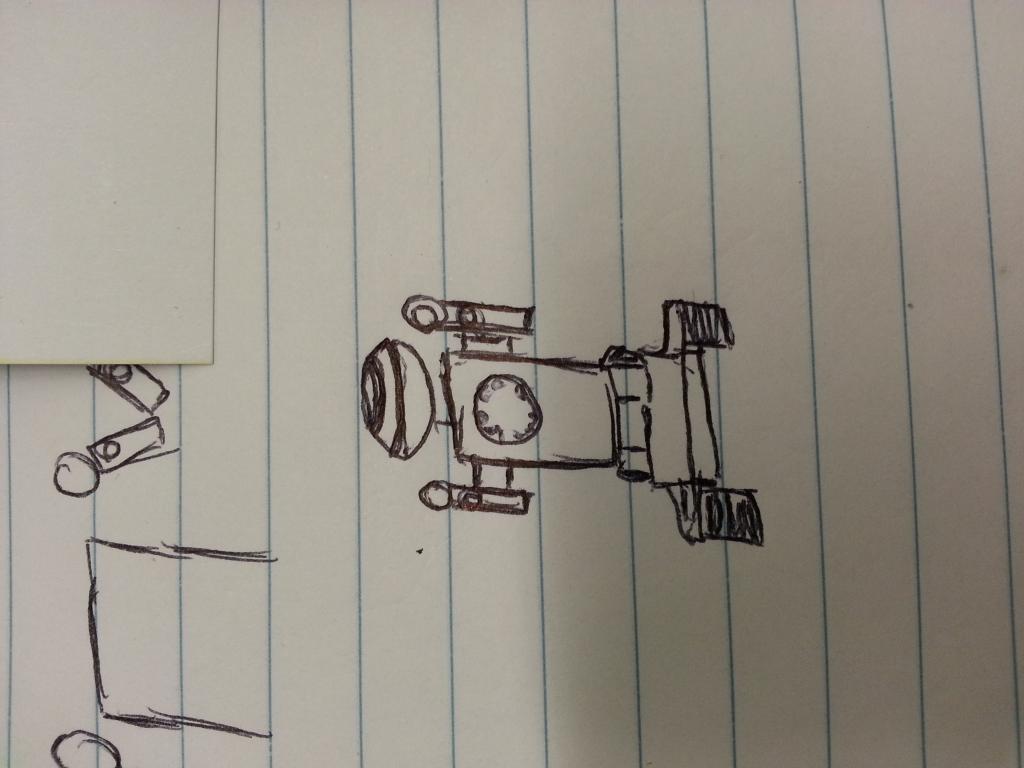
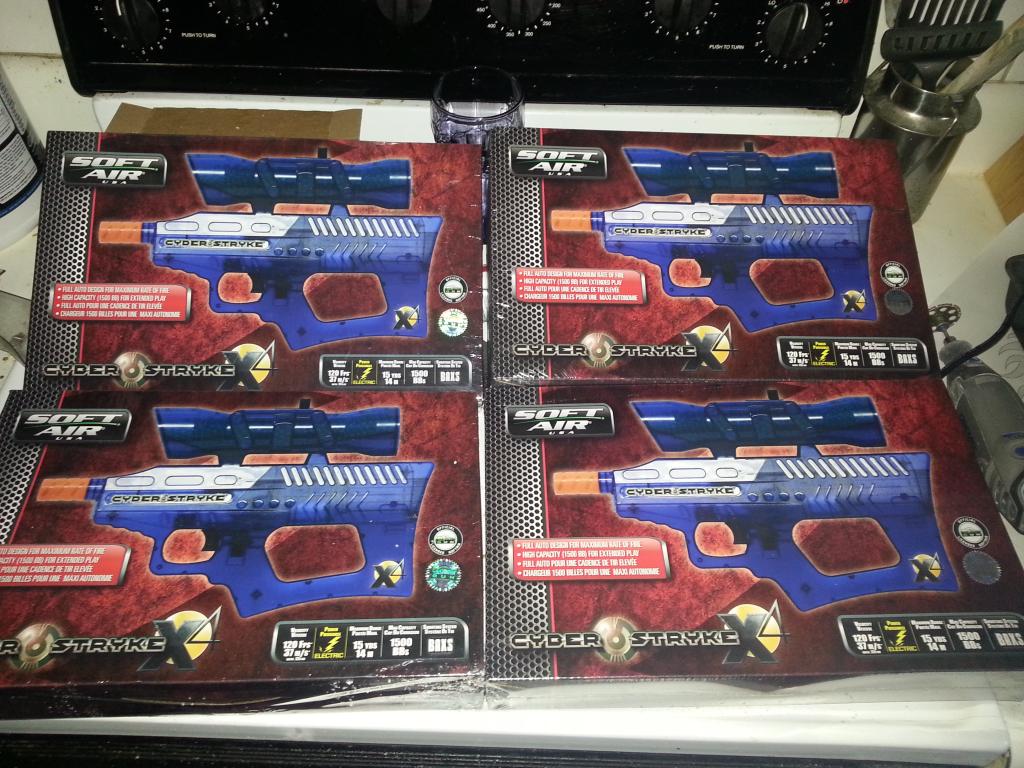
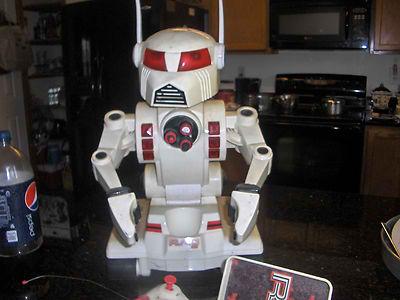


Ok this is the third of a trio of robots made to run around outside with first person view ez robot wireless cameras. Each has airsoft automatic guns and some kind of dart launcher.
By jstarne1
— Last update
Discover more robots
Cem's Eyepod Using Neopixel & Ardiuno Nano, Conrtolled Via A...
Control NeoPixel ring via Arduino Nano and EZ-B IoTiny, script servo motion for Perry's 3D eyepod; troubleshooting iris...
Recon's Development Of Autonomous Navigation Robot
Autonomous navigation robot on Roli Rover using EZ-Builder and RoboRealm, demoed as a final-year project; tutorial...
Rb550f's Ez Robot Rover V2
EZ-Robot rover CP uses Sharper Image EVAC drivetrain with EZB V3, Chumby touchscreen, fan-cooled electronics, micro and...

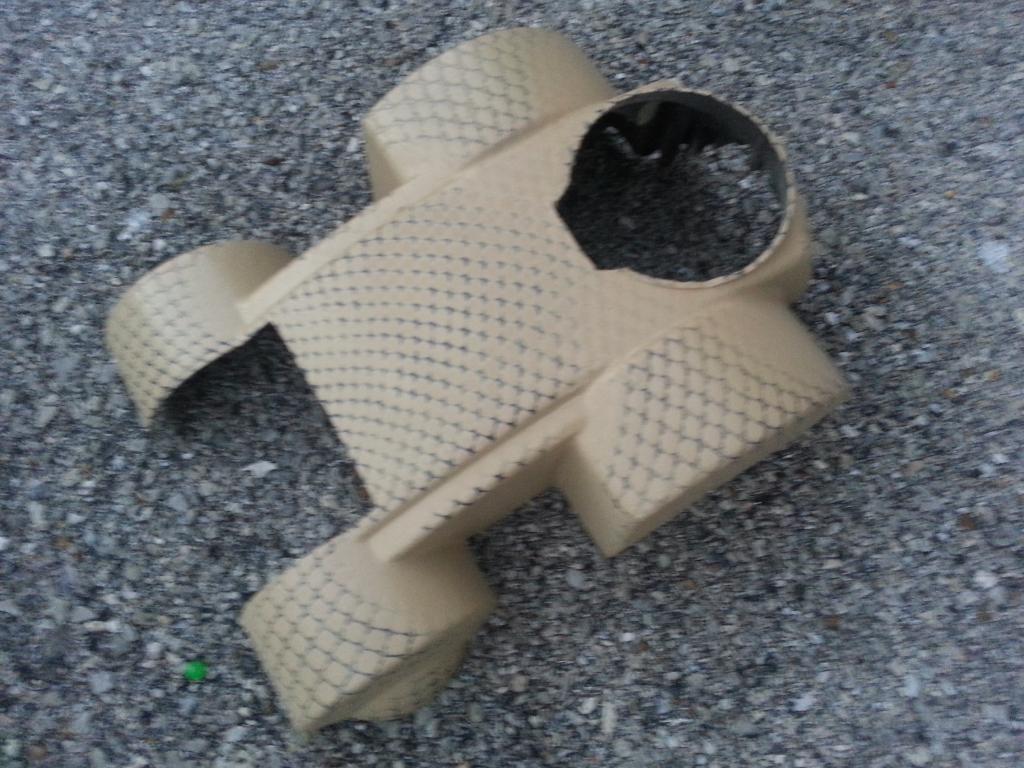
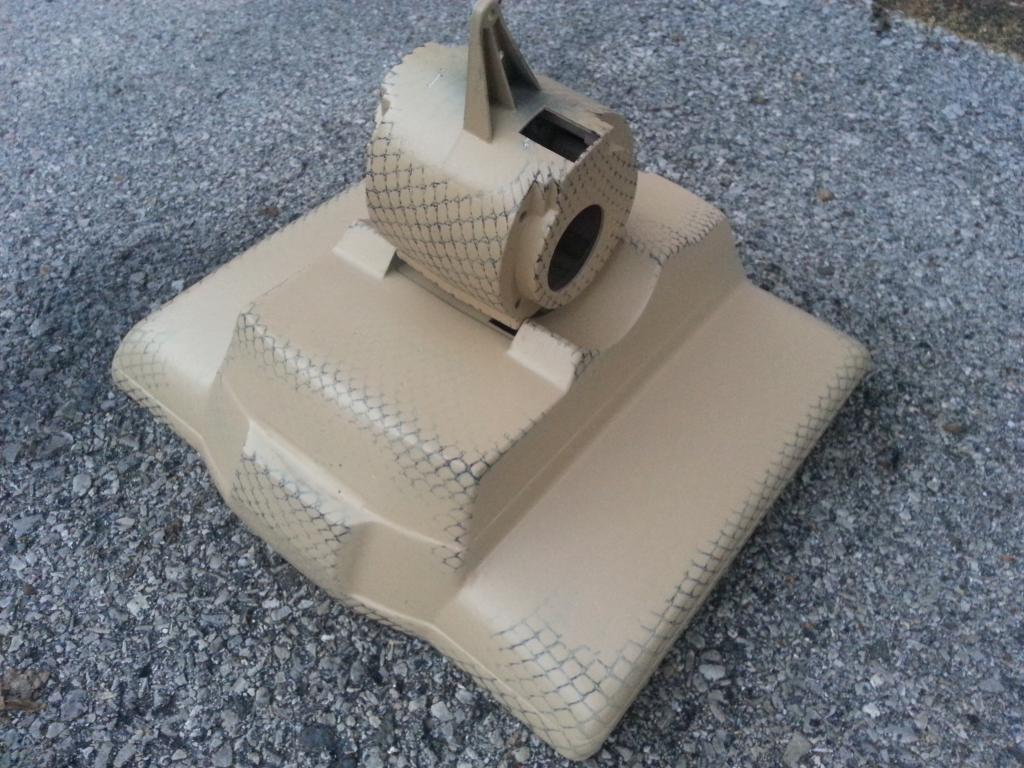
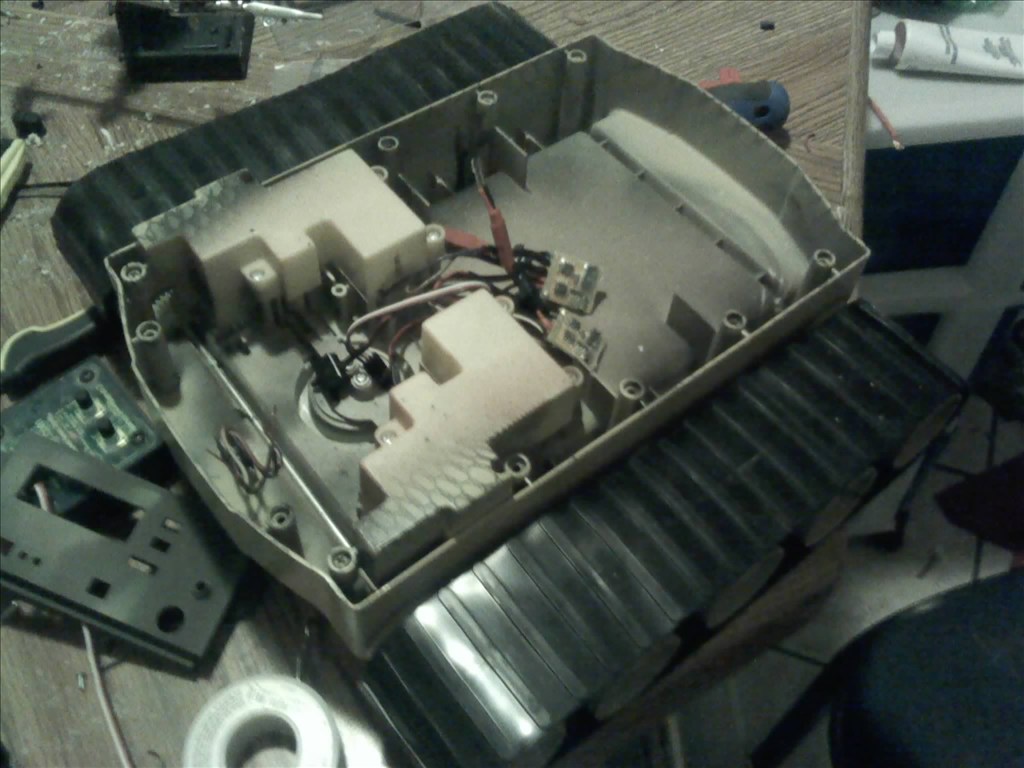
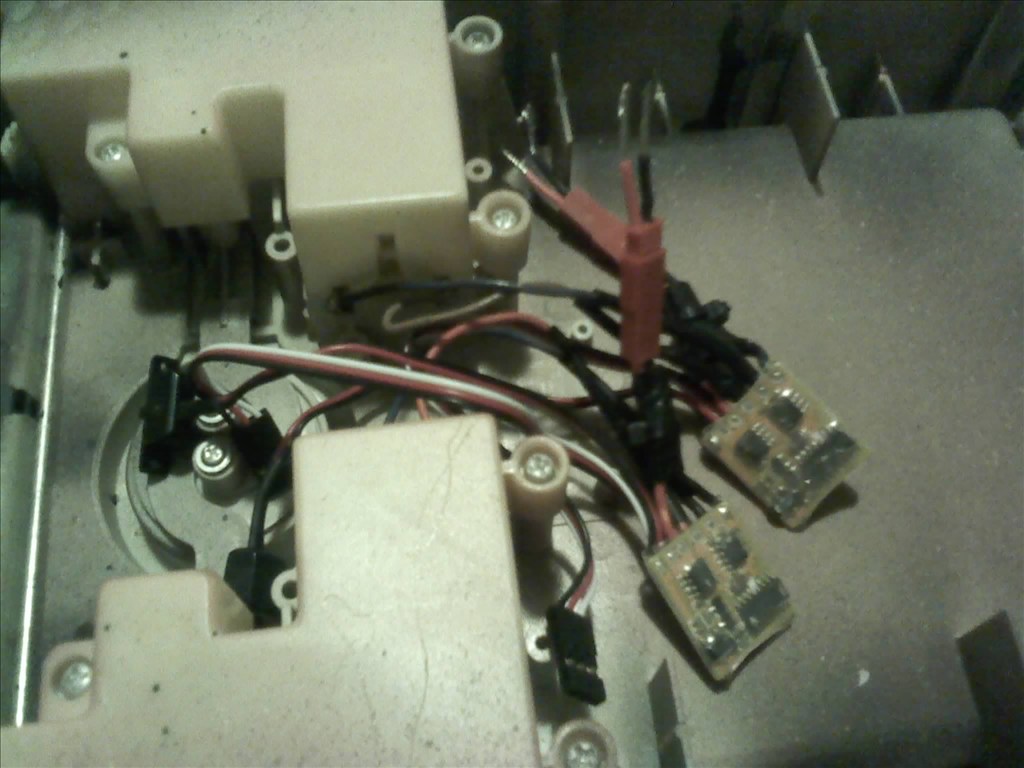
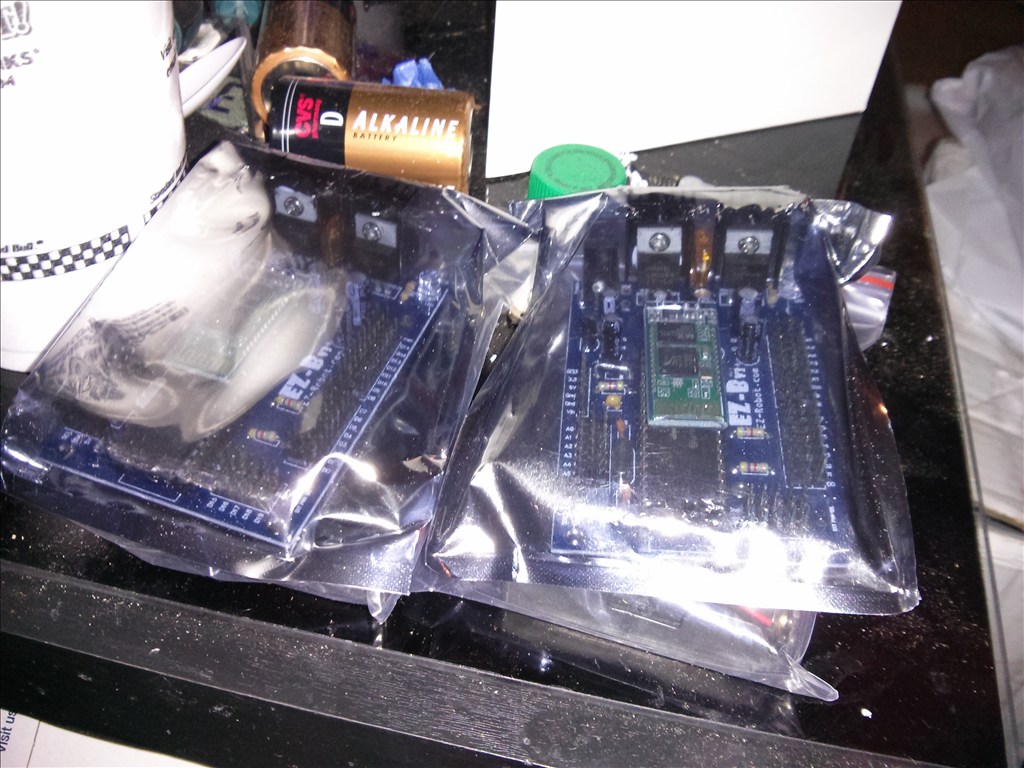
Alright for this project I will need two h bridges. I planned to use the l298n h bridge. One is going to run the tracks and other will drive the nerf cannon and machine guns. I think I need to order a few of them because one I need to use for dusty anyways. So I need three l298n controllers. I picked up more brown paint tonight so I can paint the torso and the guns as well. Im note sure if I will have time to do the next step.... the snake skin but we will see.
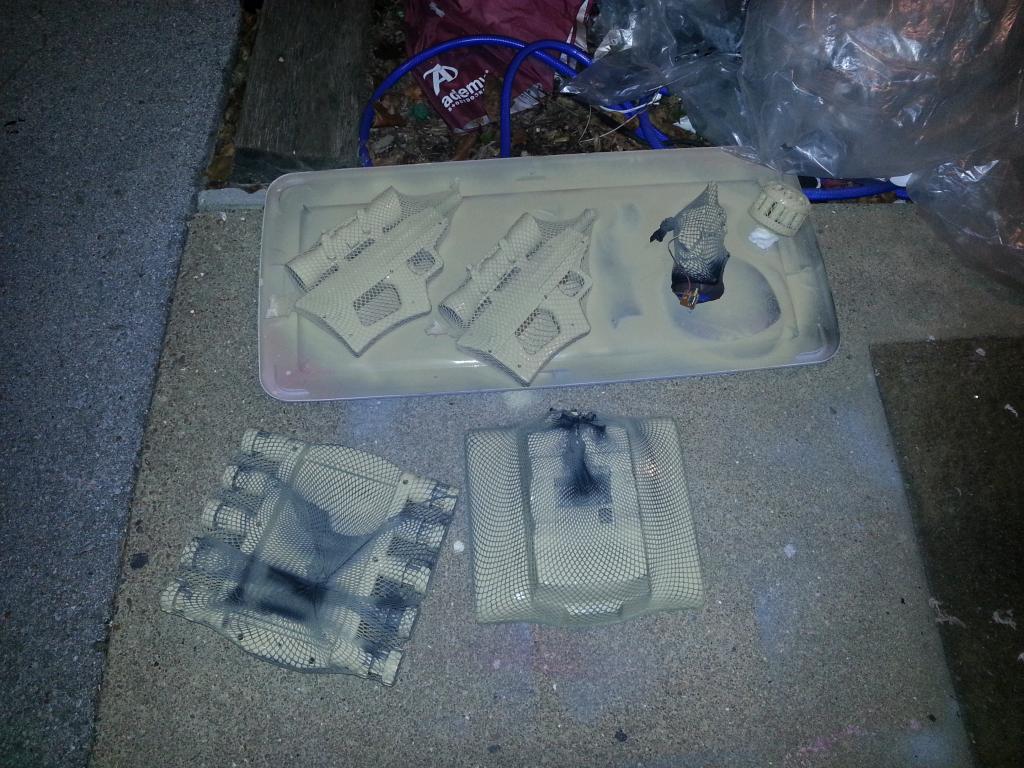
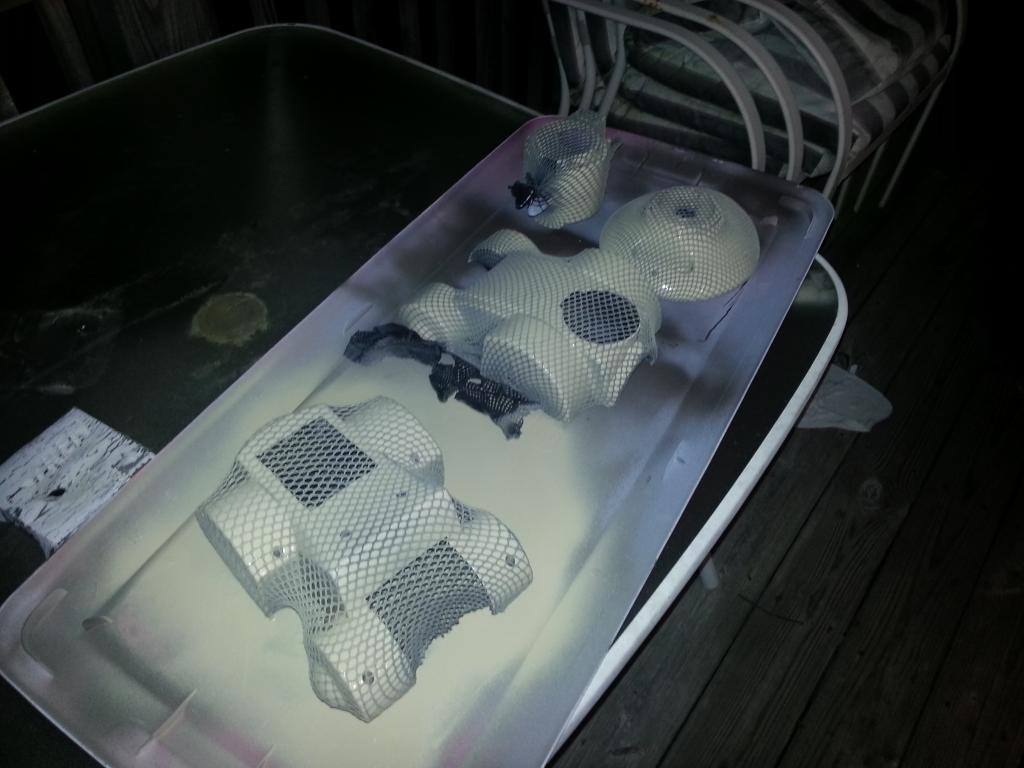
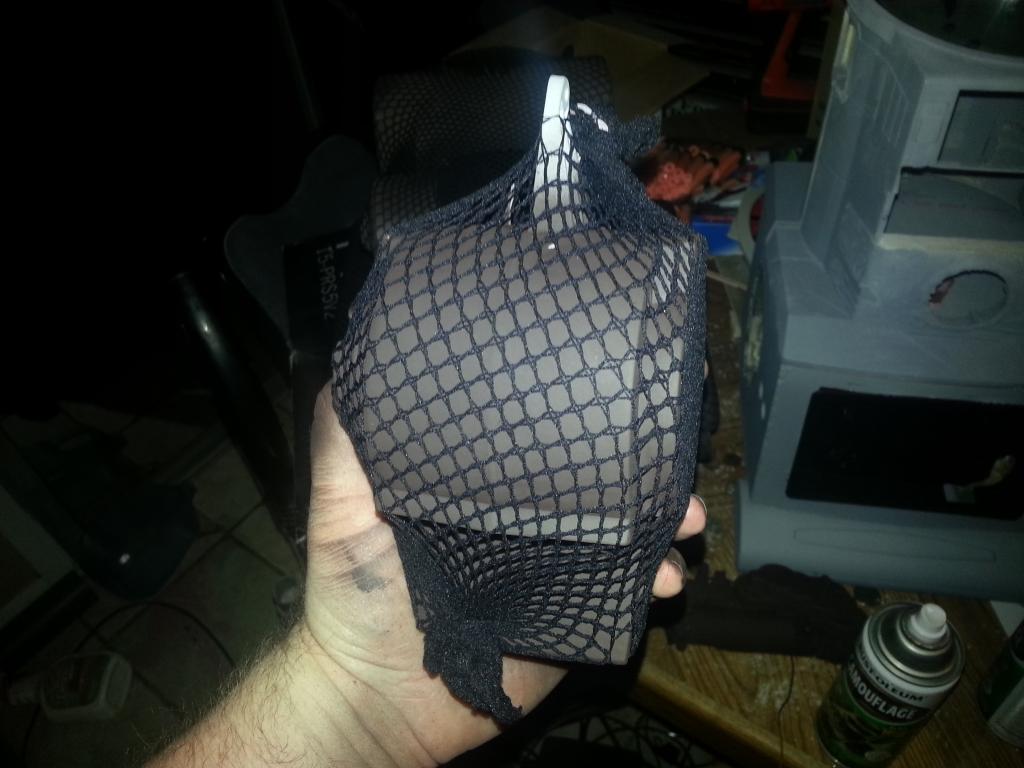
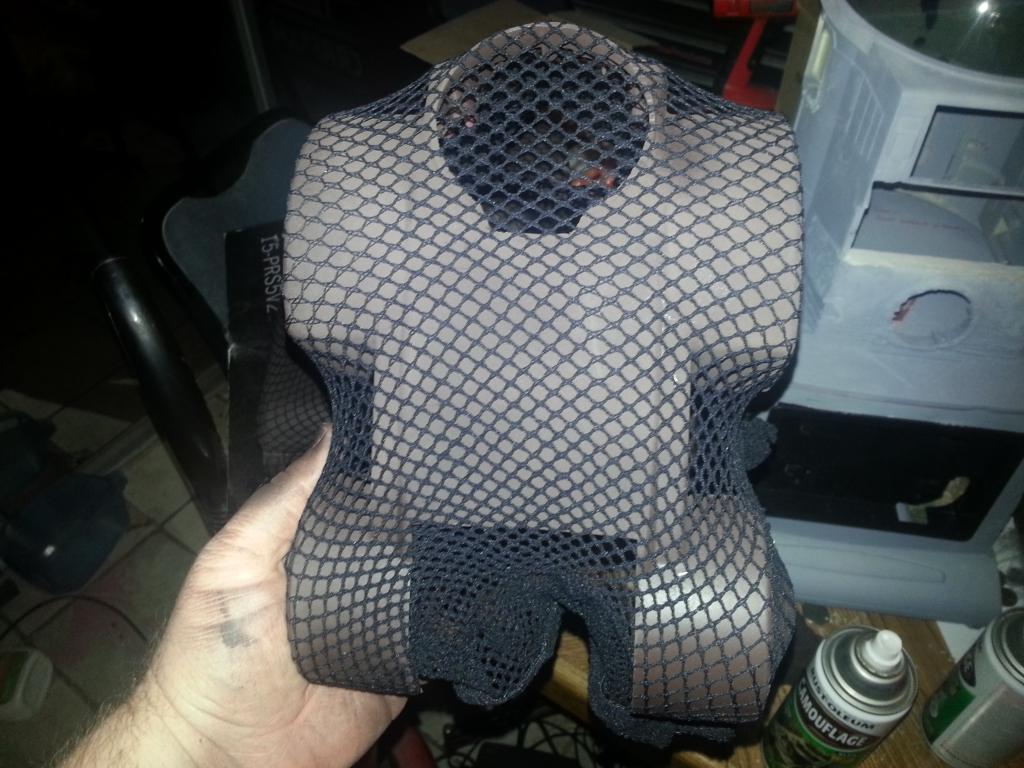
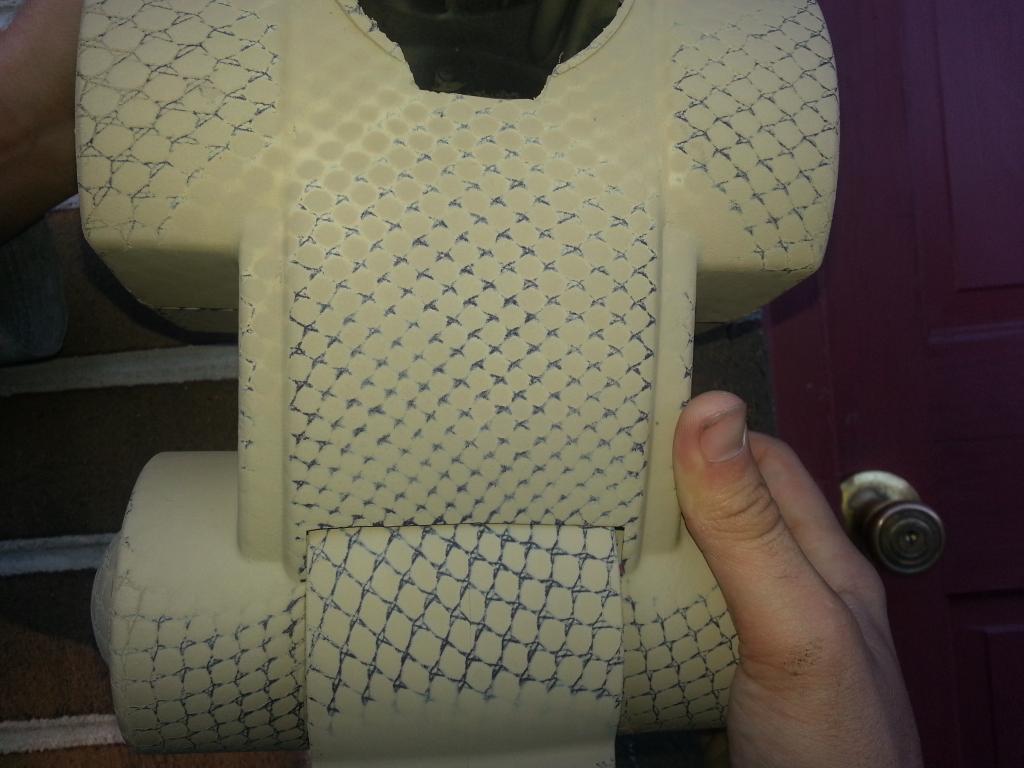
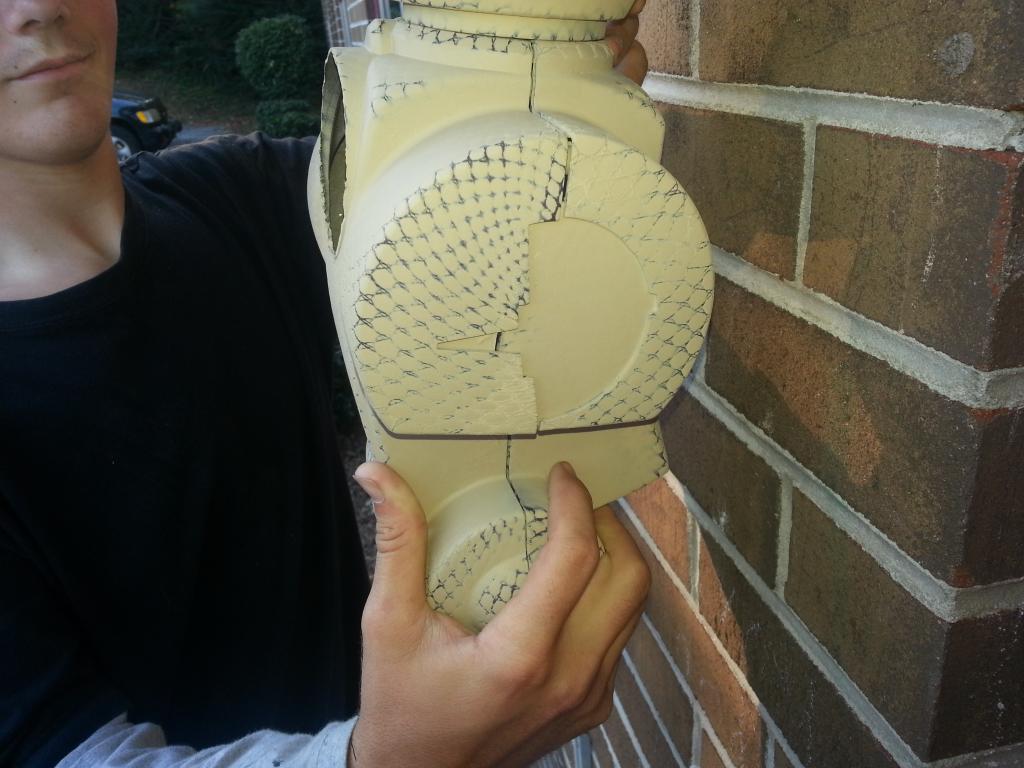
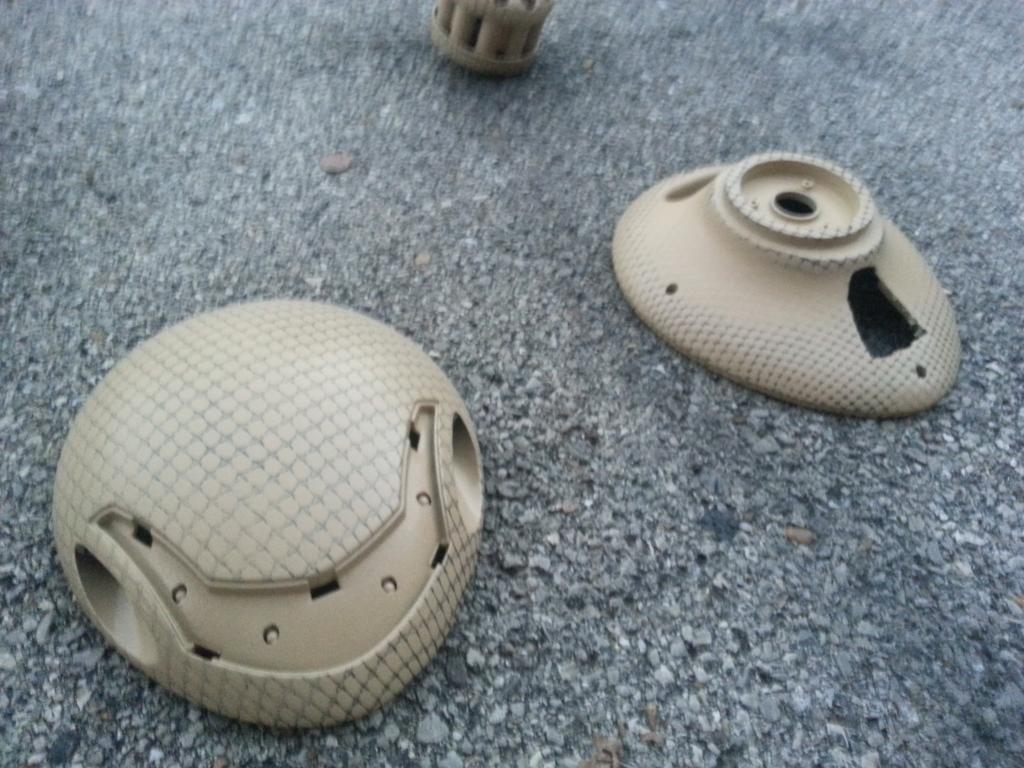
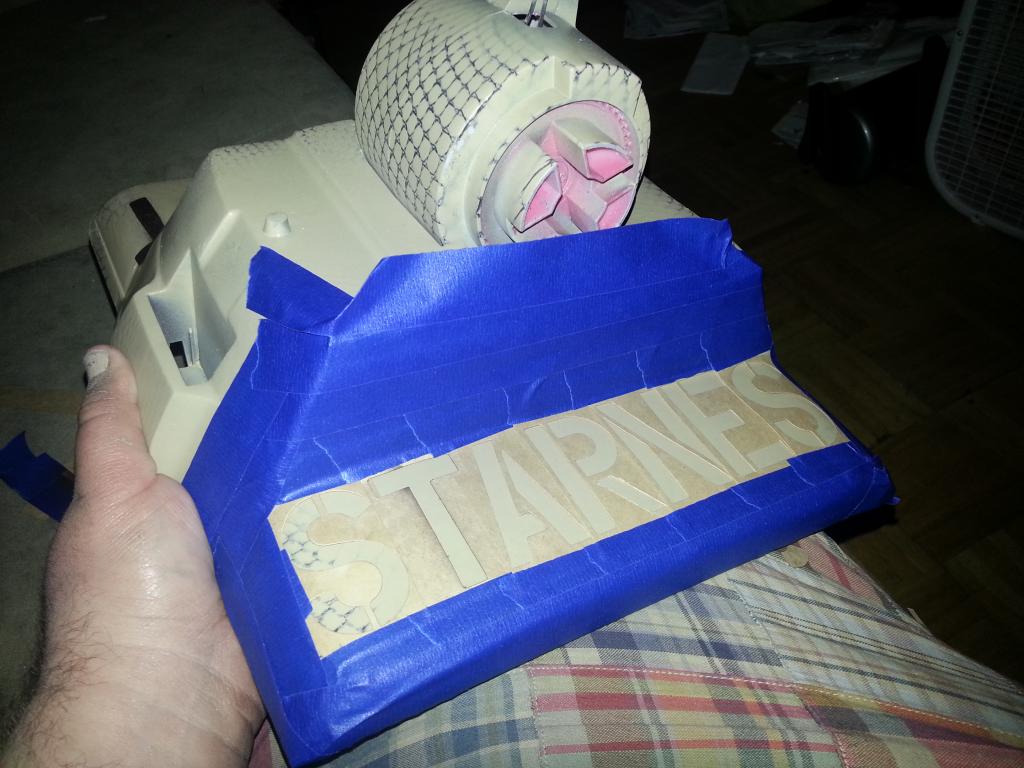
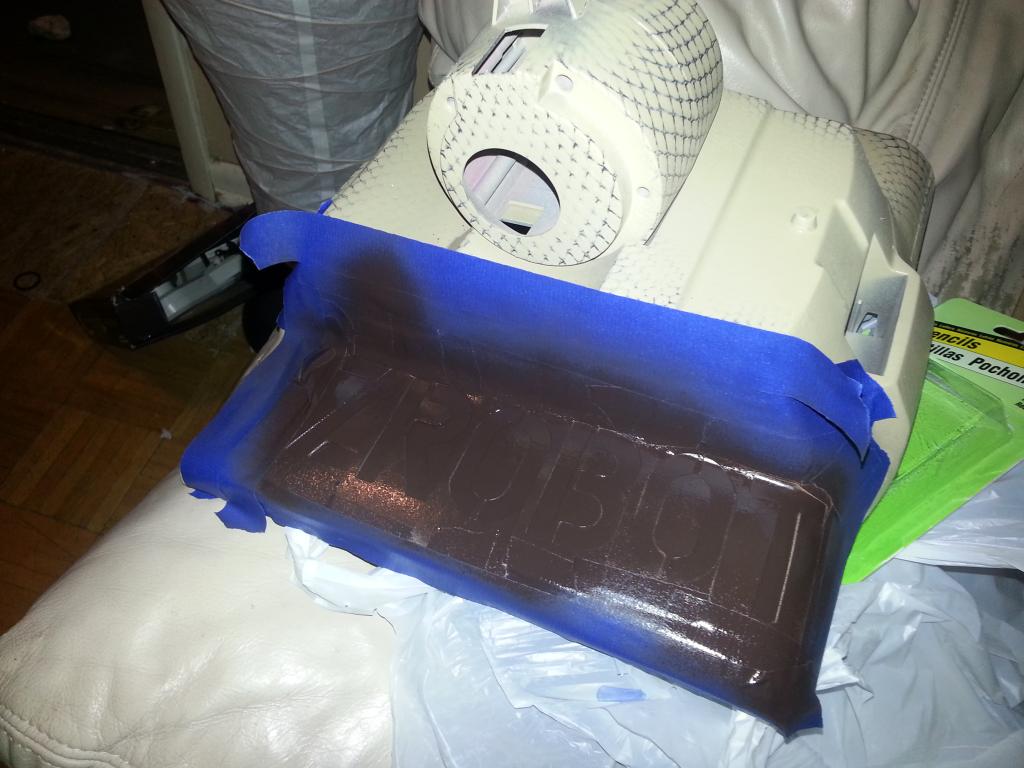
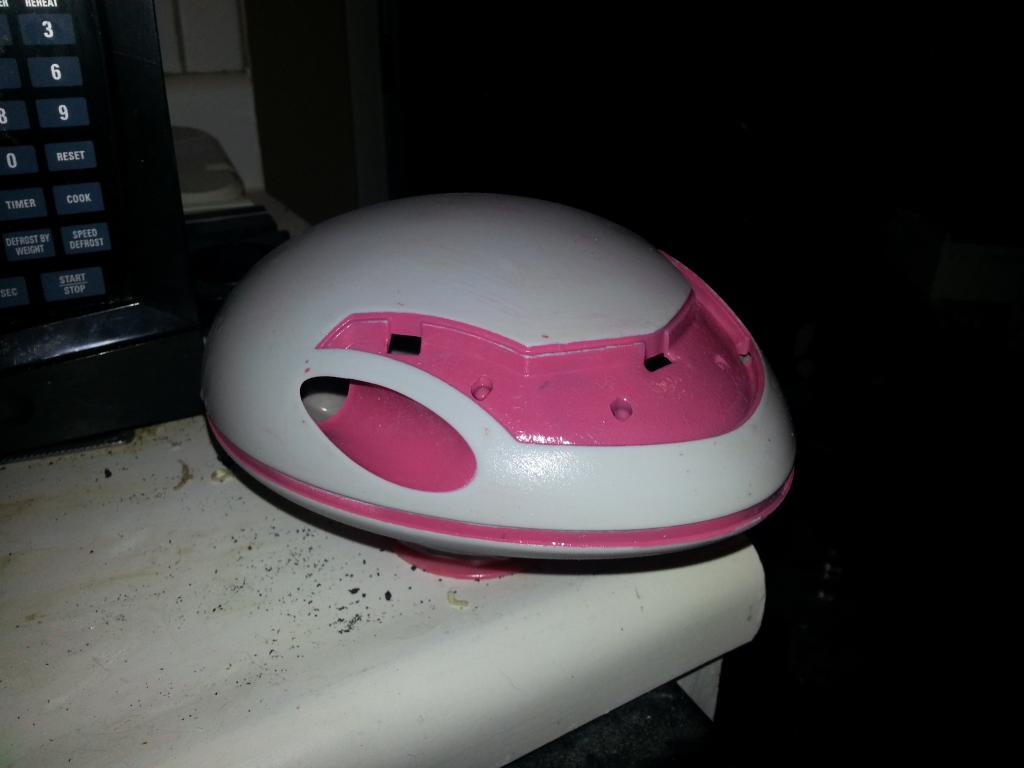
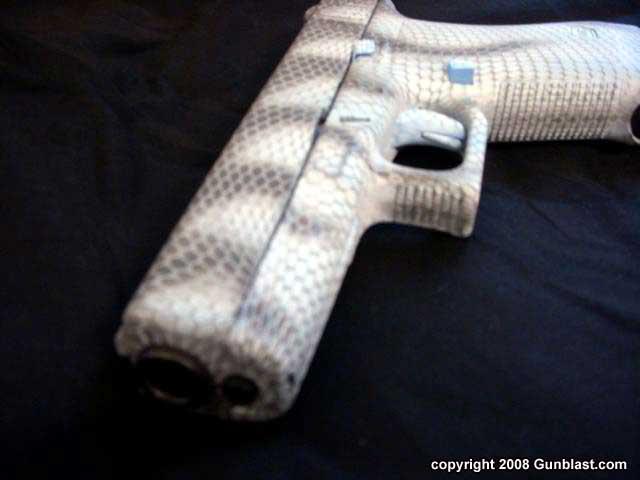
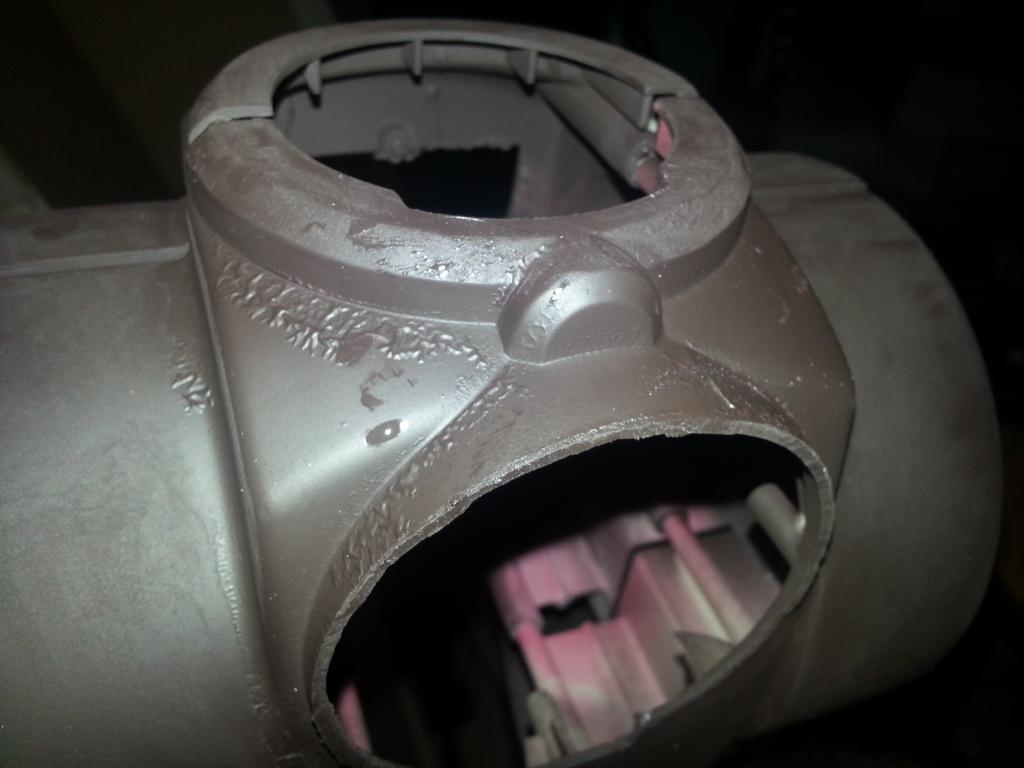
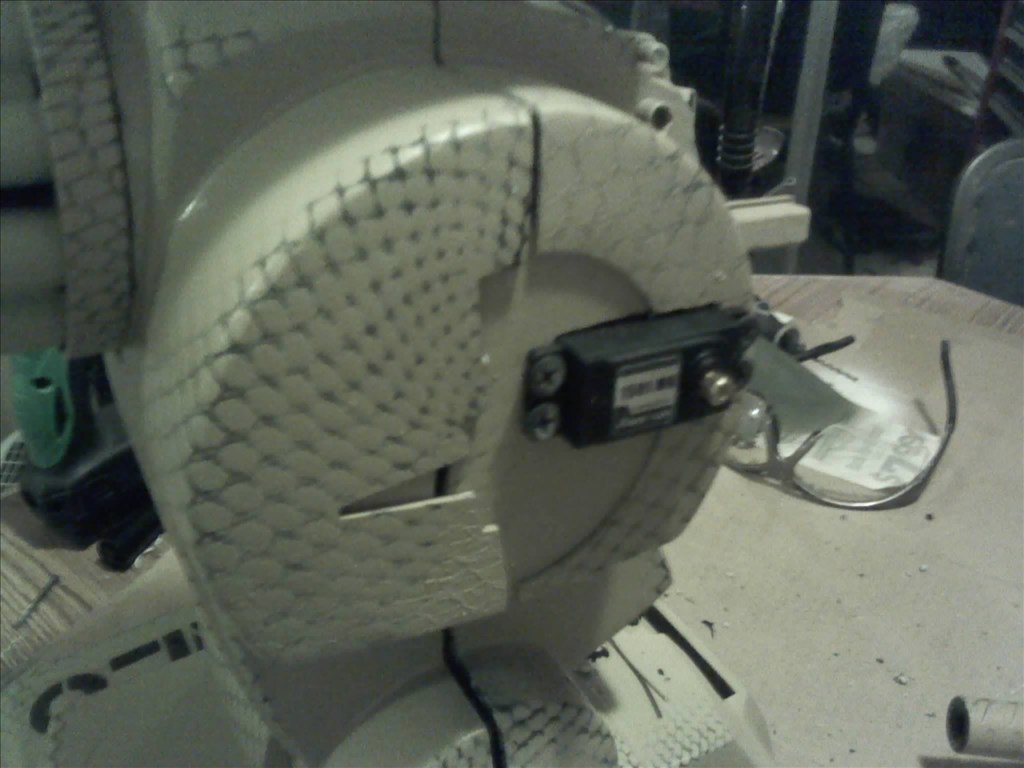
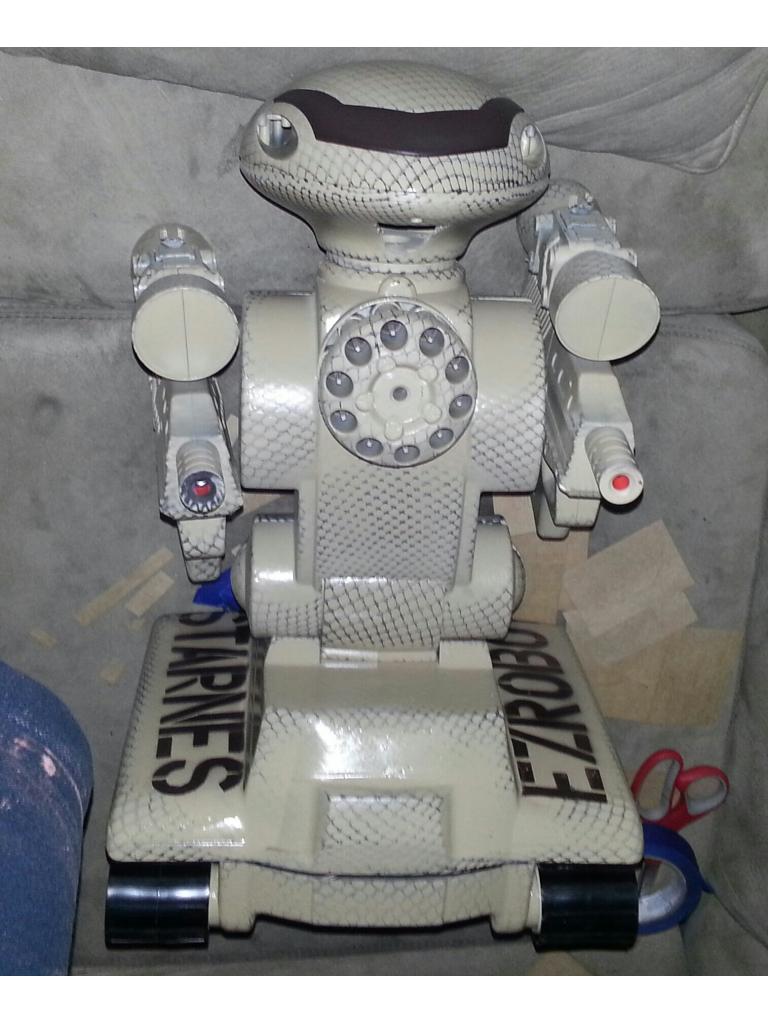
Alright here we go! Im attempting the snake skin pattern on the head. Im letting it dry overnight and well see the results
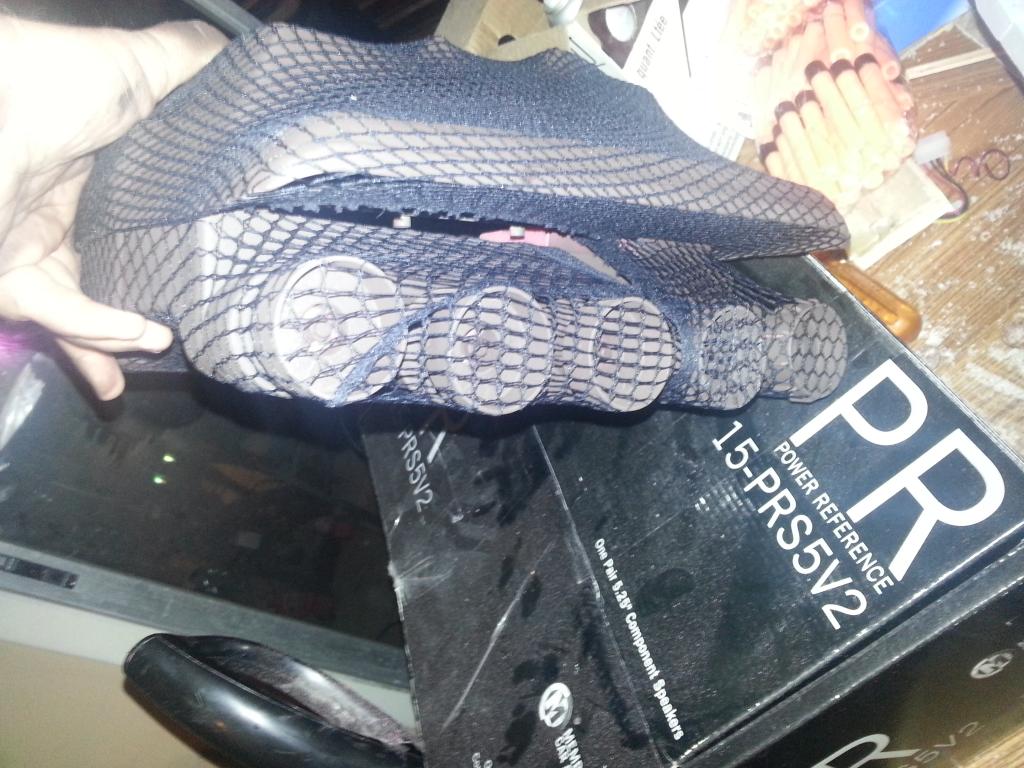
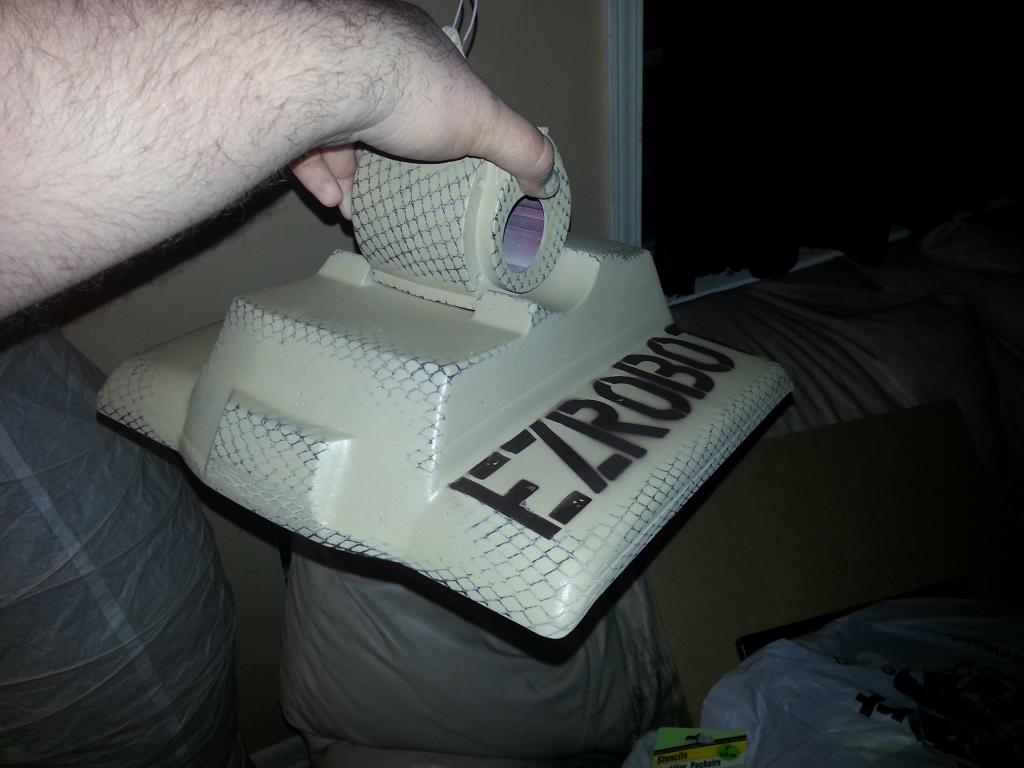
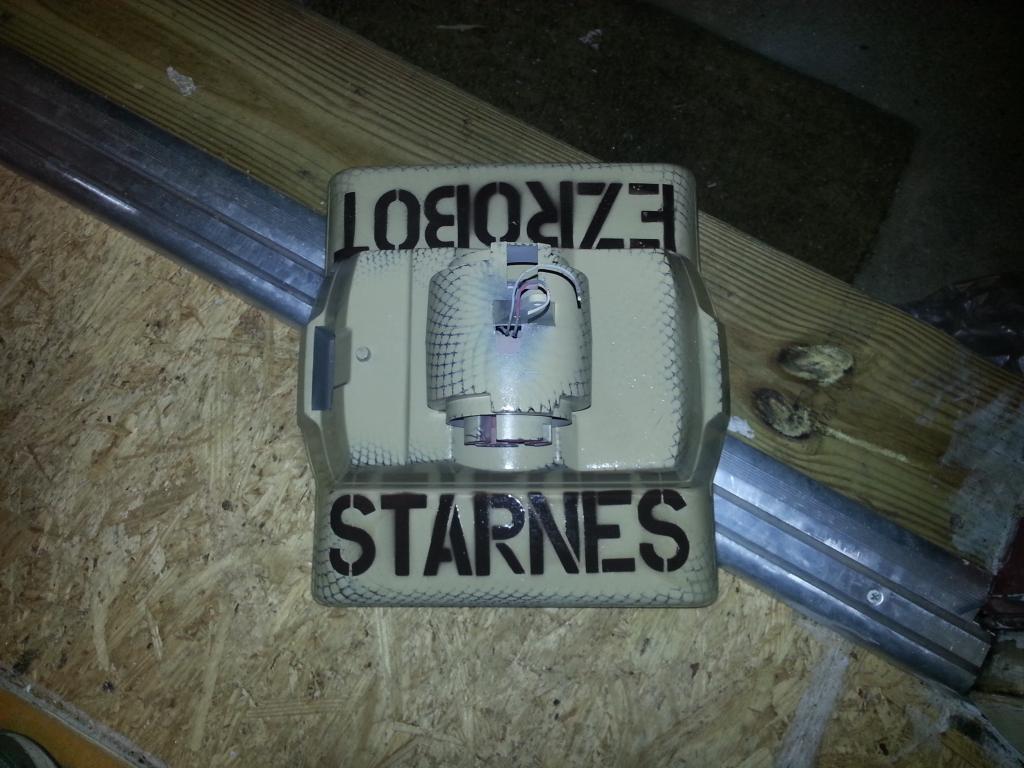
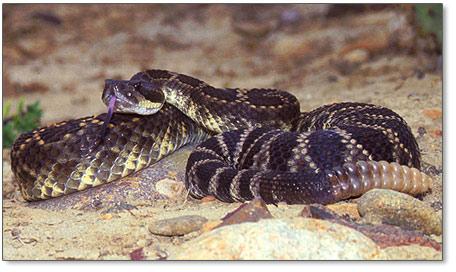
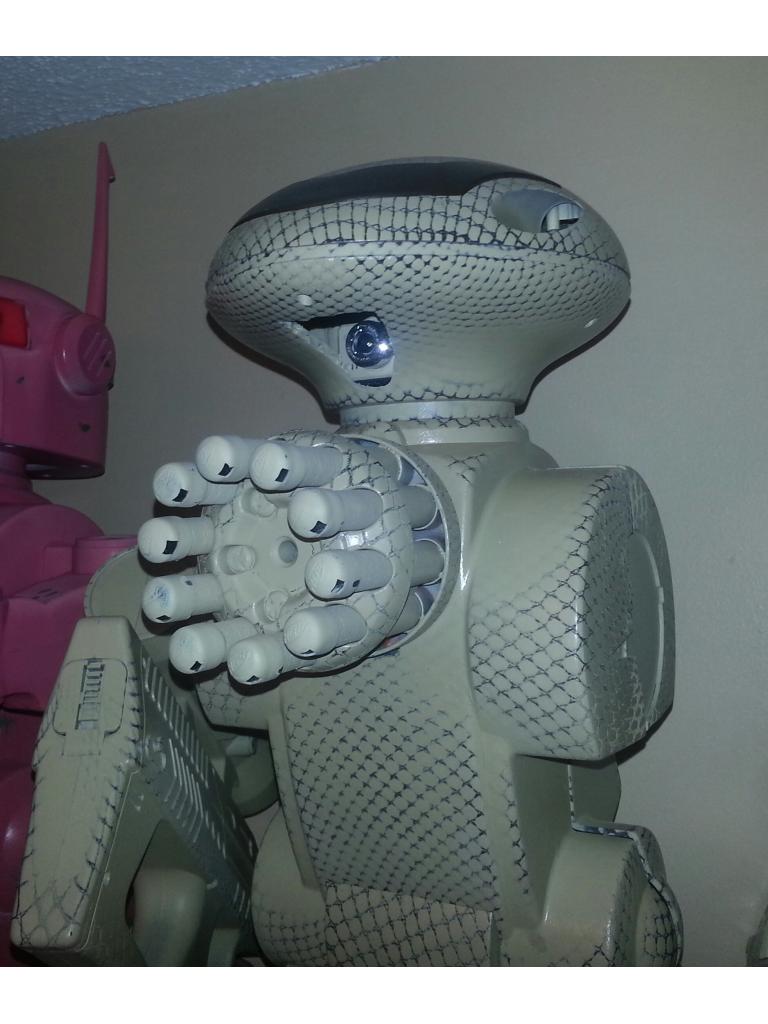
The natural imitation im going for here is Desert Diamondback rattle snake....
THat is going to look wicked! What are you using for the webbing?
Fishnet panty hose
Dude! I never knew...don't ask, don't tell. Good idea, I can't wait to see how it turns out.
Ok heres the results of the first test.....
That looks really COOL!