

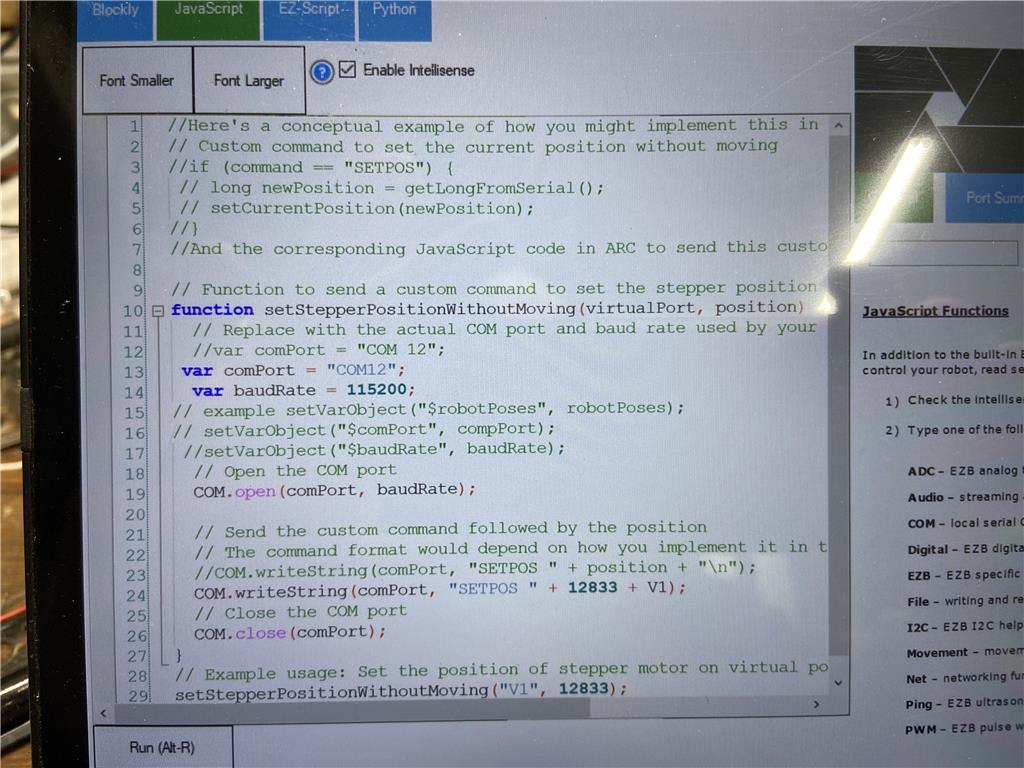
Can you show me some examples in Javascript of how to Setashome for V21? Can you also show me some examples in Javascript of how to Calibrate V22?
Asked
— Edited
6 Participants
Home Stepper Motor
Related Hardware (view all EZB hardware)

EZ-B V4
by EZ-Robot
EZ-B v4 with Synthiam ARCx controls servos, sensors, camera and audio over Wi-Fi or USB serial, no firmware needed.
Wi-Fi / USB
Servos
24
Camera
Audio
UART
3
I2C
ADC
8
Digital
24
Related Robot Skills (view all robot skills)
Stepper Servo
by Synthian Inc.
Control up to 127 stepper motors via Arduinos mapped to ARC servos; supports any stepper driver, serial network, home calibration, speed/accel.
Requires ARC
v21
Inverse Kinematic Arm
by Synthiam
Control robot arms with inverse and forward kinematics, converting X/Y/Z positions into joint motion and reporting end-effector location.
Requires ARC
v12

You the man!! Thankyou very much!! Tried it and it worked like a charm. If you can make a Go Fund My Bar Tab account I'll be happy to help fund it! (and I'm sure others will too). It may make a nice outing for your whole crew. Just put a little quiet icon in the corner somewhere and let us know where it is.
That's an interesting idea - I'm unsure how that would work for tax purposes. A long time ago, when I started my first company, ez-robot, we had a "donate" option. It was to let ppl donate towards the software development. Because hardware sales don't really support the commitment to software development of new features. However, I had to remove it because of some tax implications of being a for-profit corporation. I'd have to look into how the go-fund-me system works and such. But it would be a good idea if the funds were to go toward activities. Or even the ability for community members to purchase new features. Maybe that's a good direction to go. Allow people to fund new features.
I'd donate. In a "Allen" heartbeat.
Tried calibrating this week and have a slight hiccup. When you send the command for calibrate it does start rotating and it stops when pin 6 is grounded, that part is very good. The thing is that it rotates very slowly 1rev per 2 seconds. I have tried to change Calibration_Steps to many different values but it still rotates very slowly. I am using a 10-1 gearbox and about 20k steps per axis for high accuracy so I need it to move about 2500/sec for typical calibrating. Looked over the Javascript code but I don't see the problem. It's been defined but it seems to be defaulting back to about 100 steps/sec. If you try it you'll see the same thing. Didn't notice it before because it was on my experimental bench with no gearbox, it was moving-but slowly.