
cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


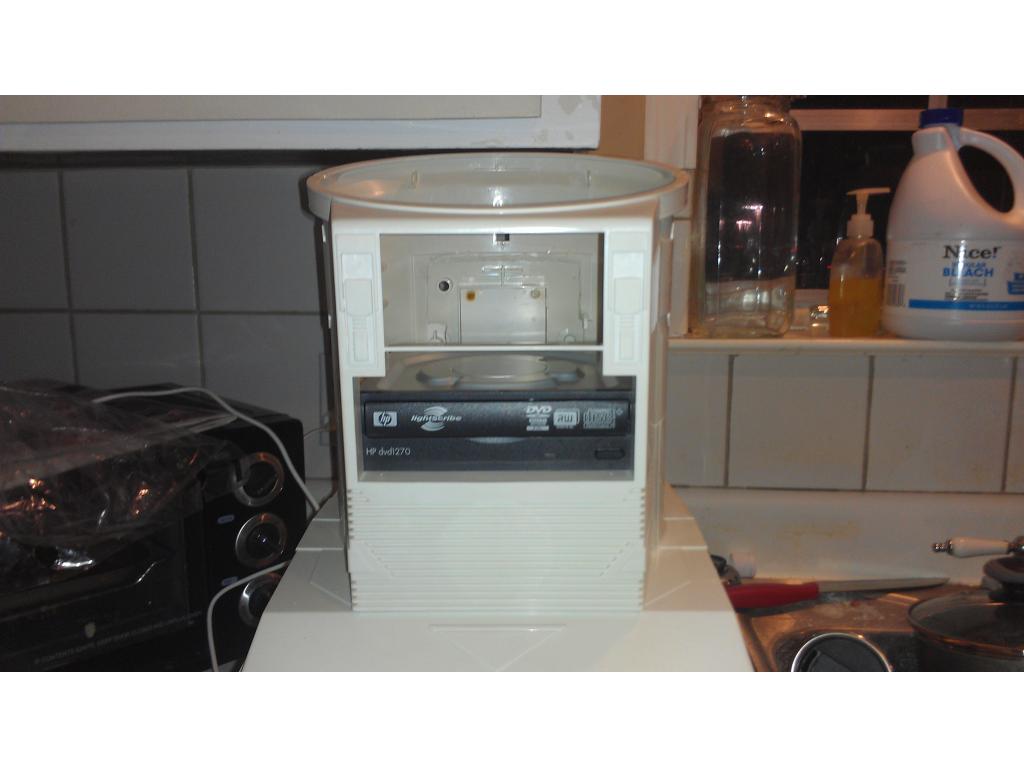
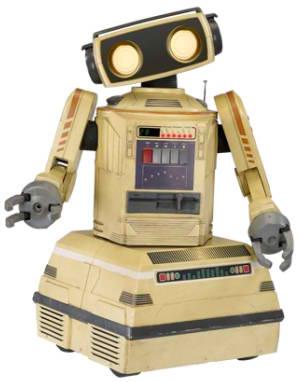
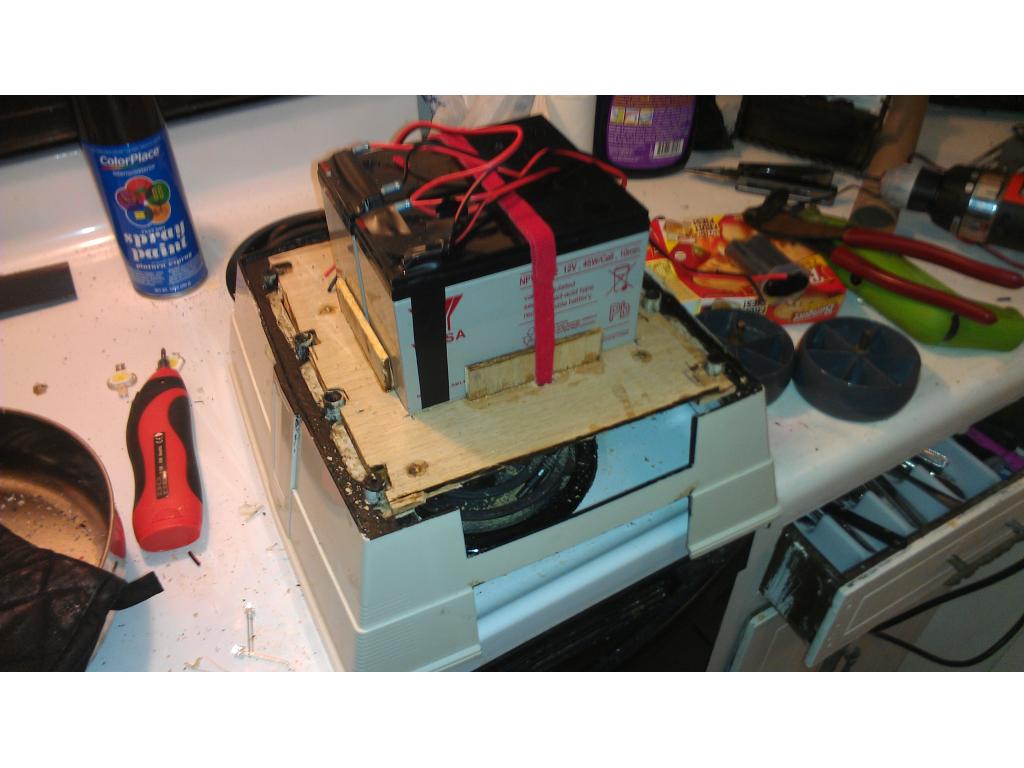

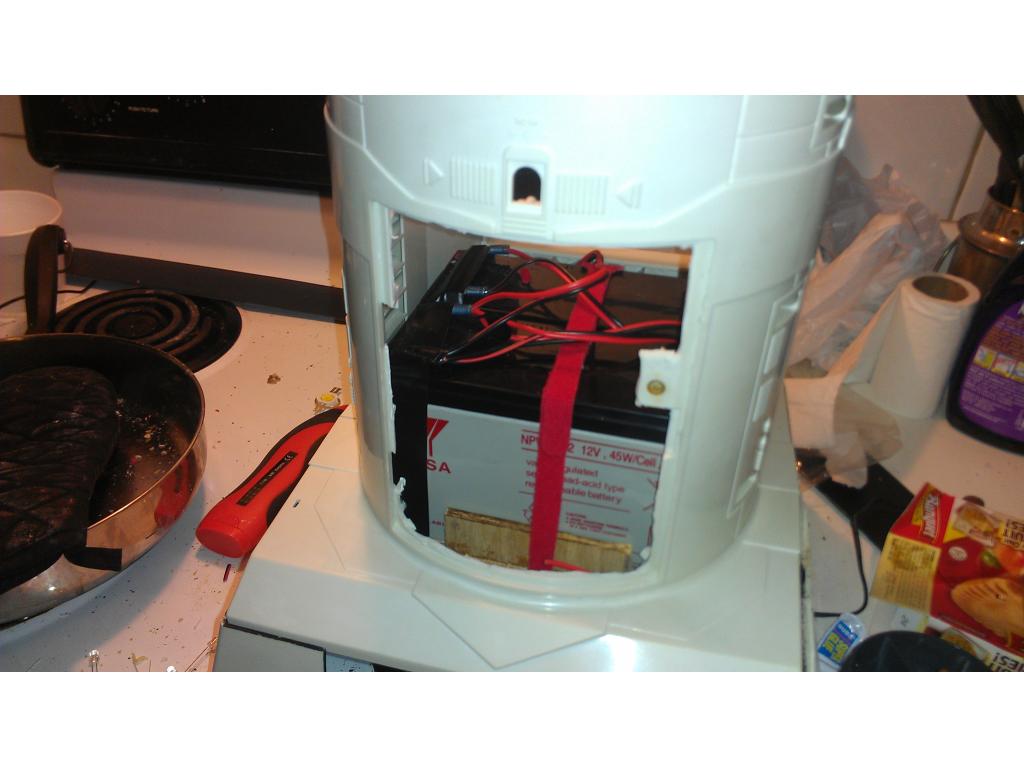
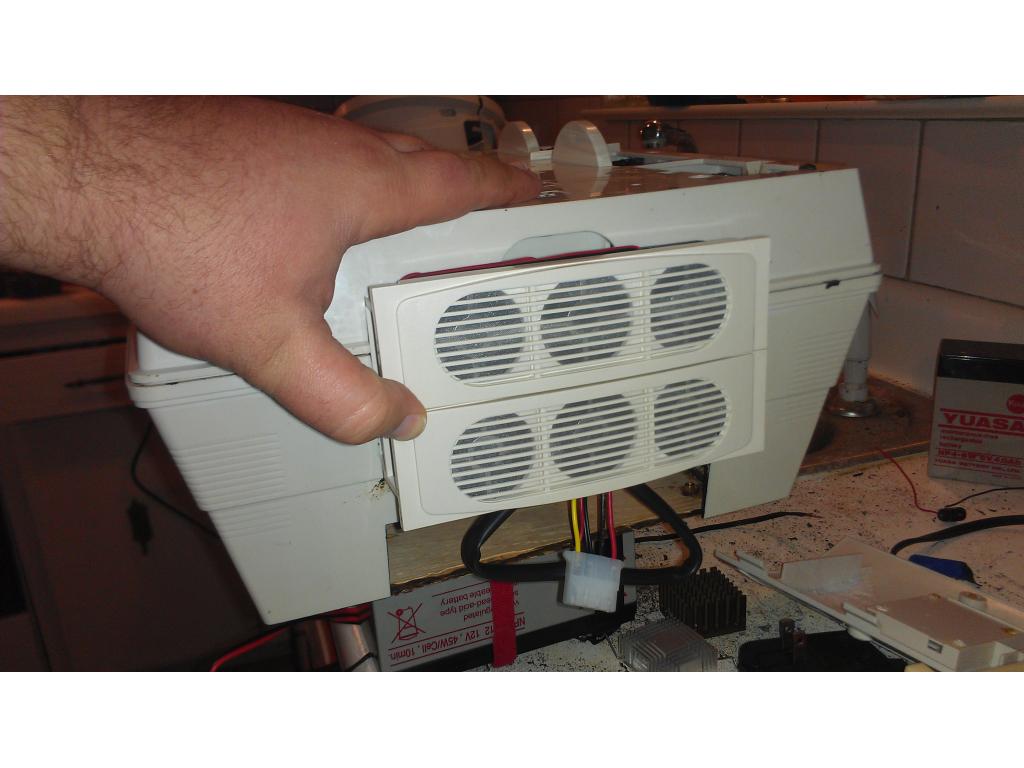
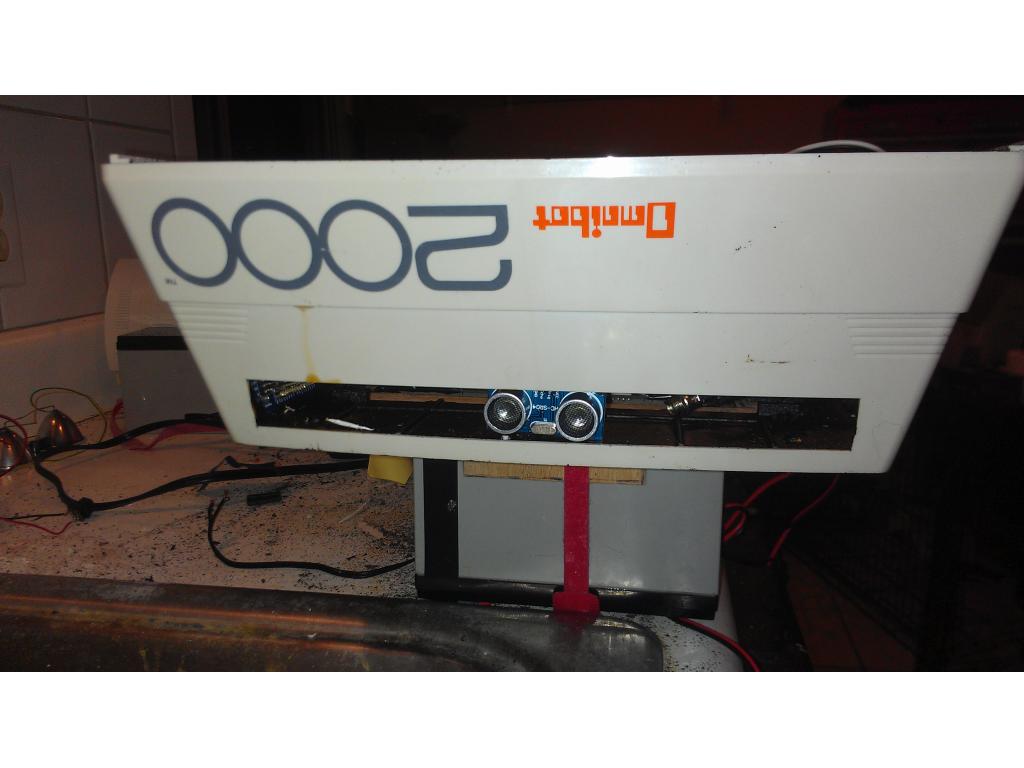
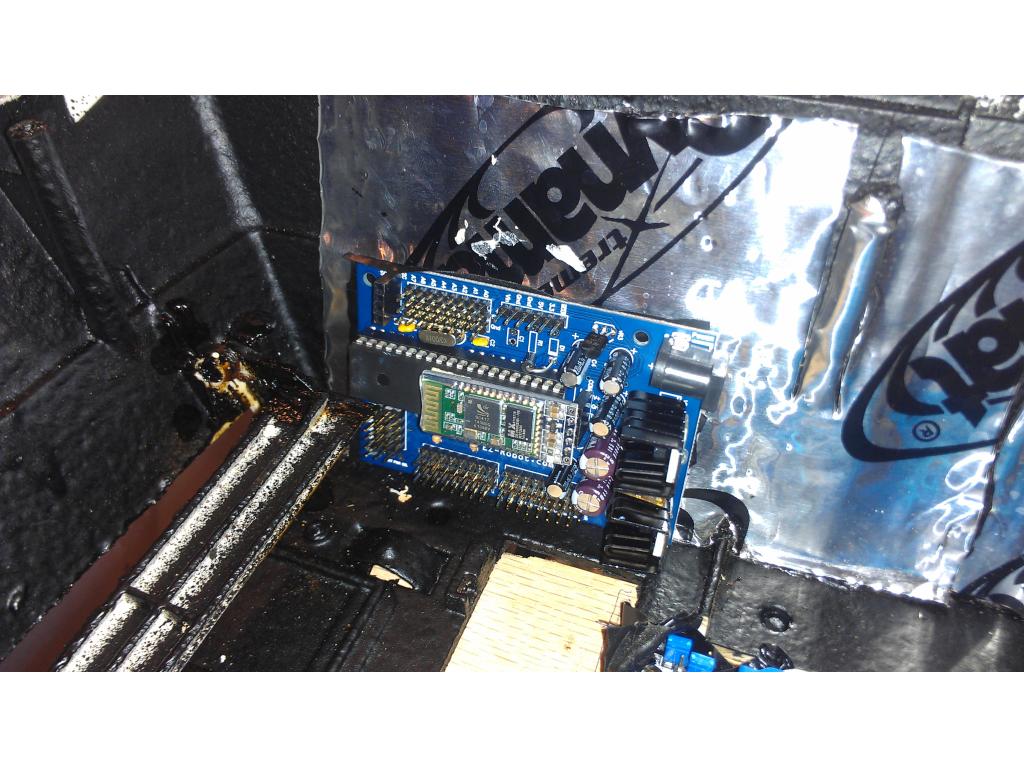


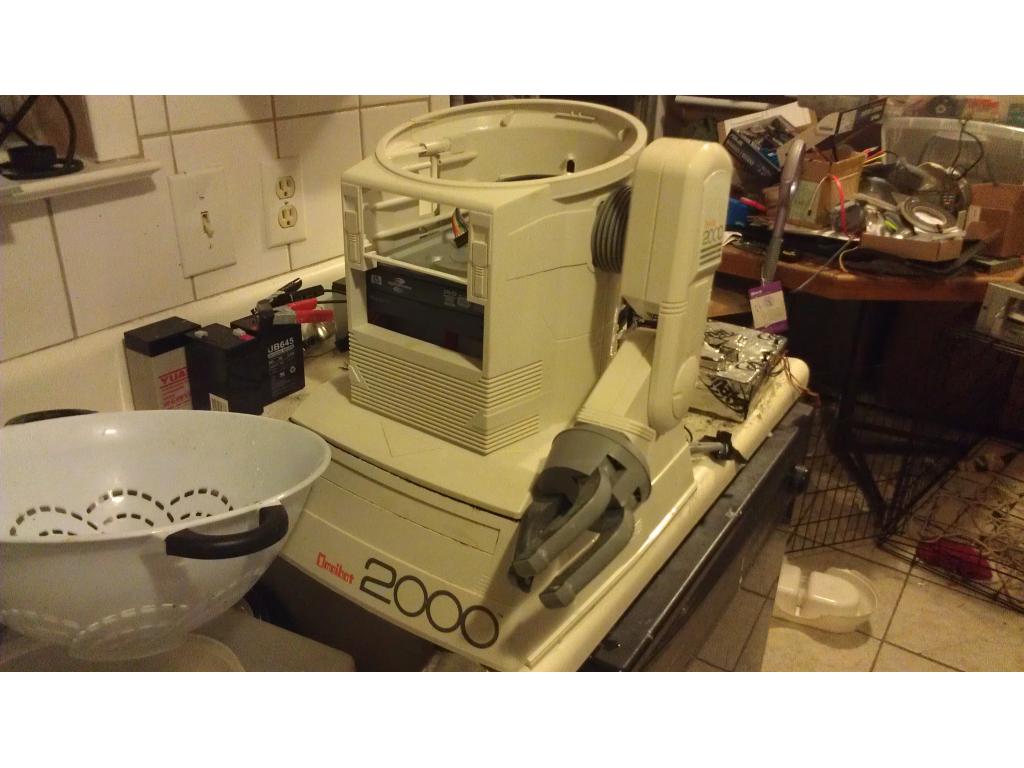
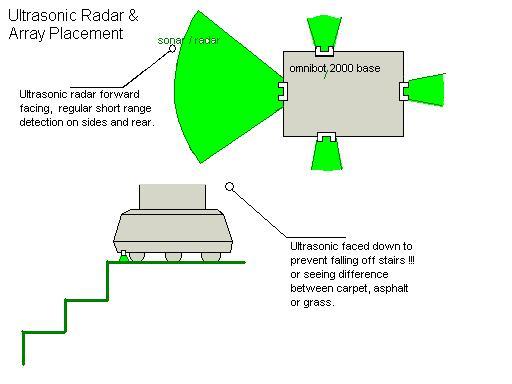
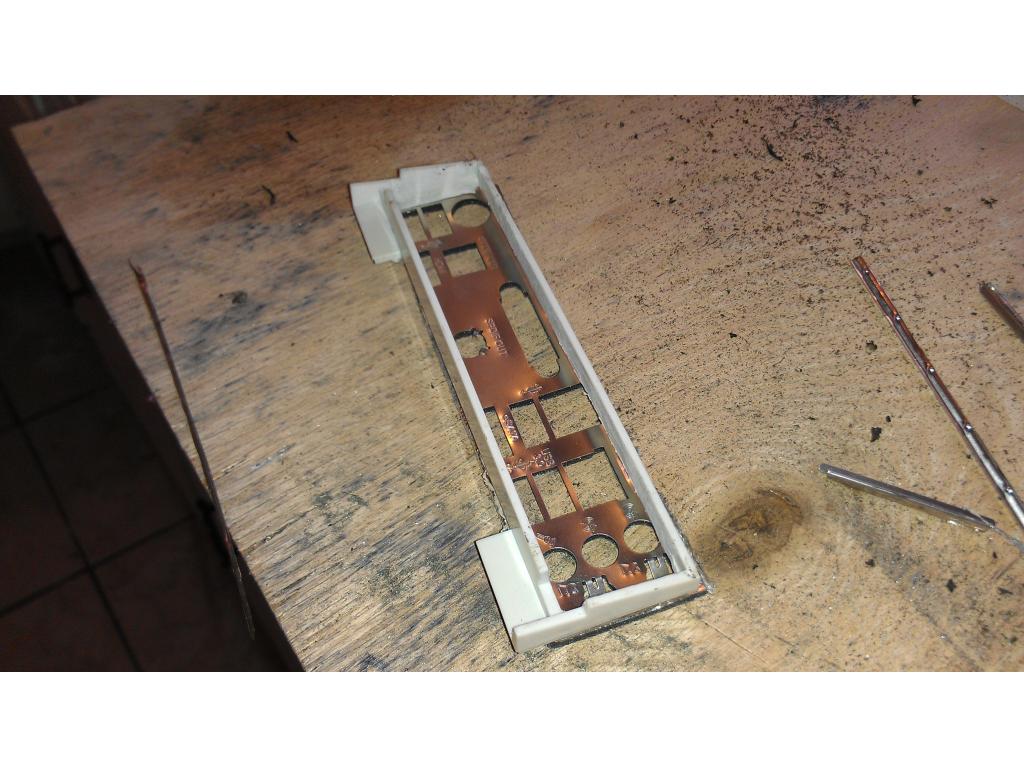
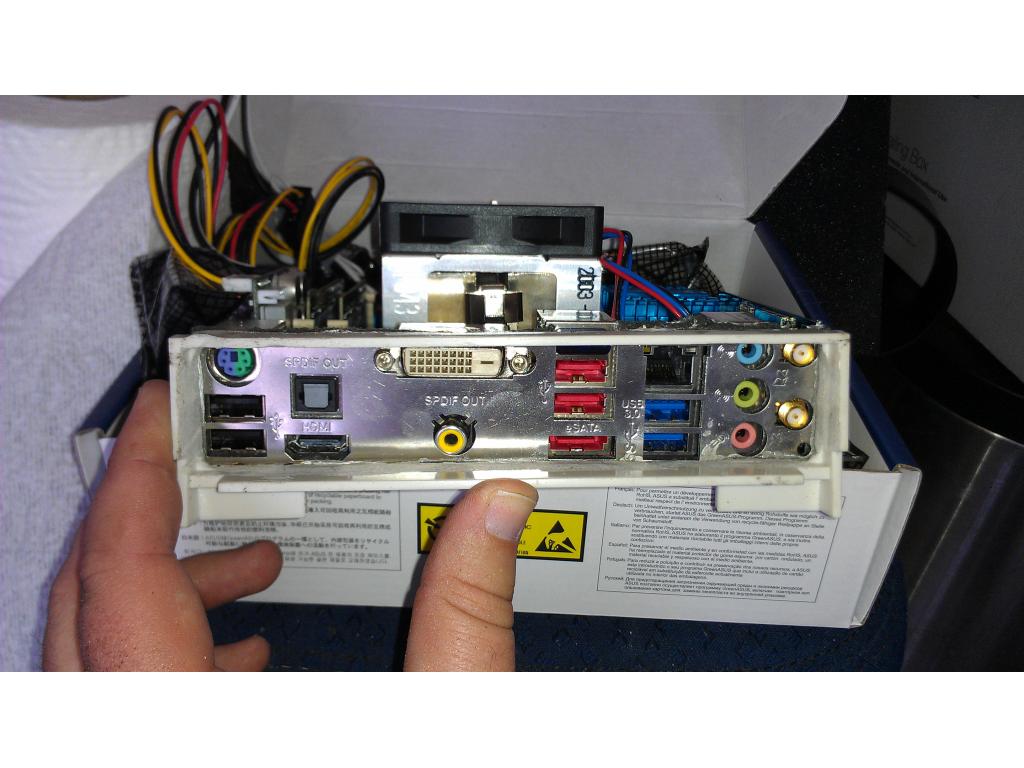
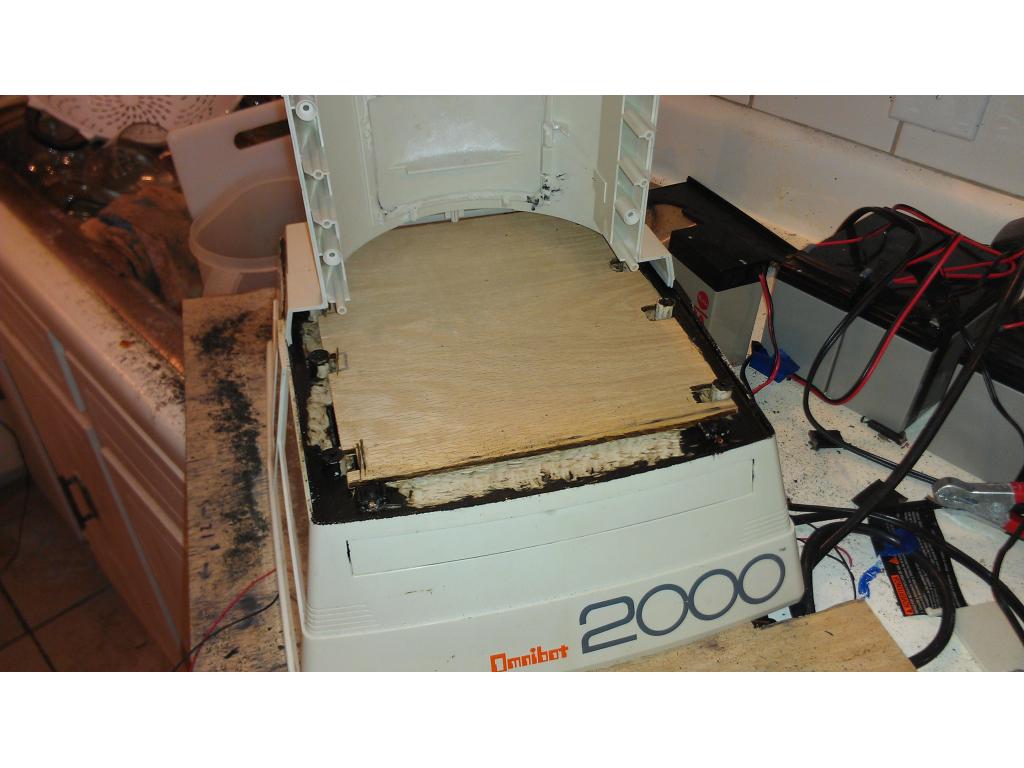
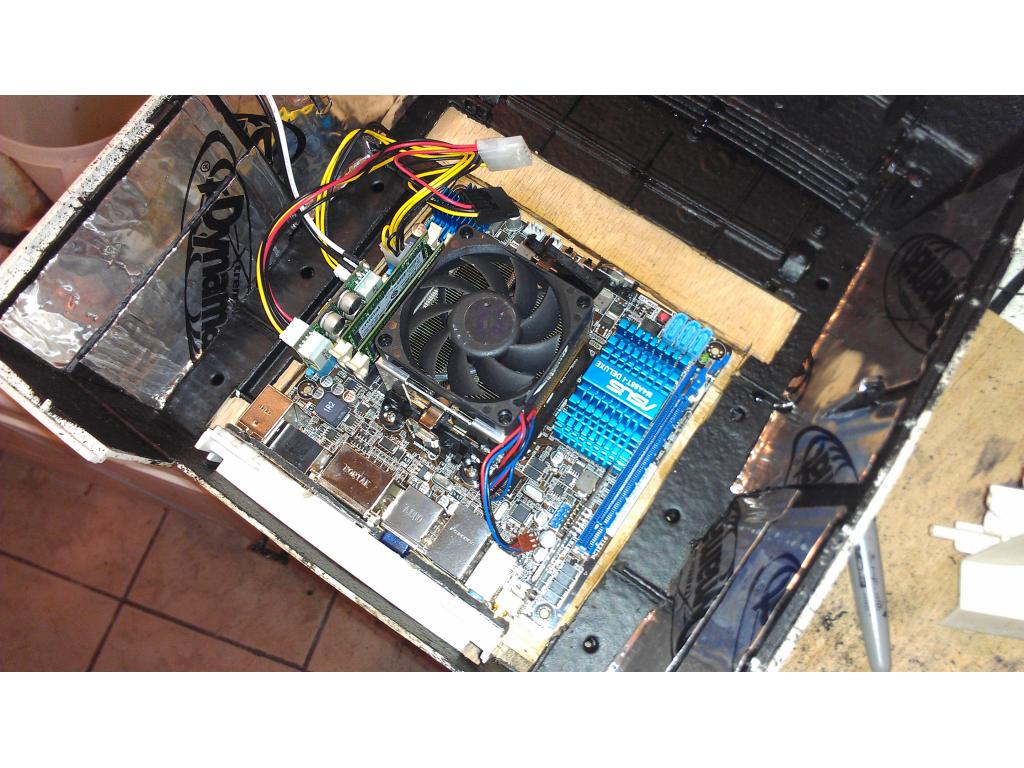
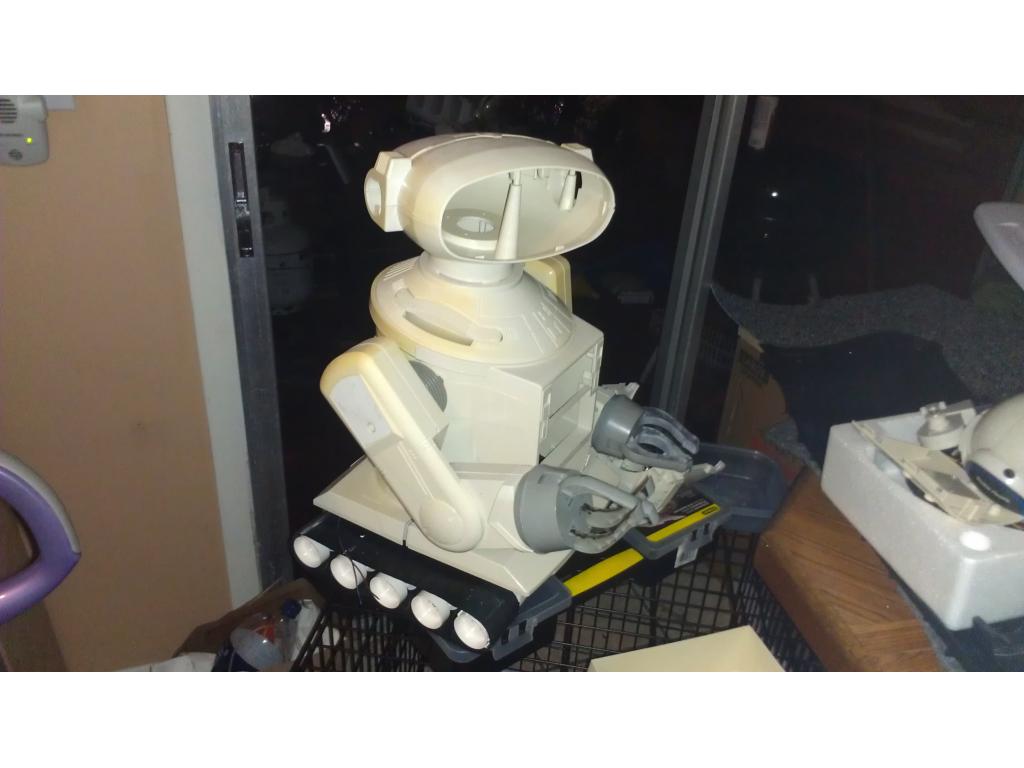
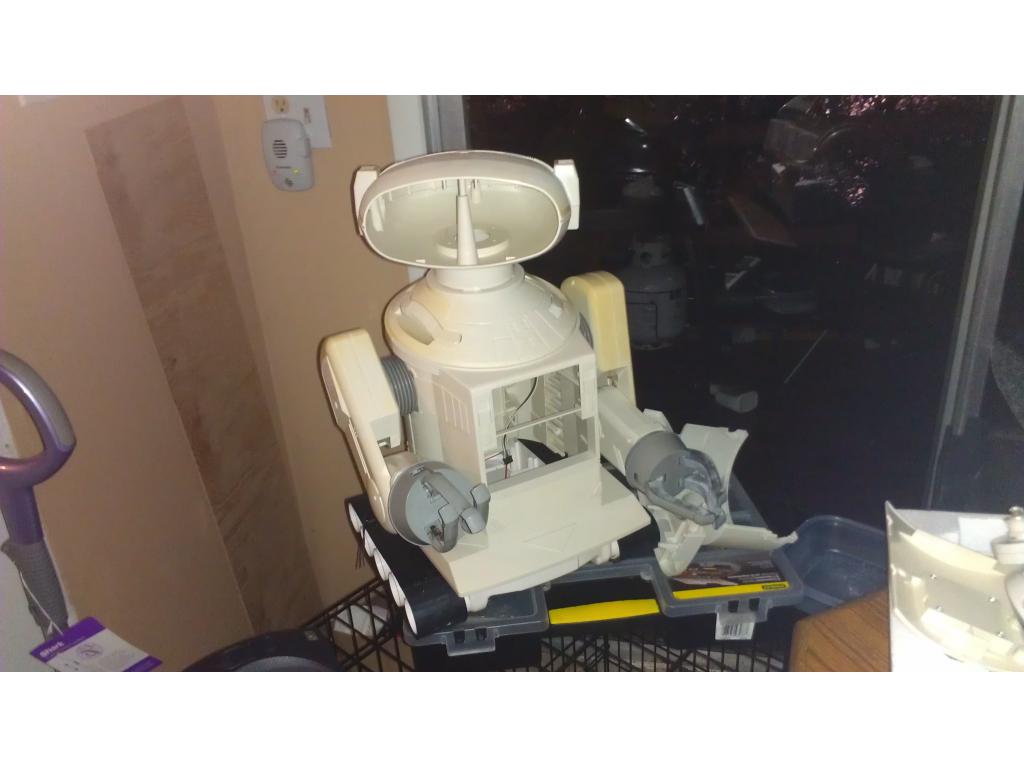
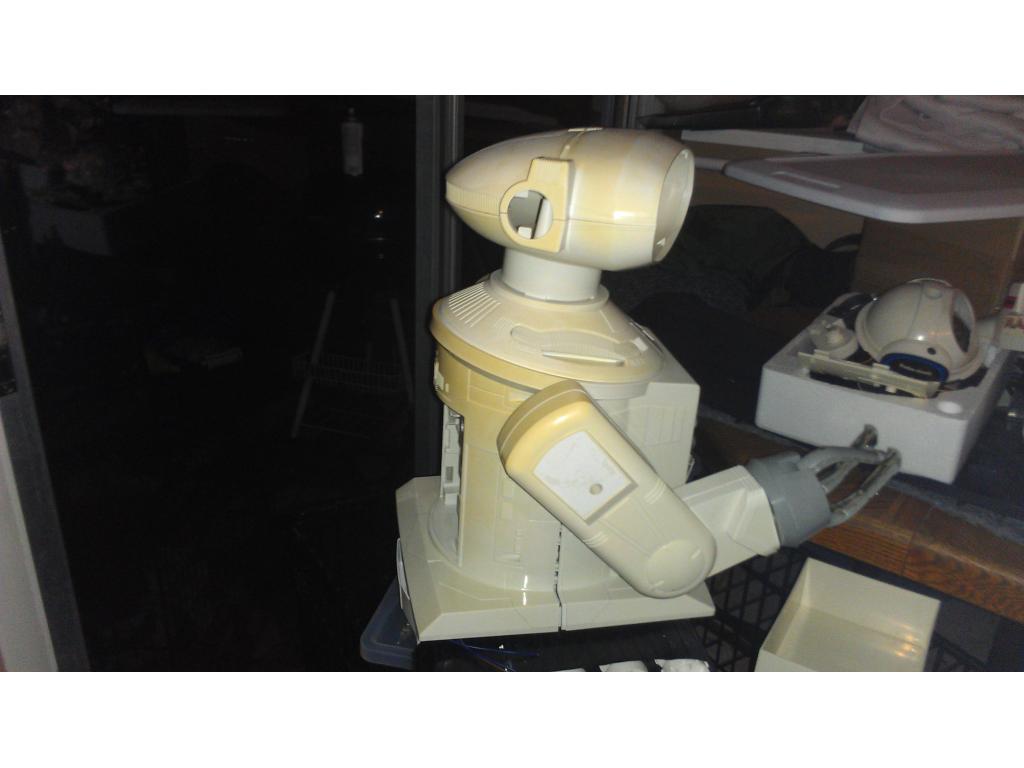
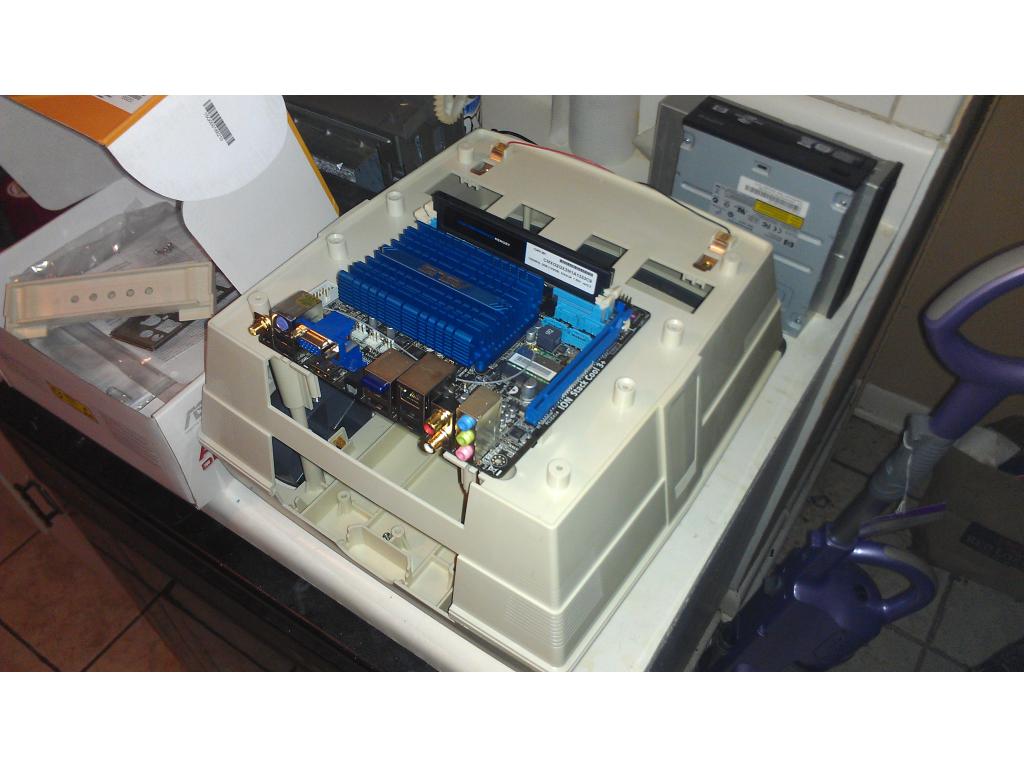
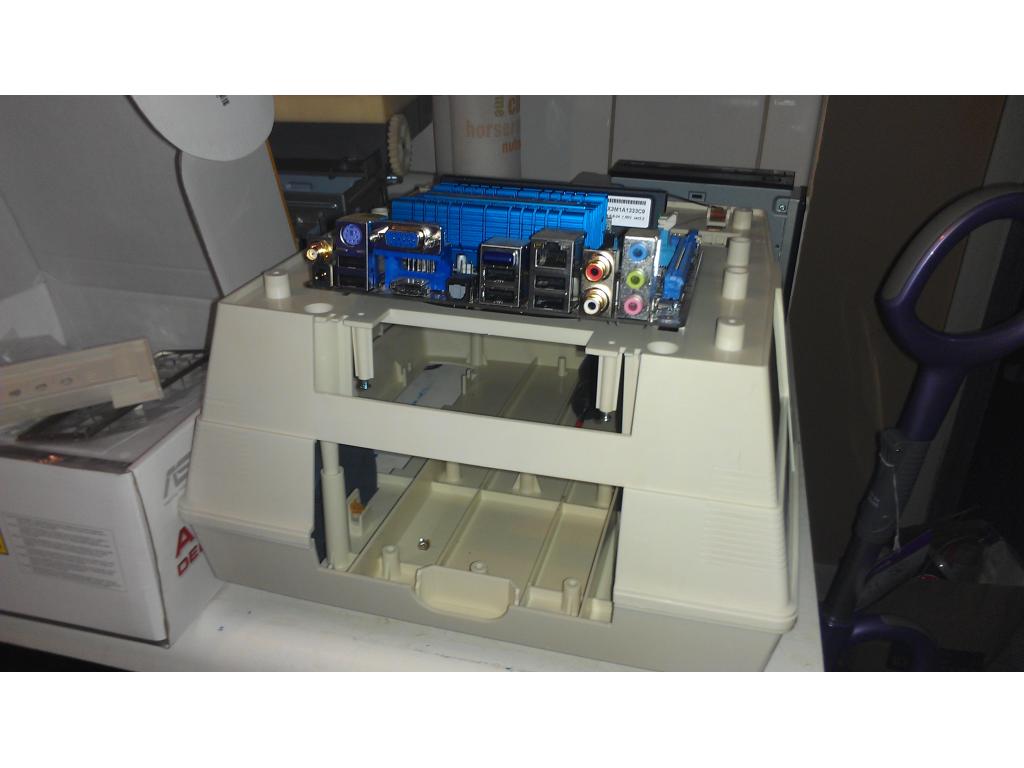
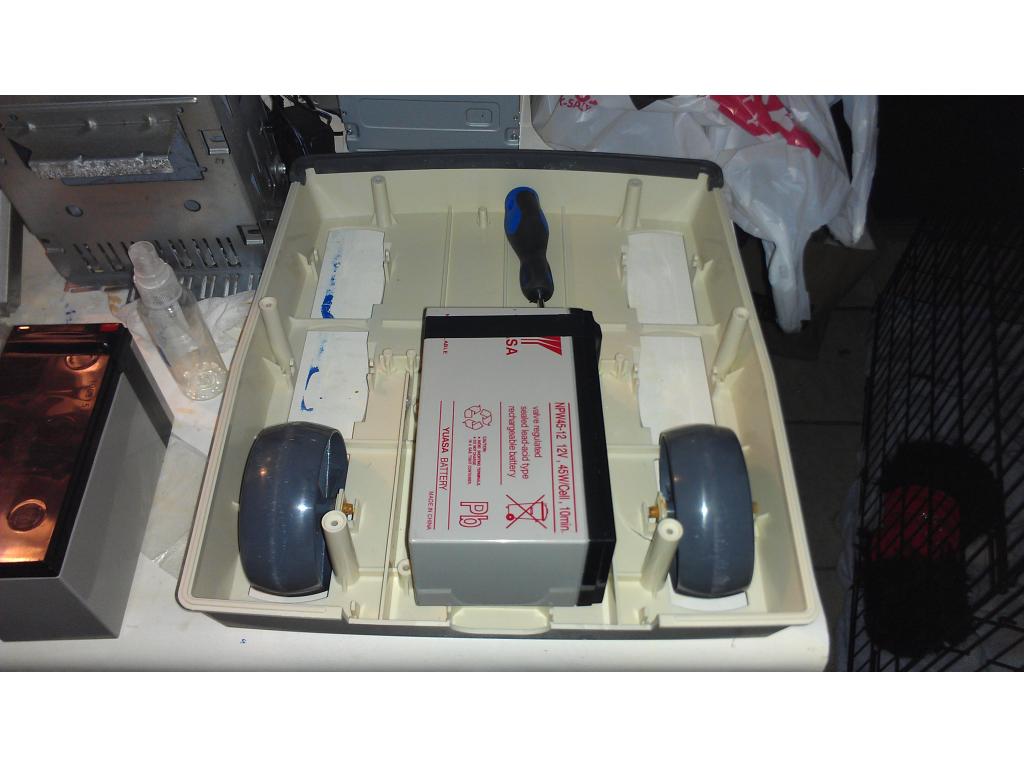
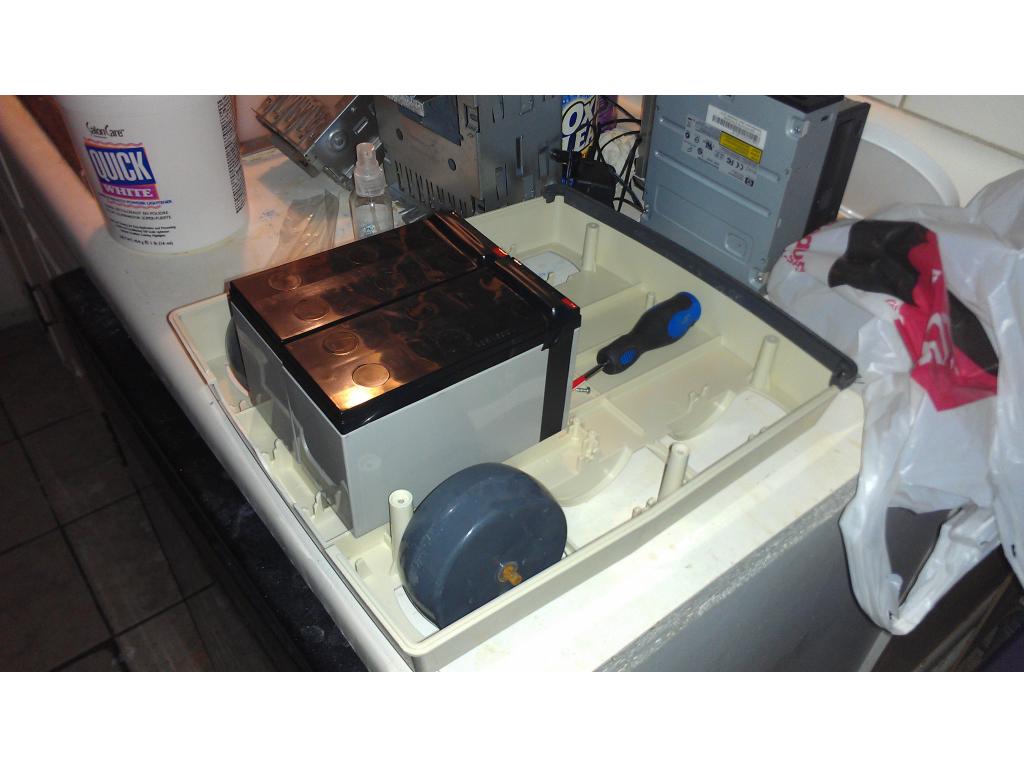
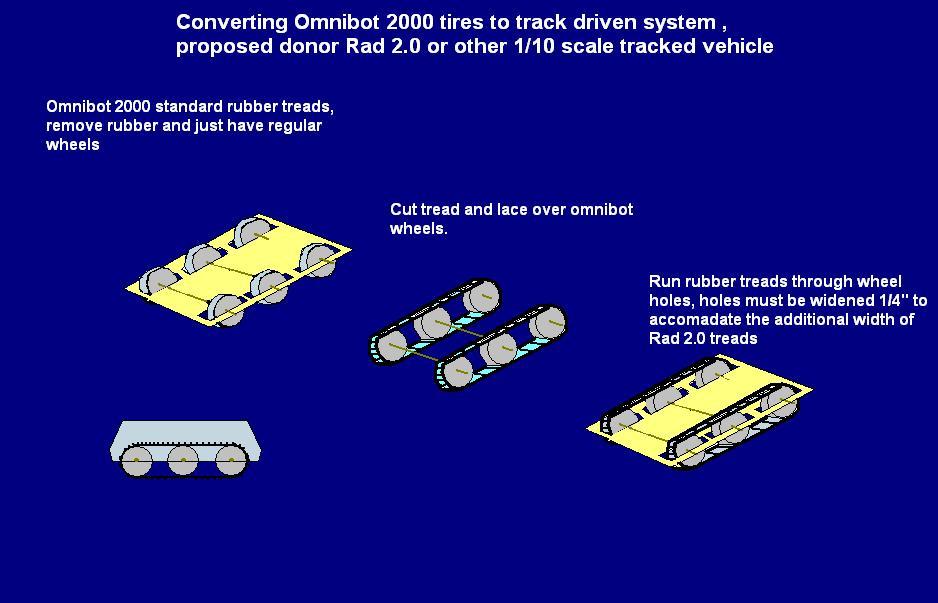


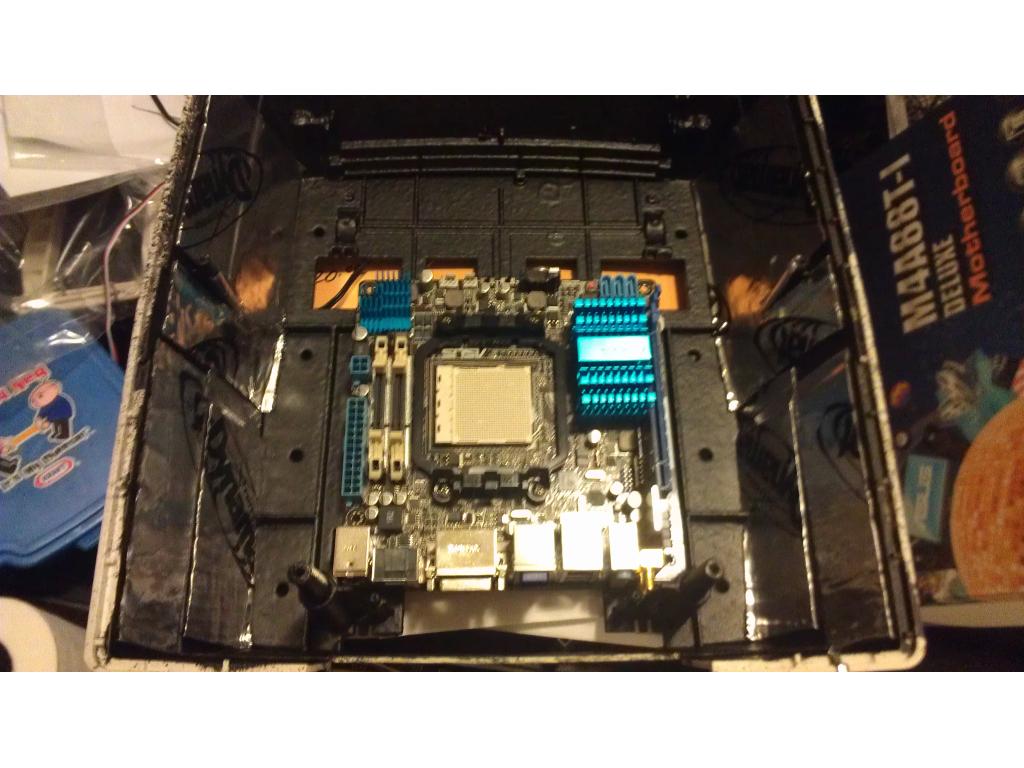
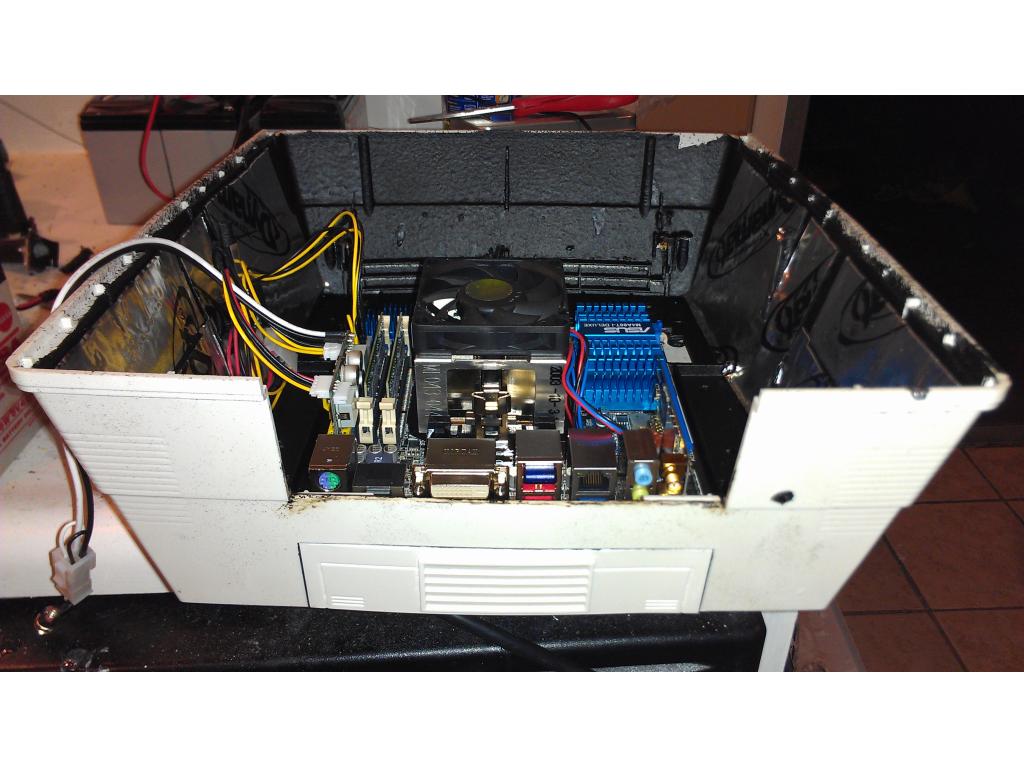
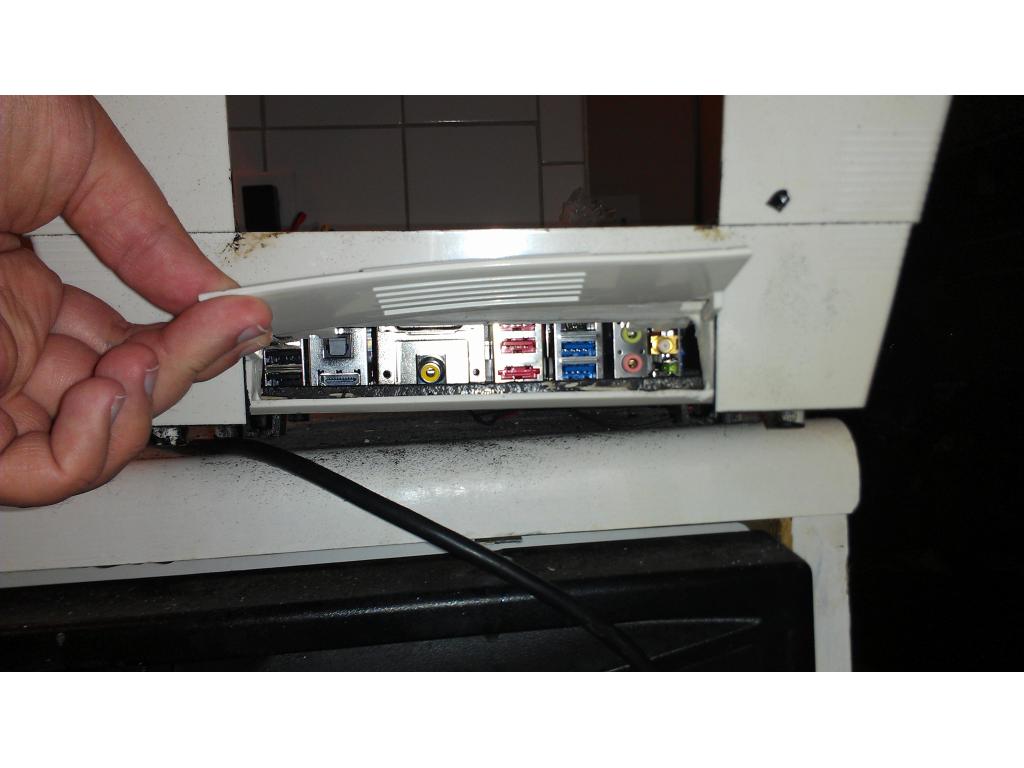
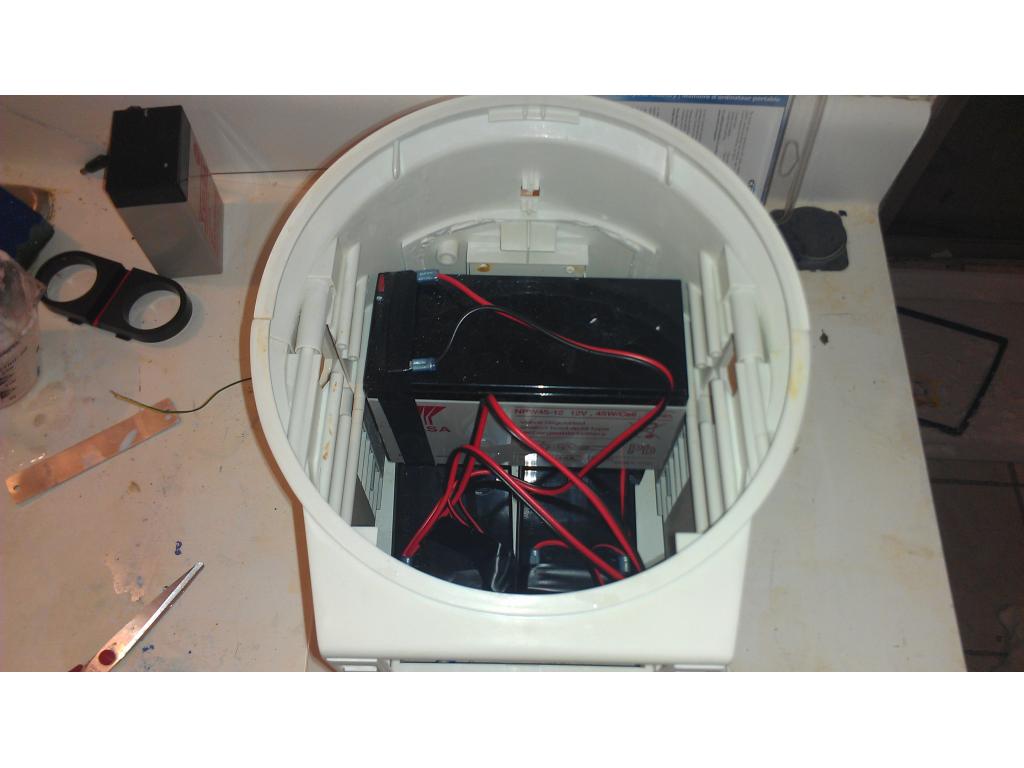
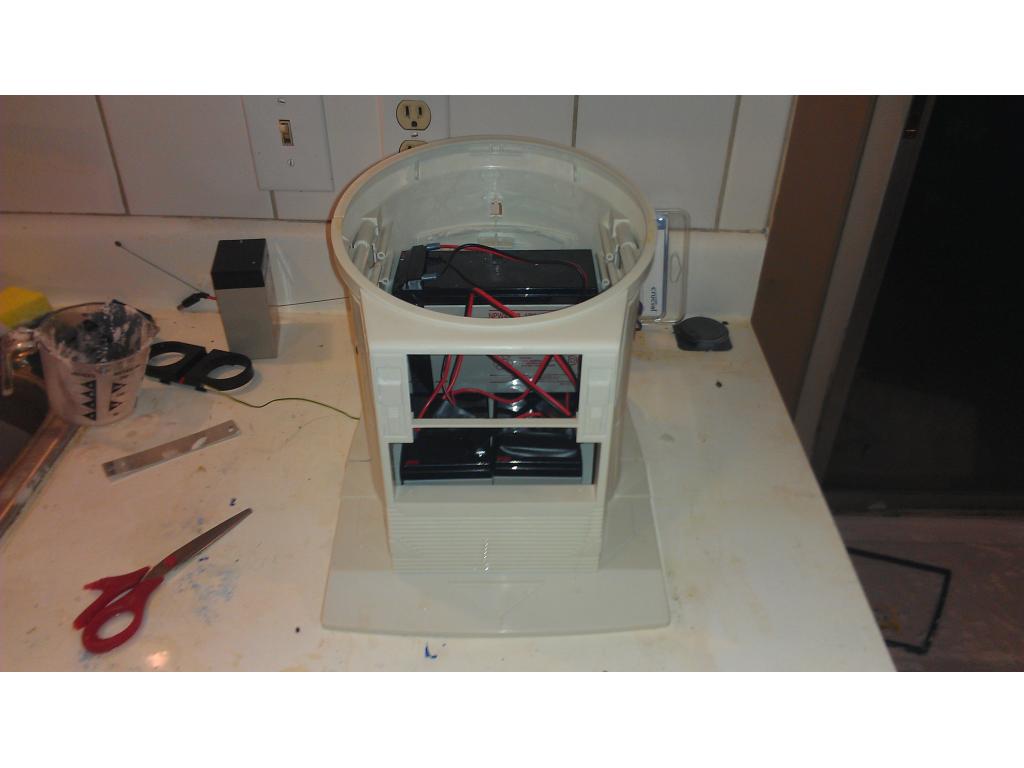
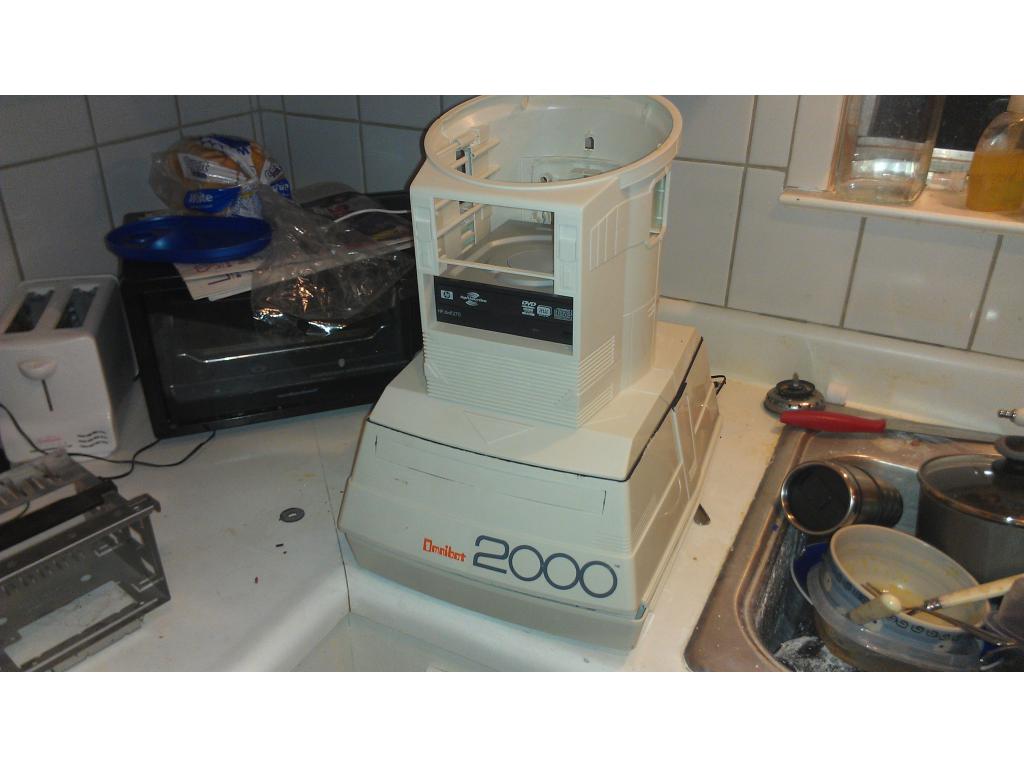
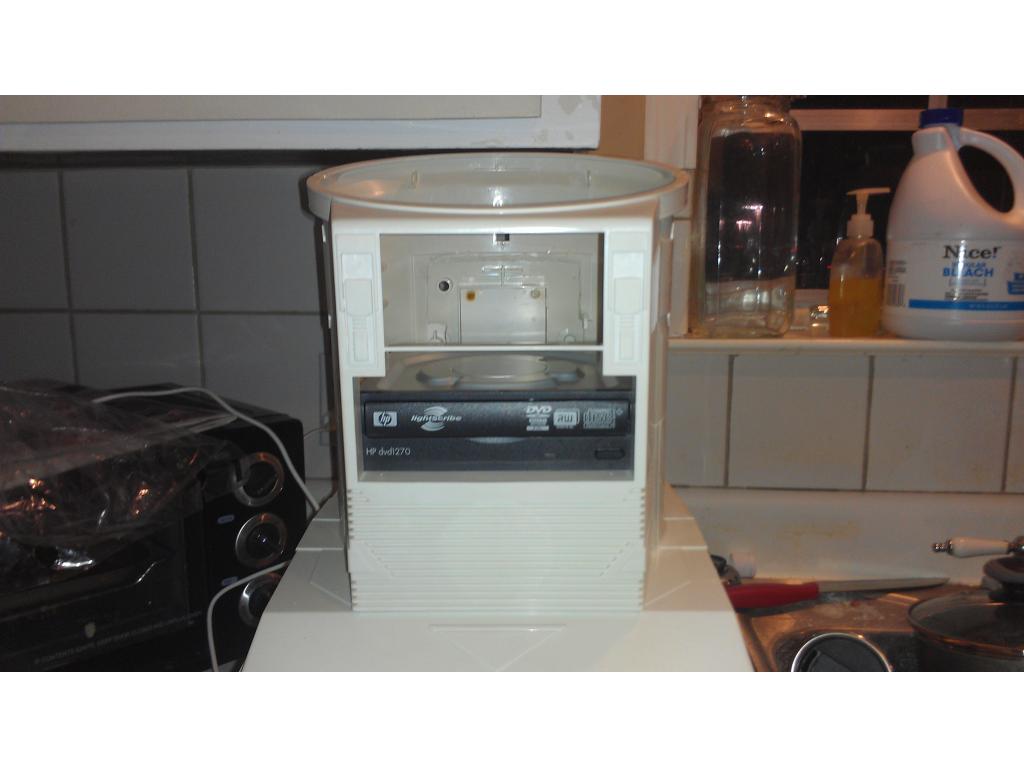
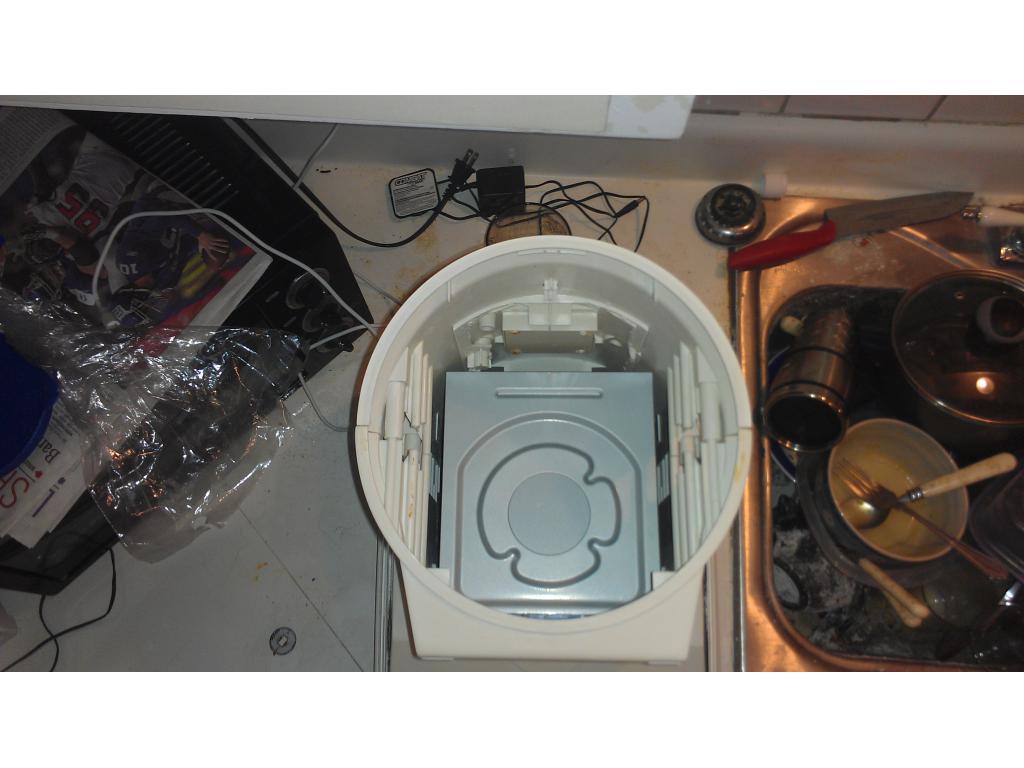

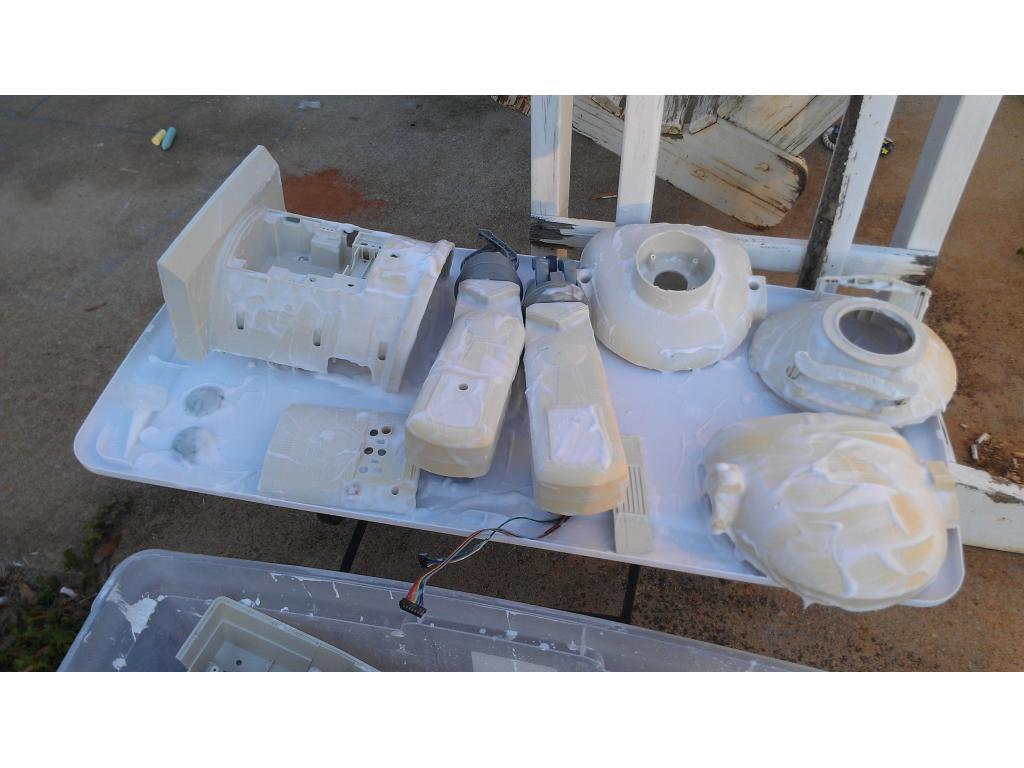
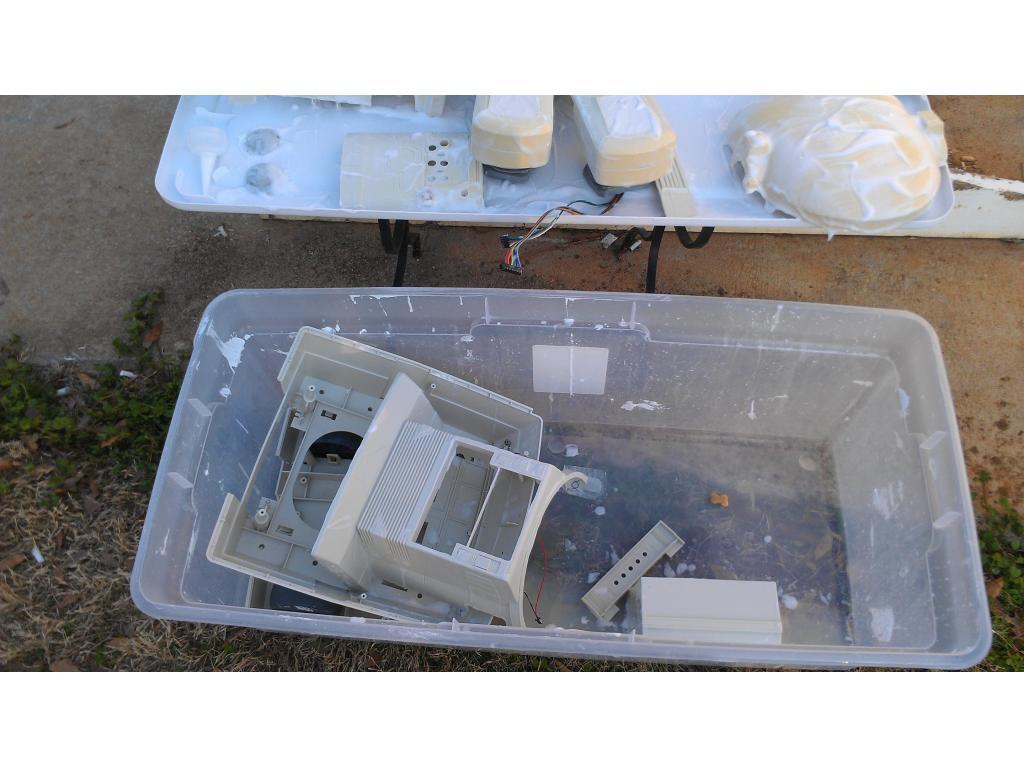
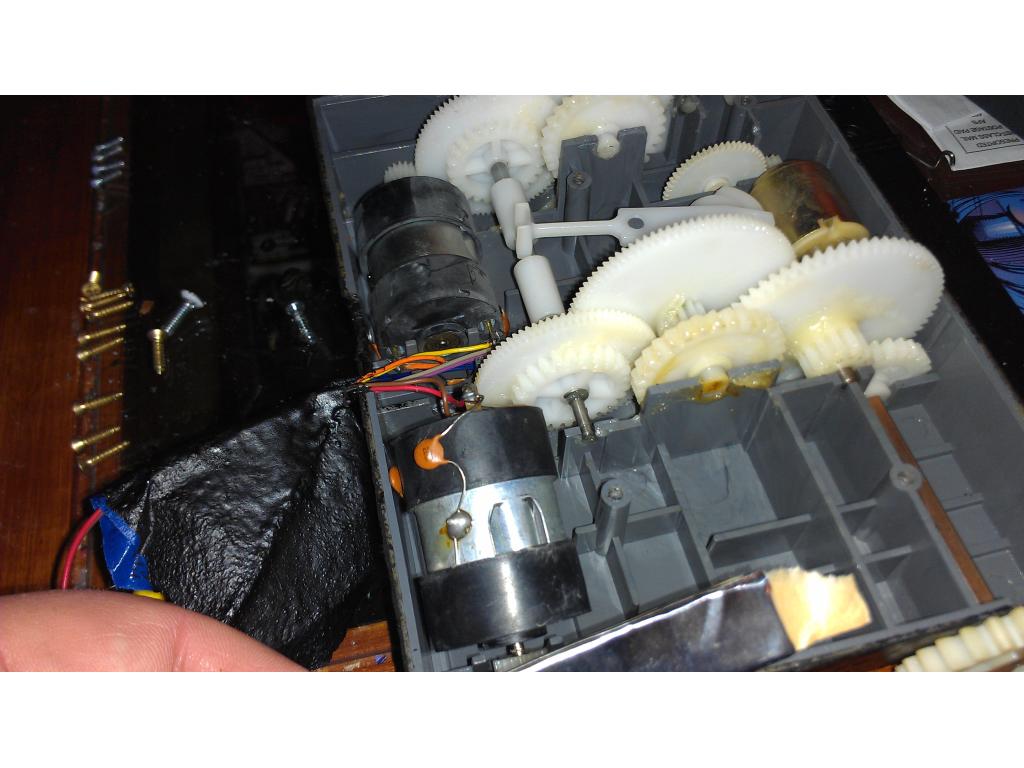
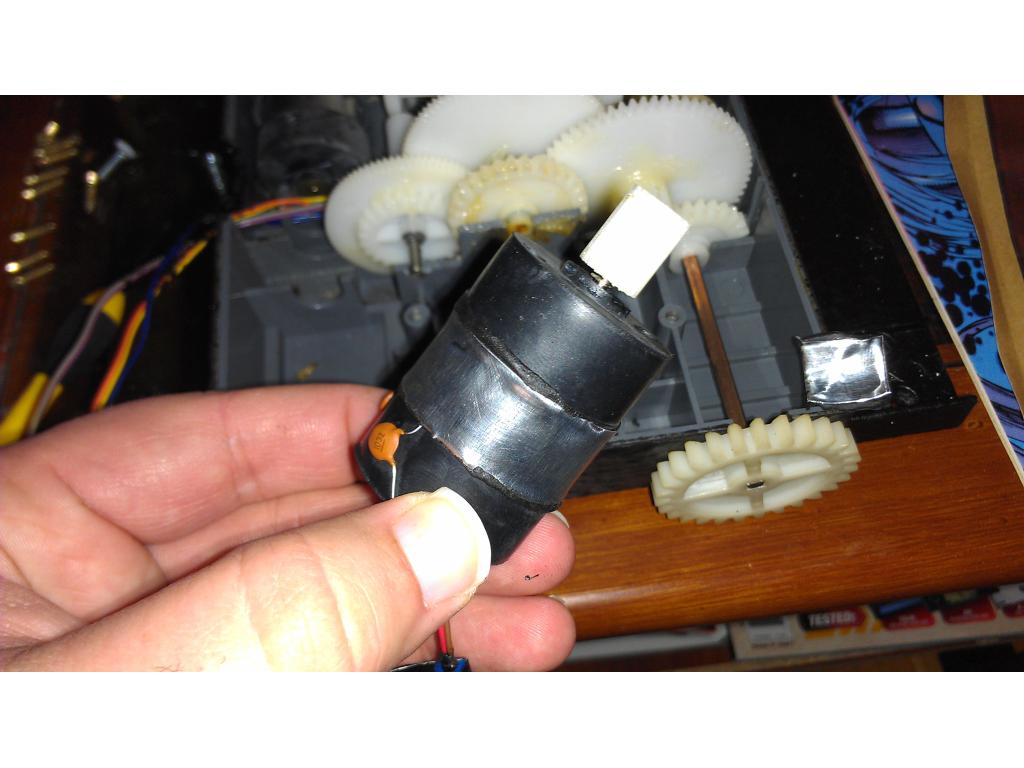
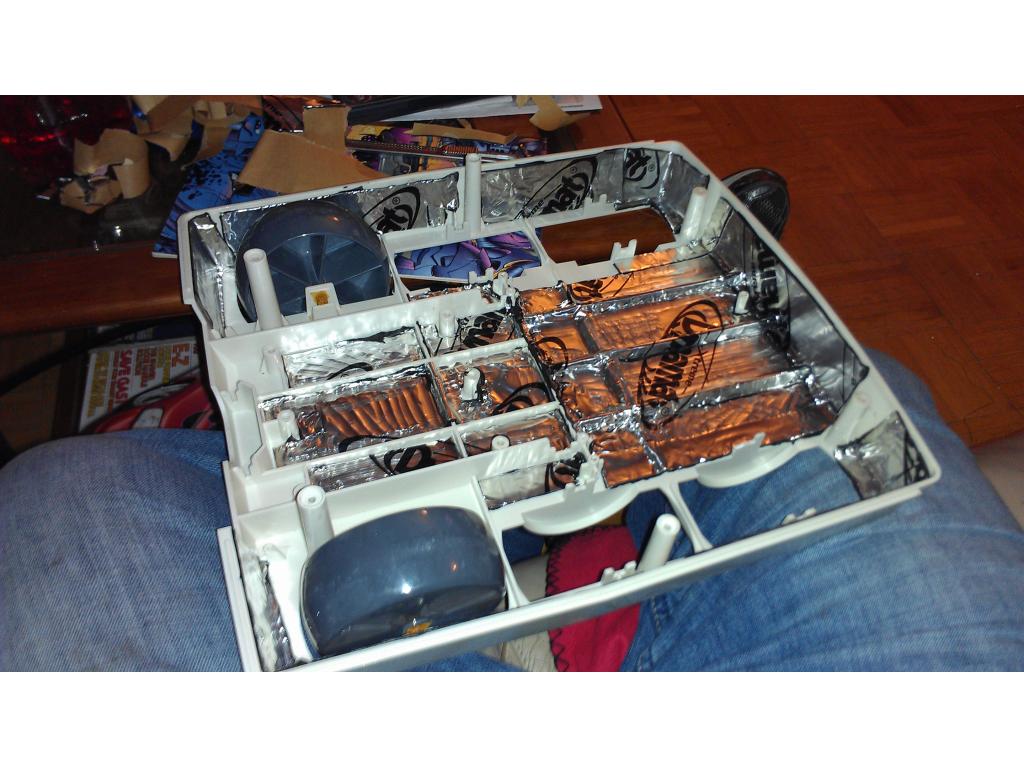
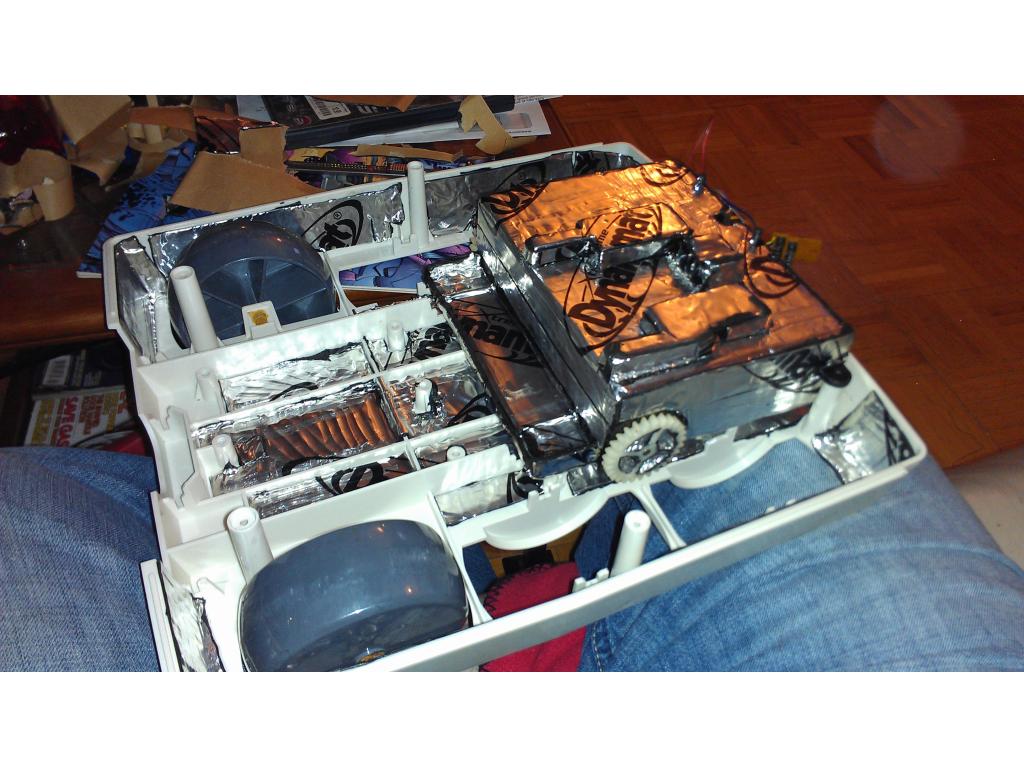
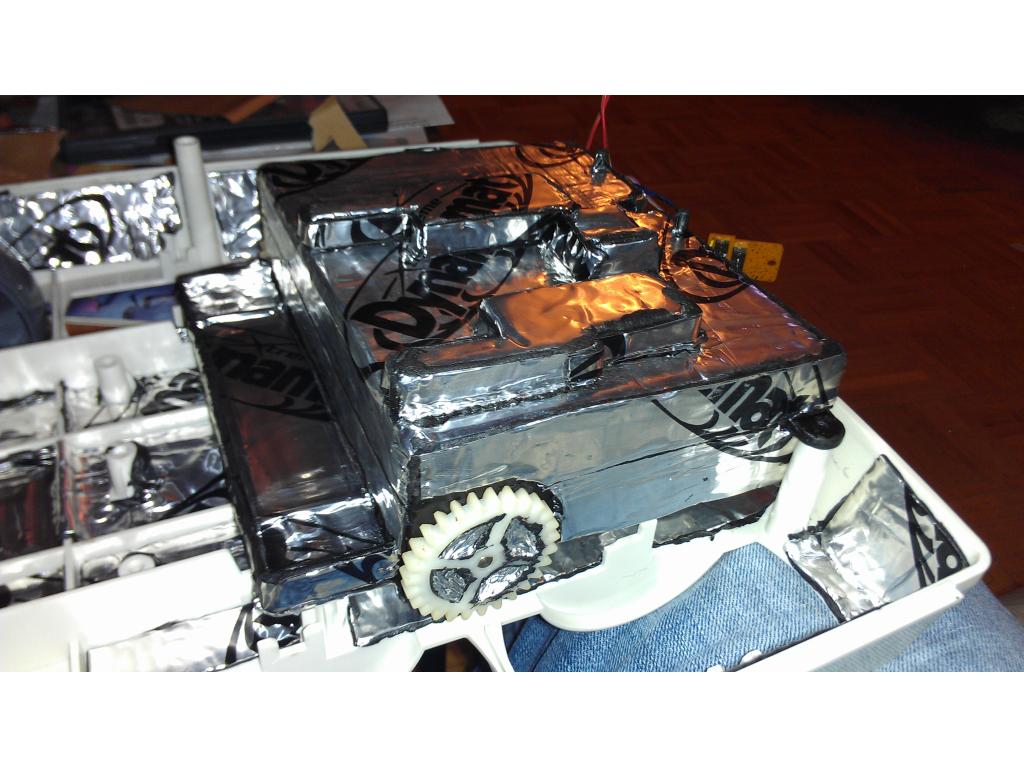
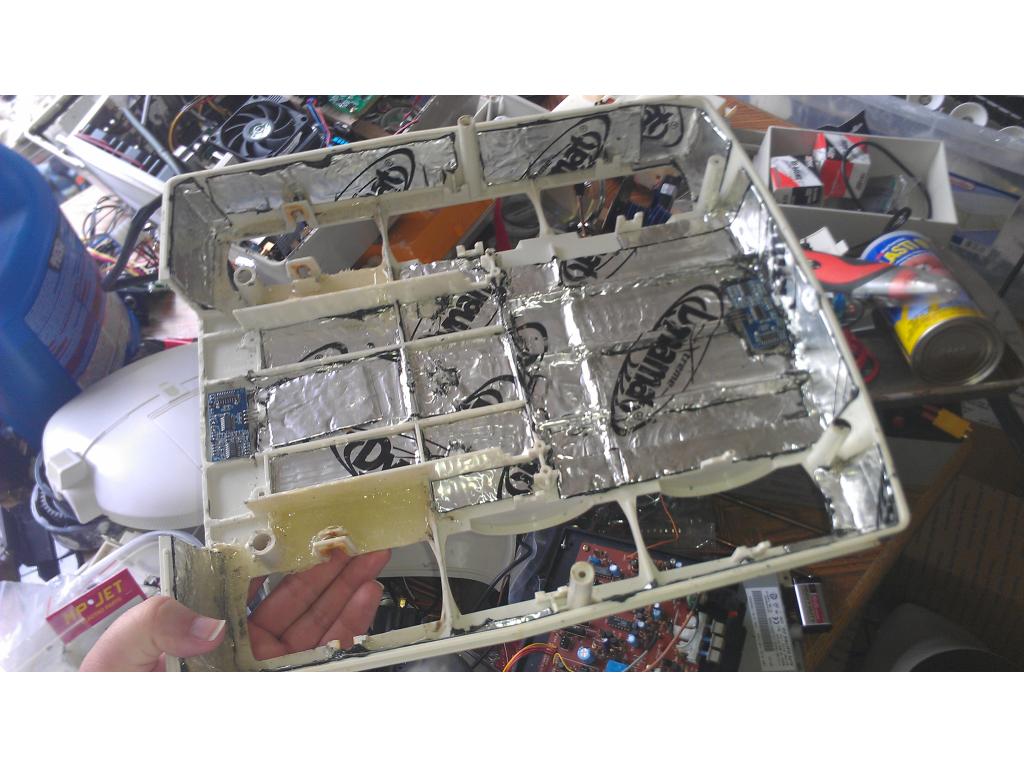
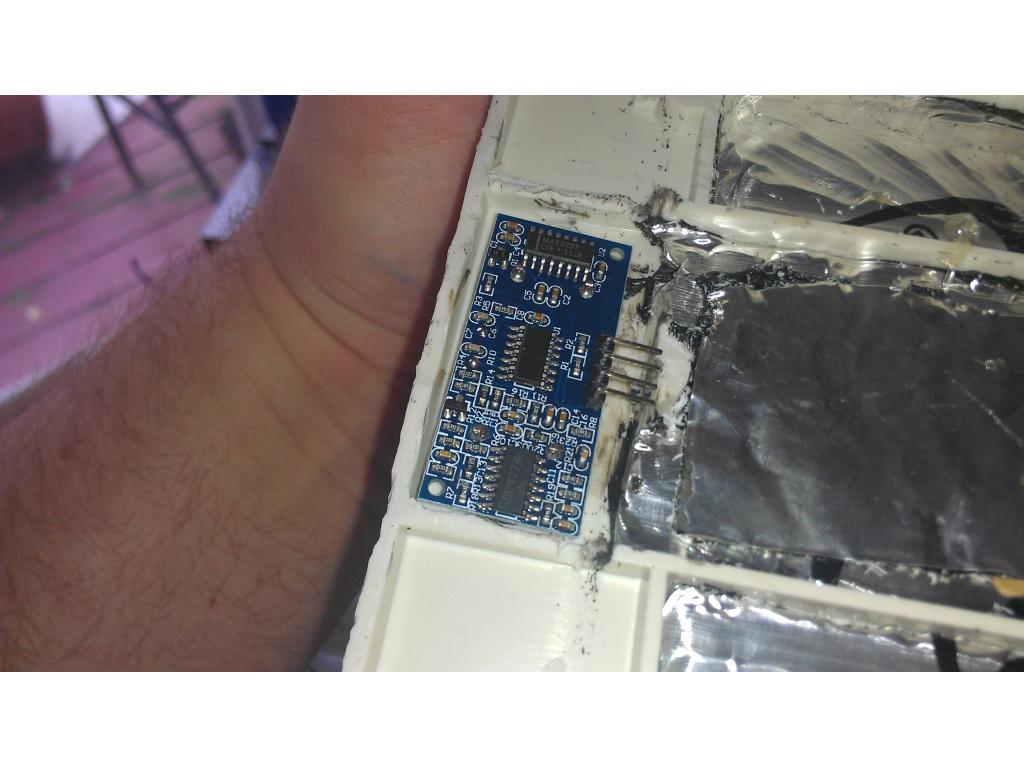
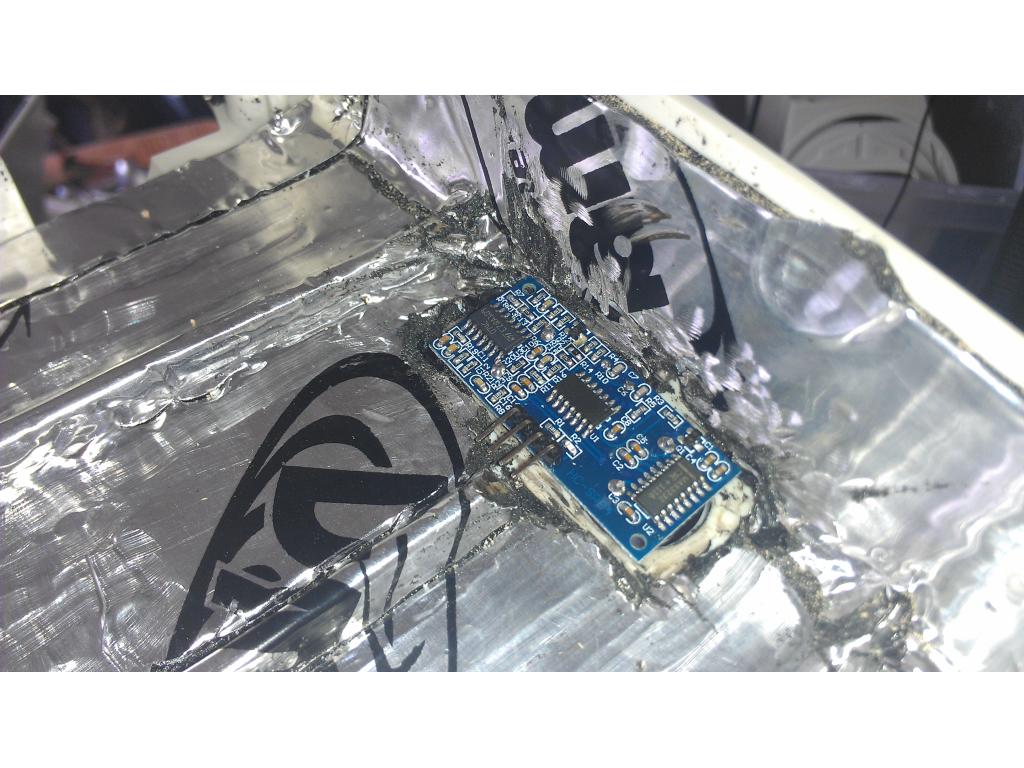
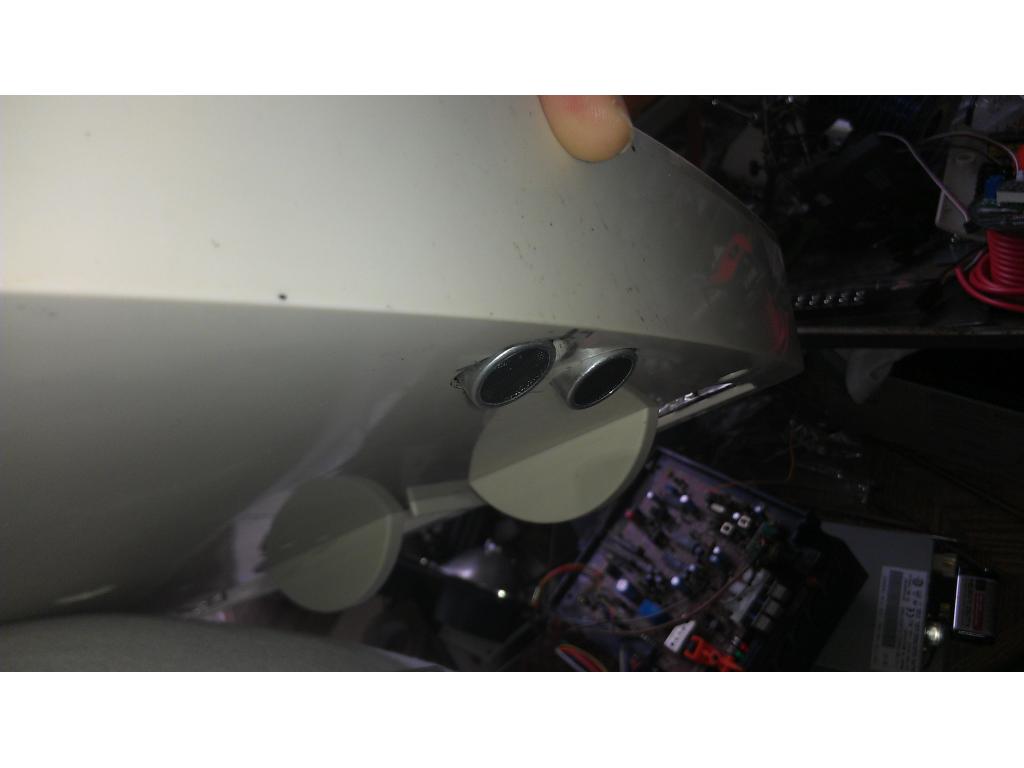

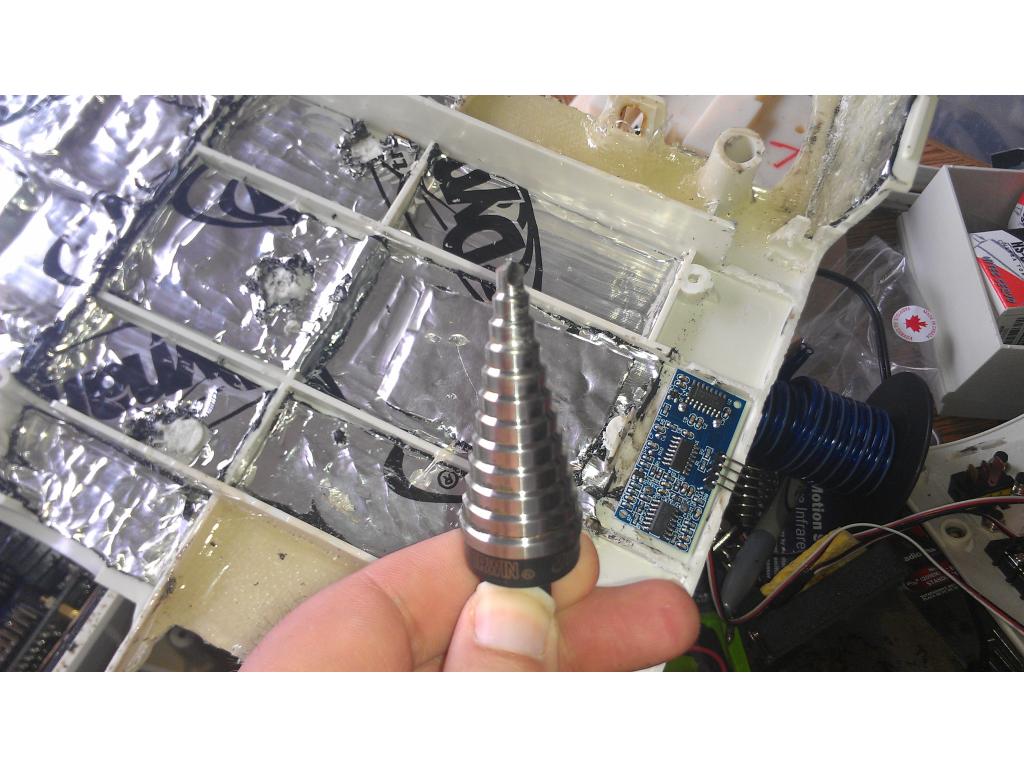
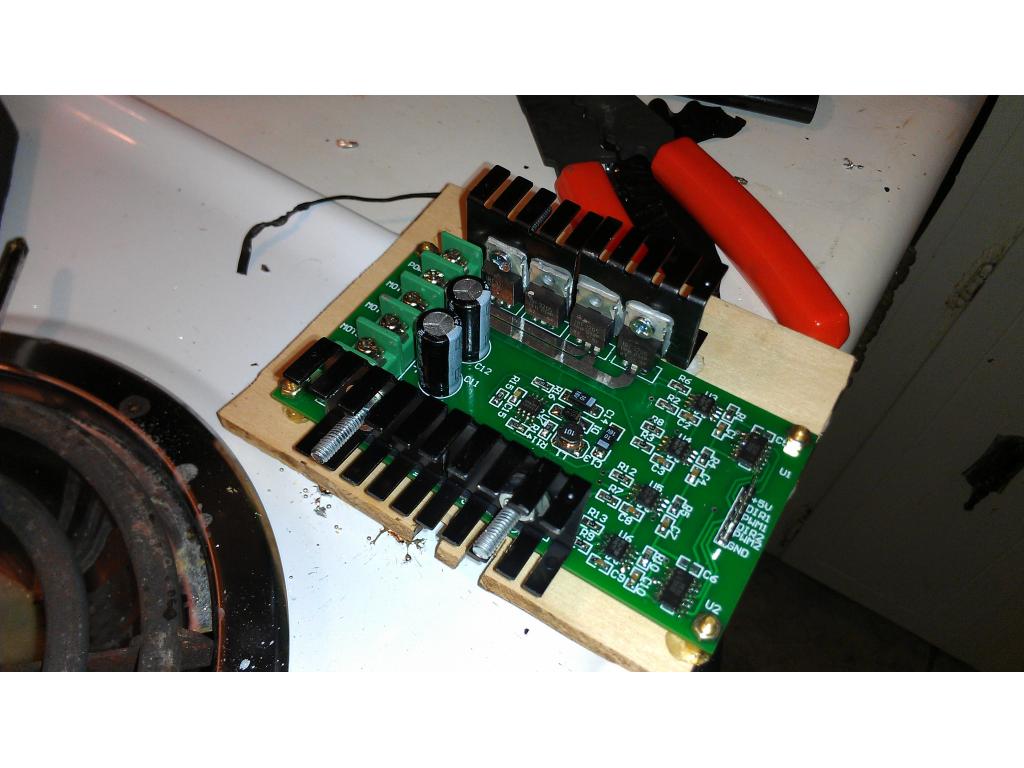
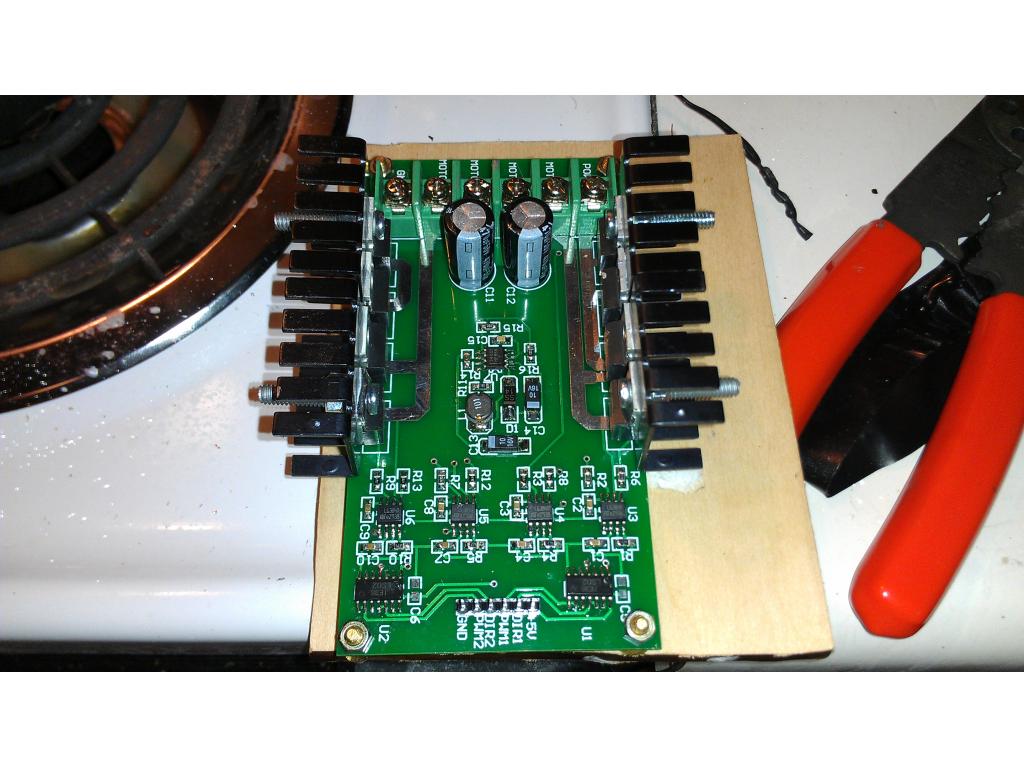
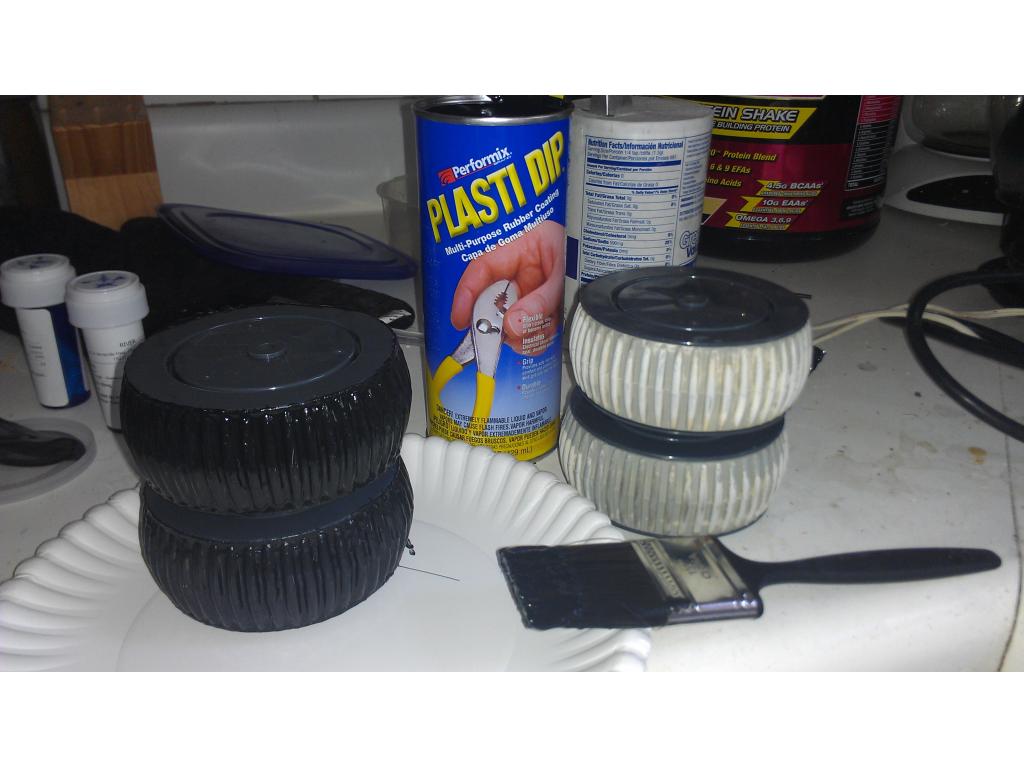
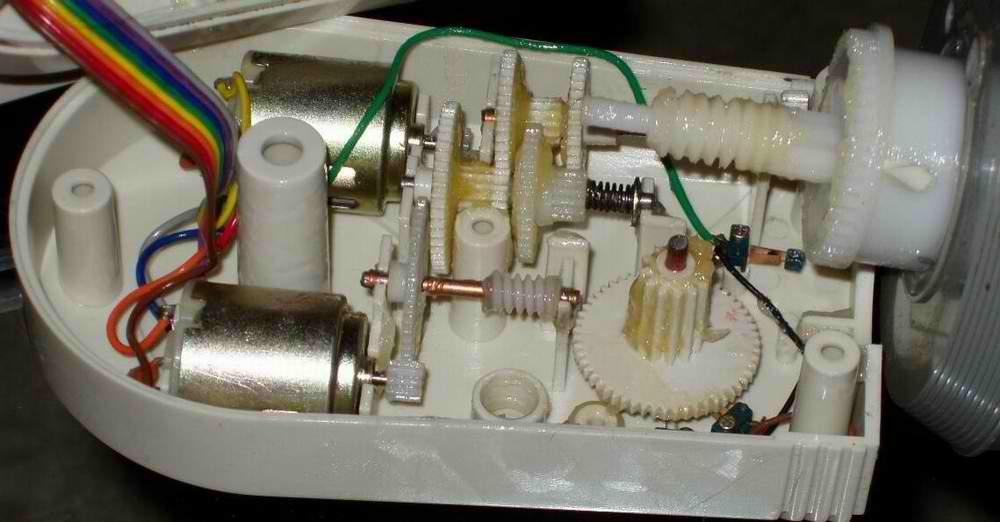
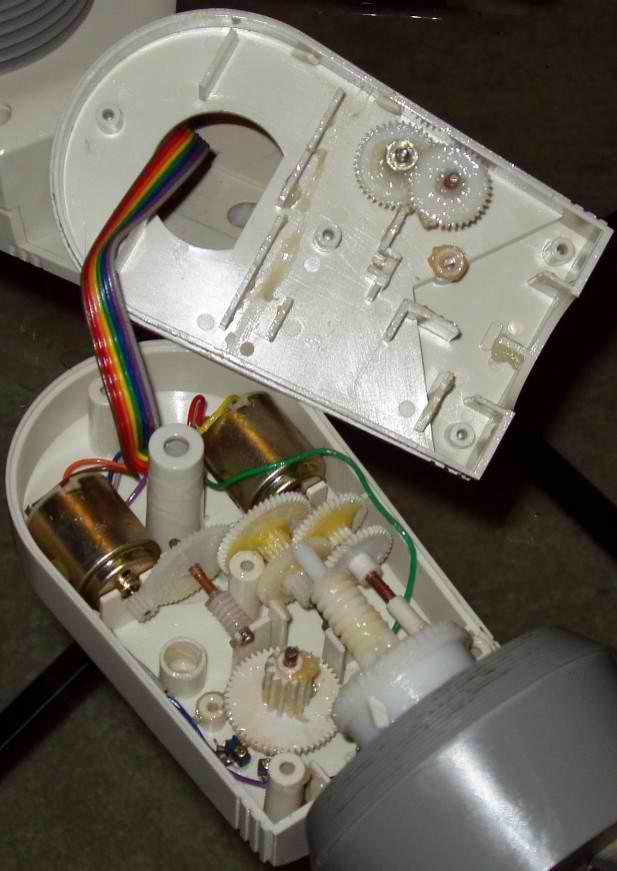
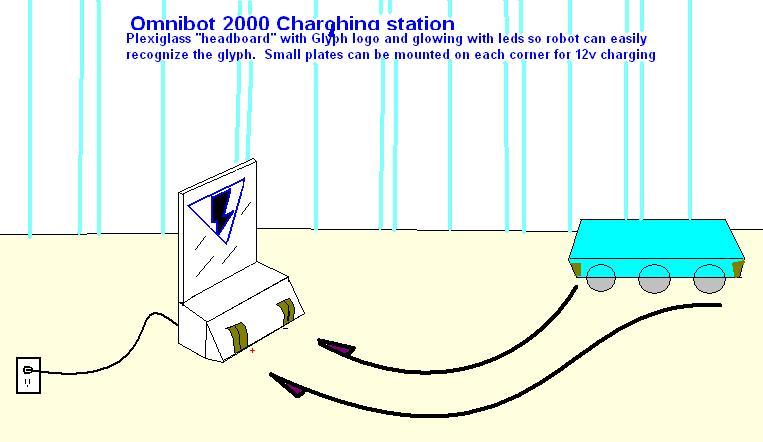
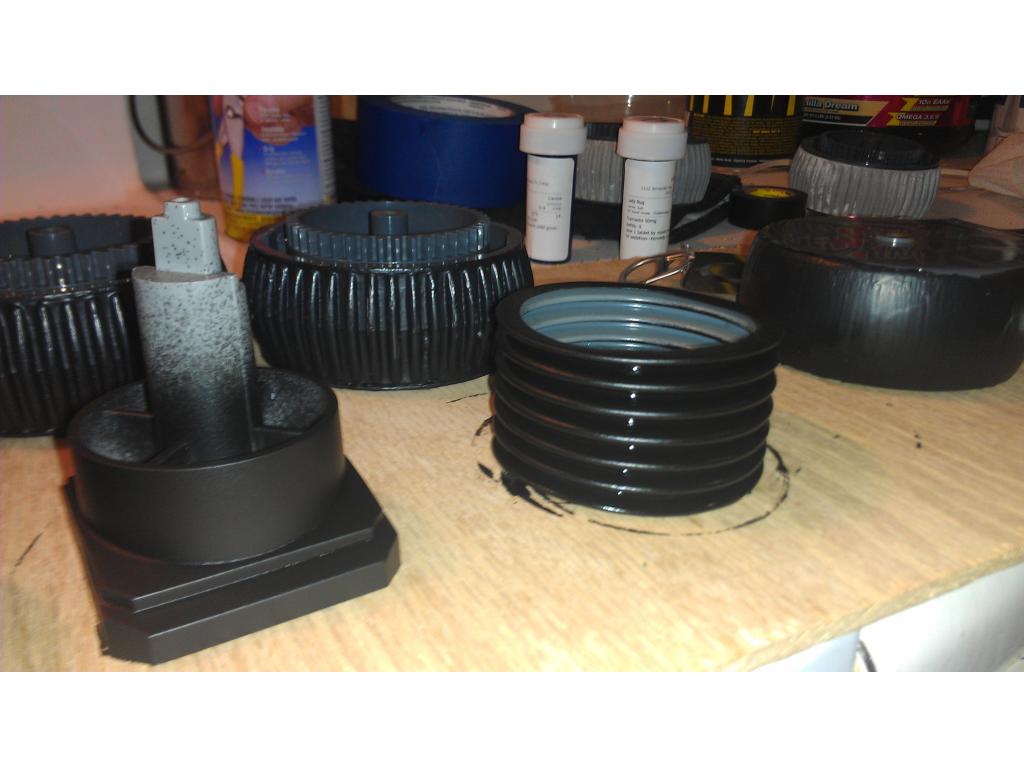
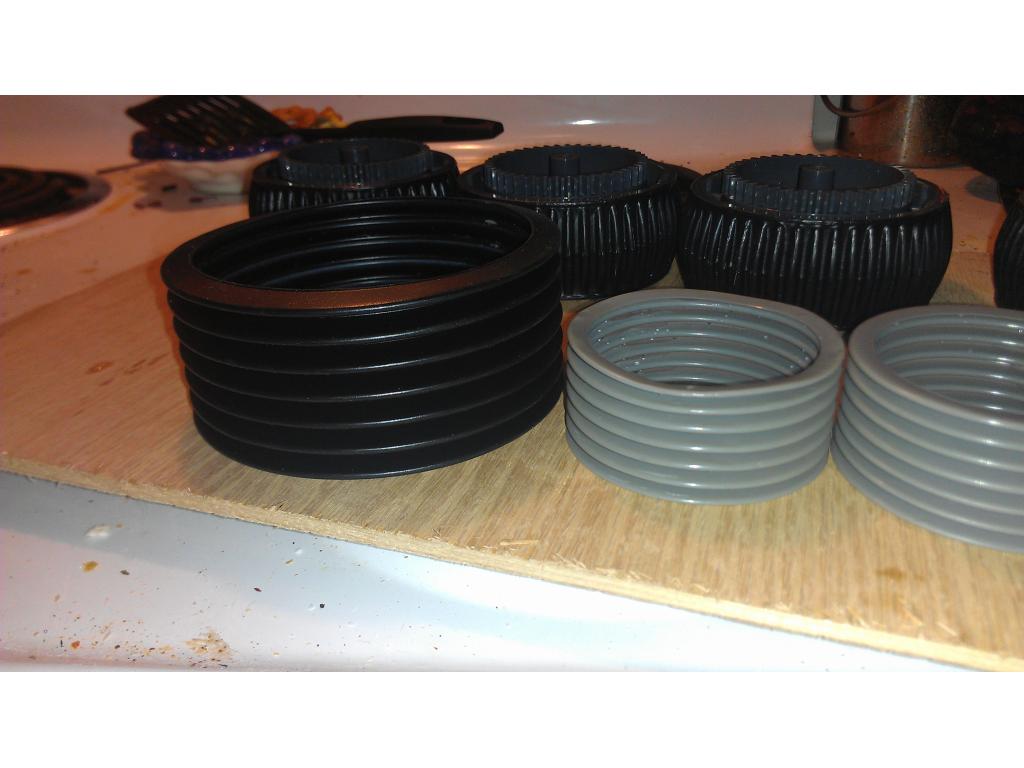
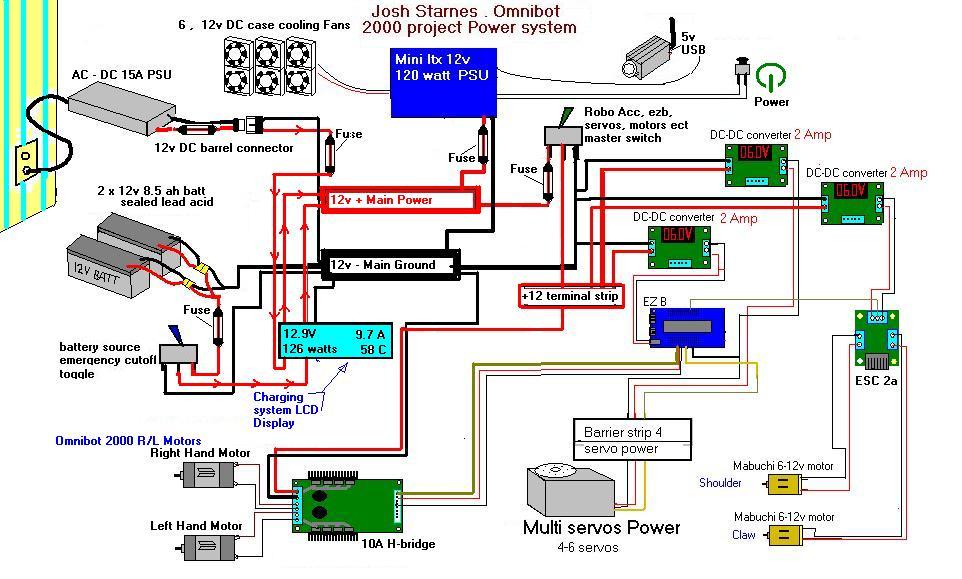
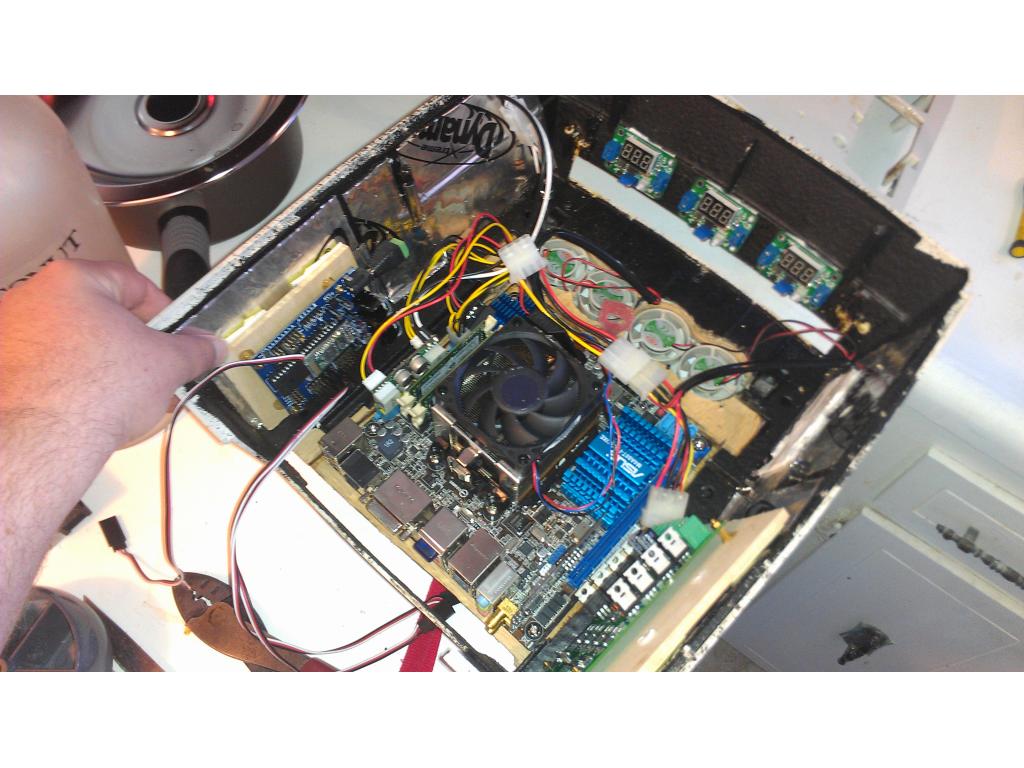
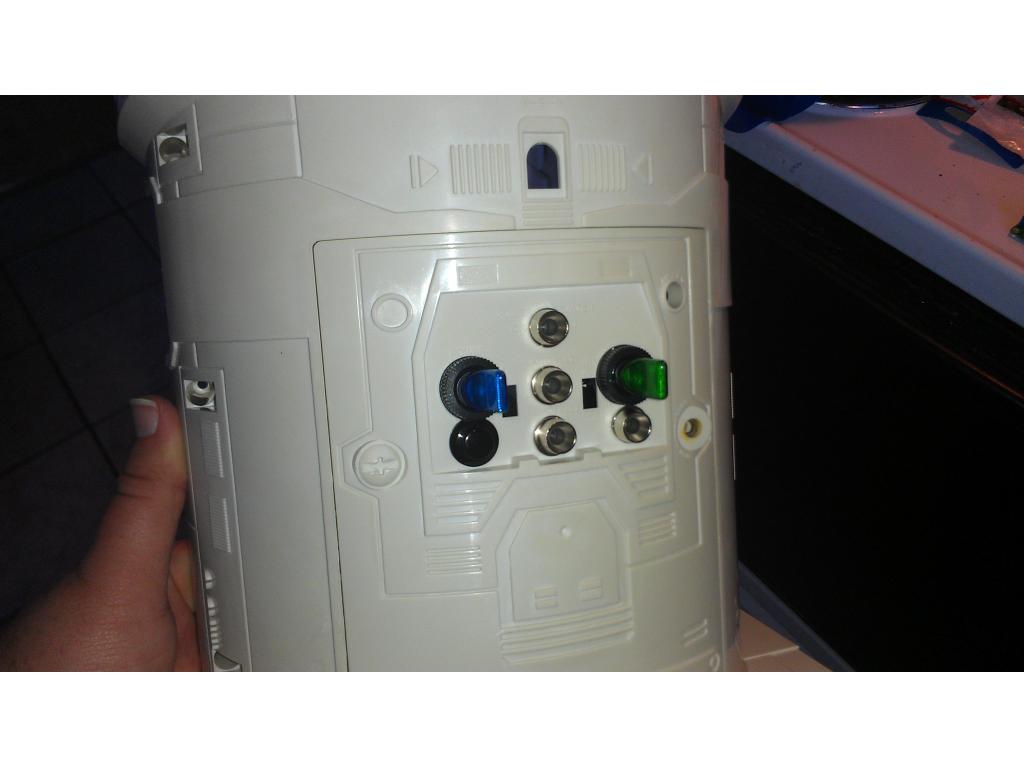
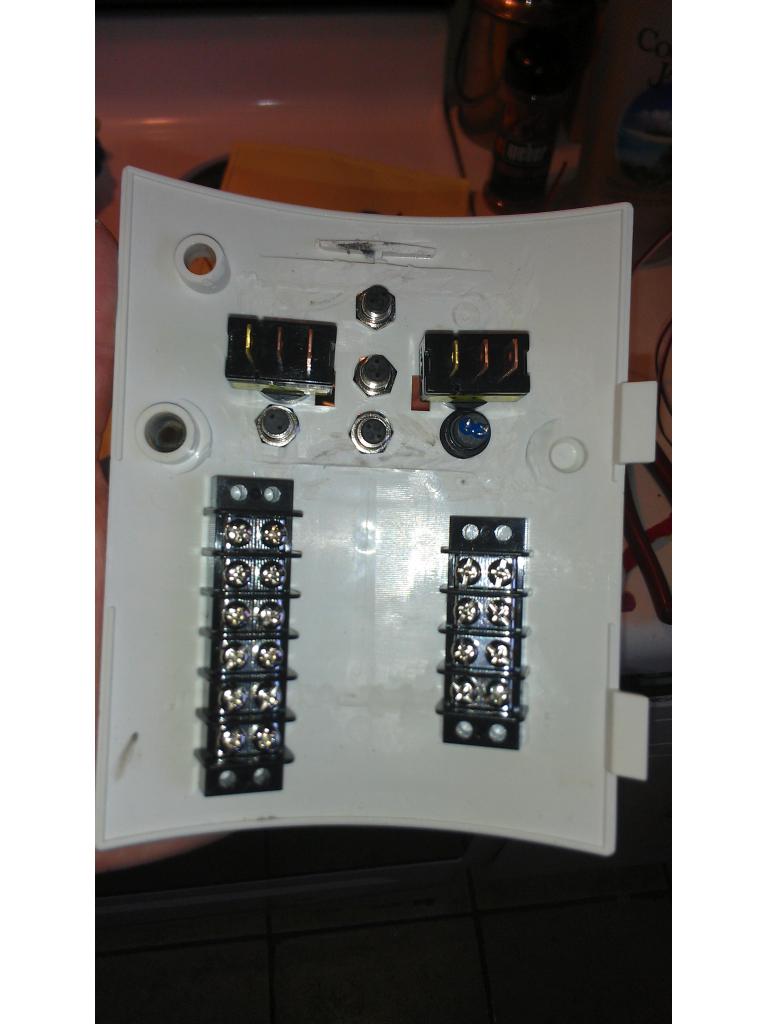
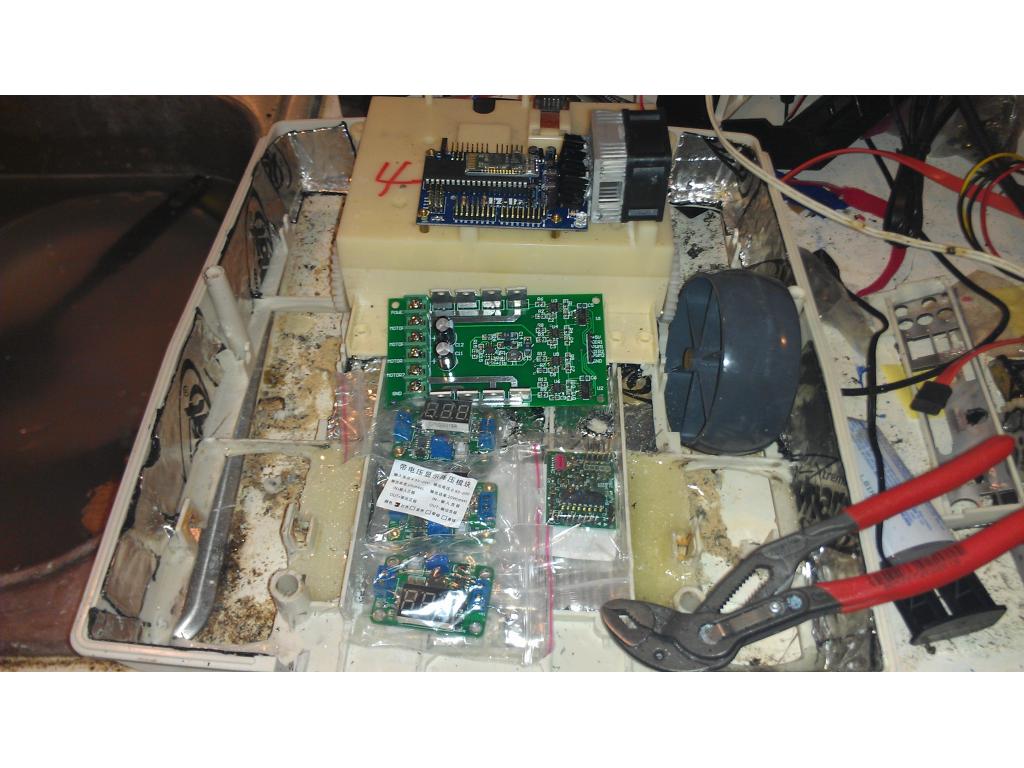
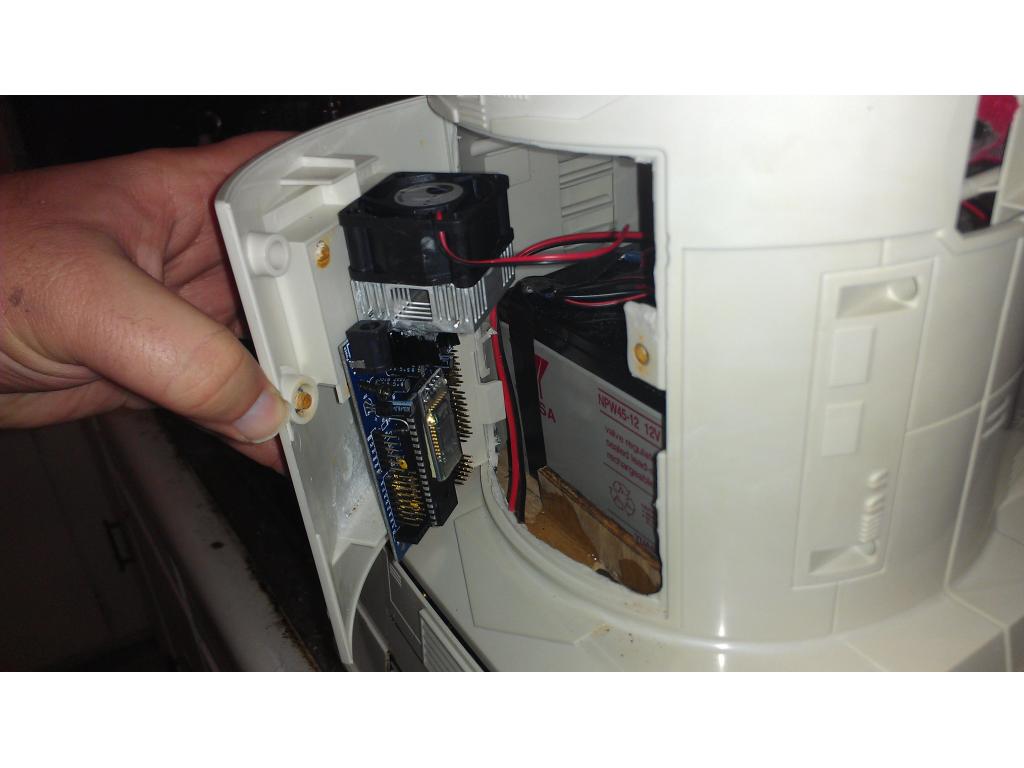
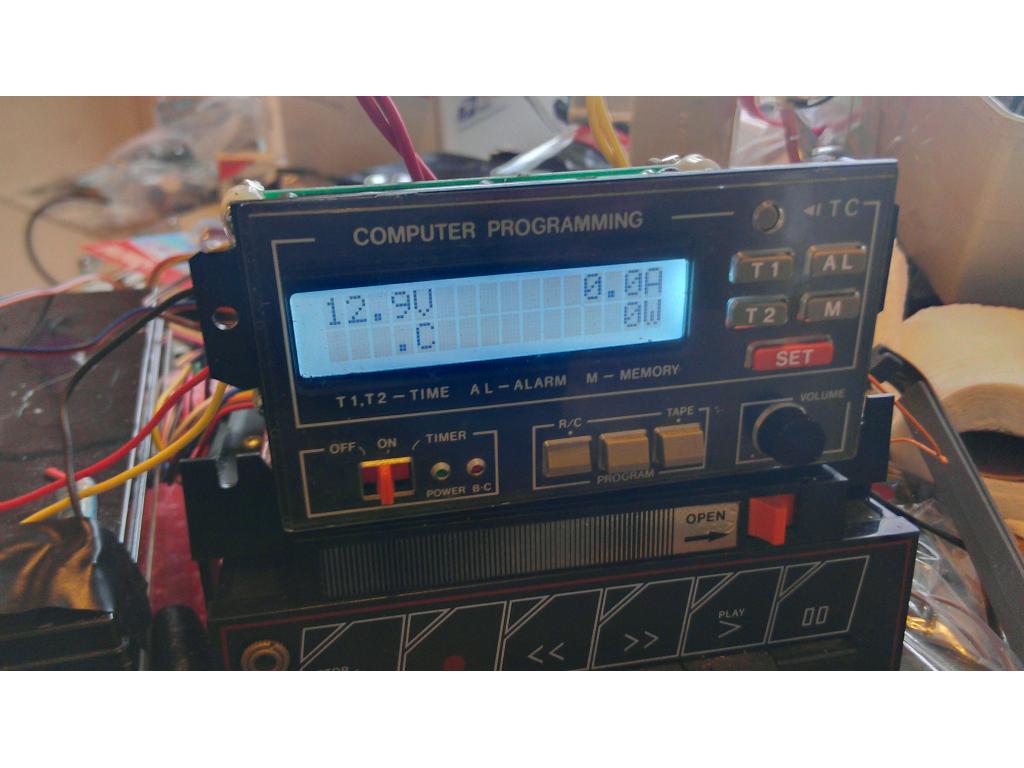
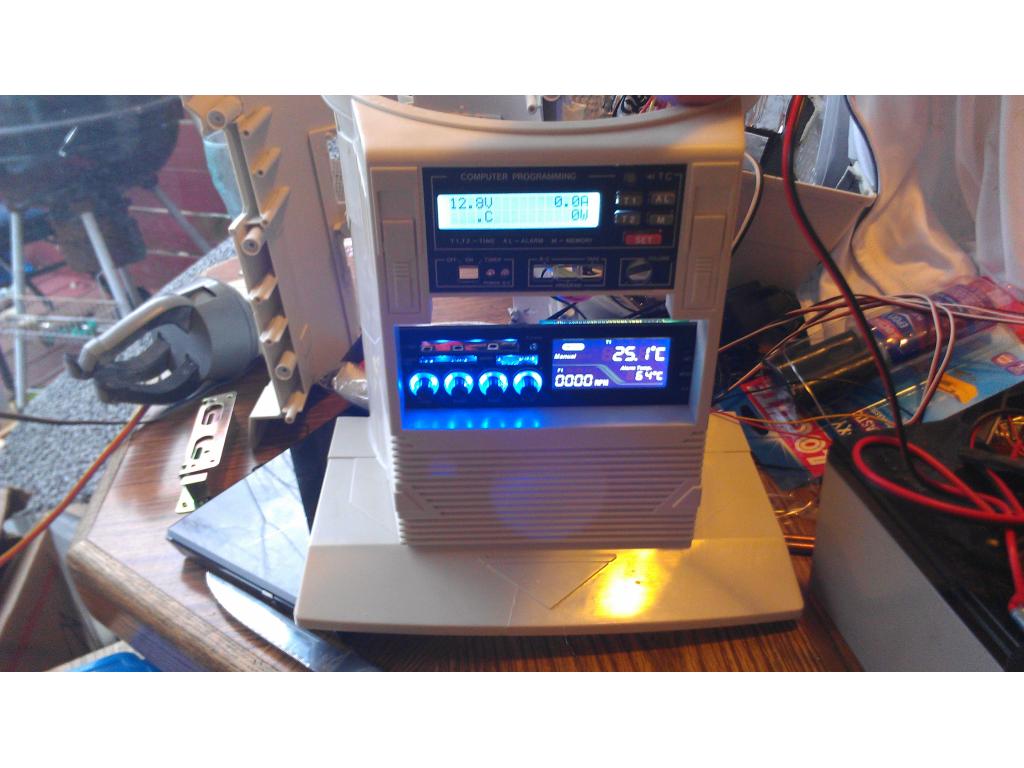
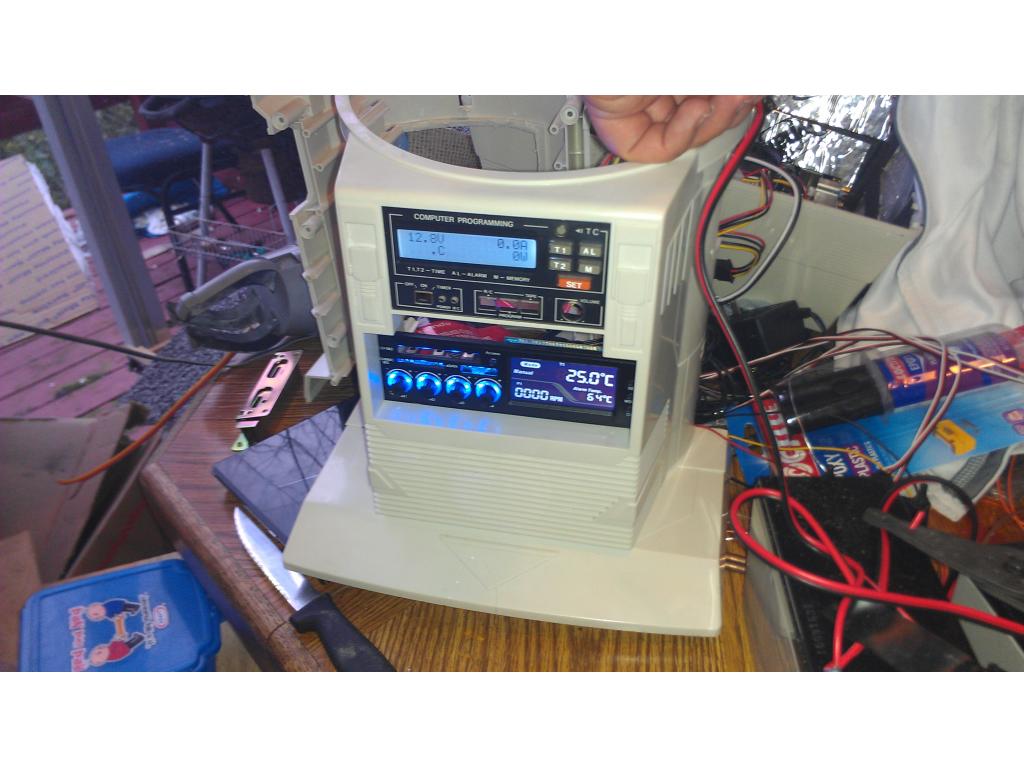
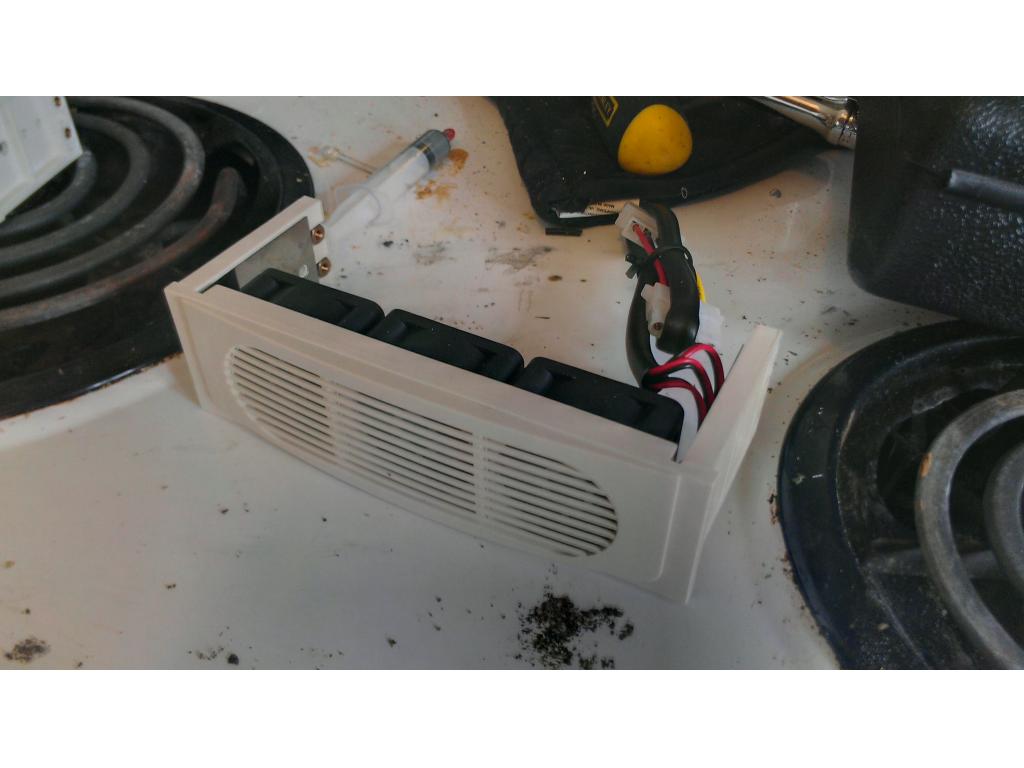
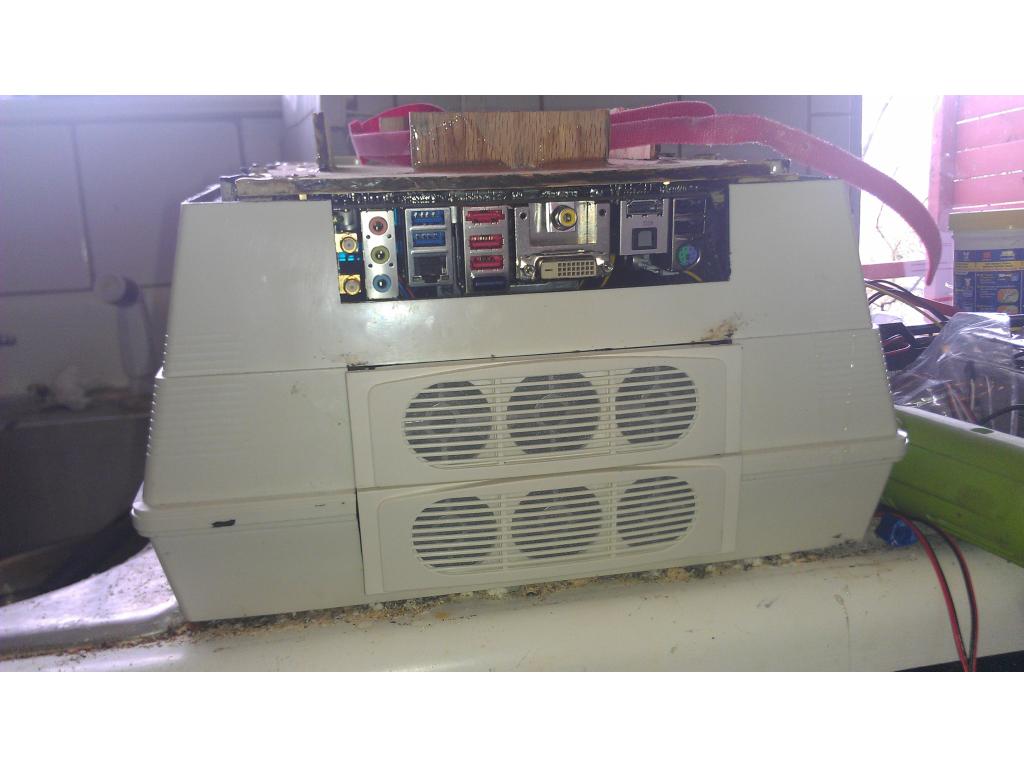
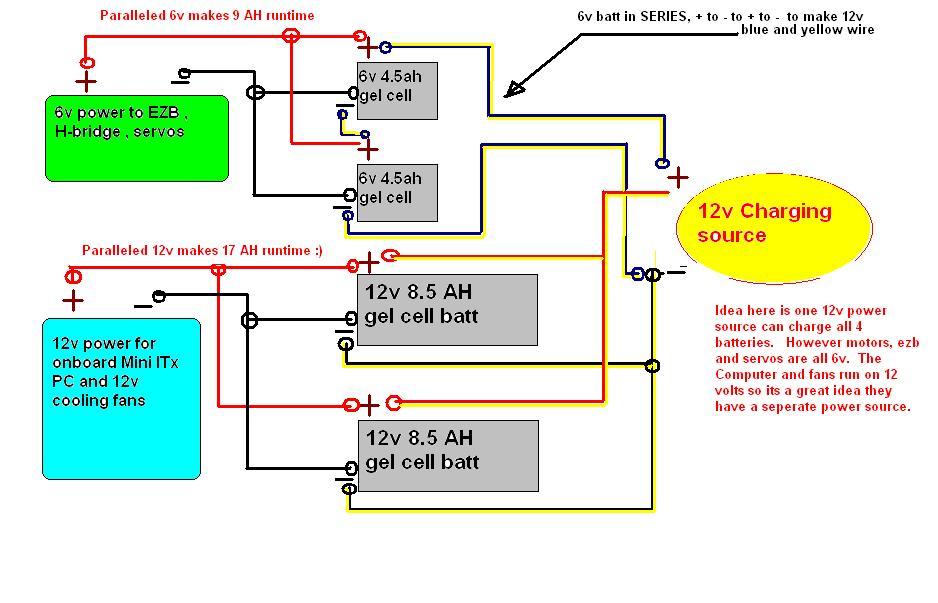
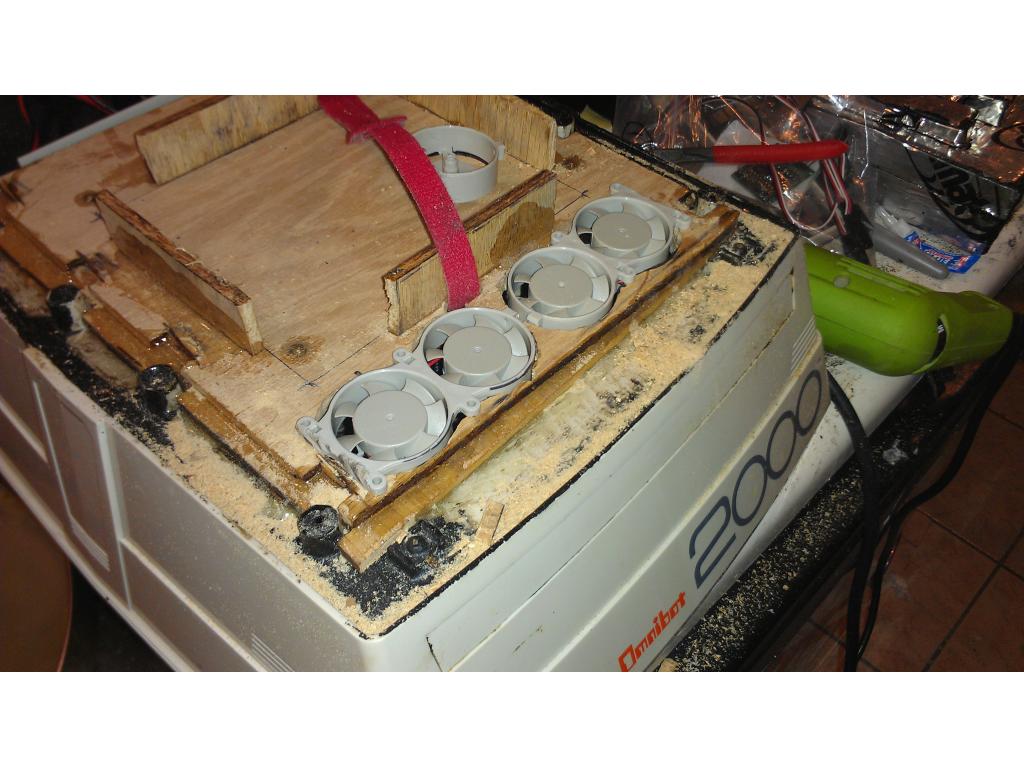
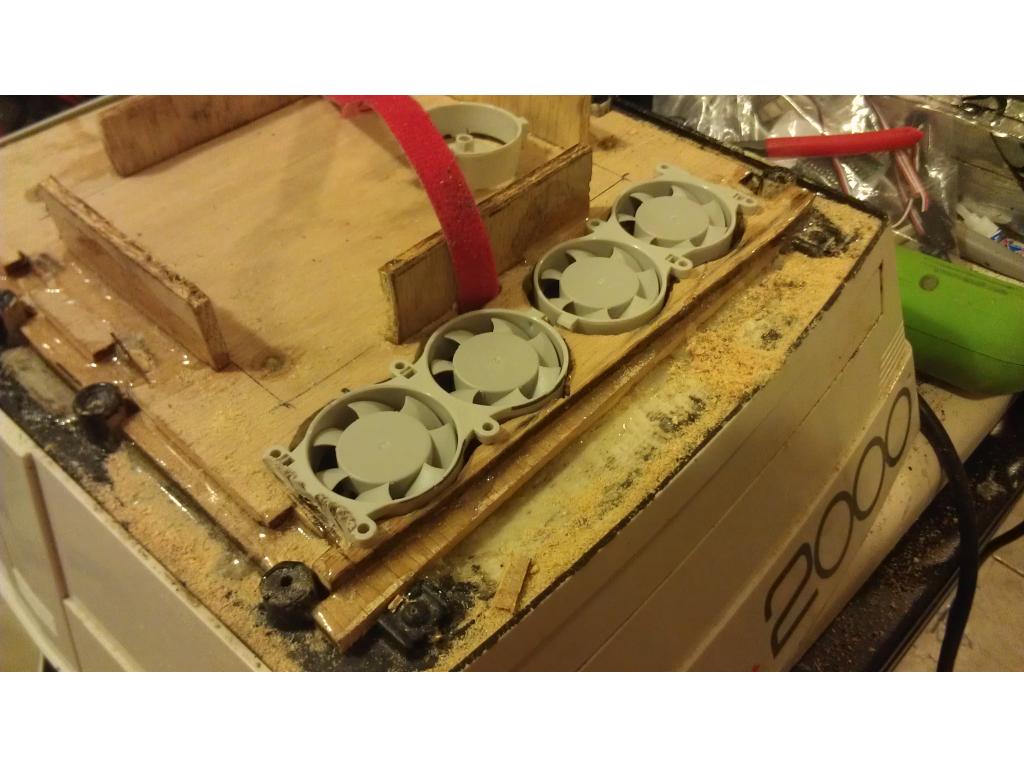
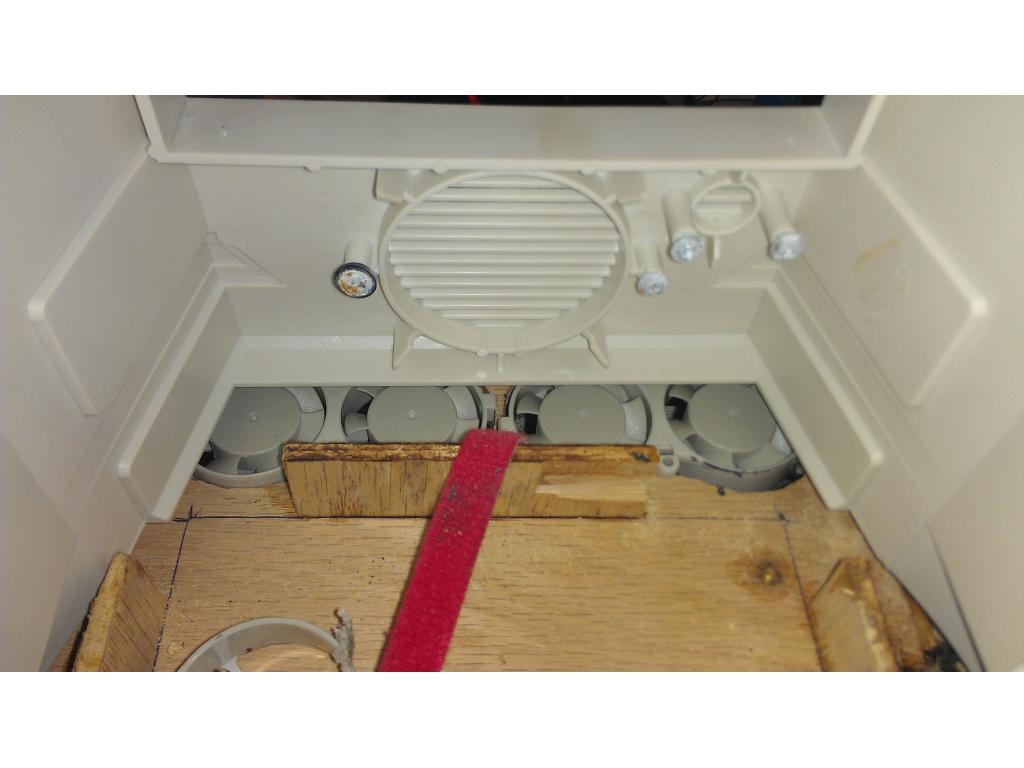
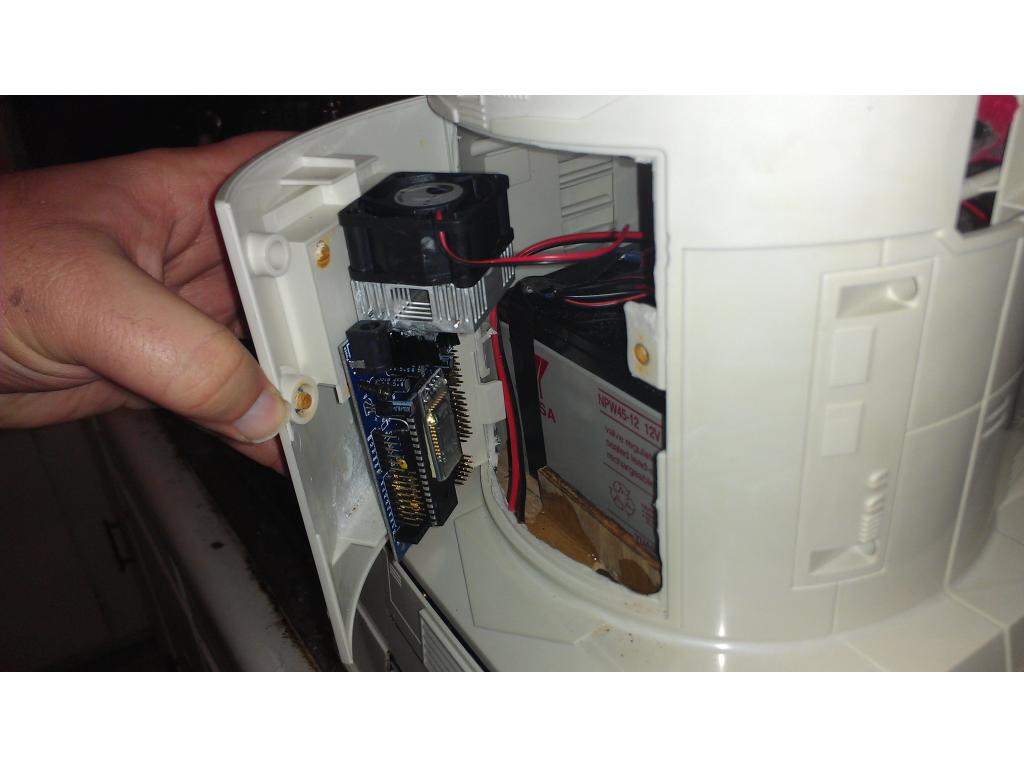
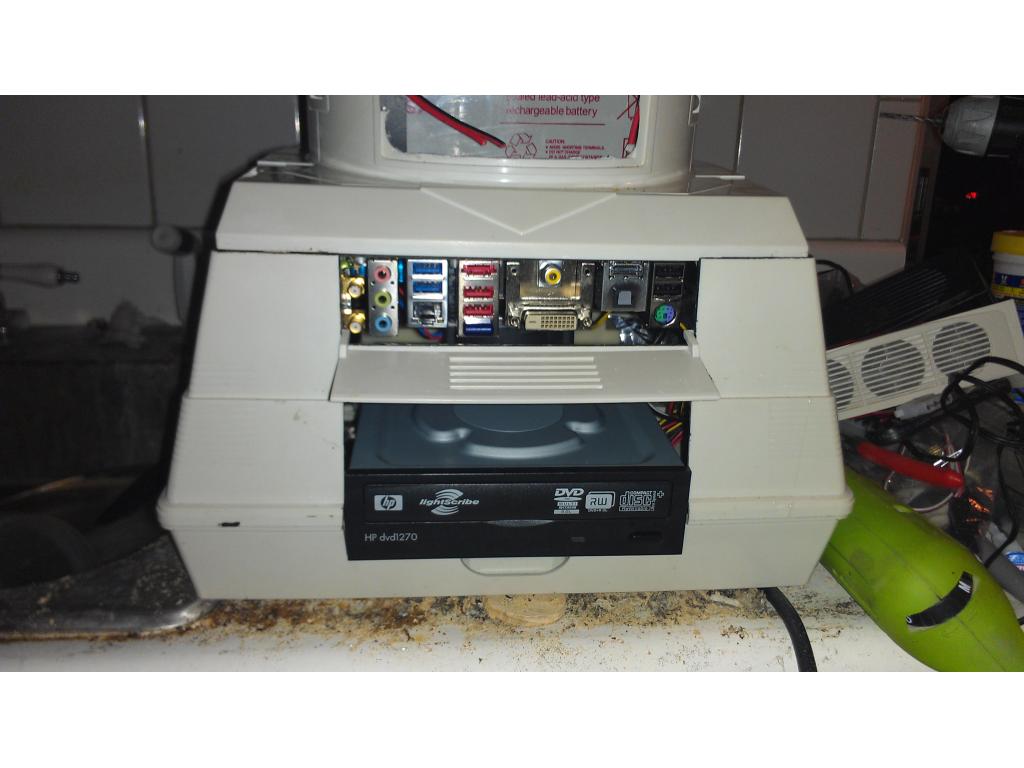
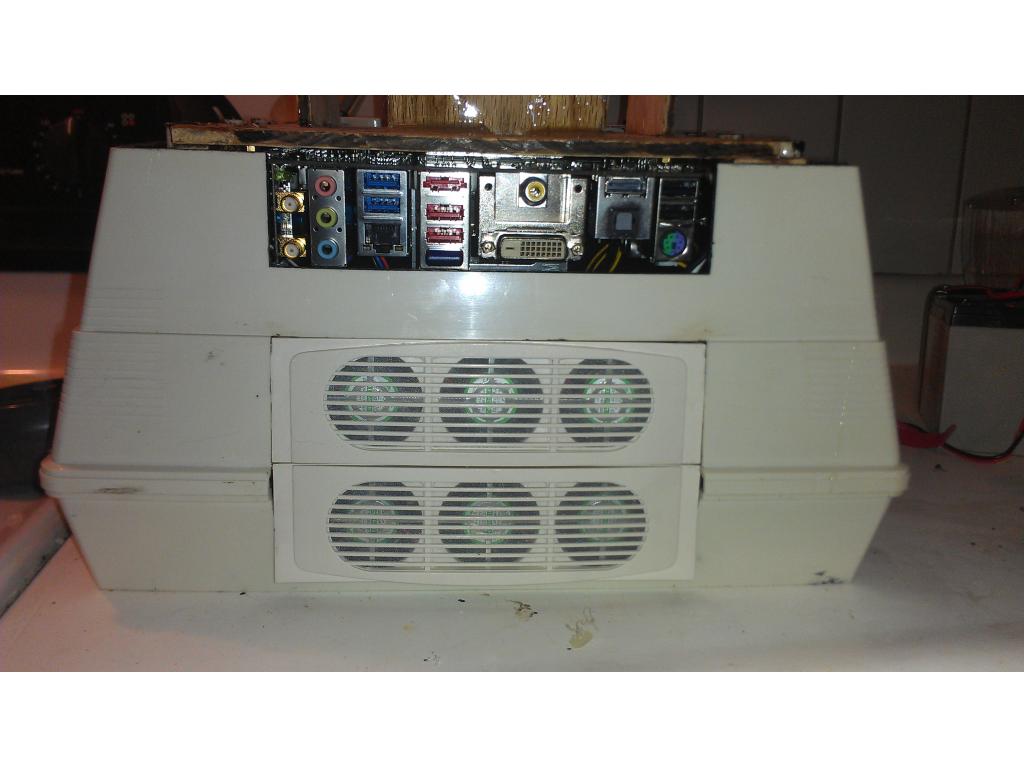
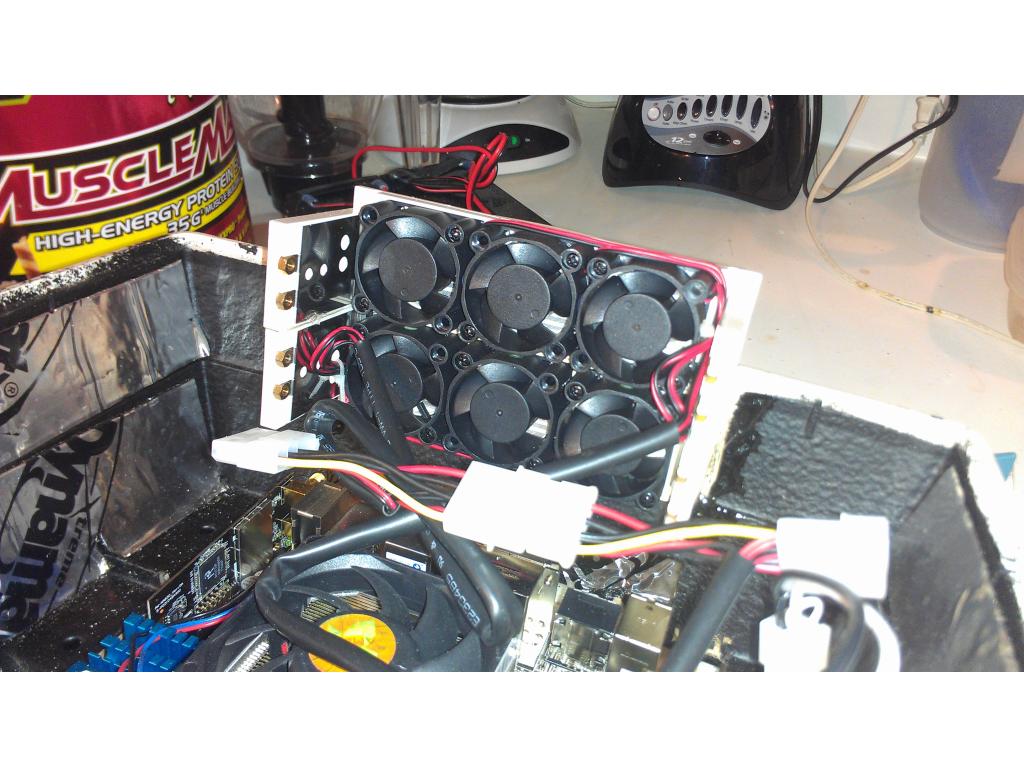

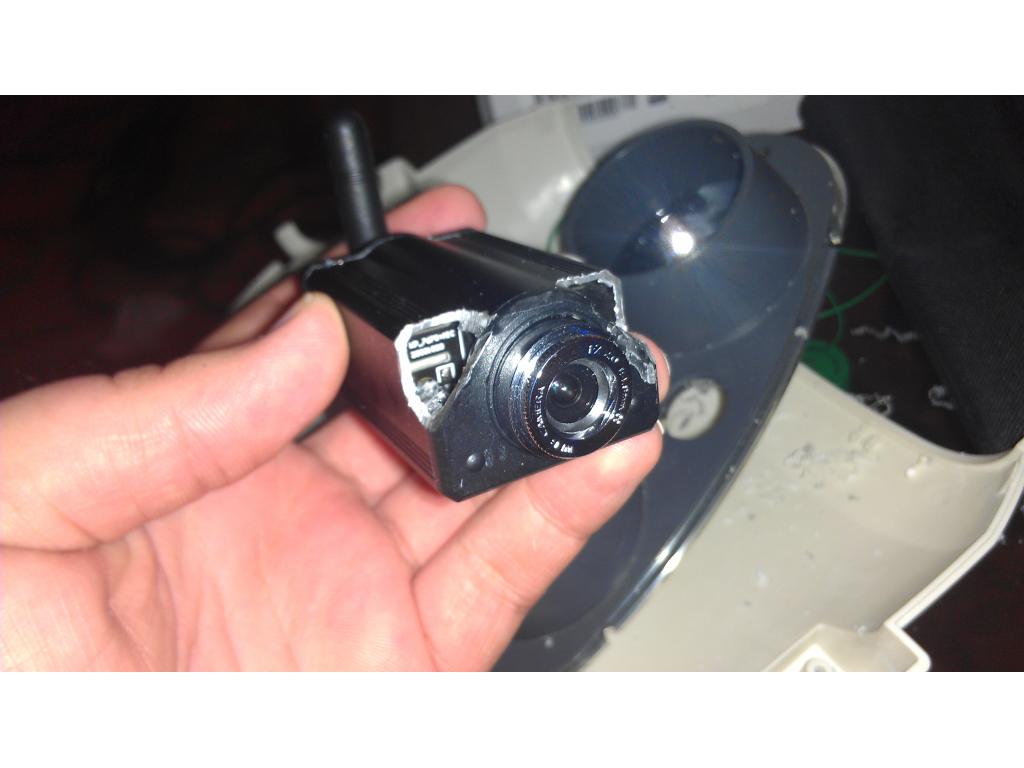
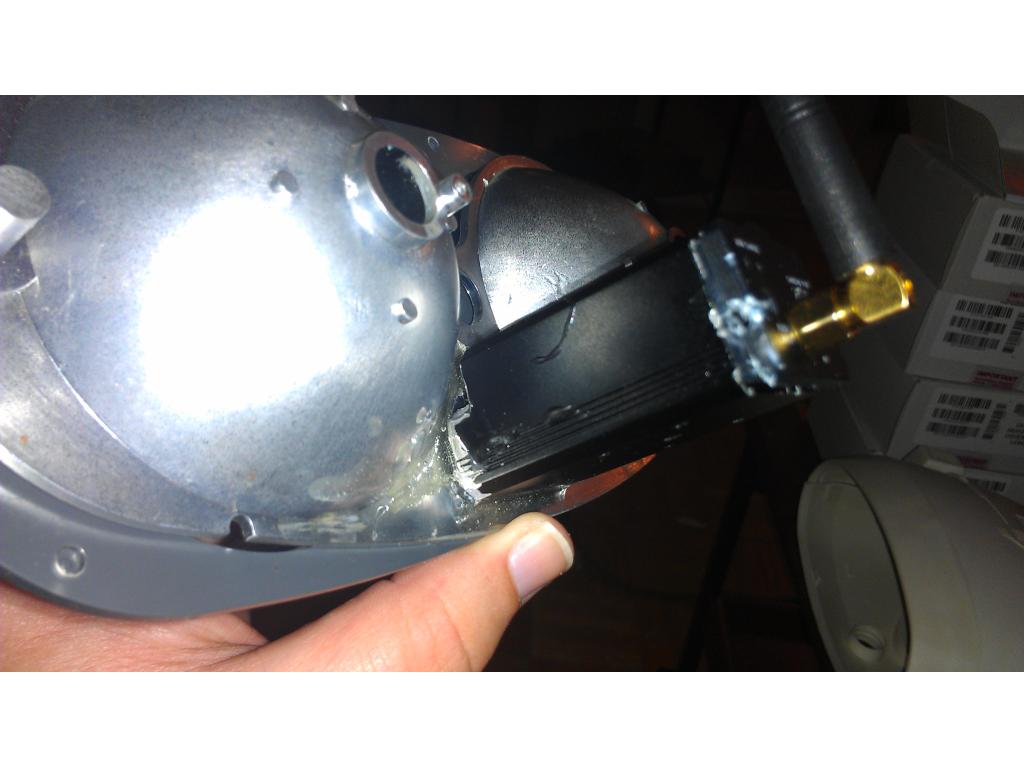
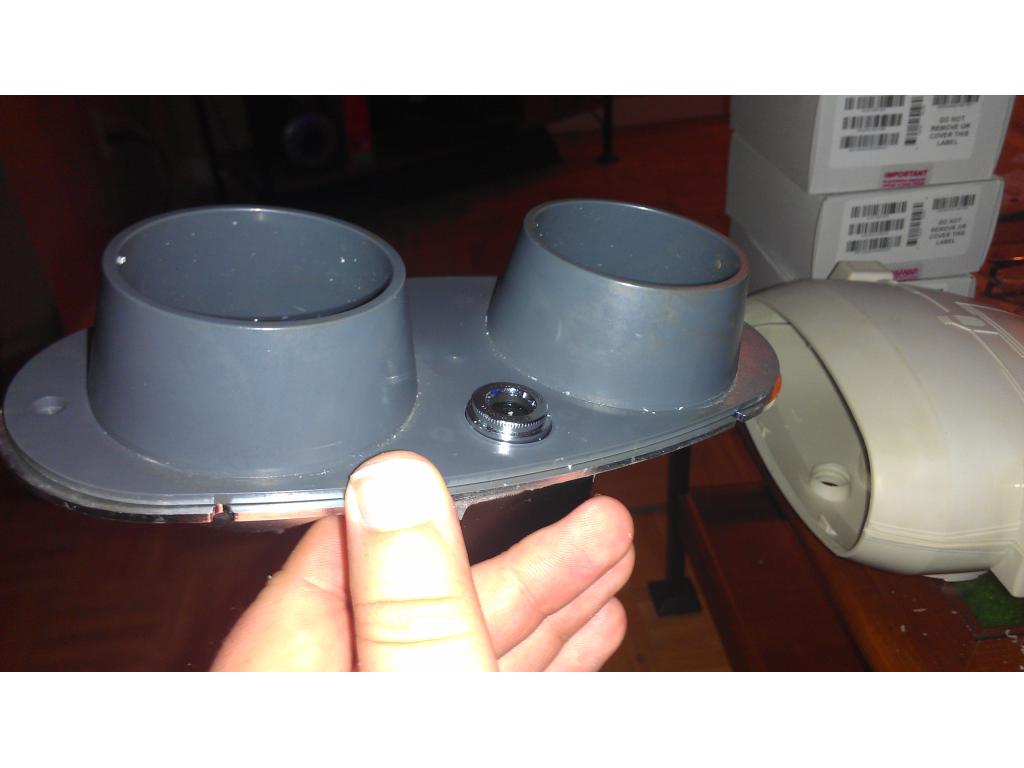
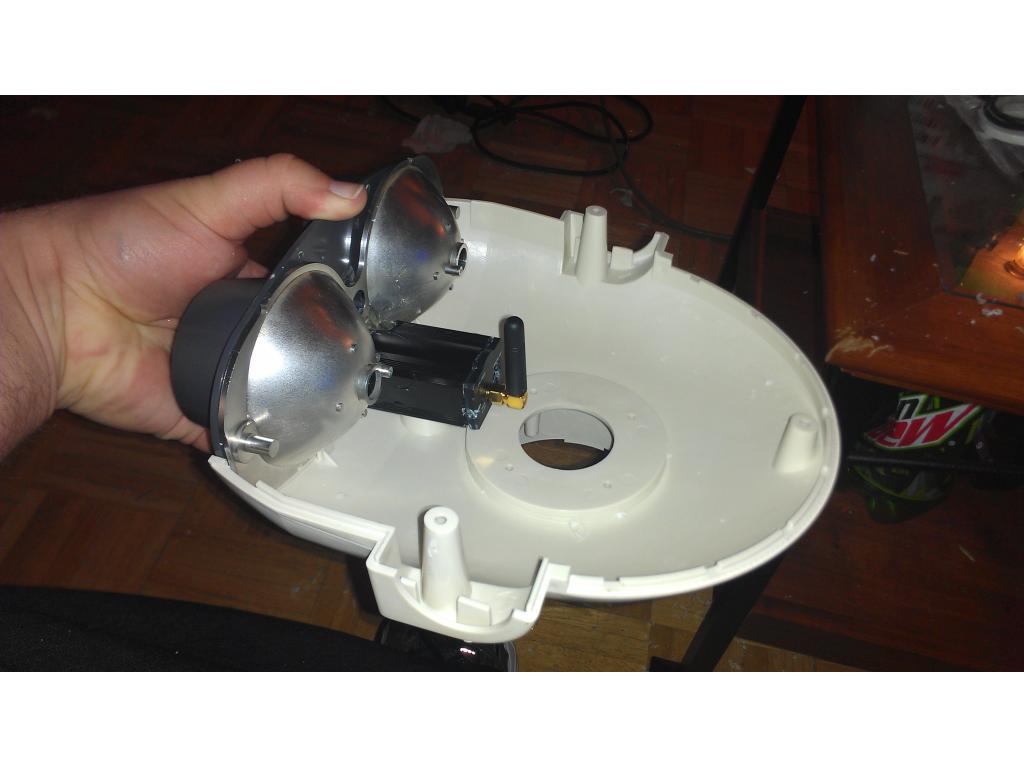
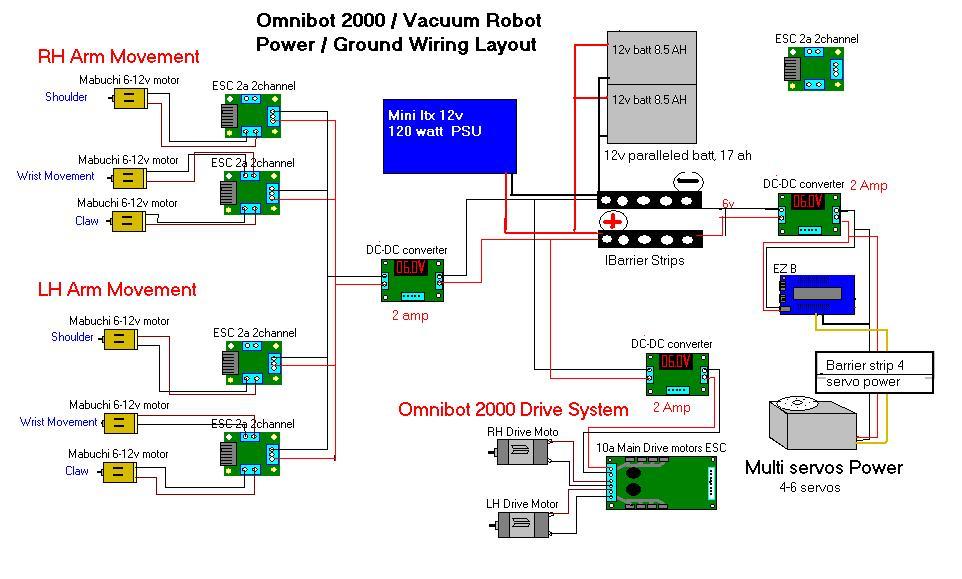
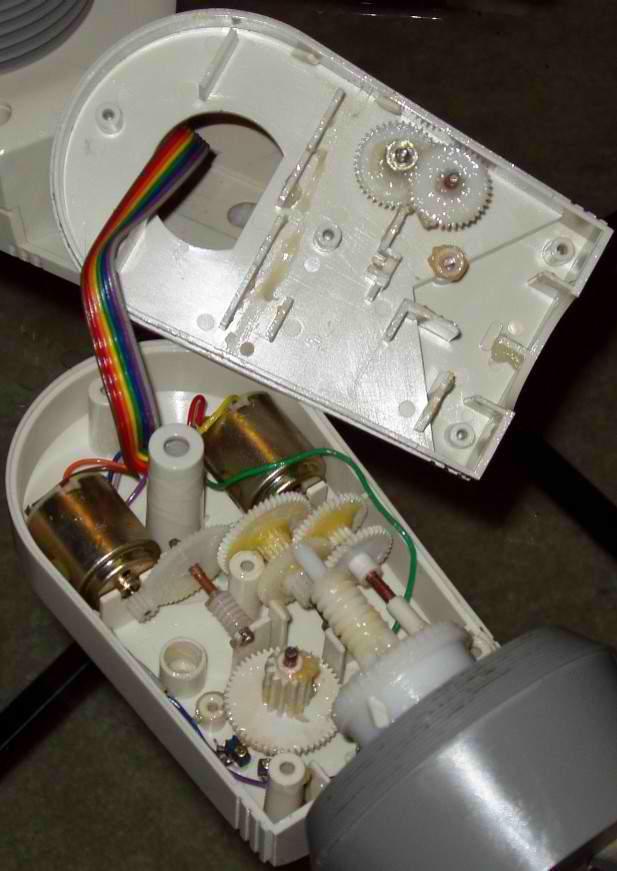
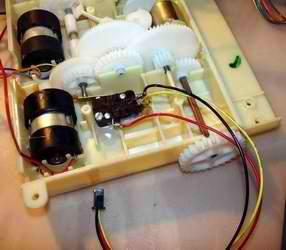
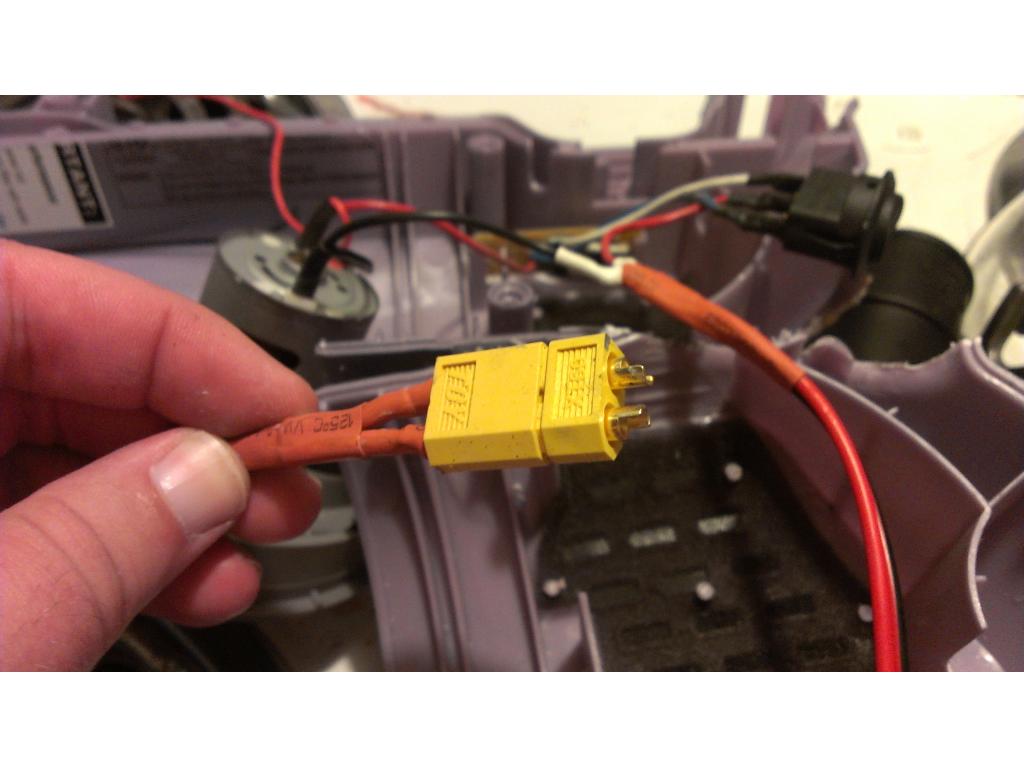
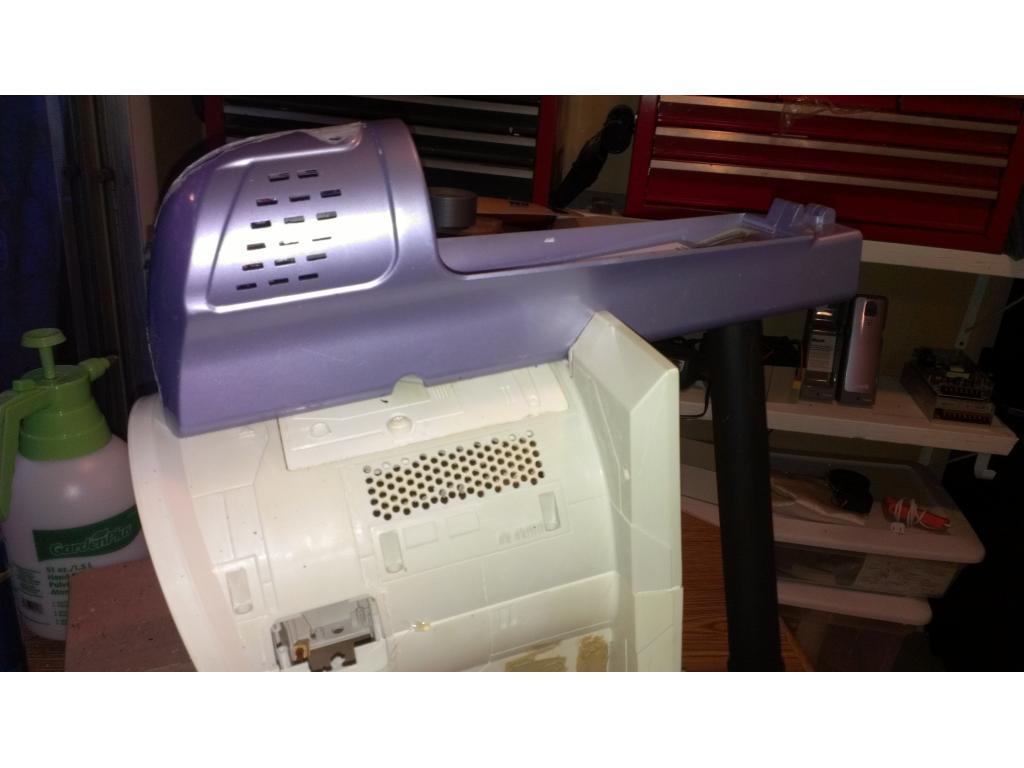
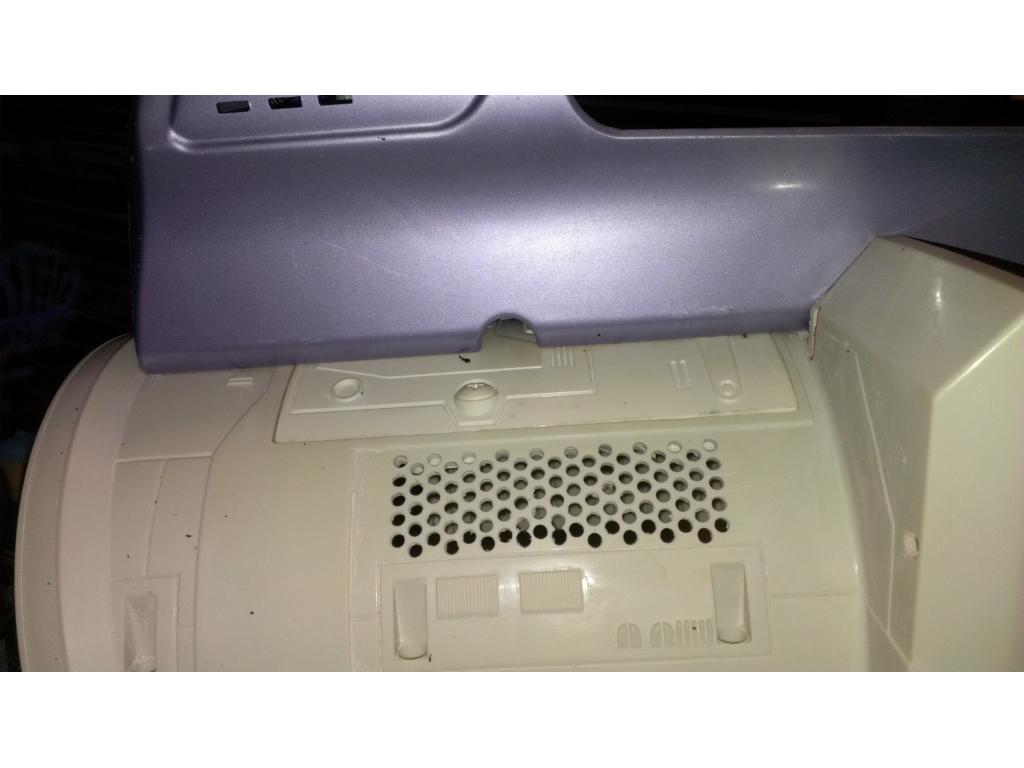
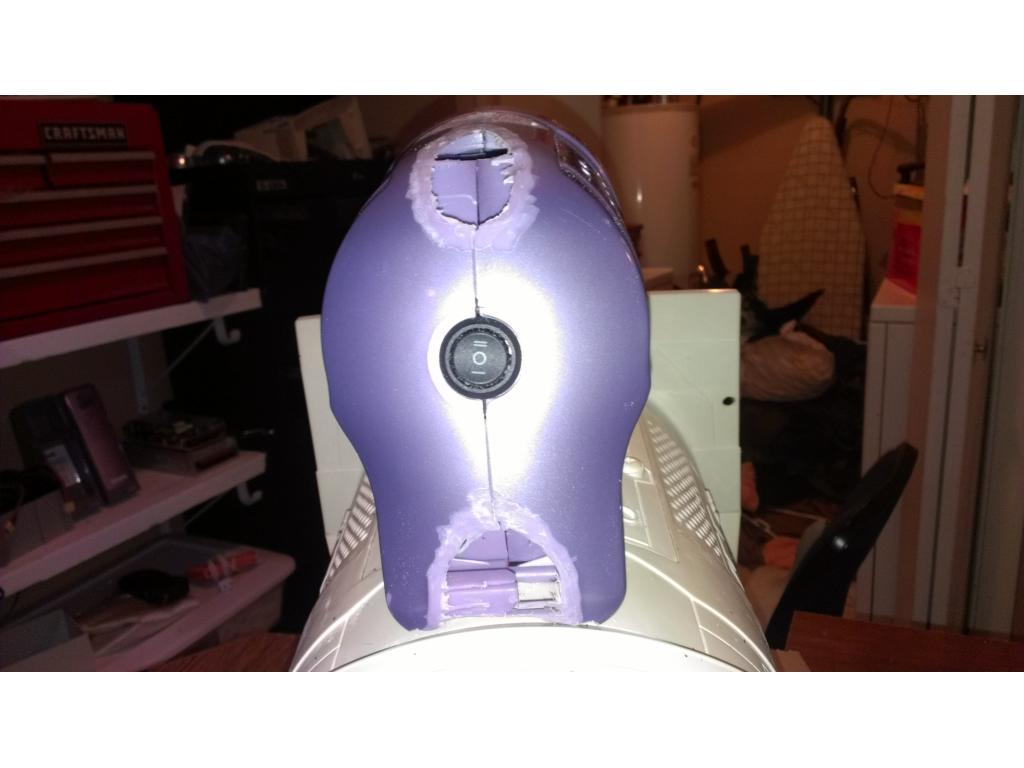
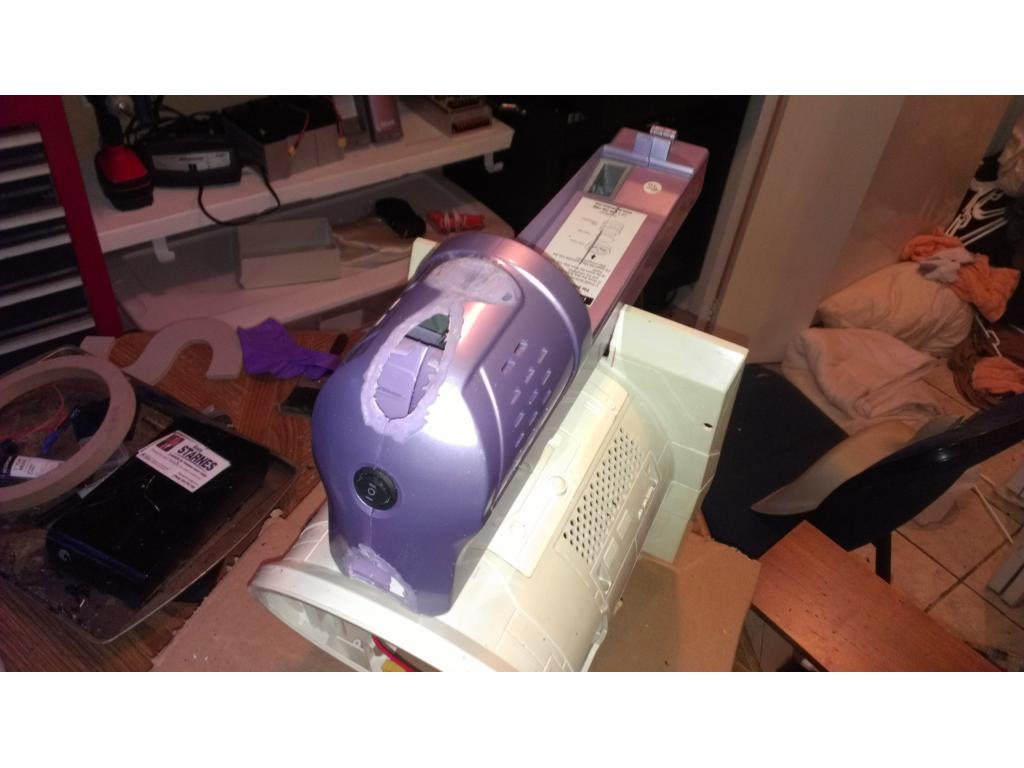
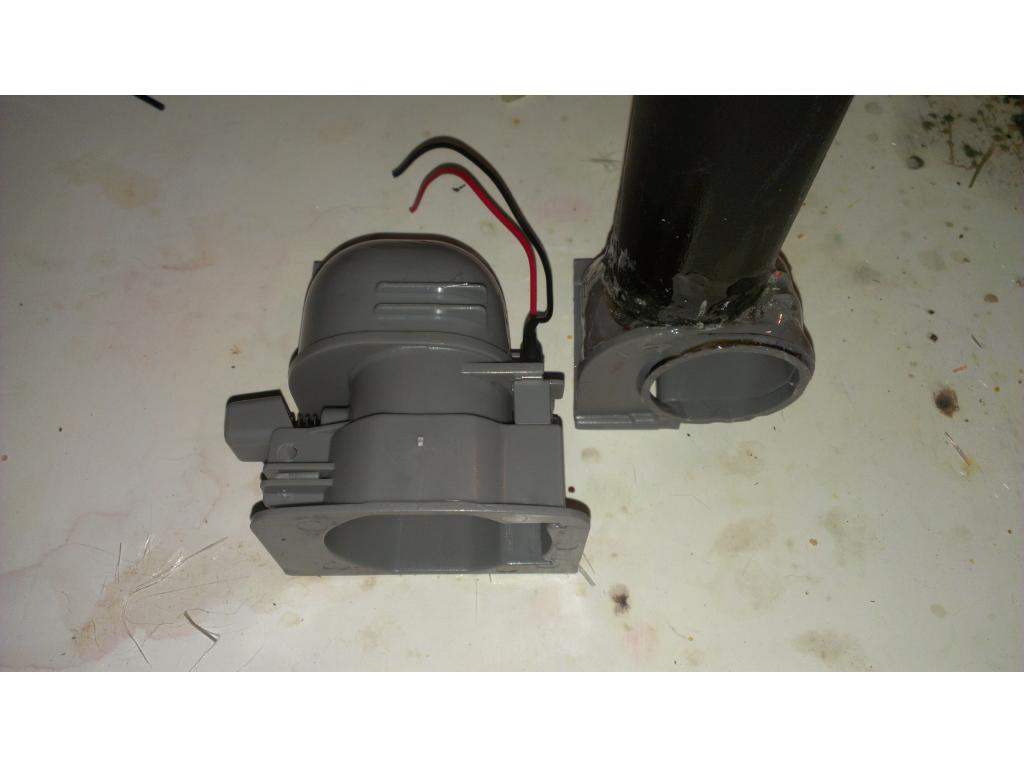
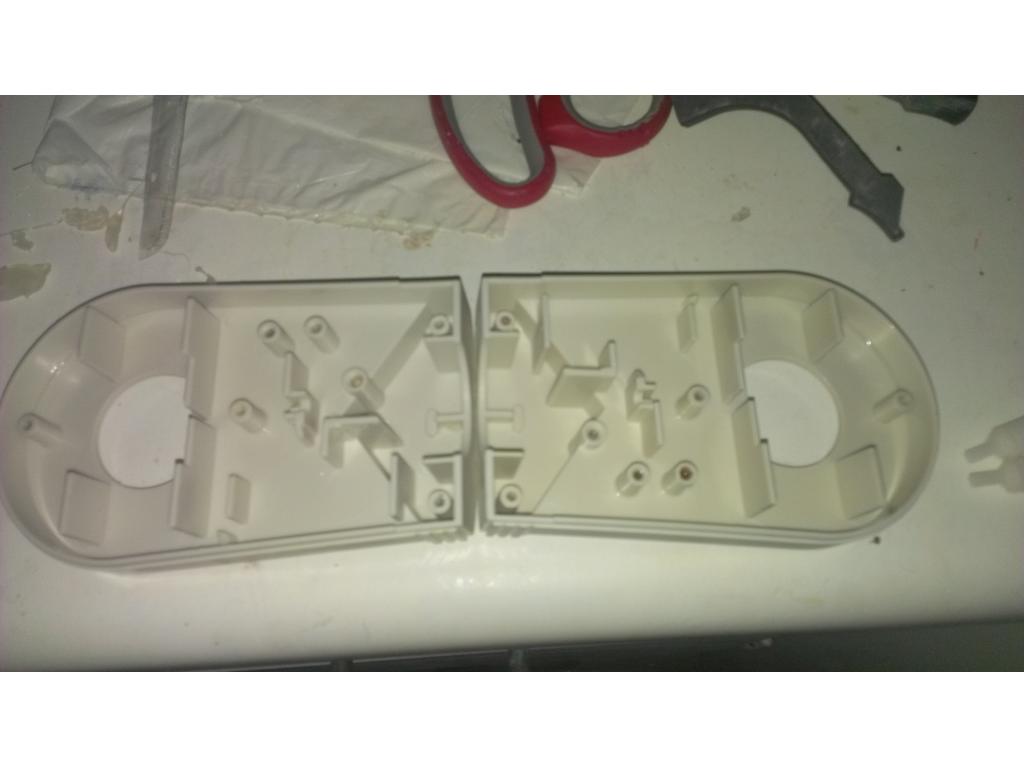
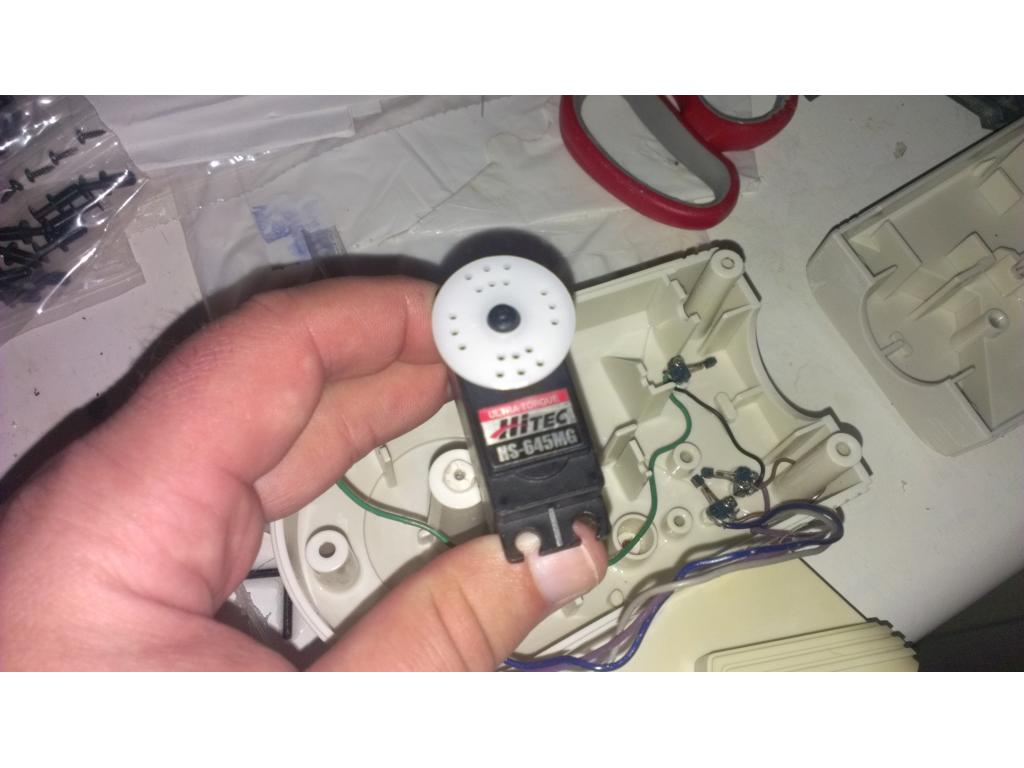
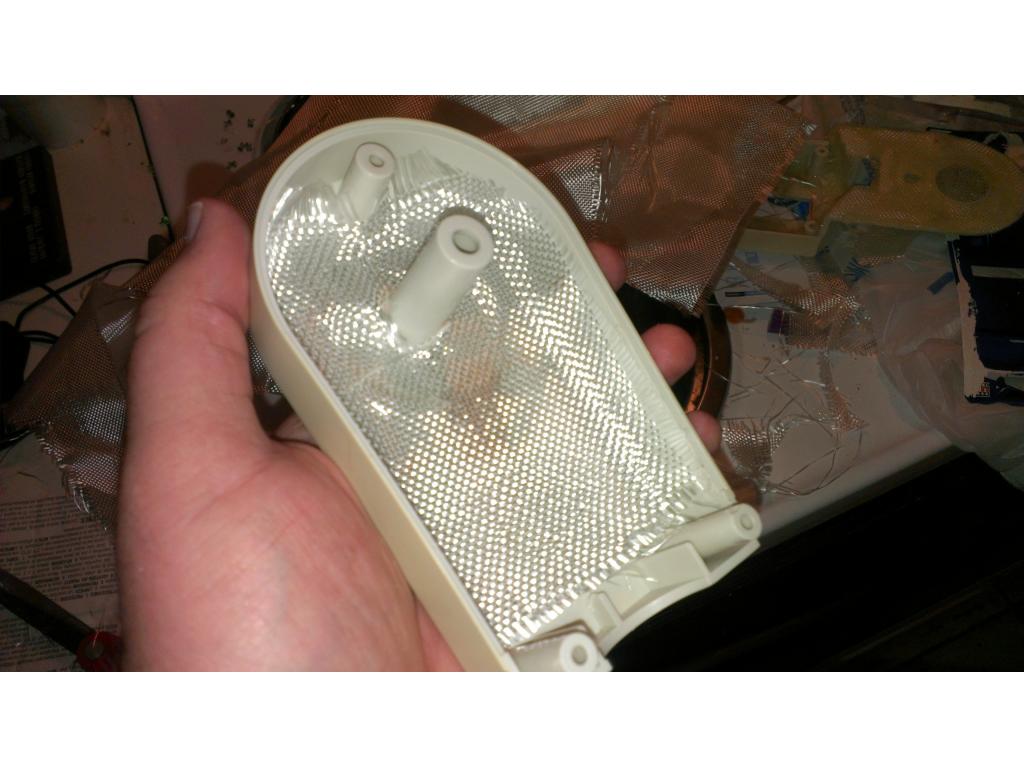
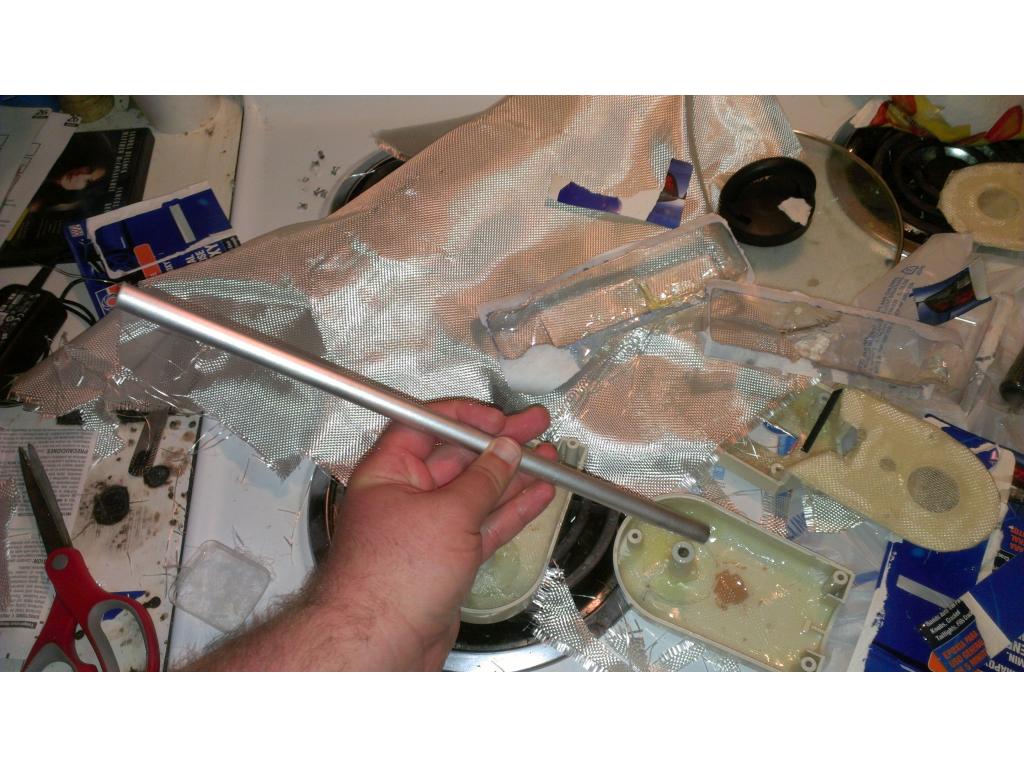
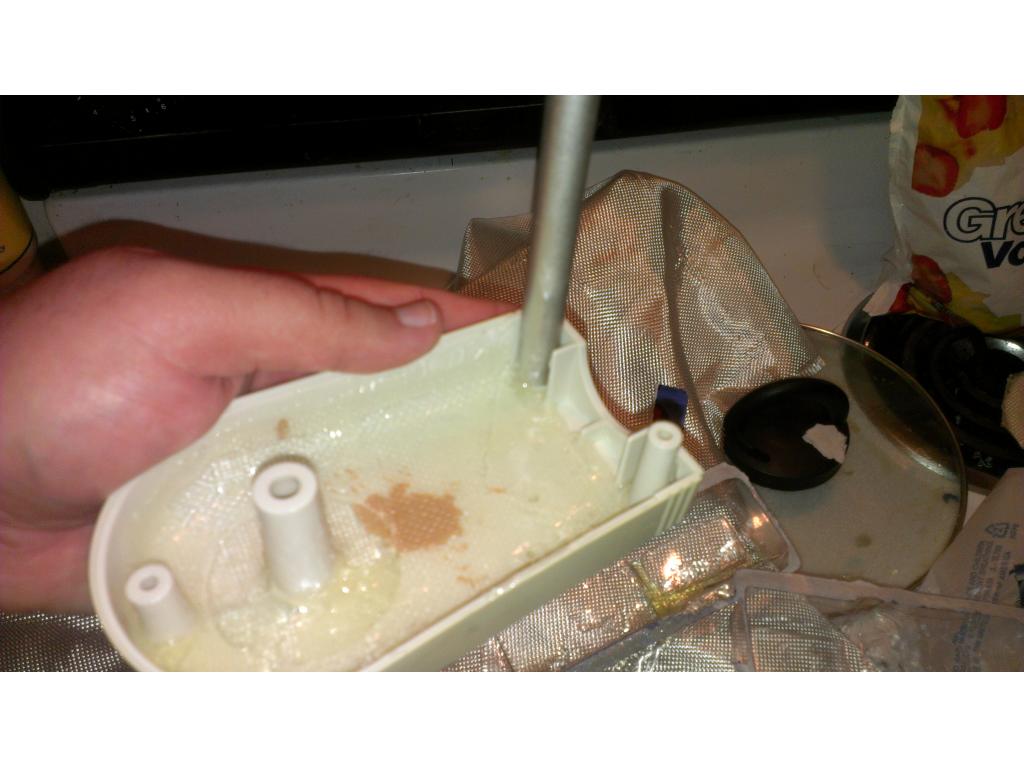
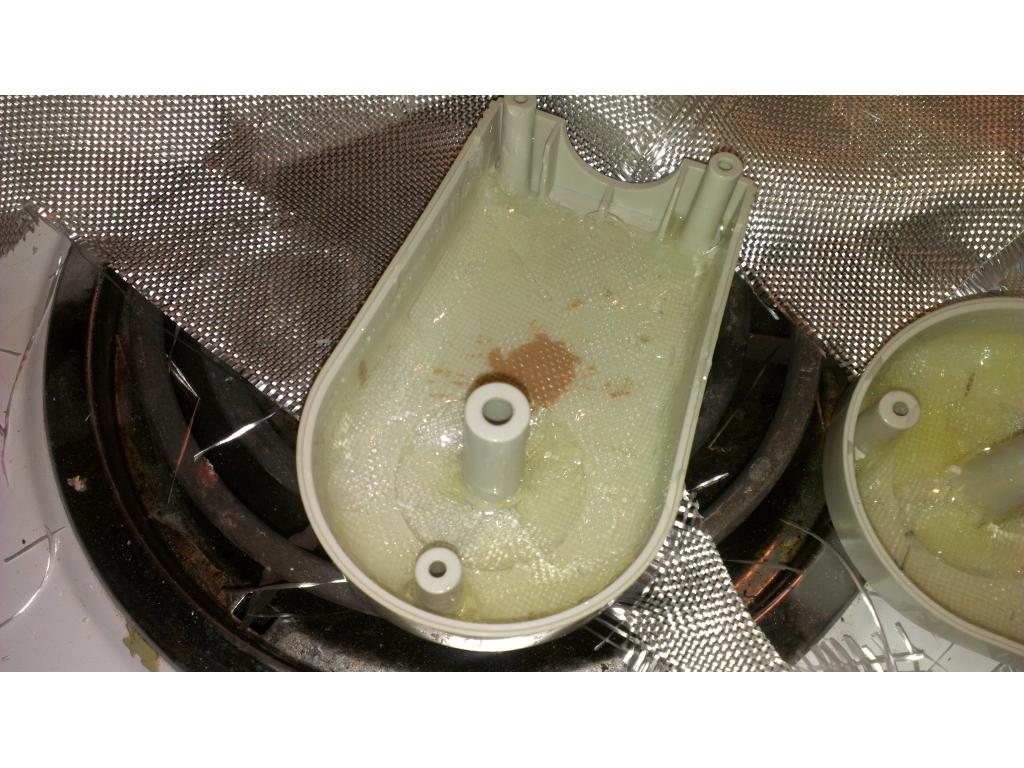
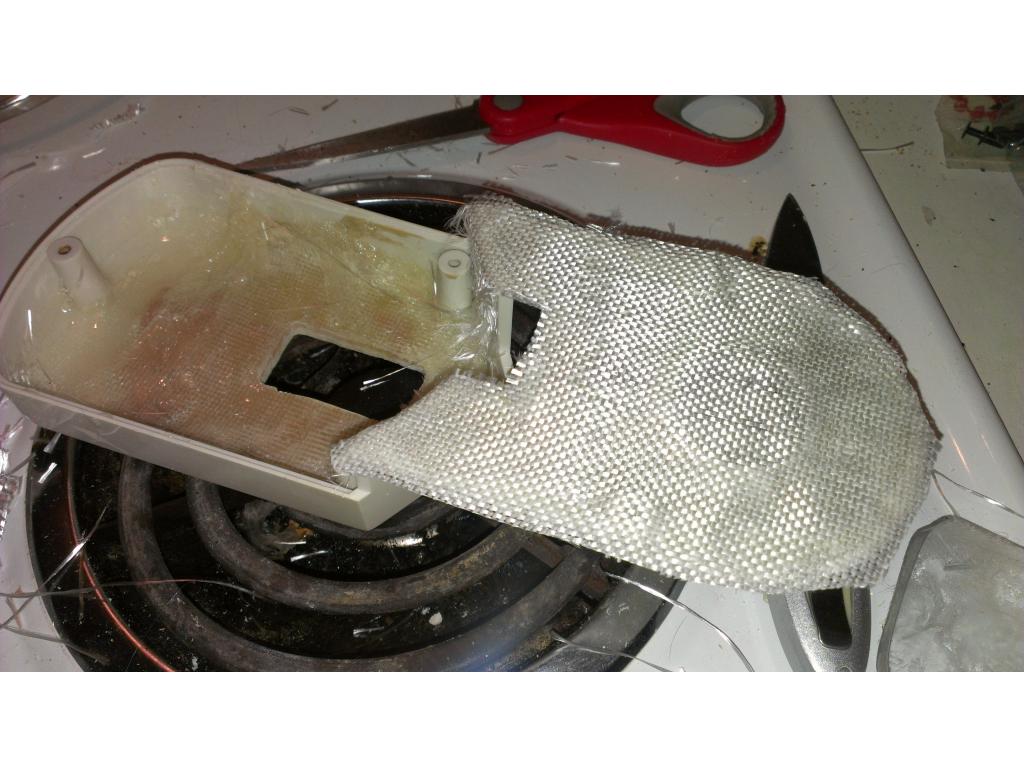
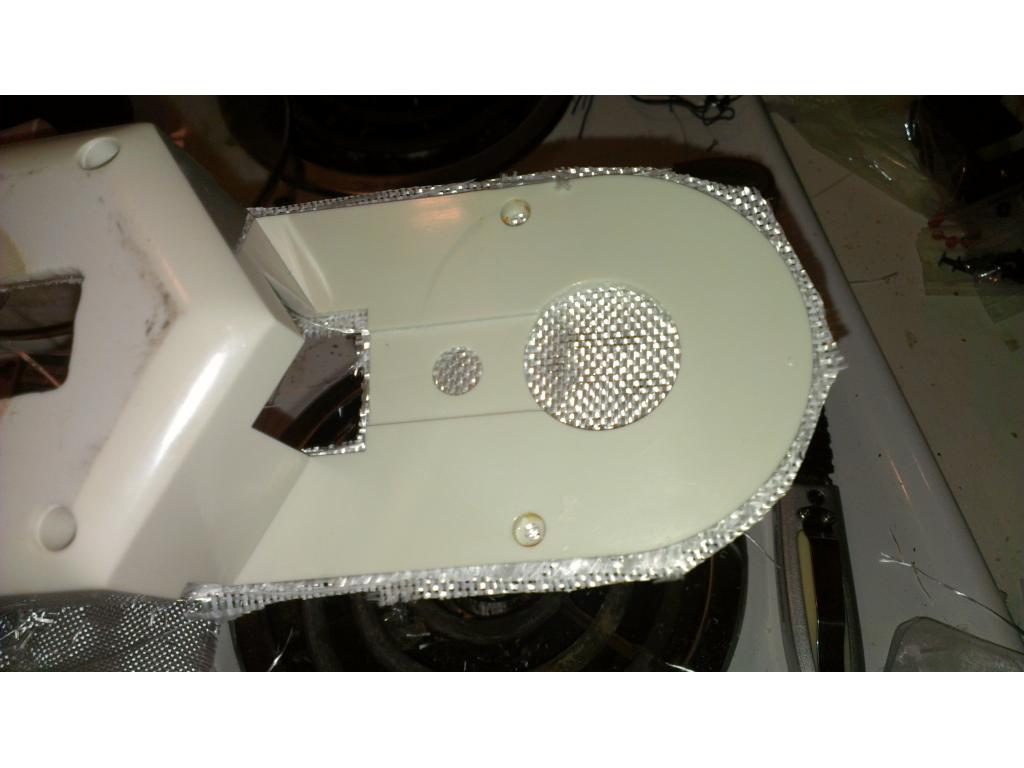
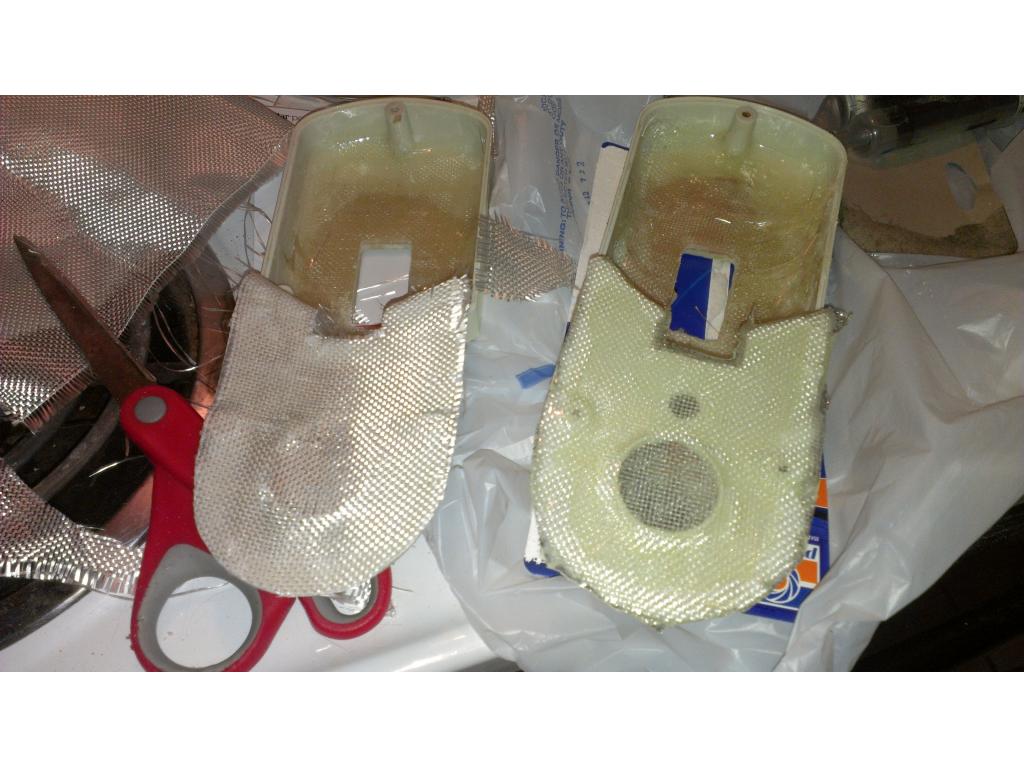
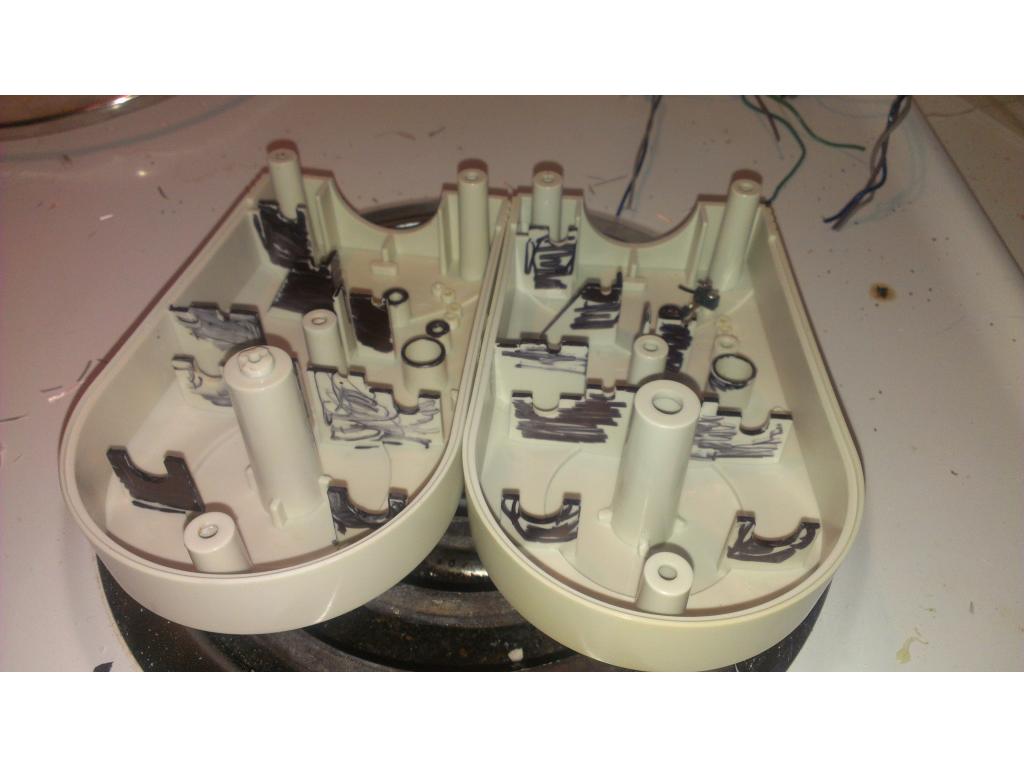
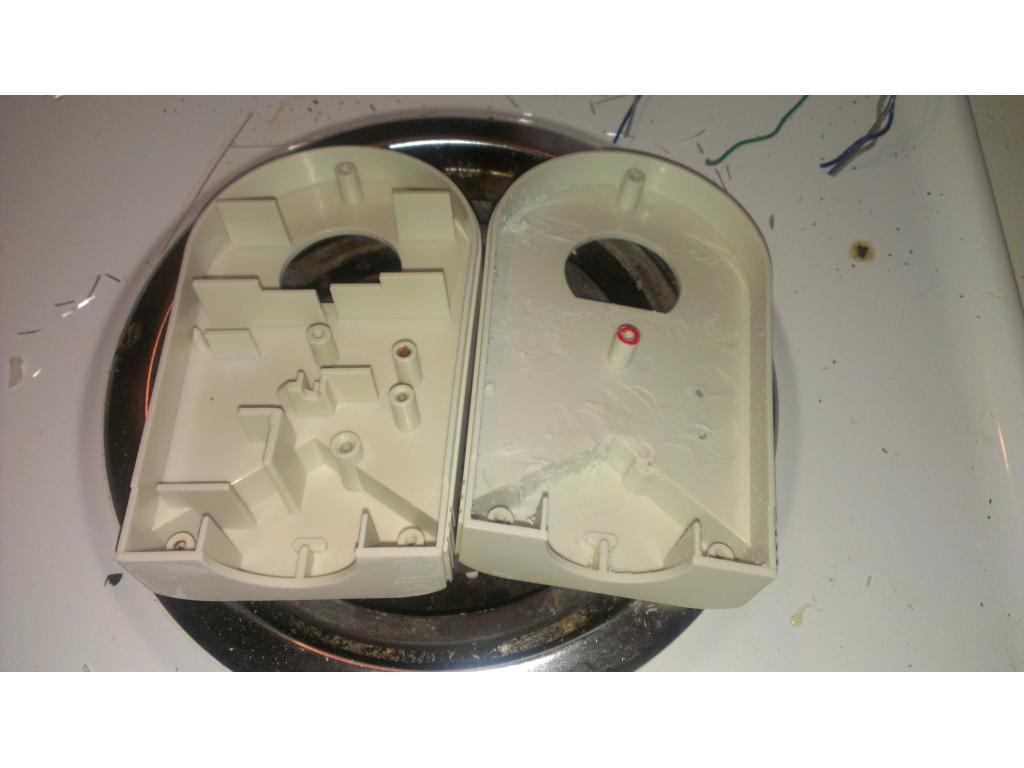
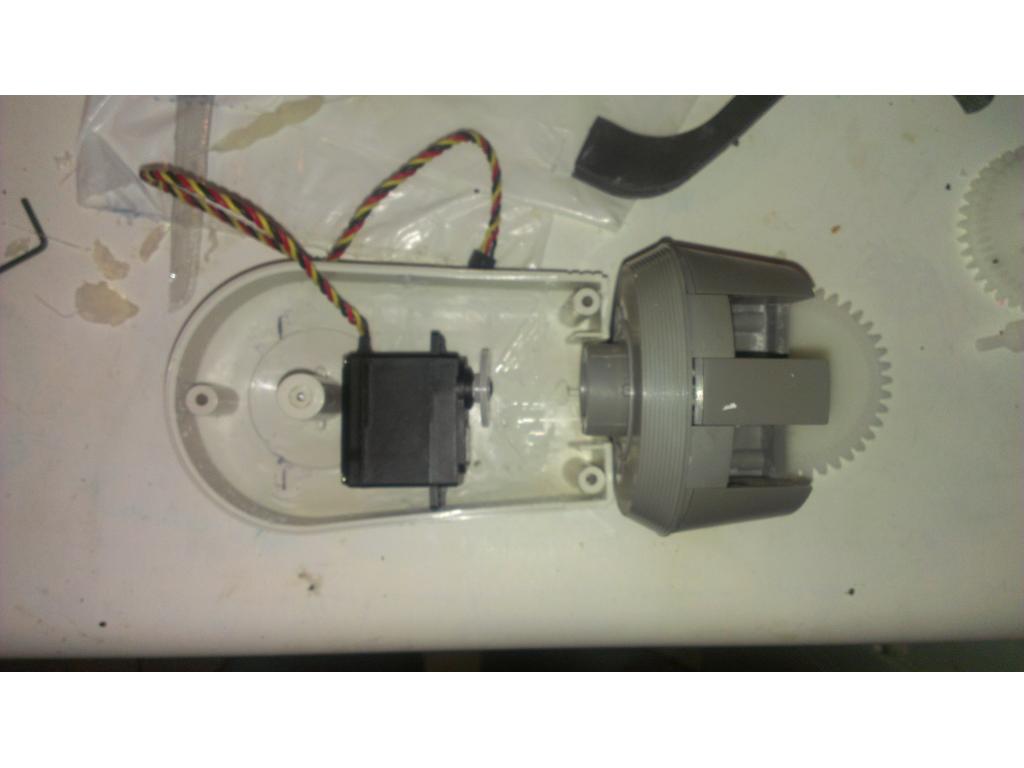
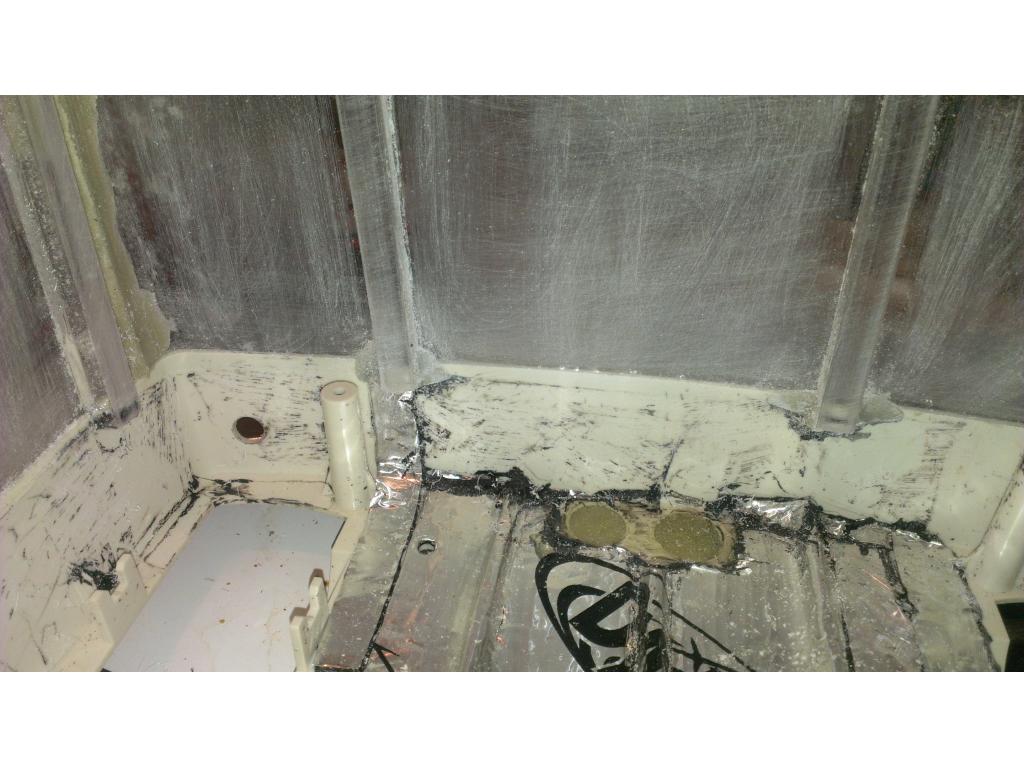
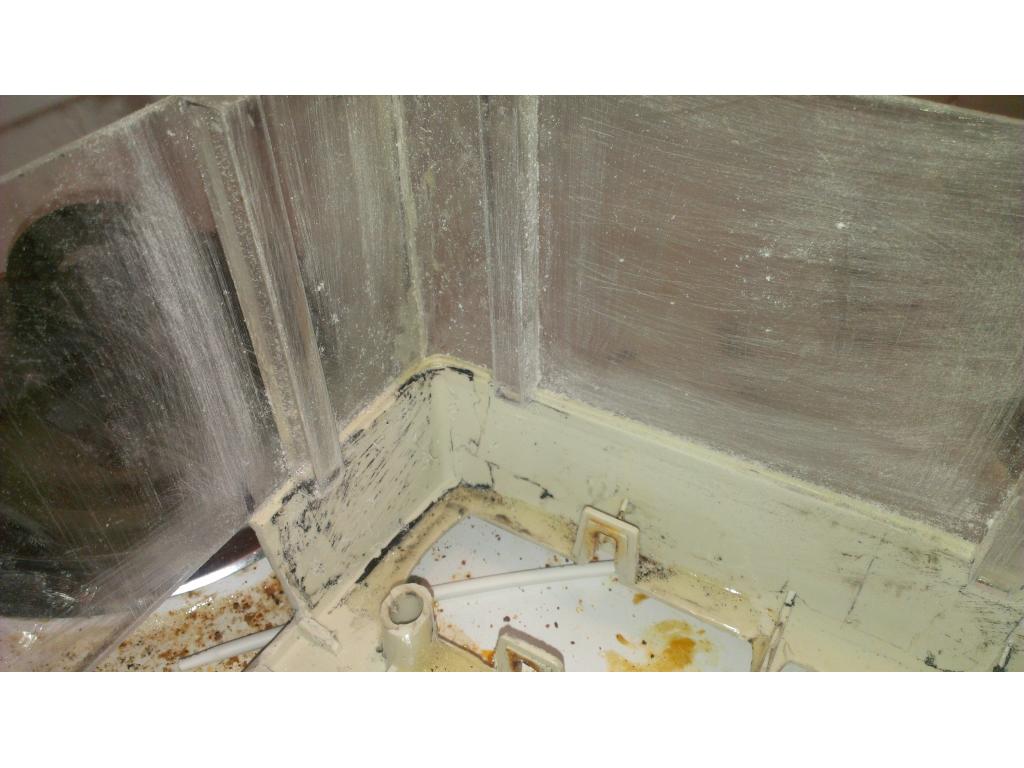
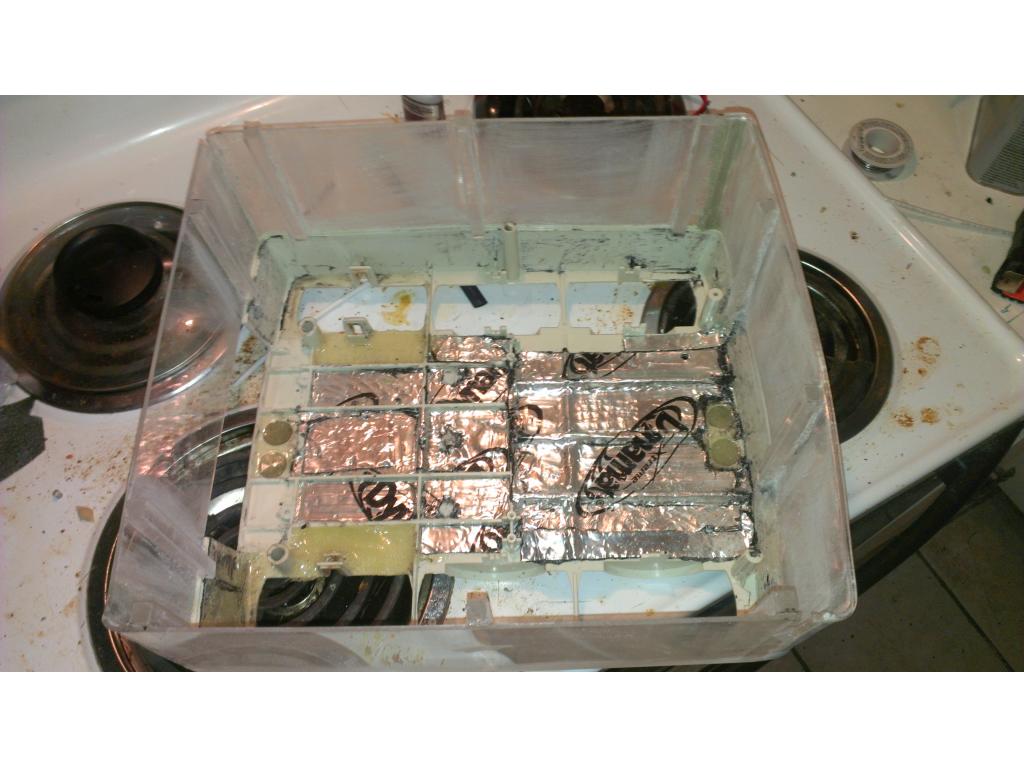

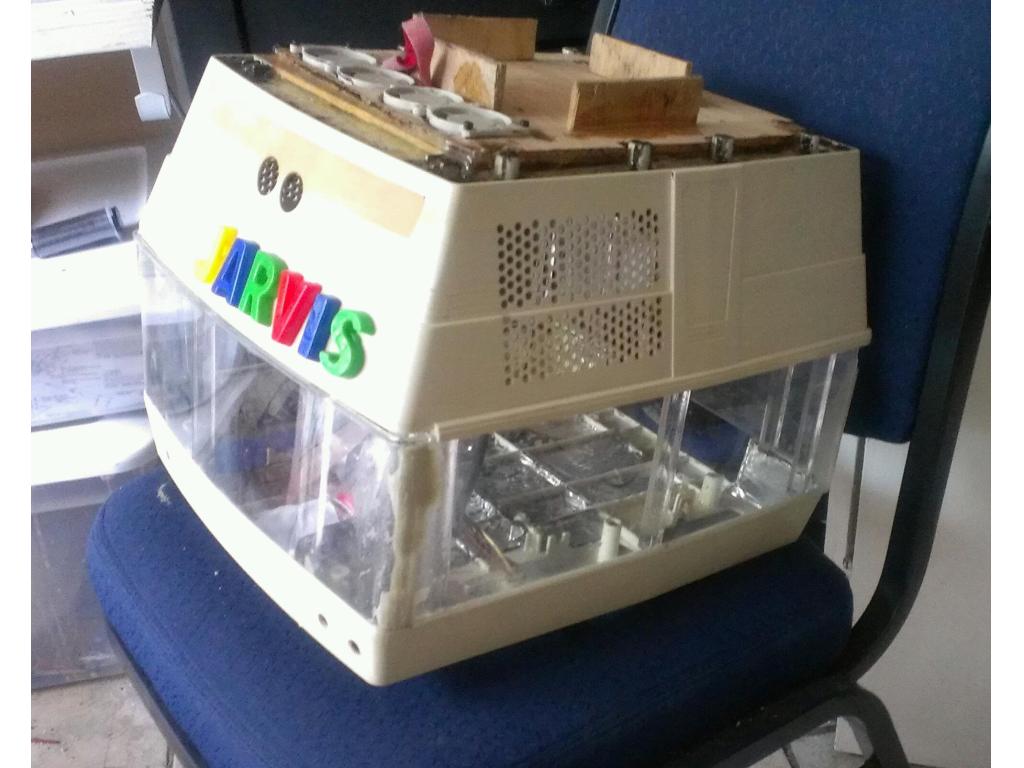
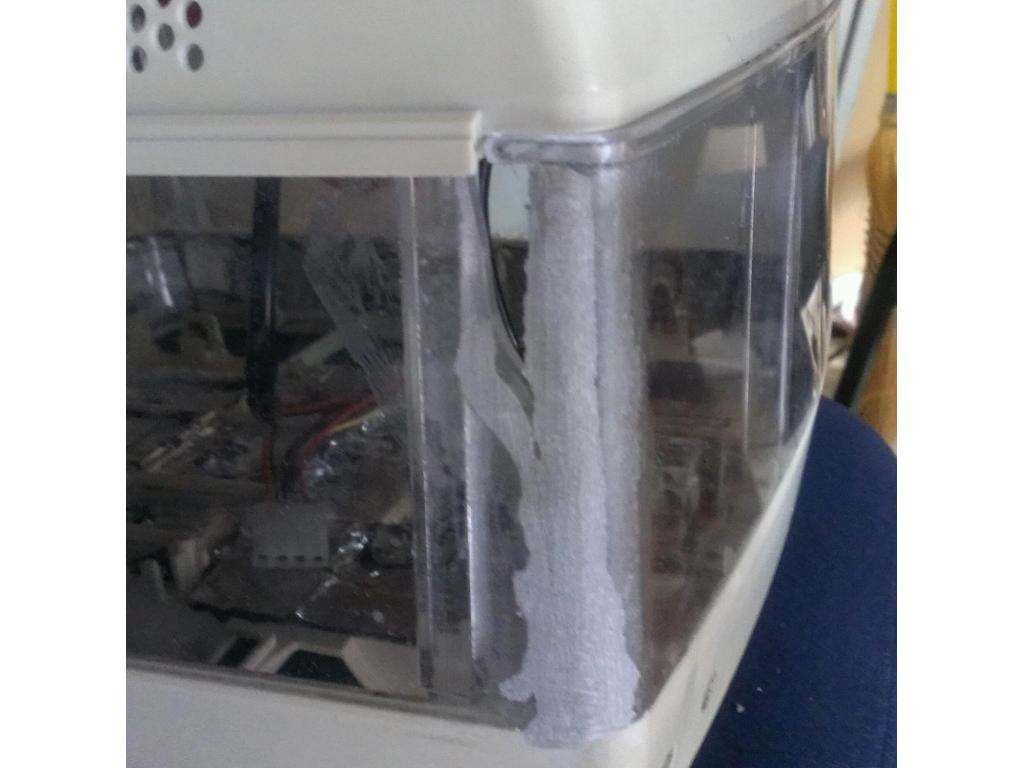
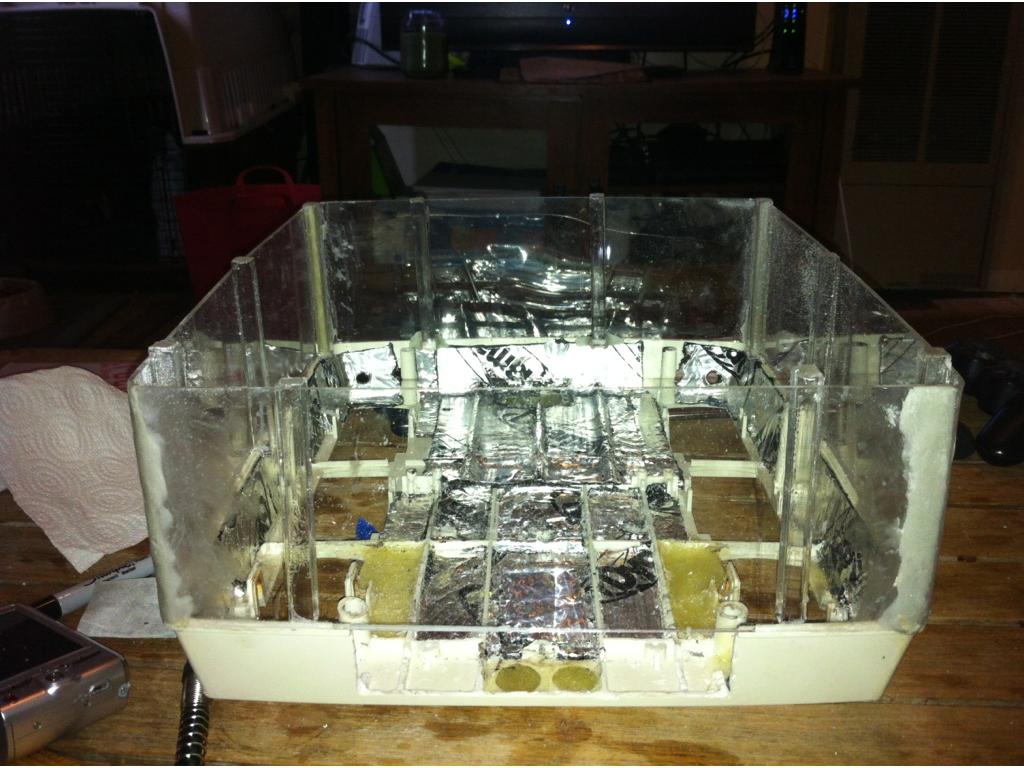
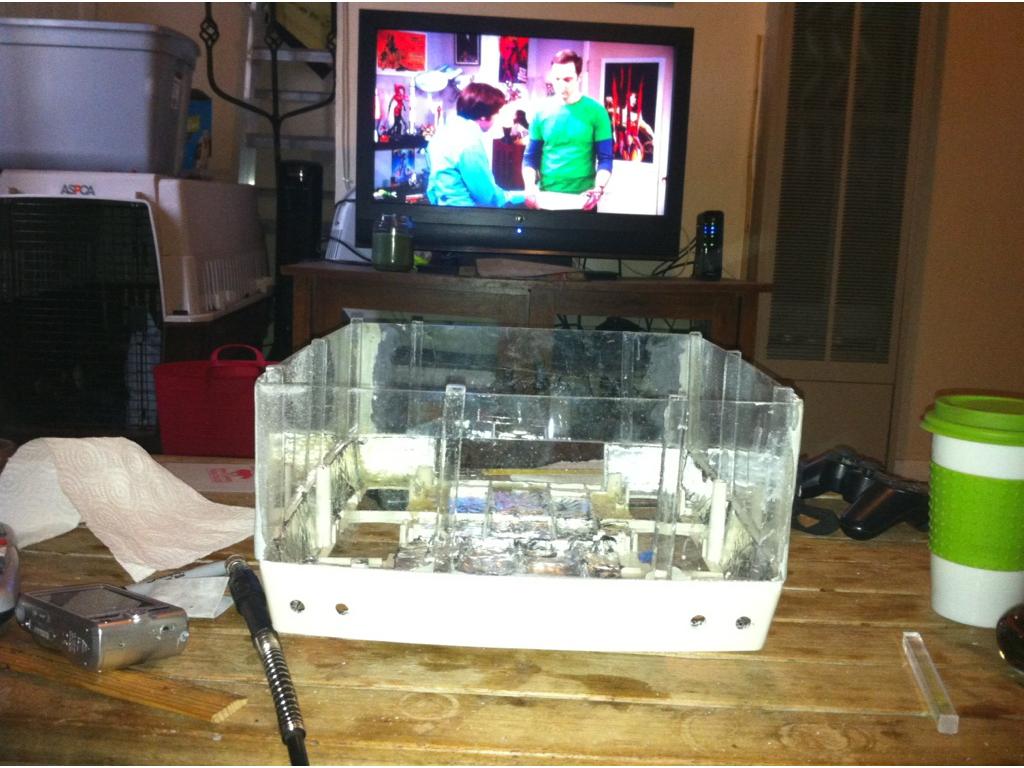
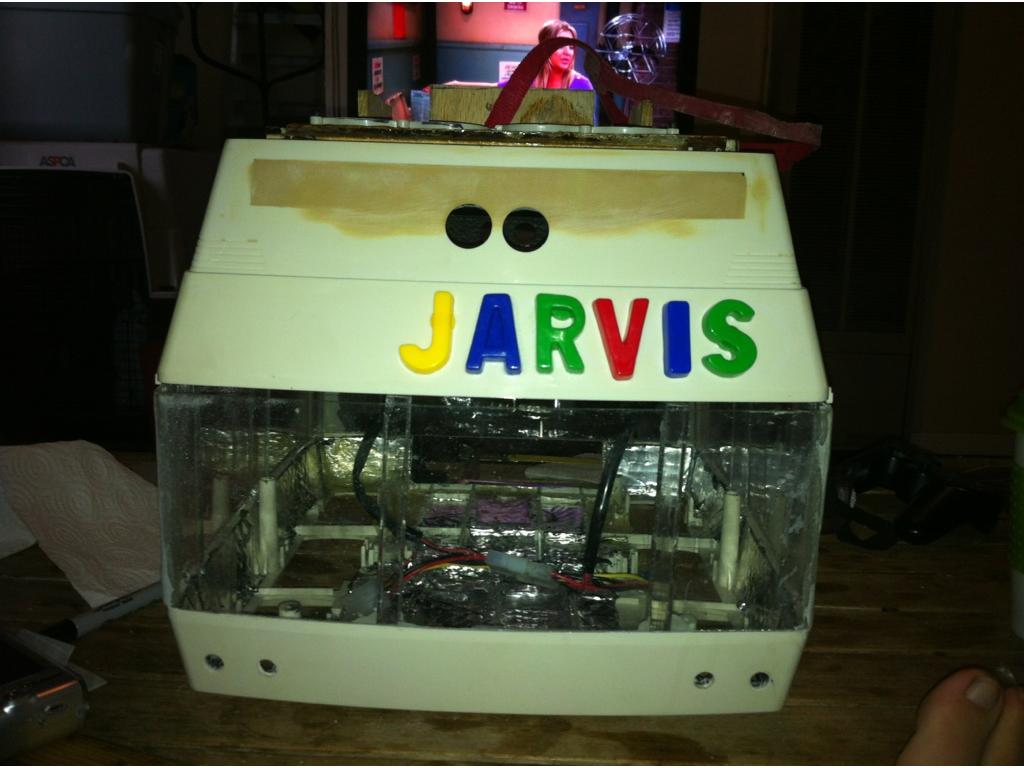
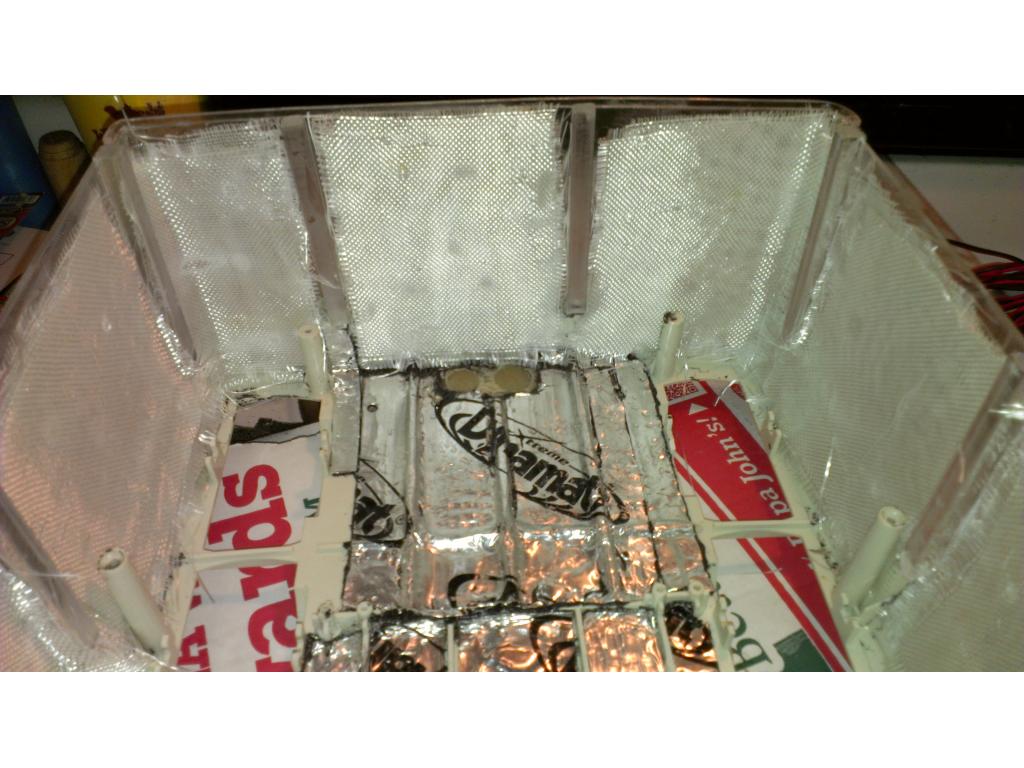
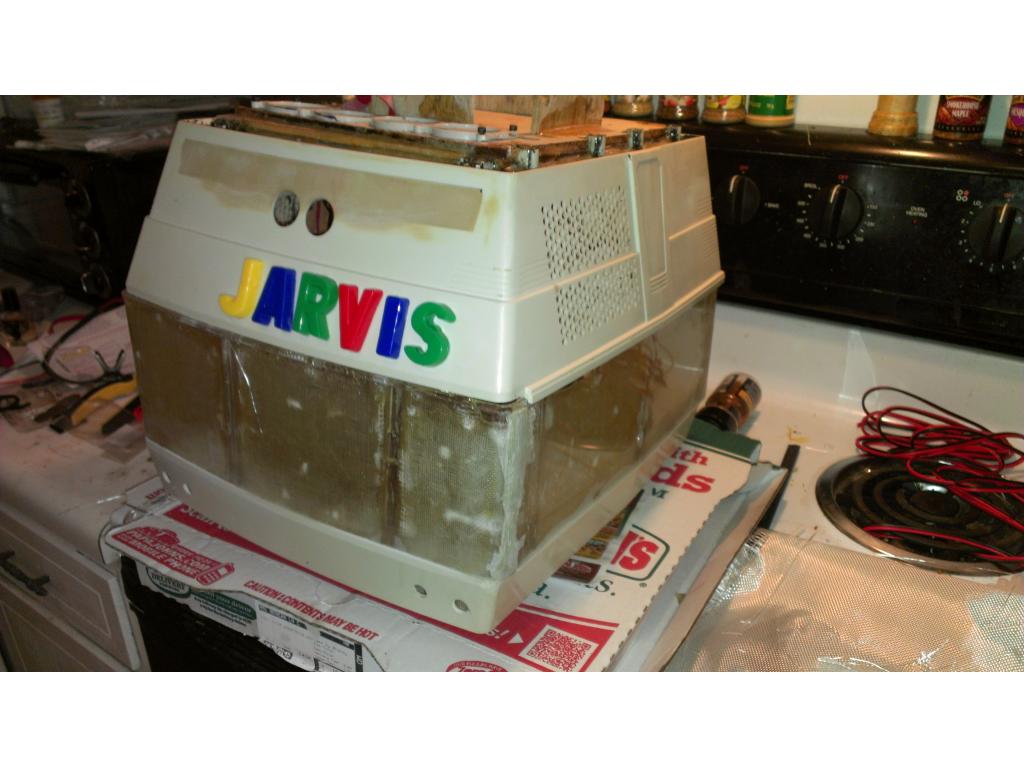
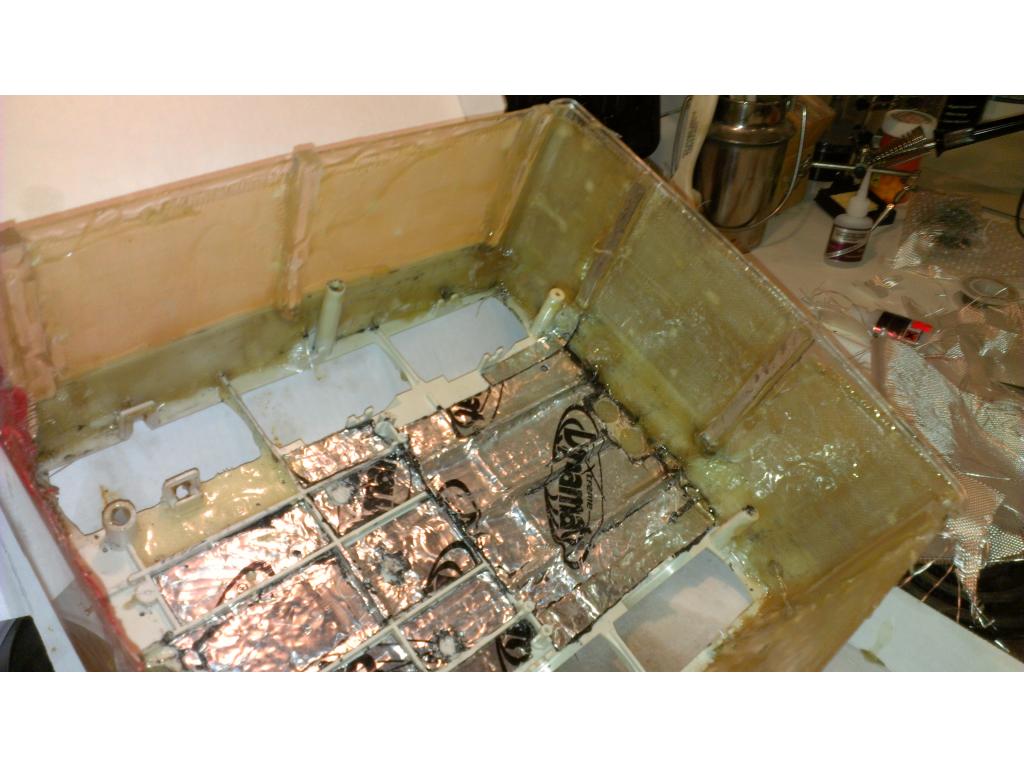
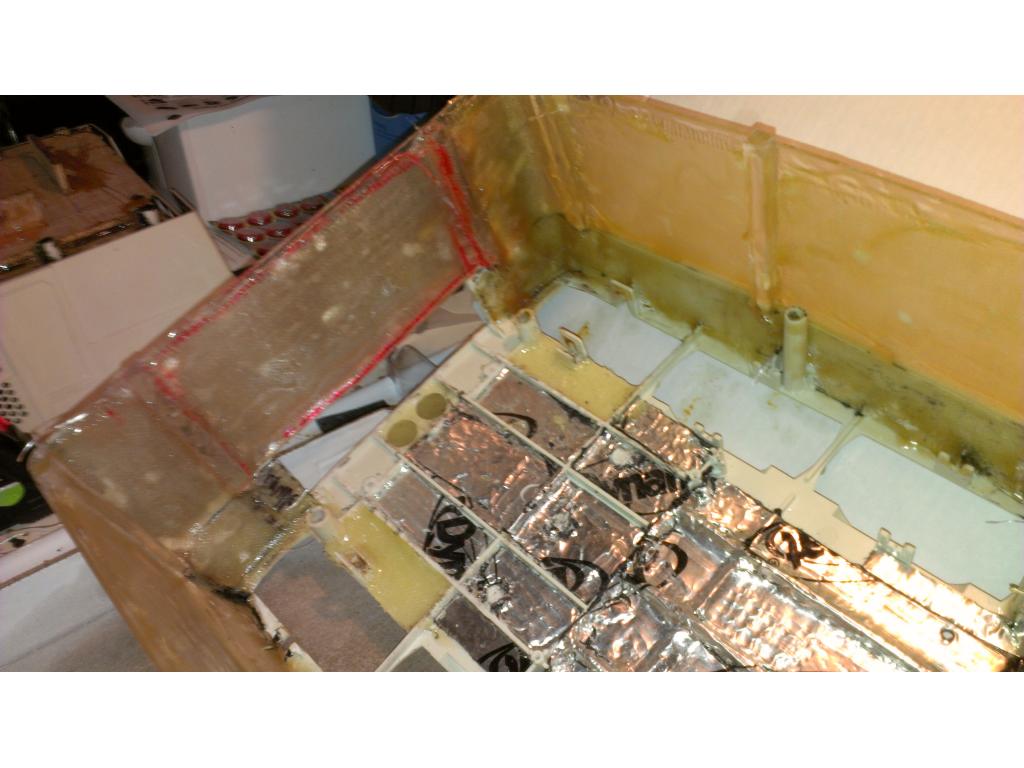
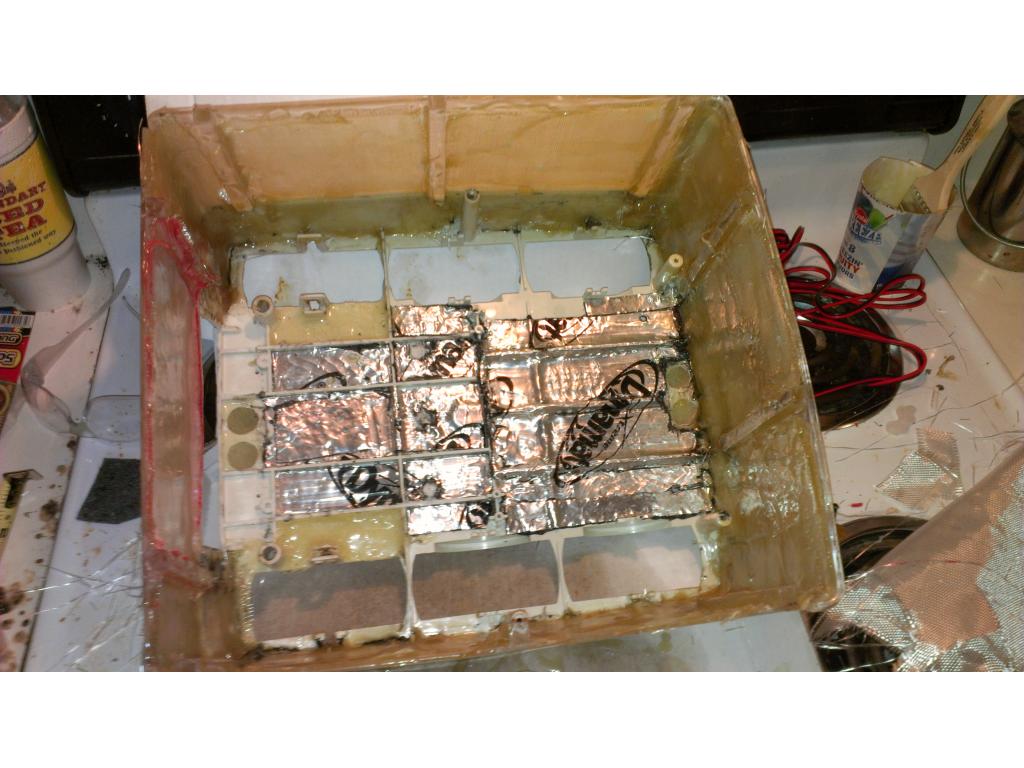
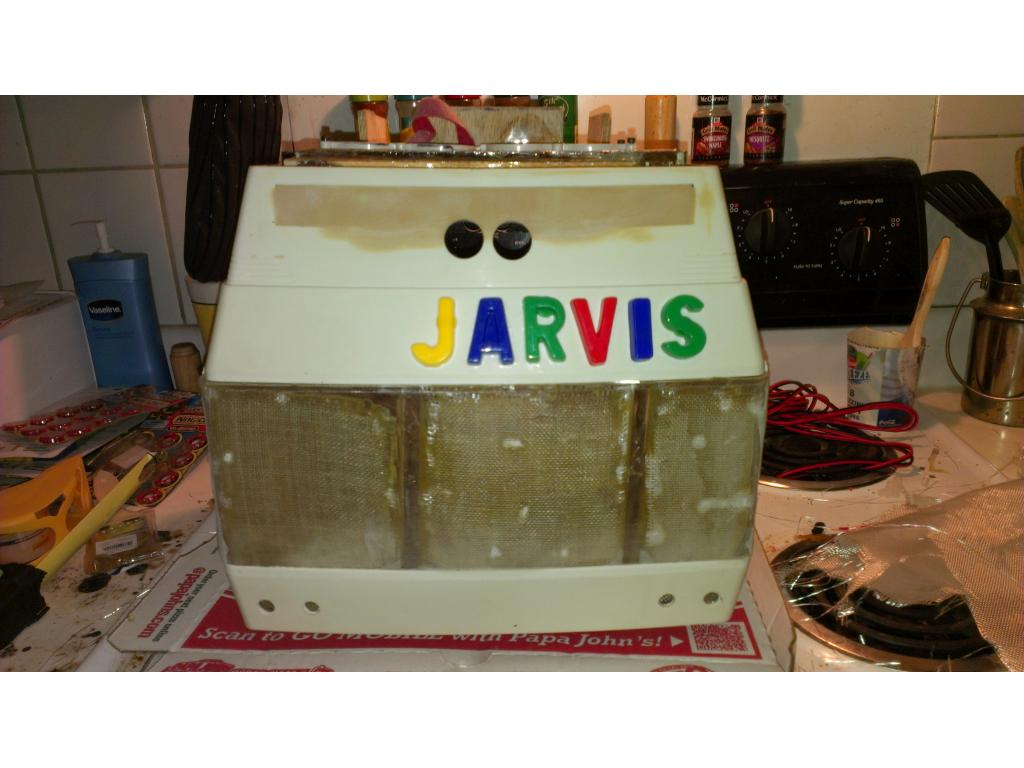

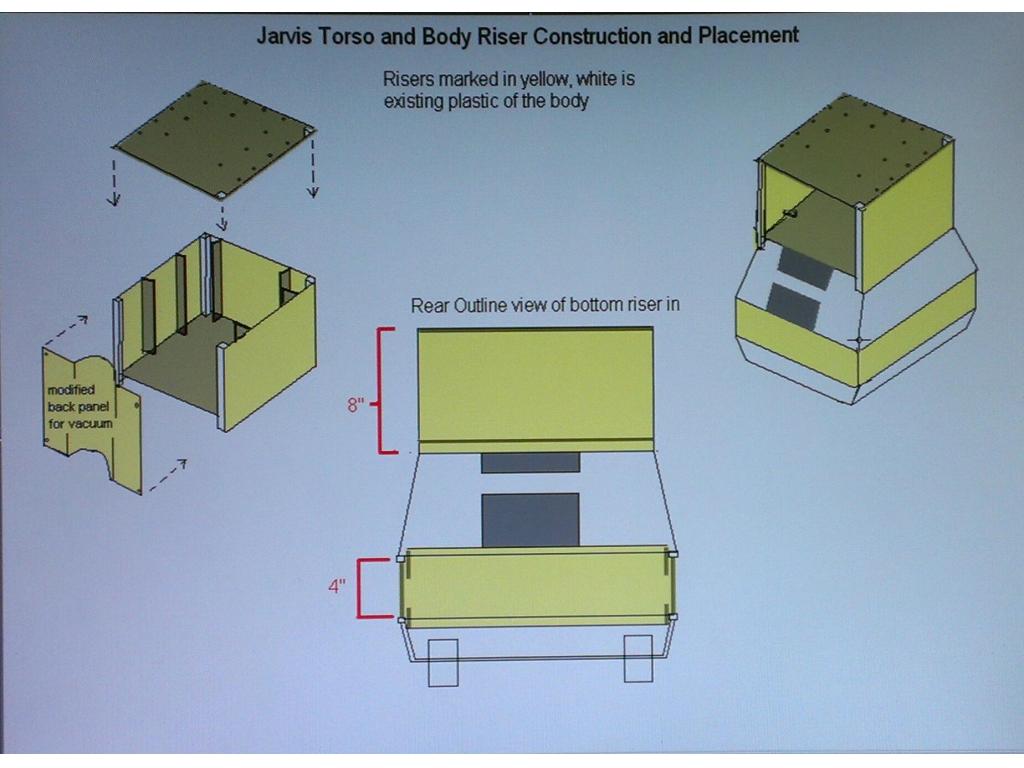
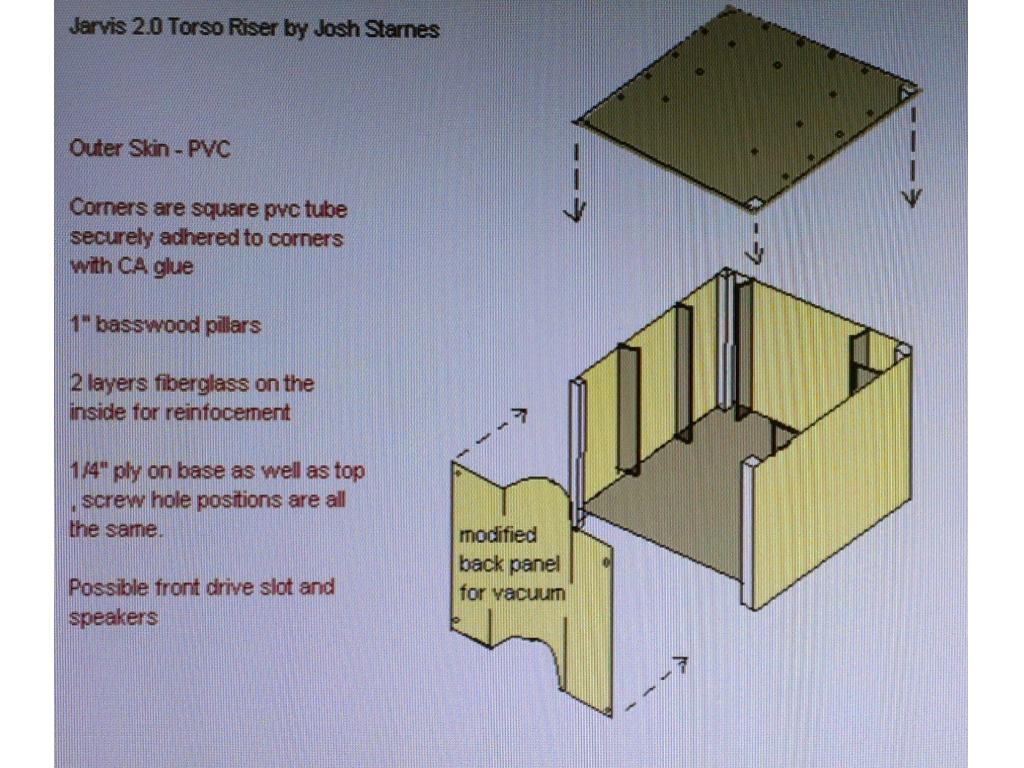
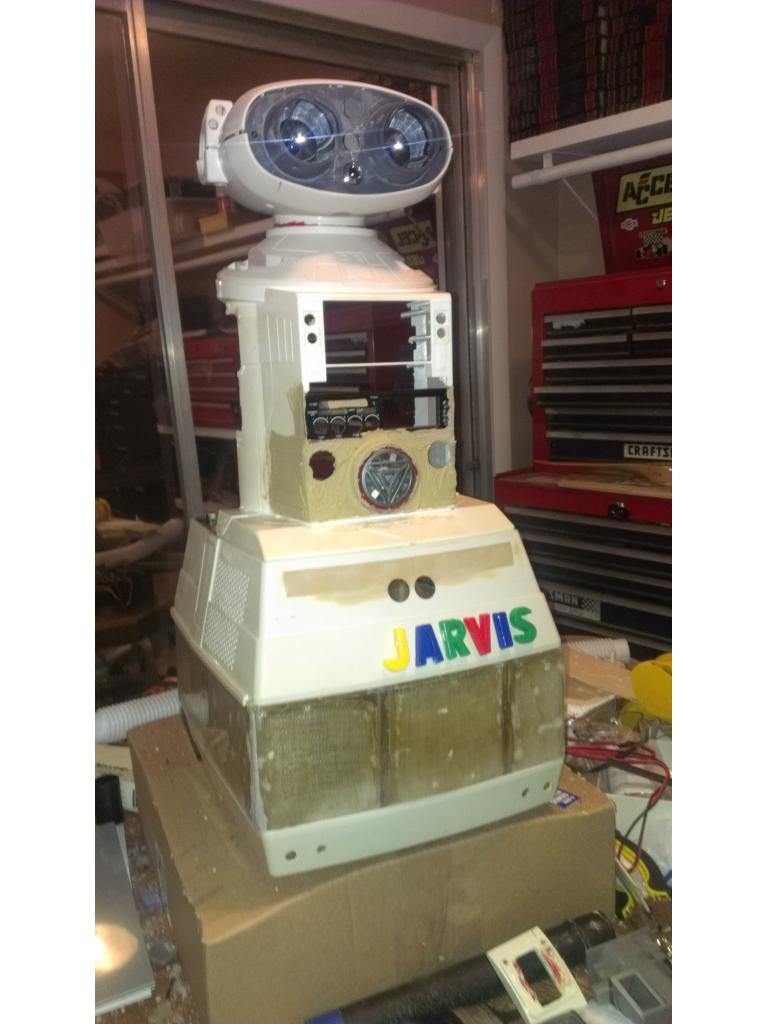
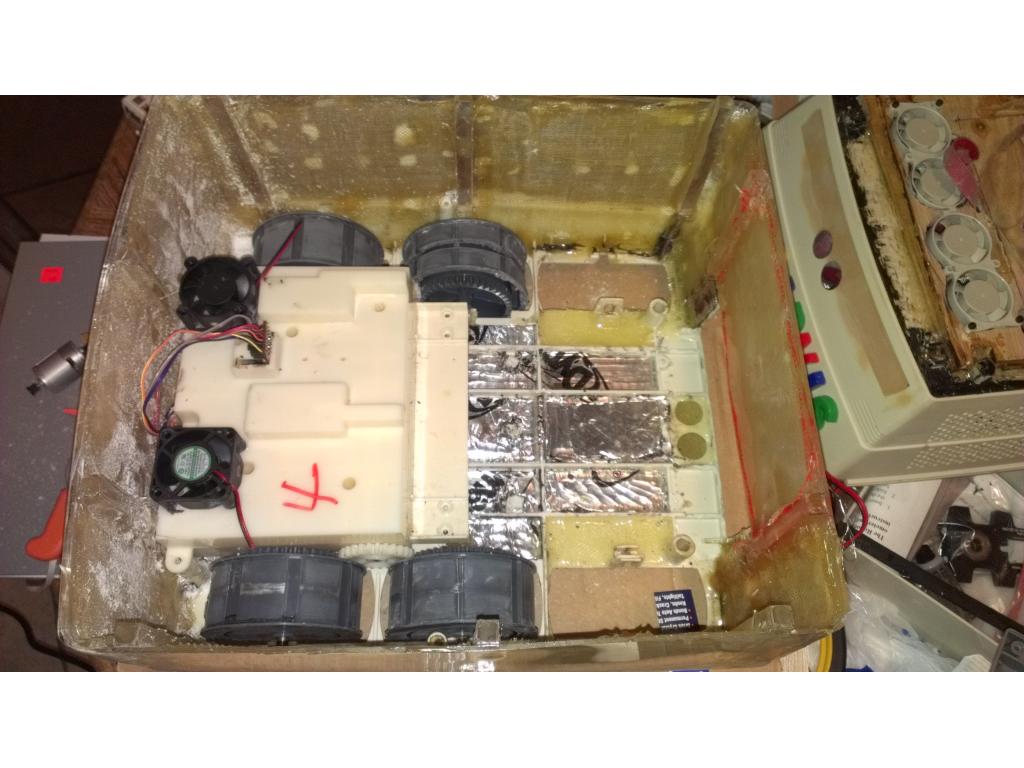
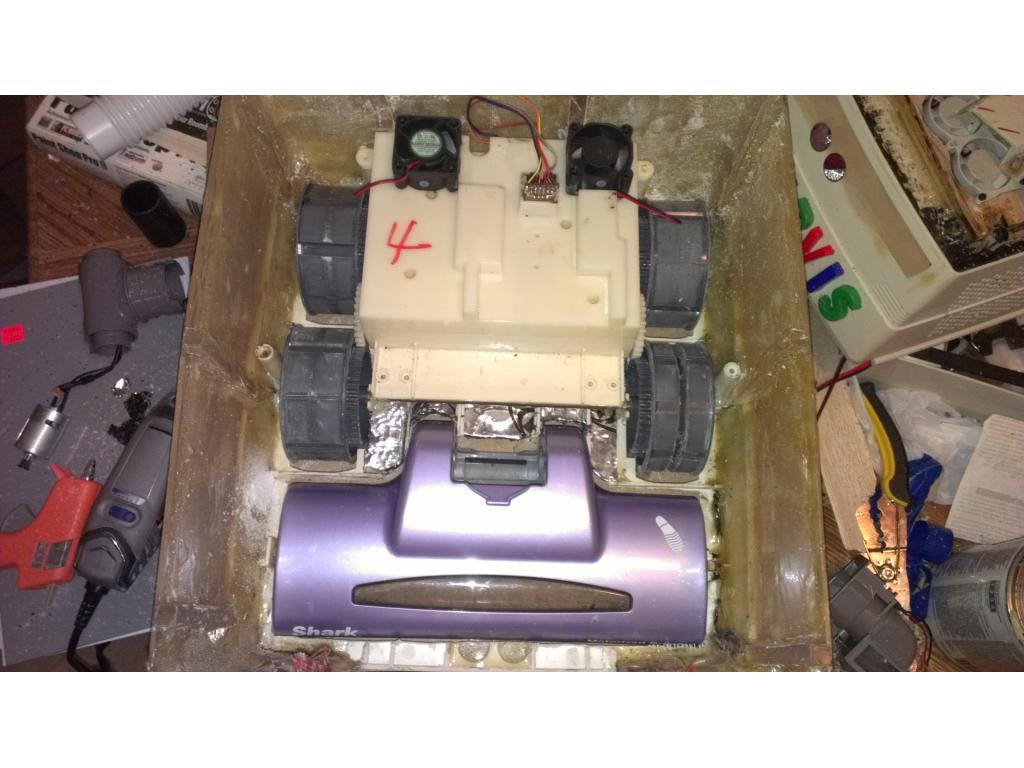
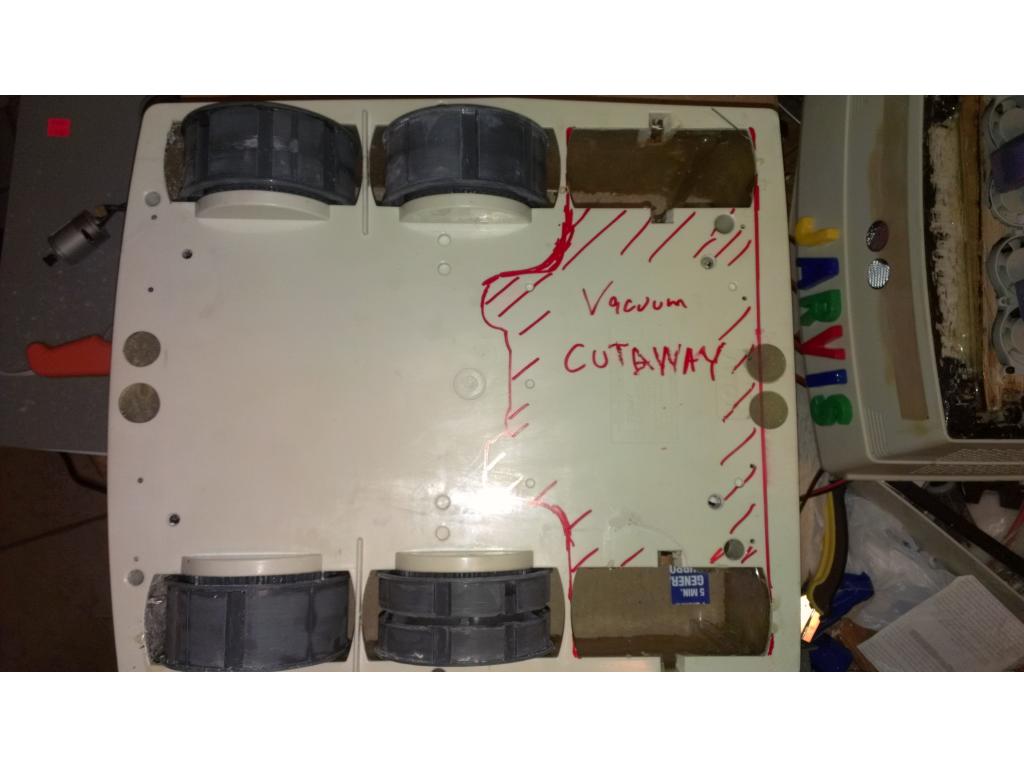
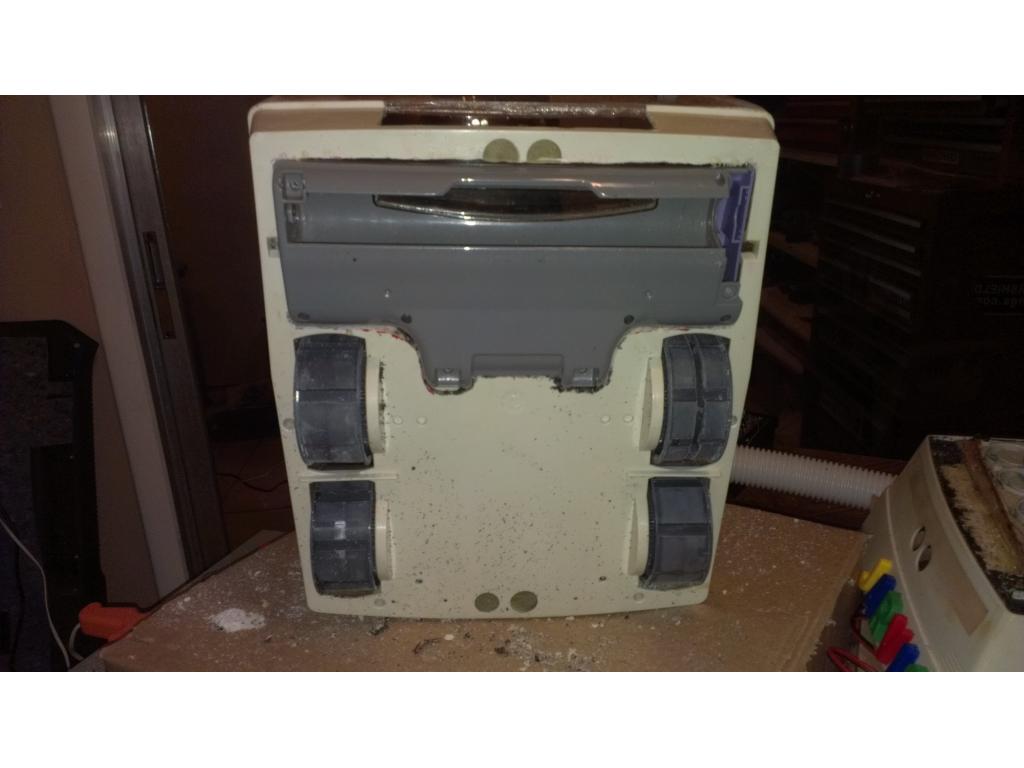
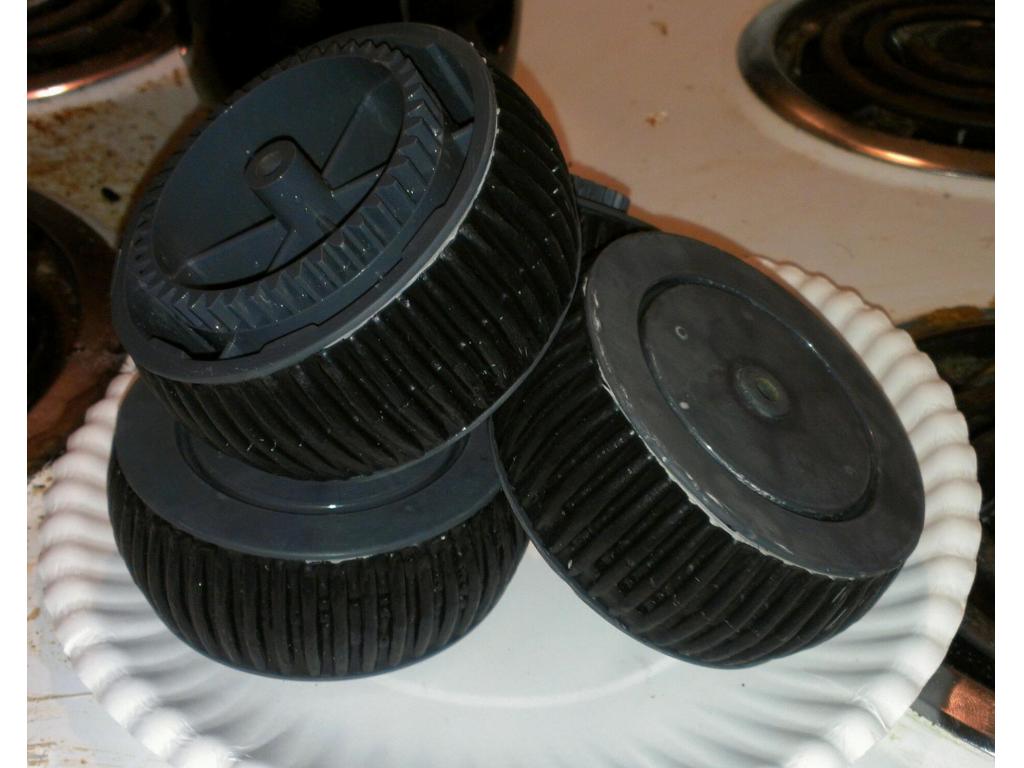
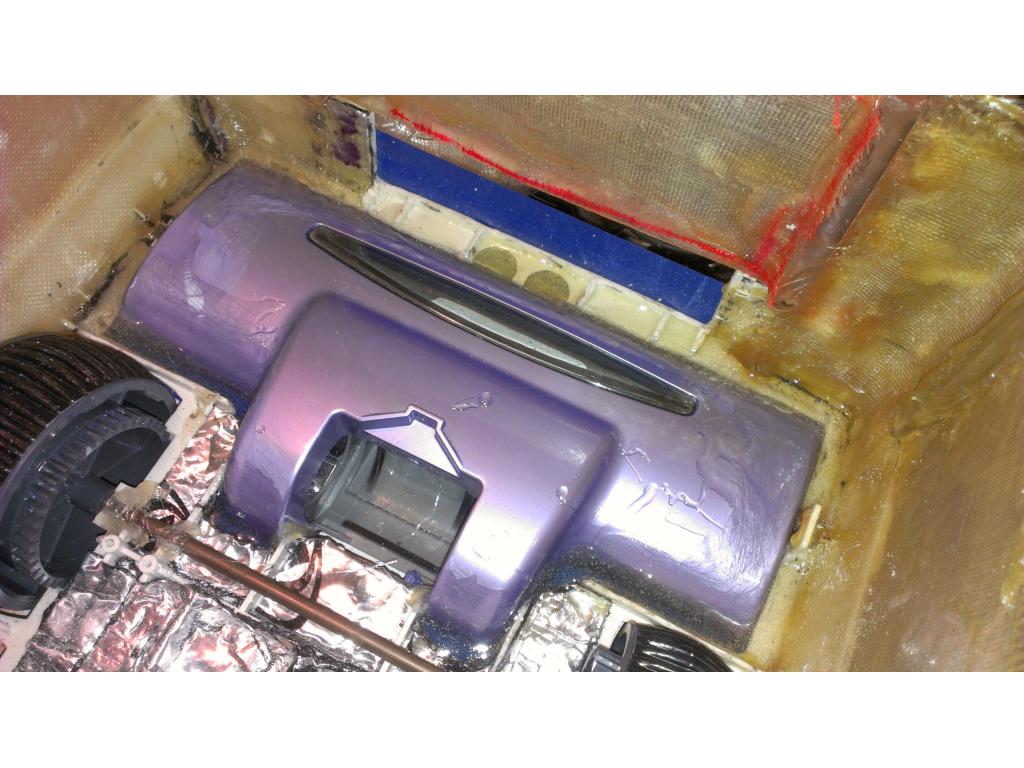
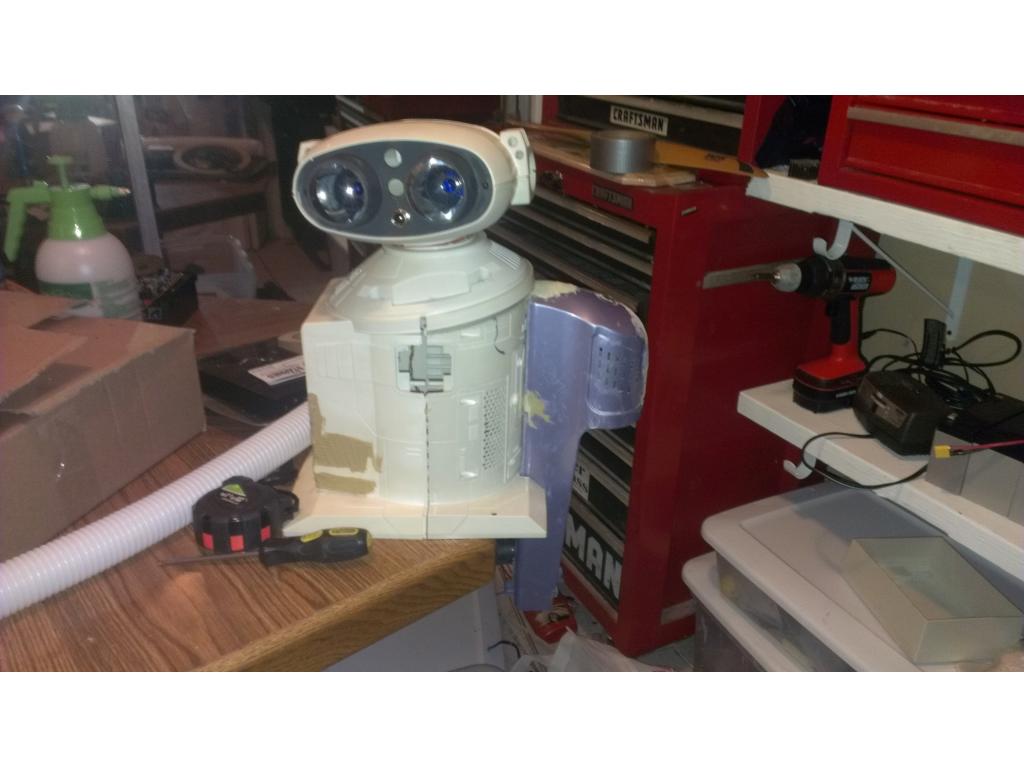
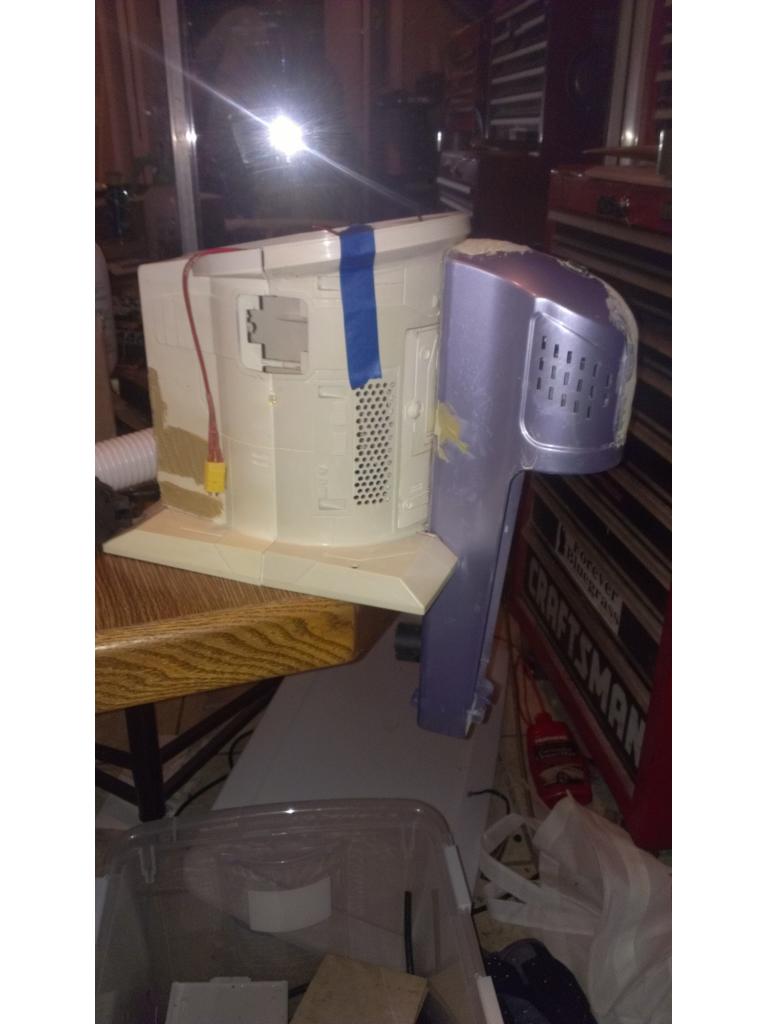

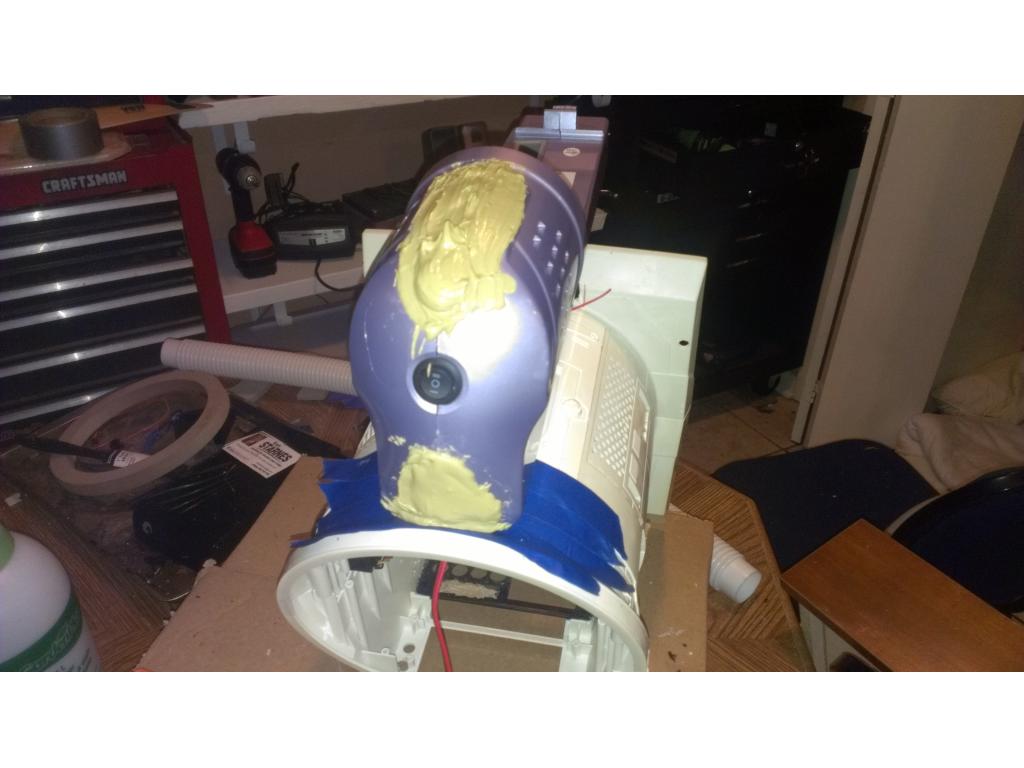
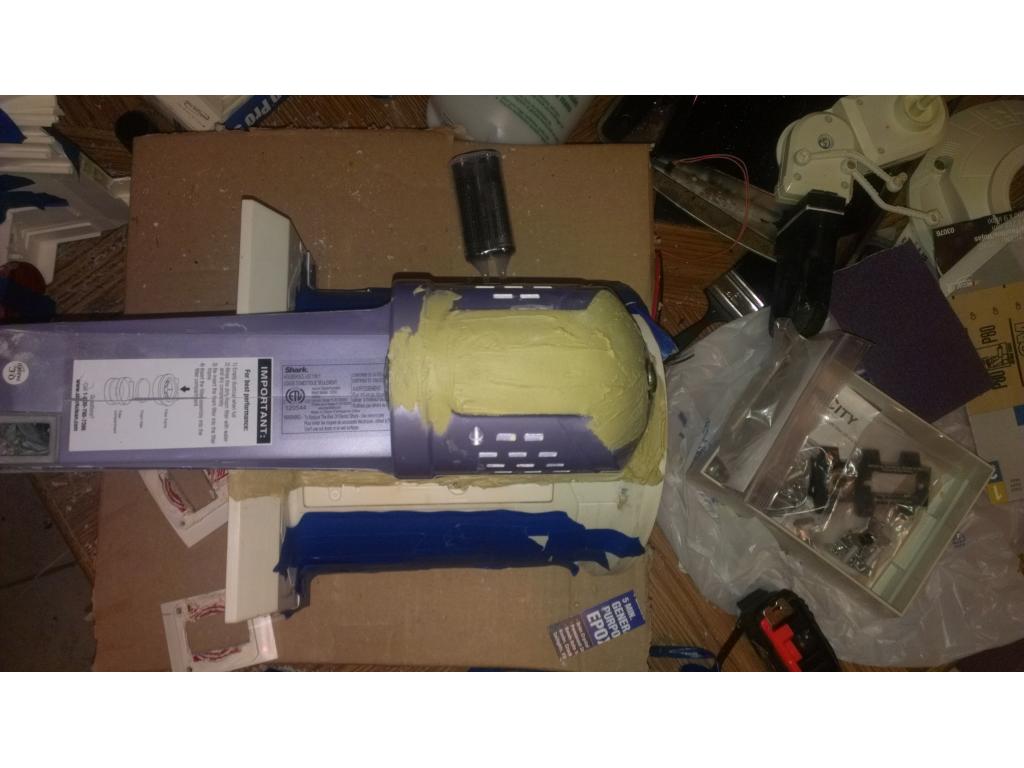
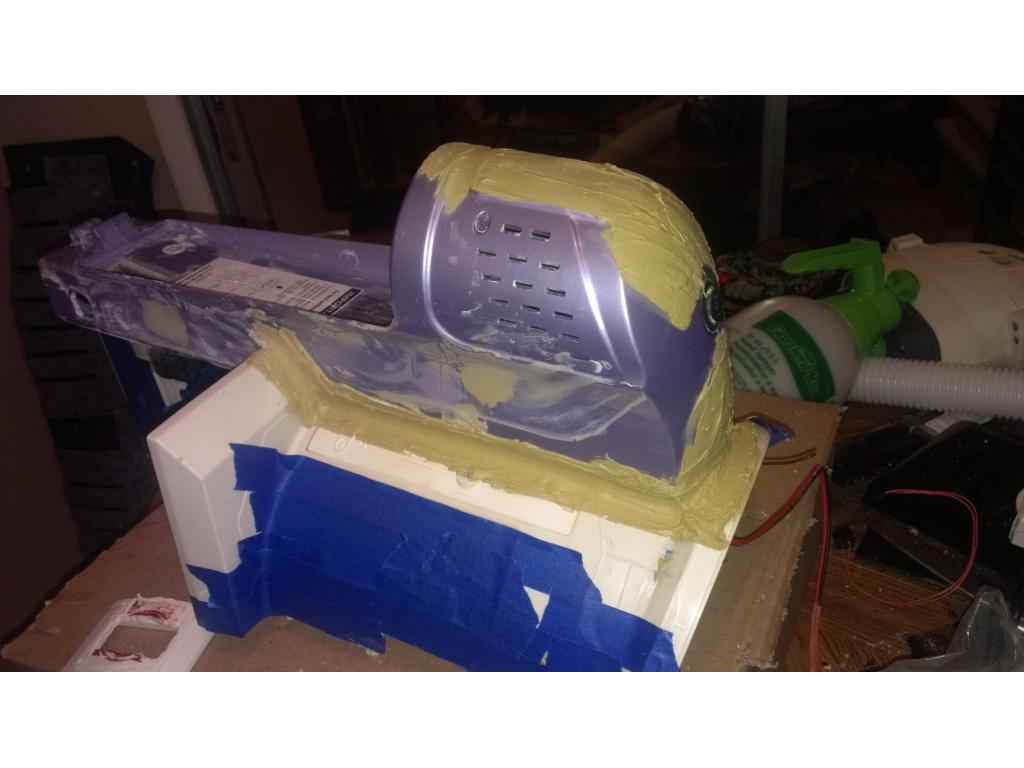
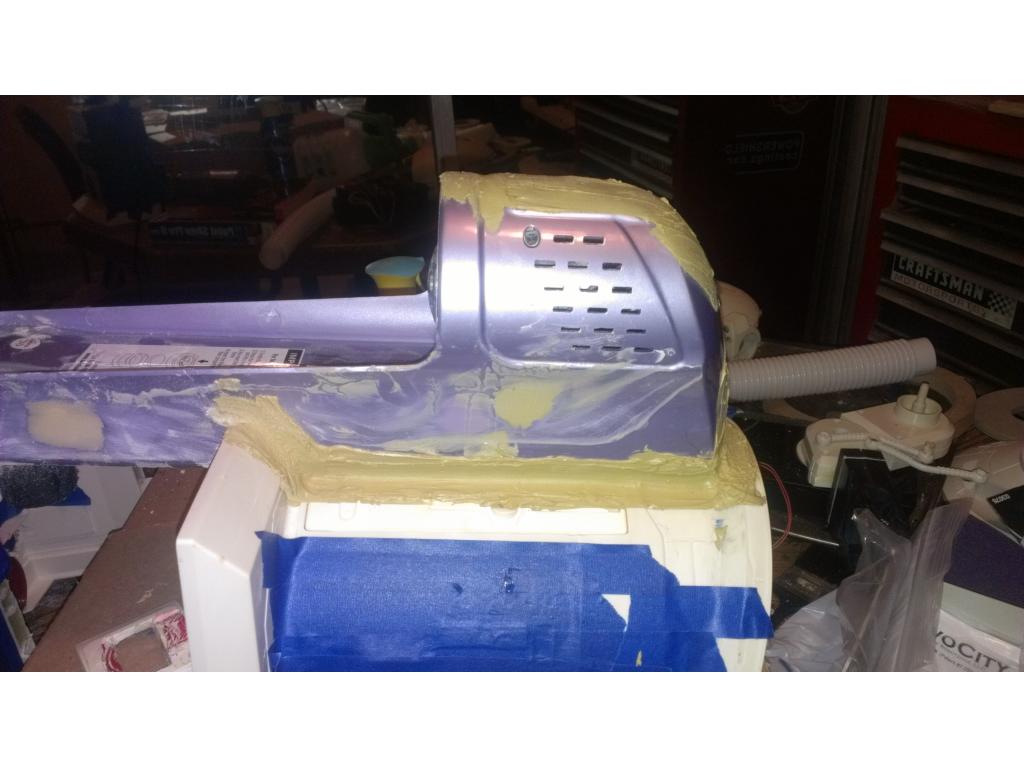
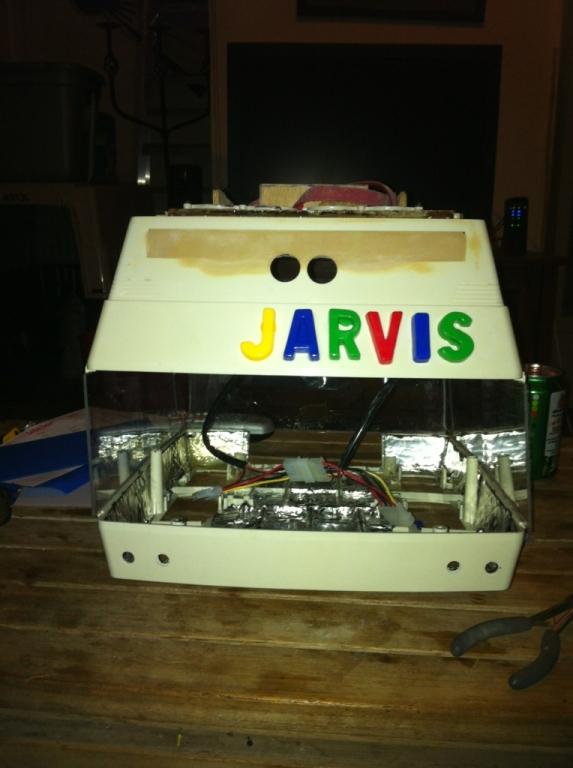
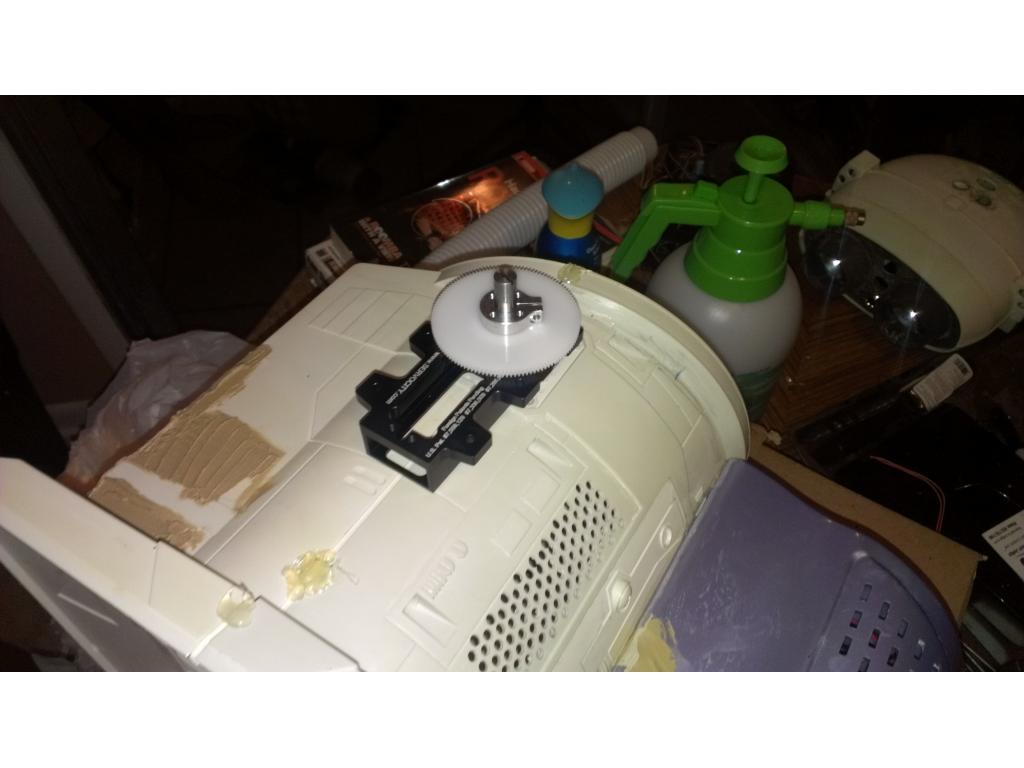
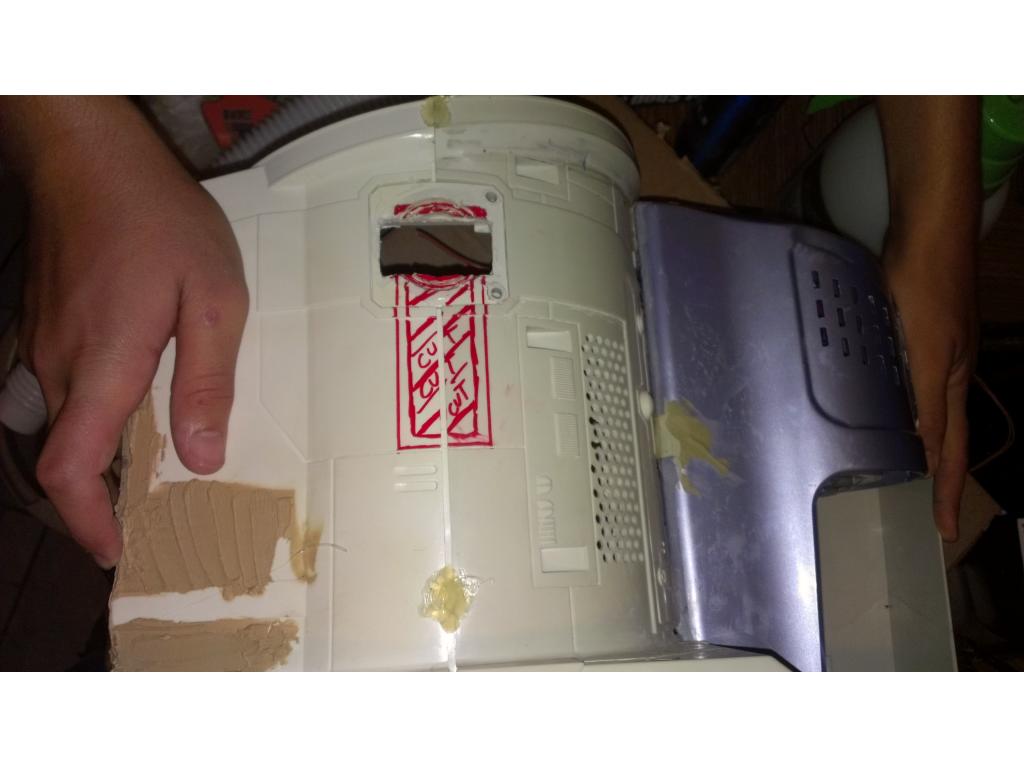
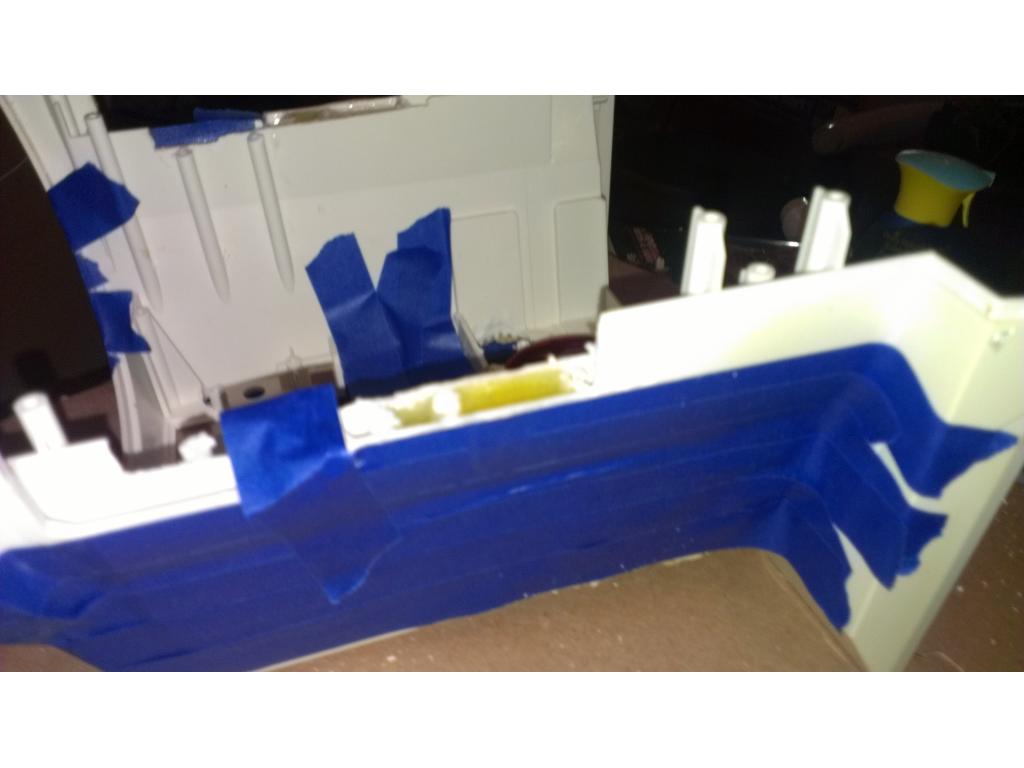
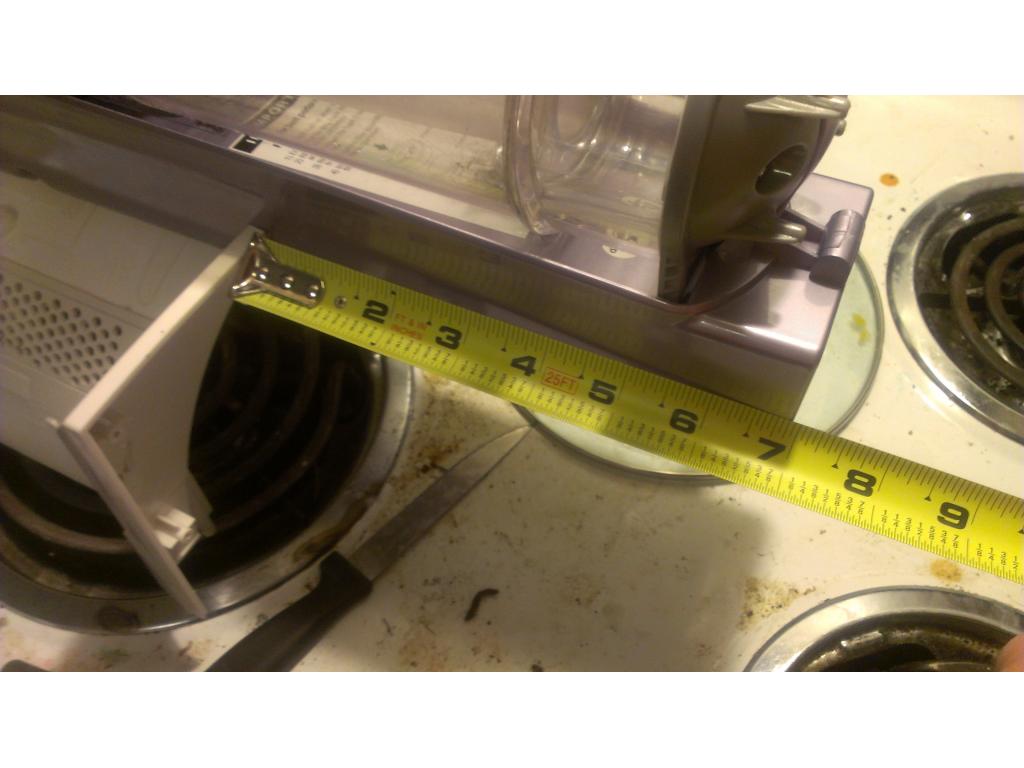
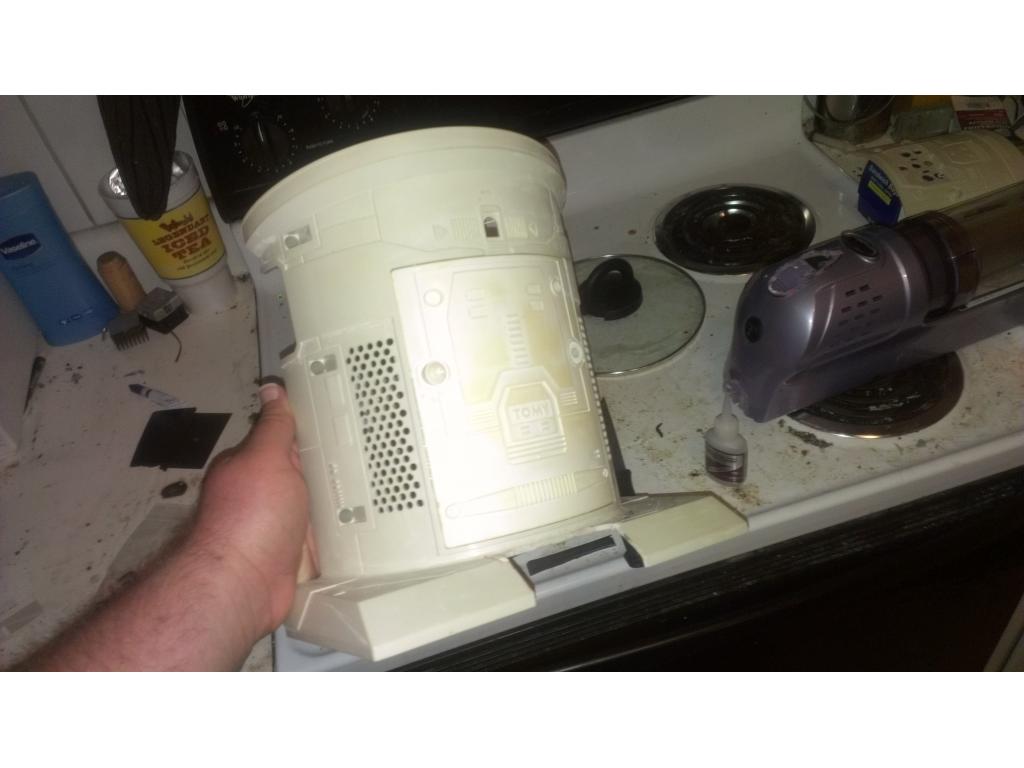
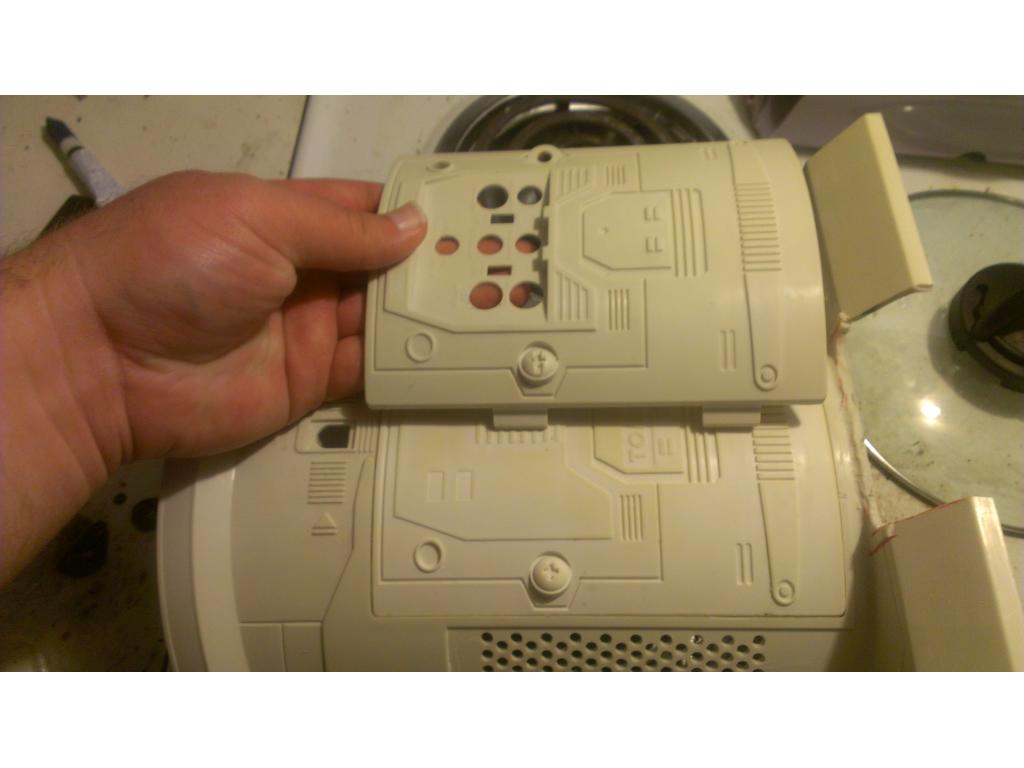
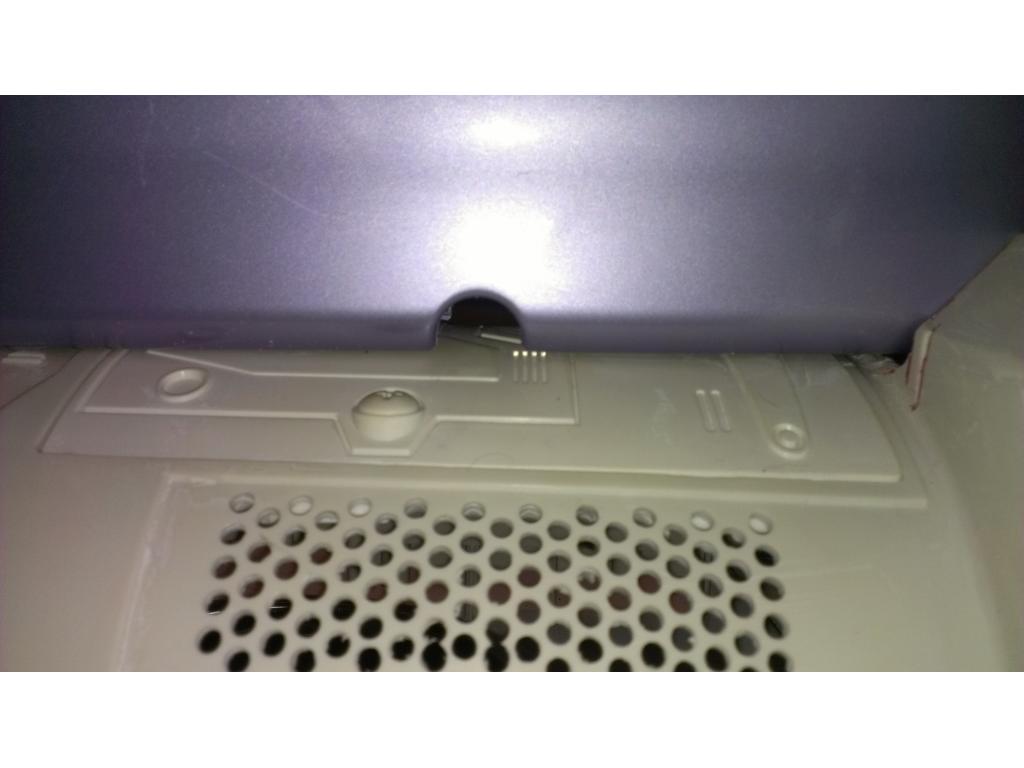
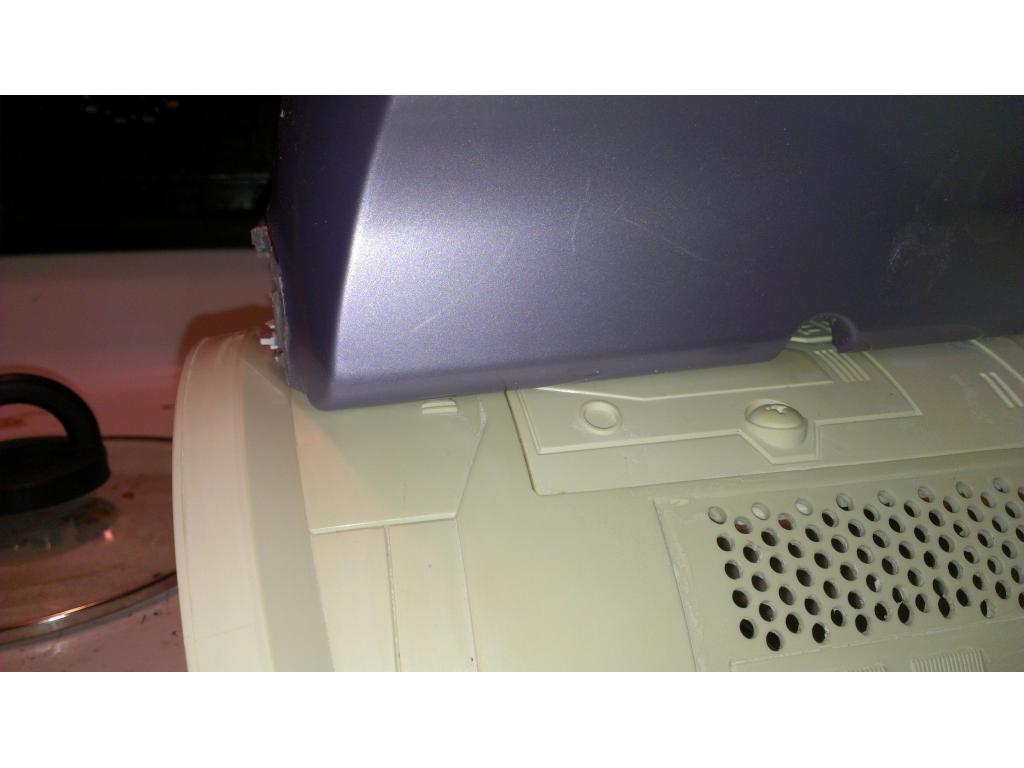
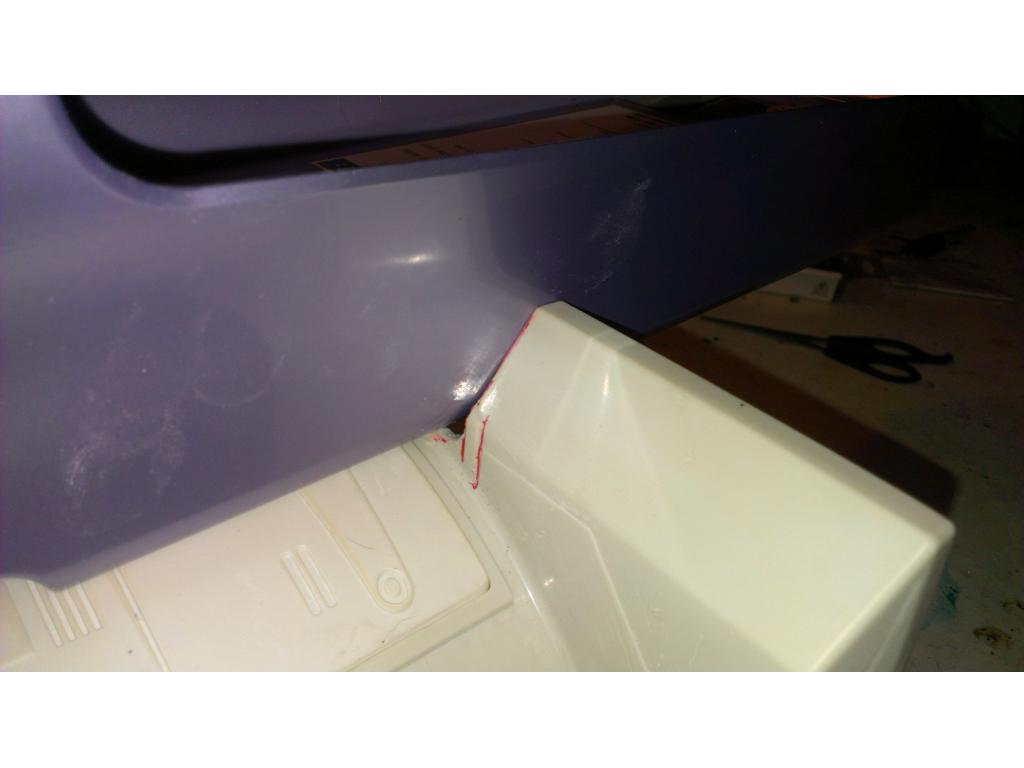
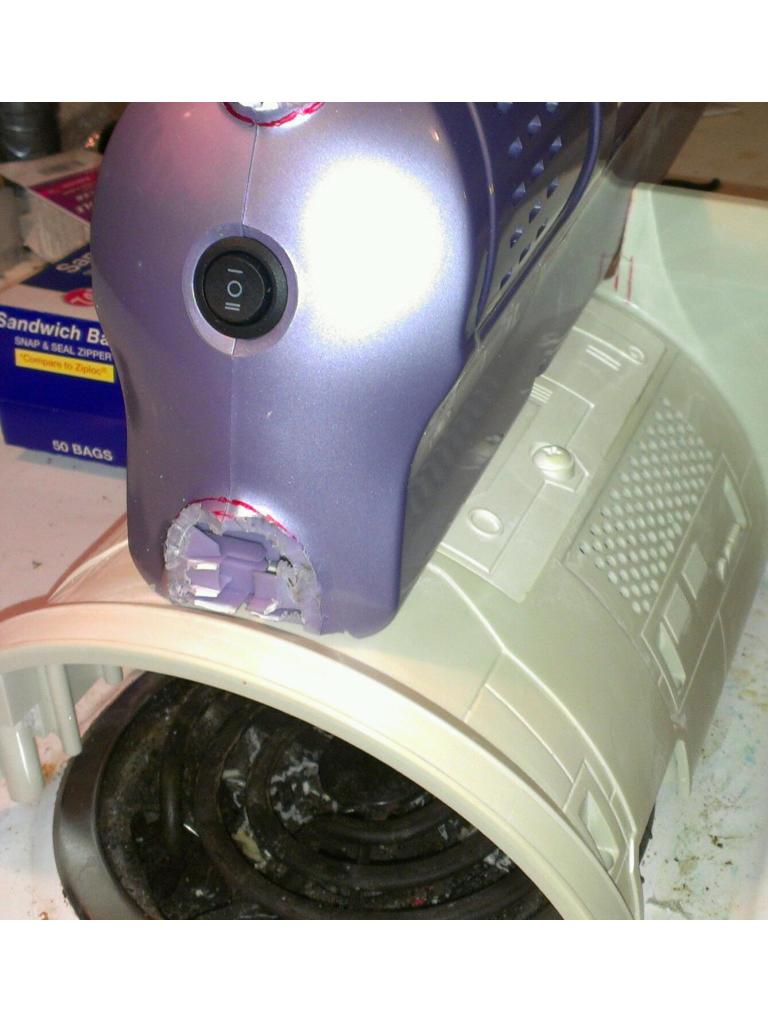
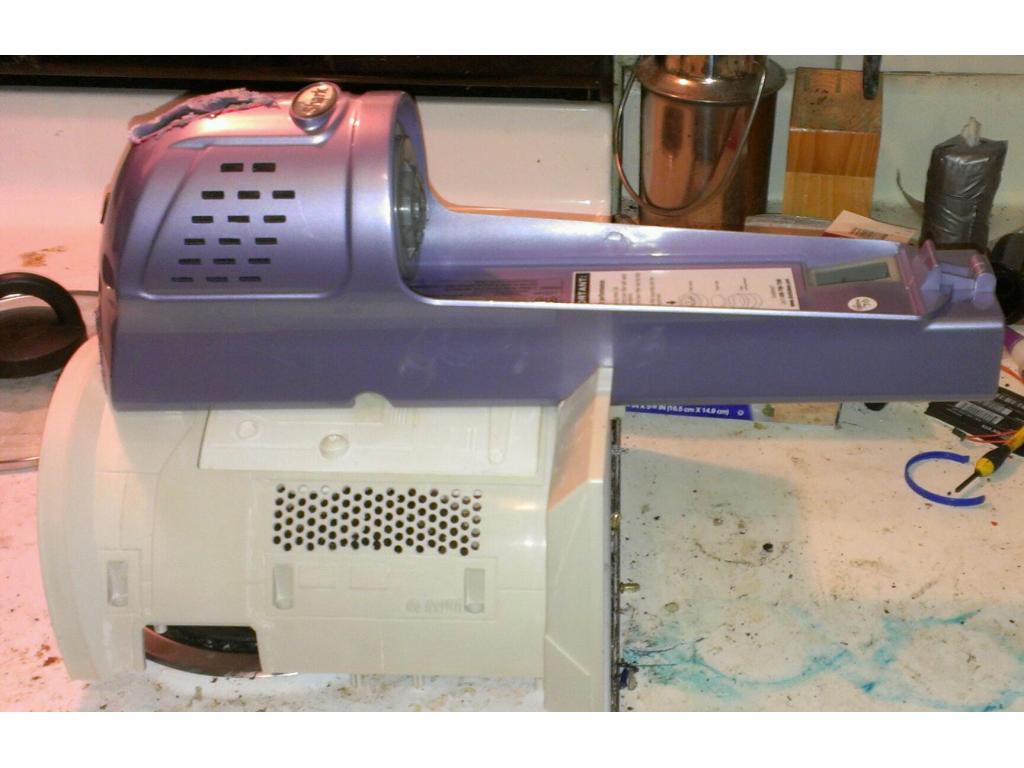
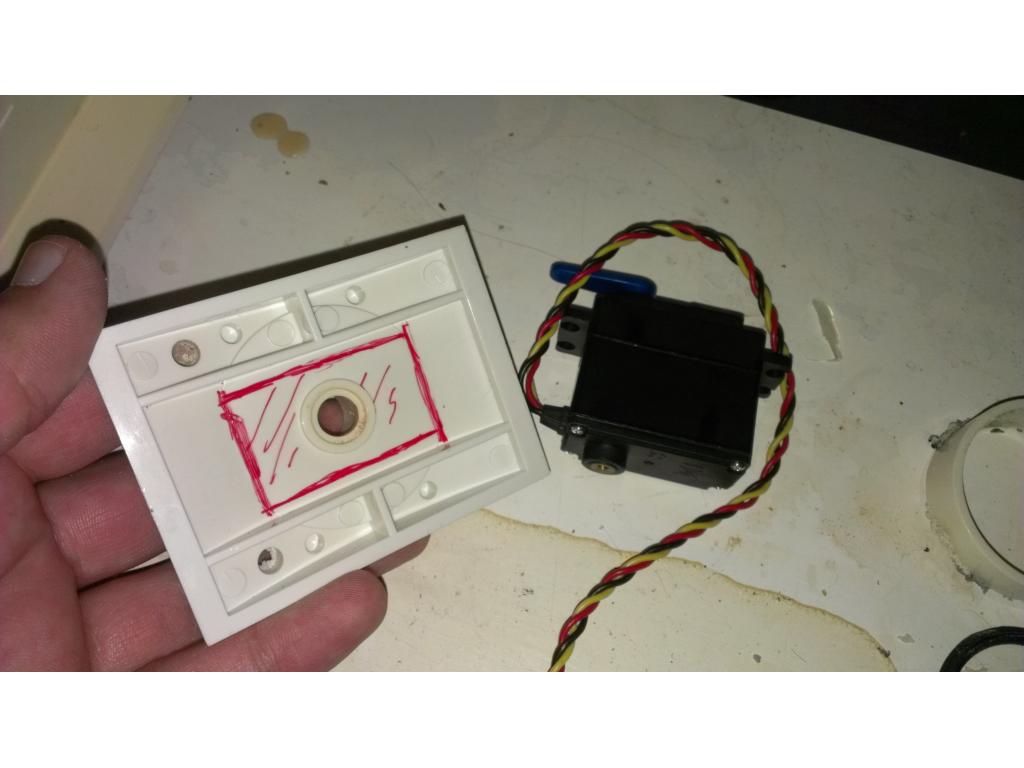
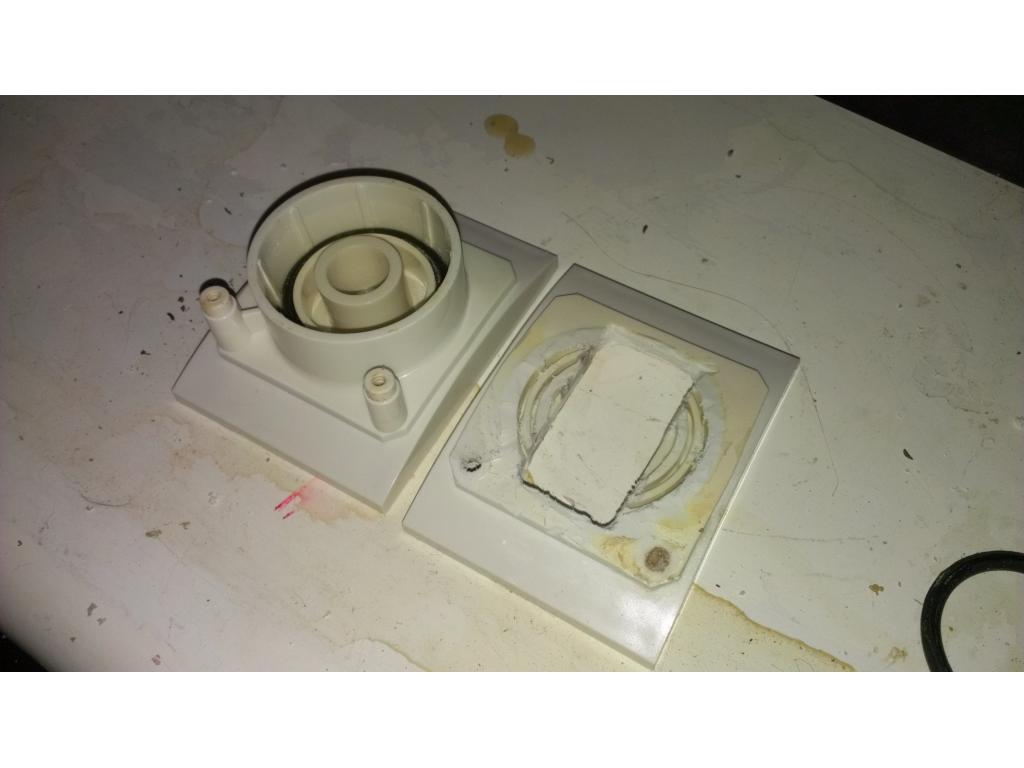
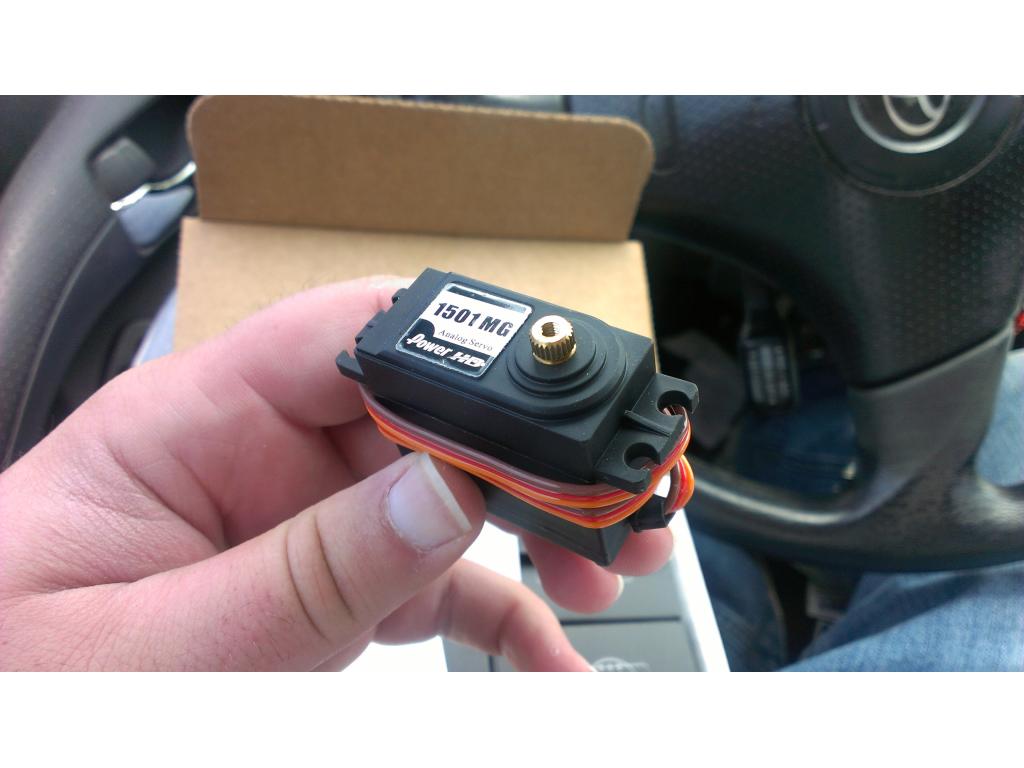
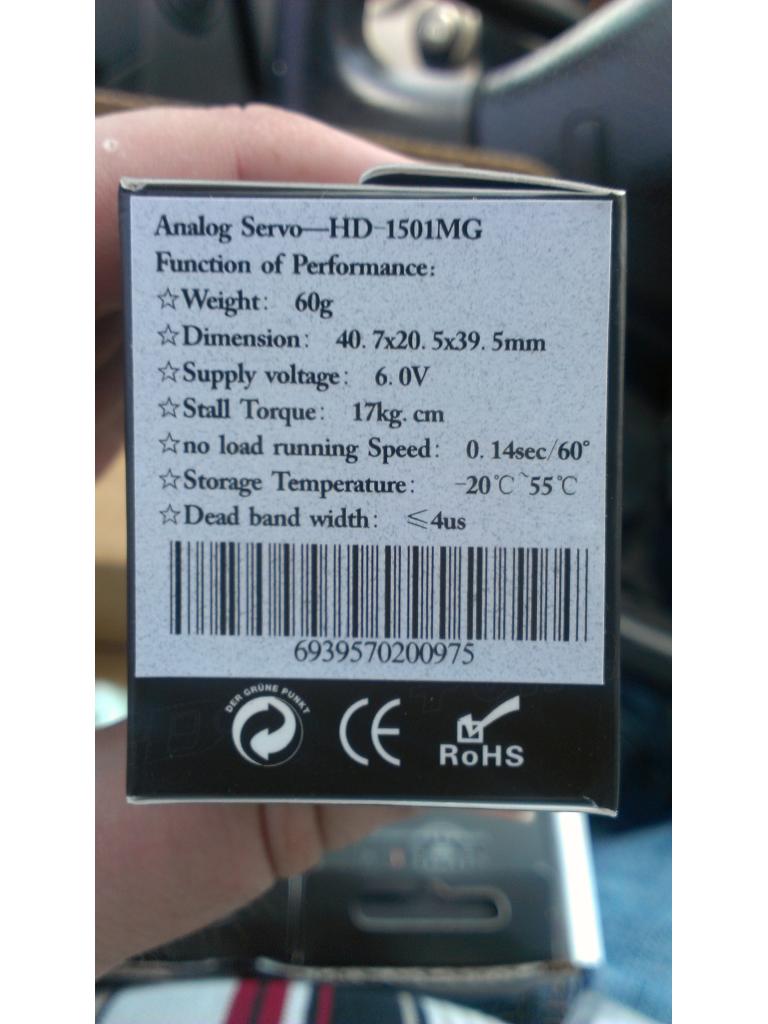
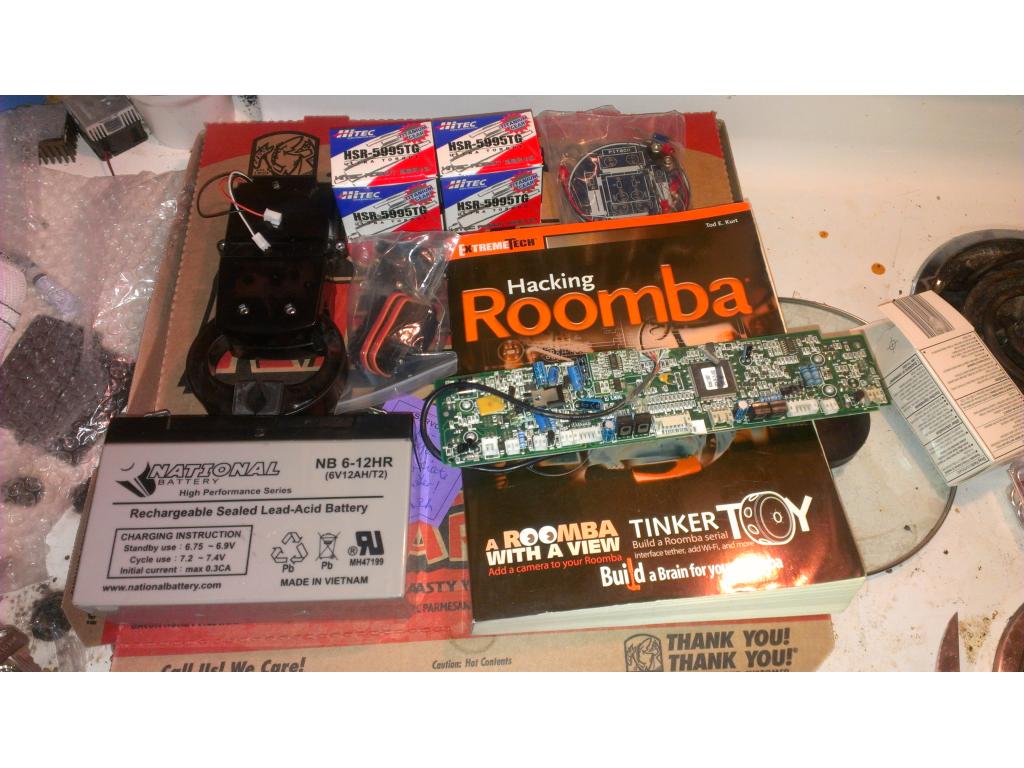
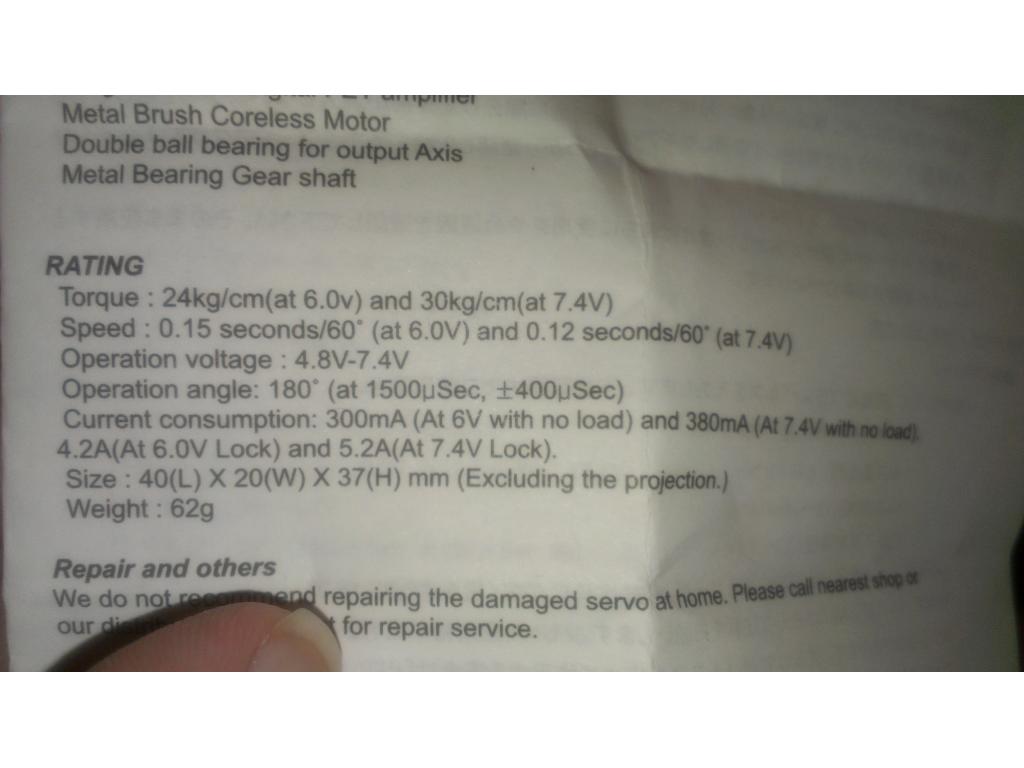
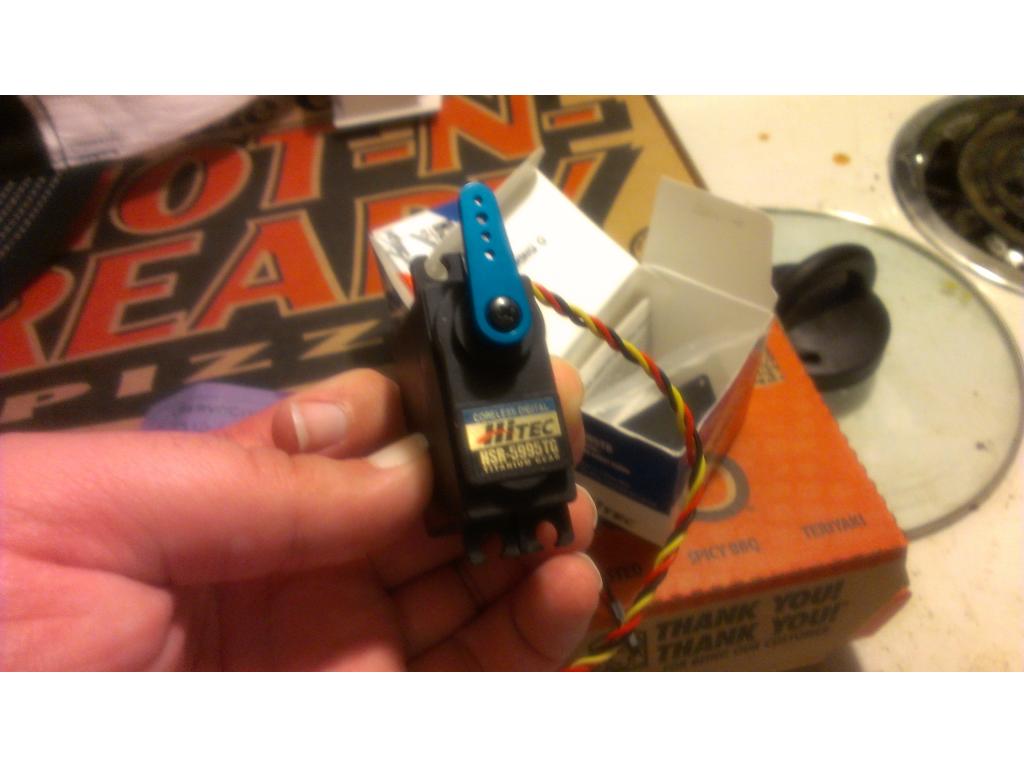
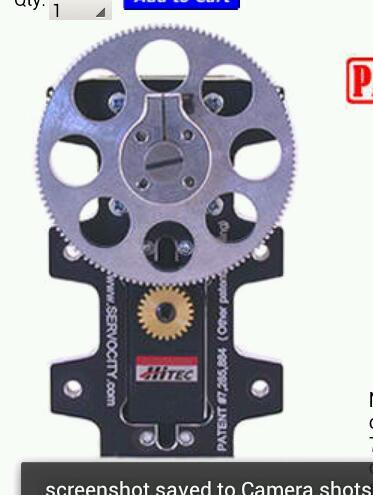
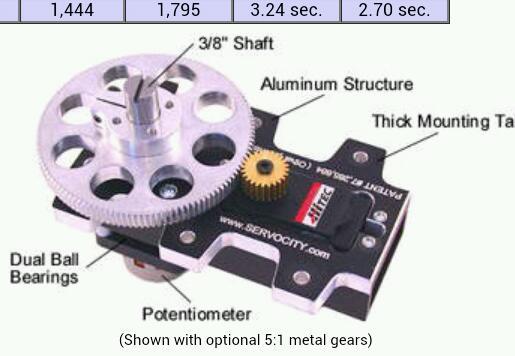
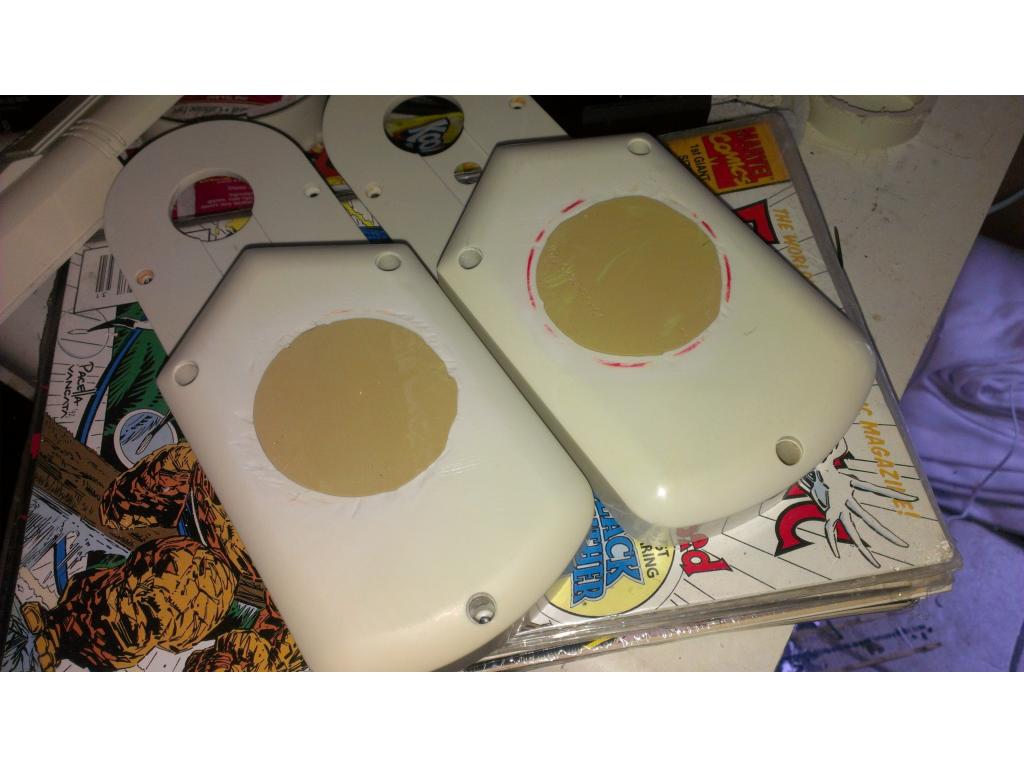
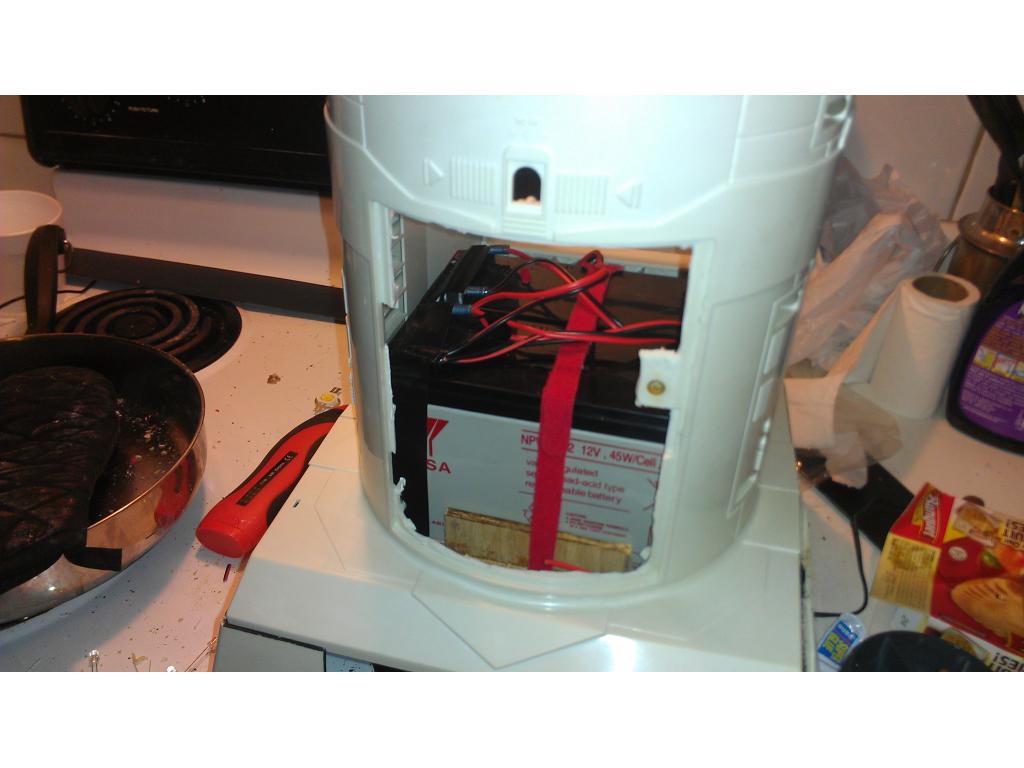
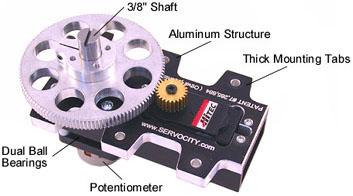
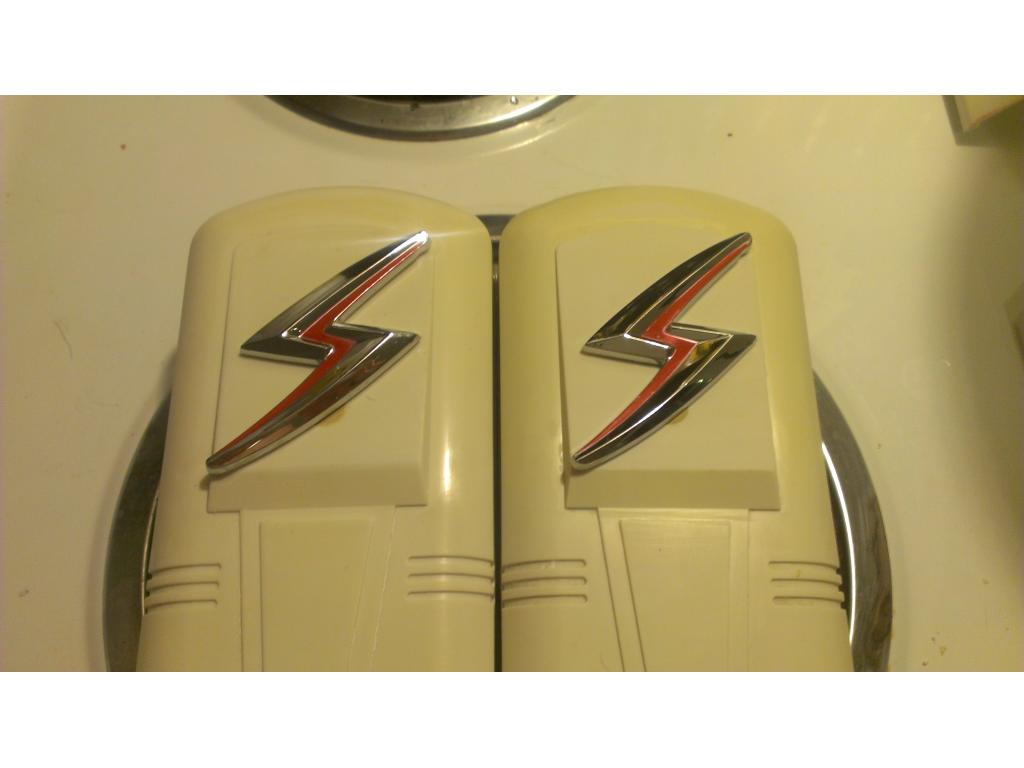
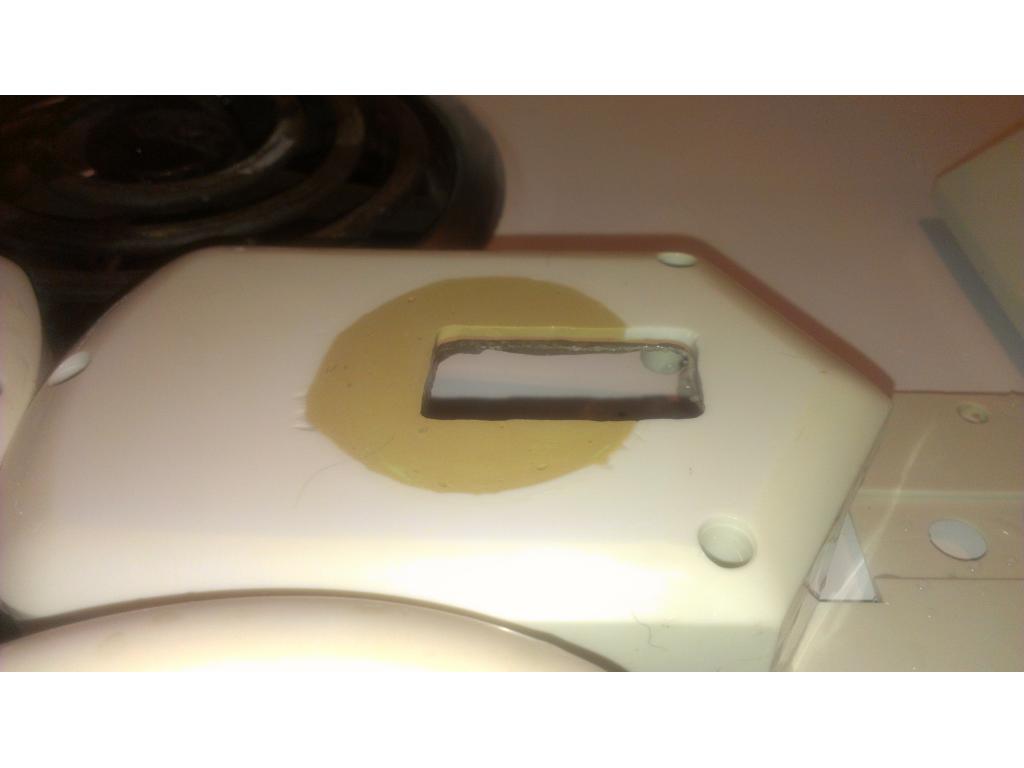
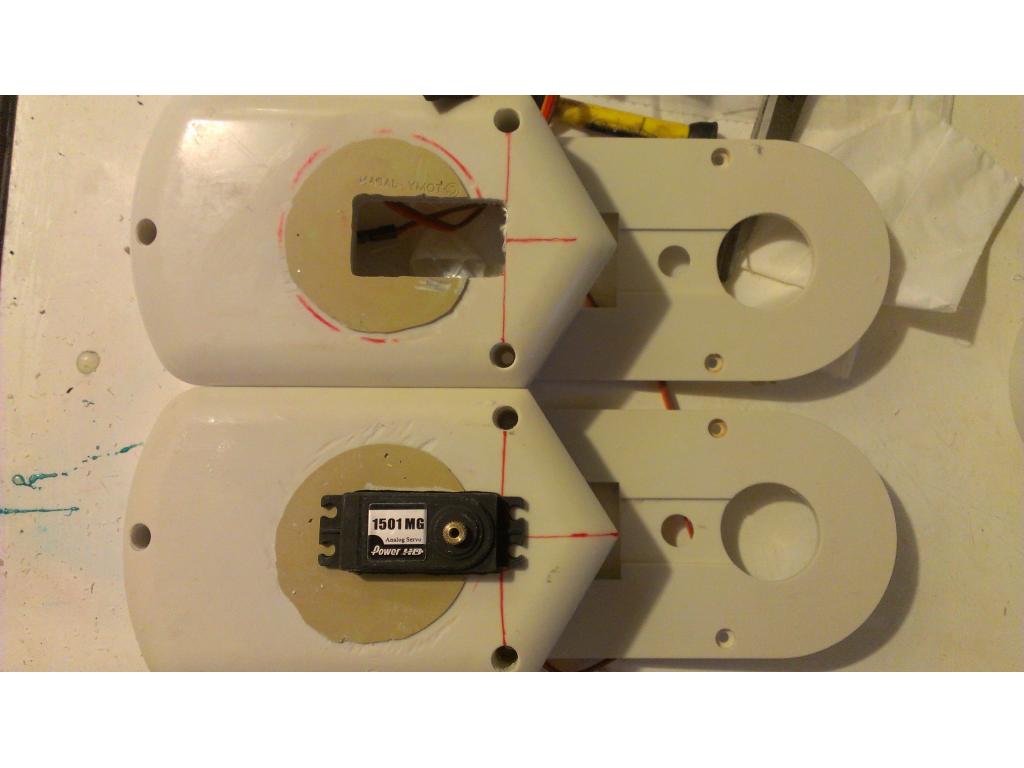
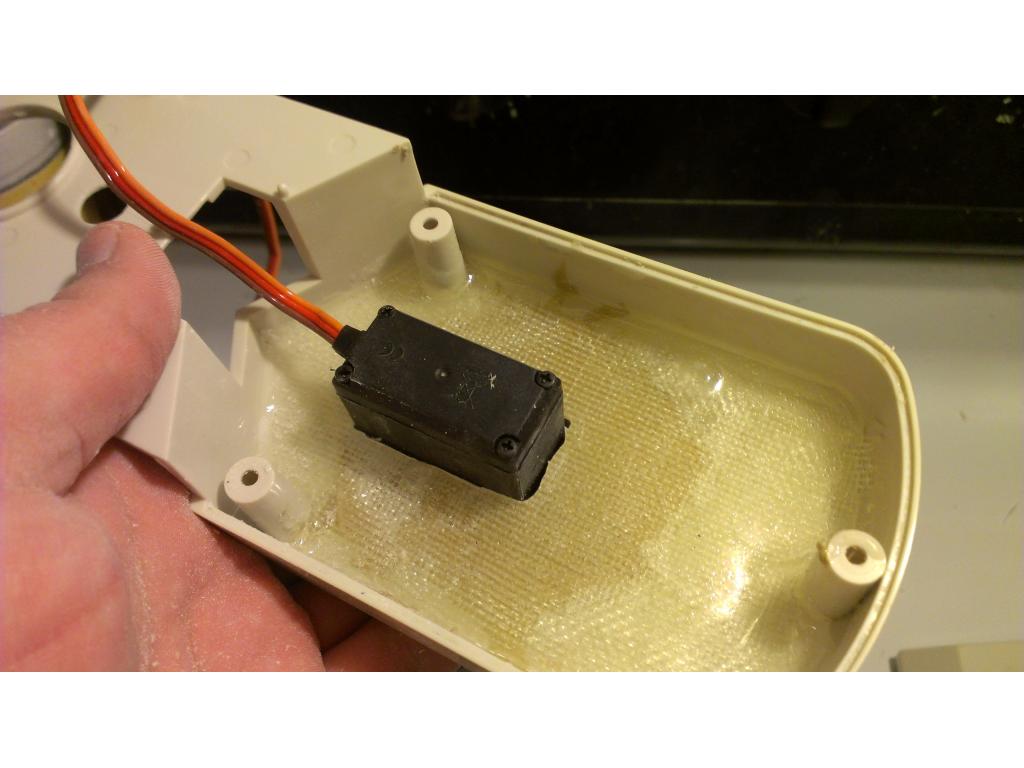
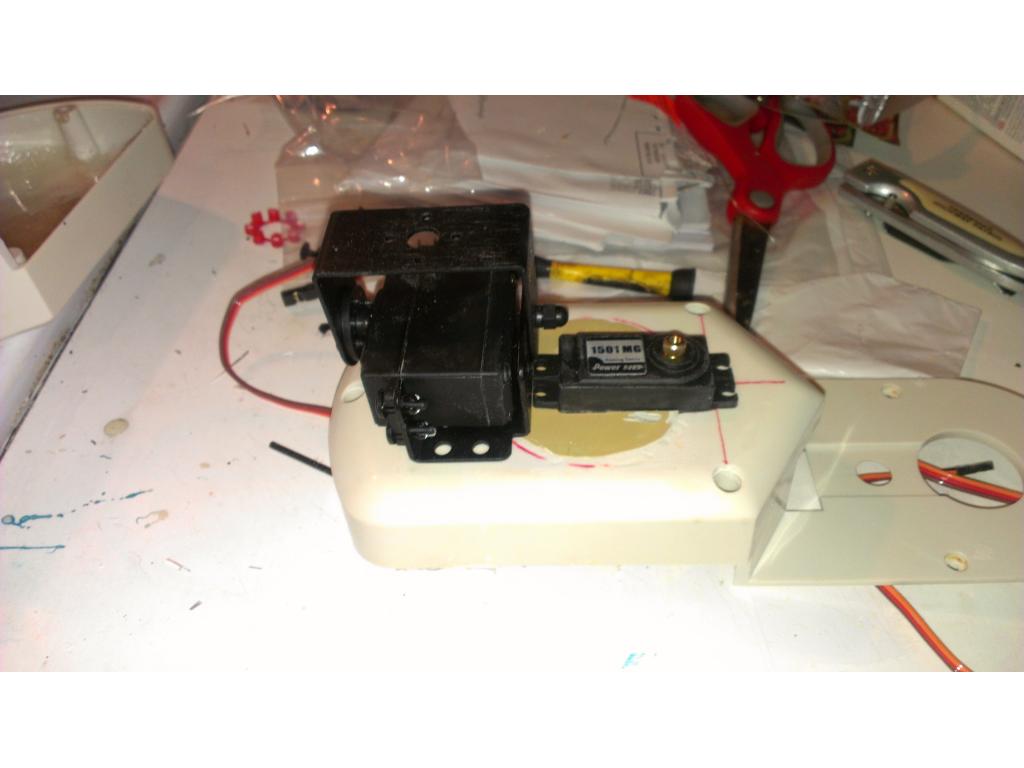
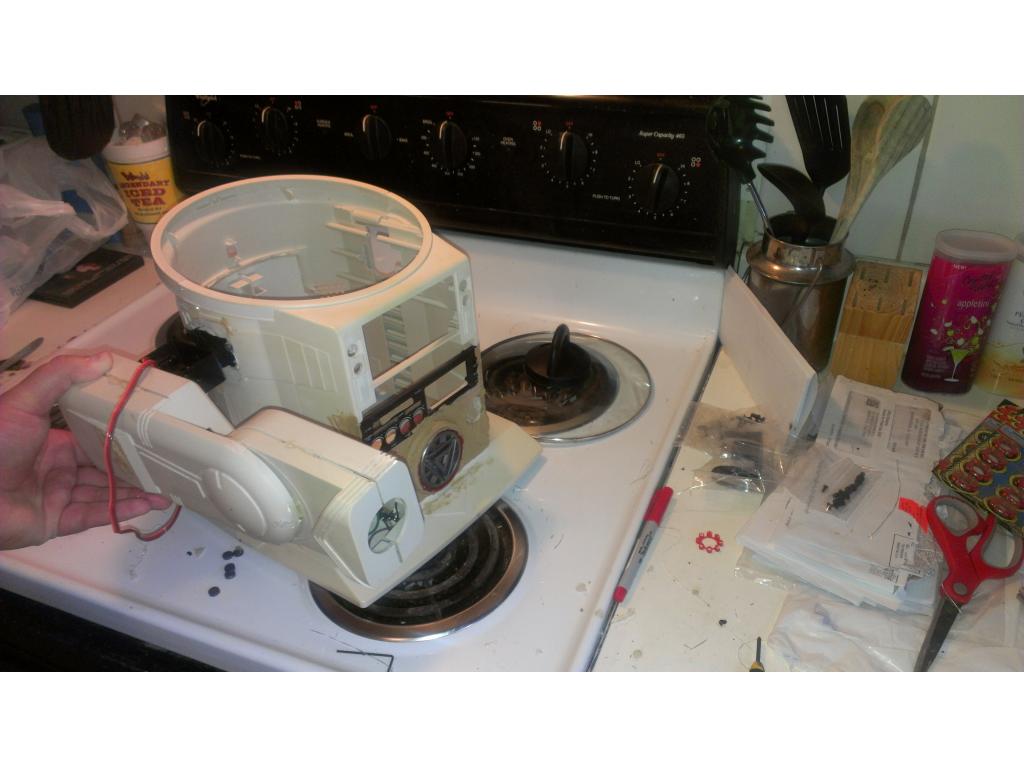
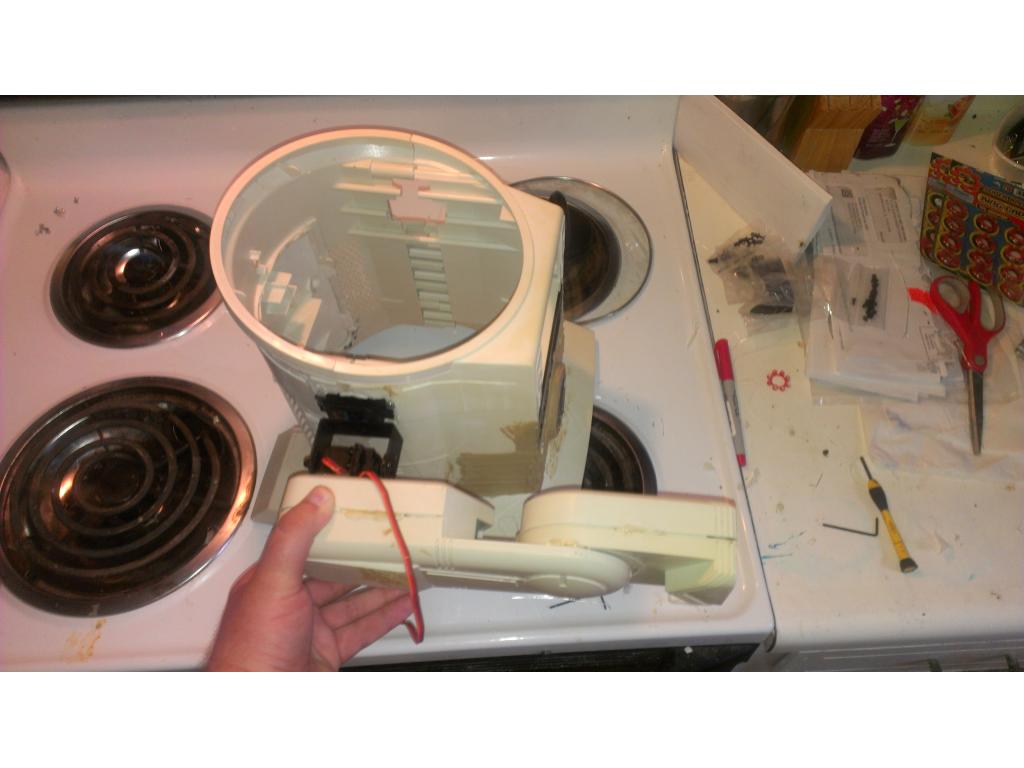

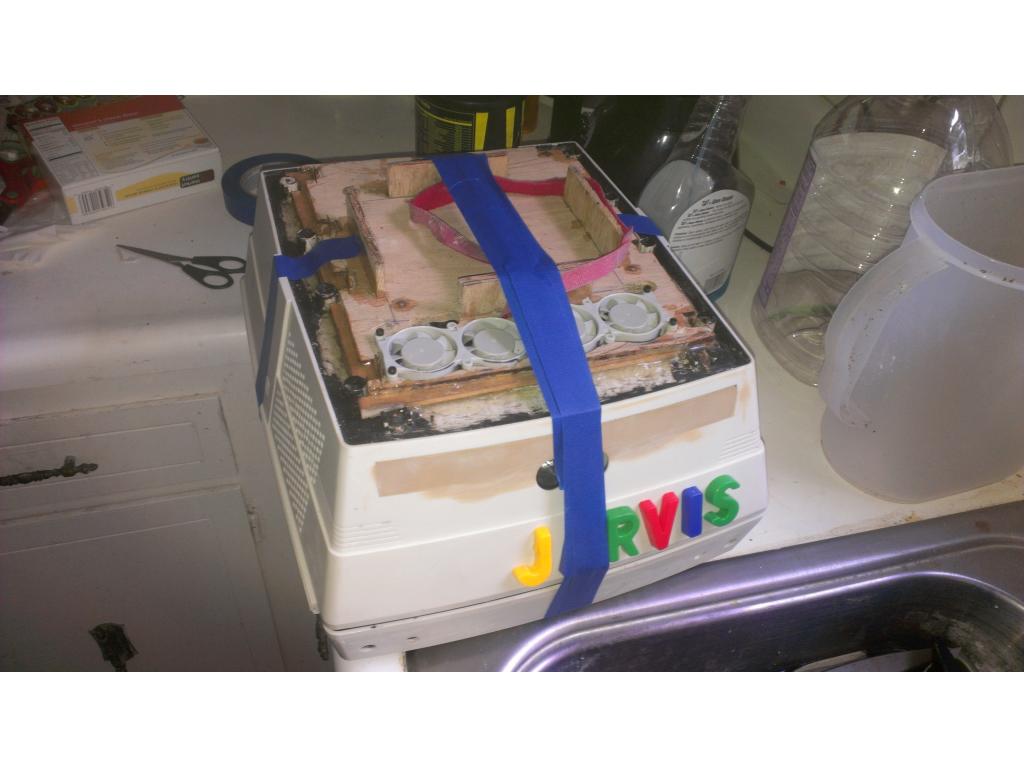
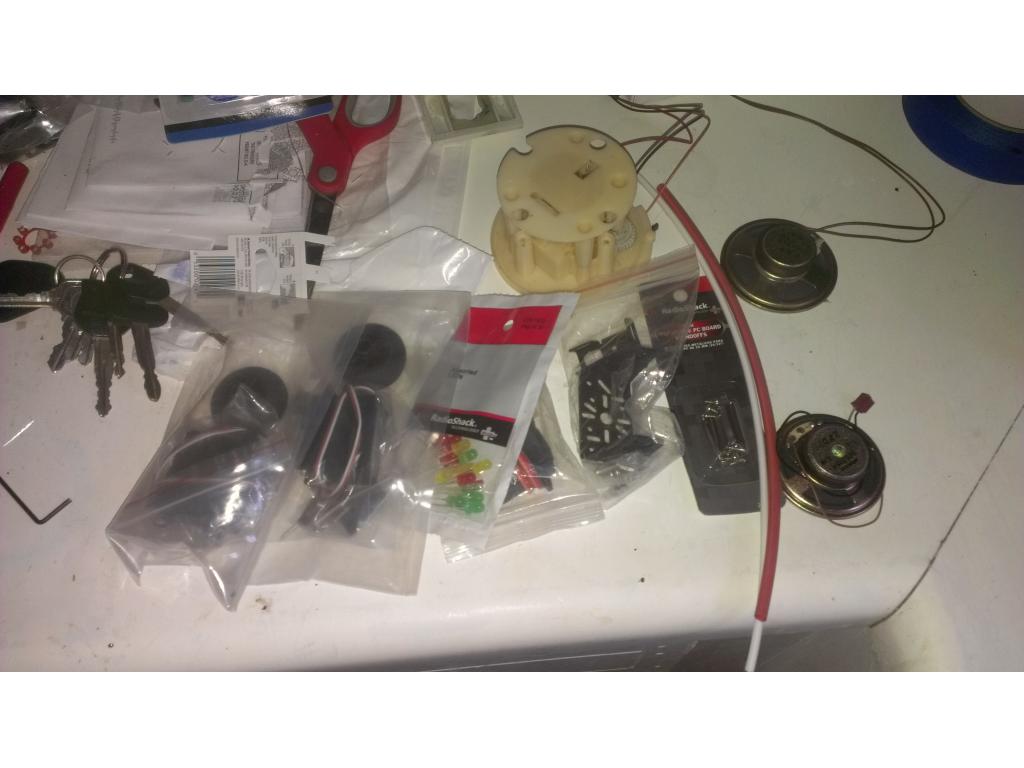
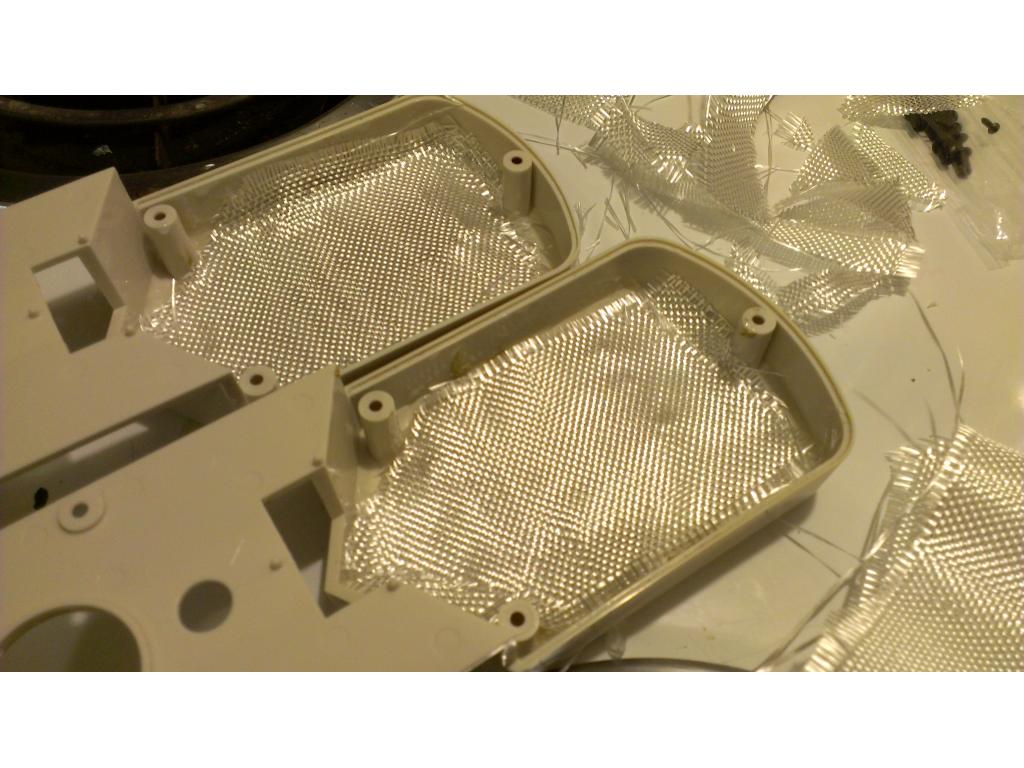
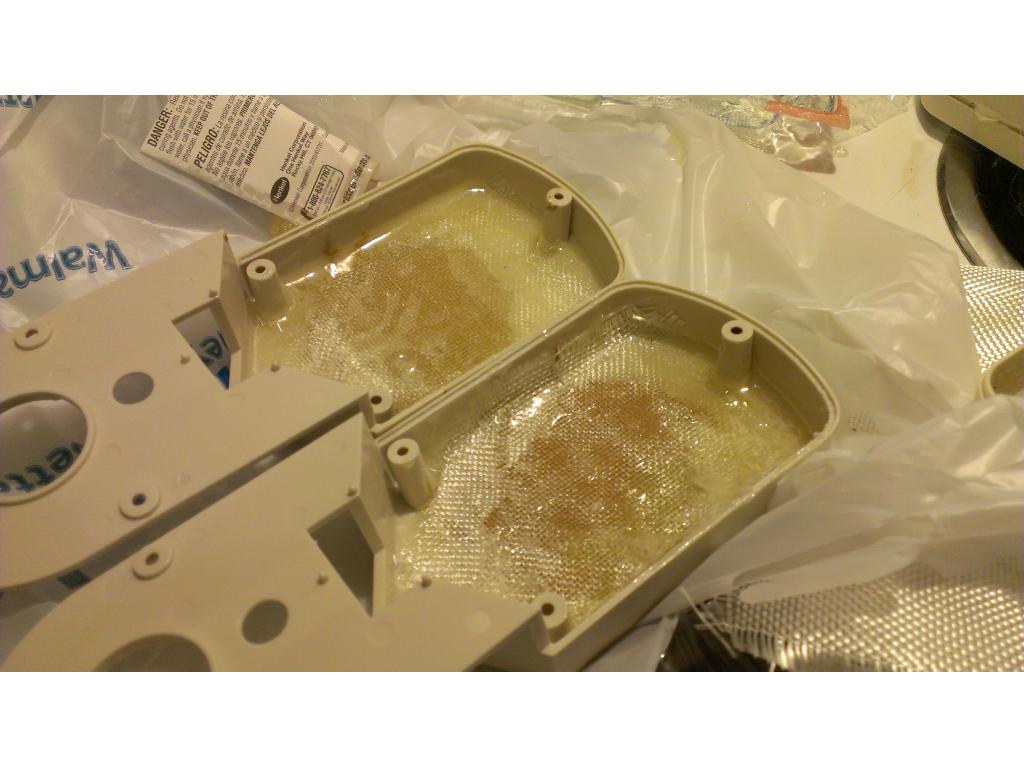
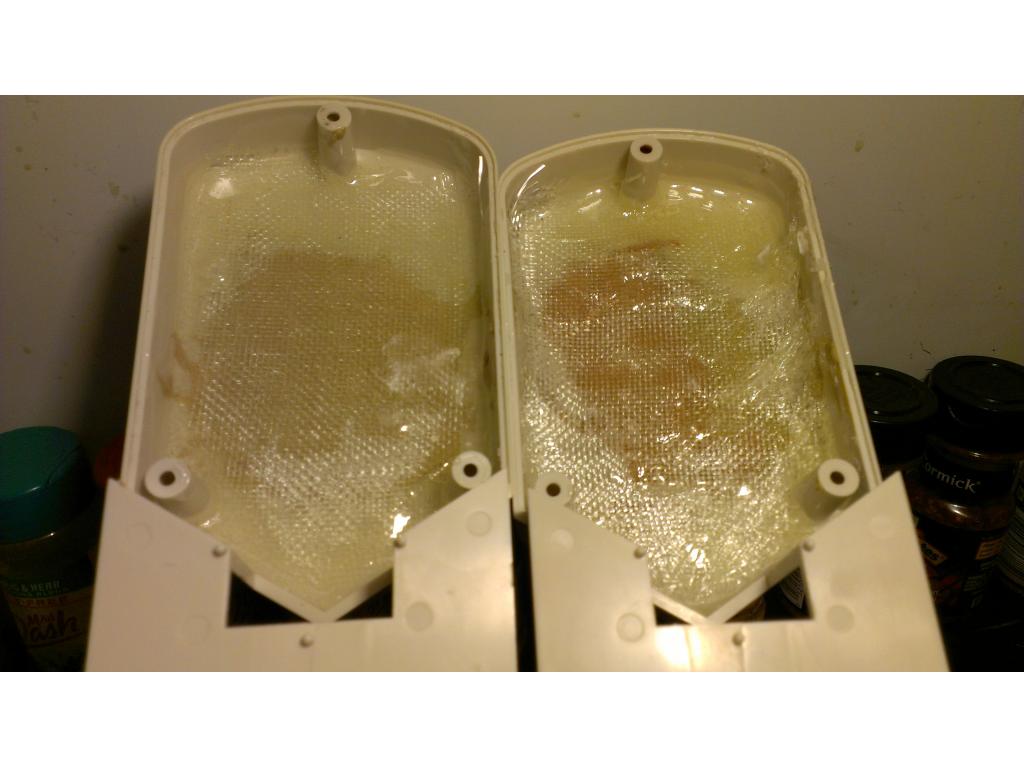
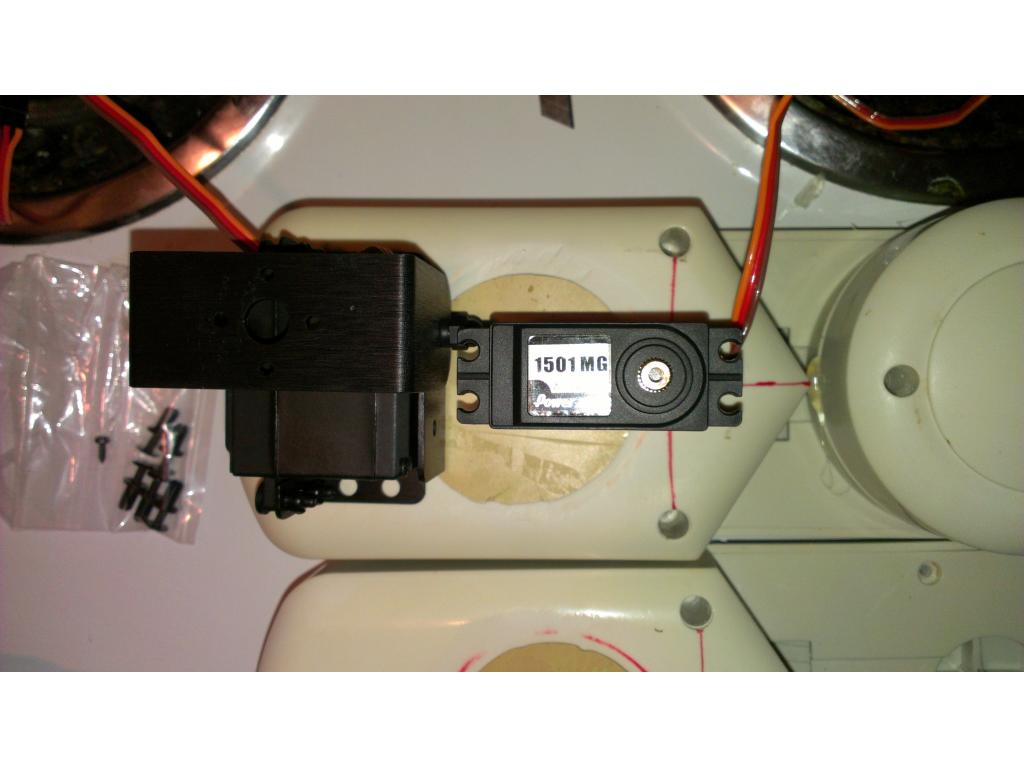
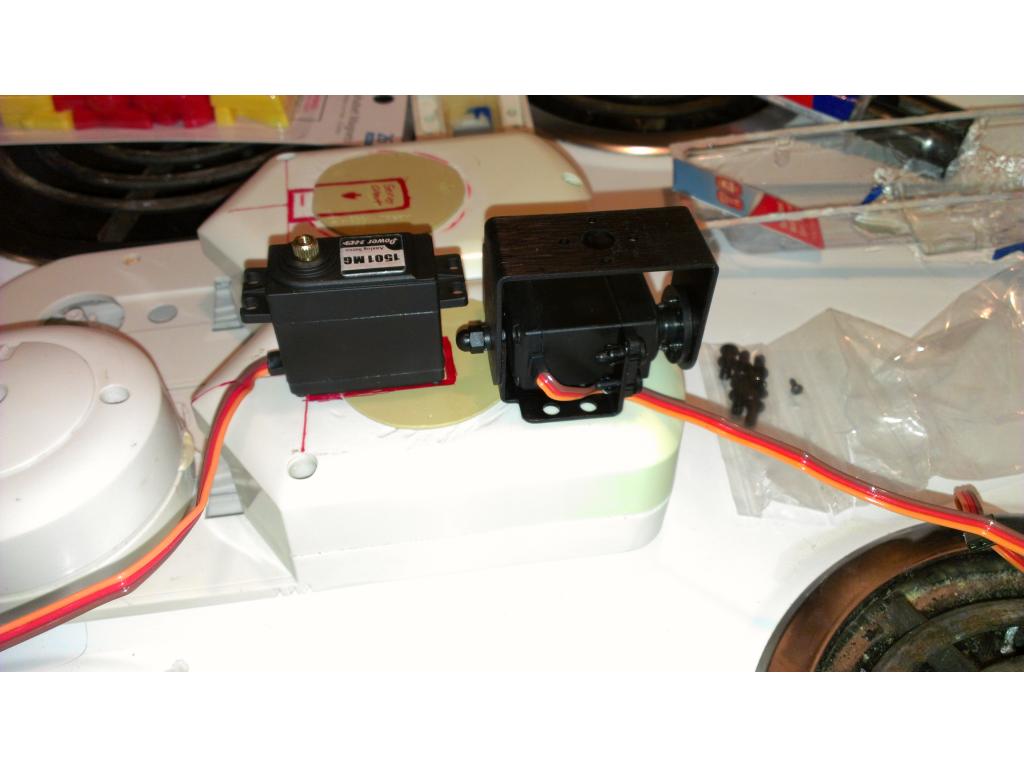
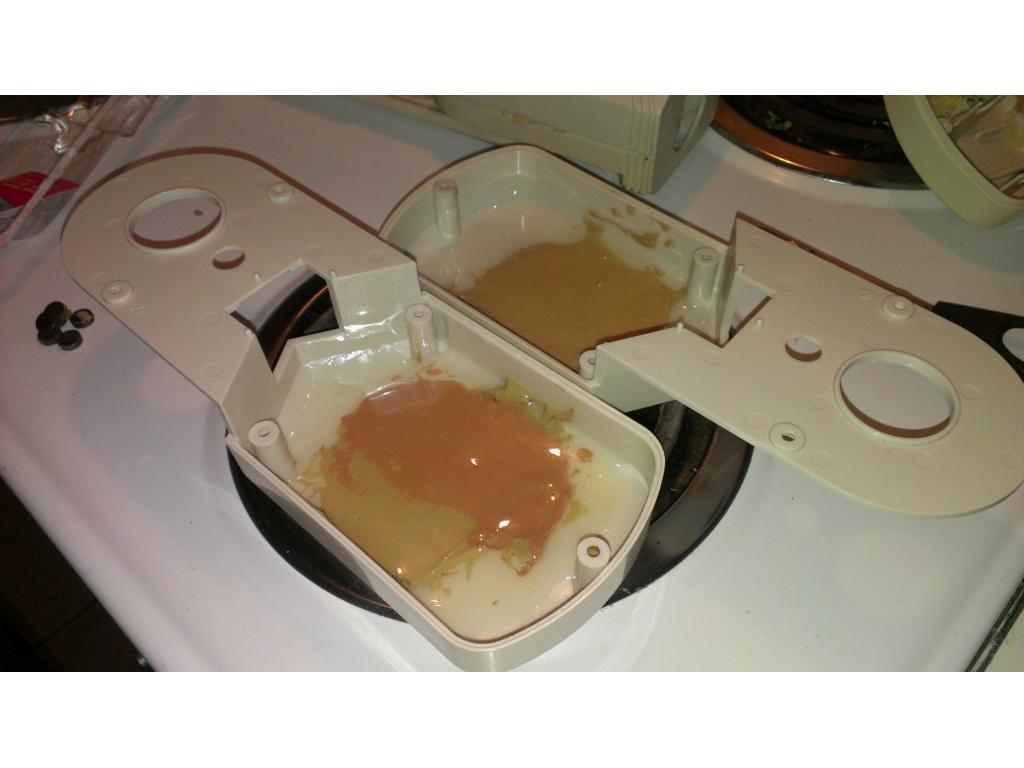
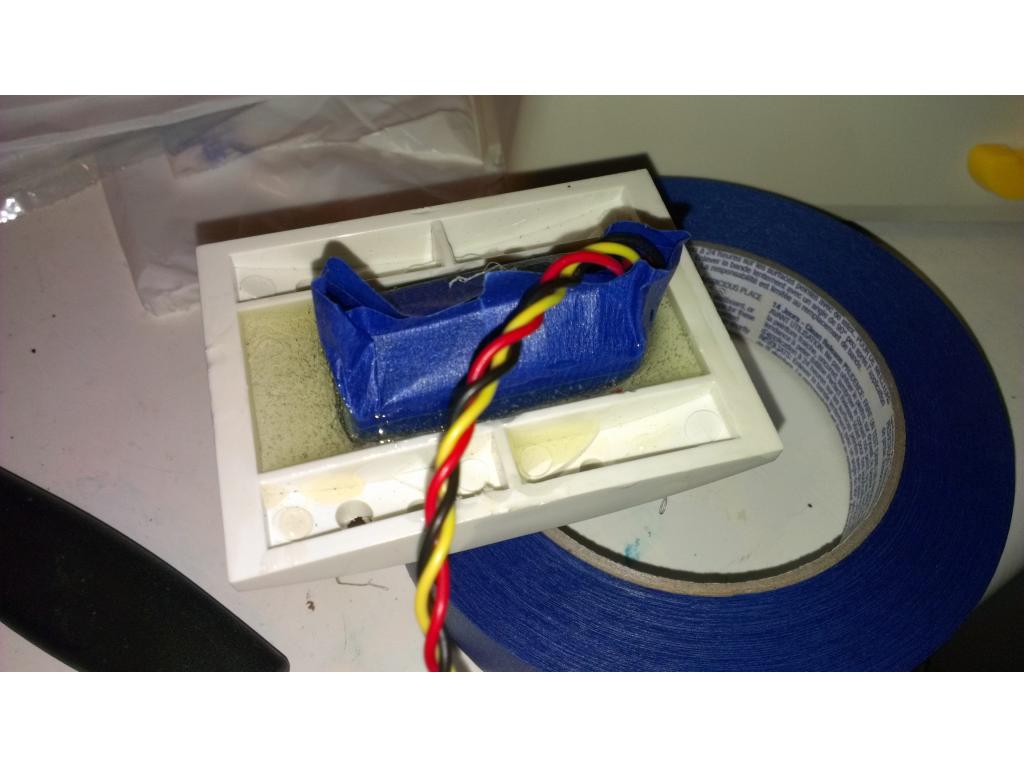
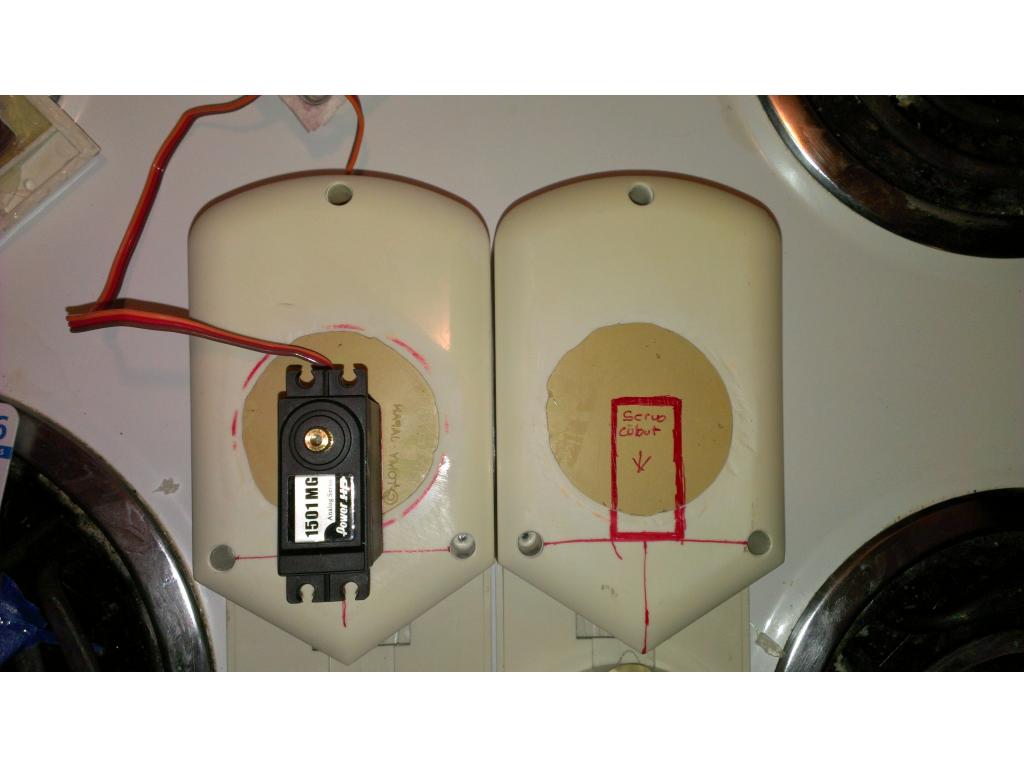
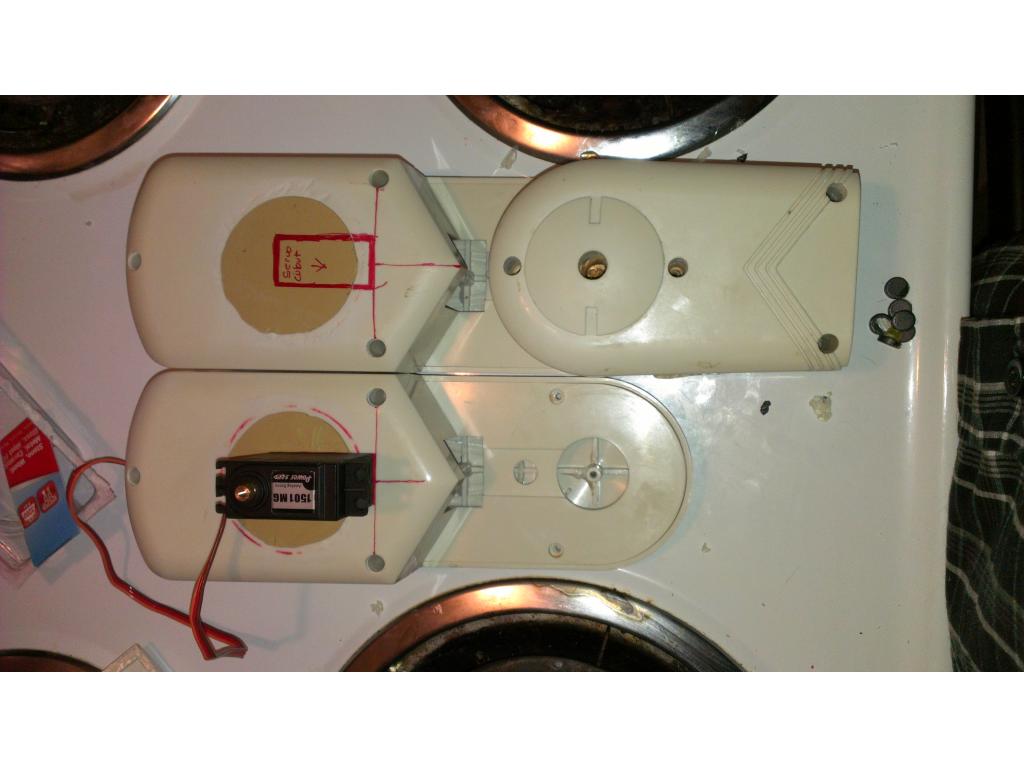
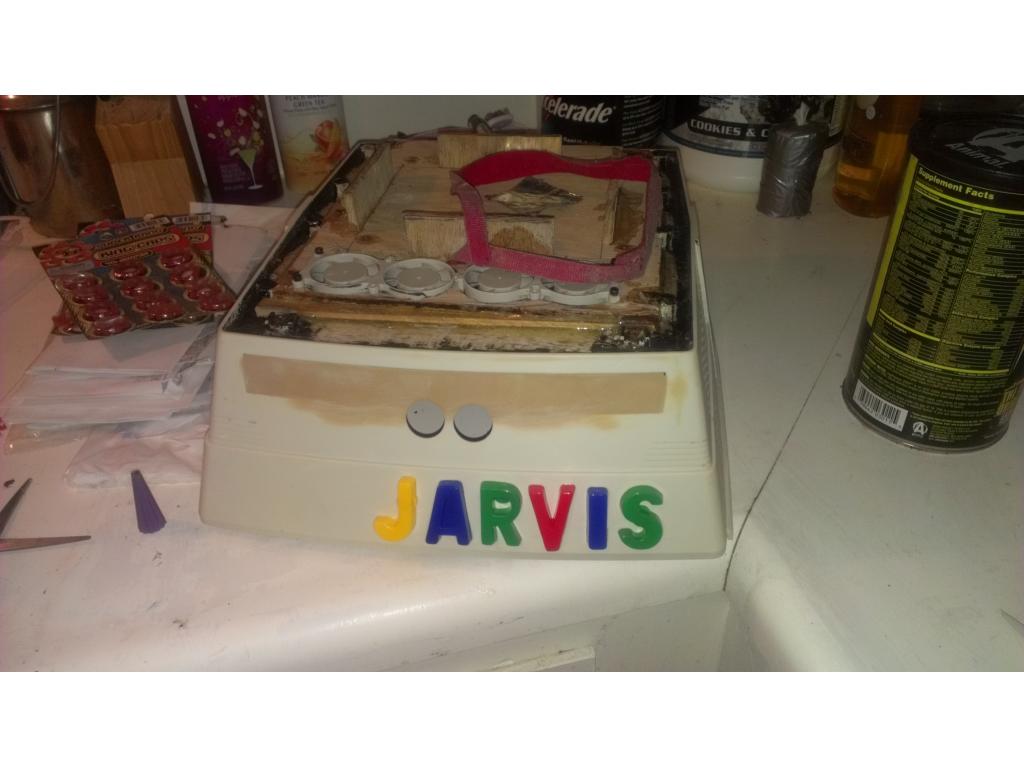
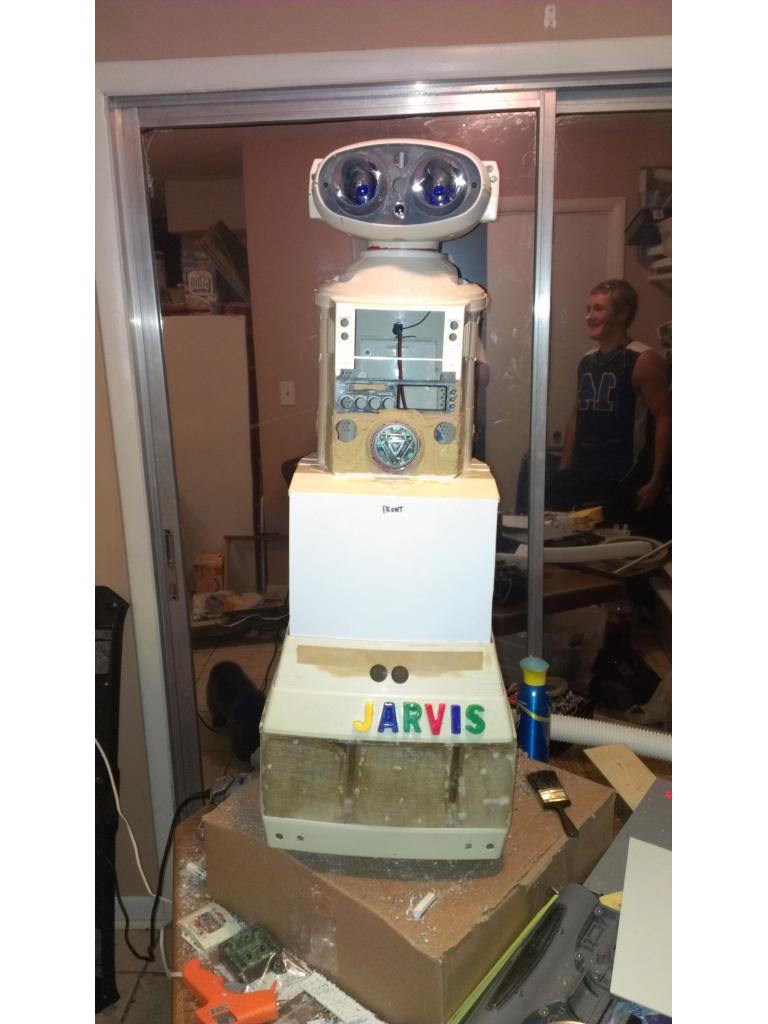

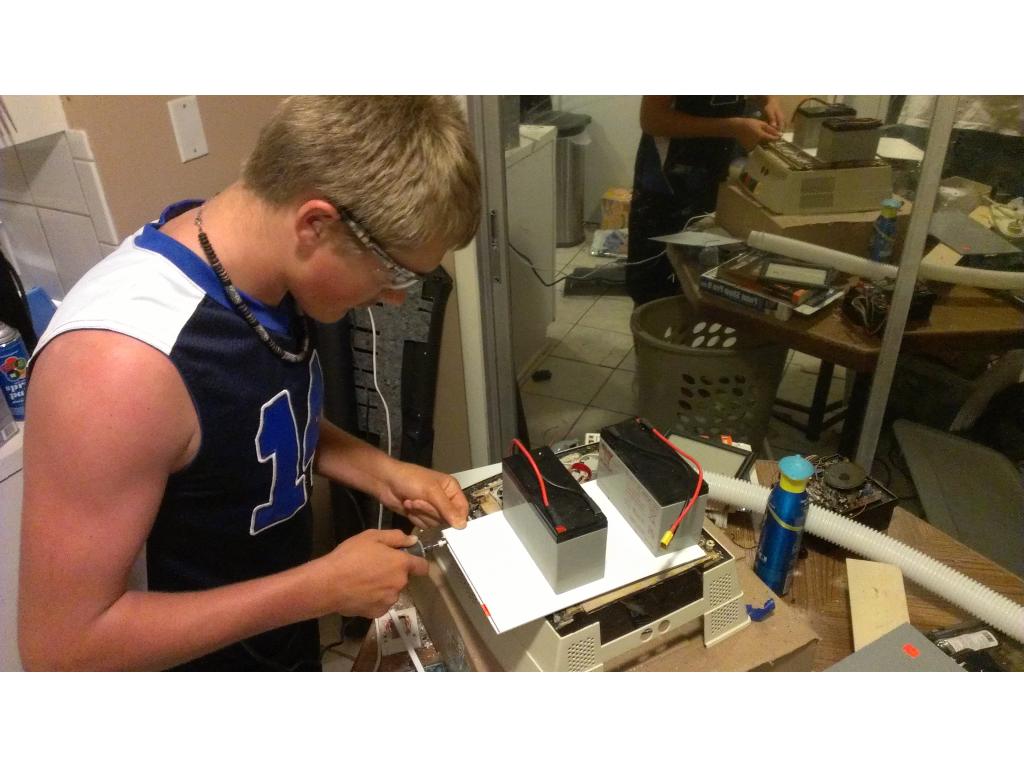
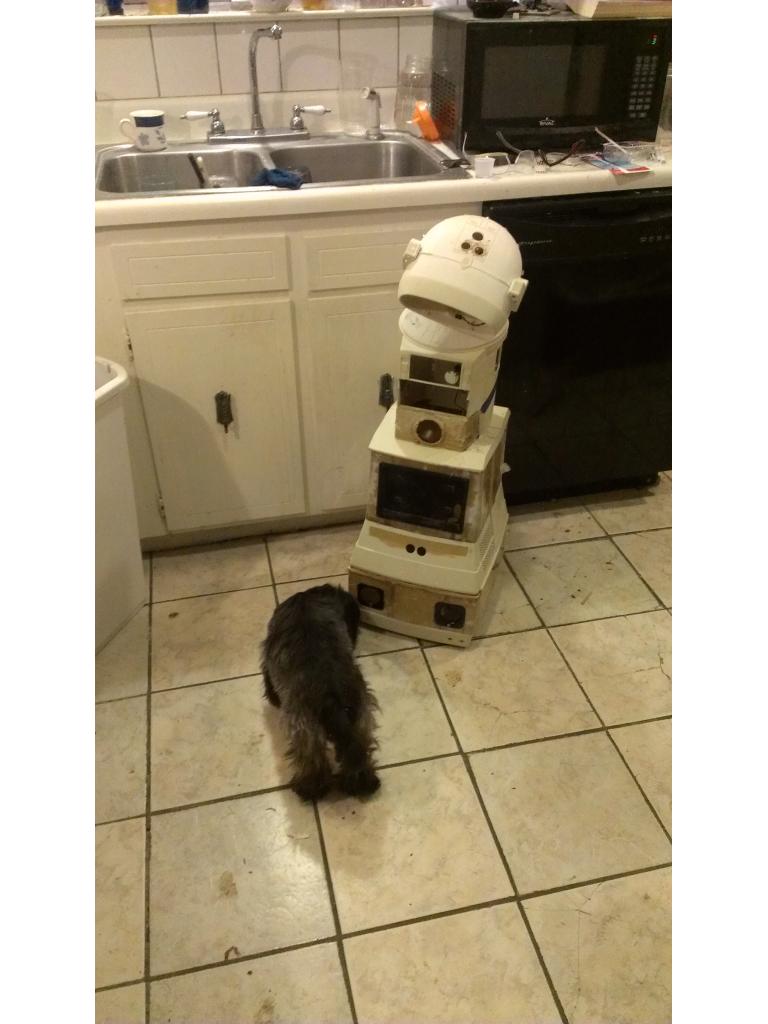
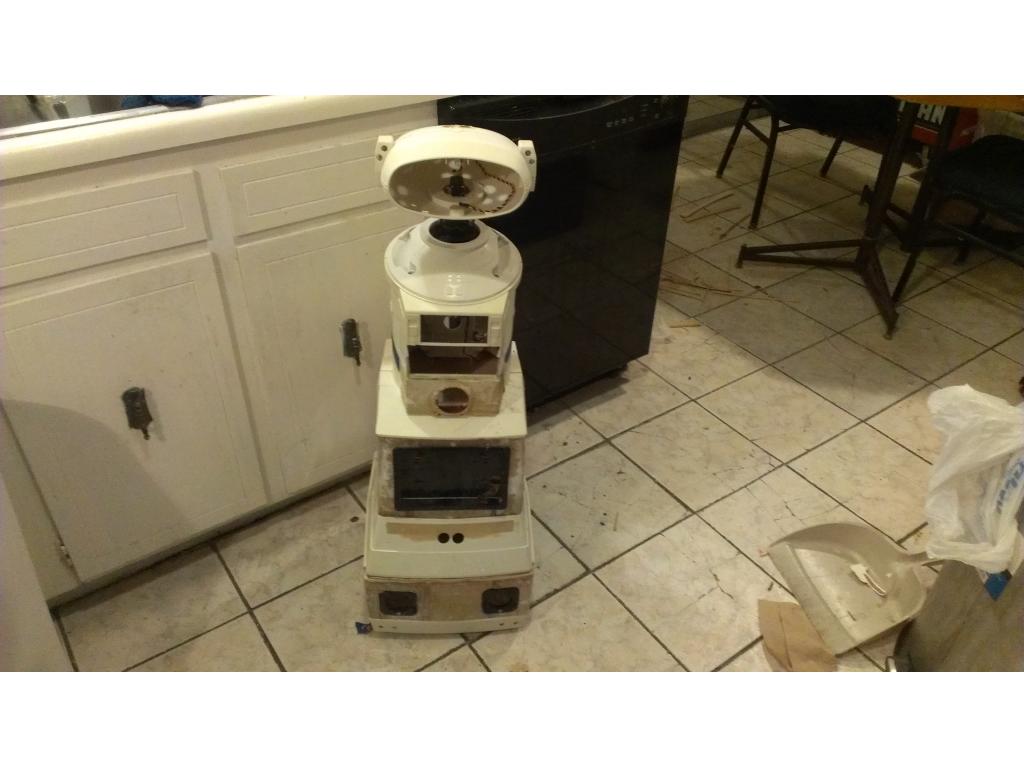
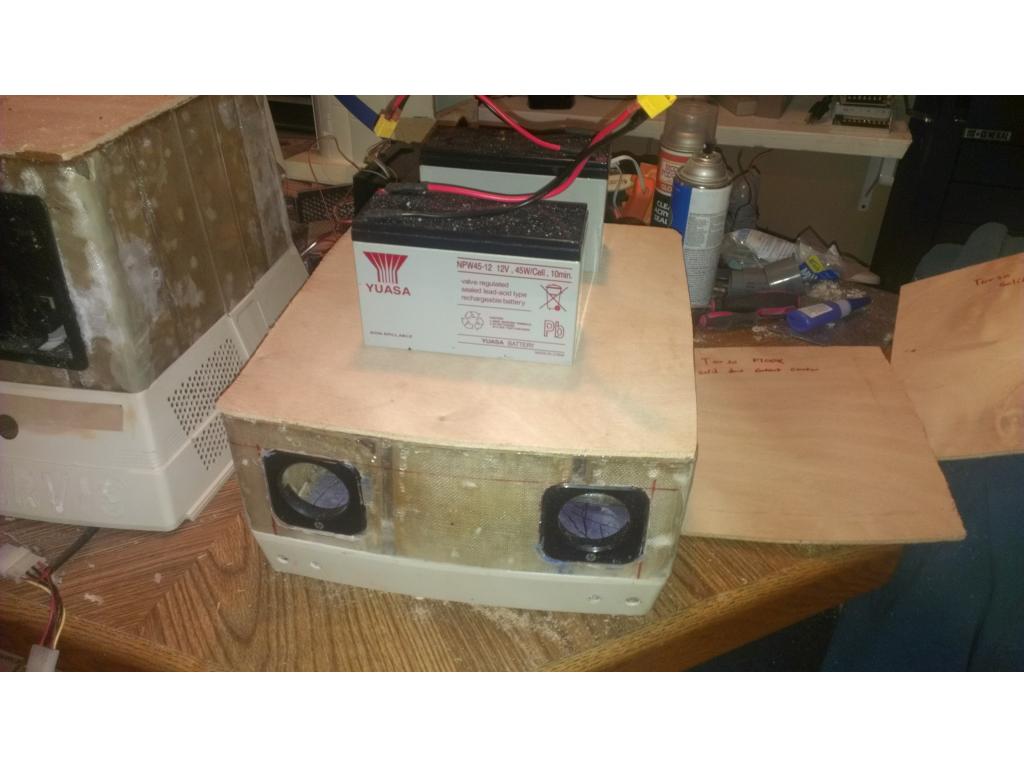

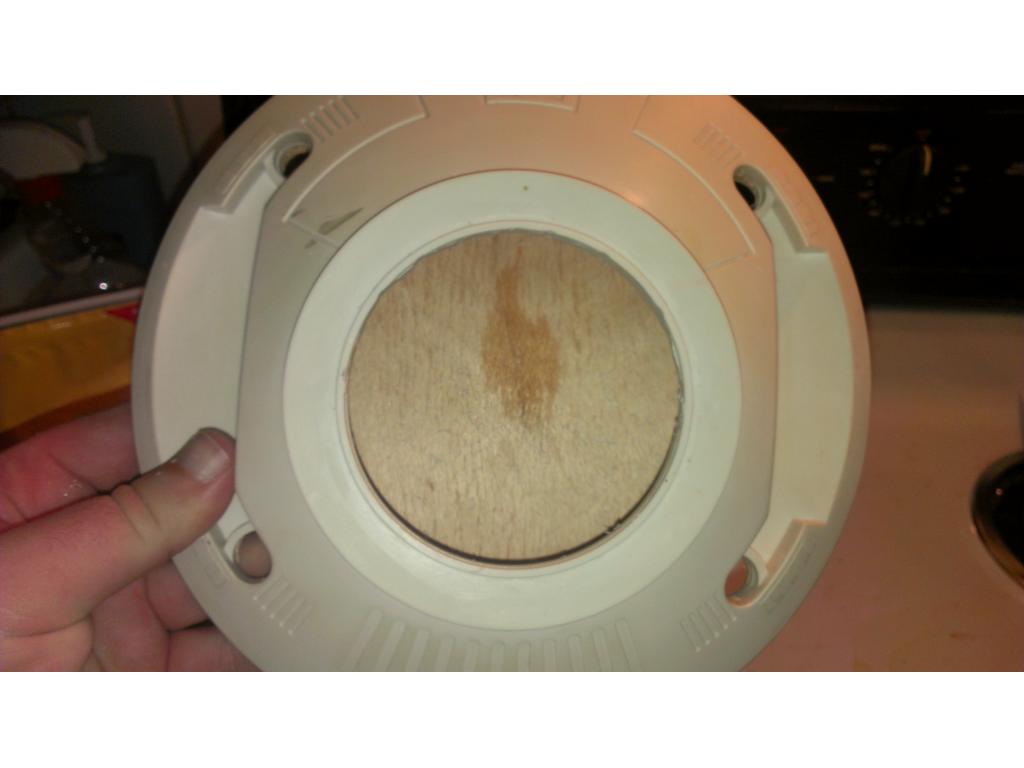
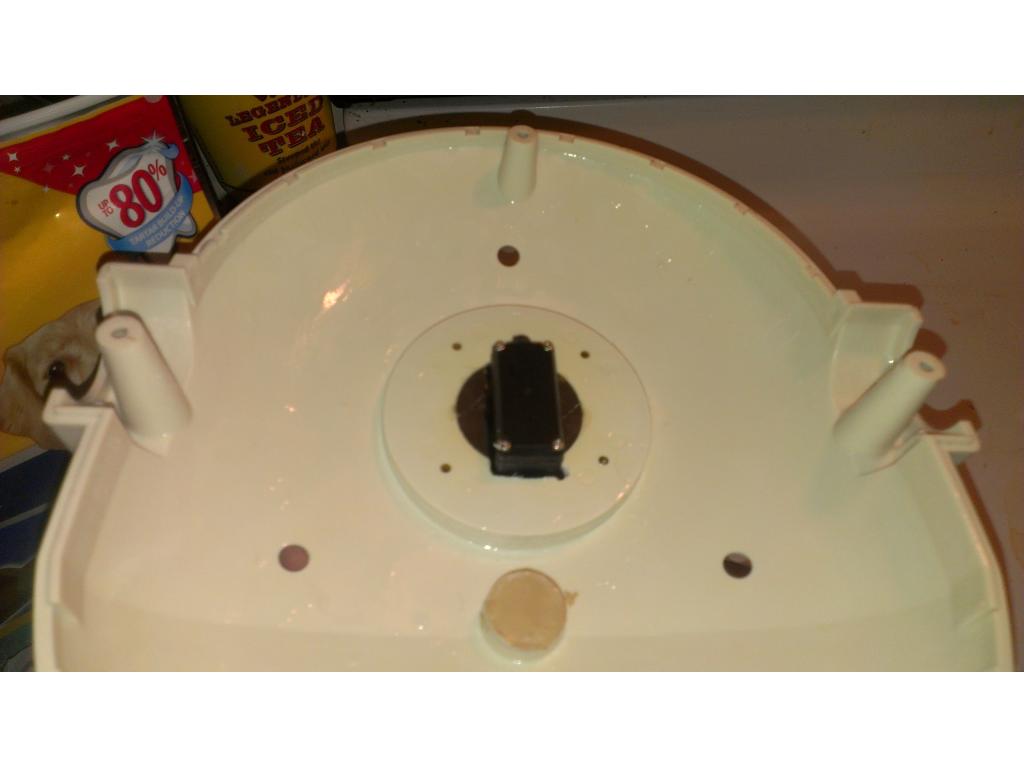
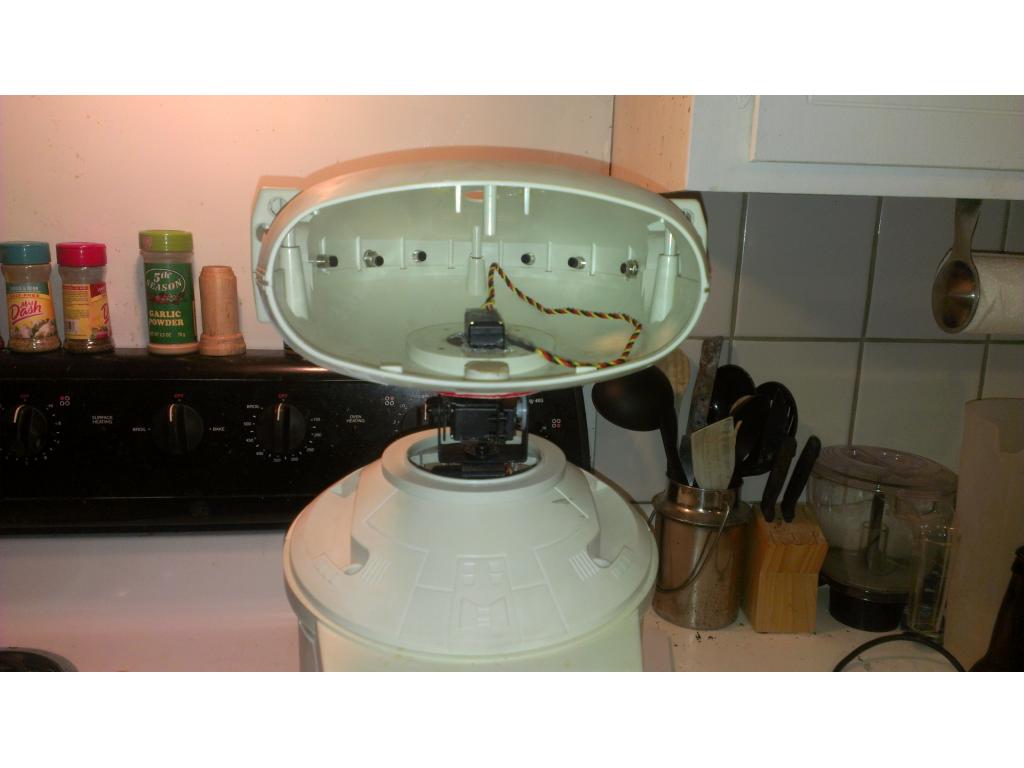
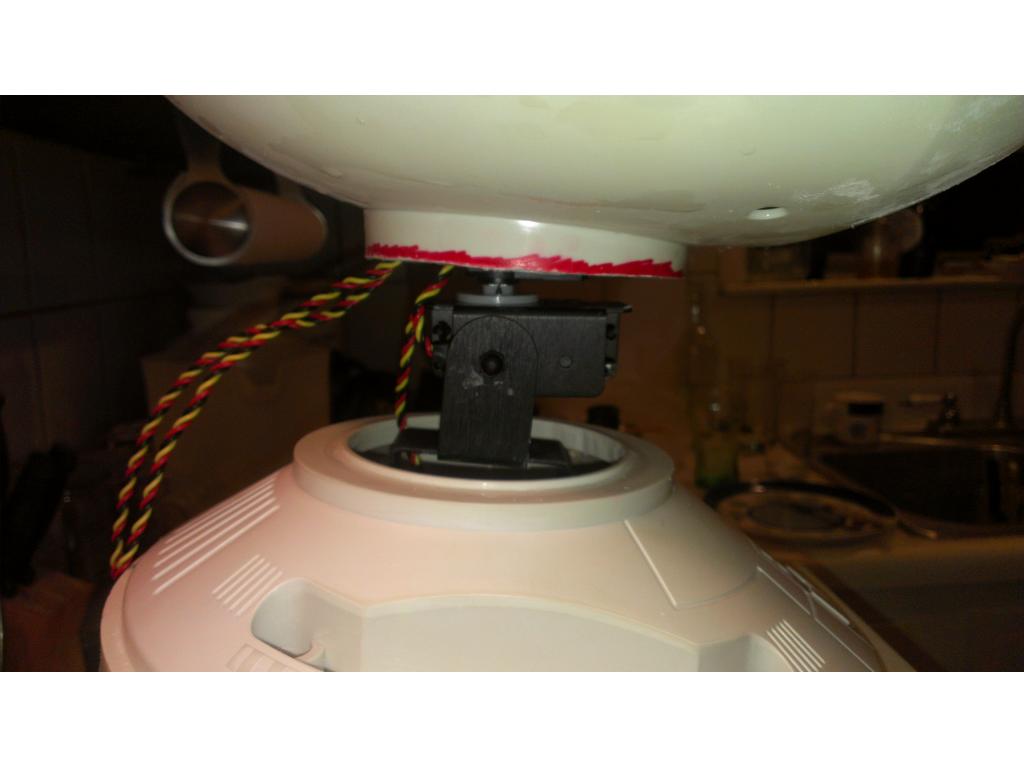
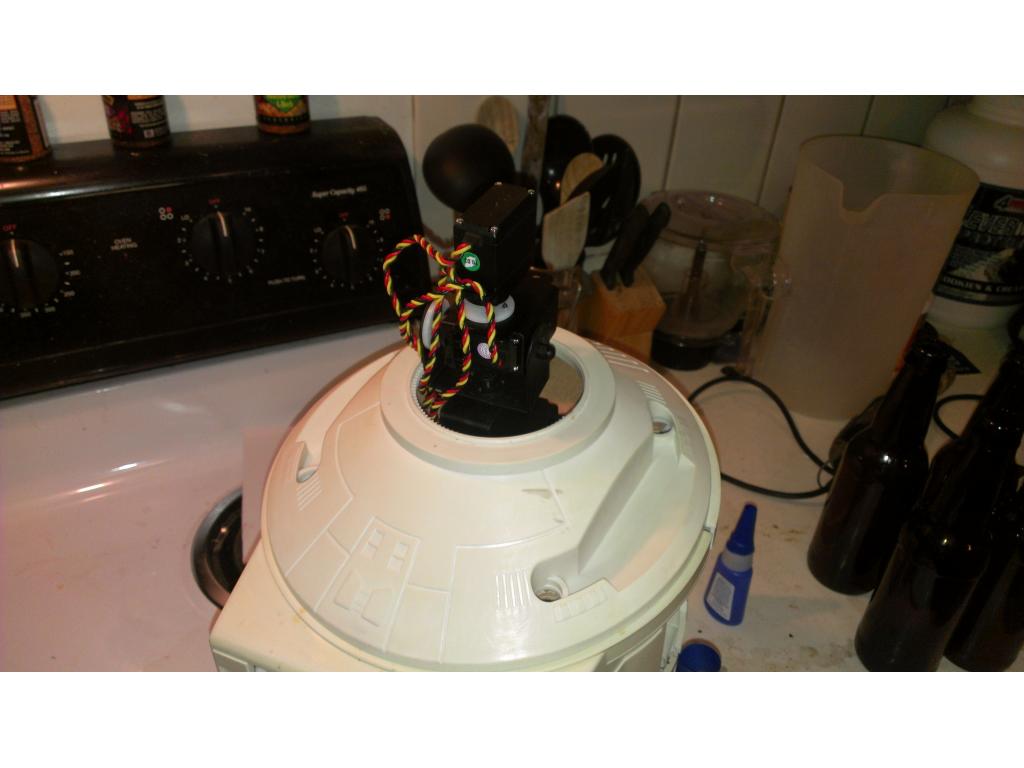
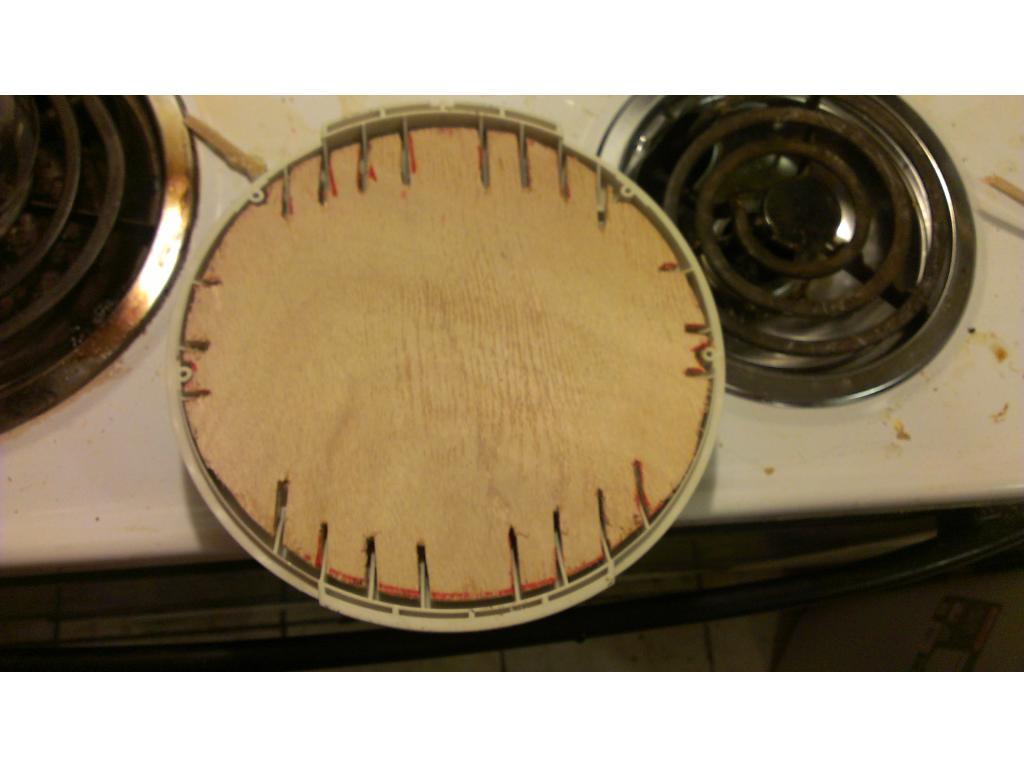
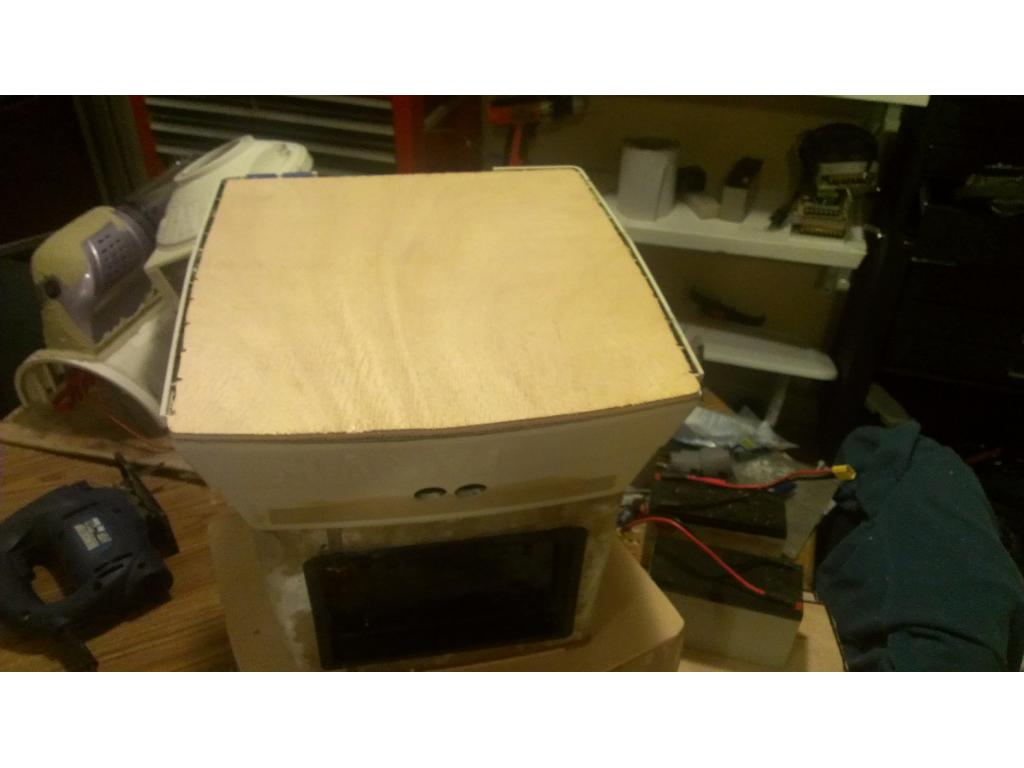
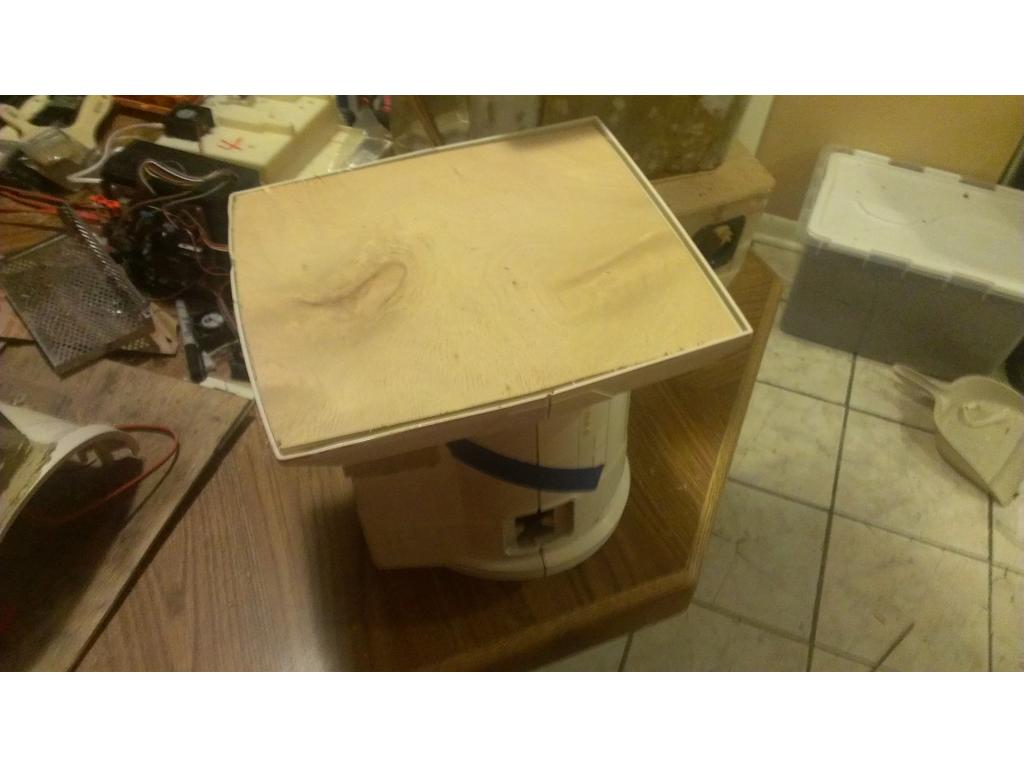
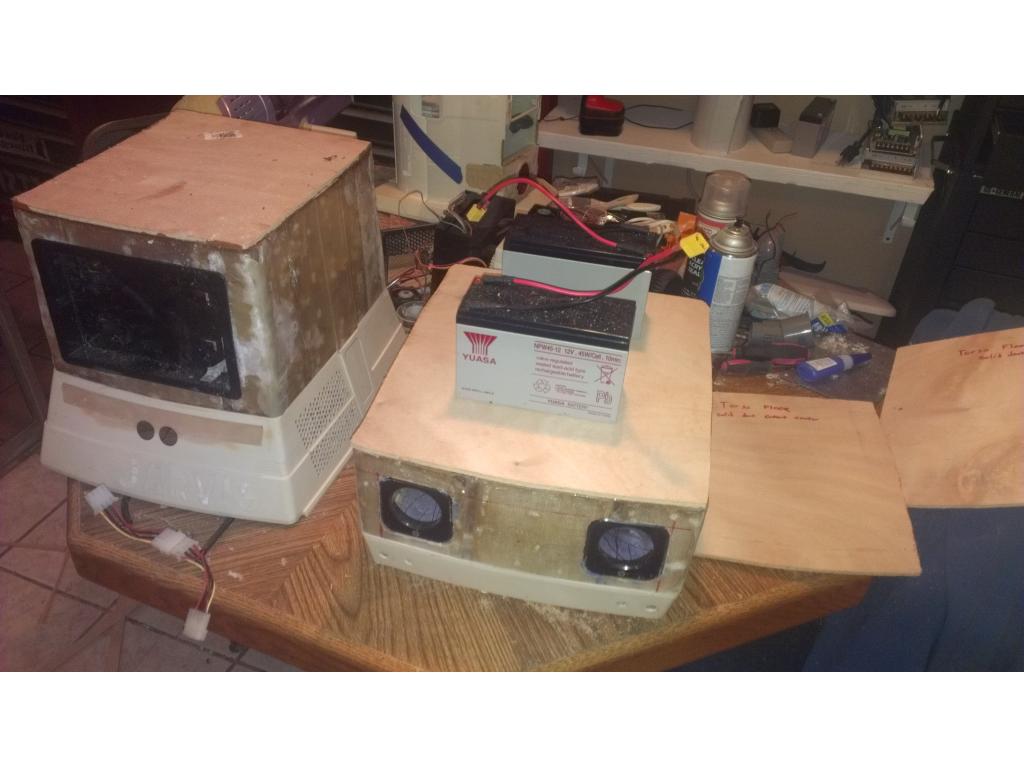
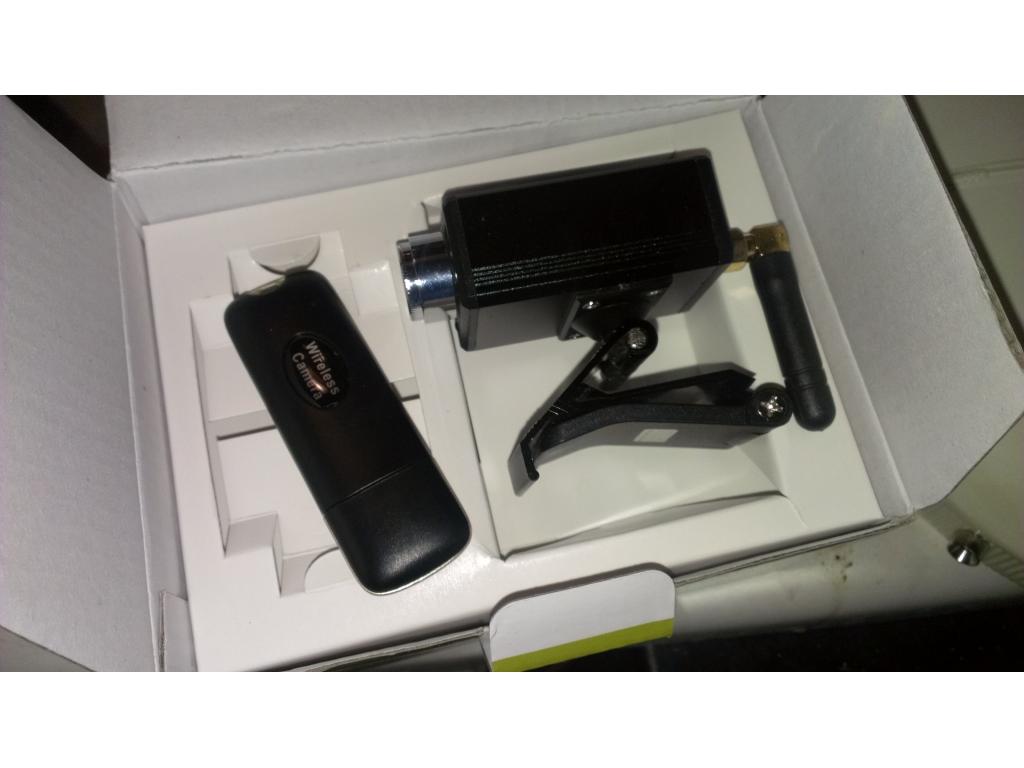
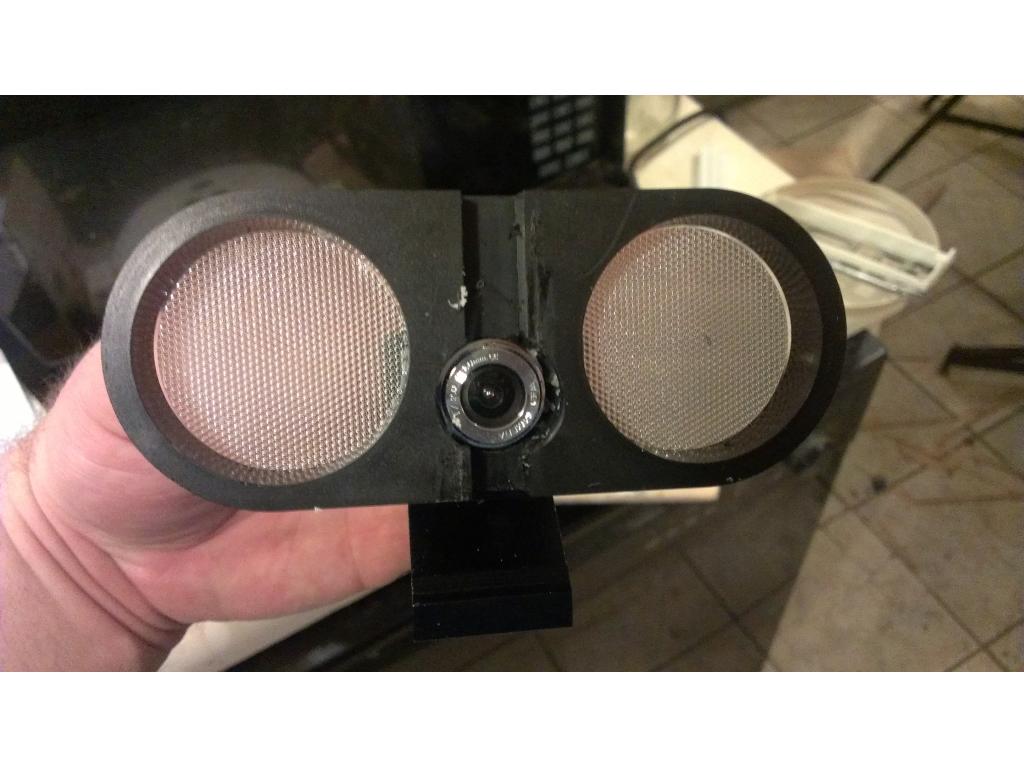
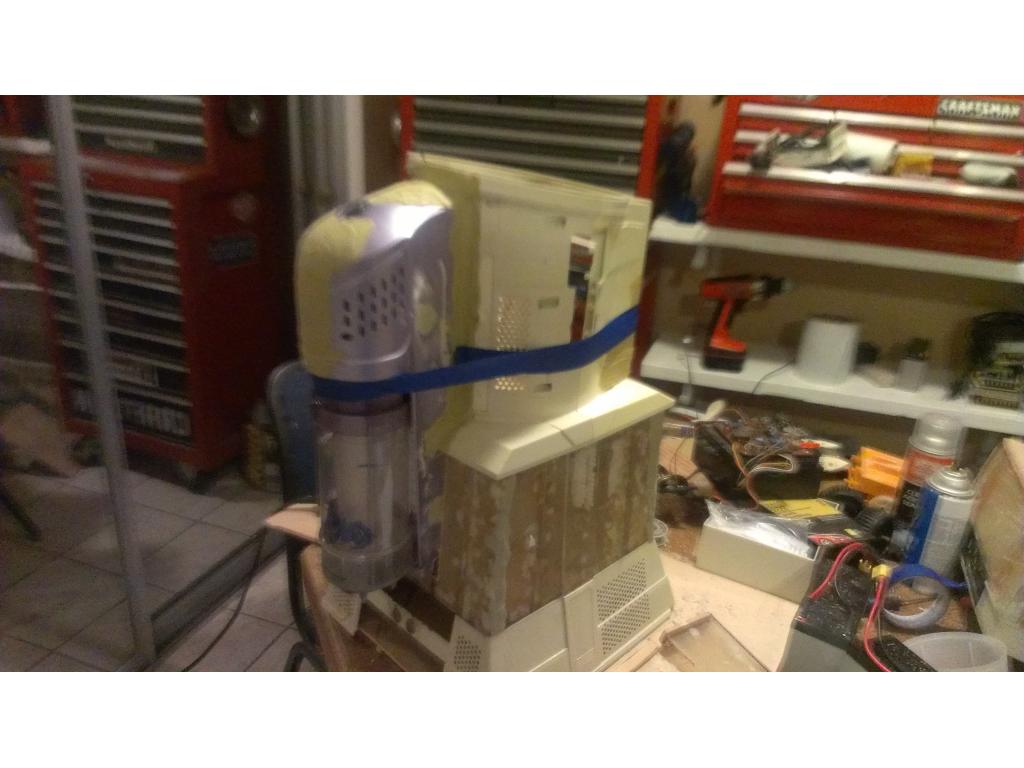
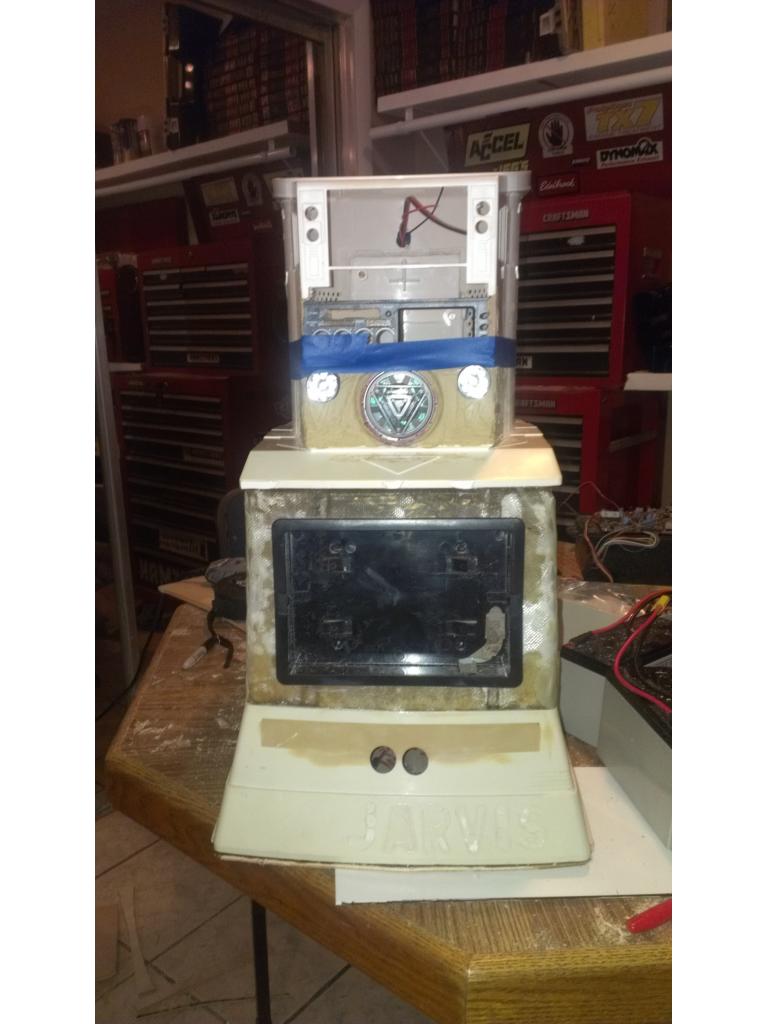
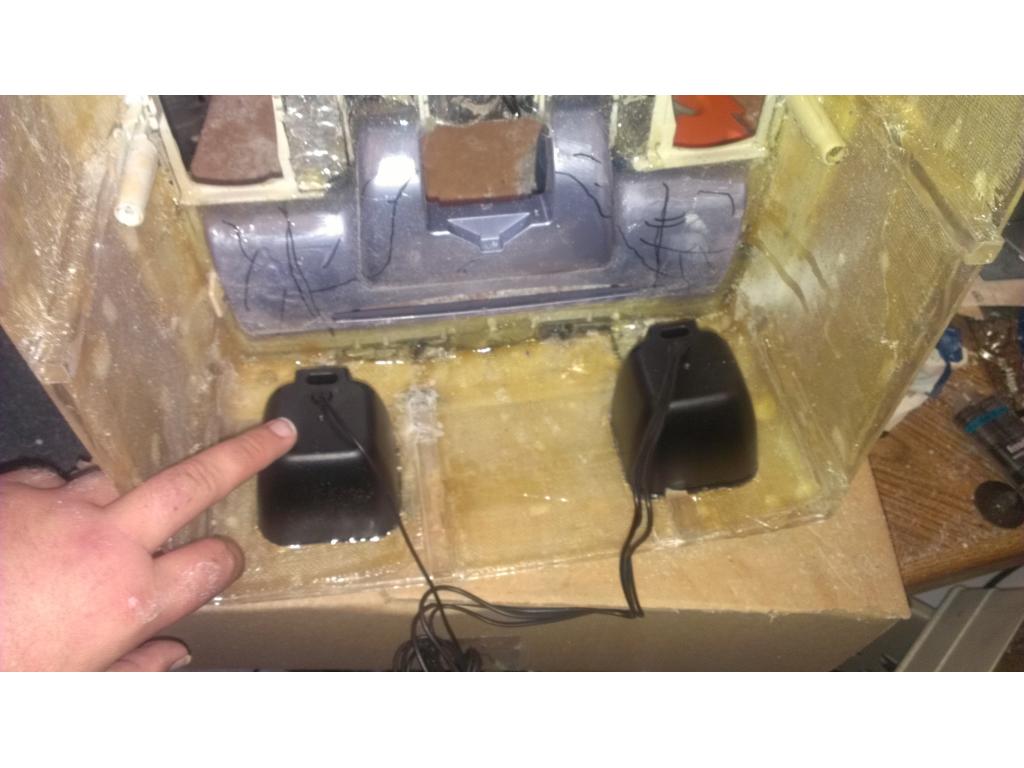
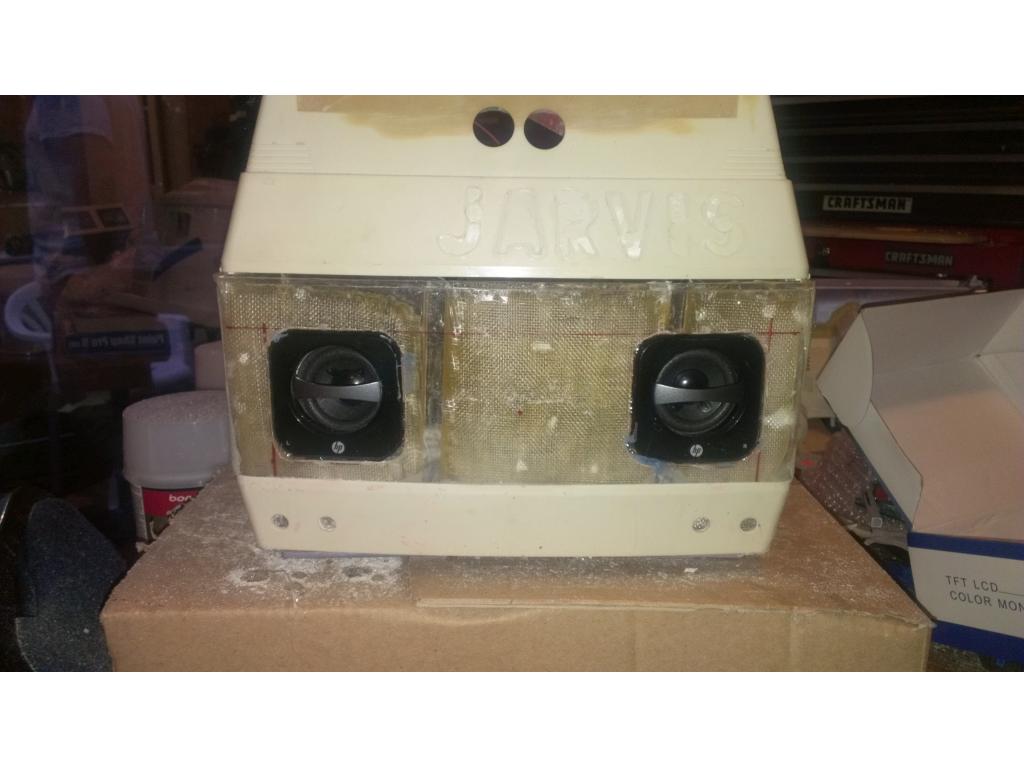
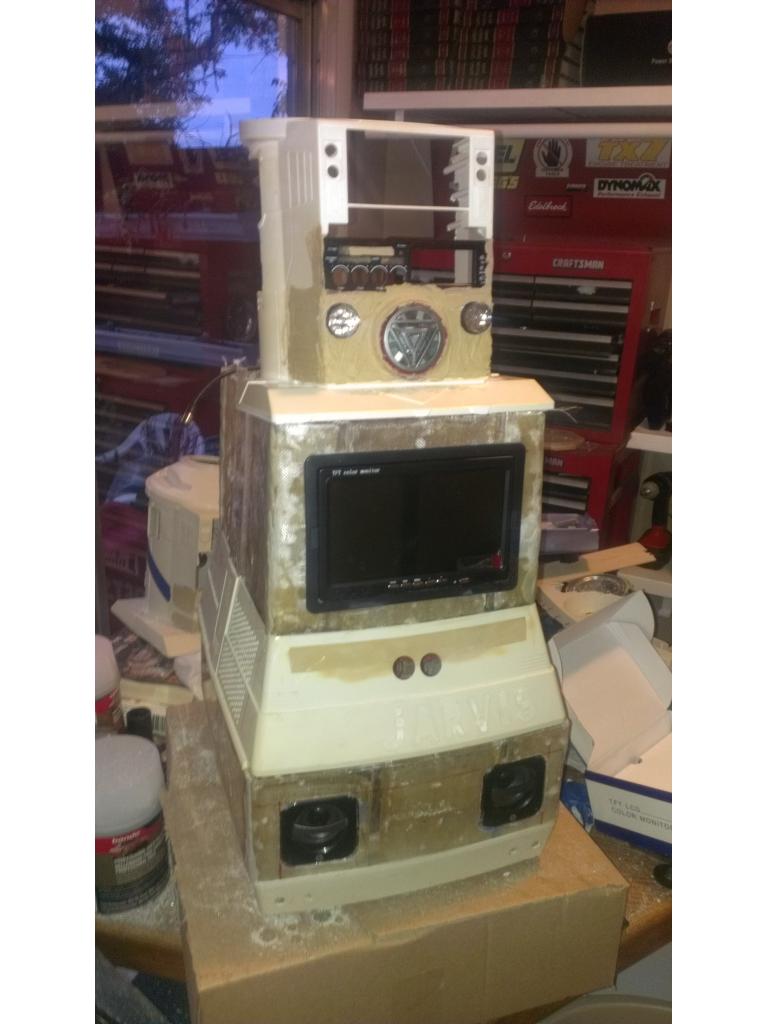
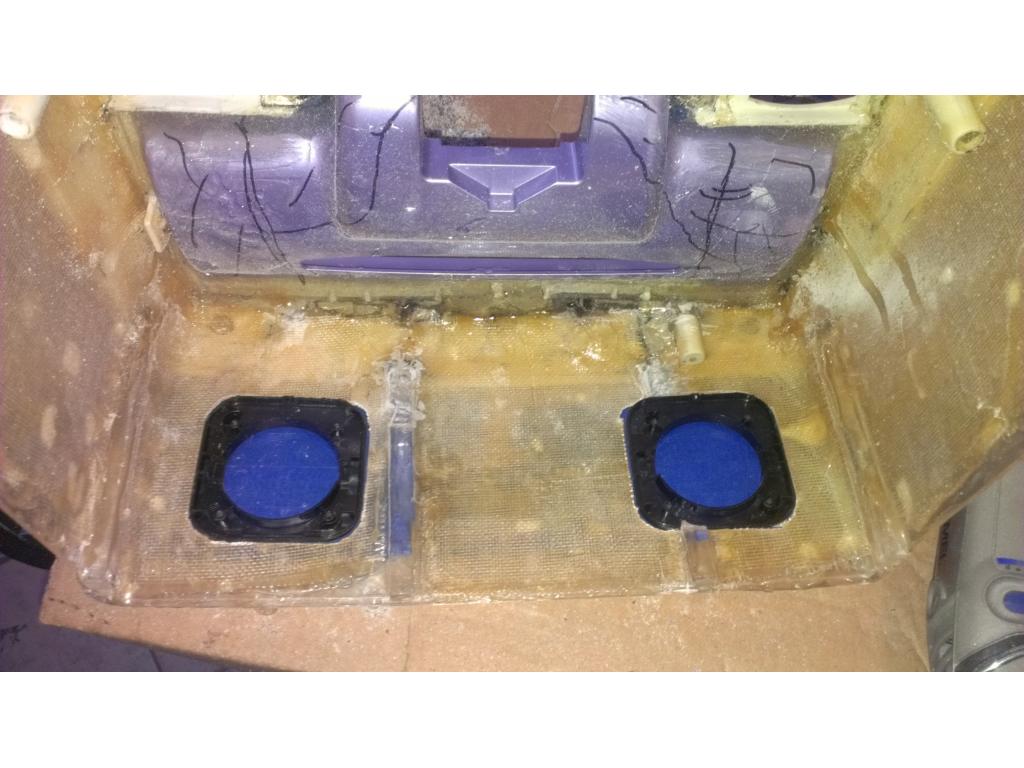
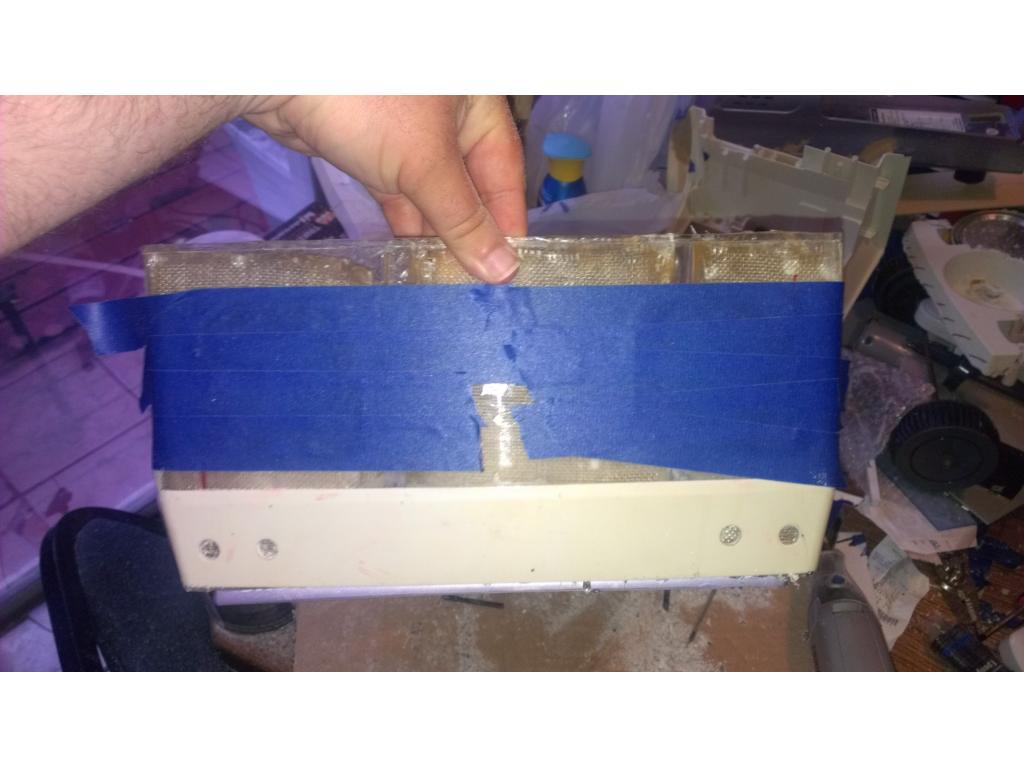

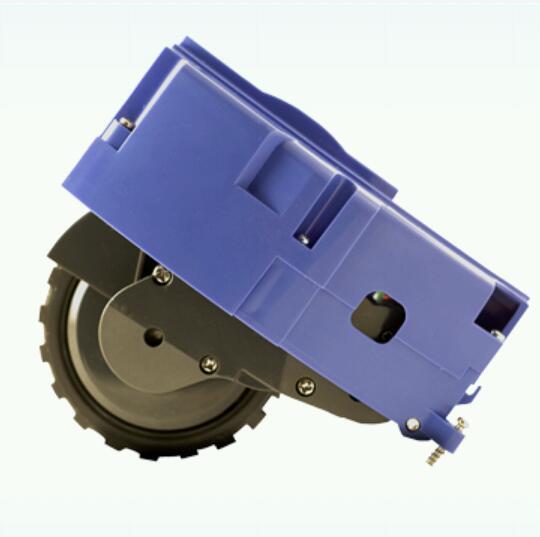
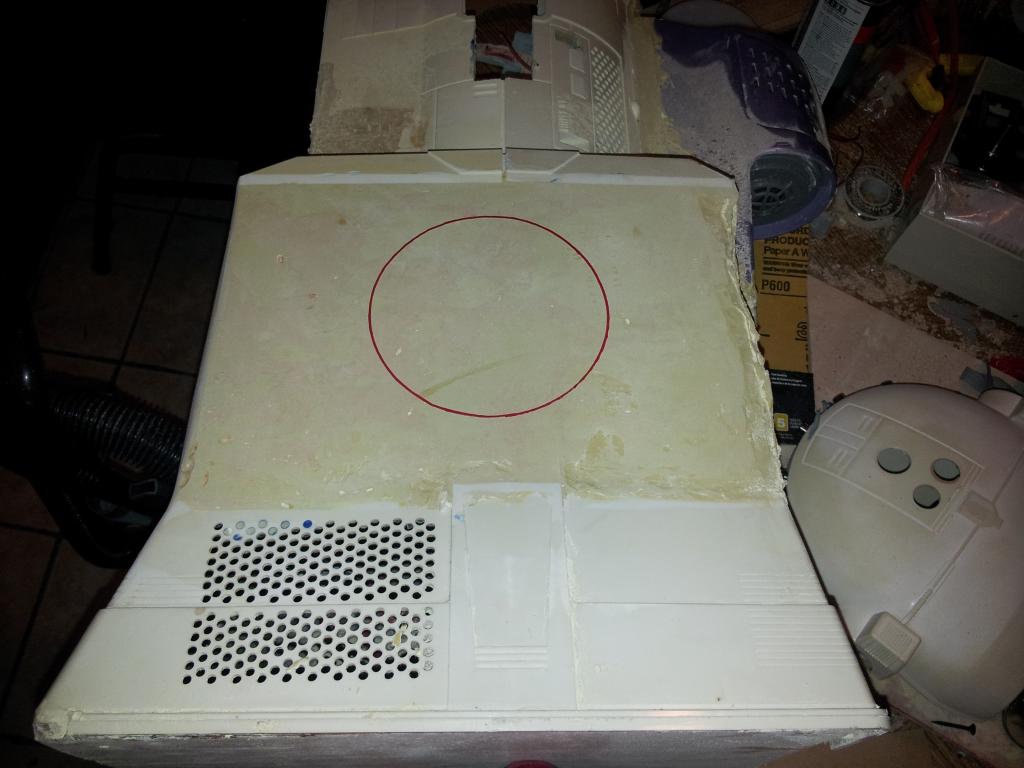
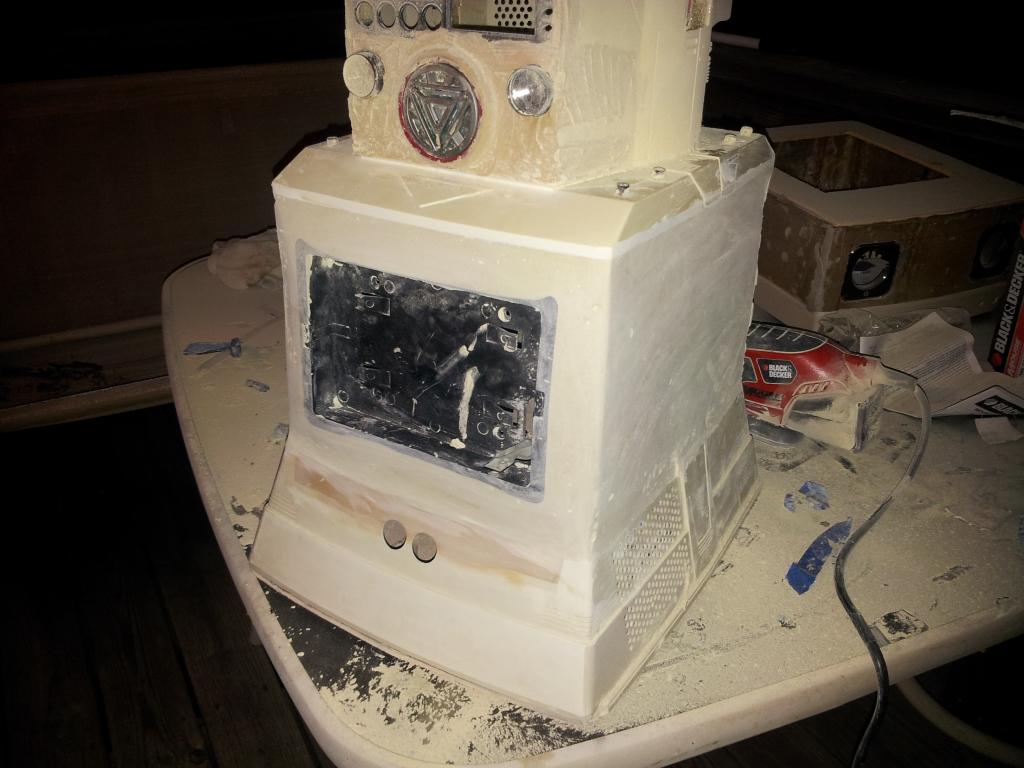
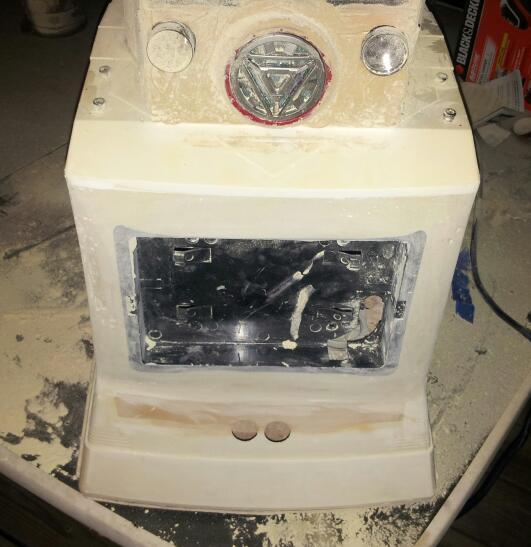
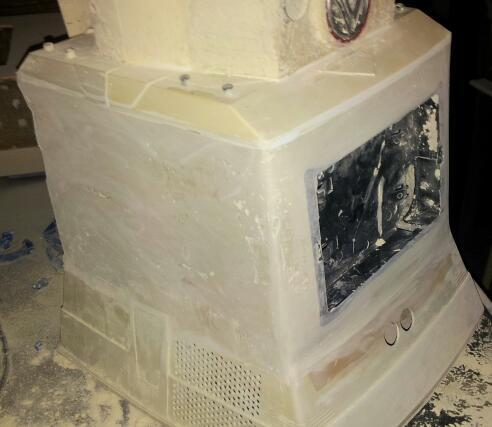
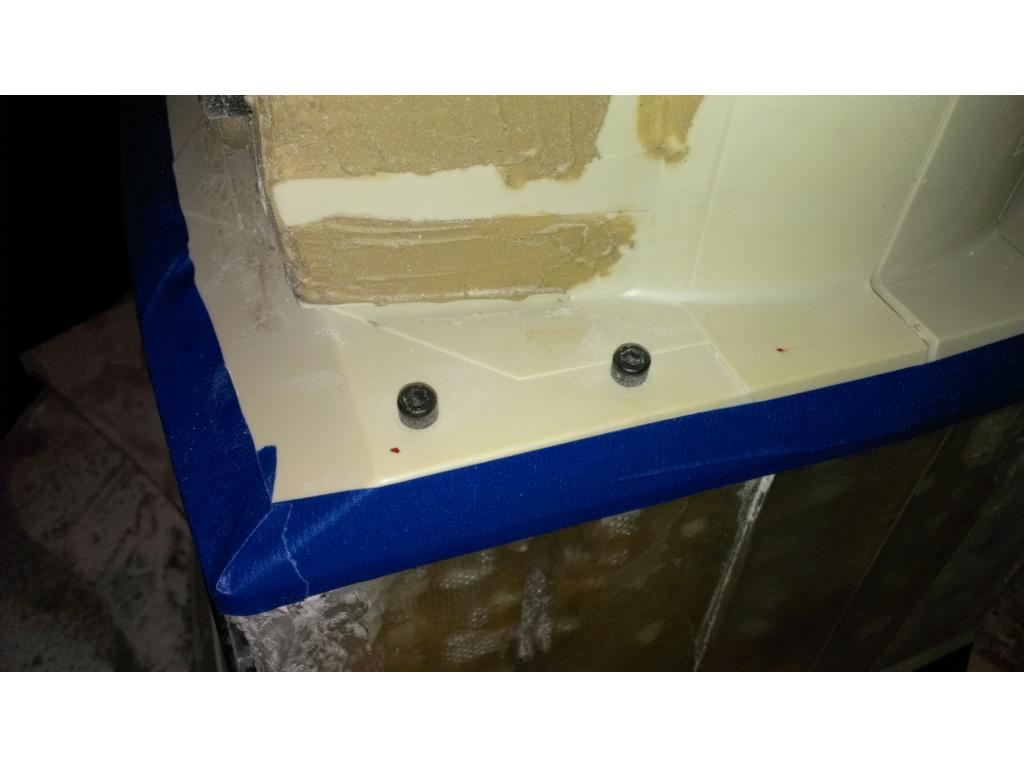
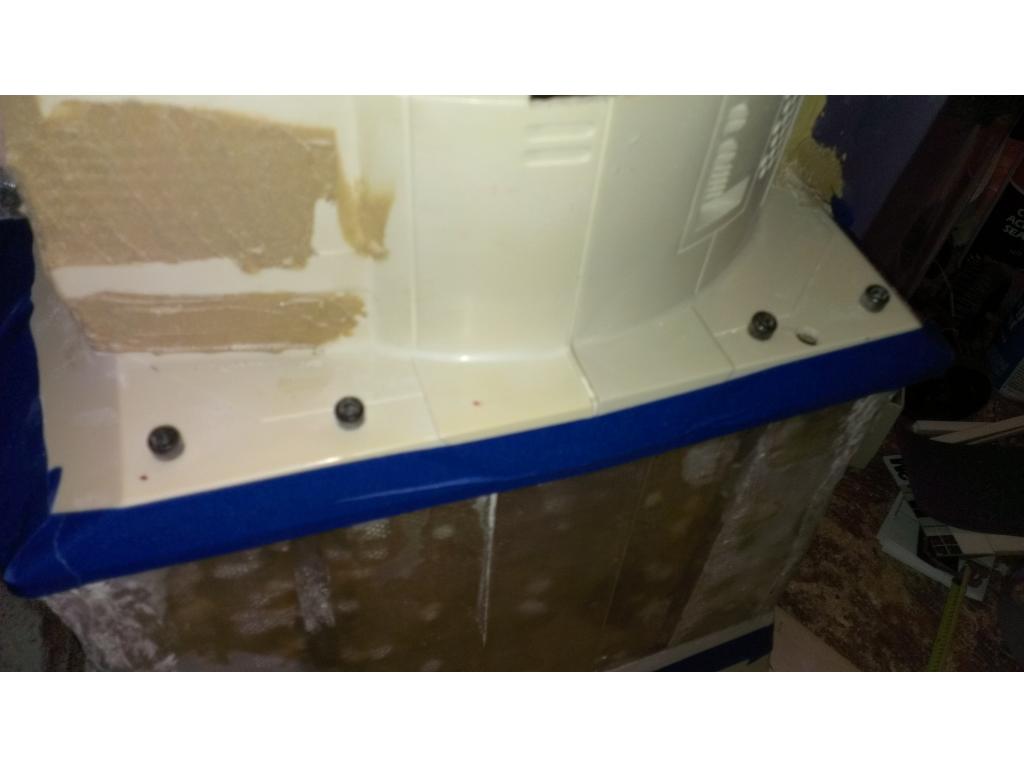
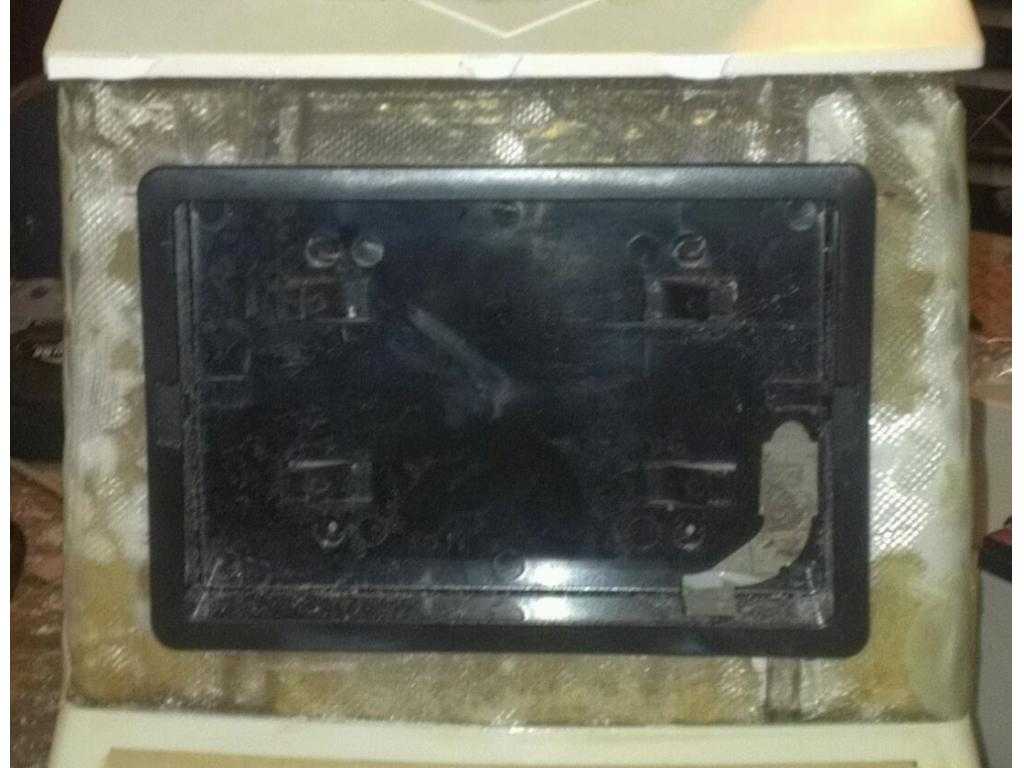
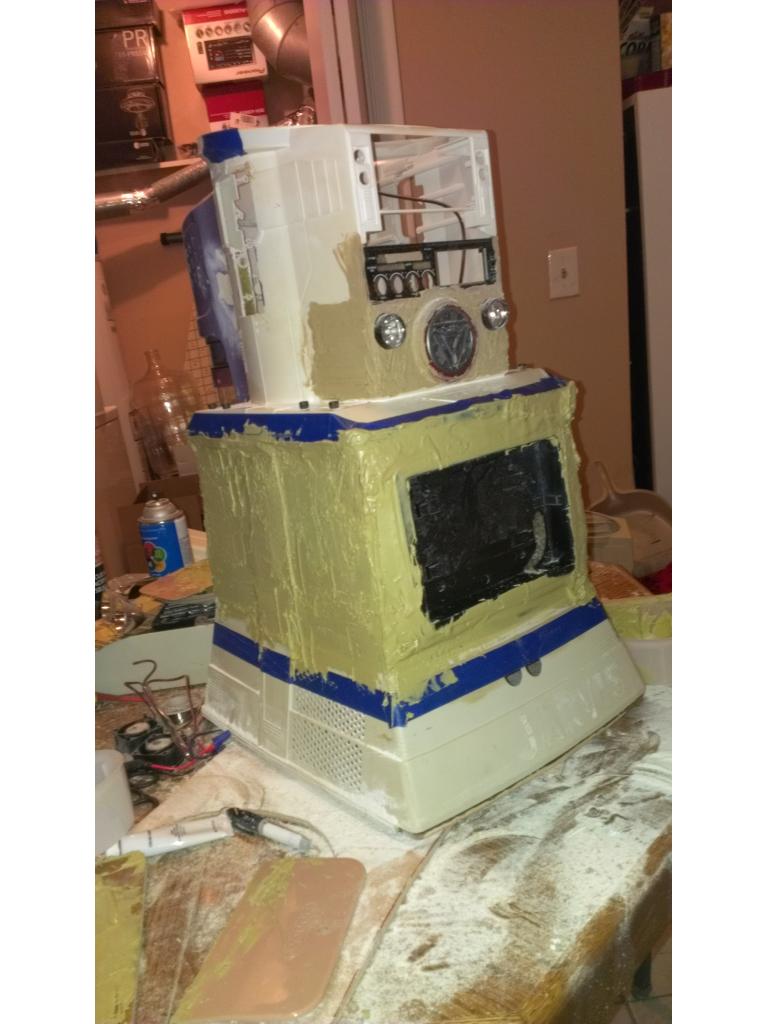
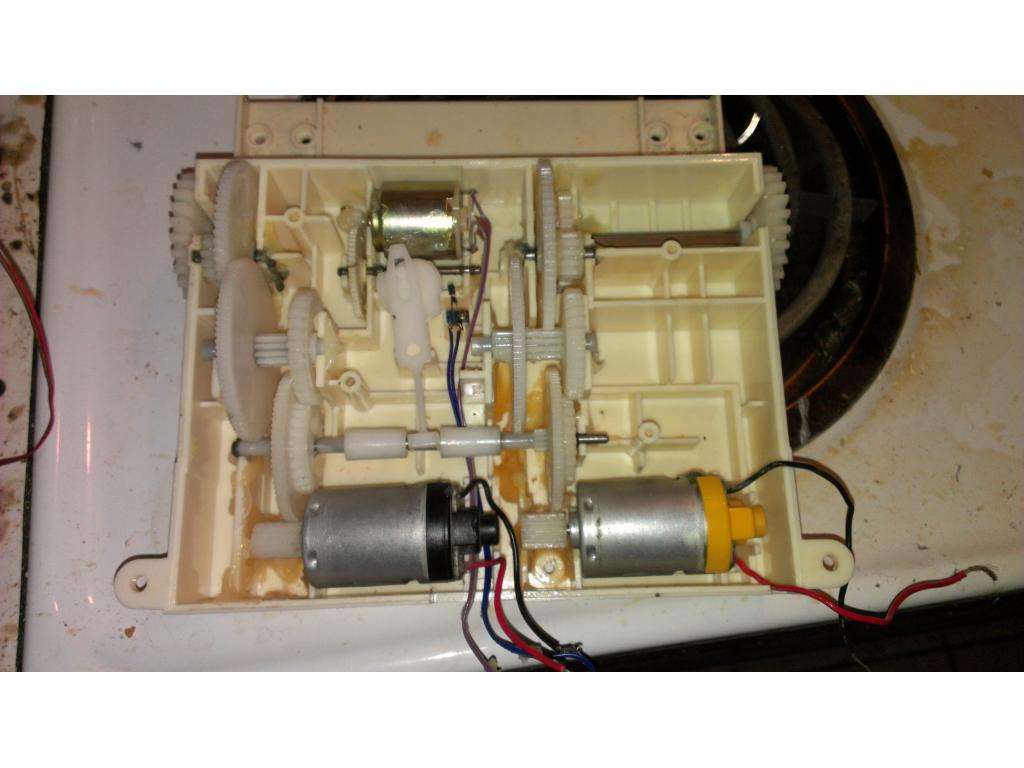
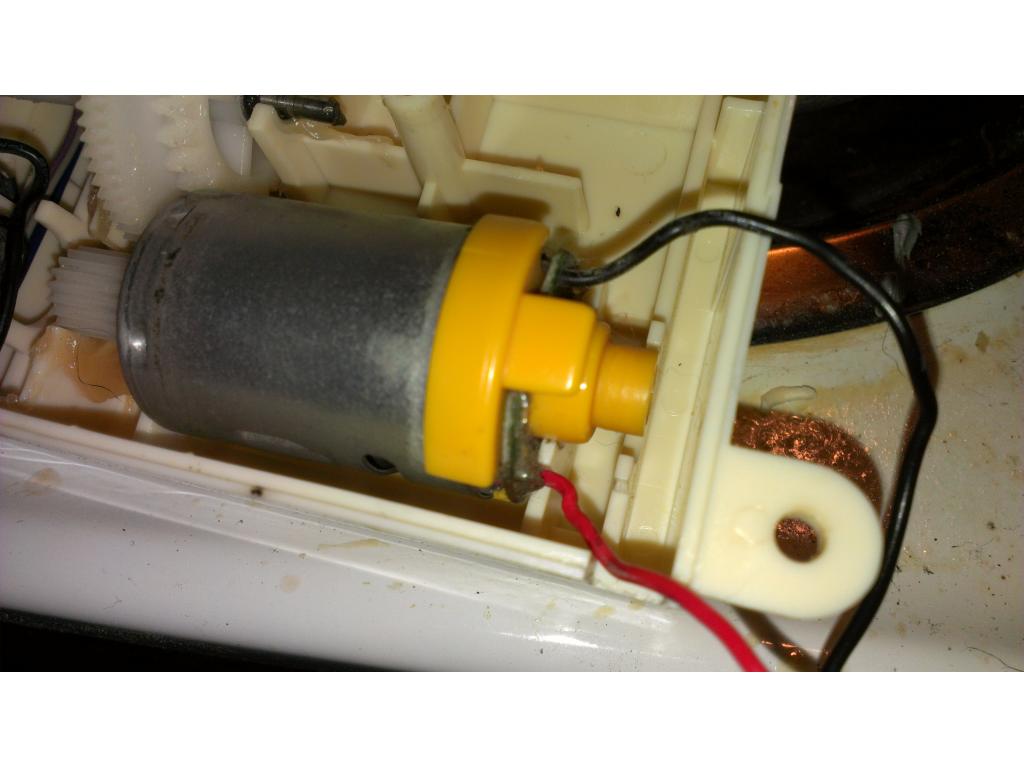
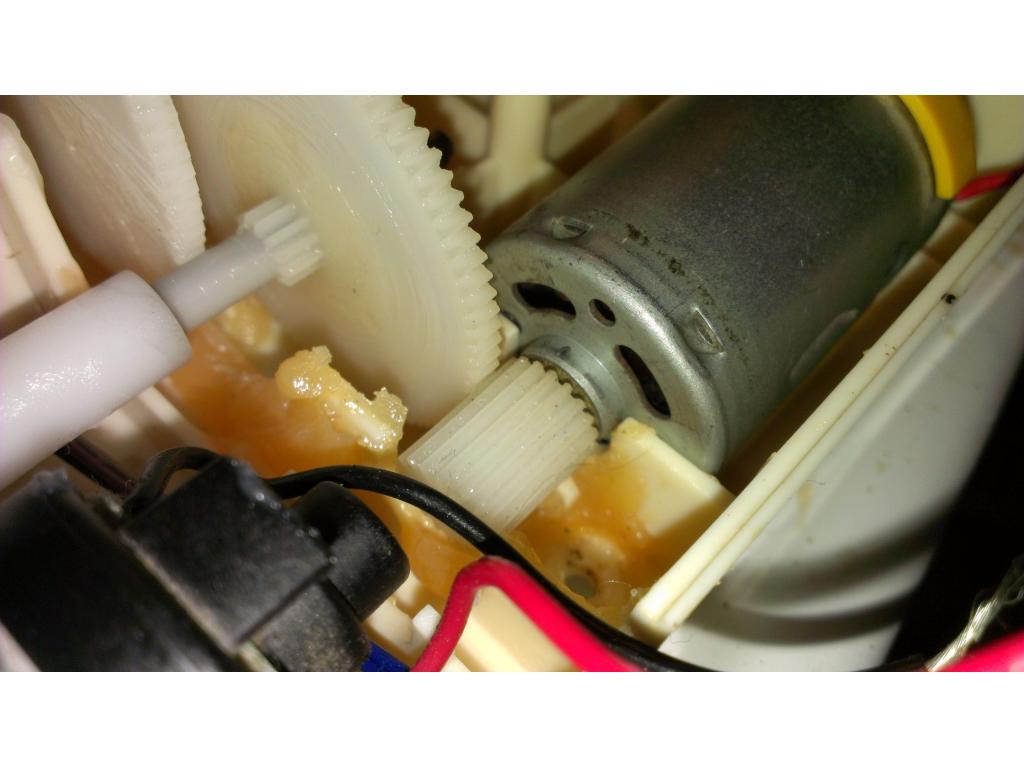
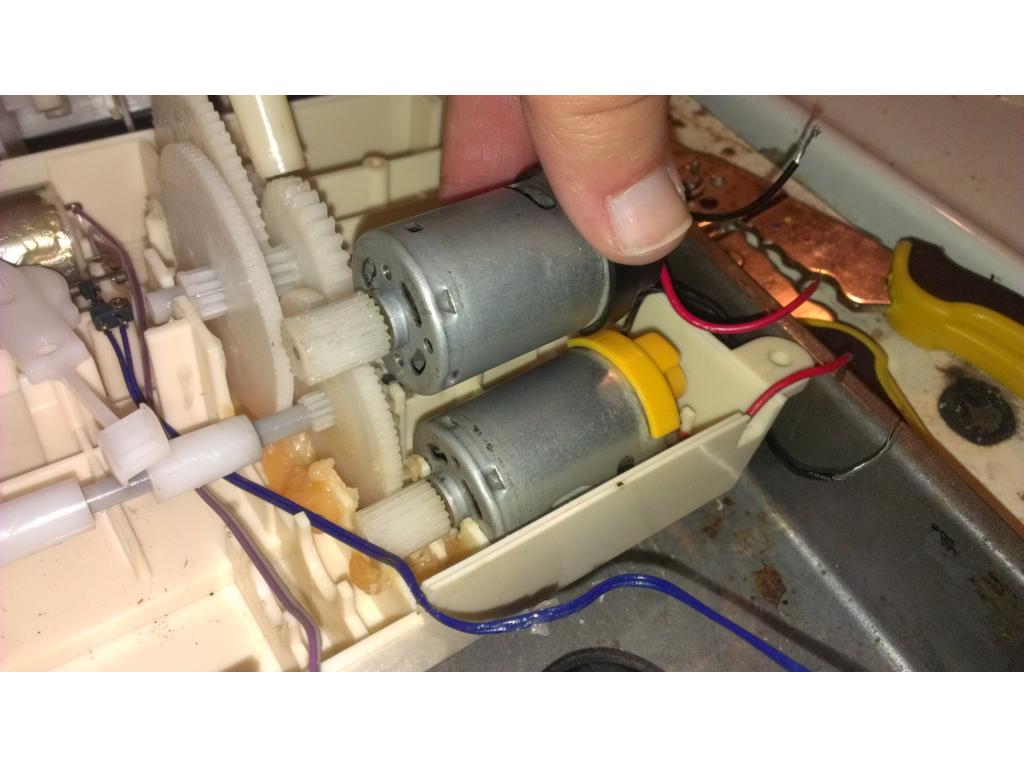
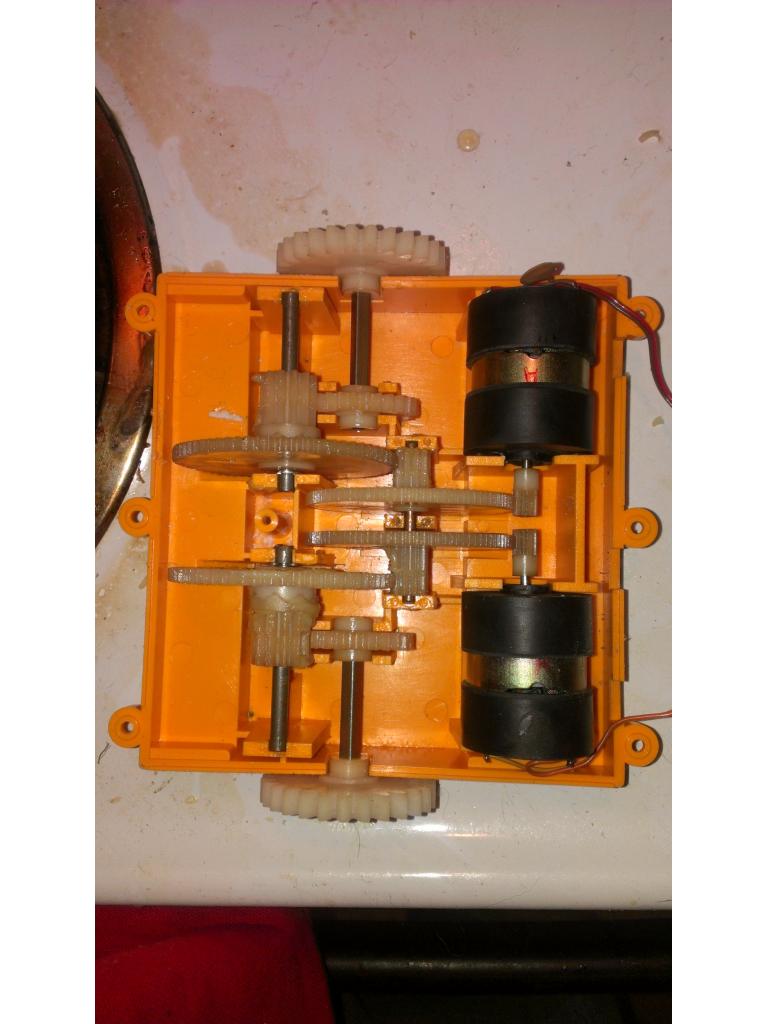
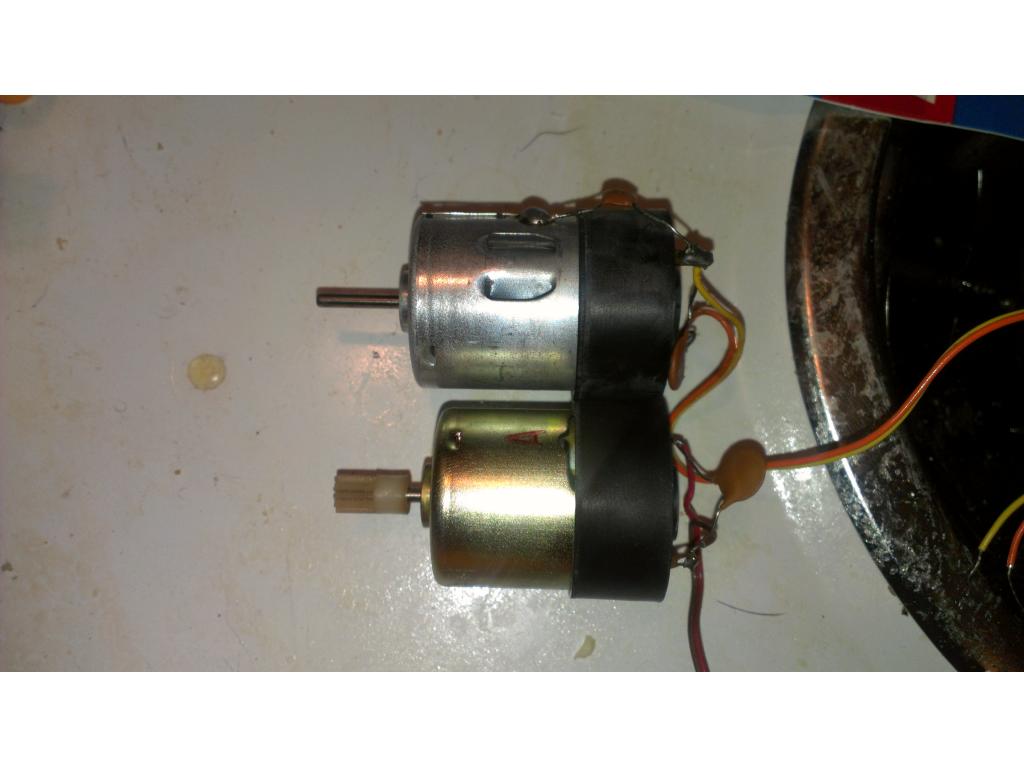

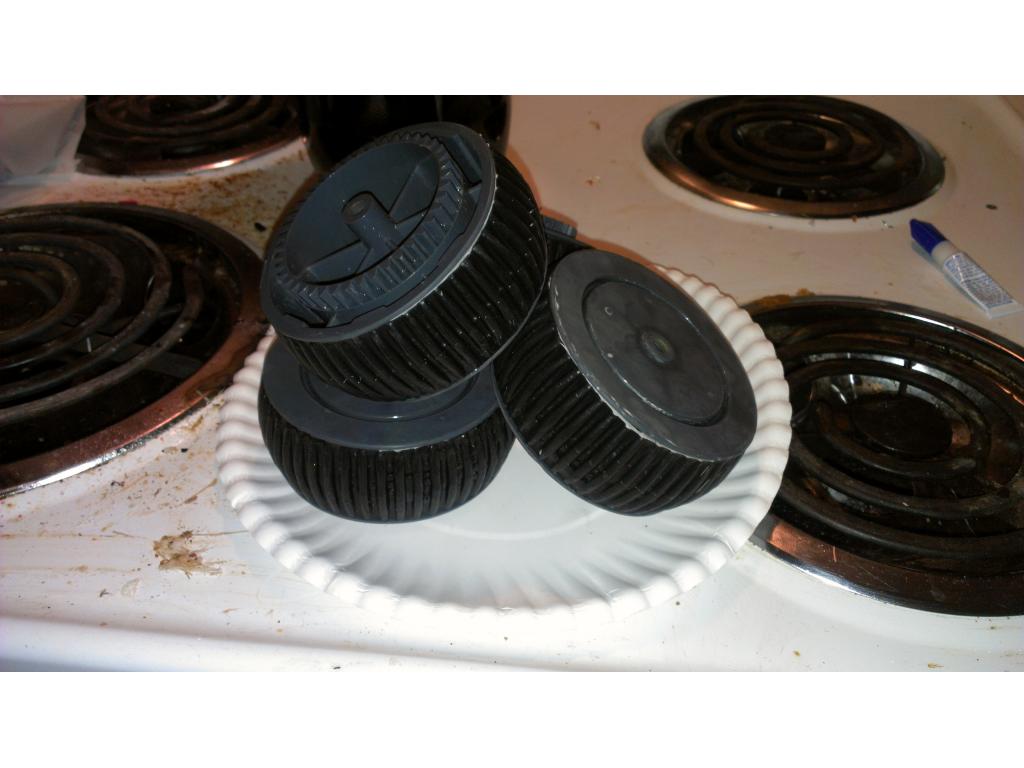

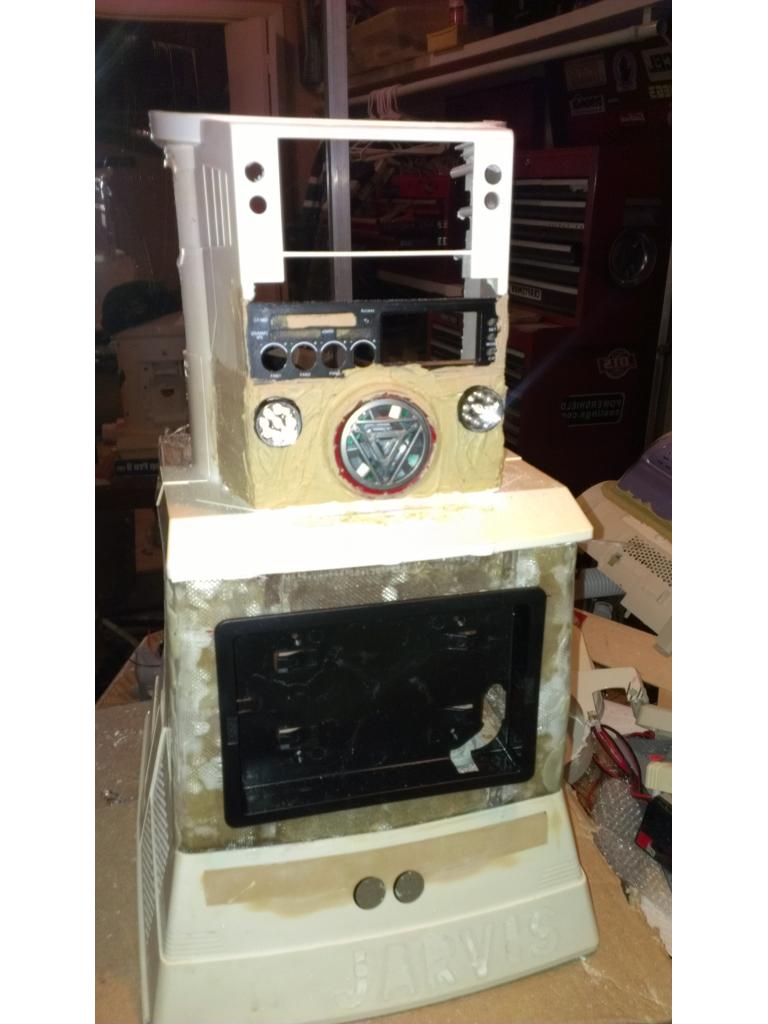
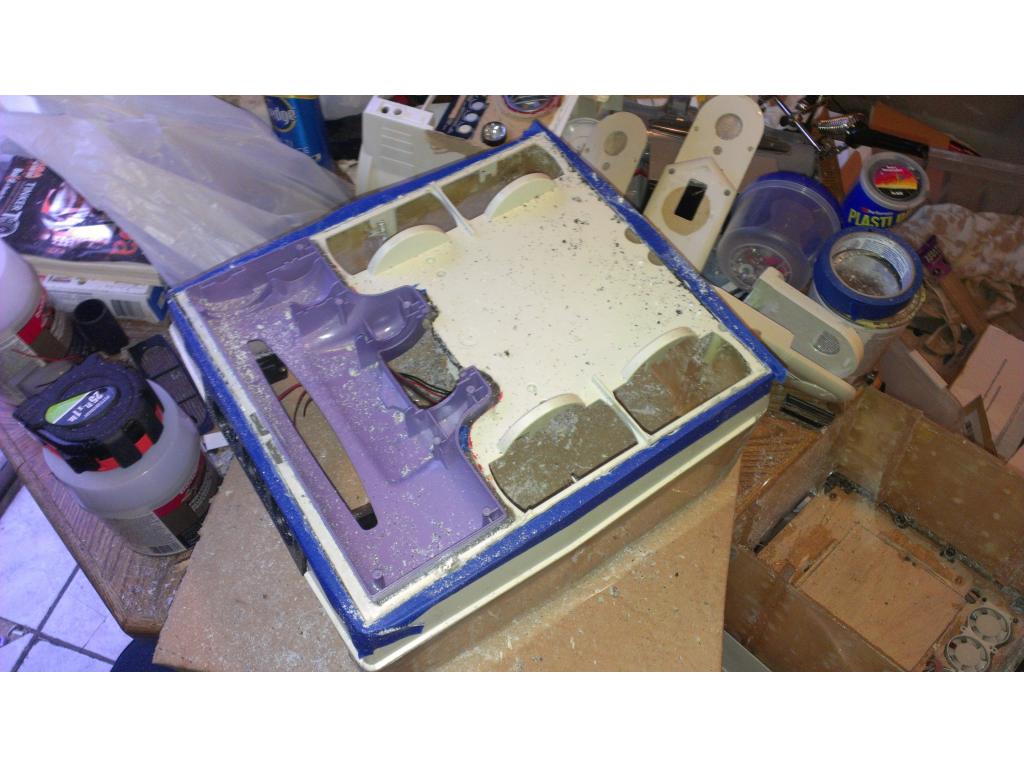
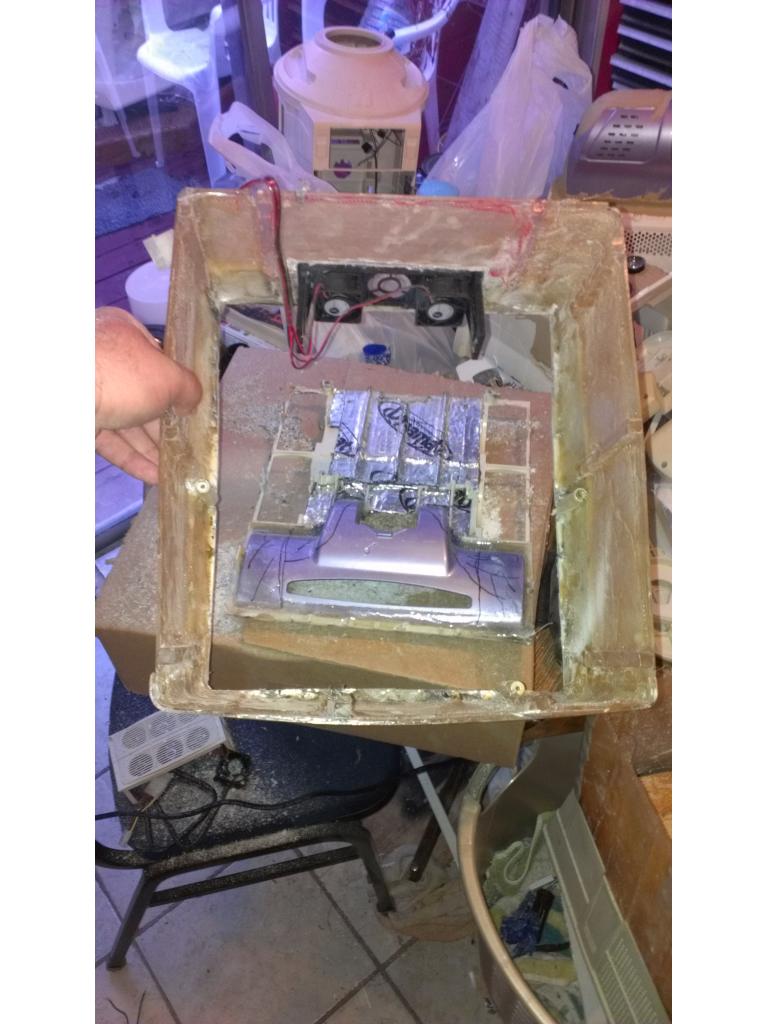
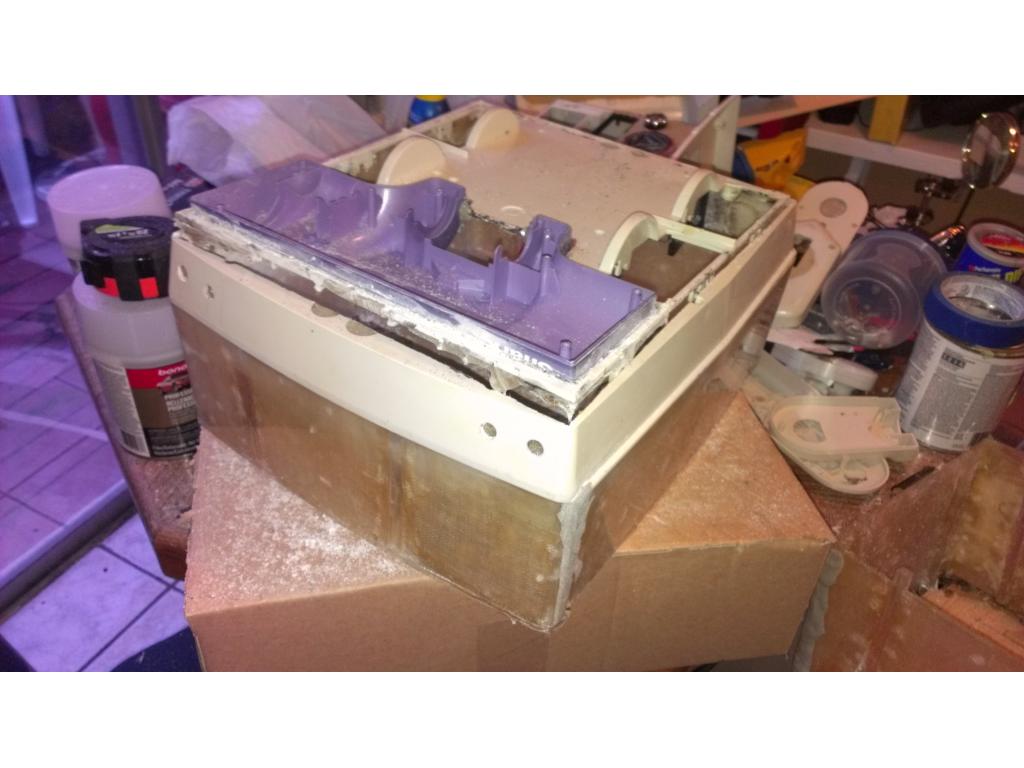
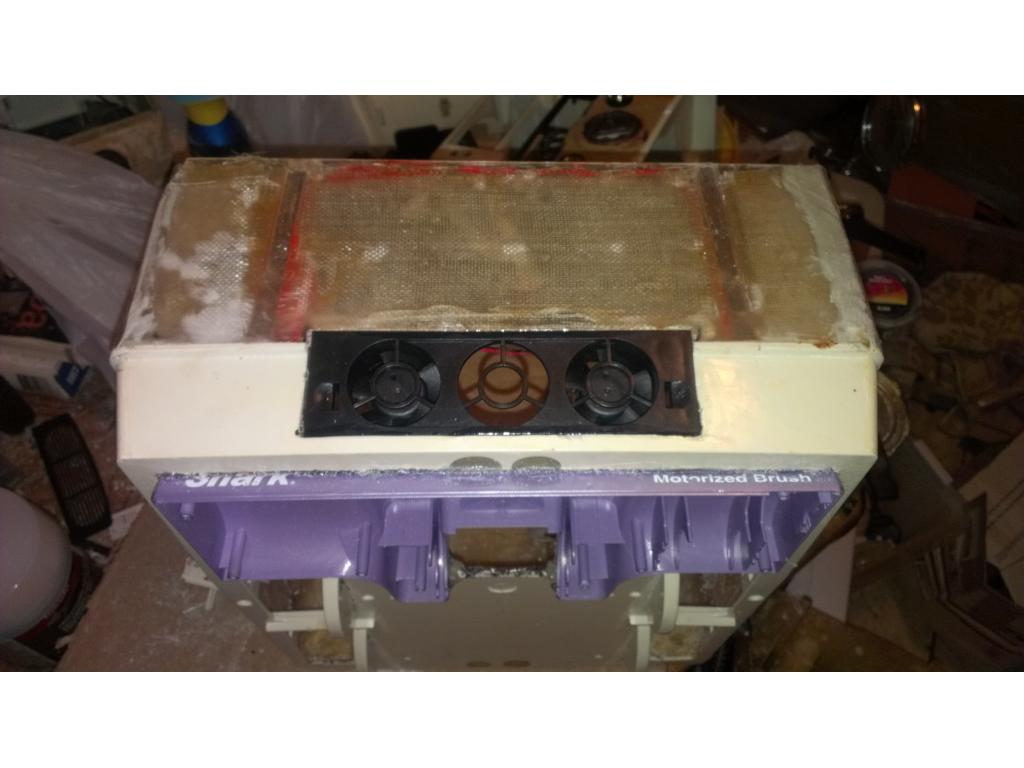
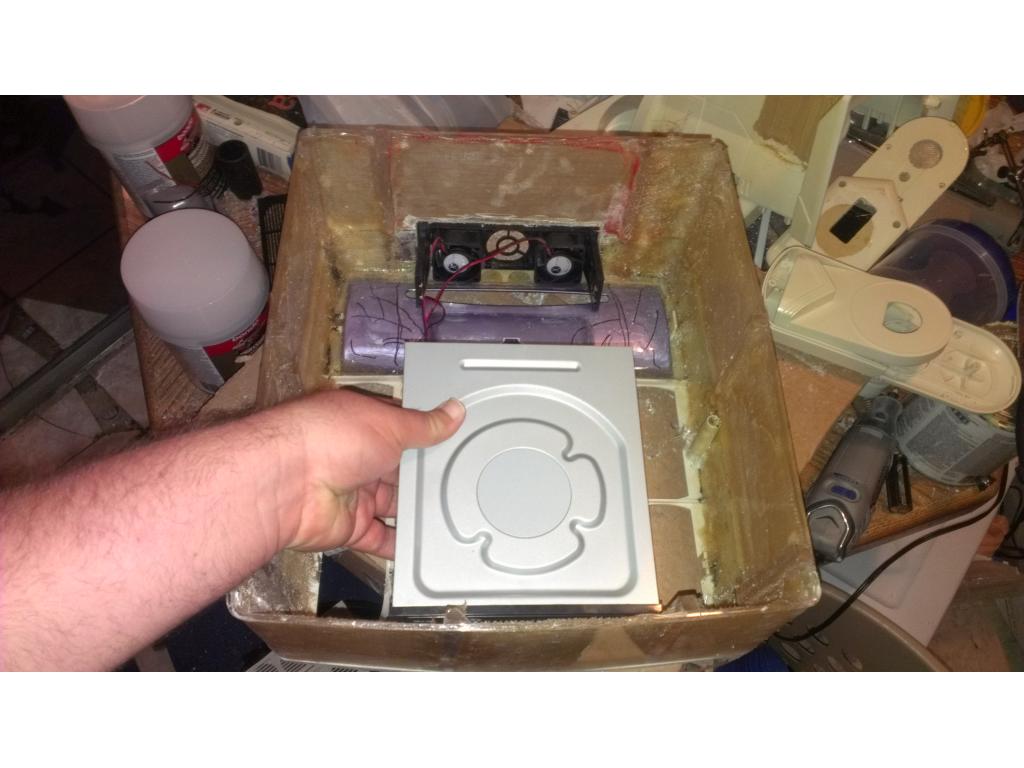
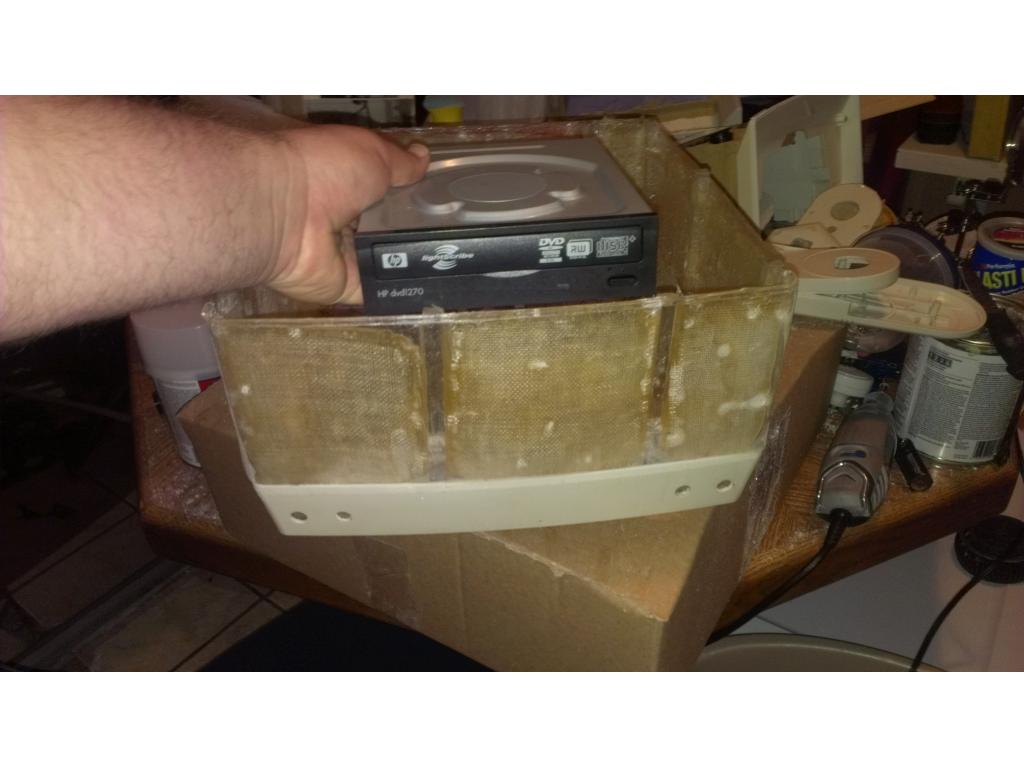
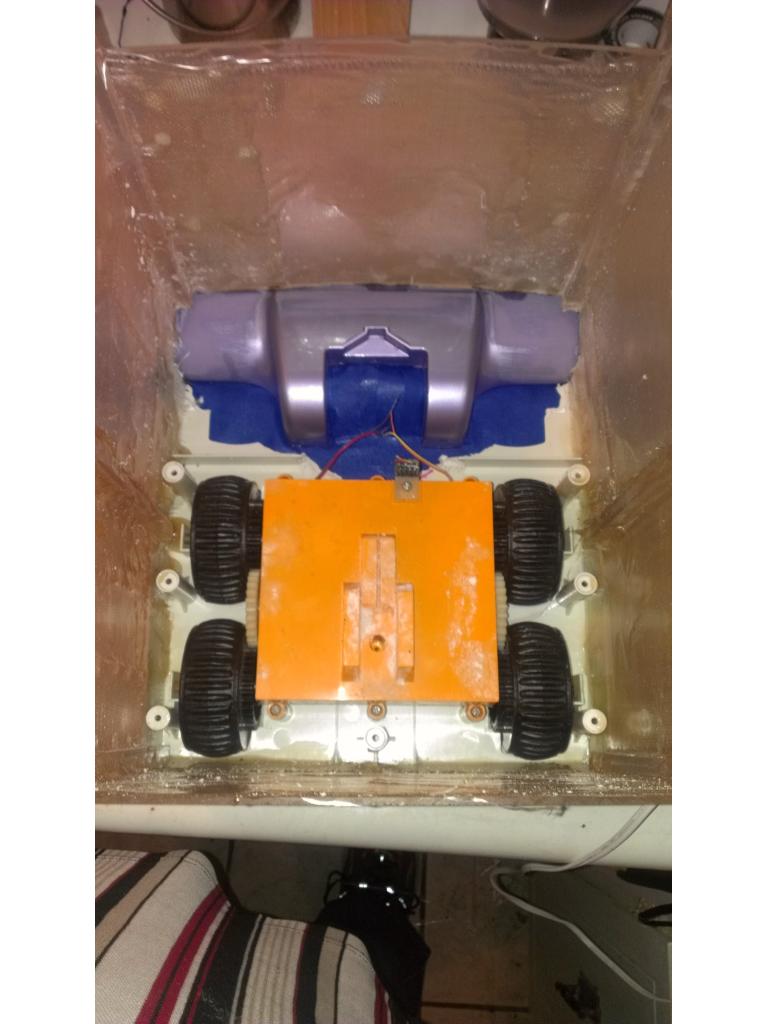
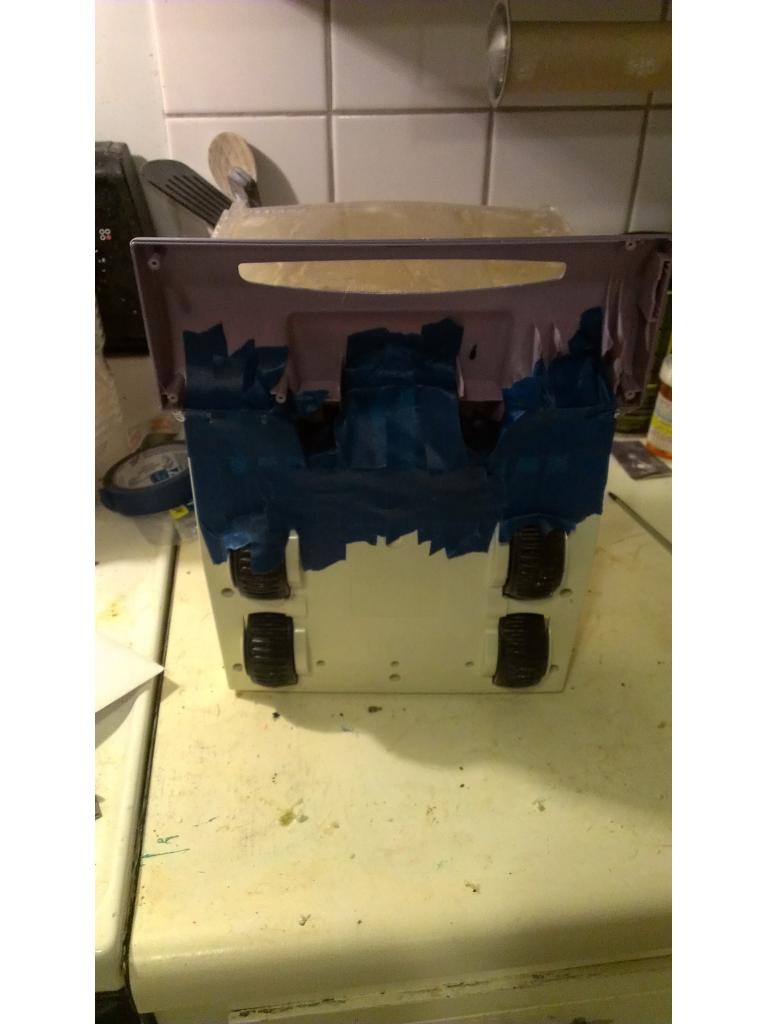
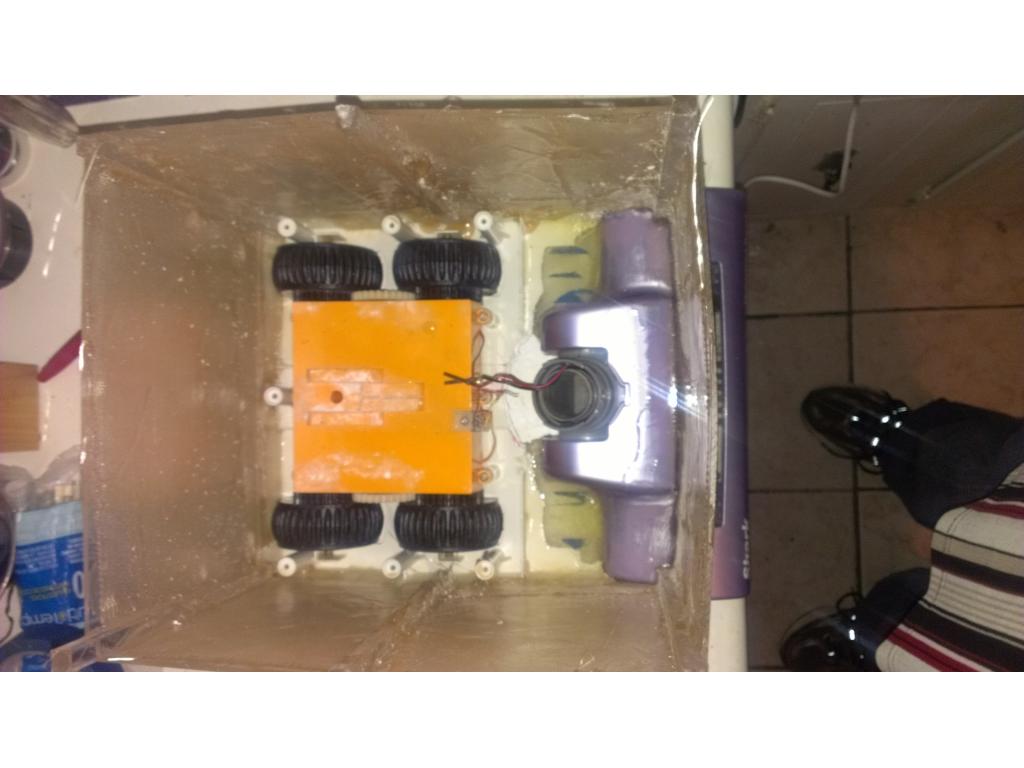
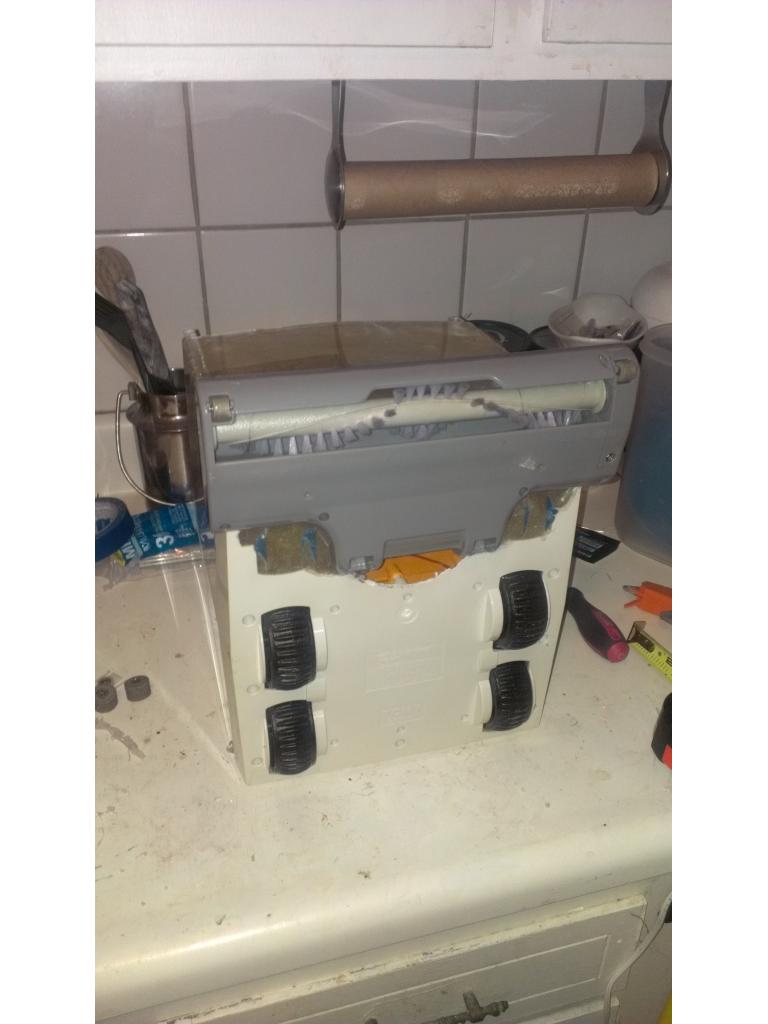
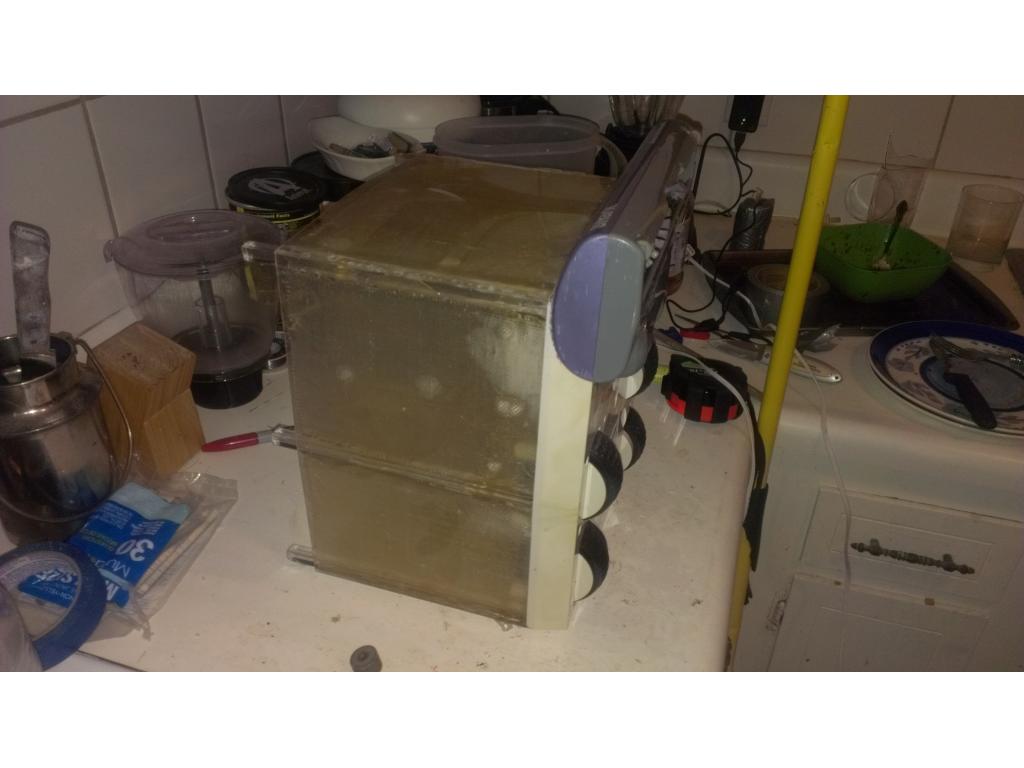
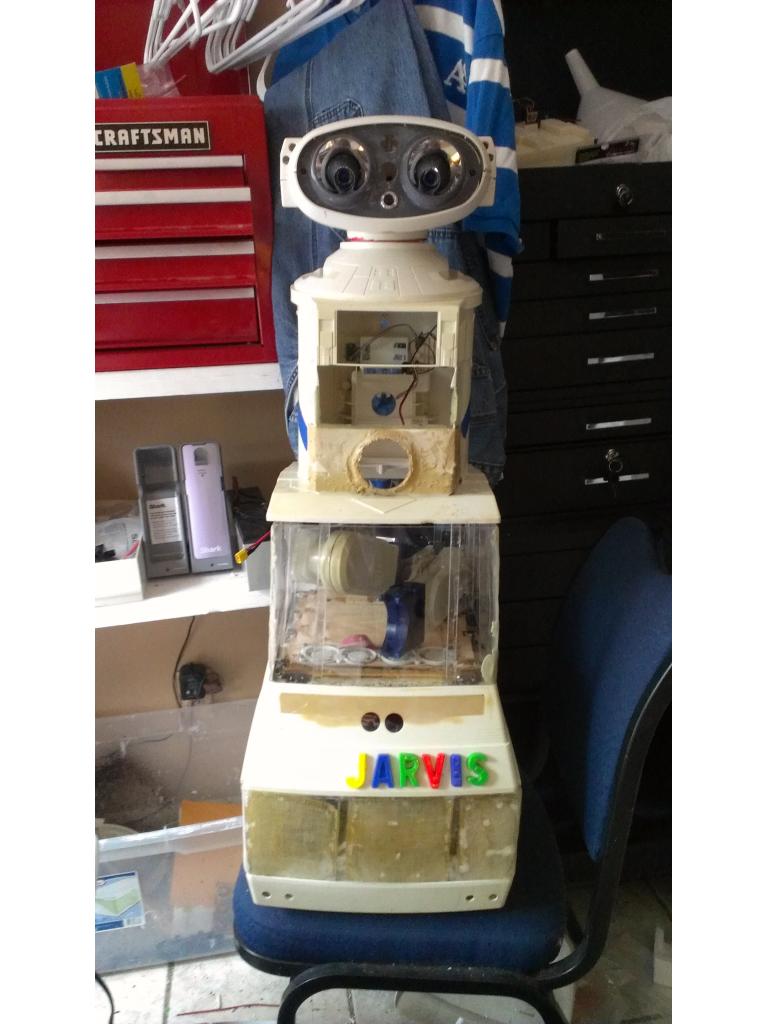
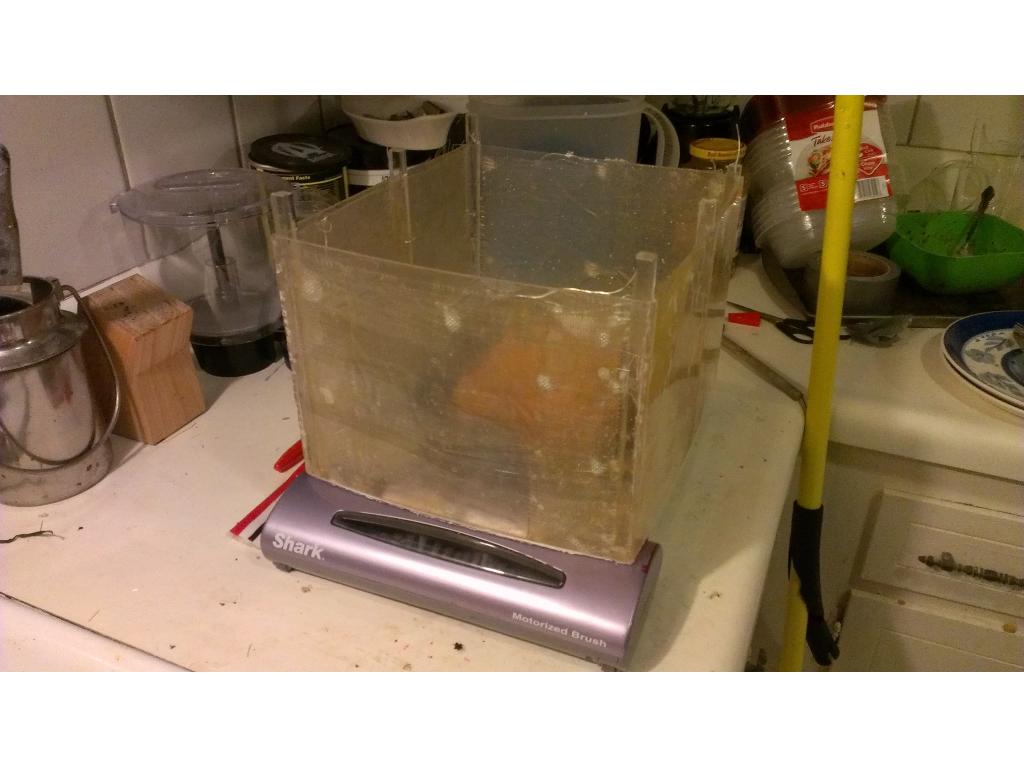
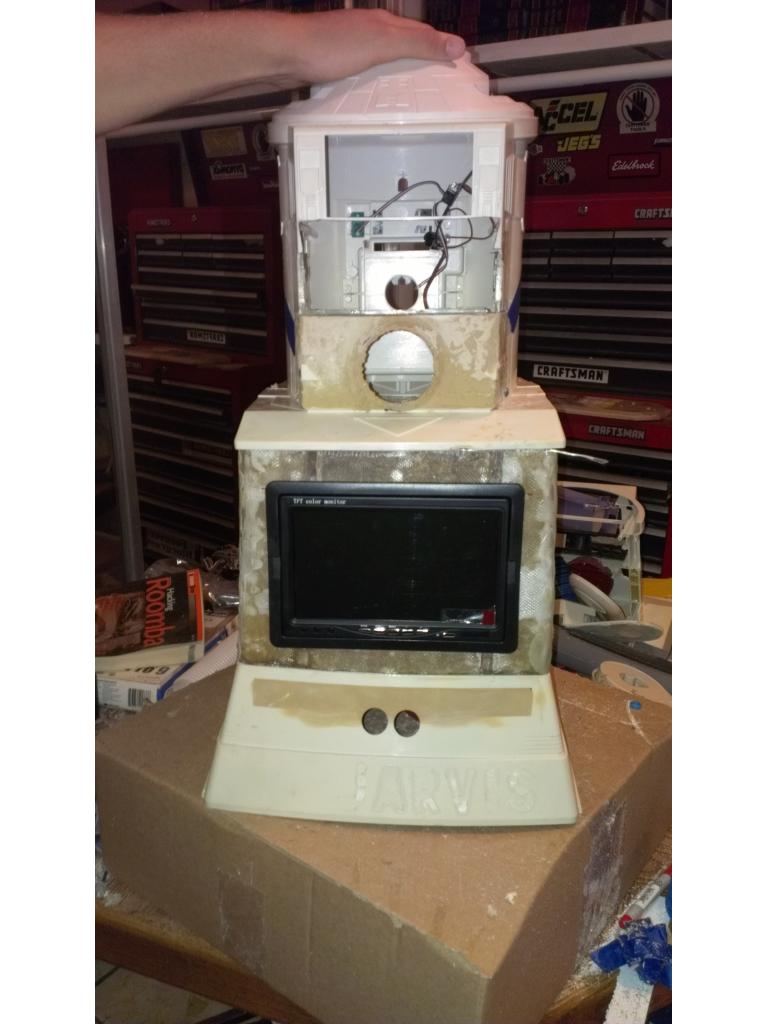
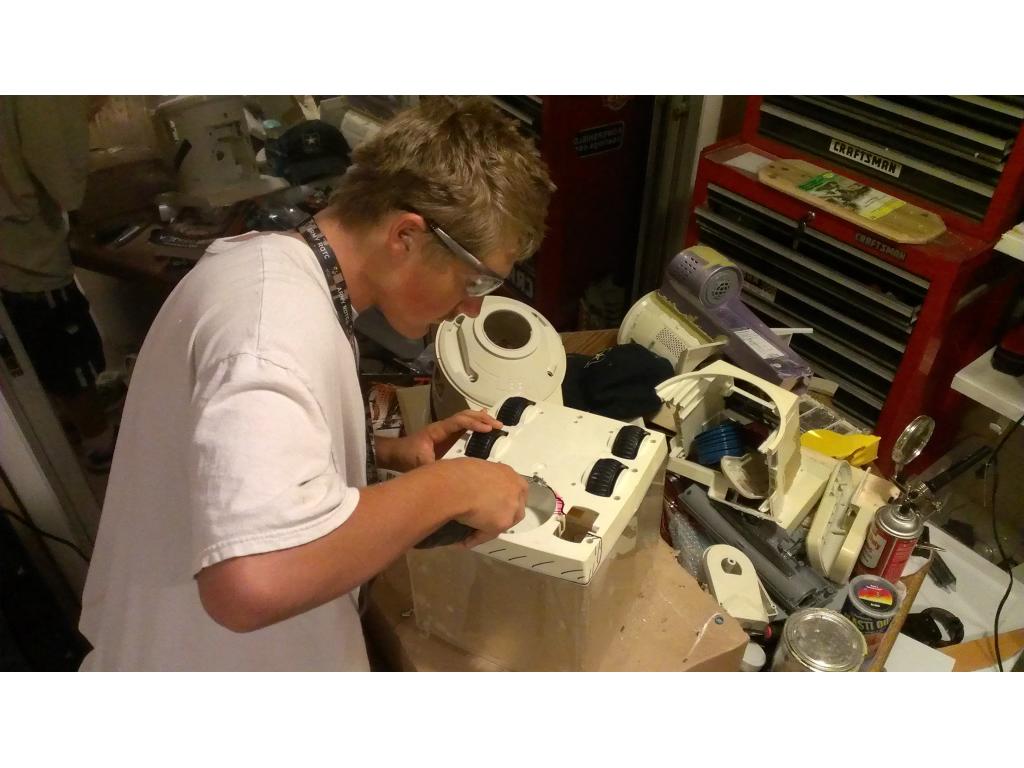
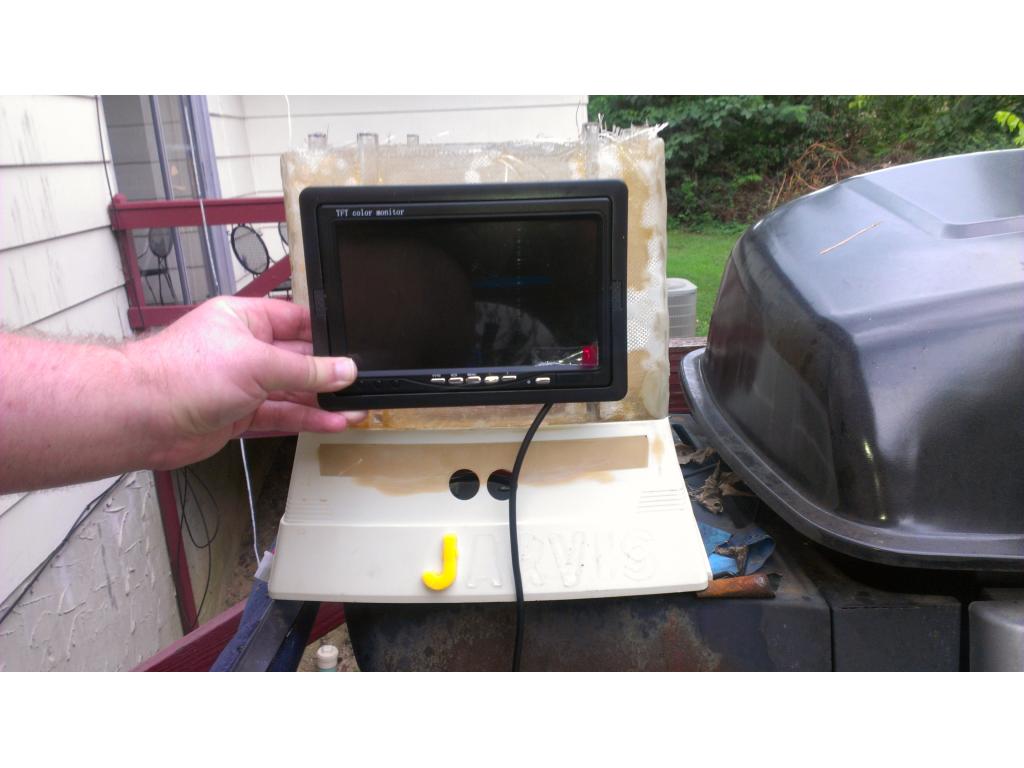
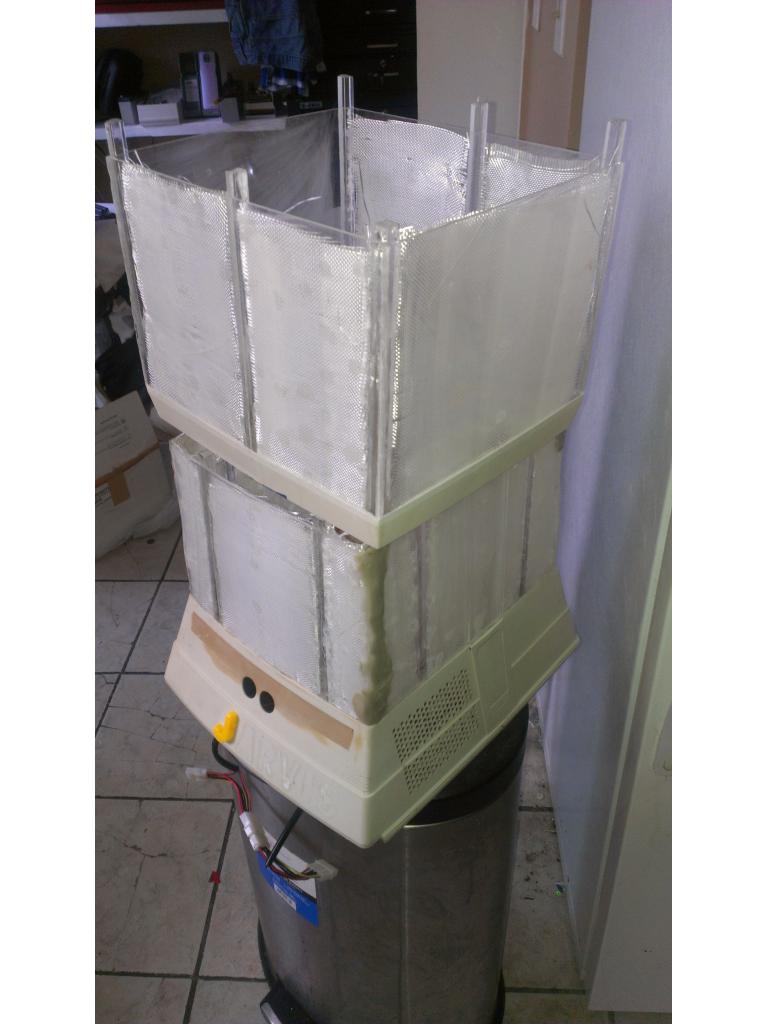
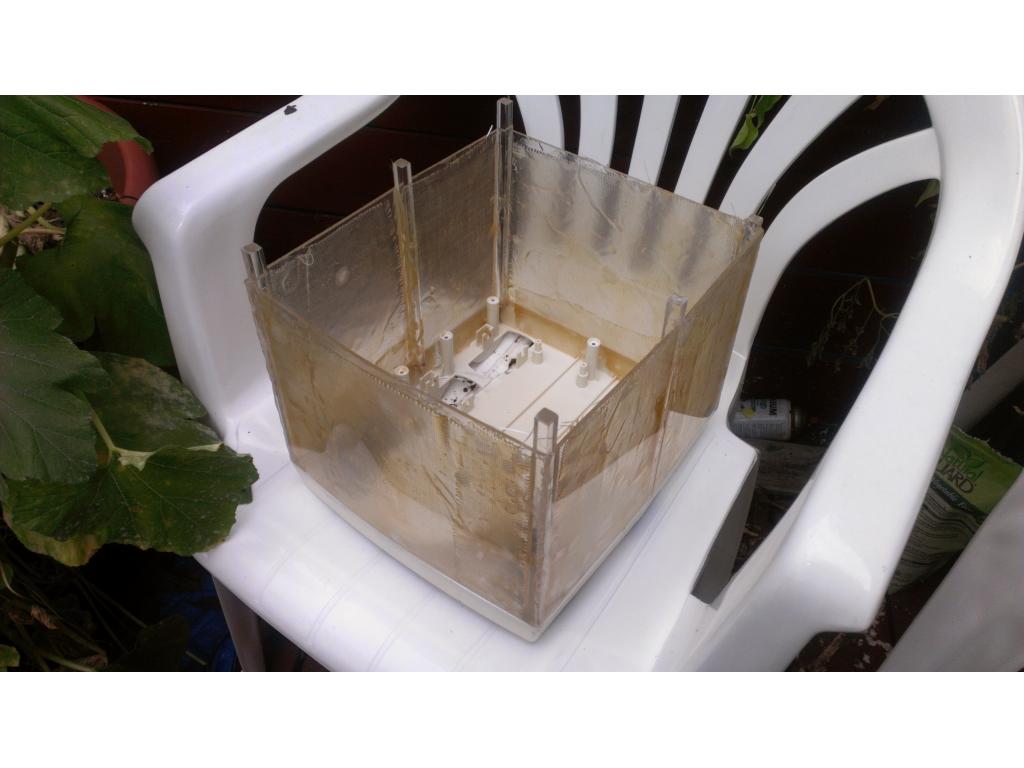
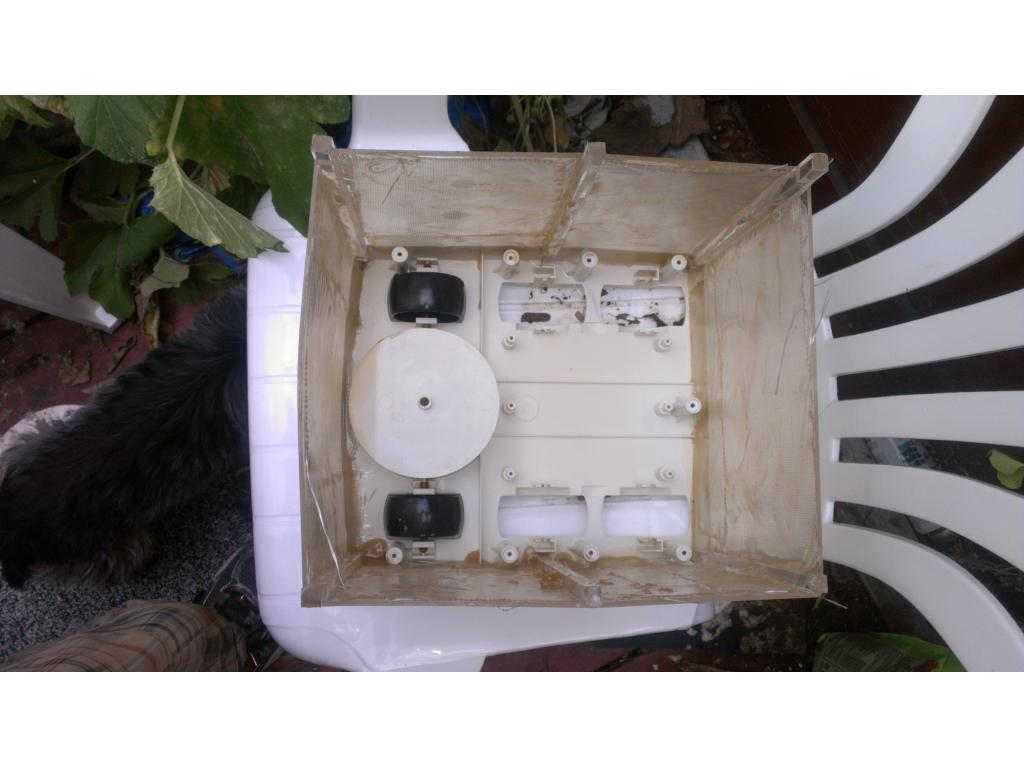
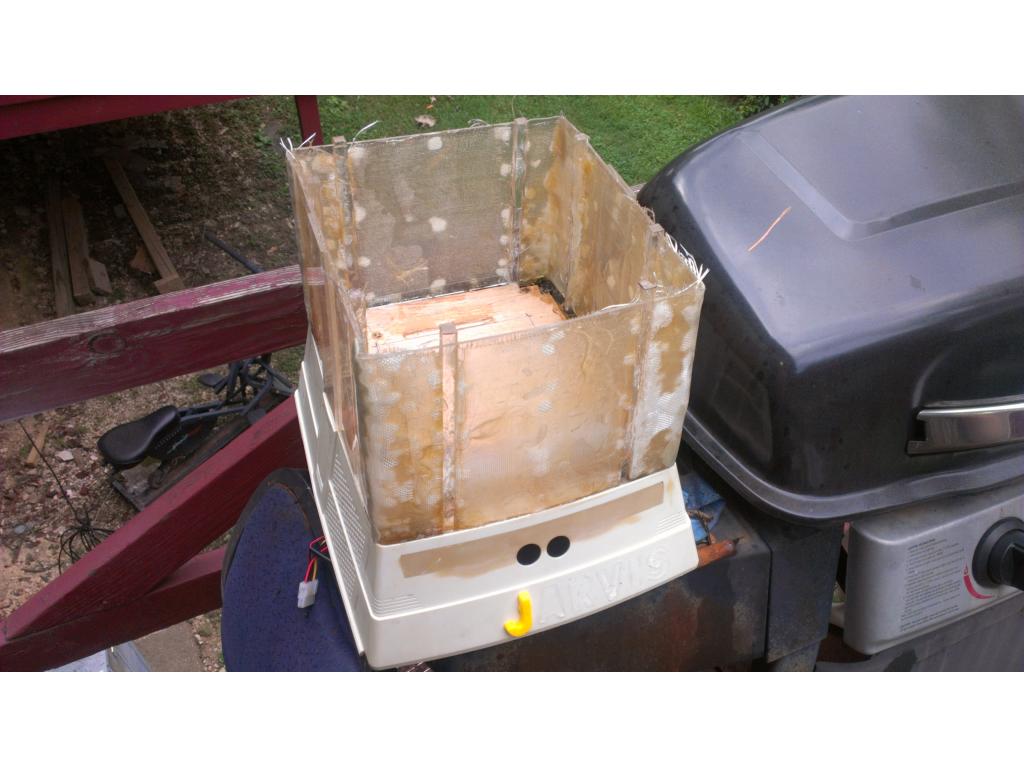
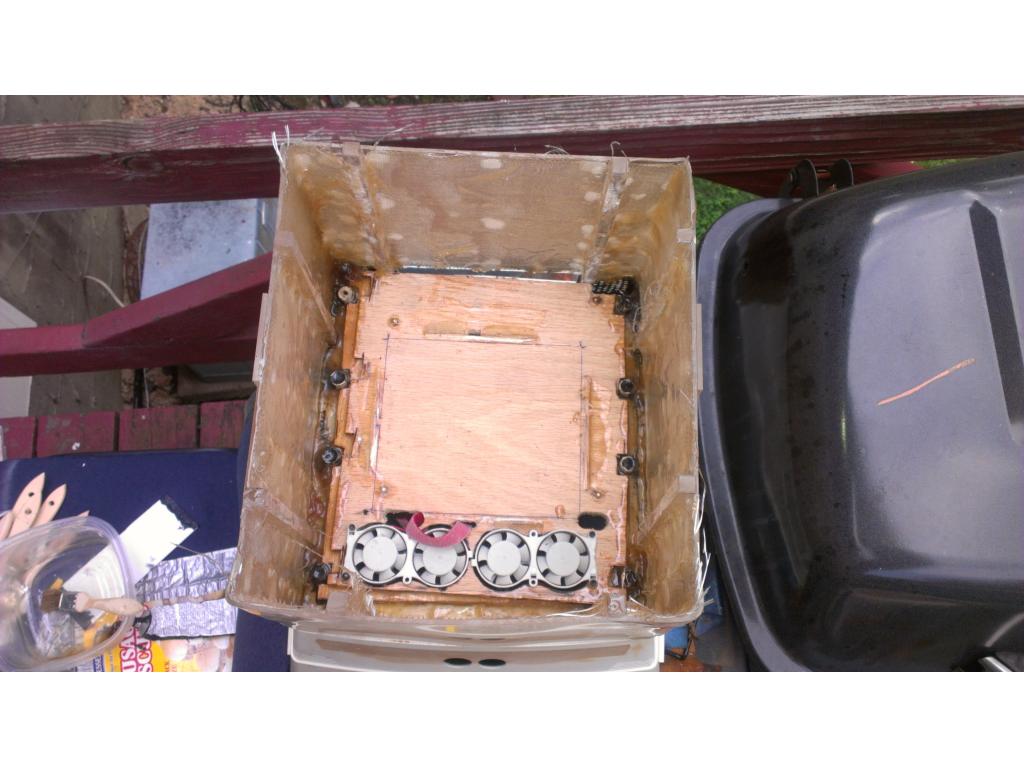
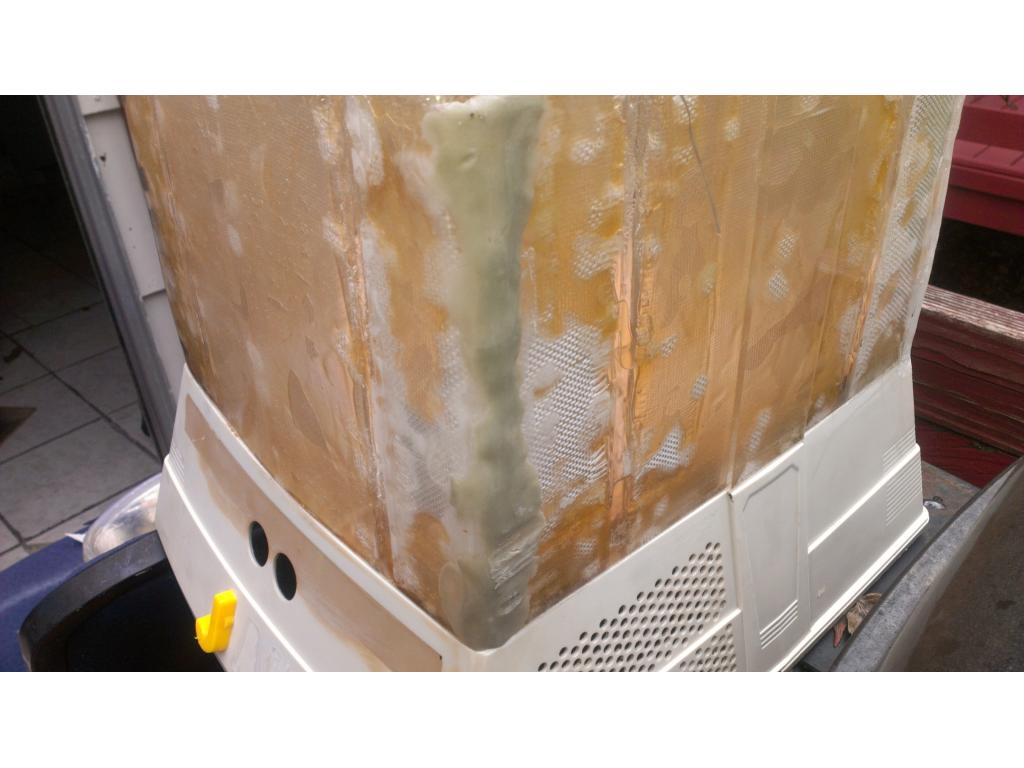
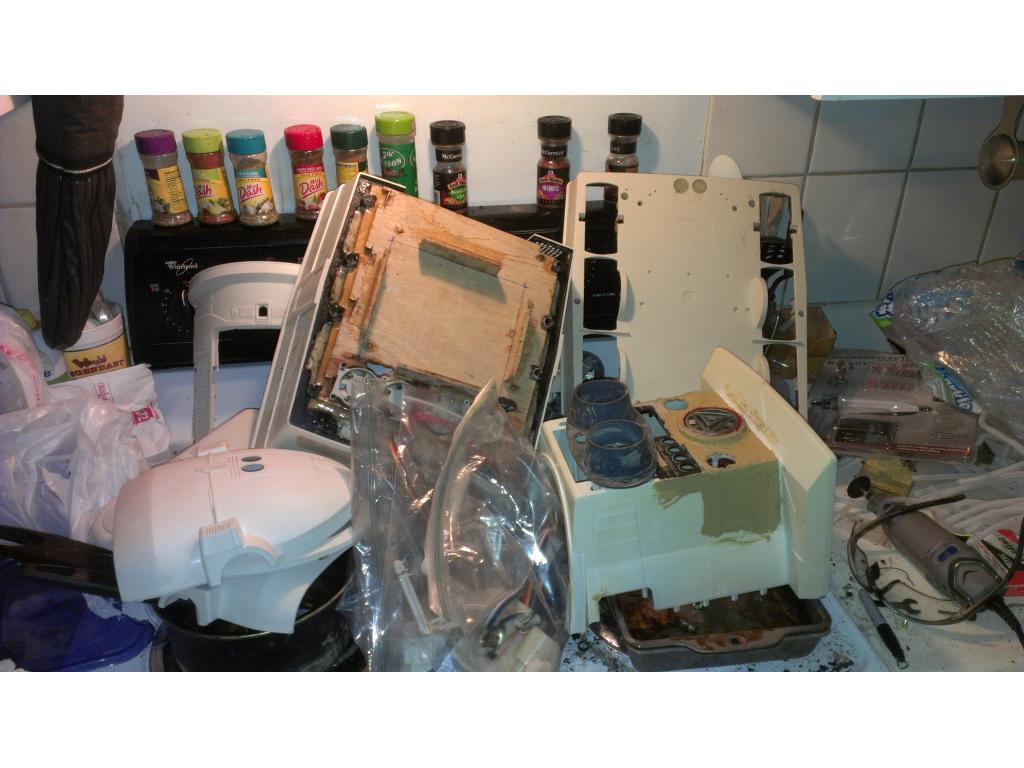

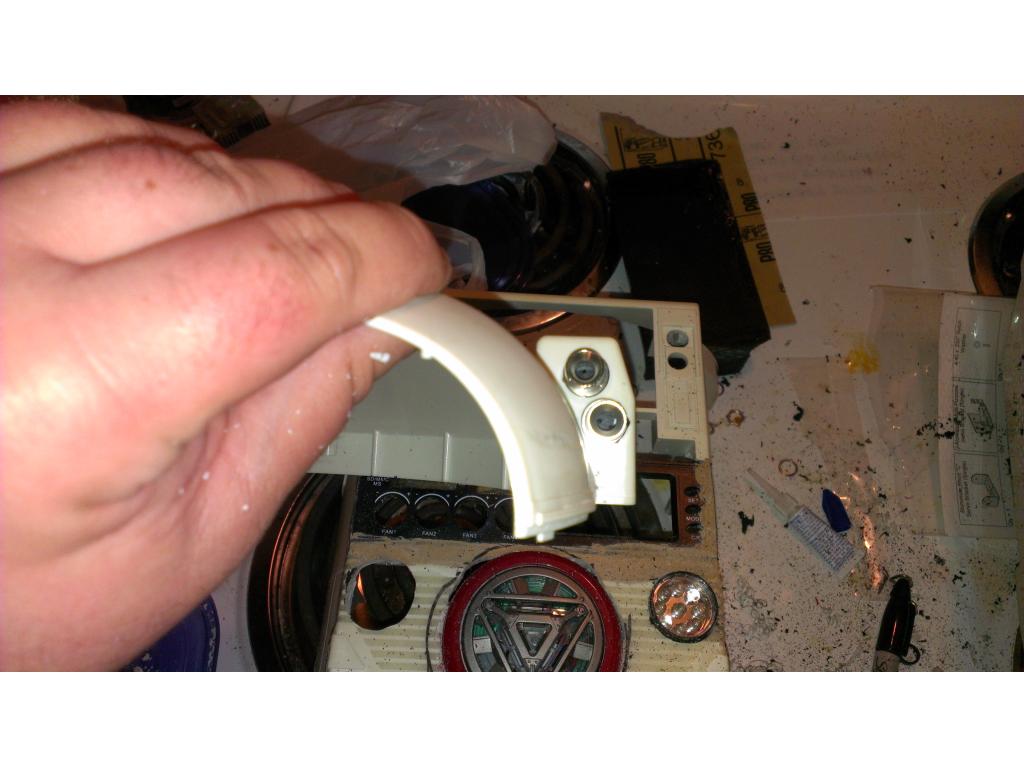

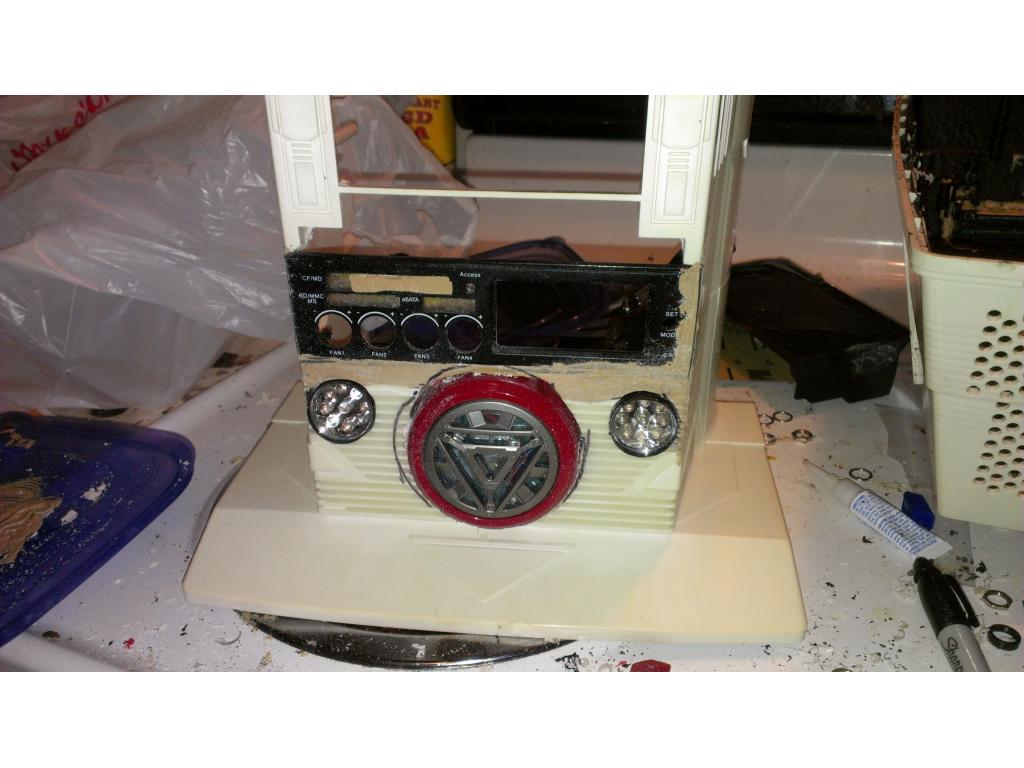
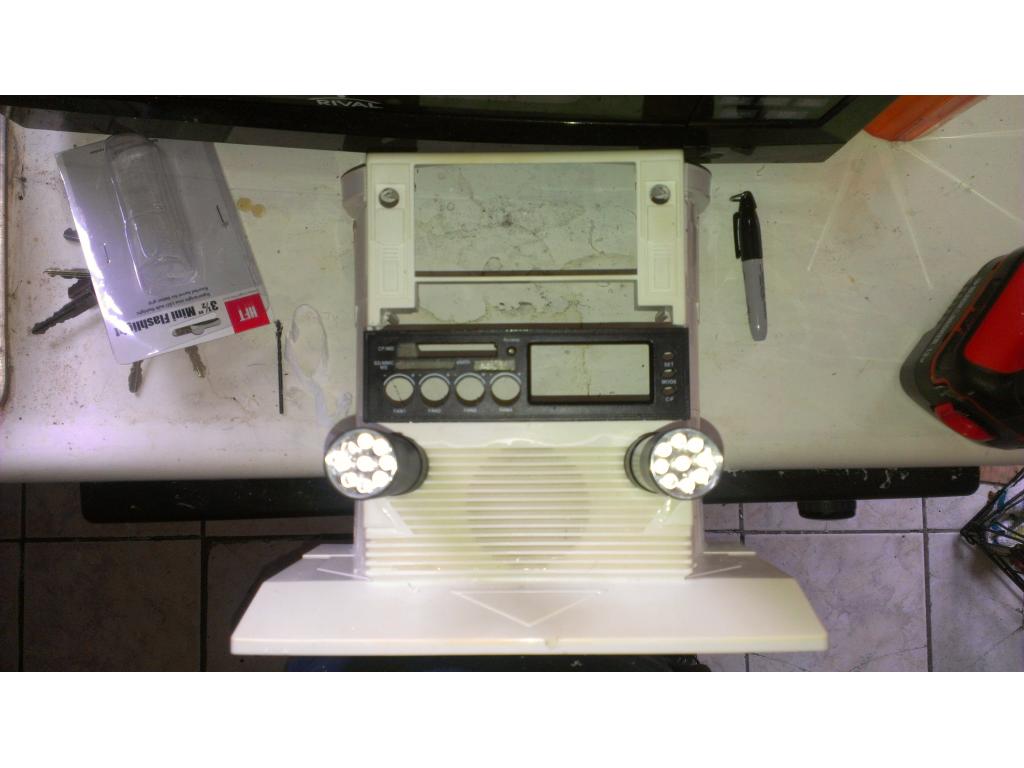
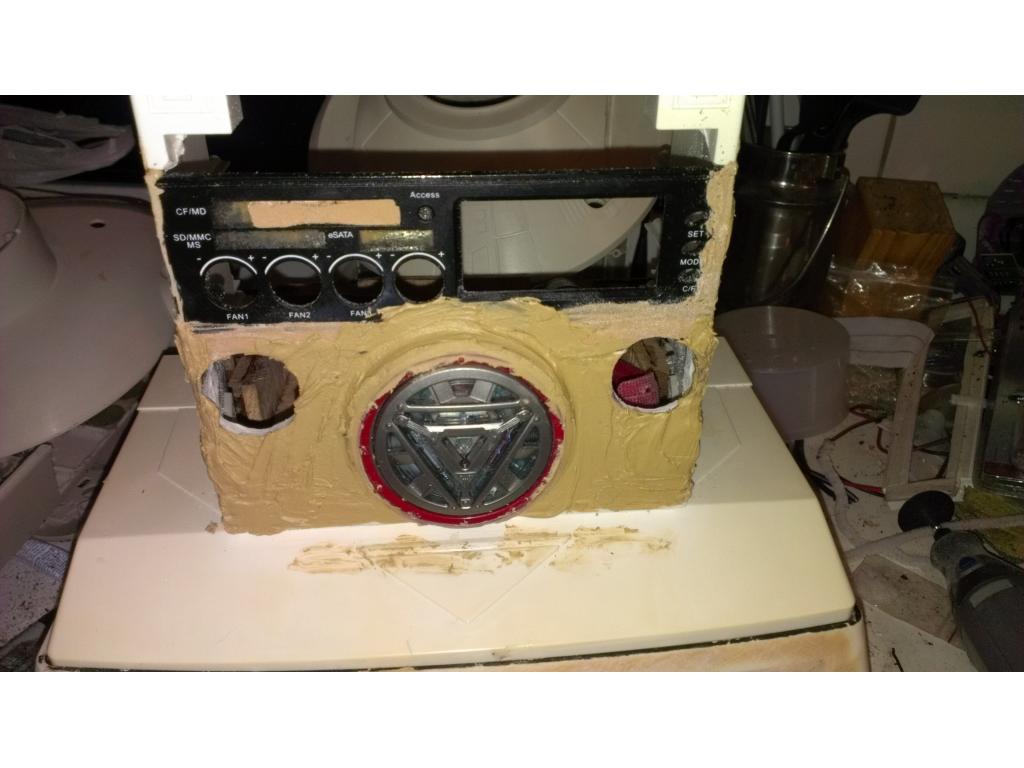
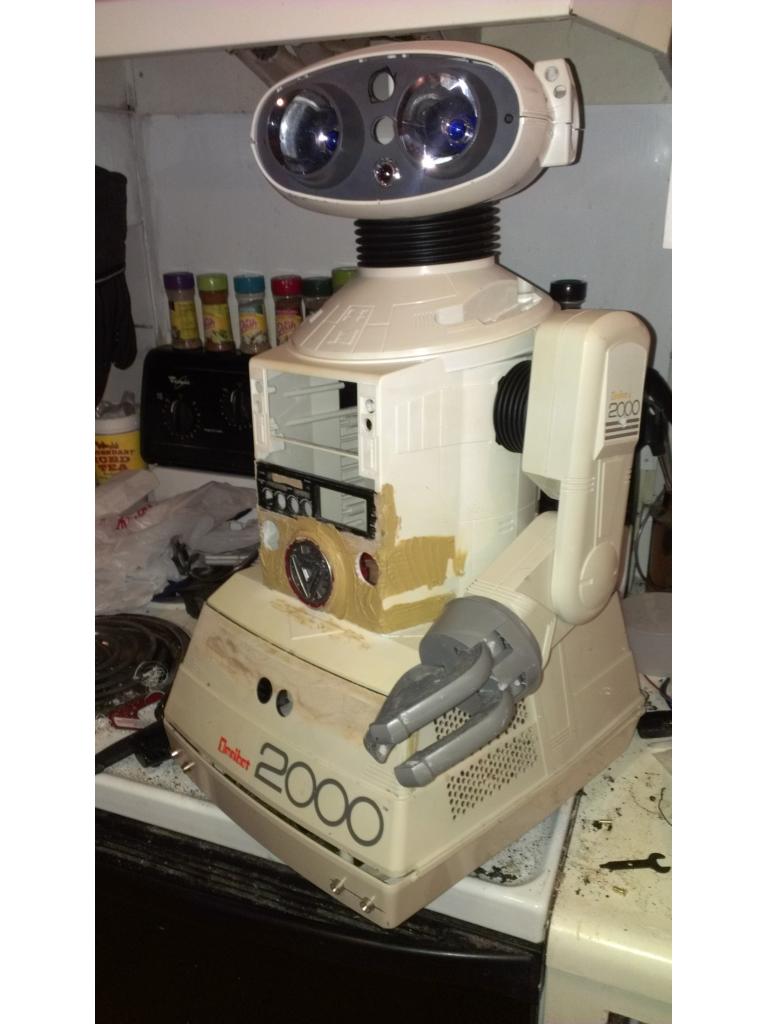
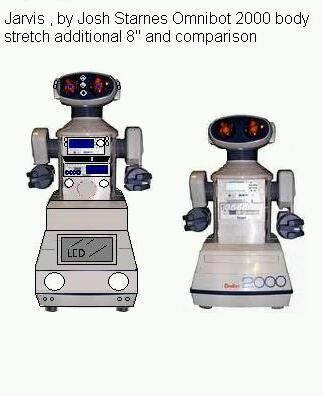
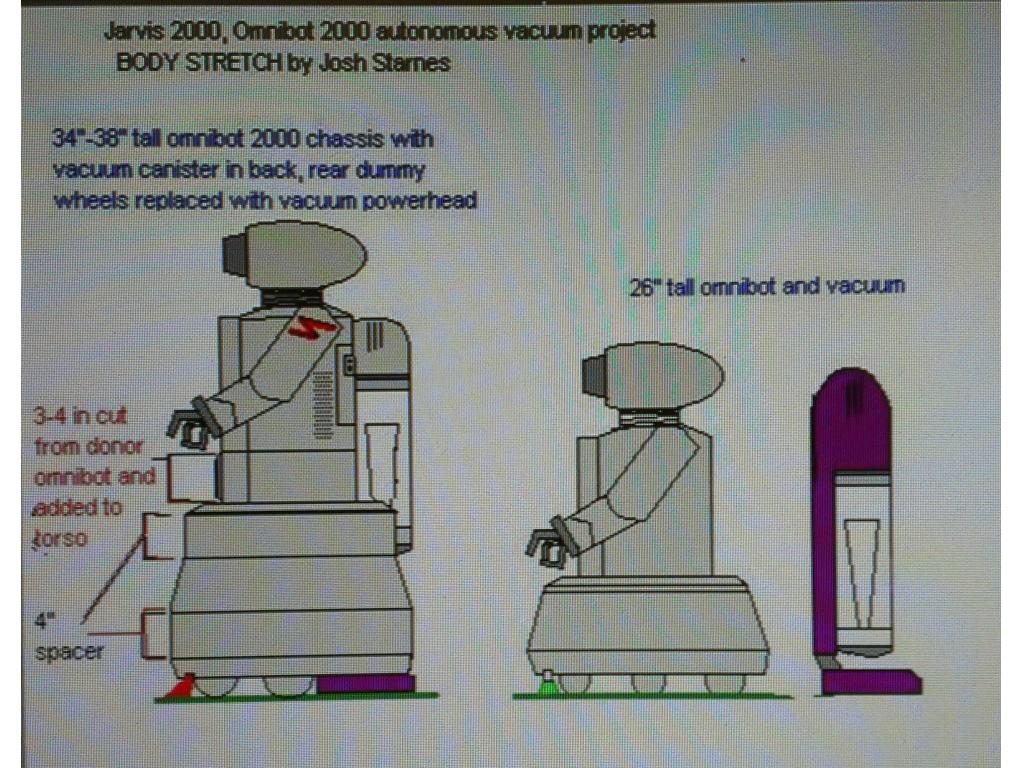
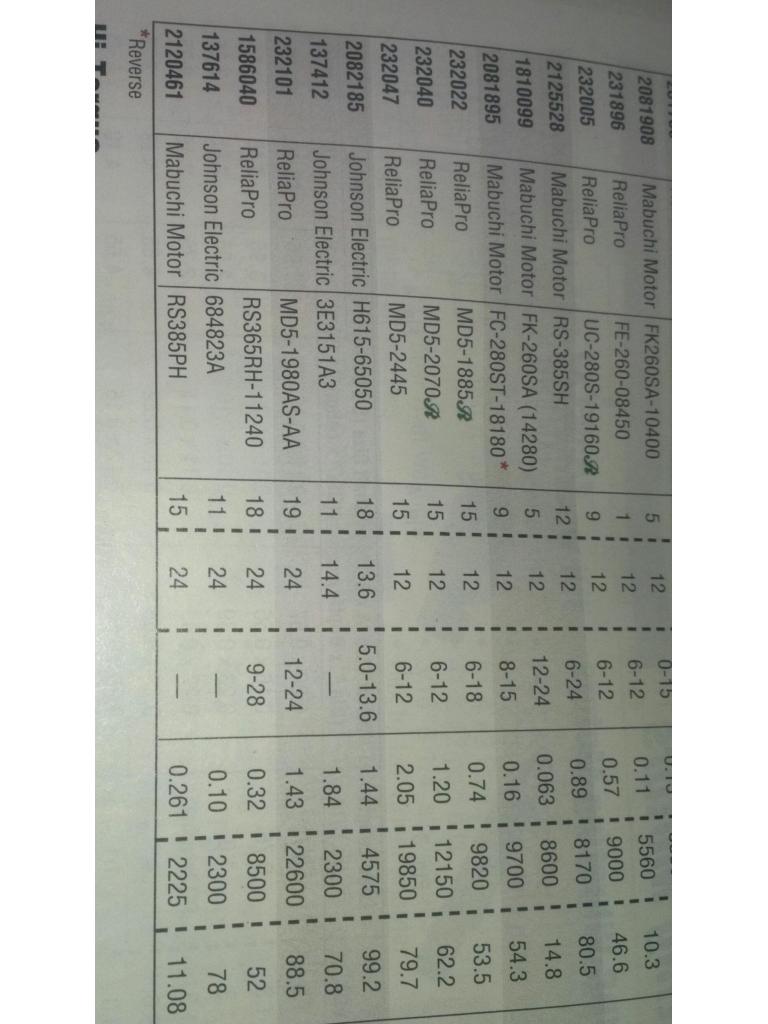
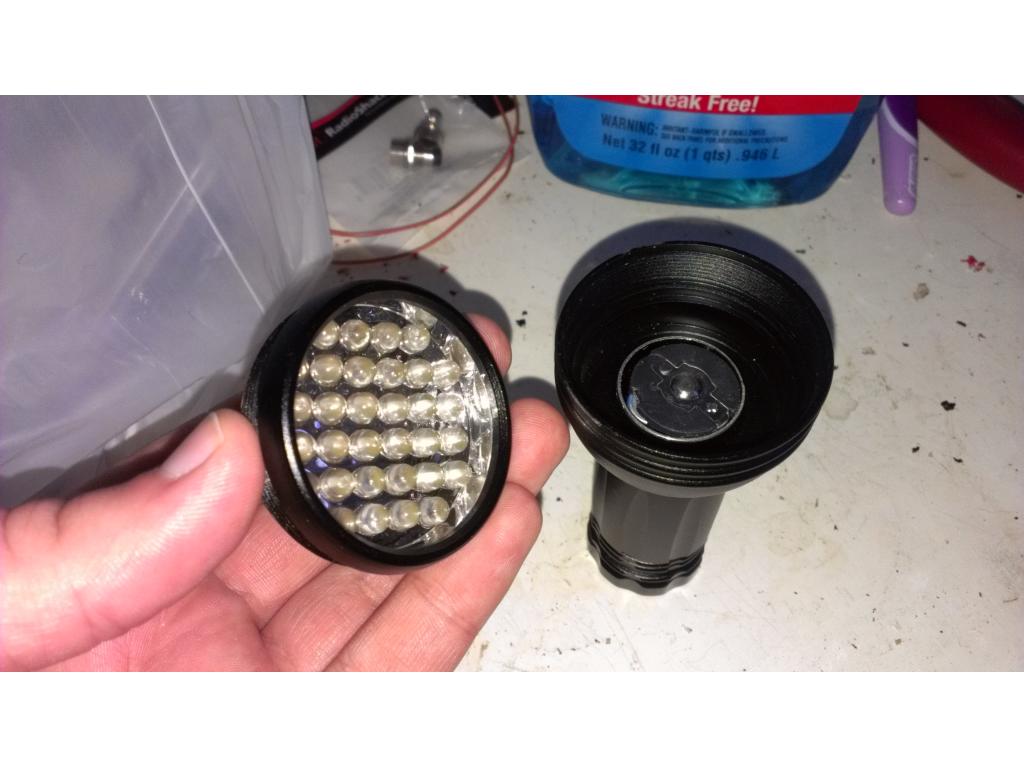
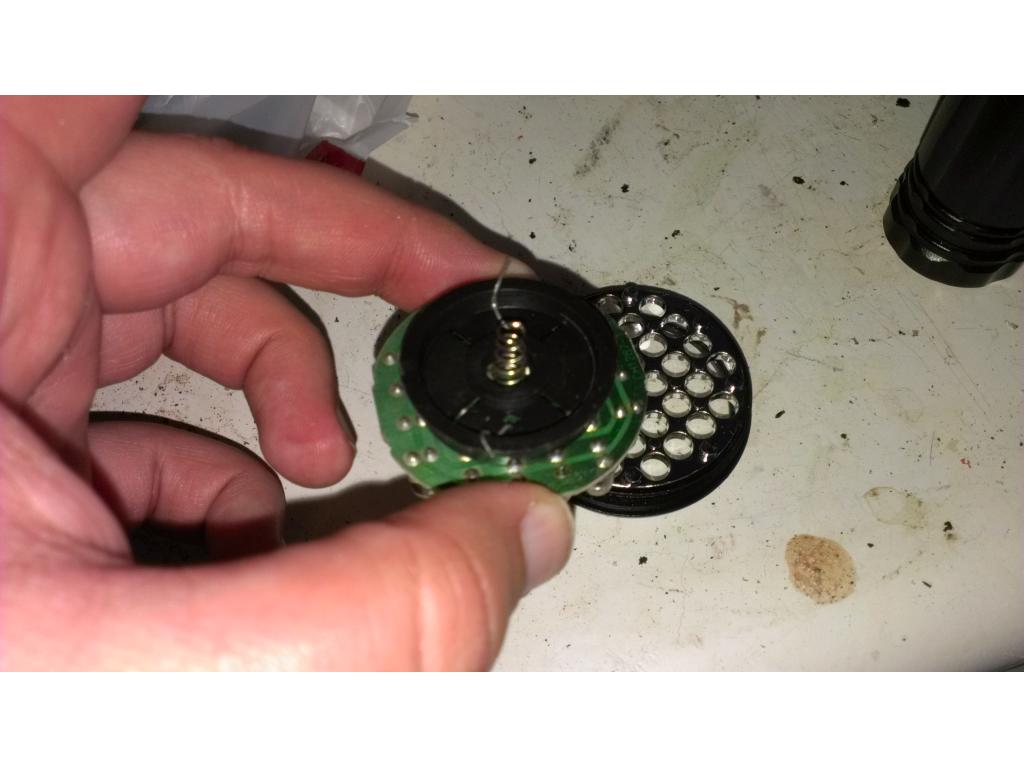
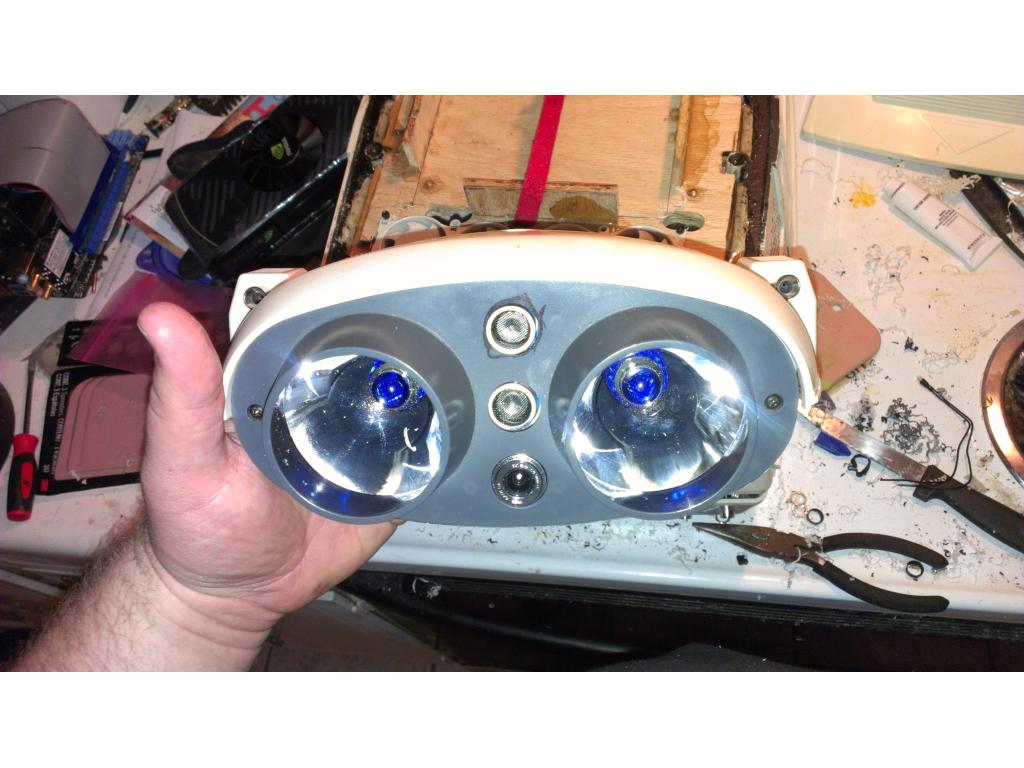
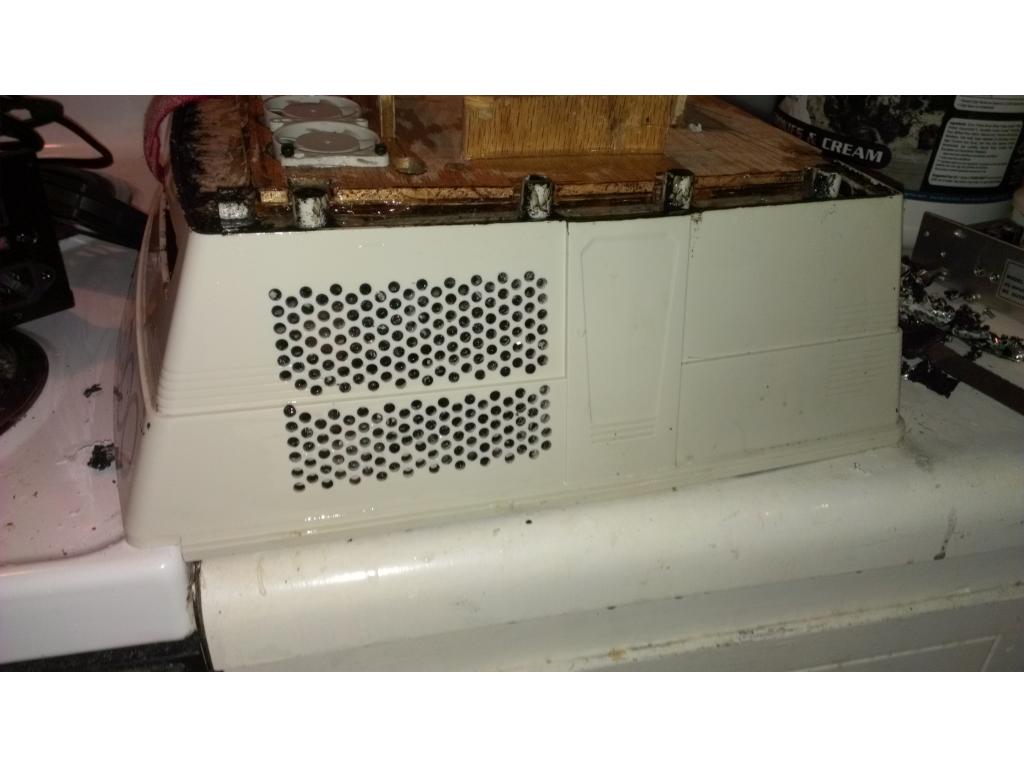
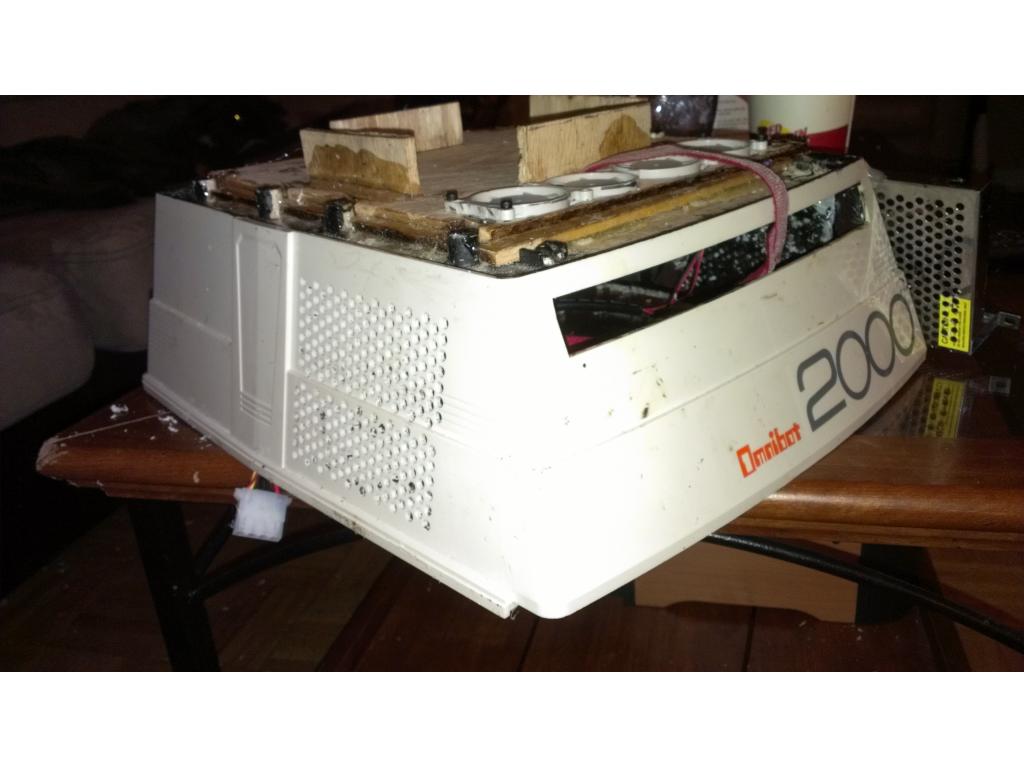
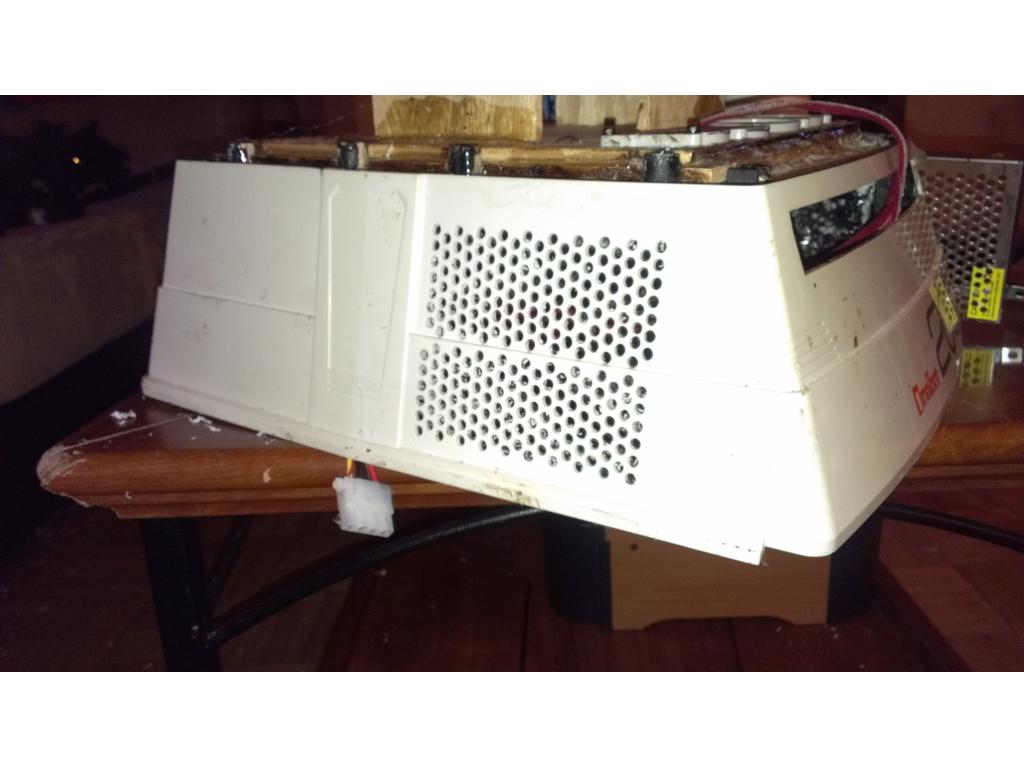
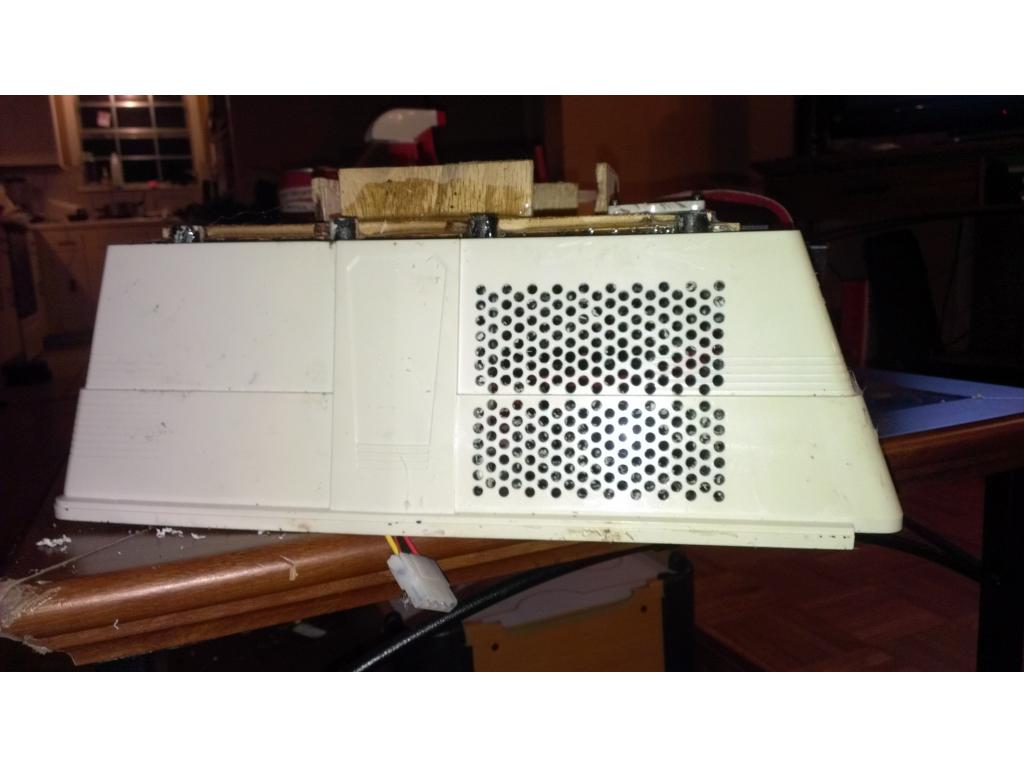
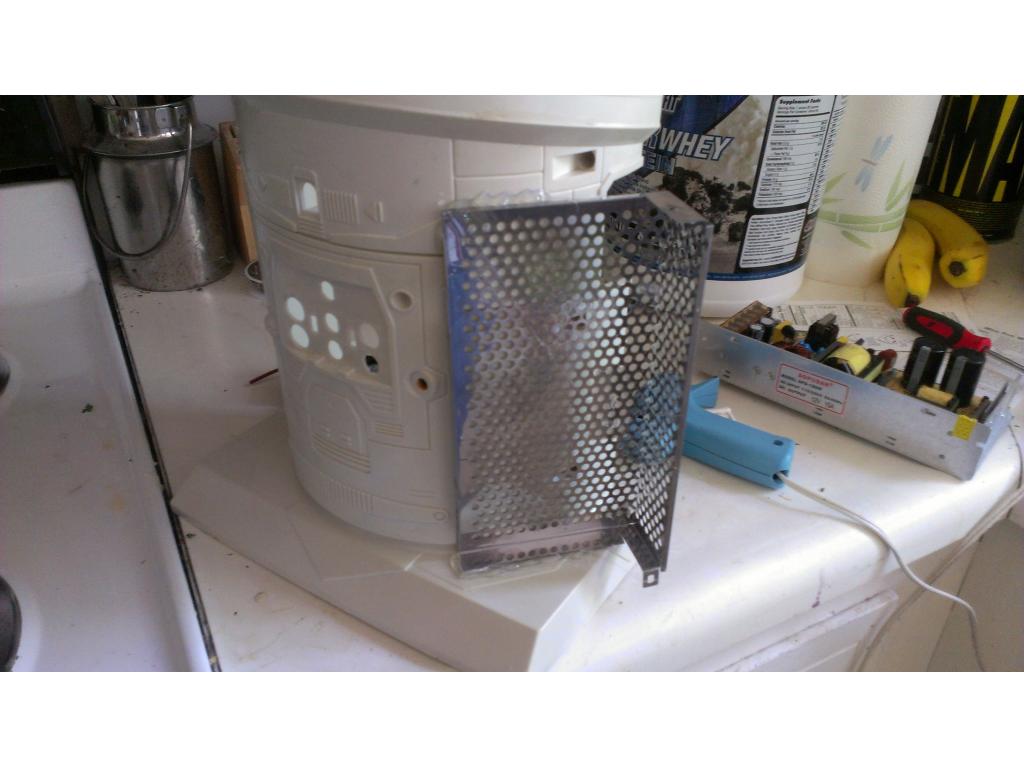
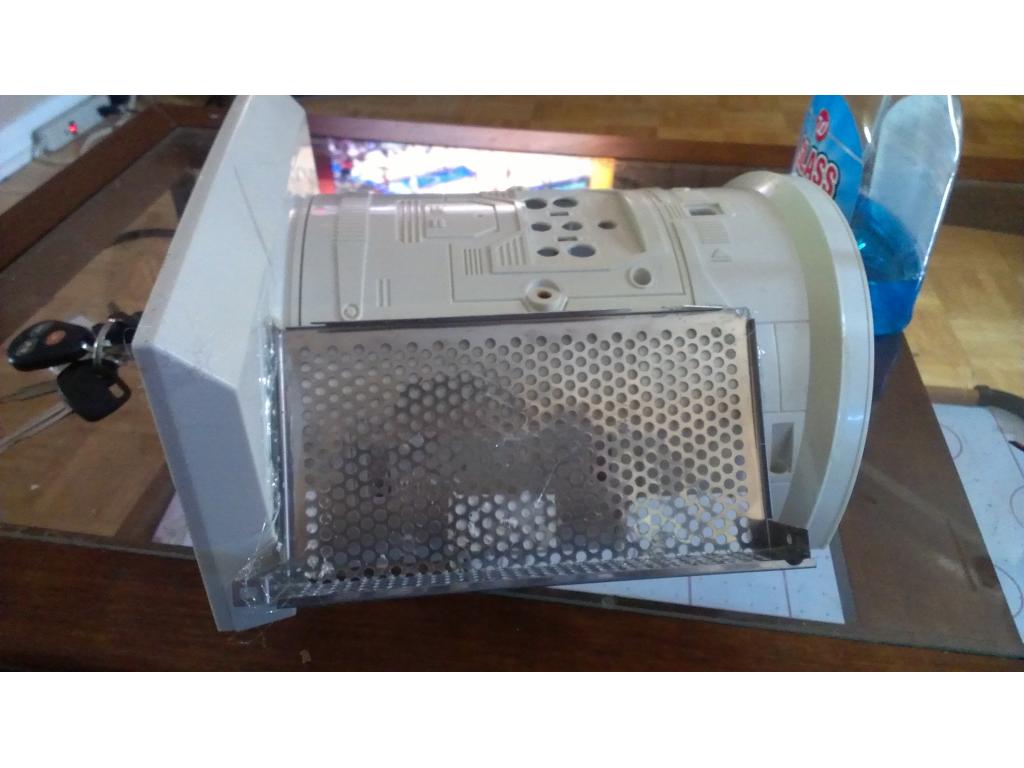
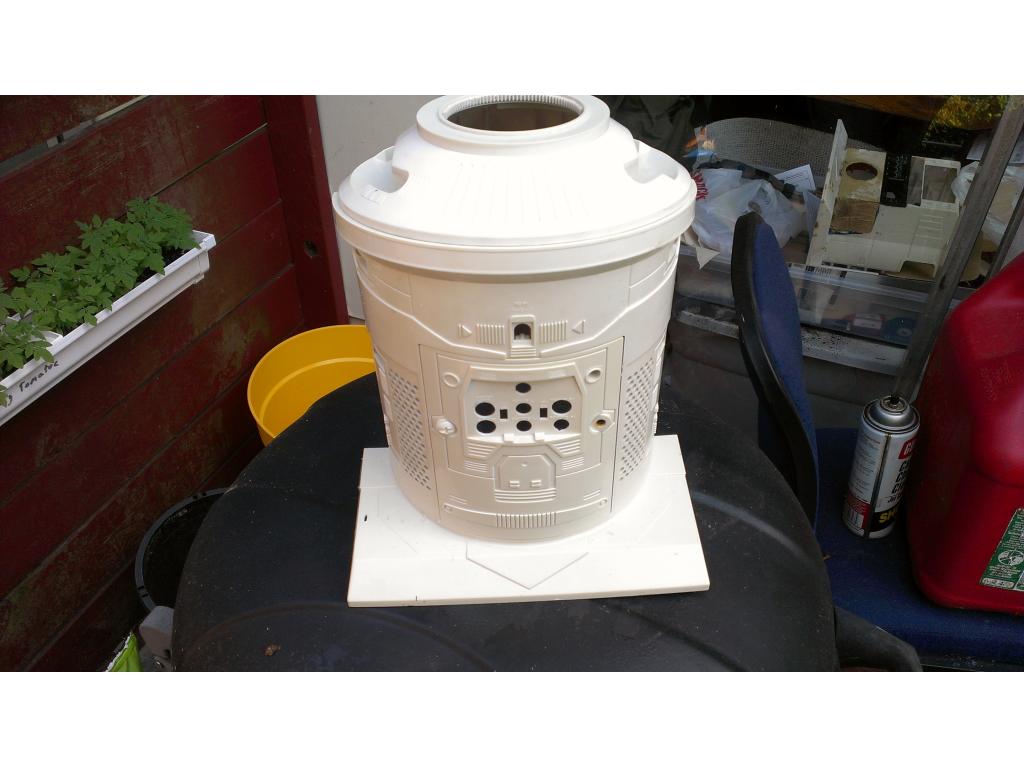
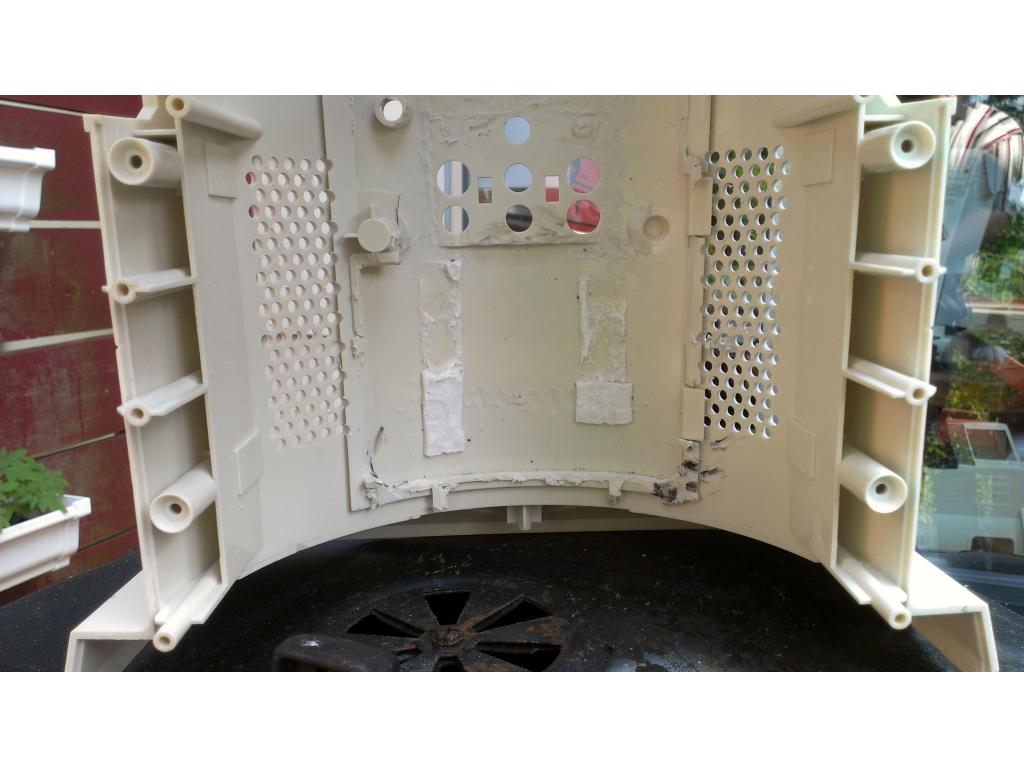
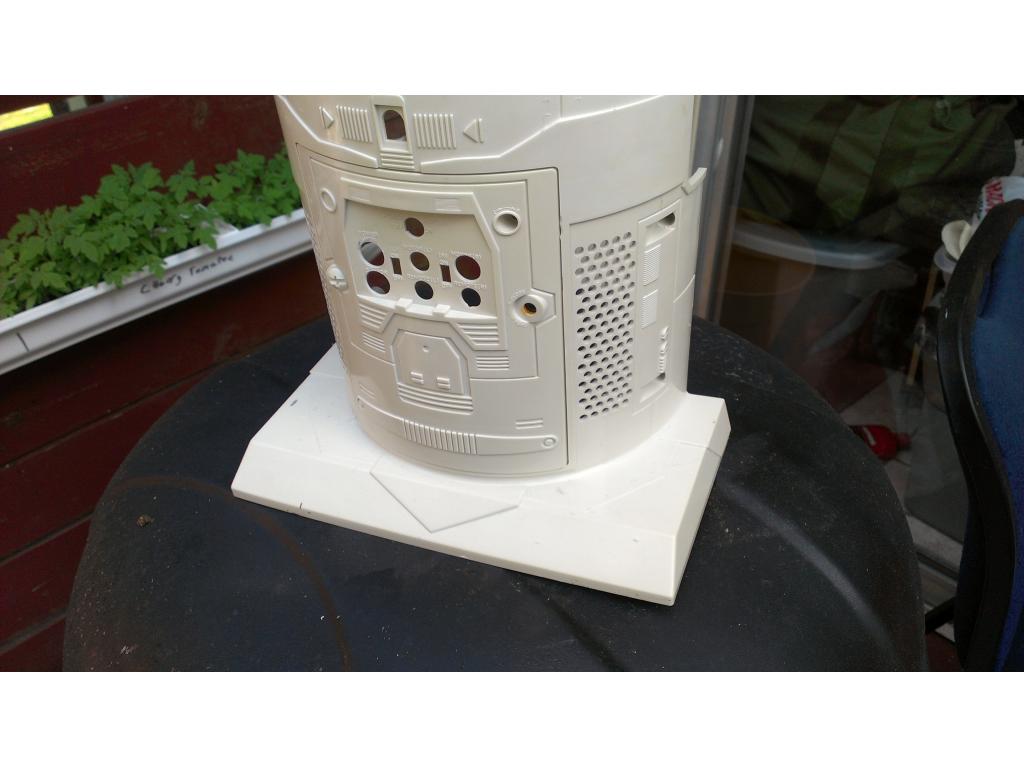
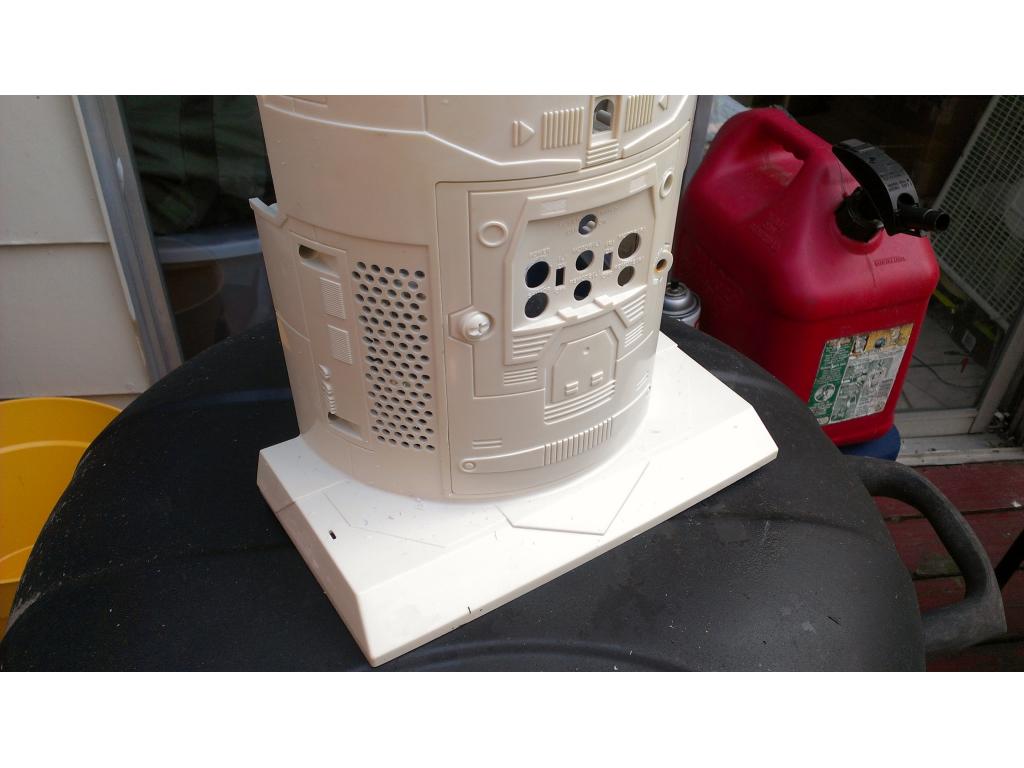
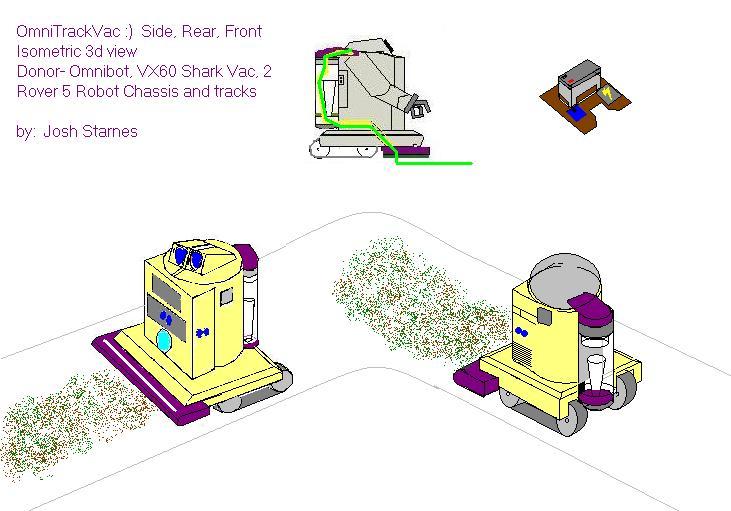
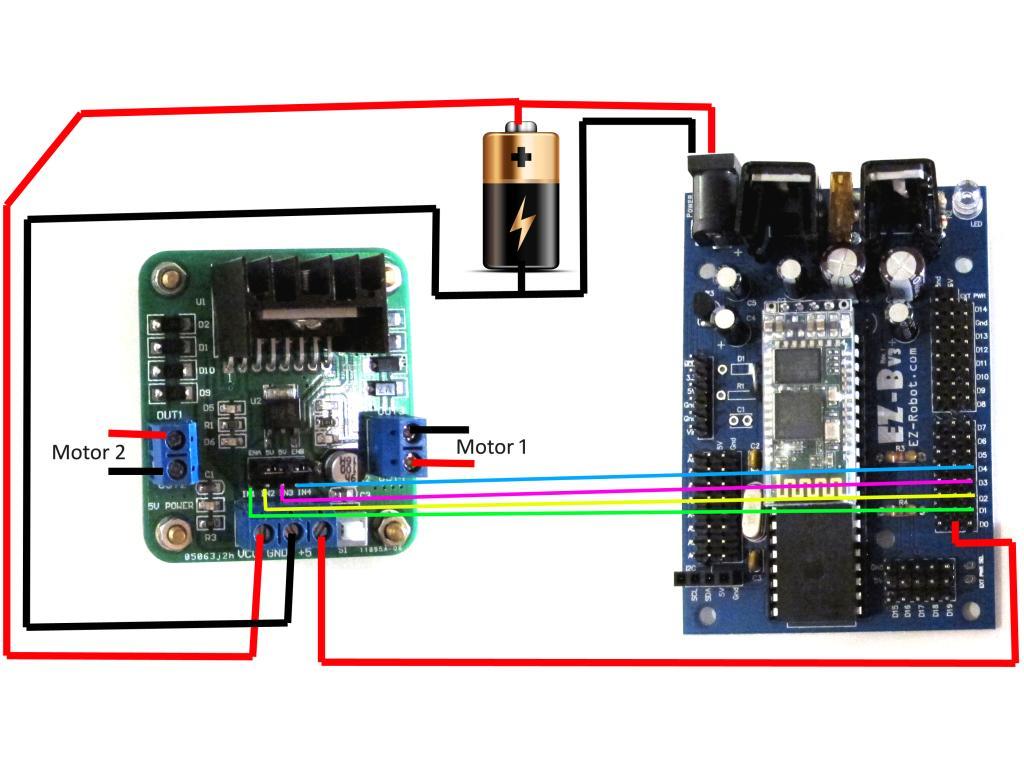
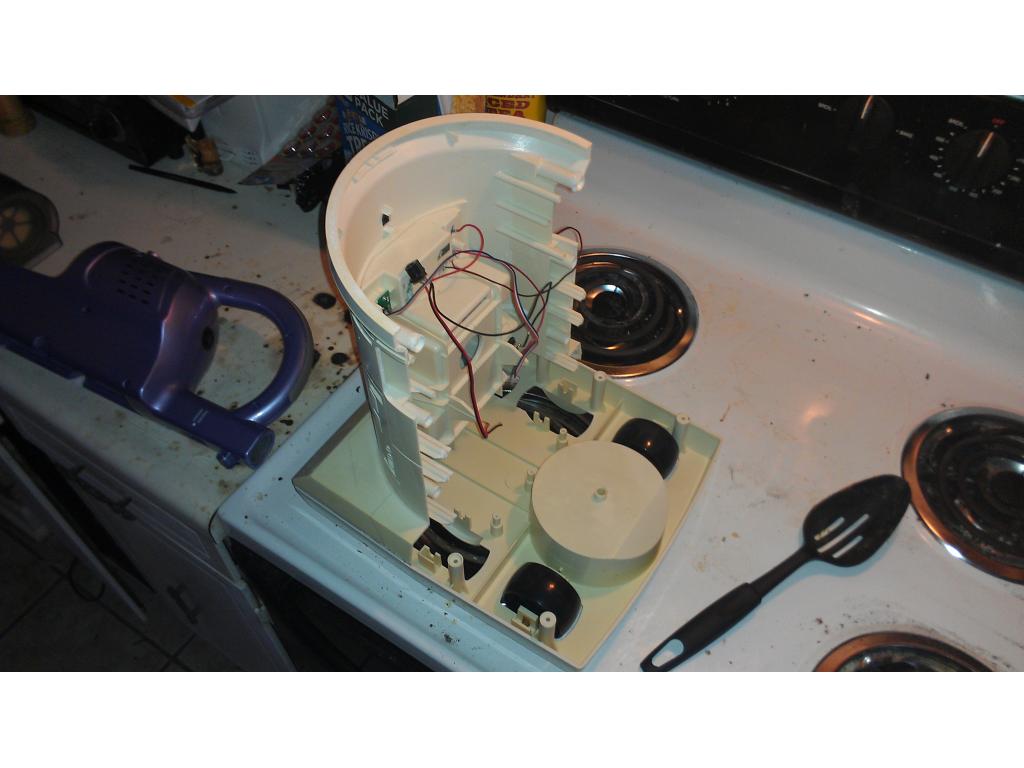
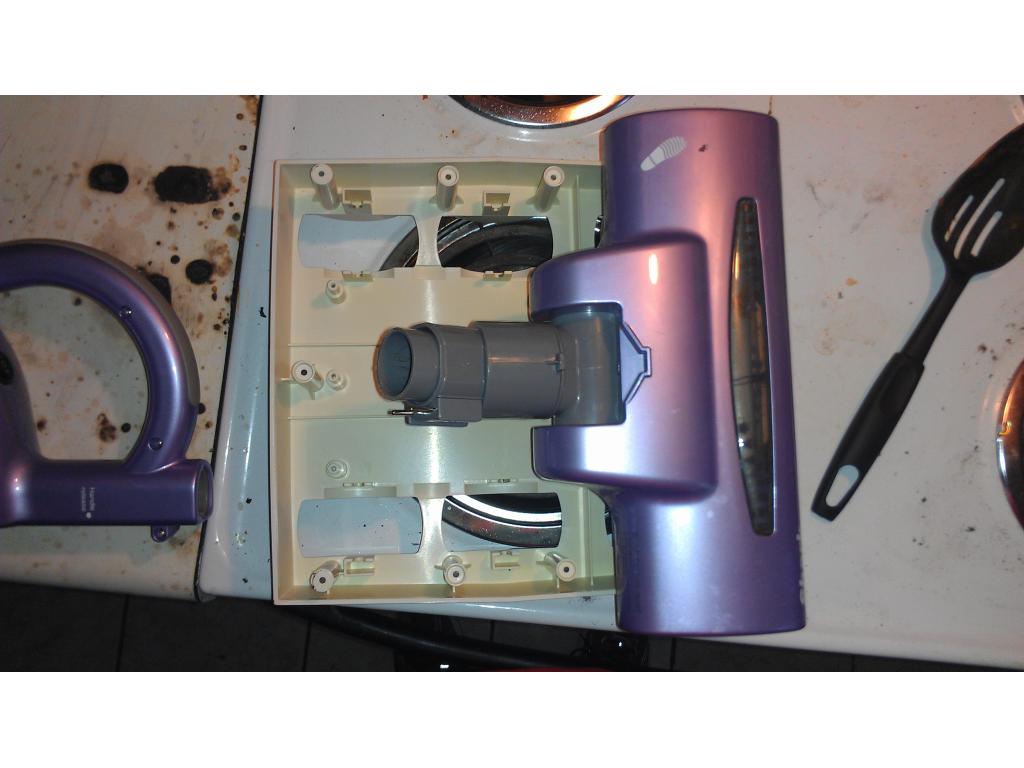
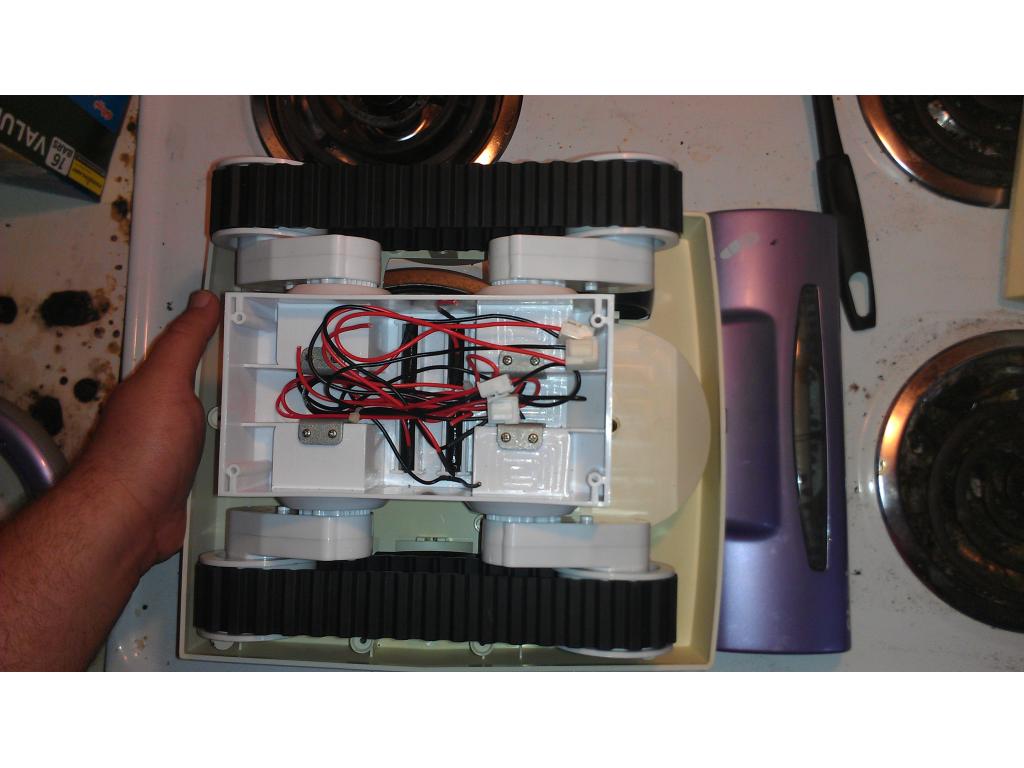
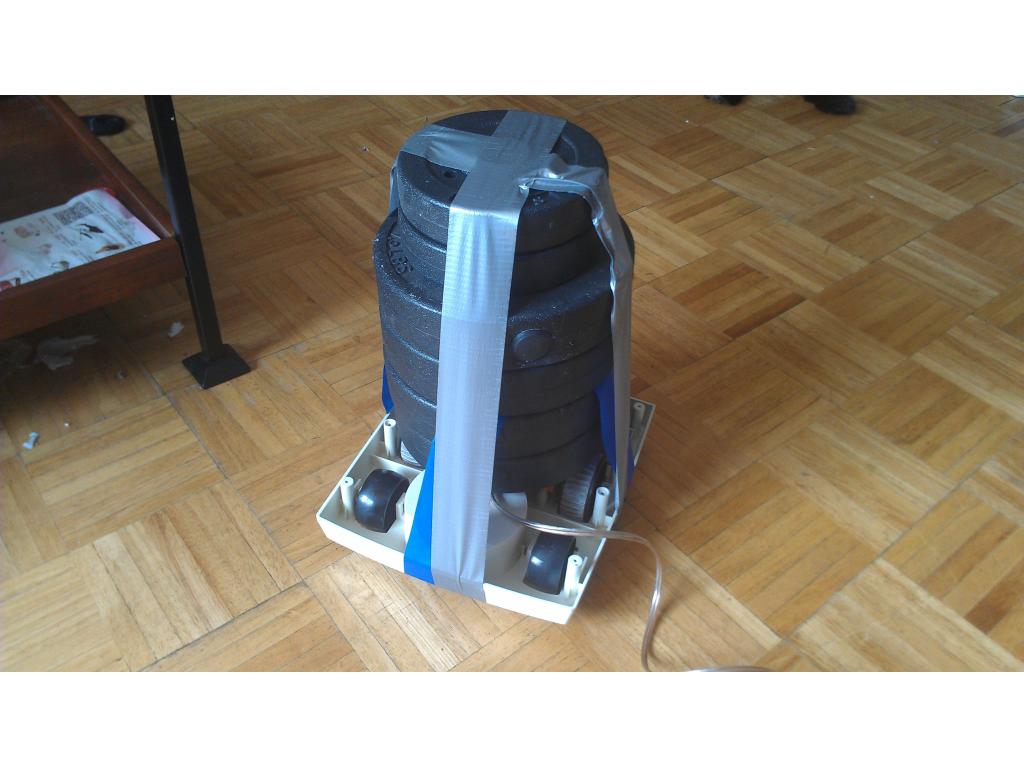
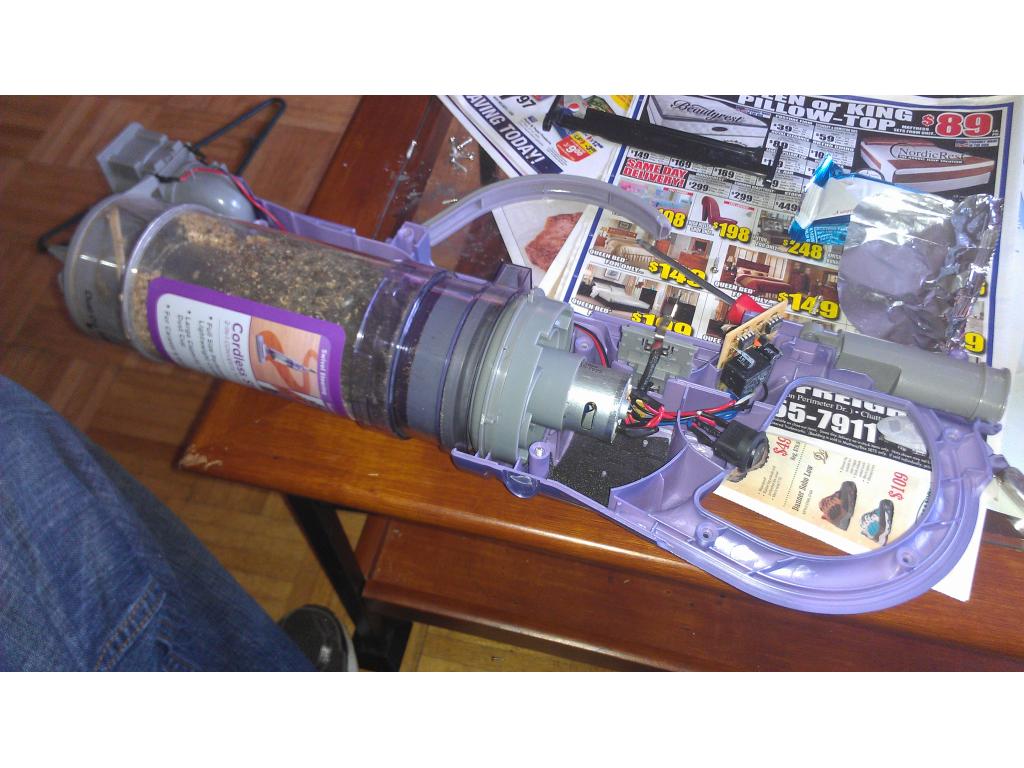
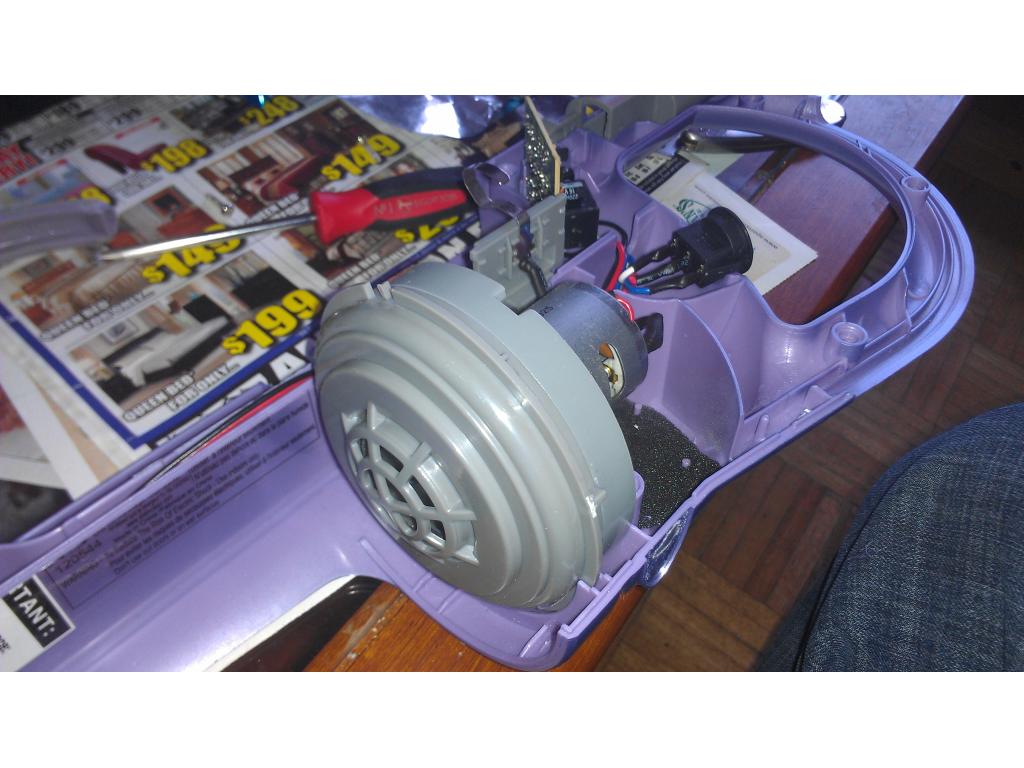
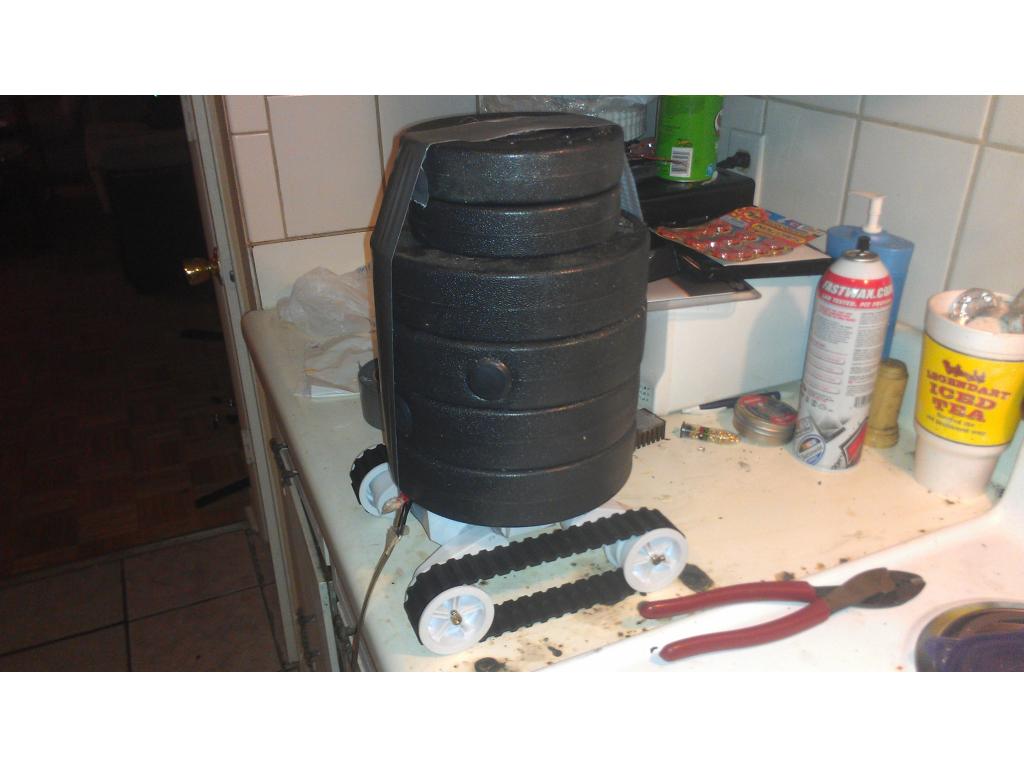
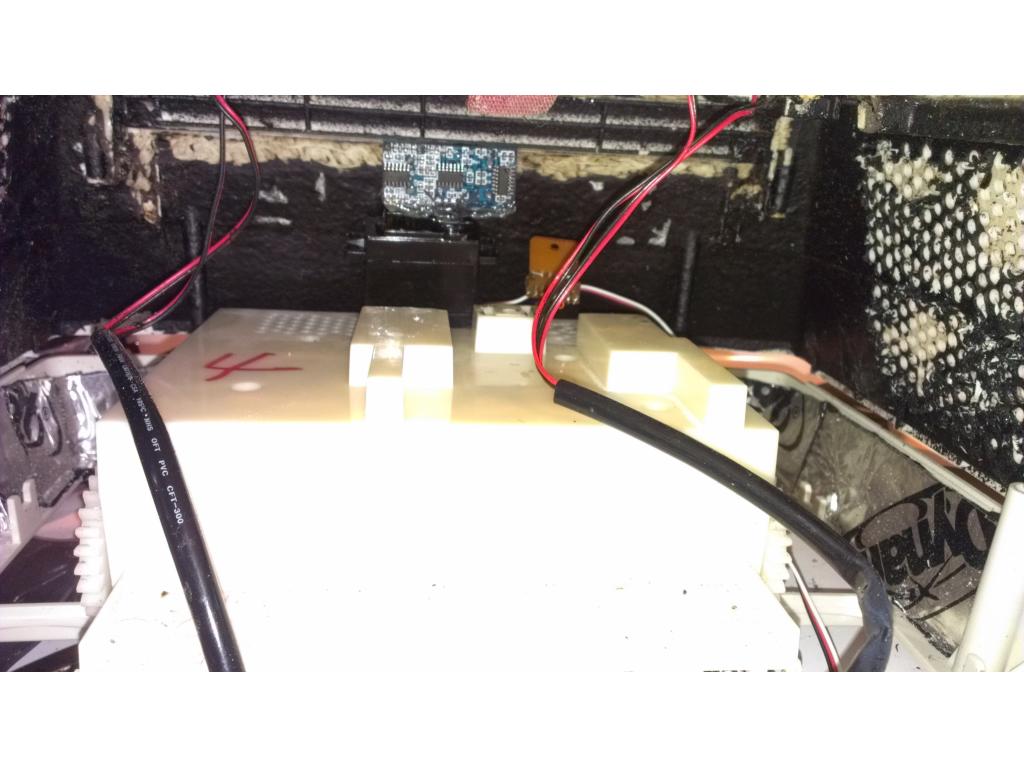
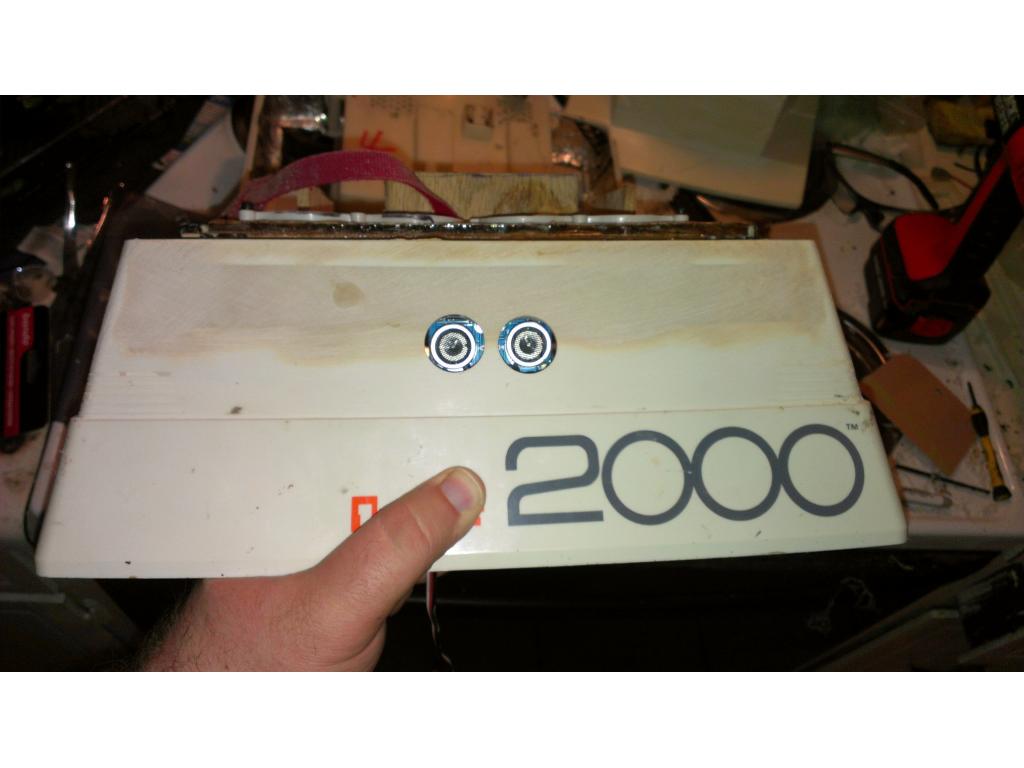
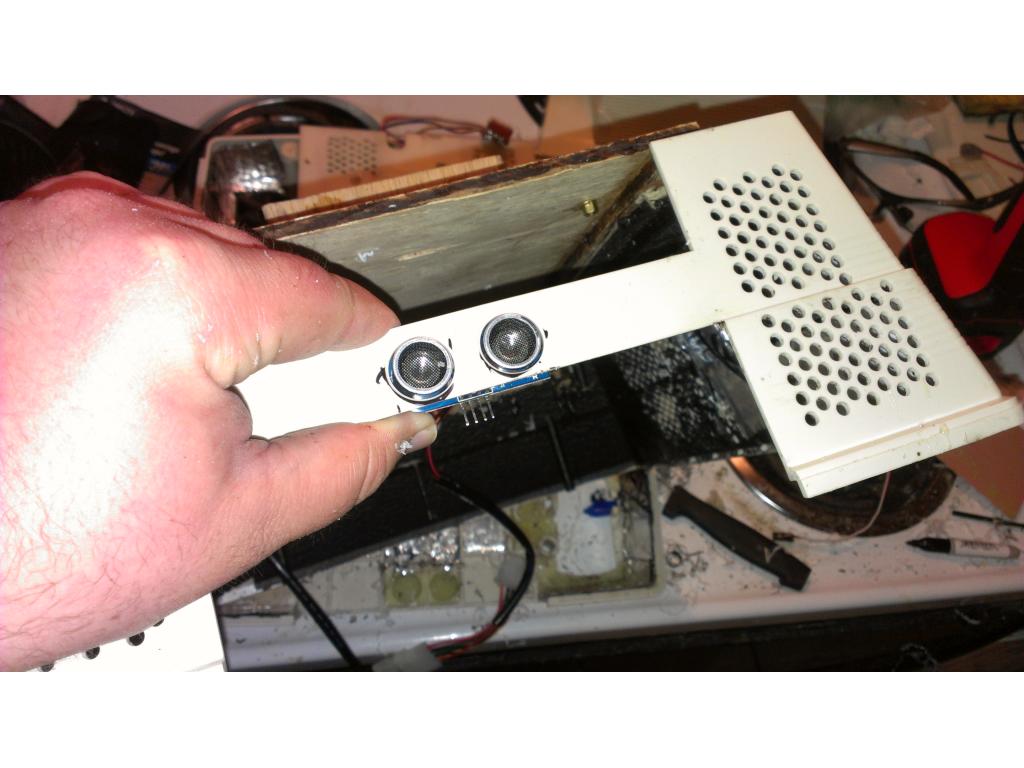
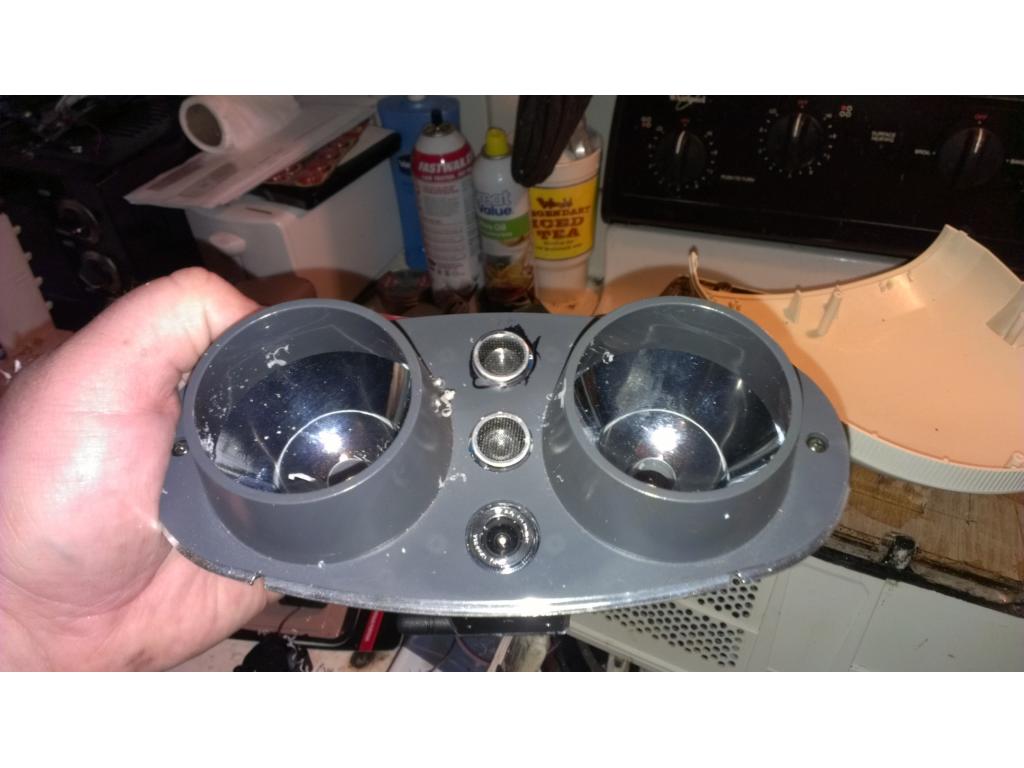
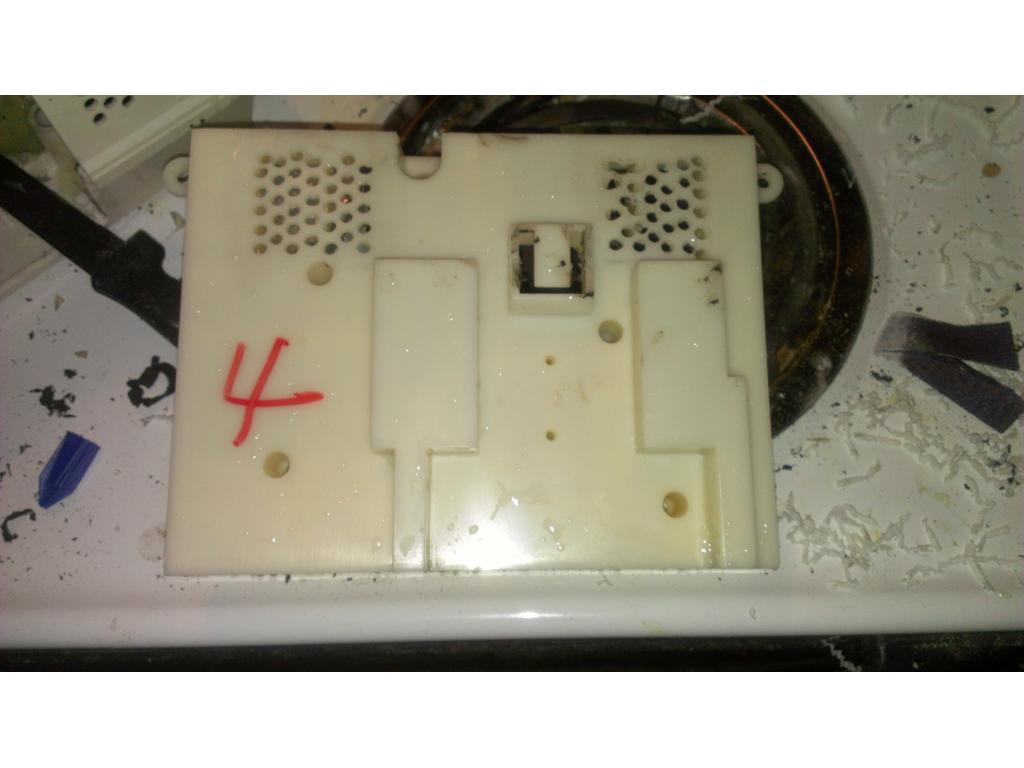
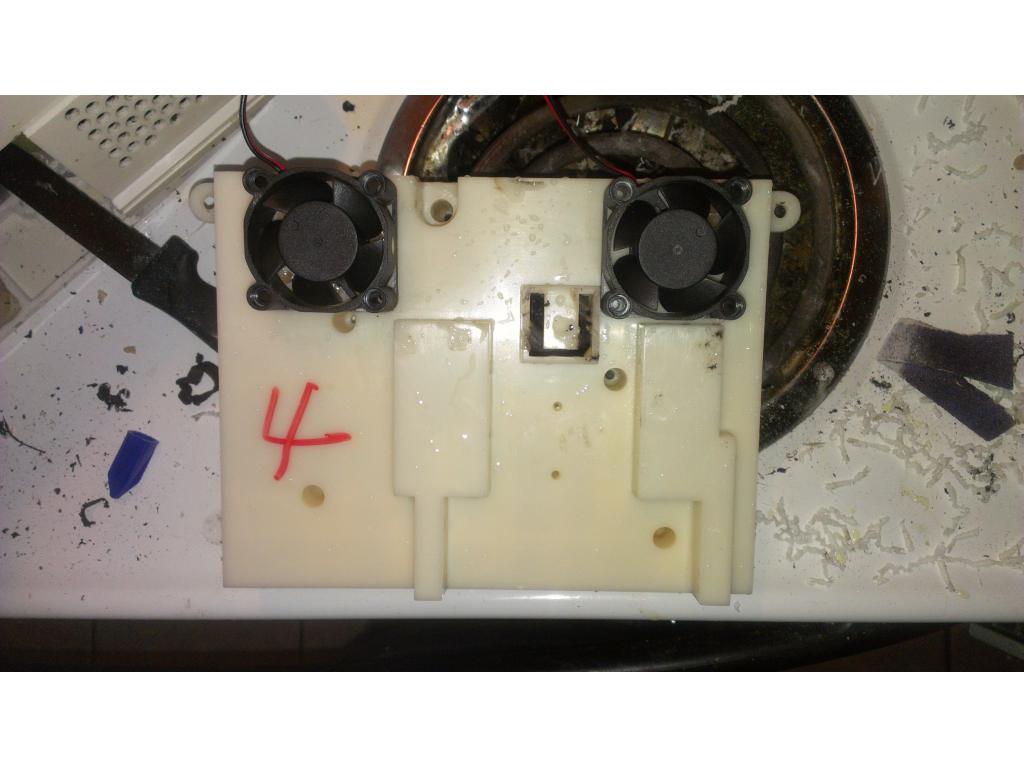
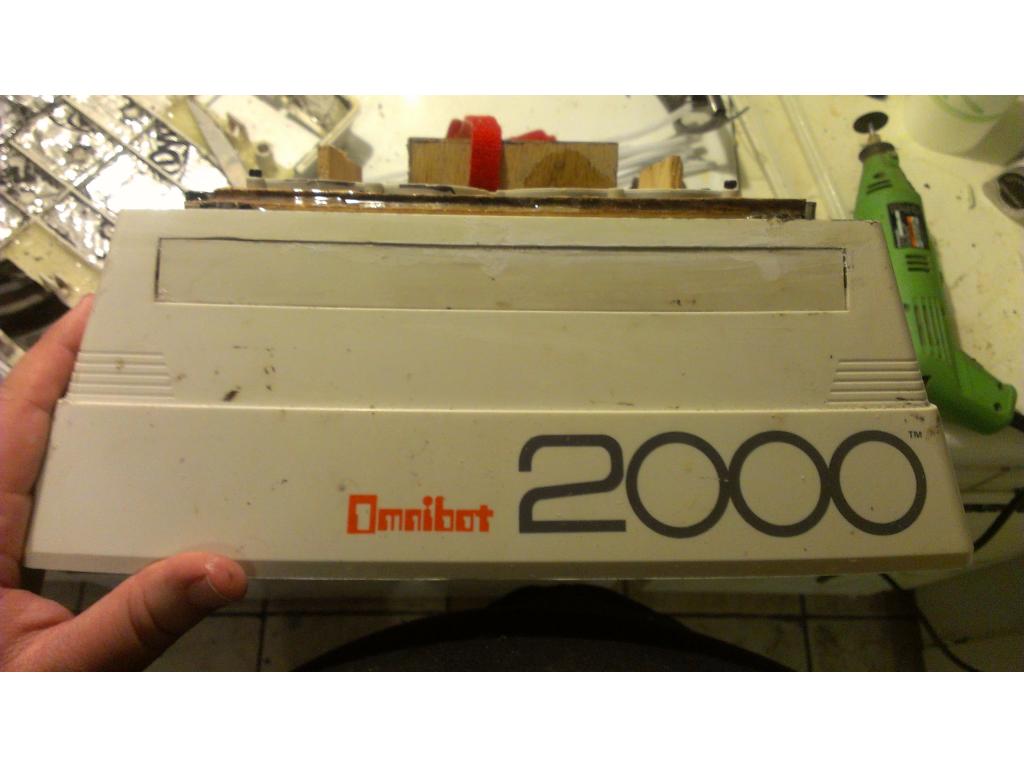
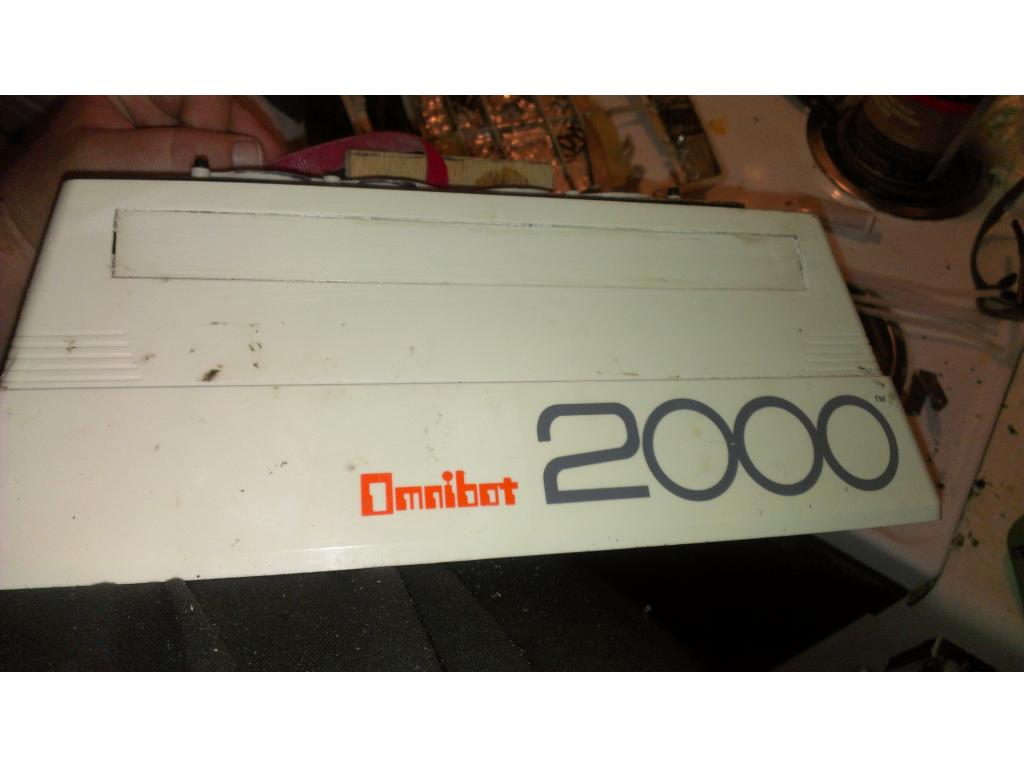
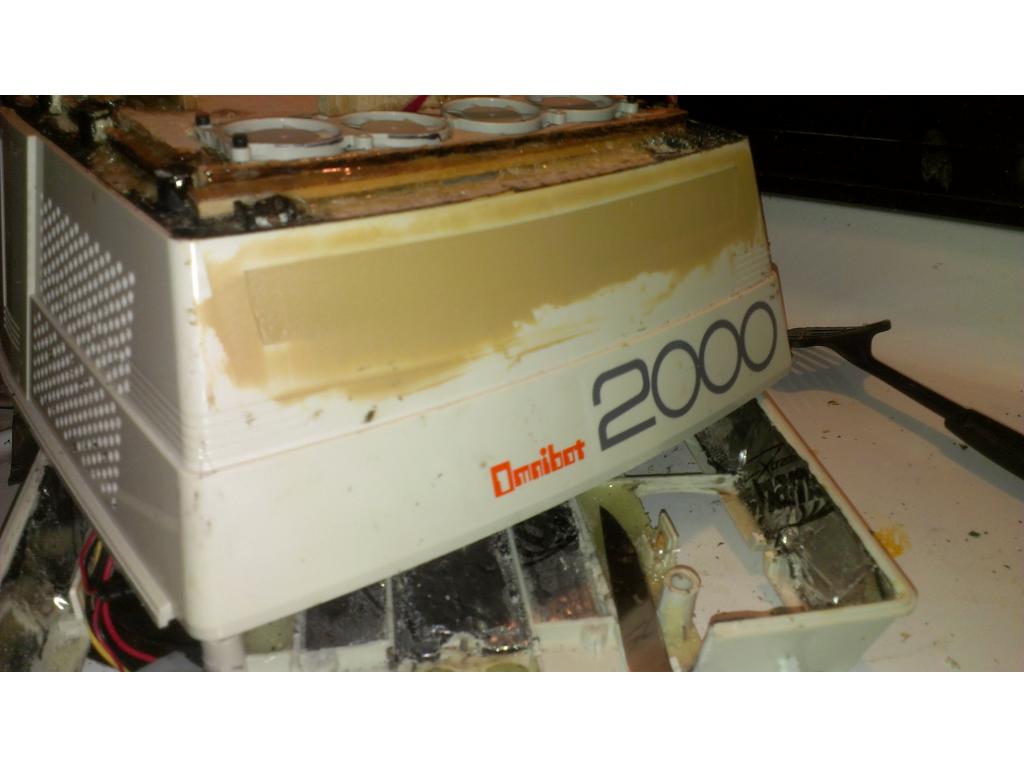
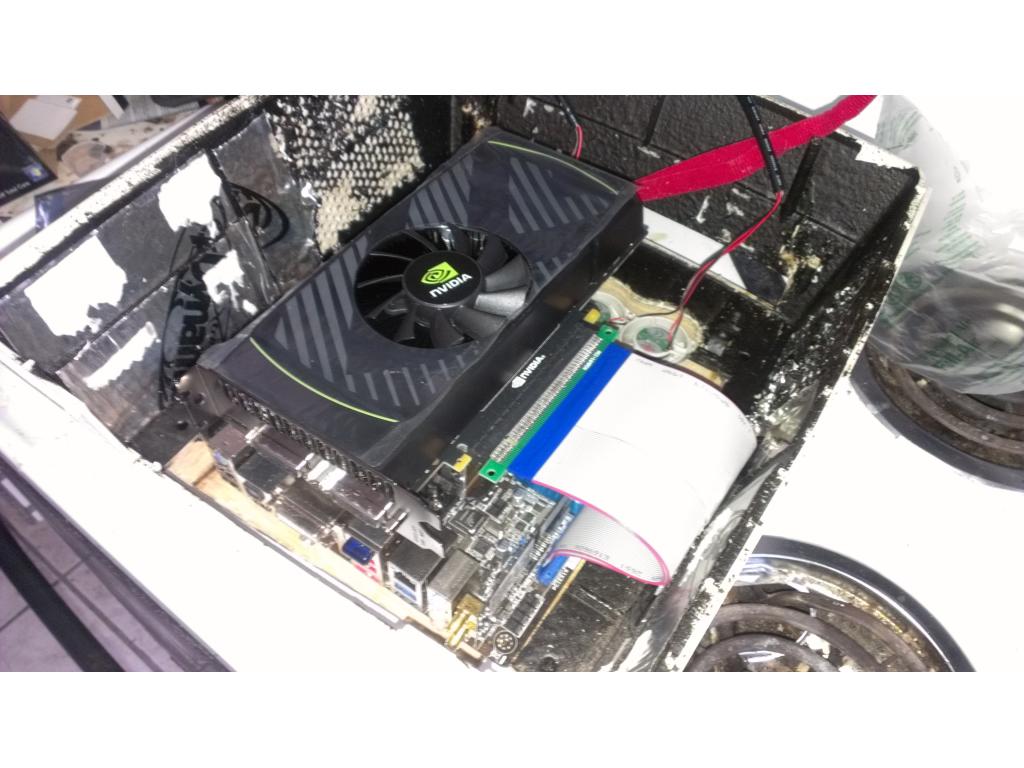
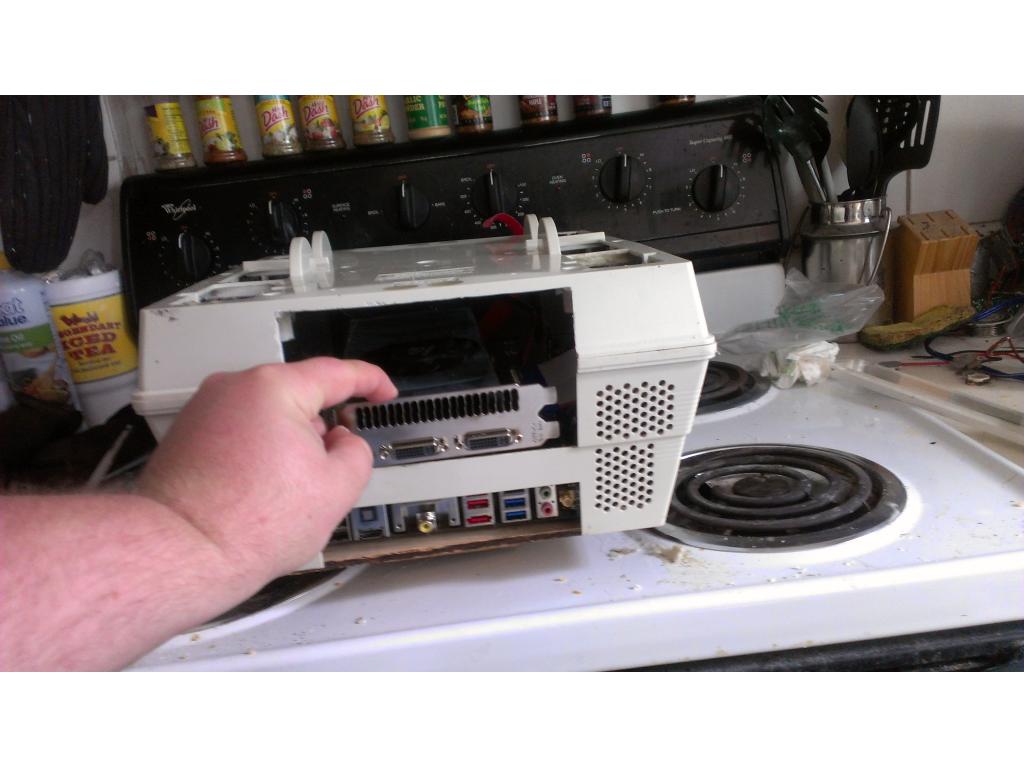
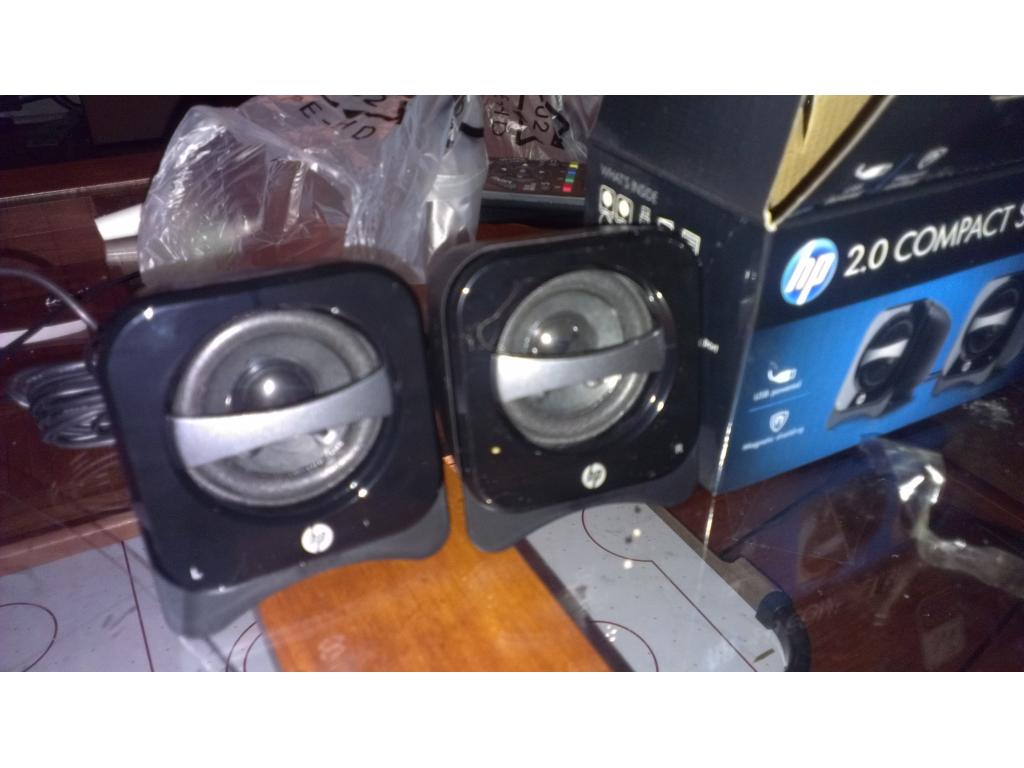
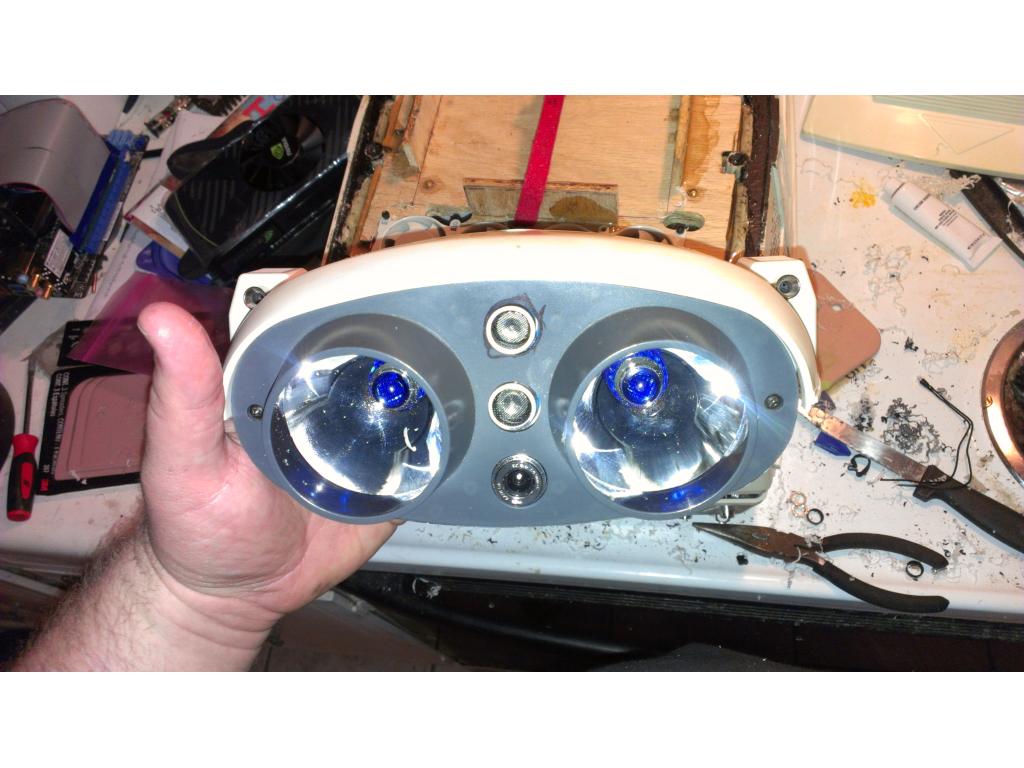
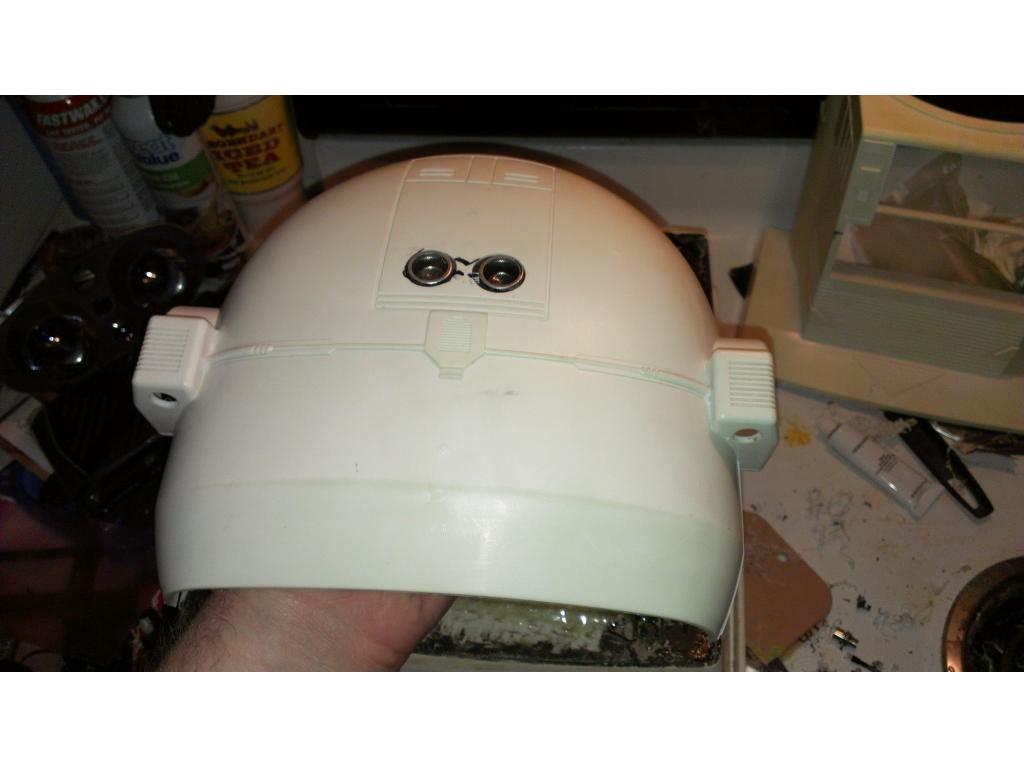
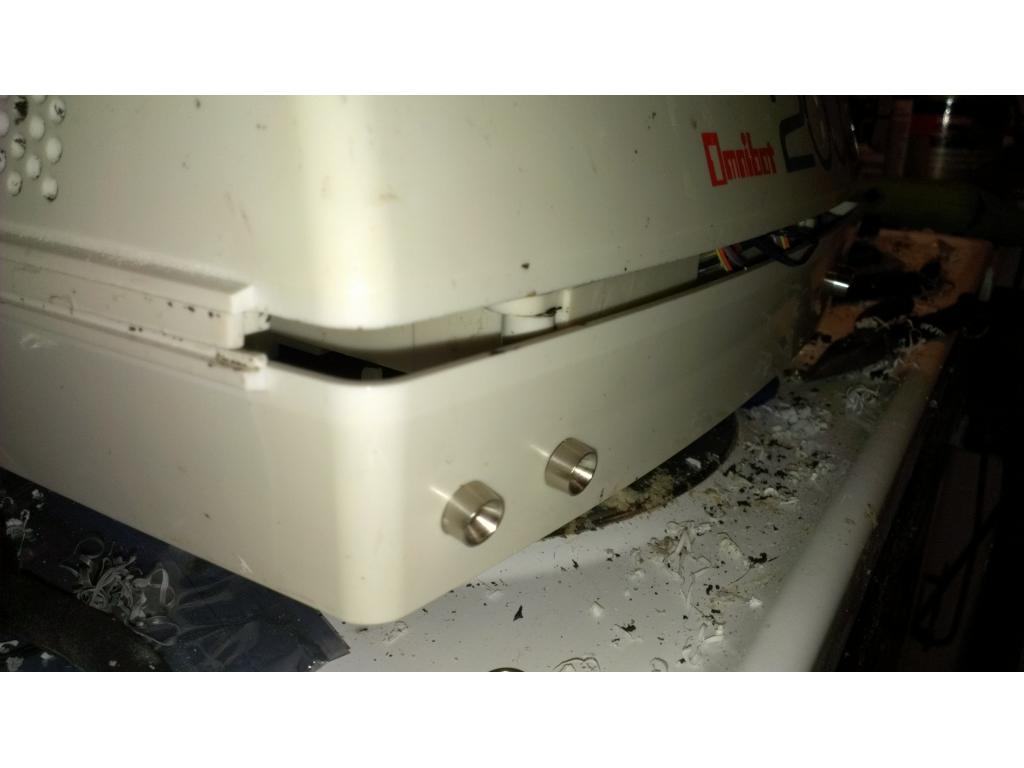
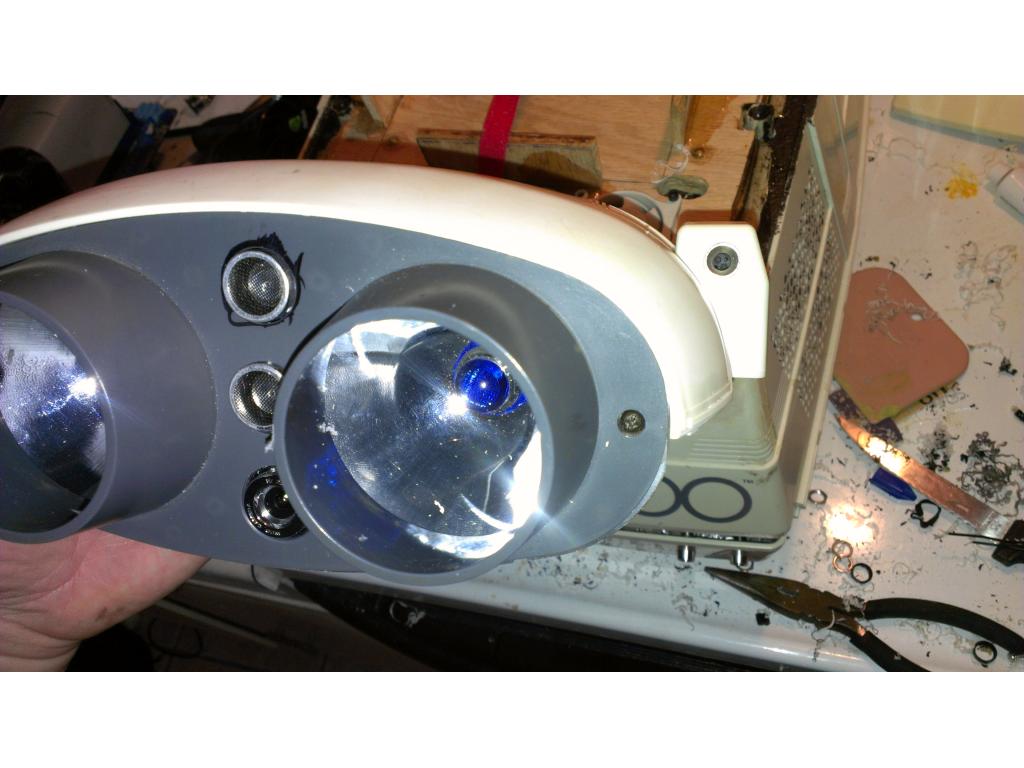
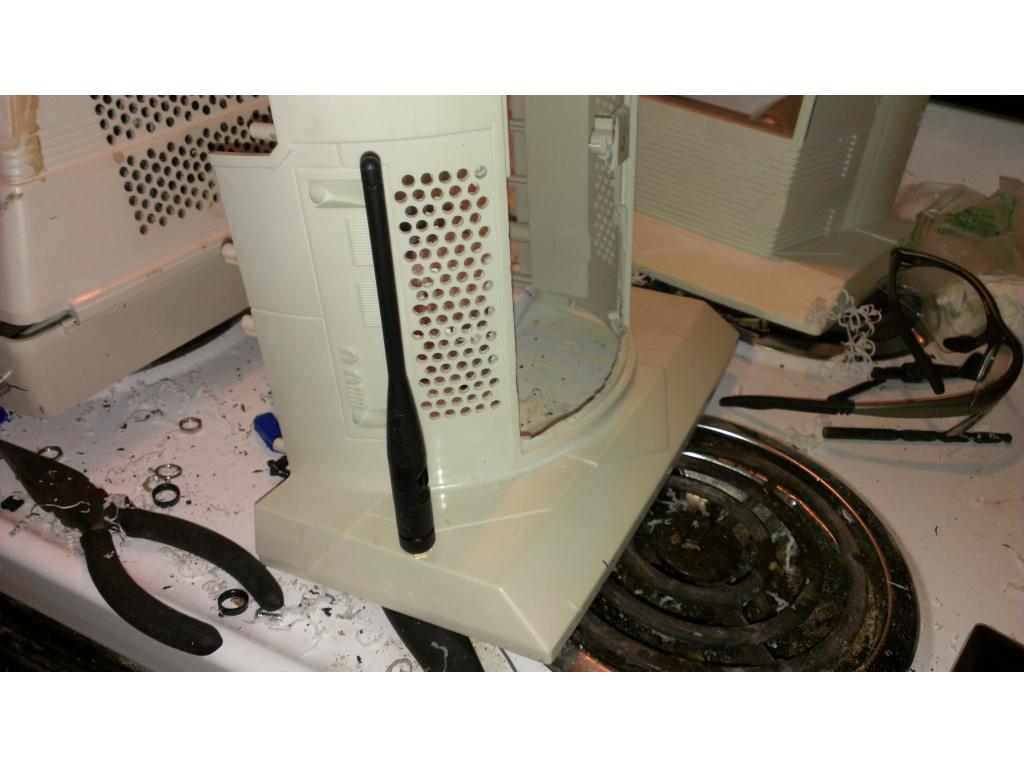
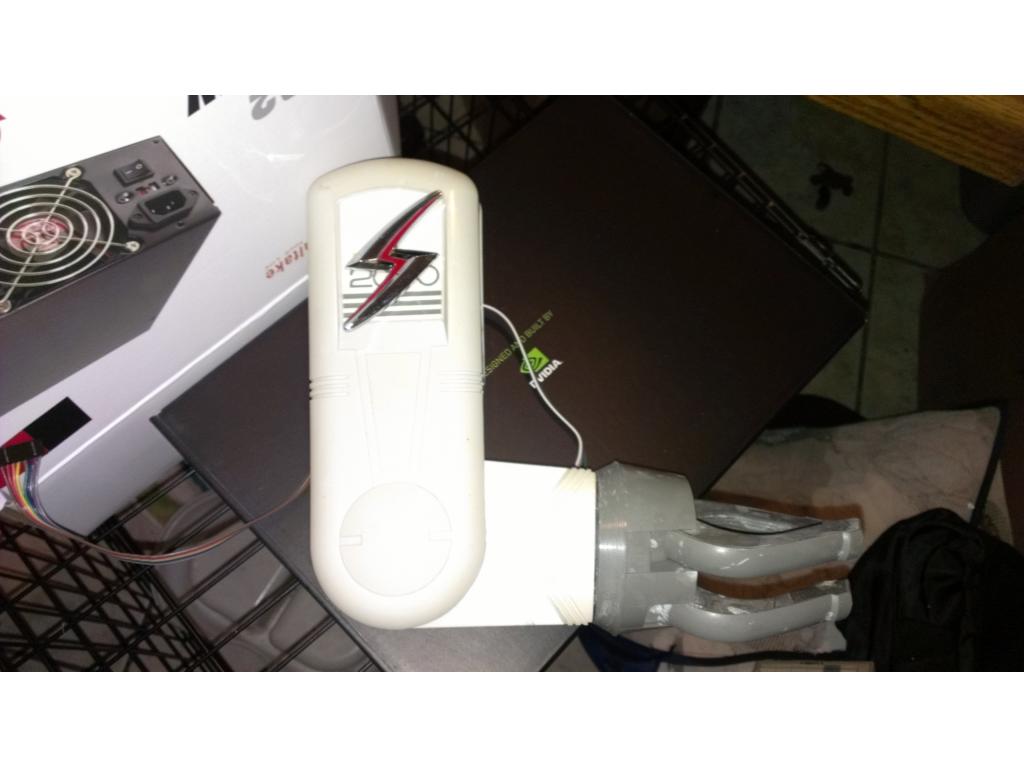
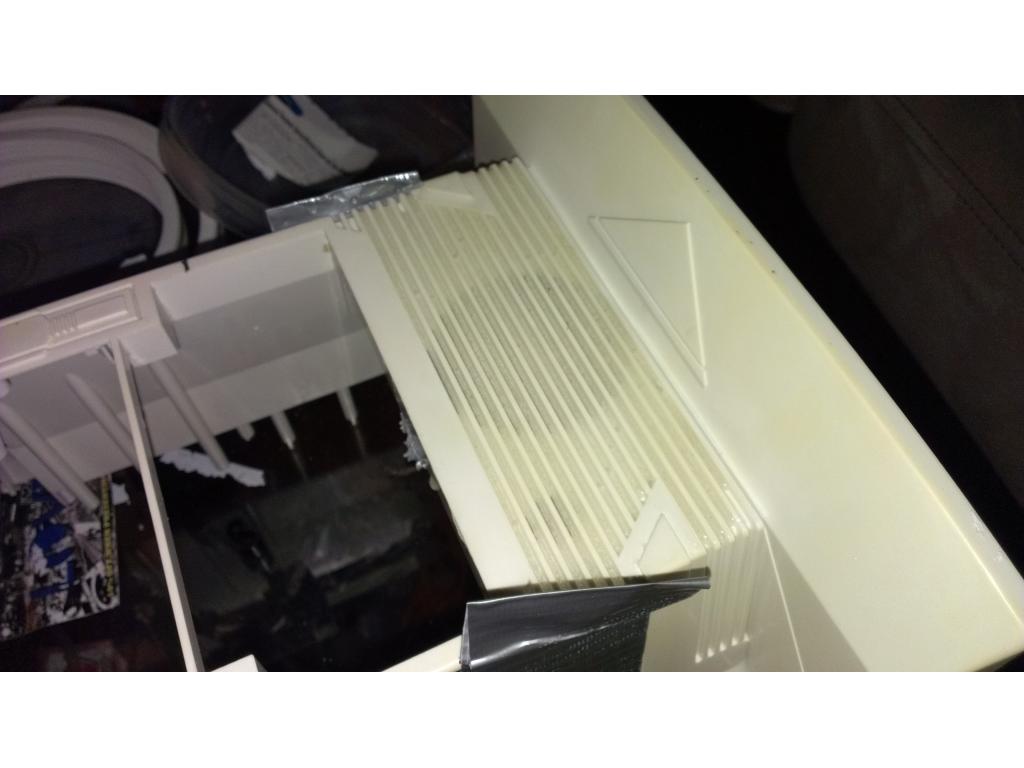
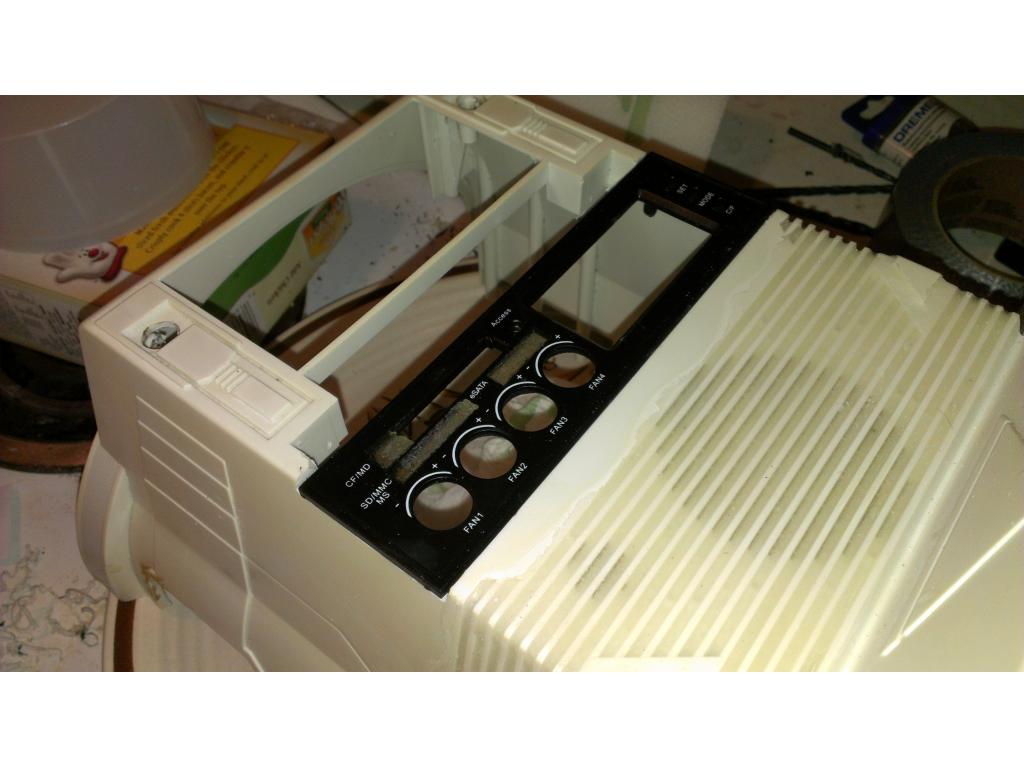
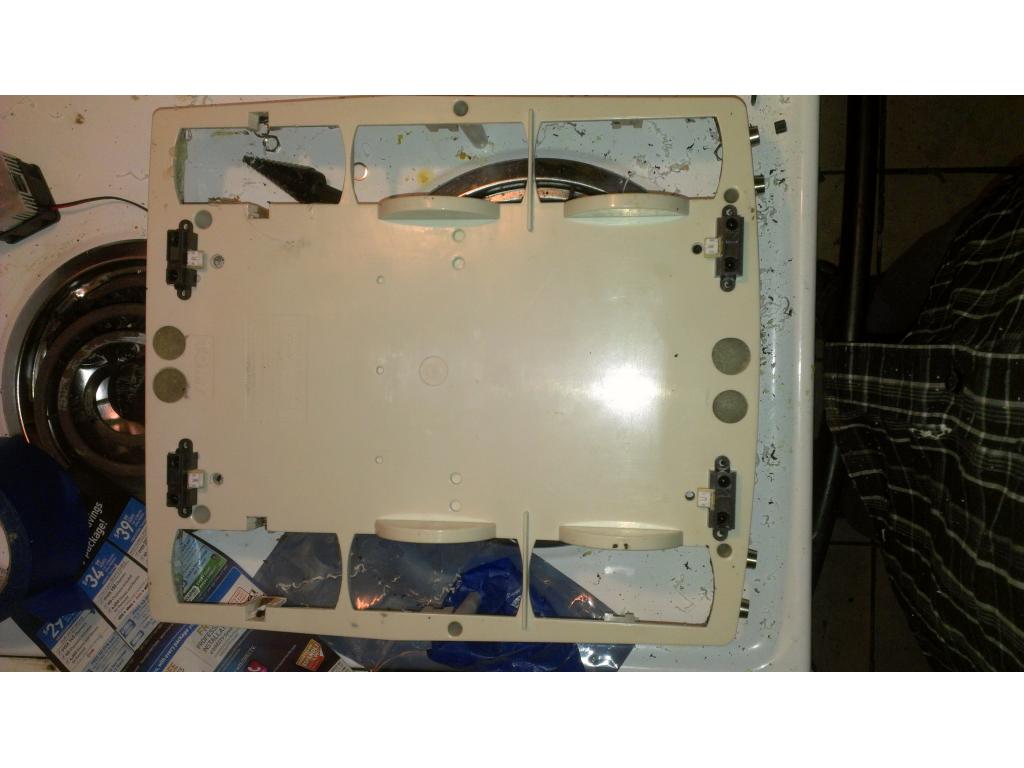
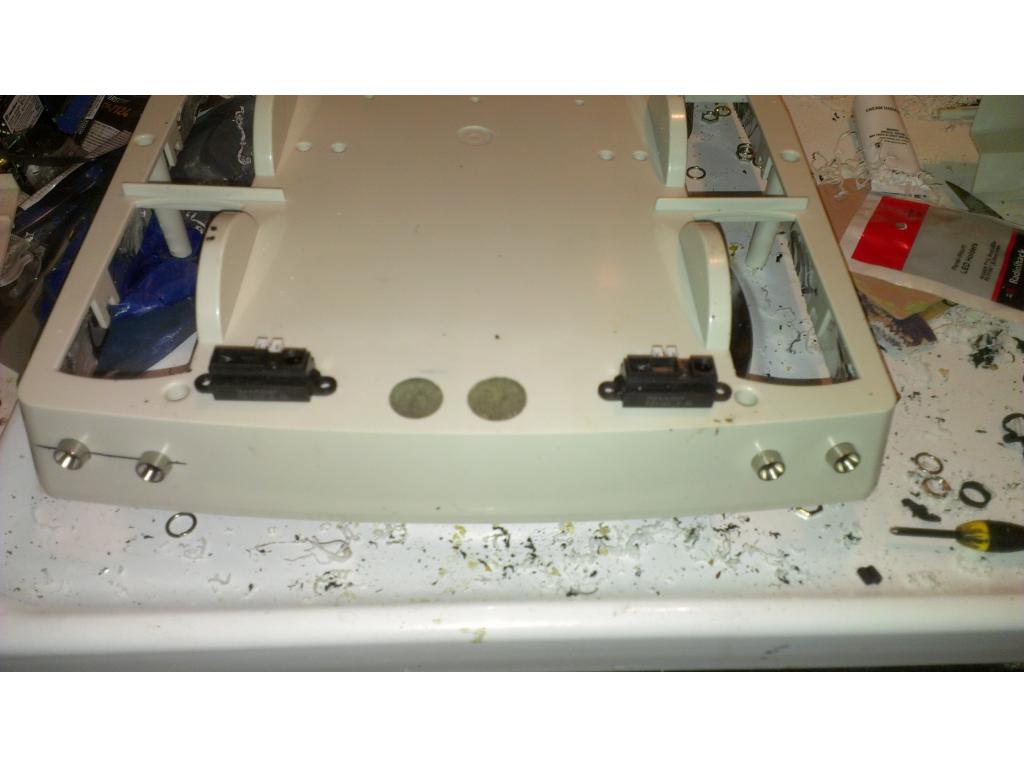
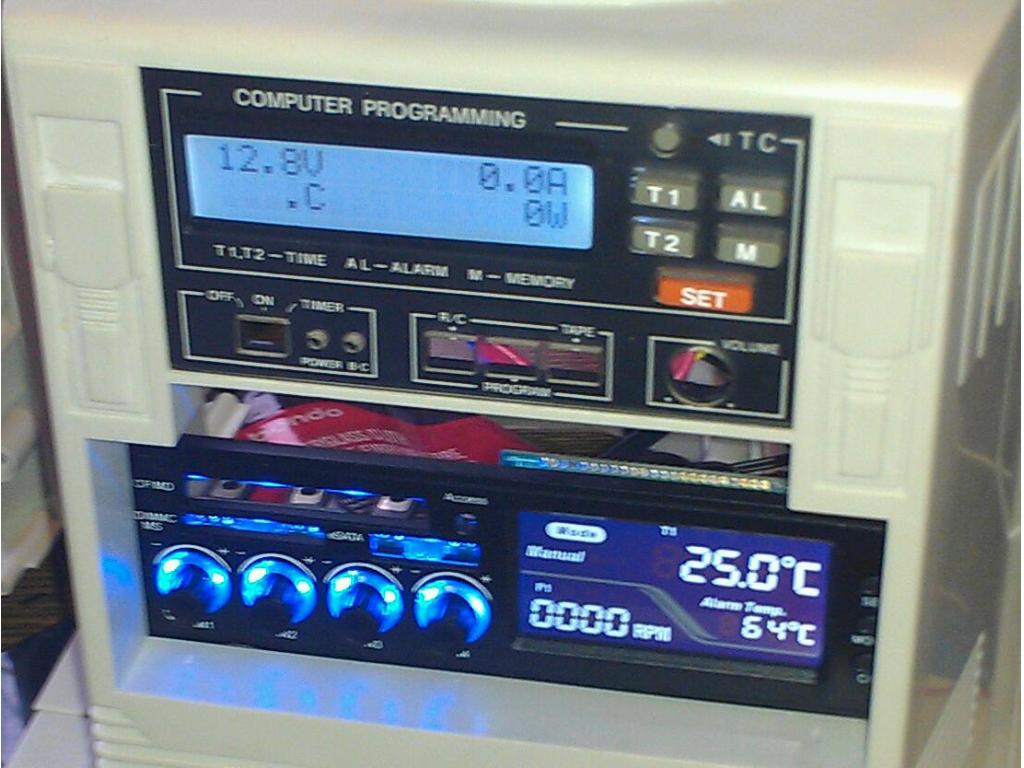
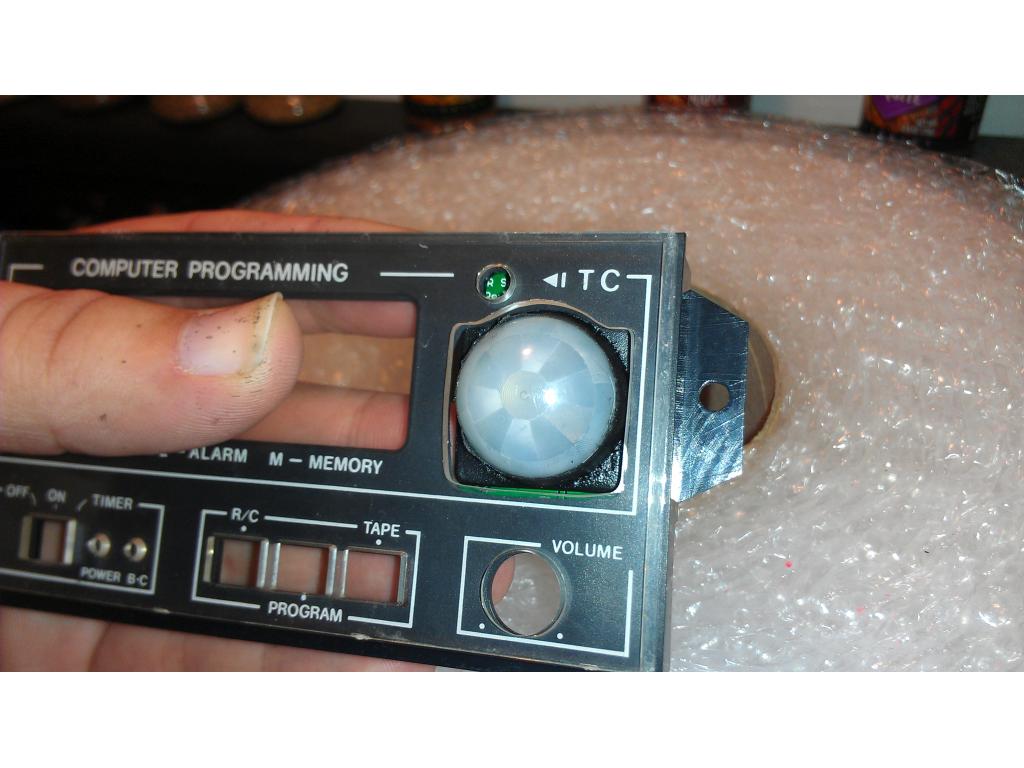
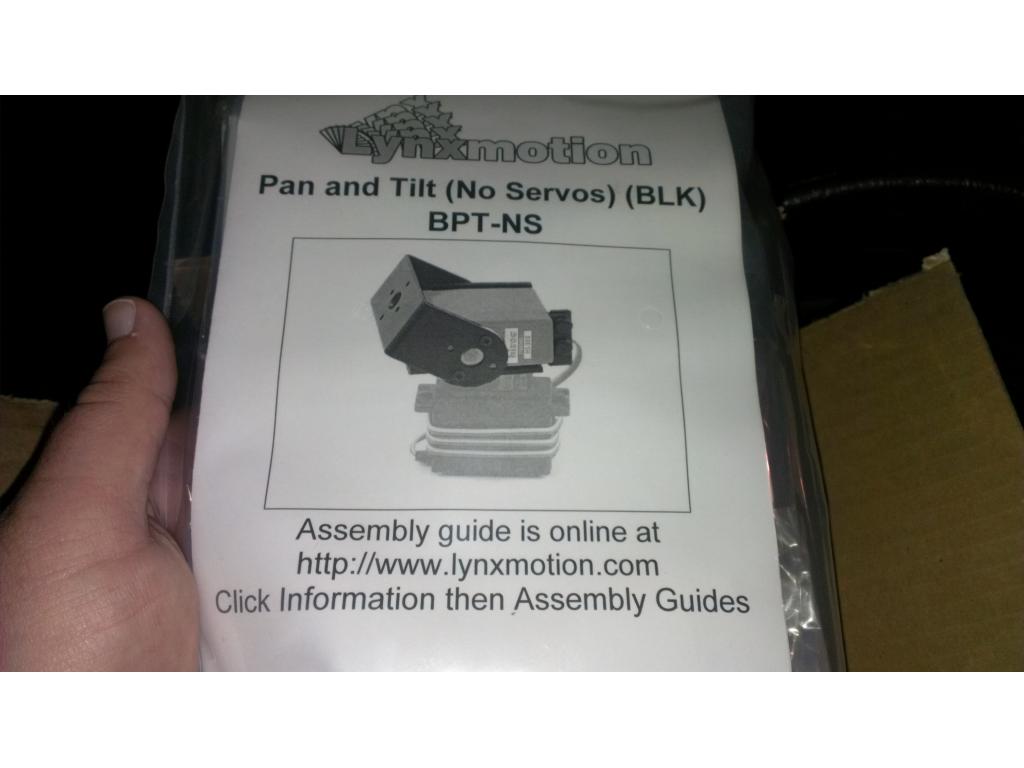
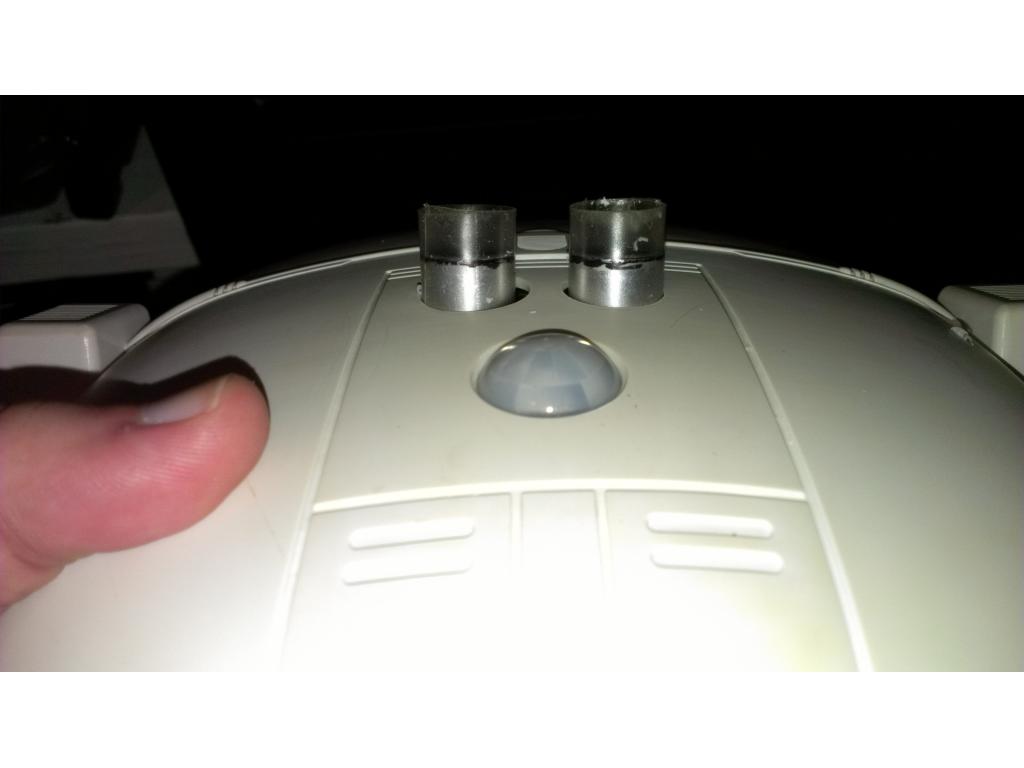
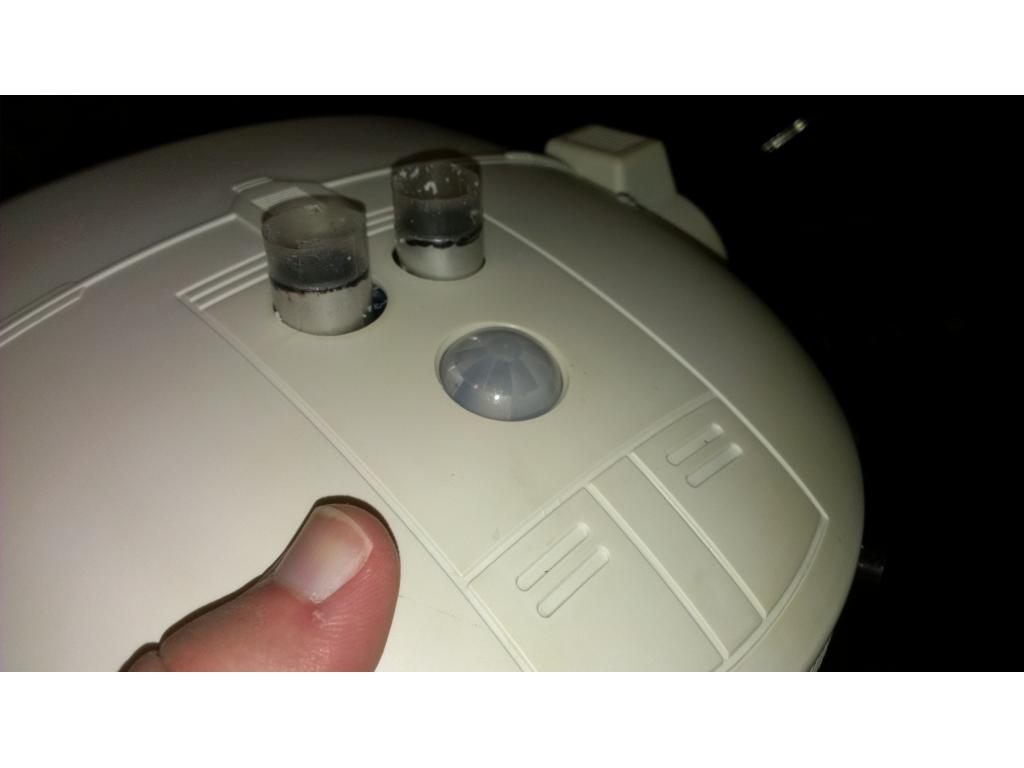
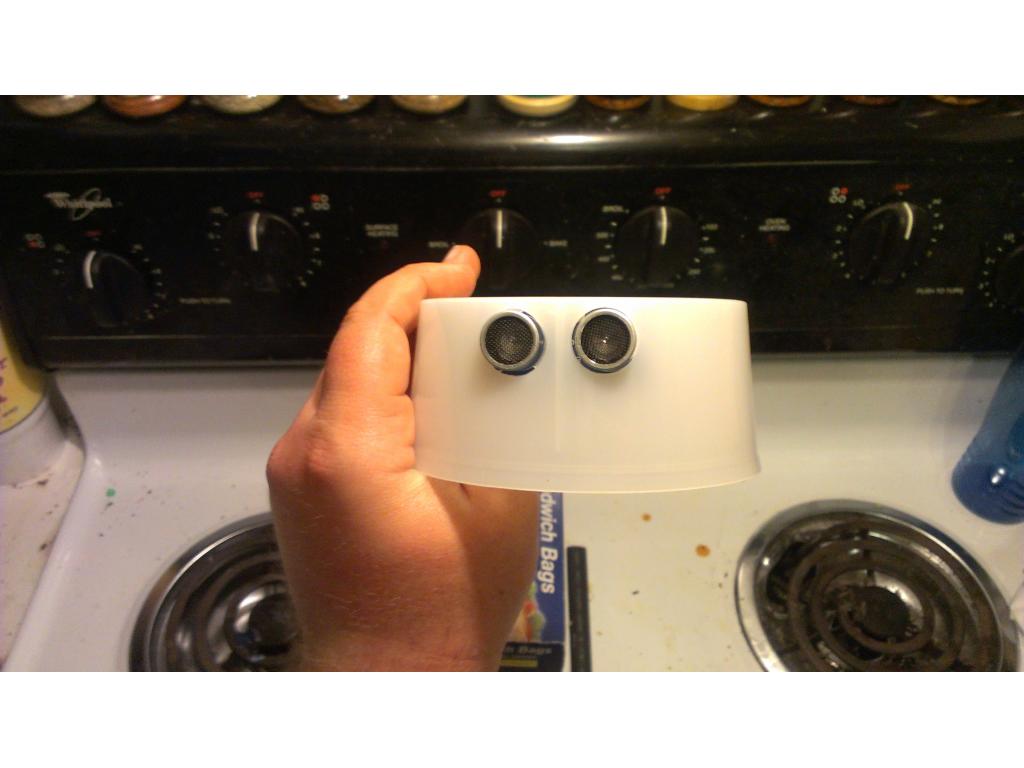
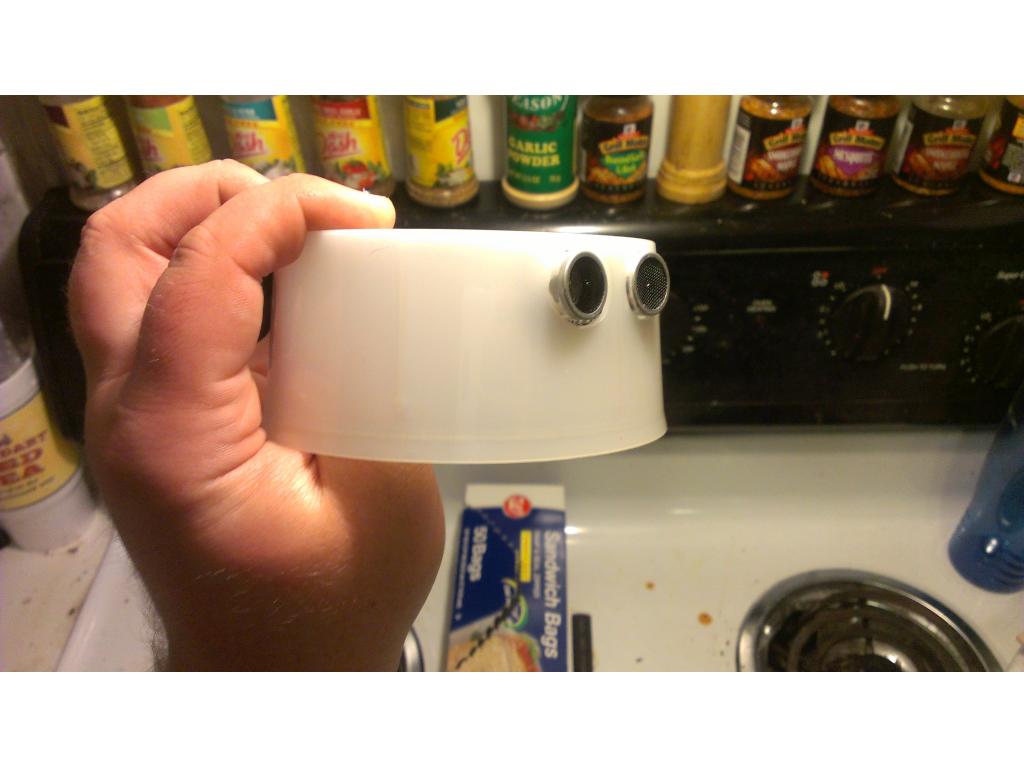
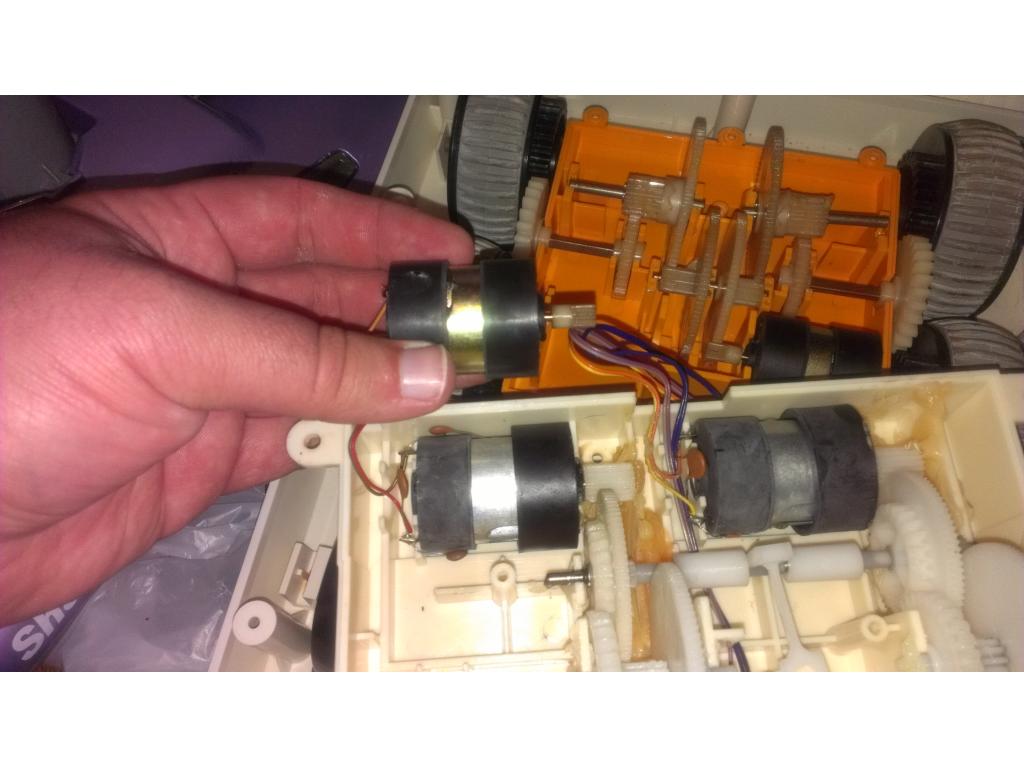
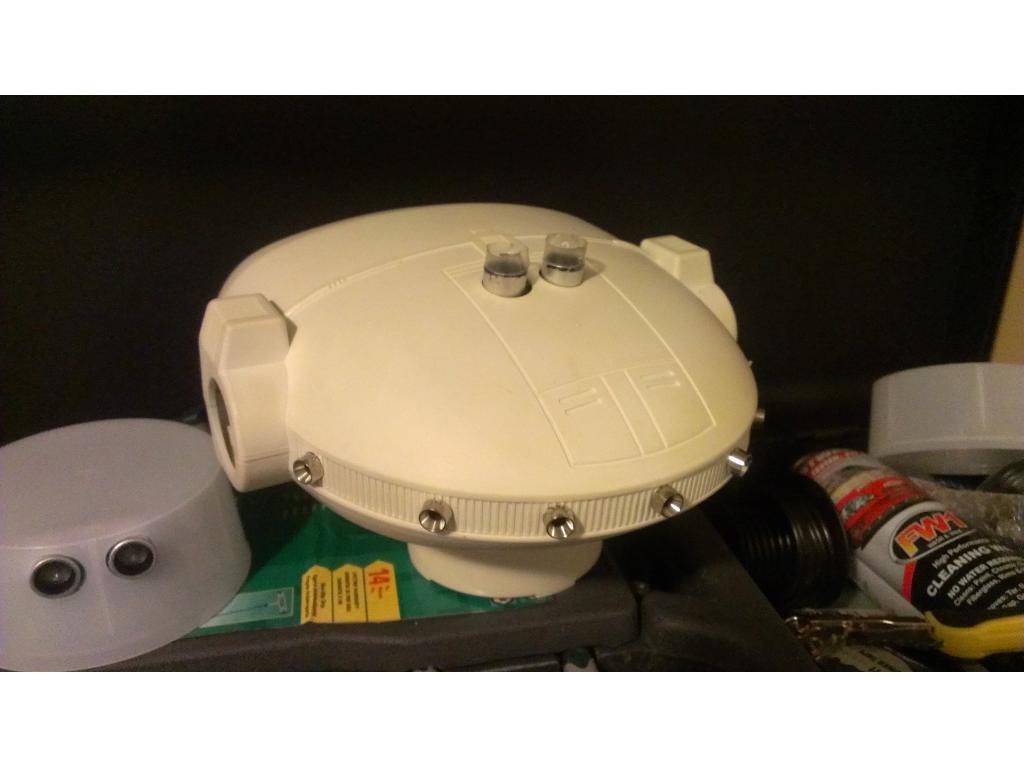
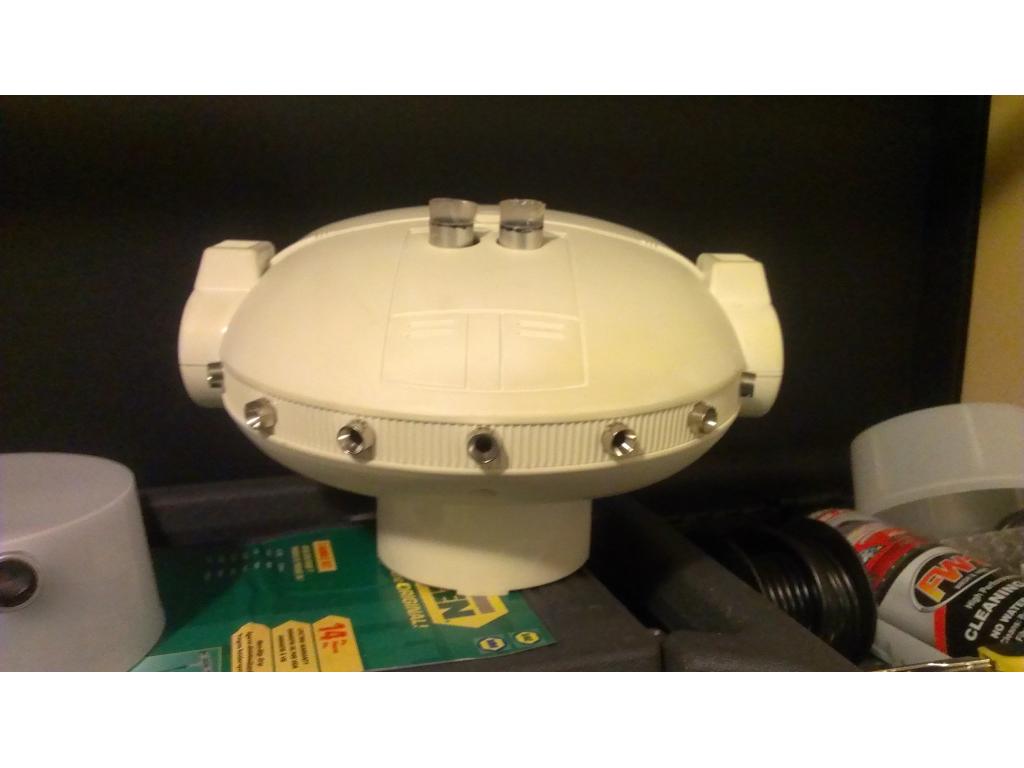
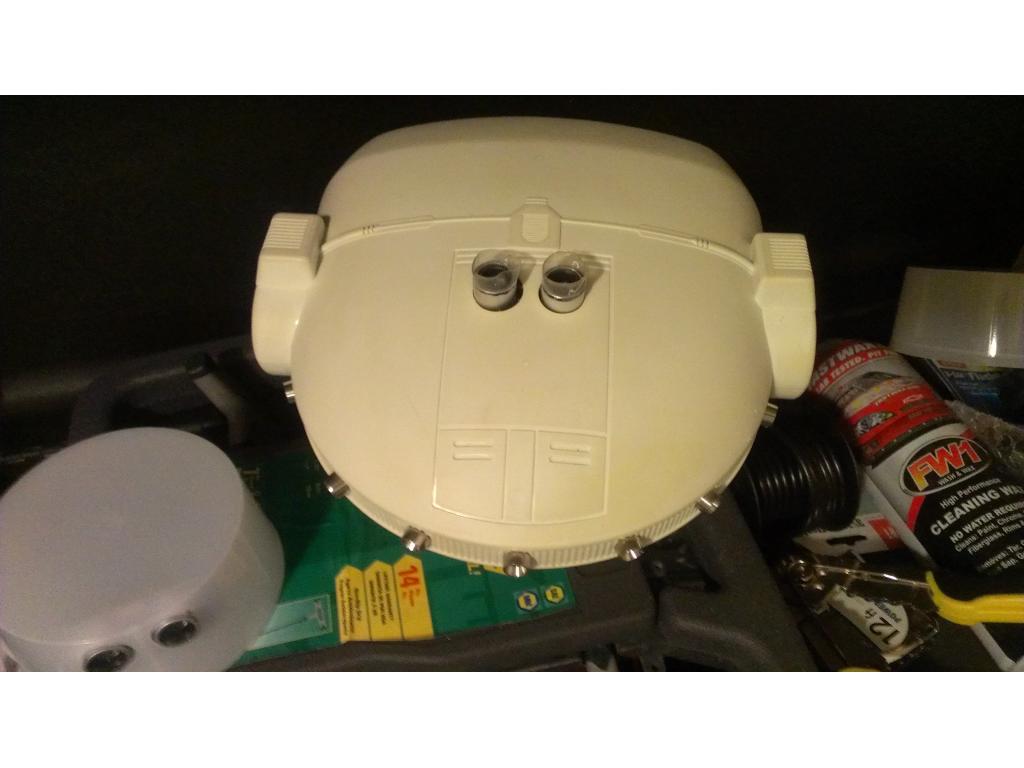
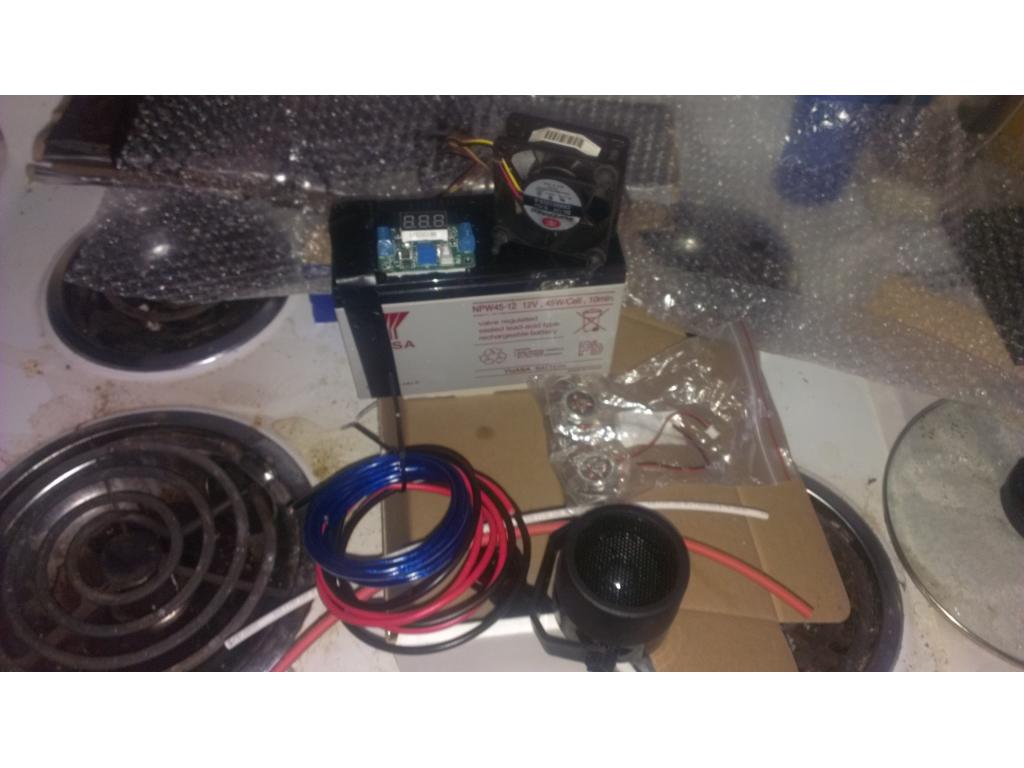
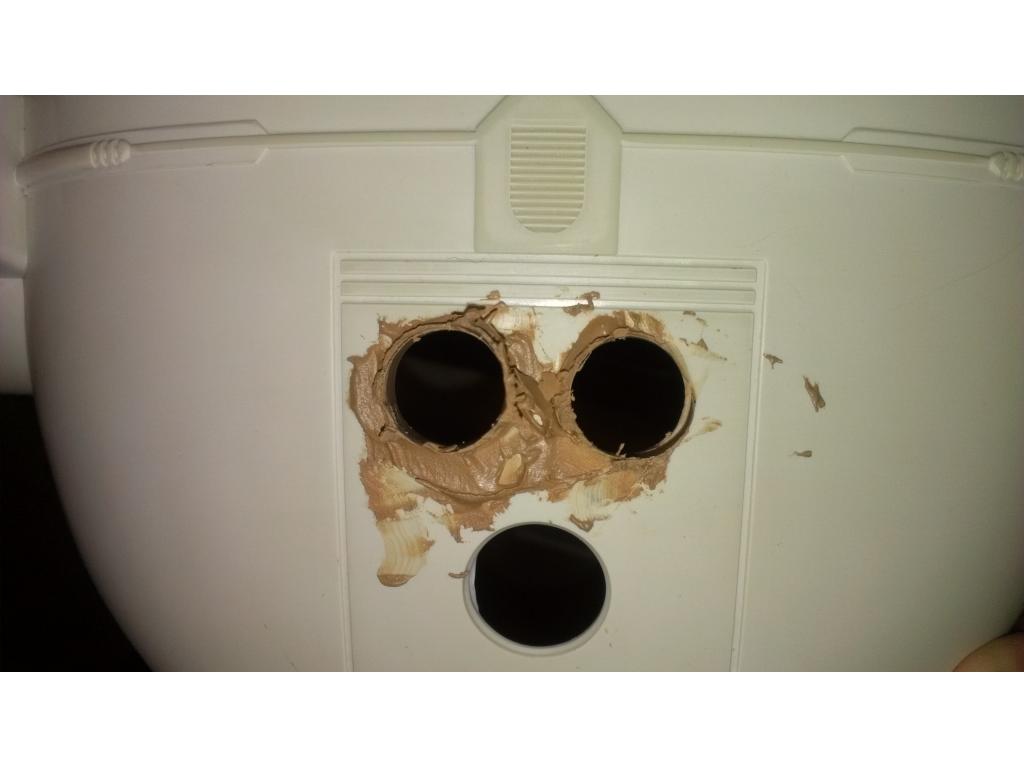
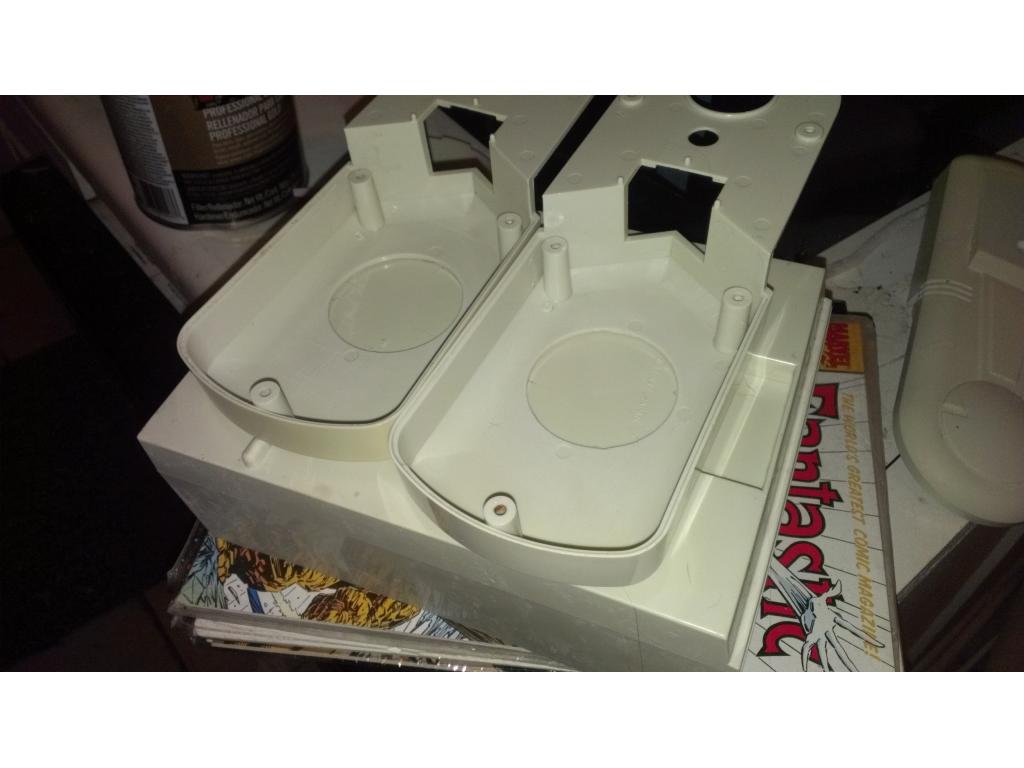
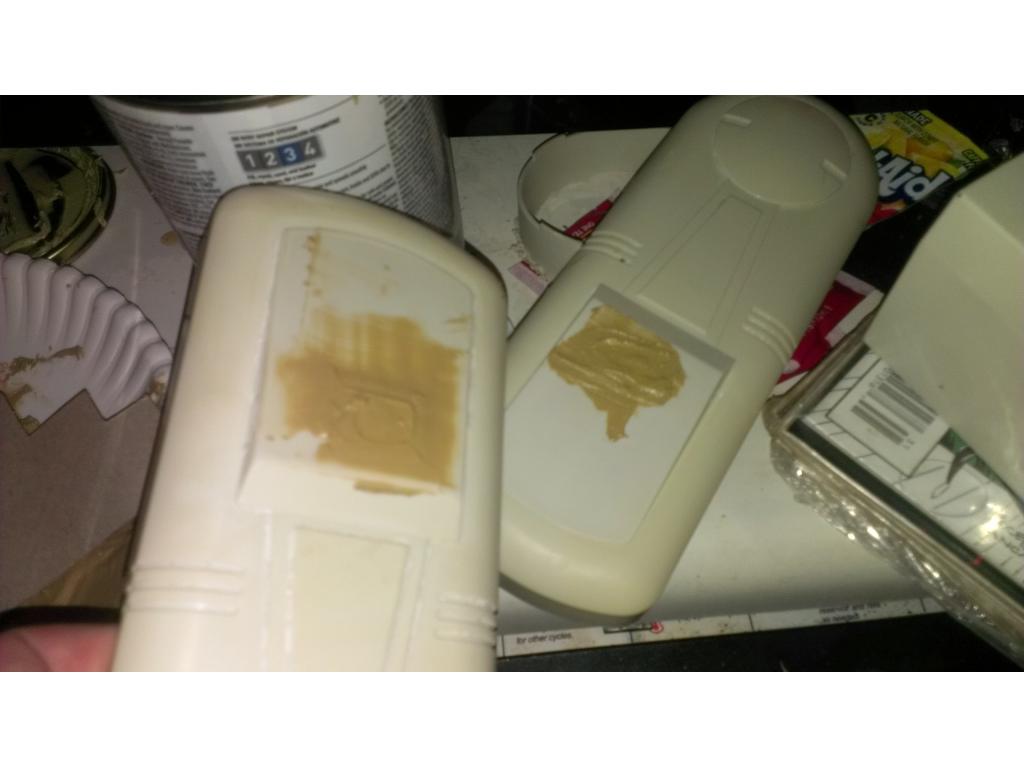
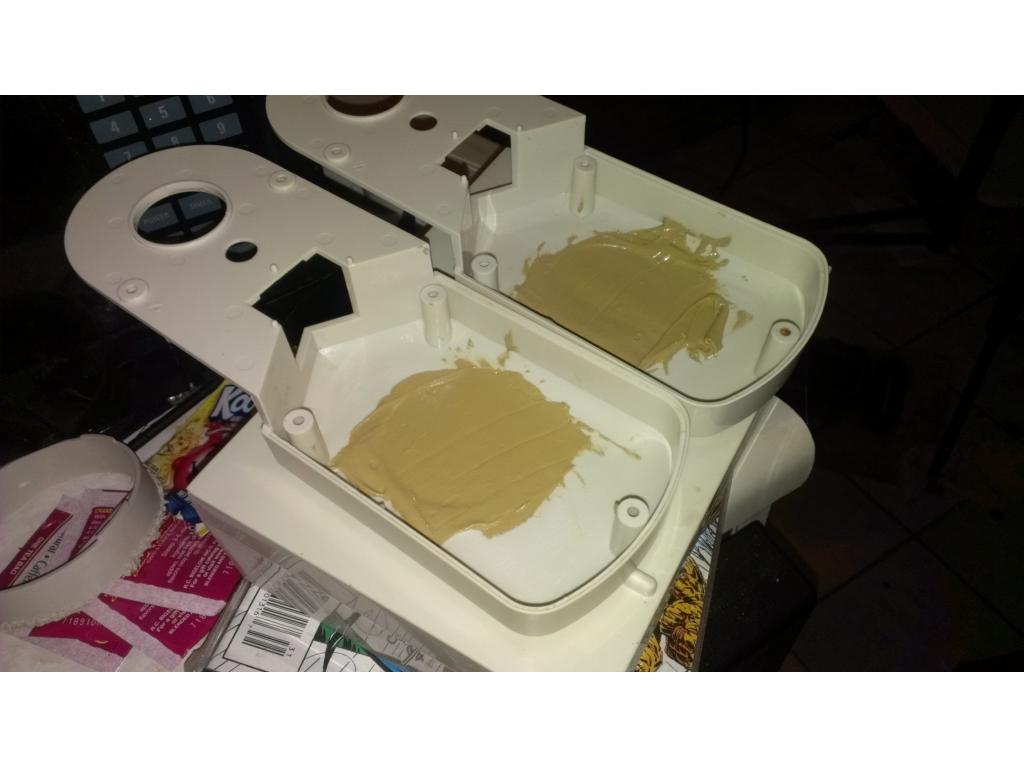
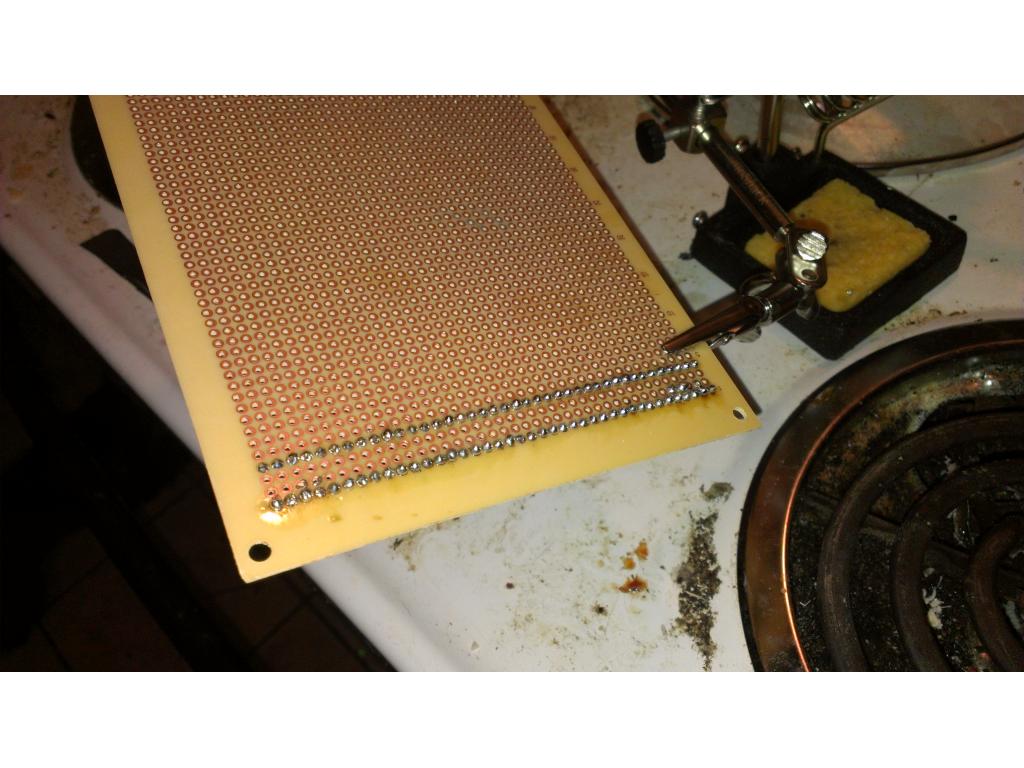
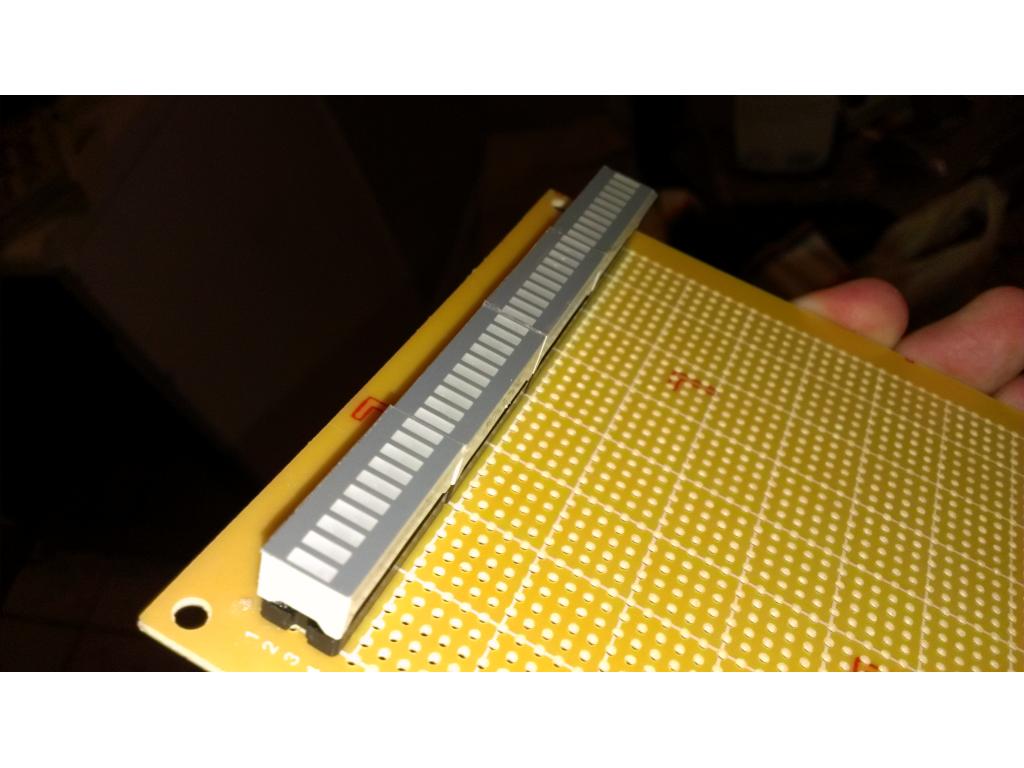
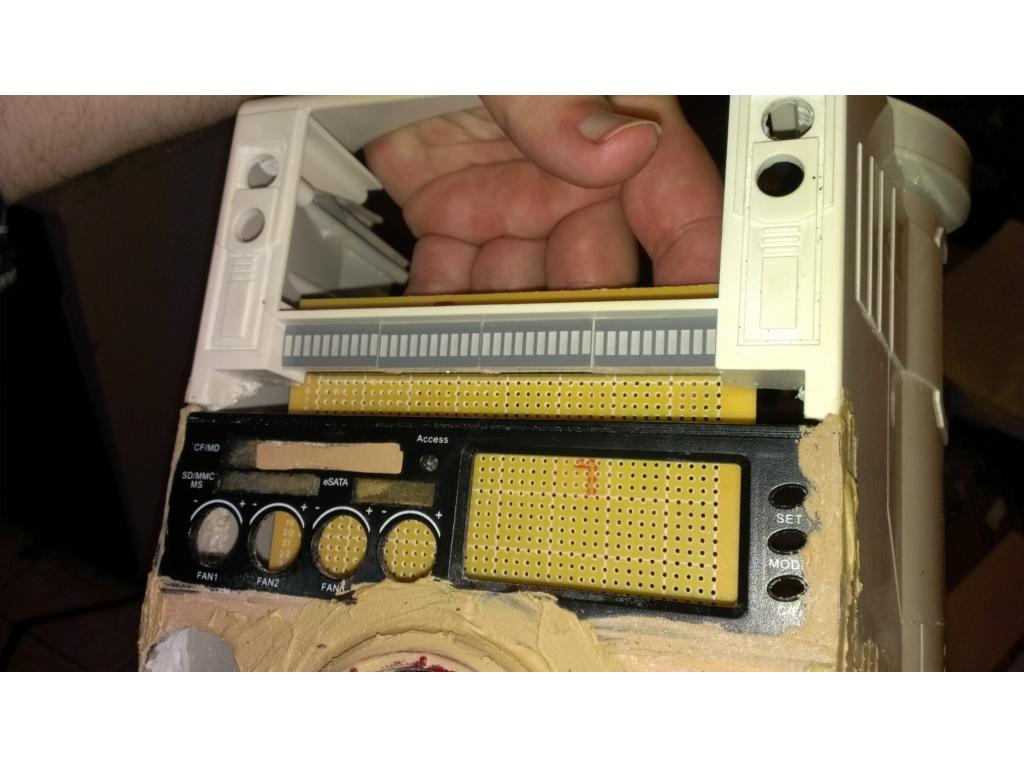
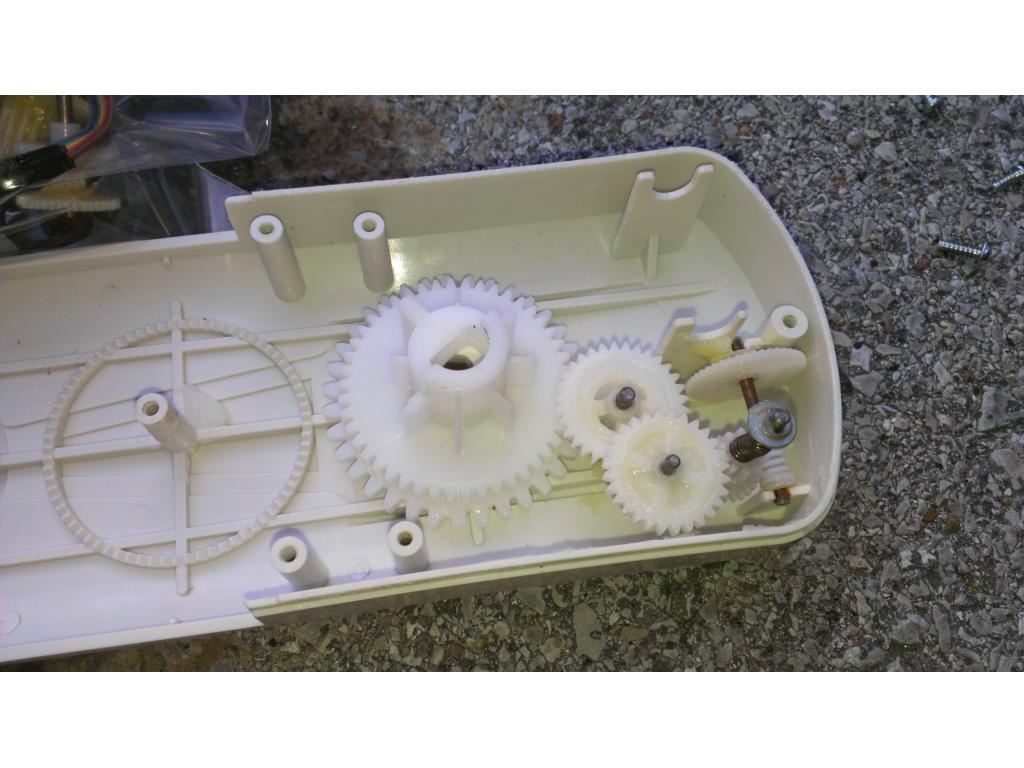
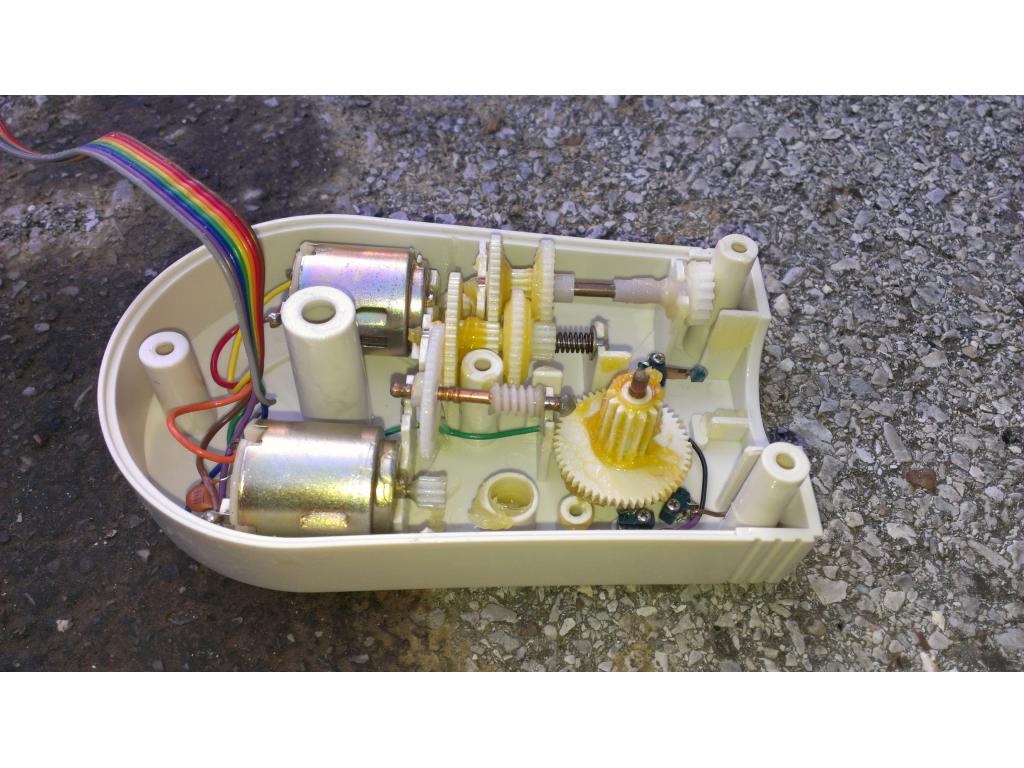
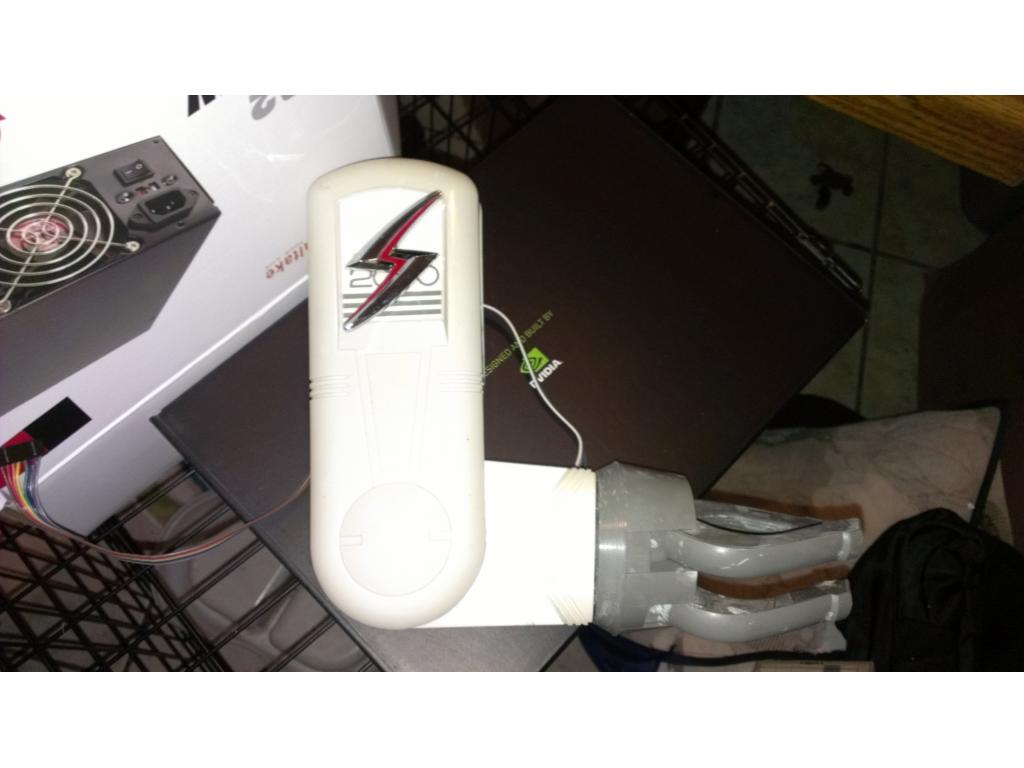

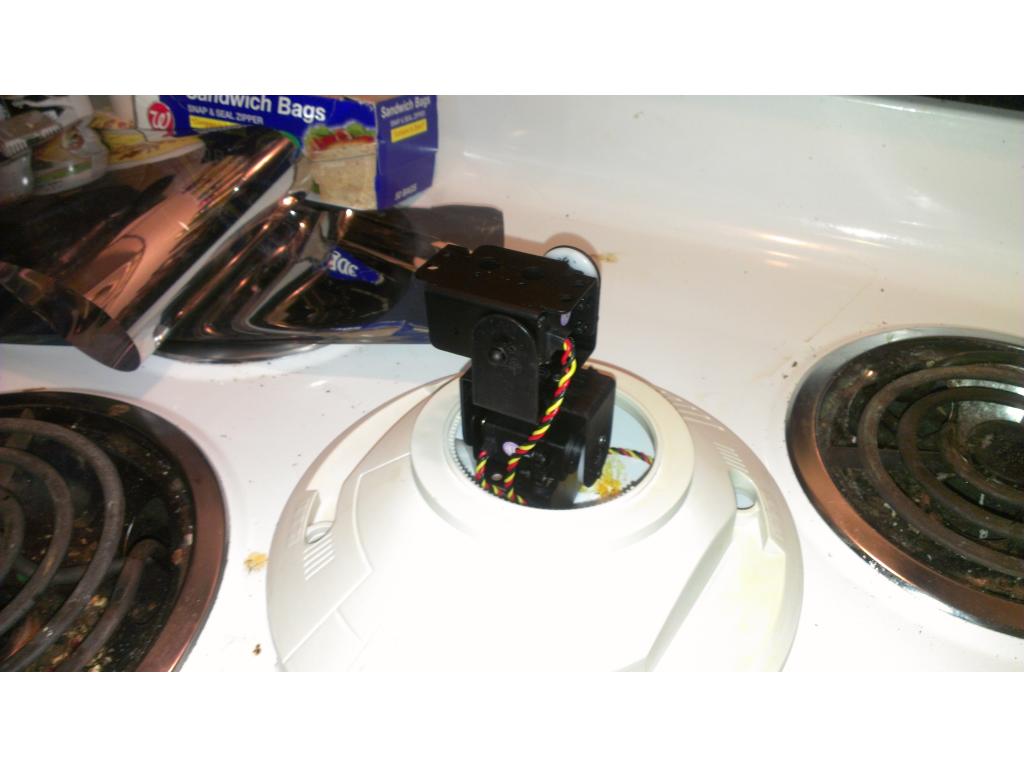
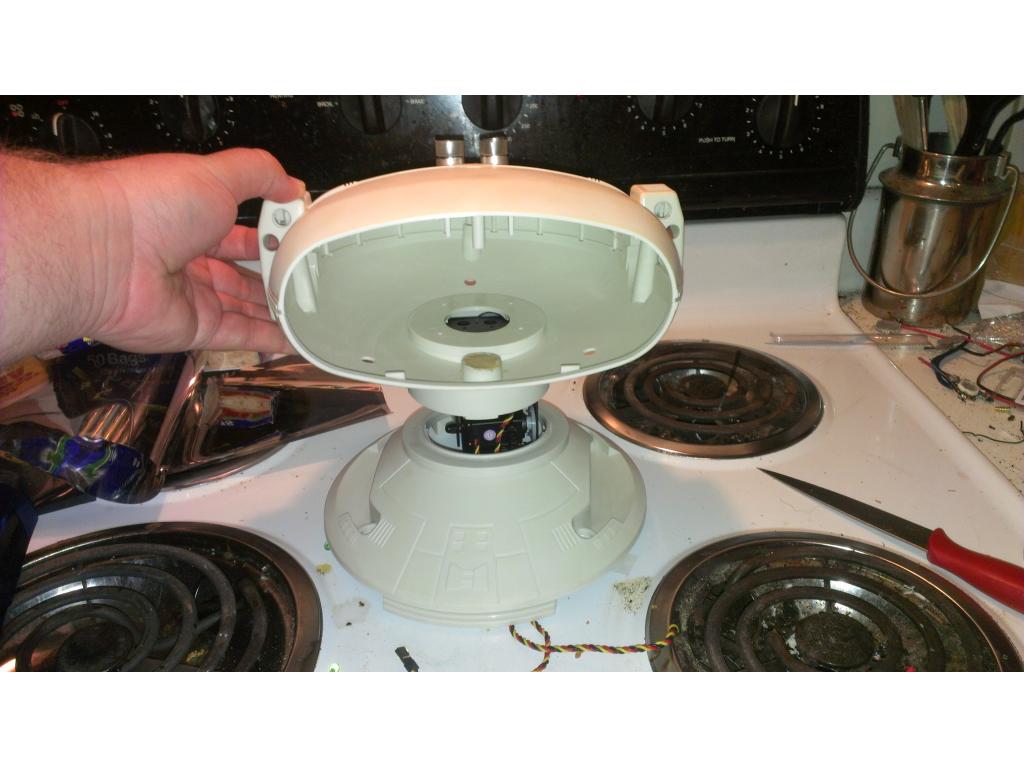
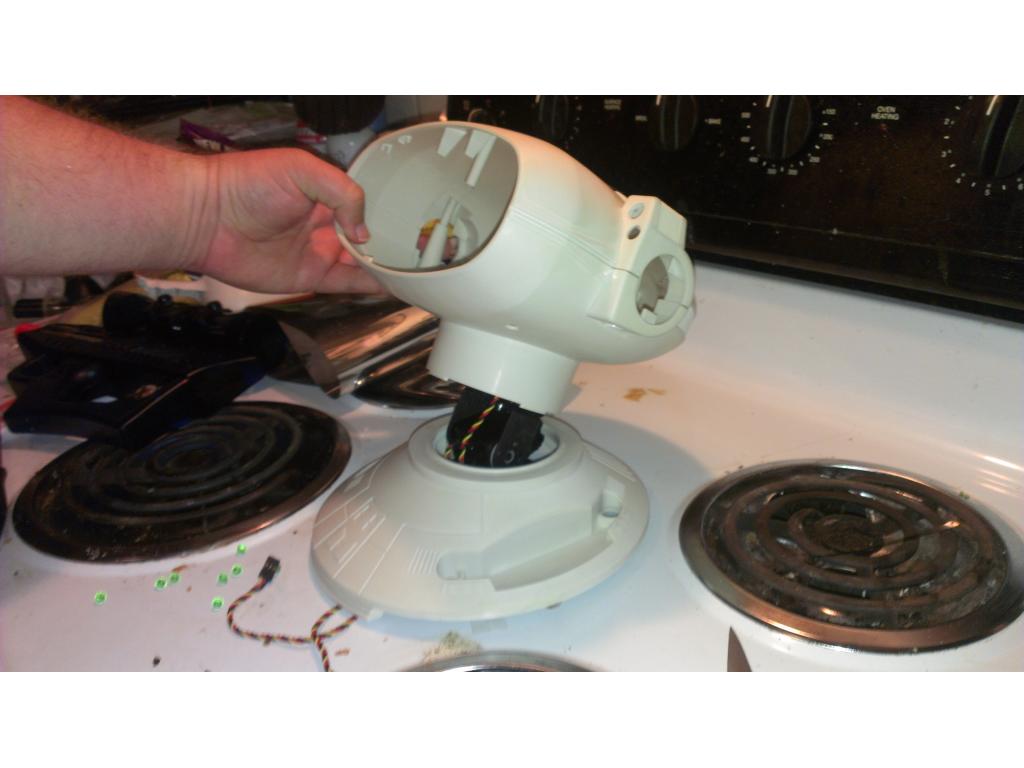
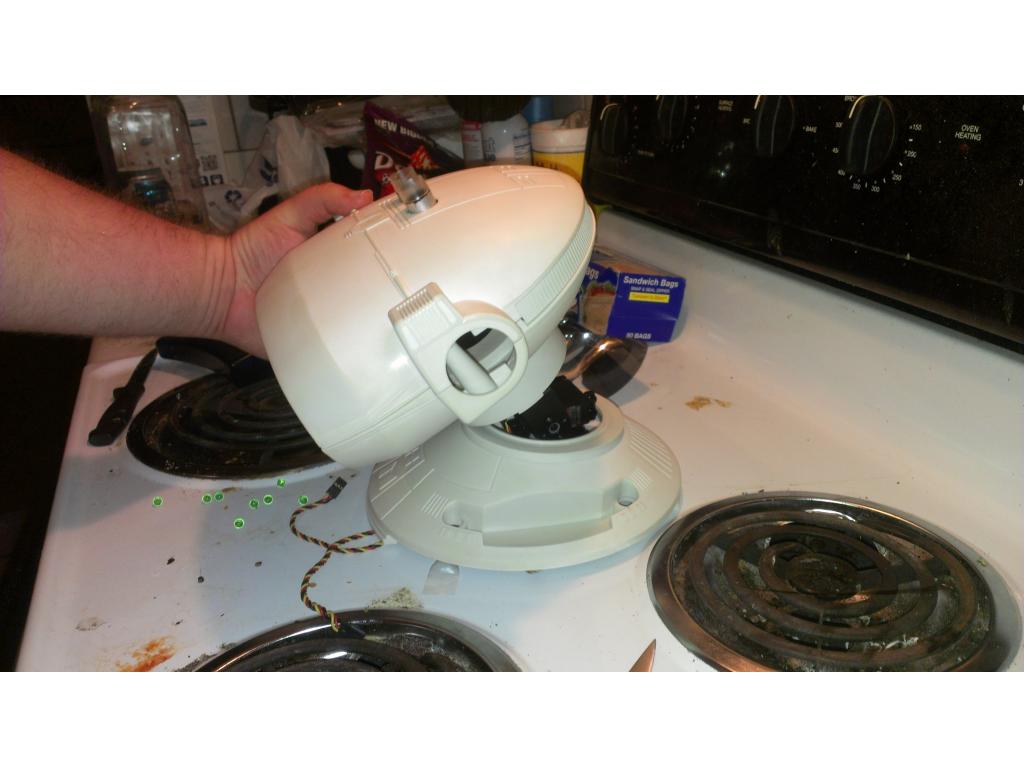
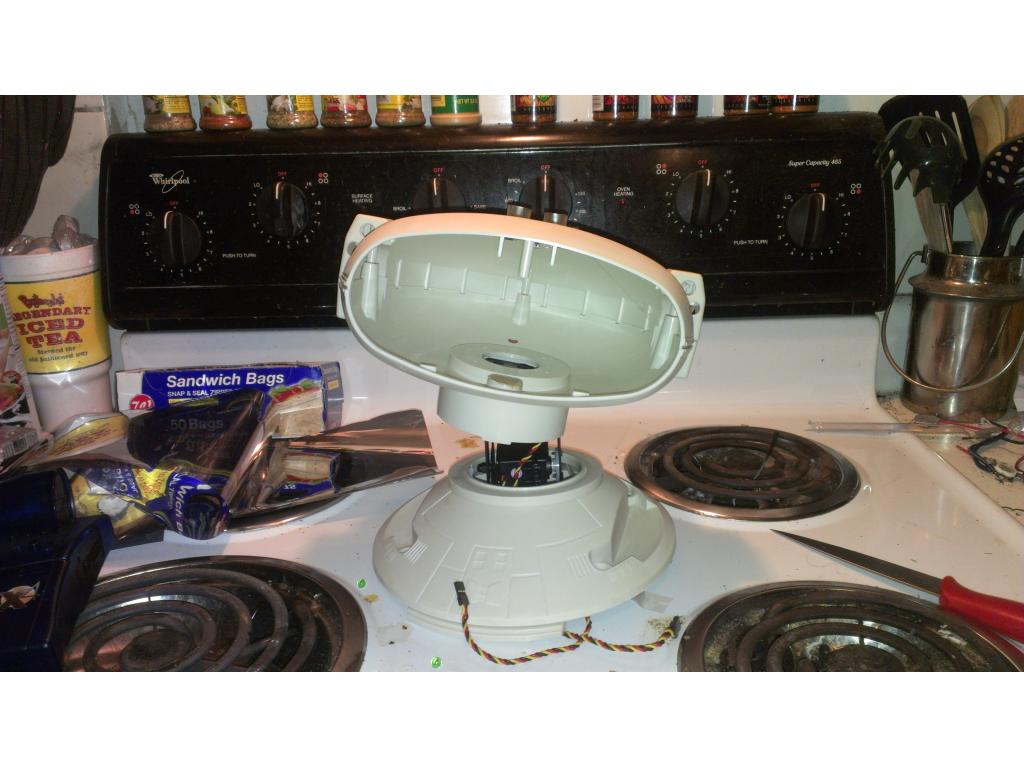
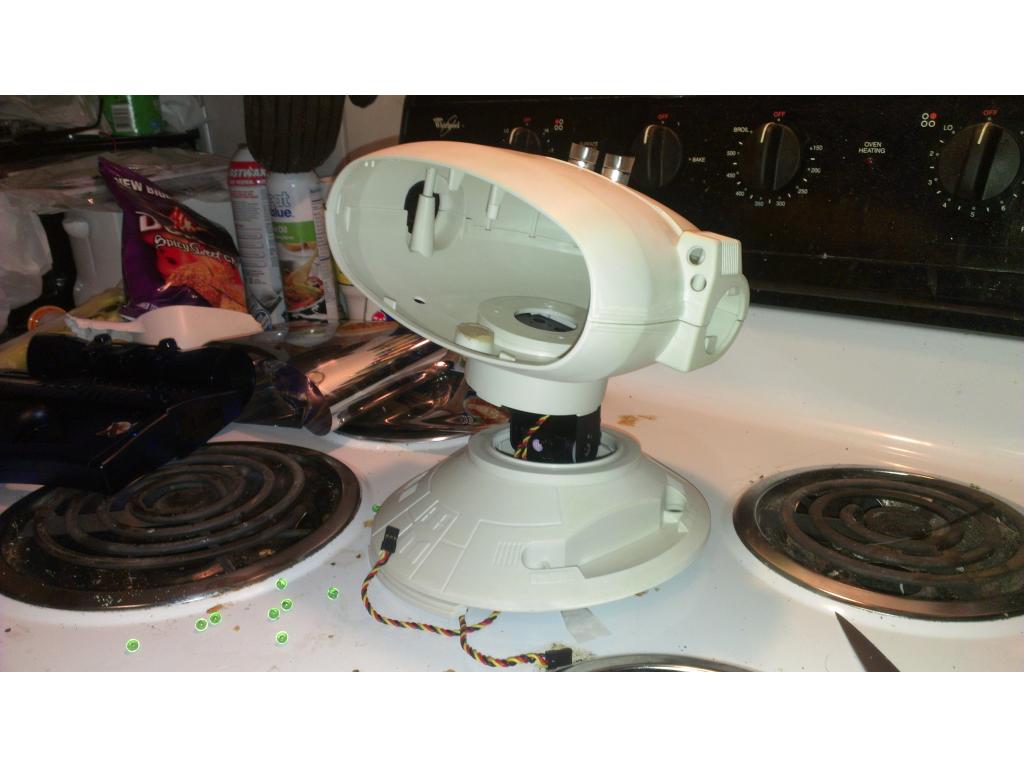
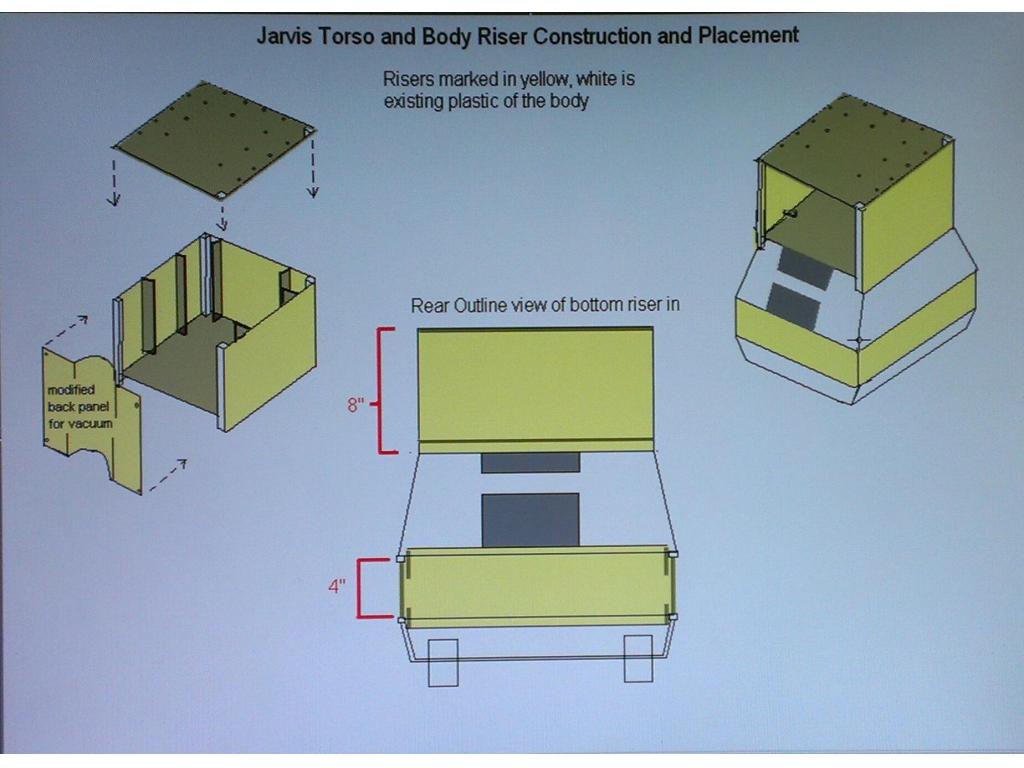
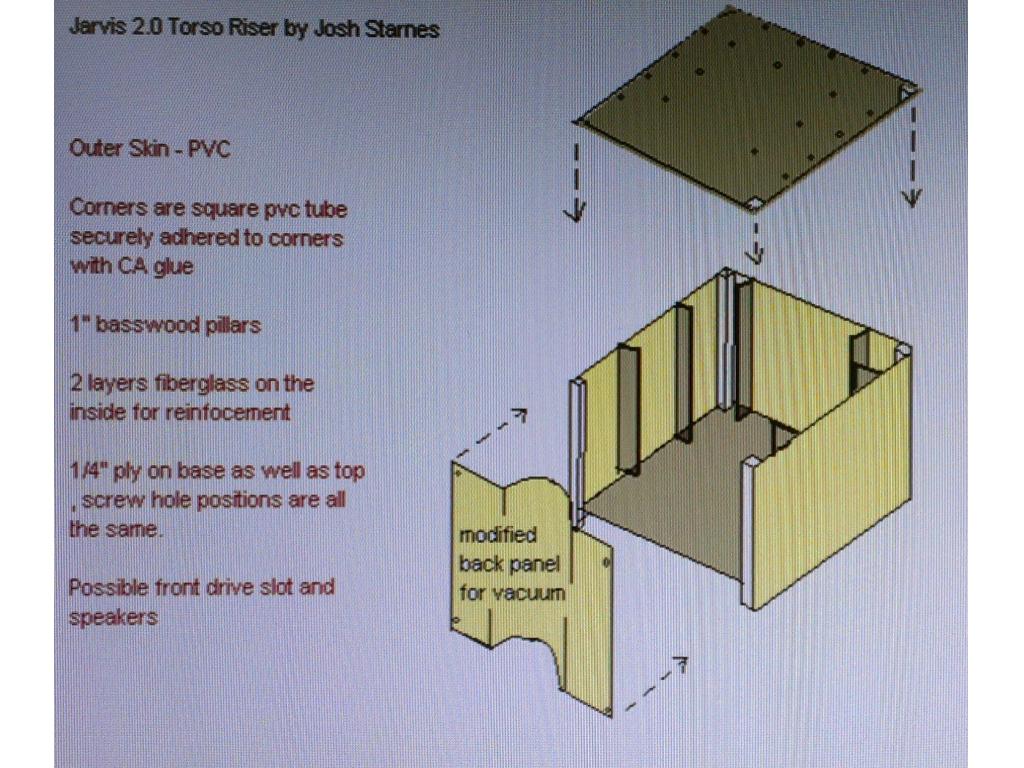
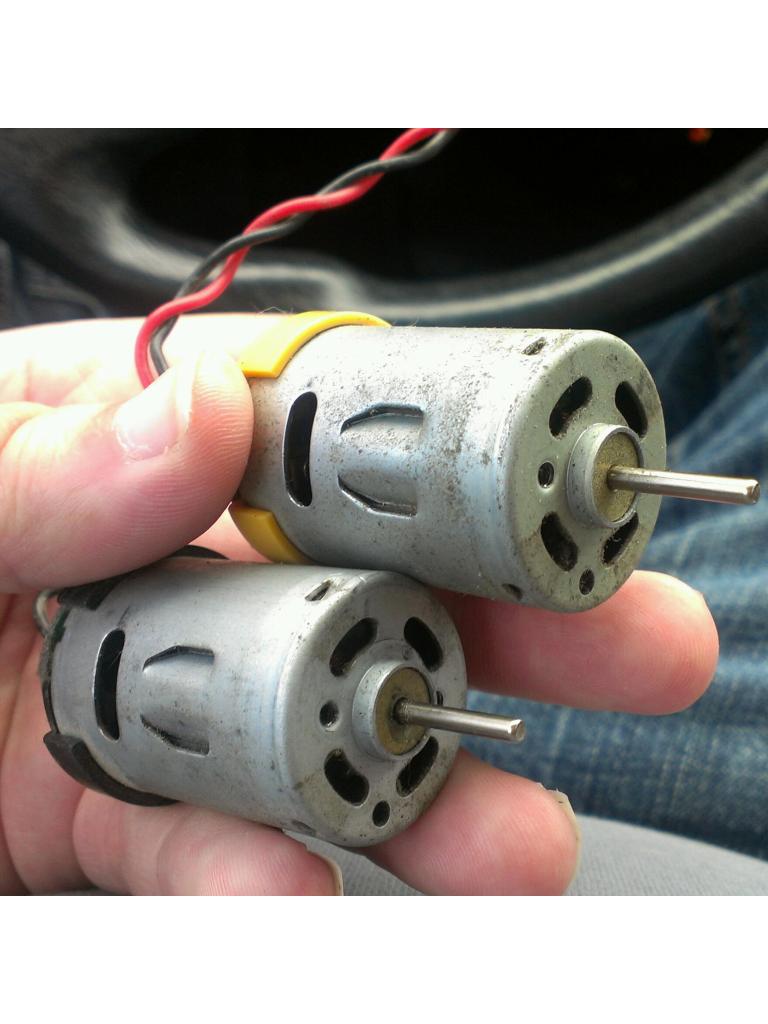
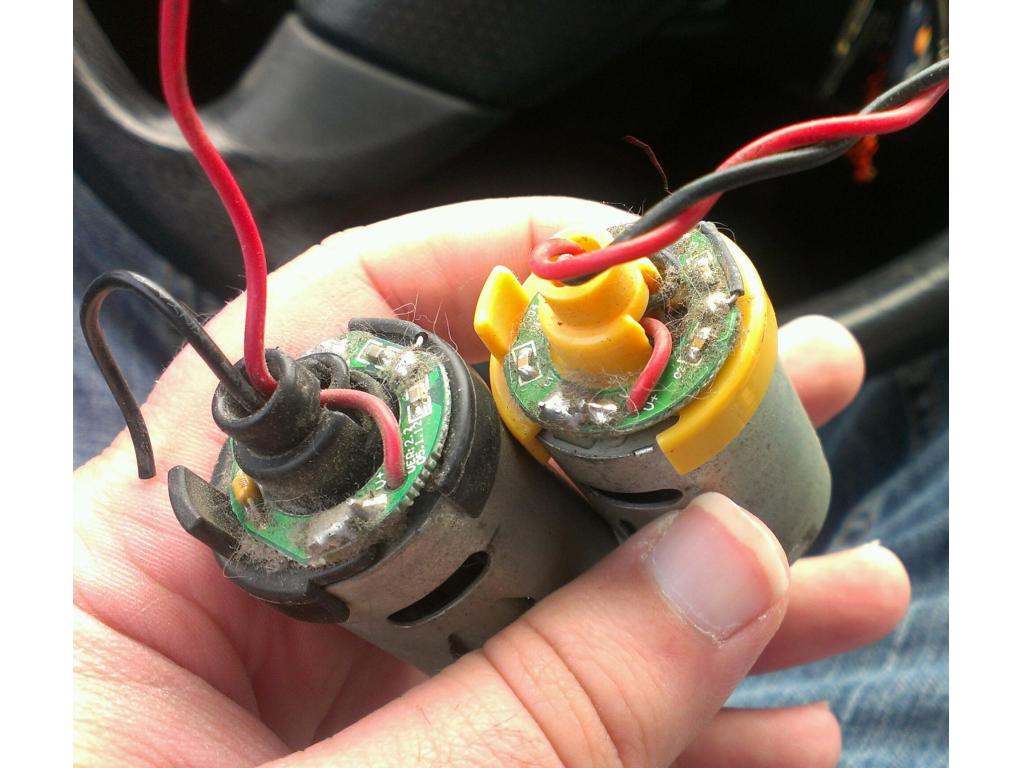
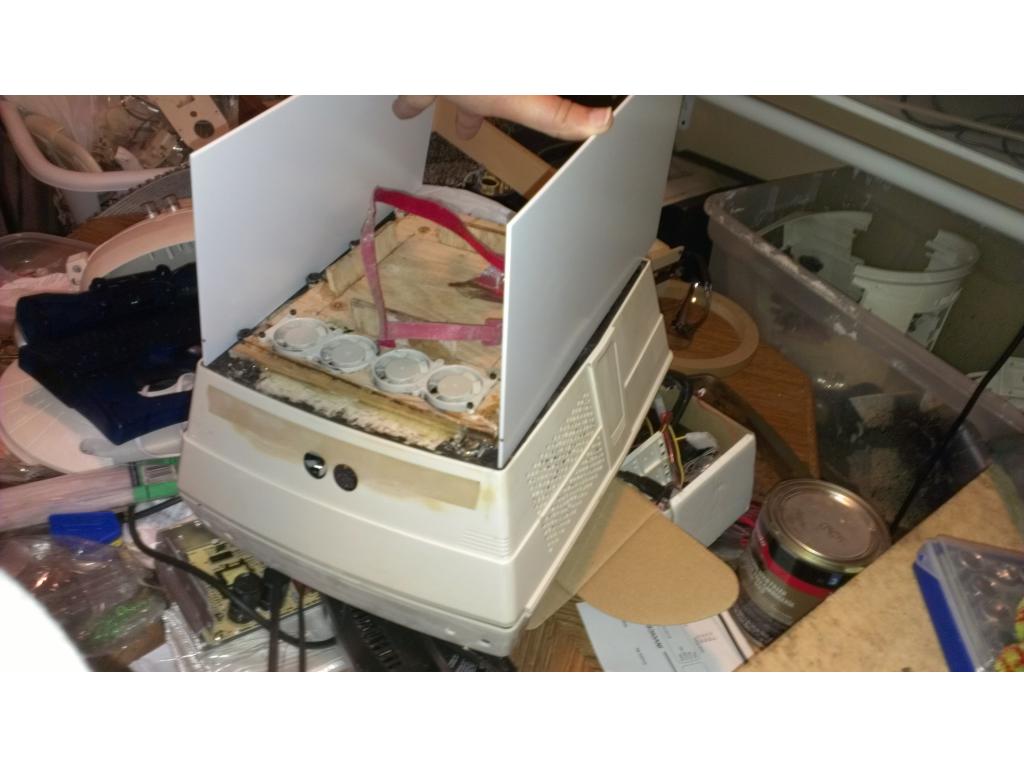
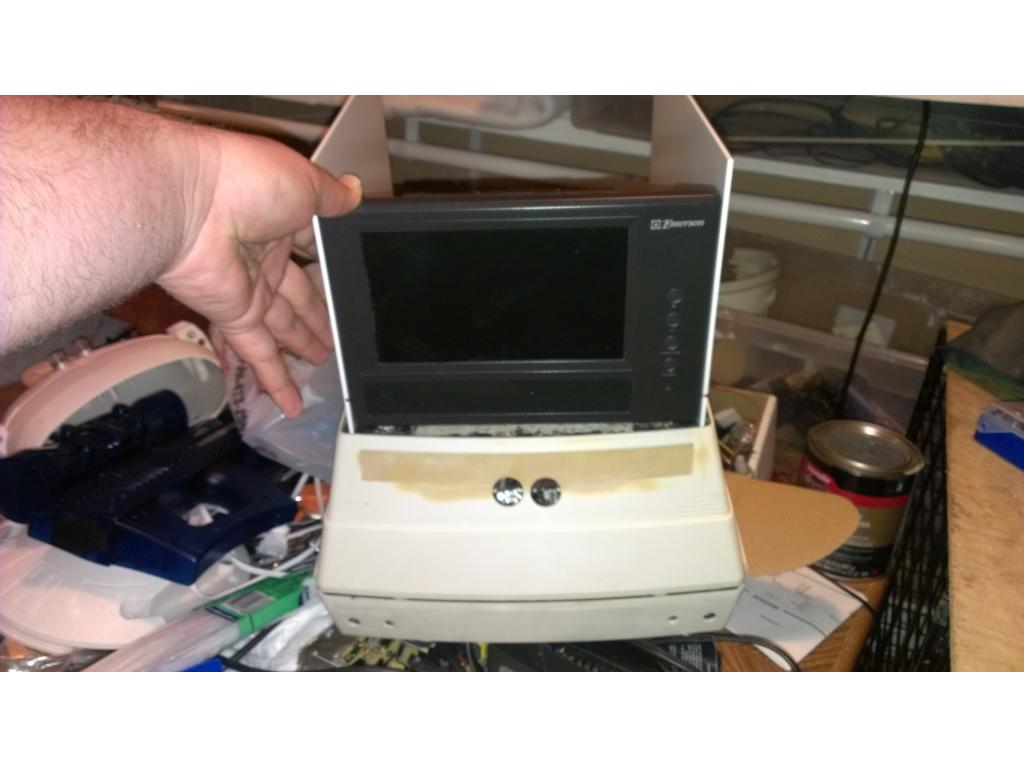
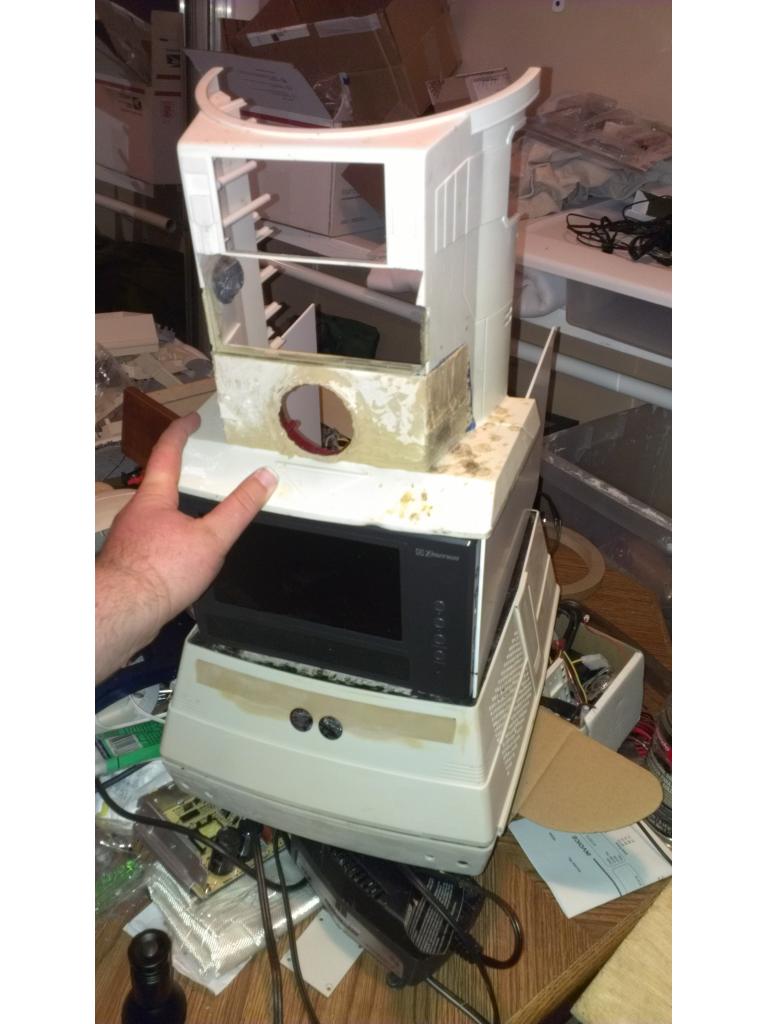
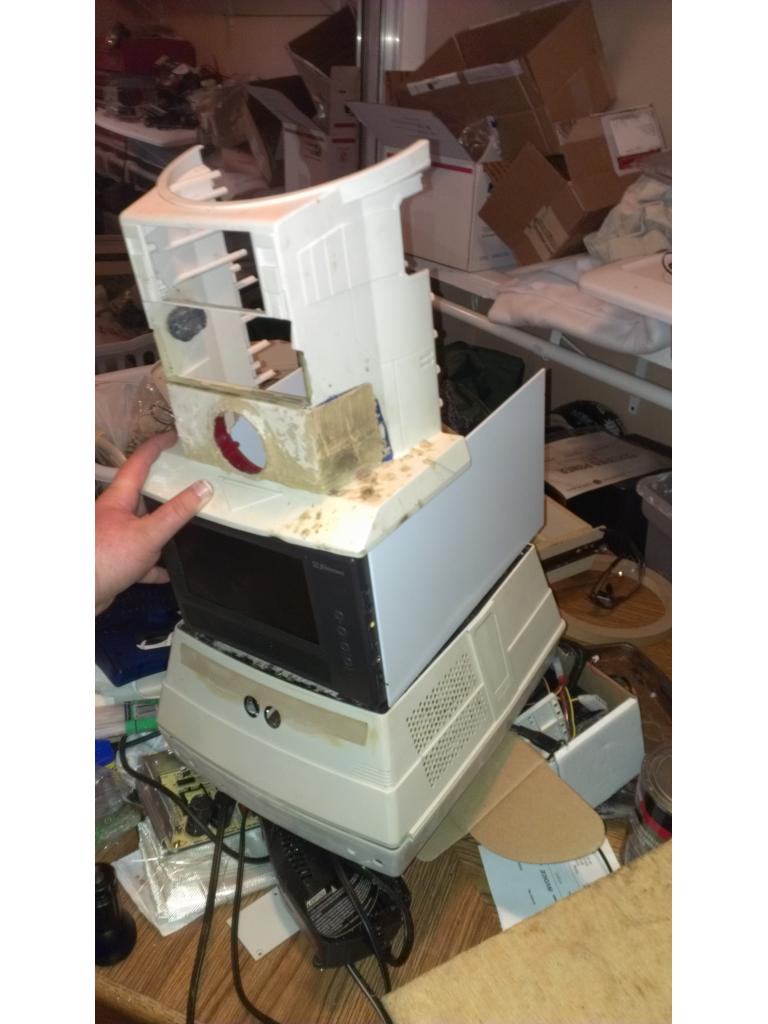
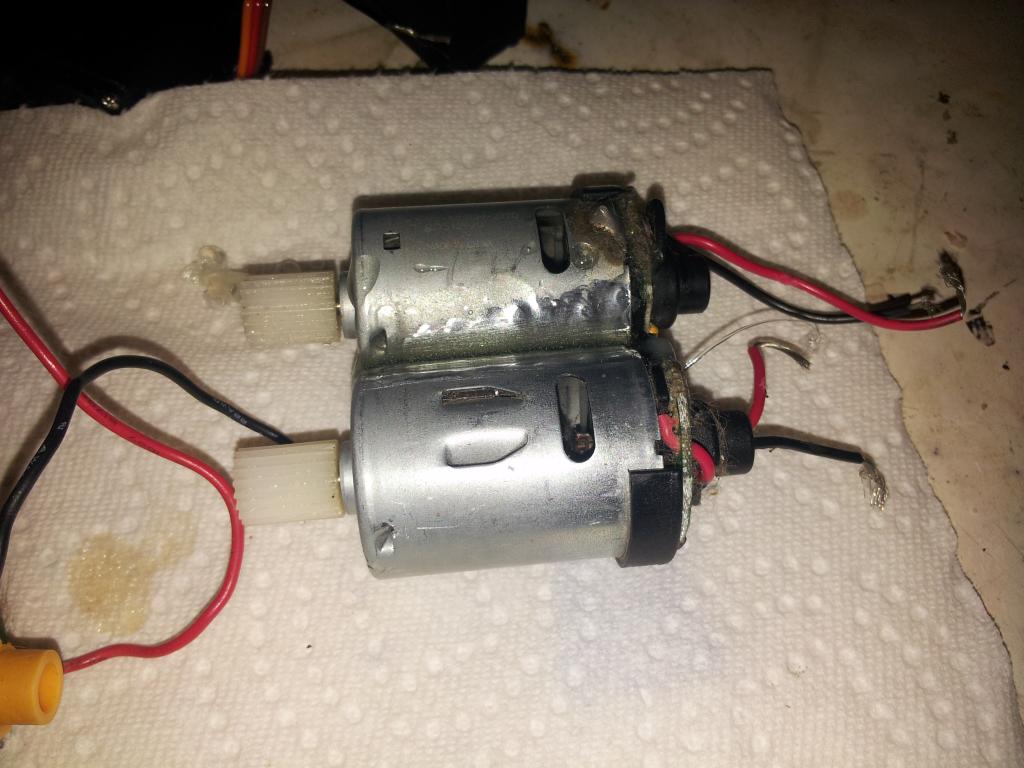
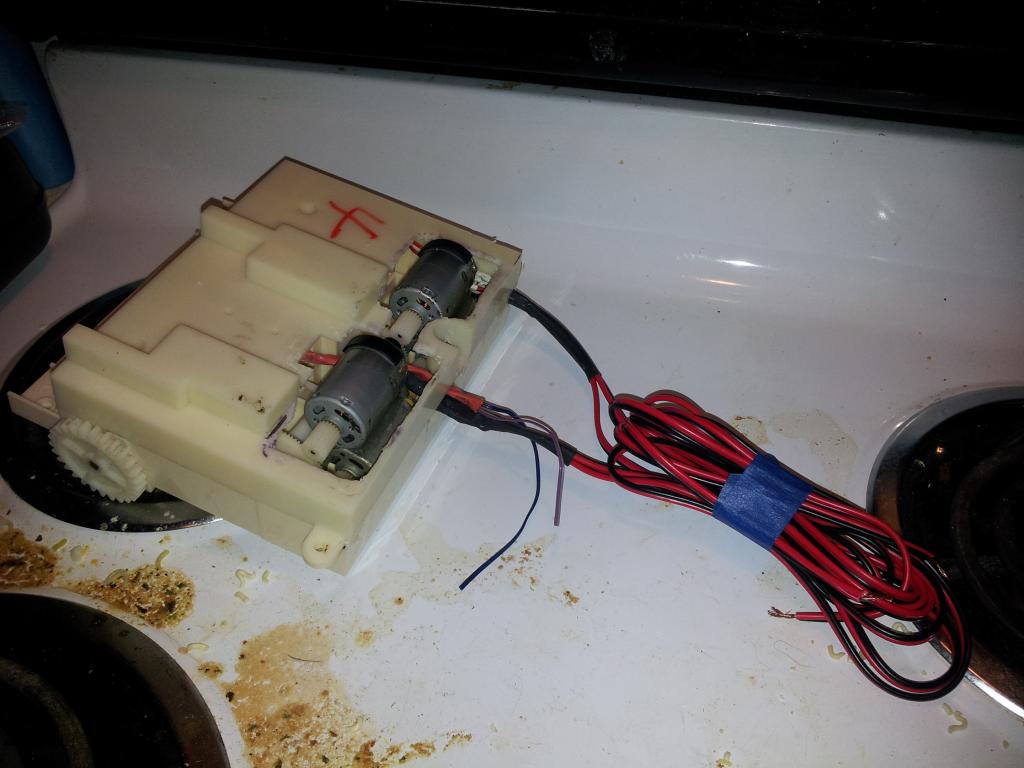
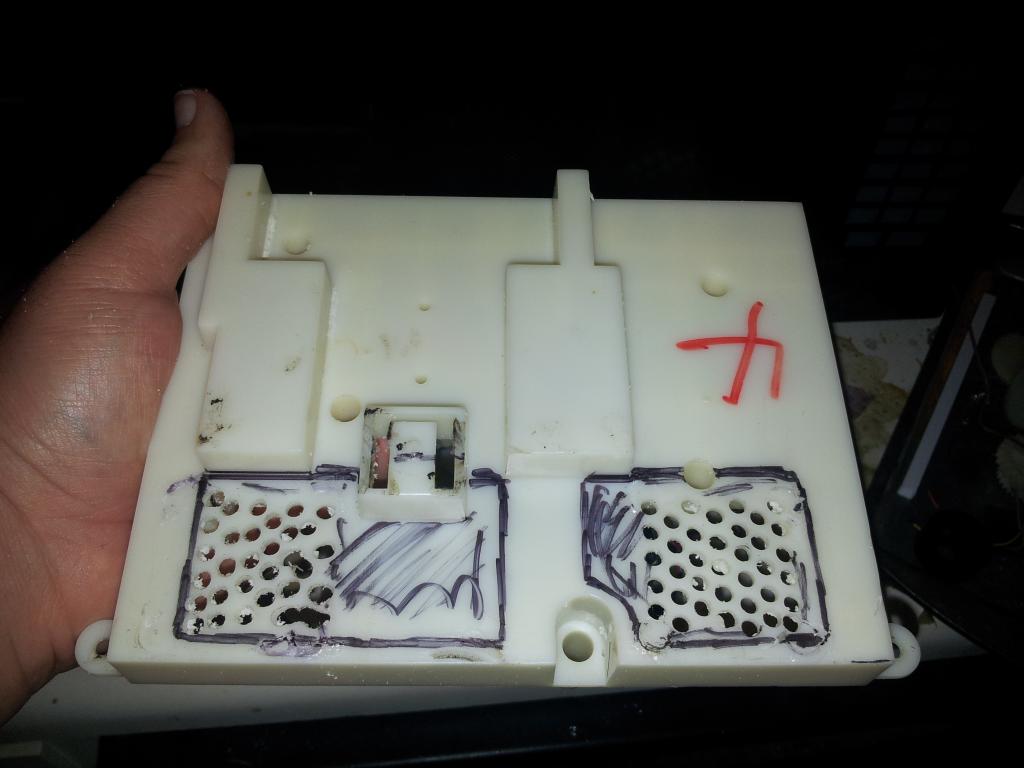
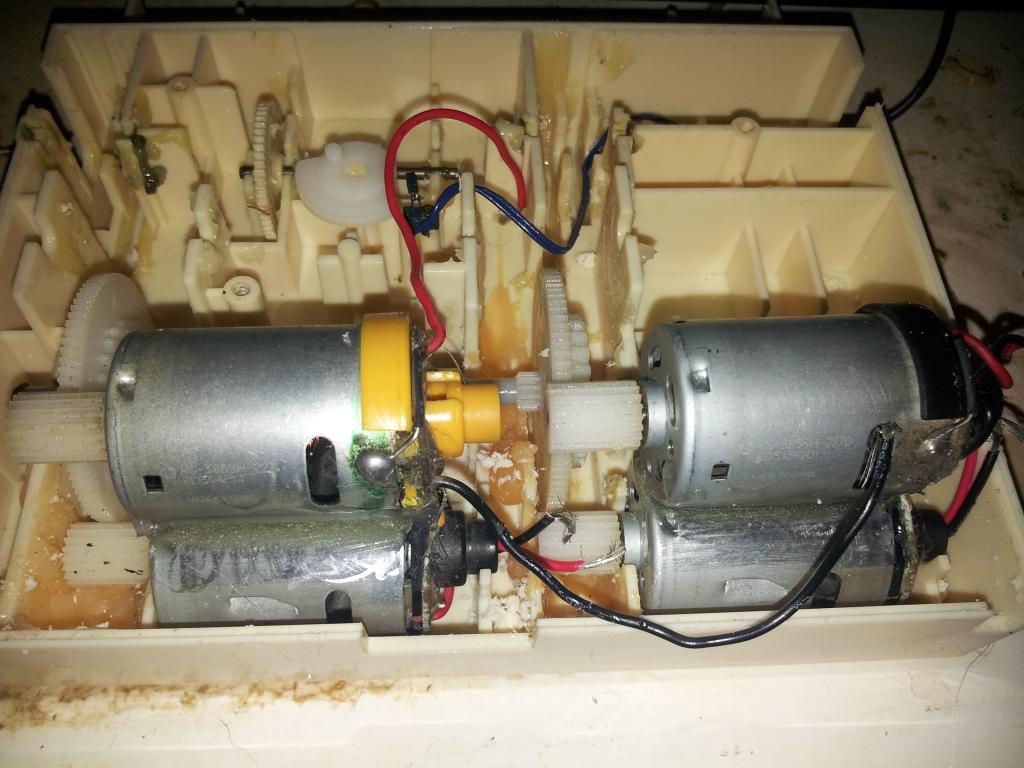
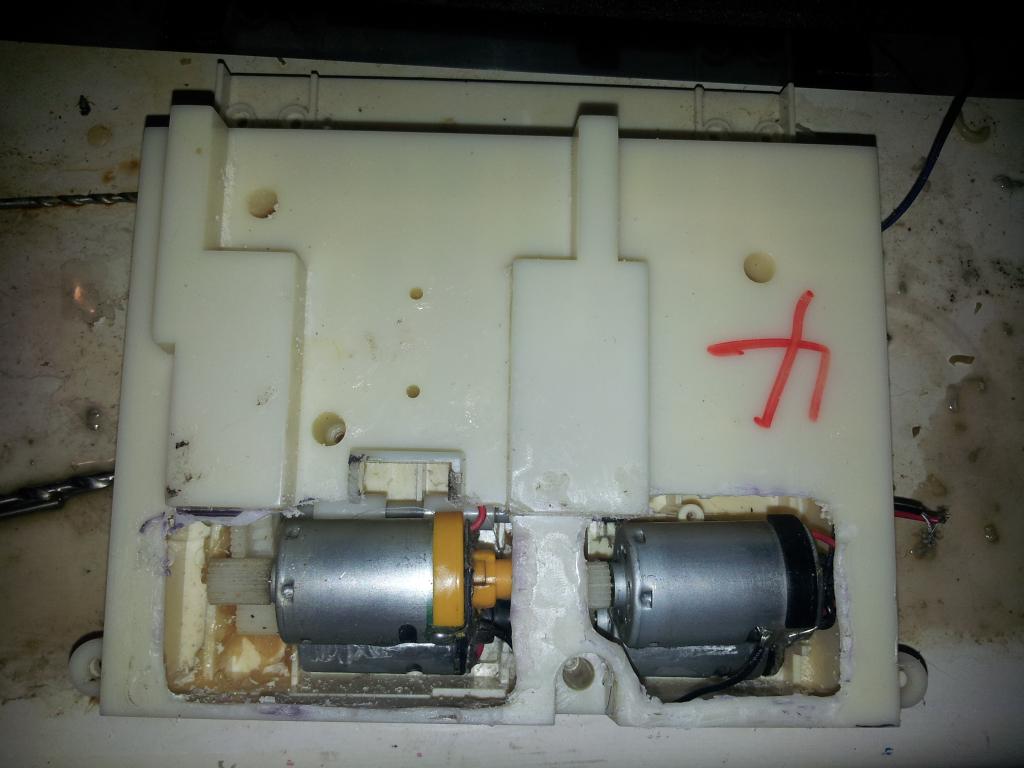
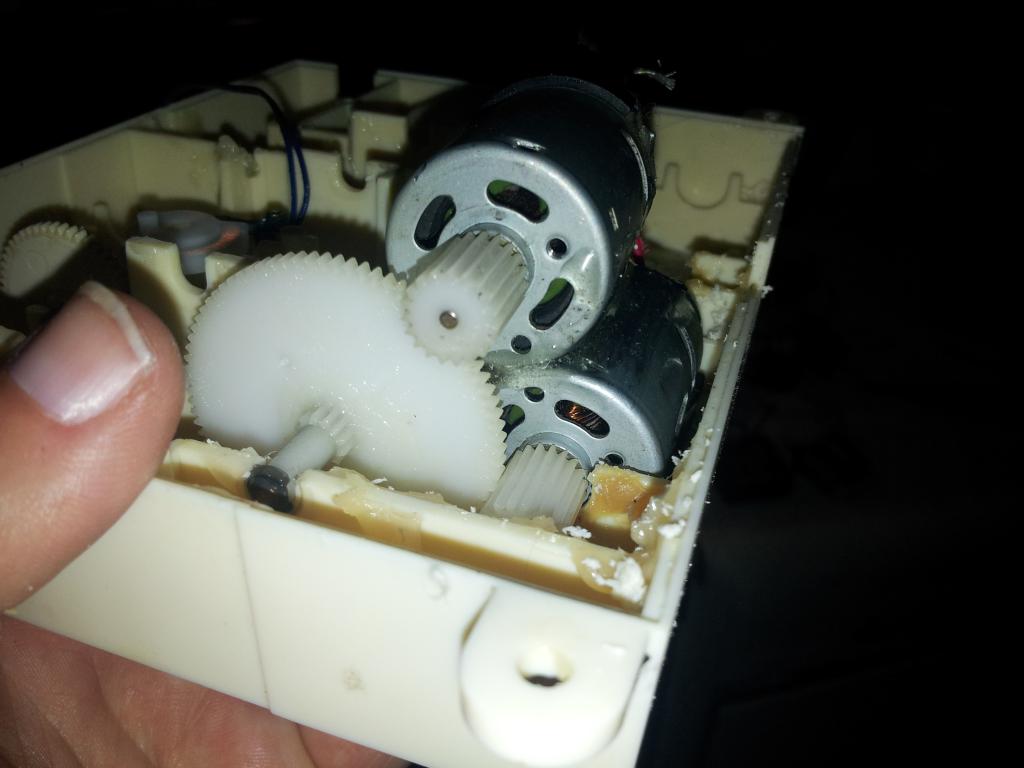
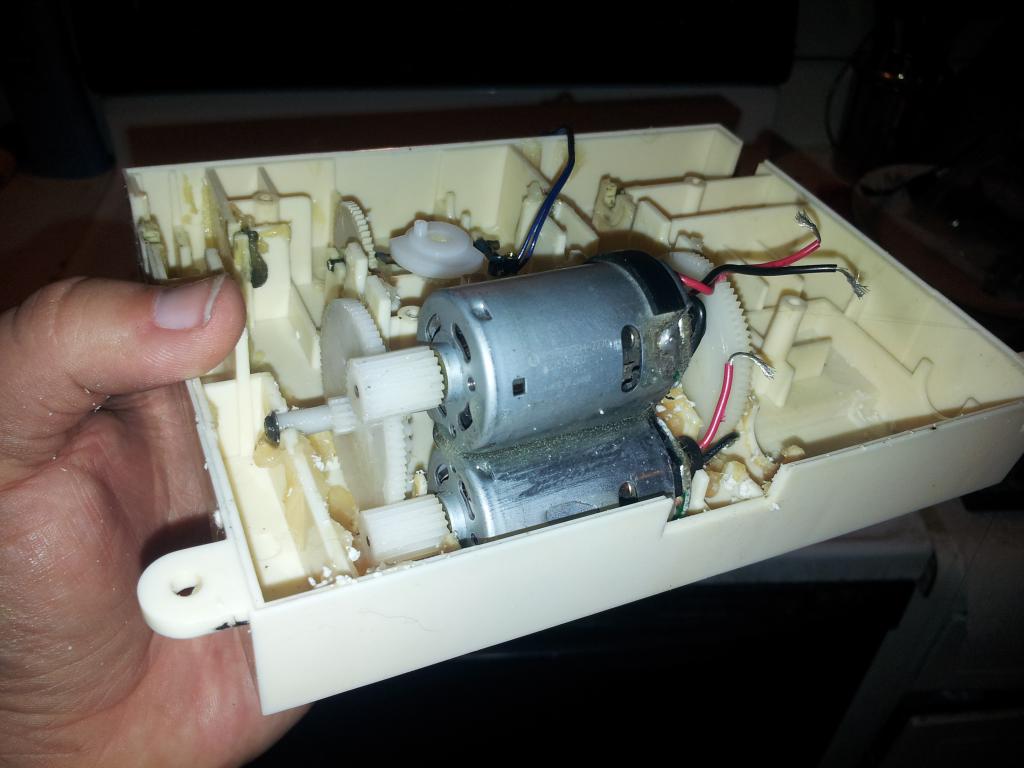
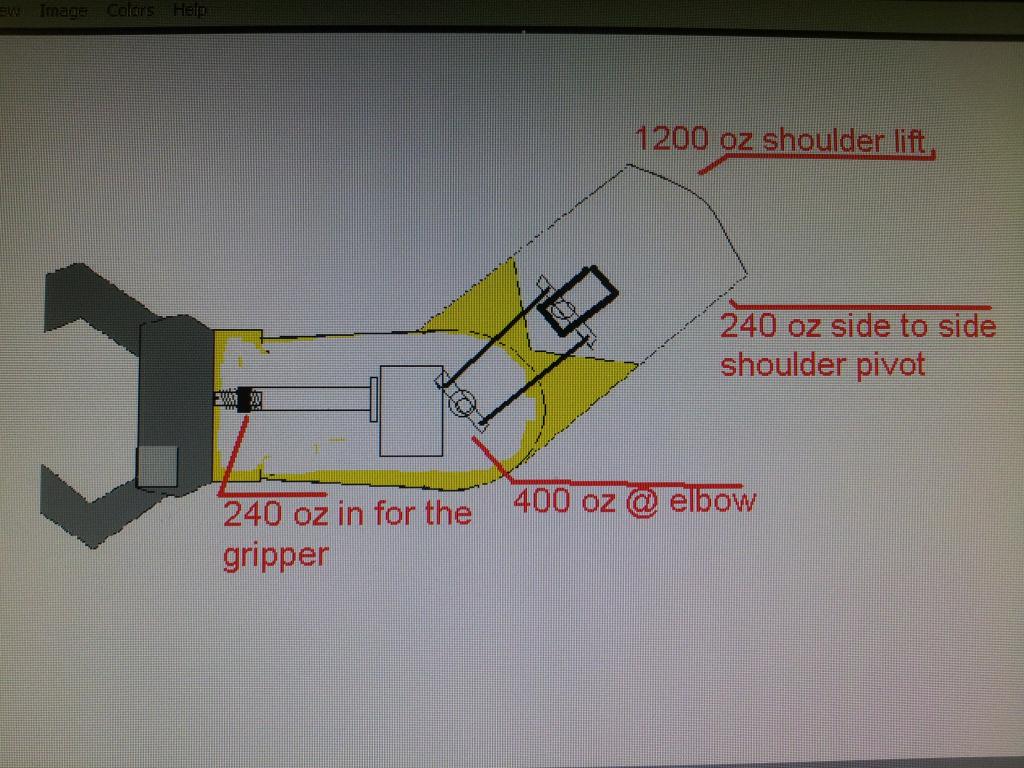
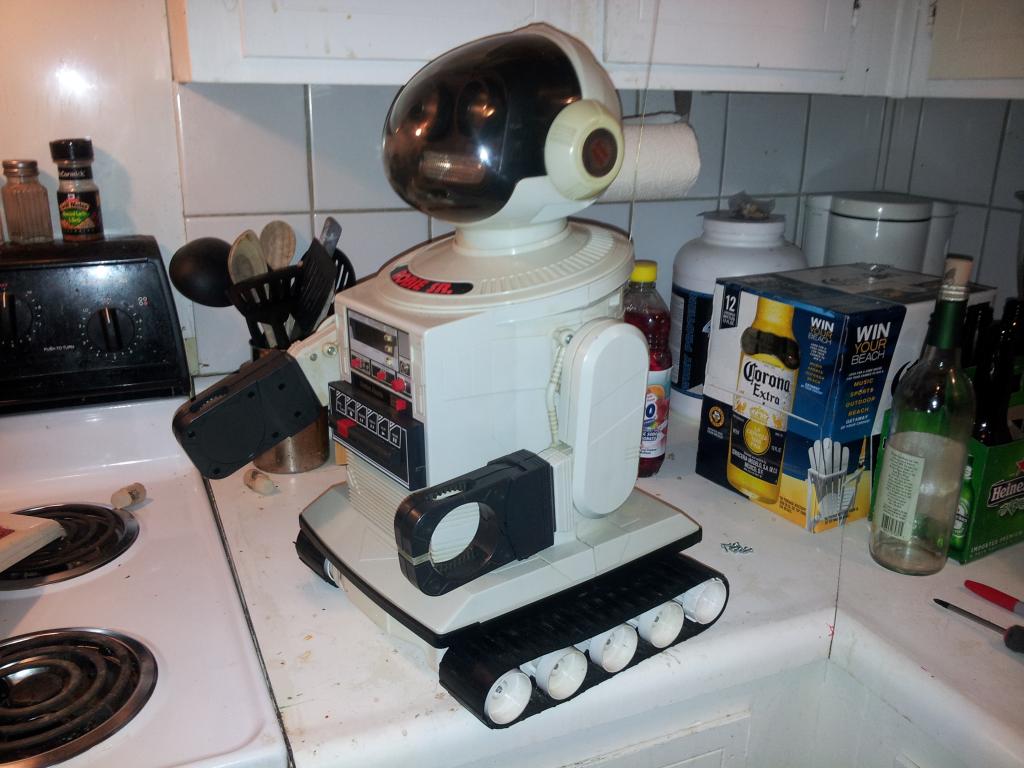
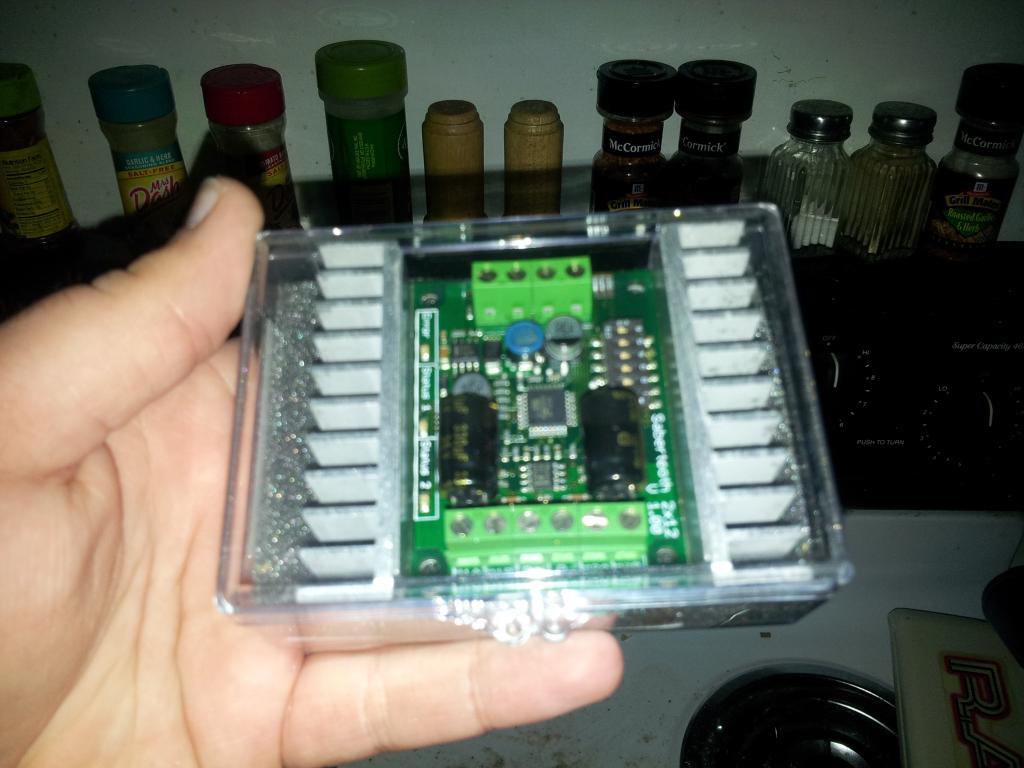
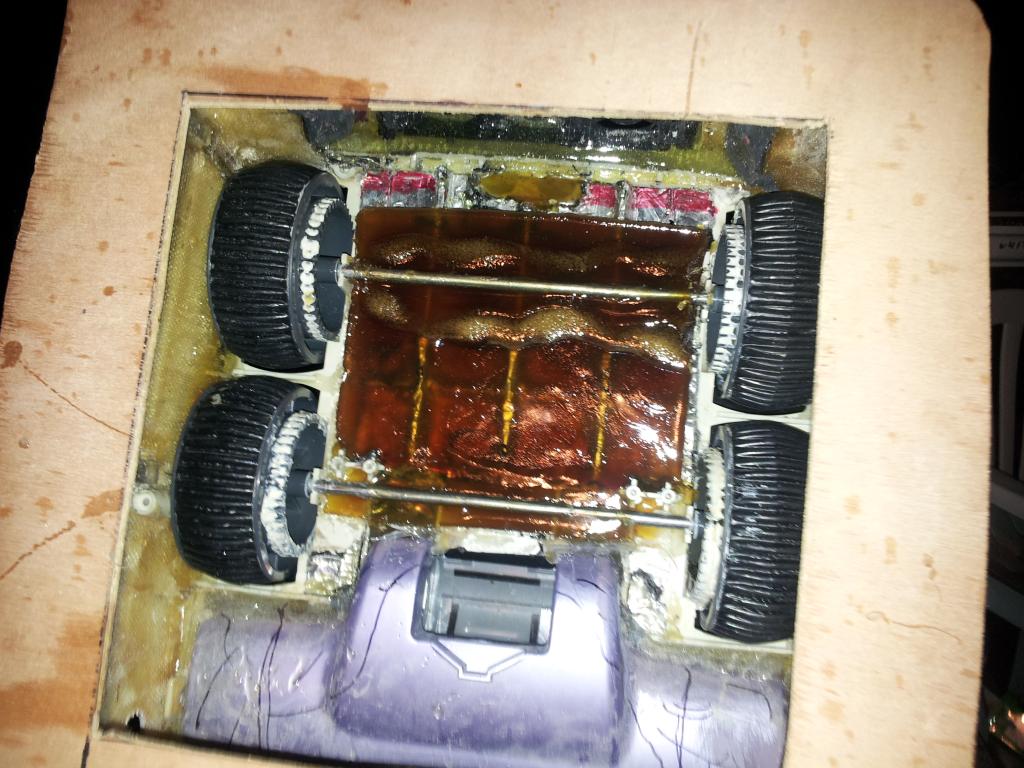
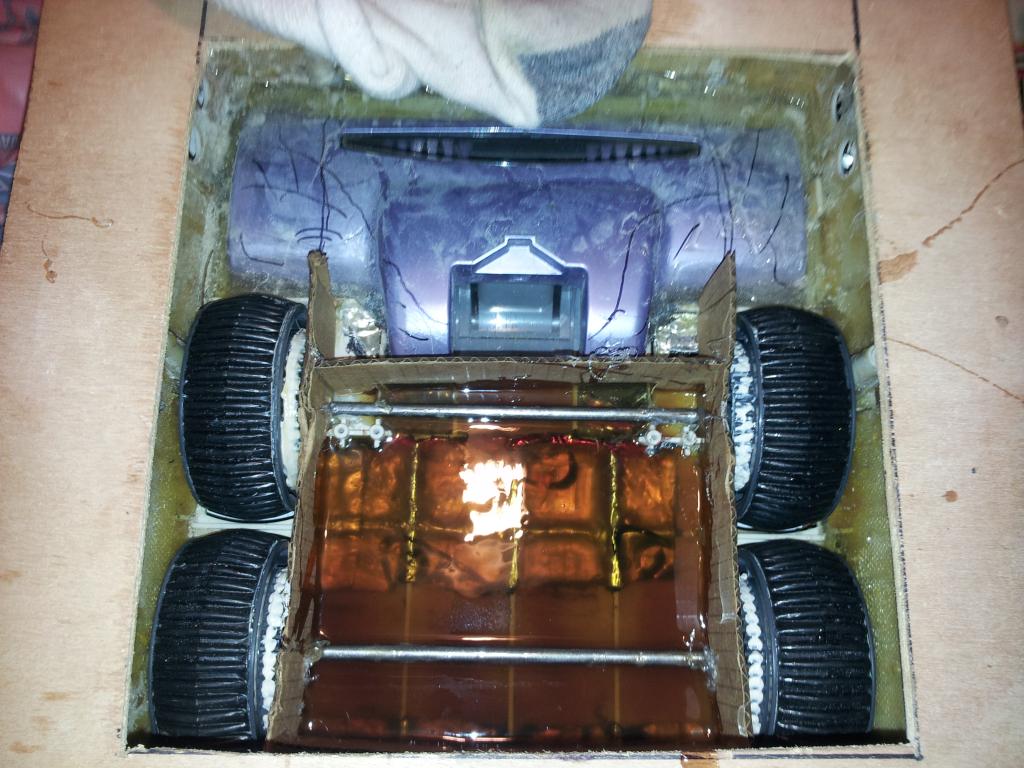
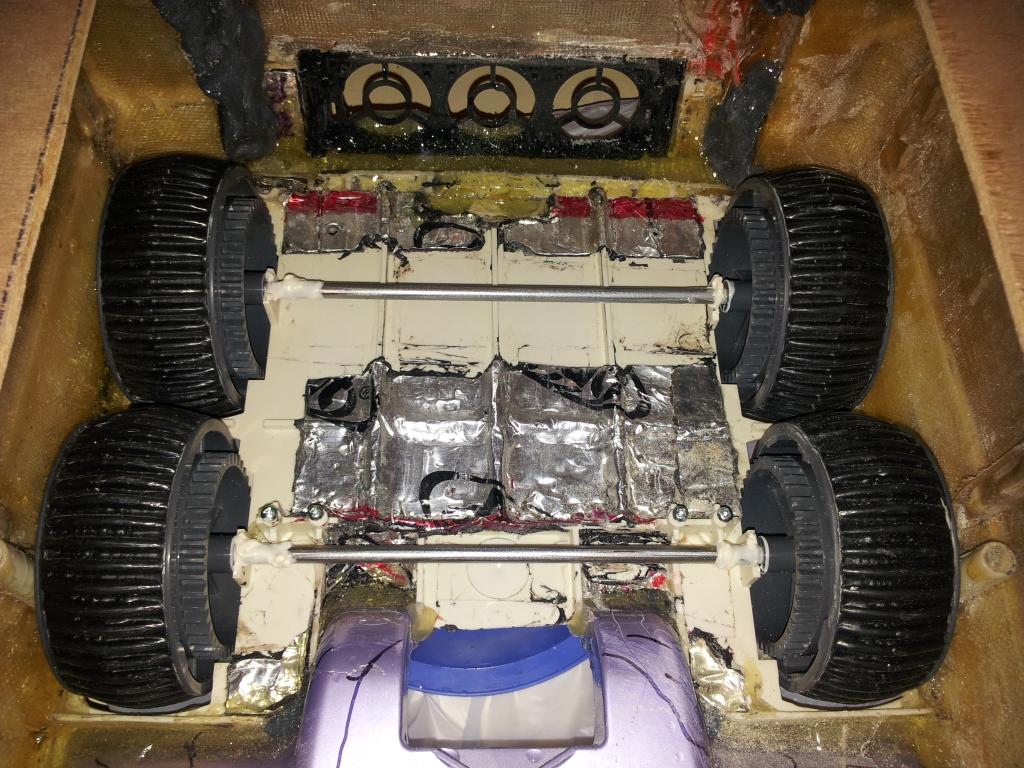
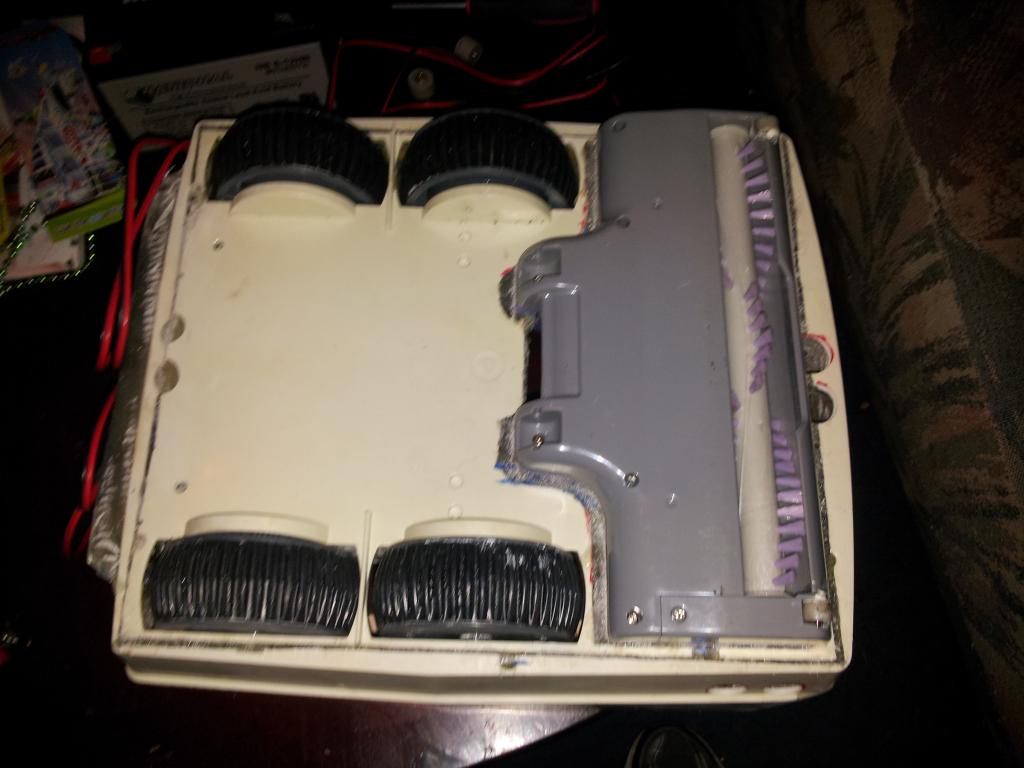
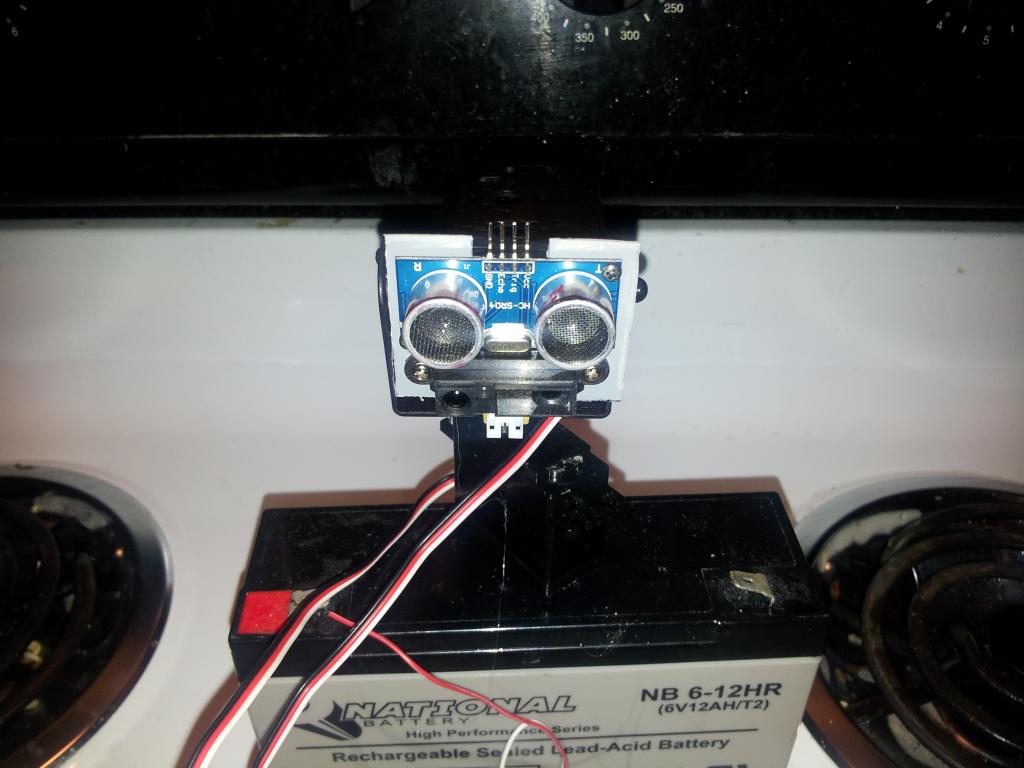
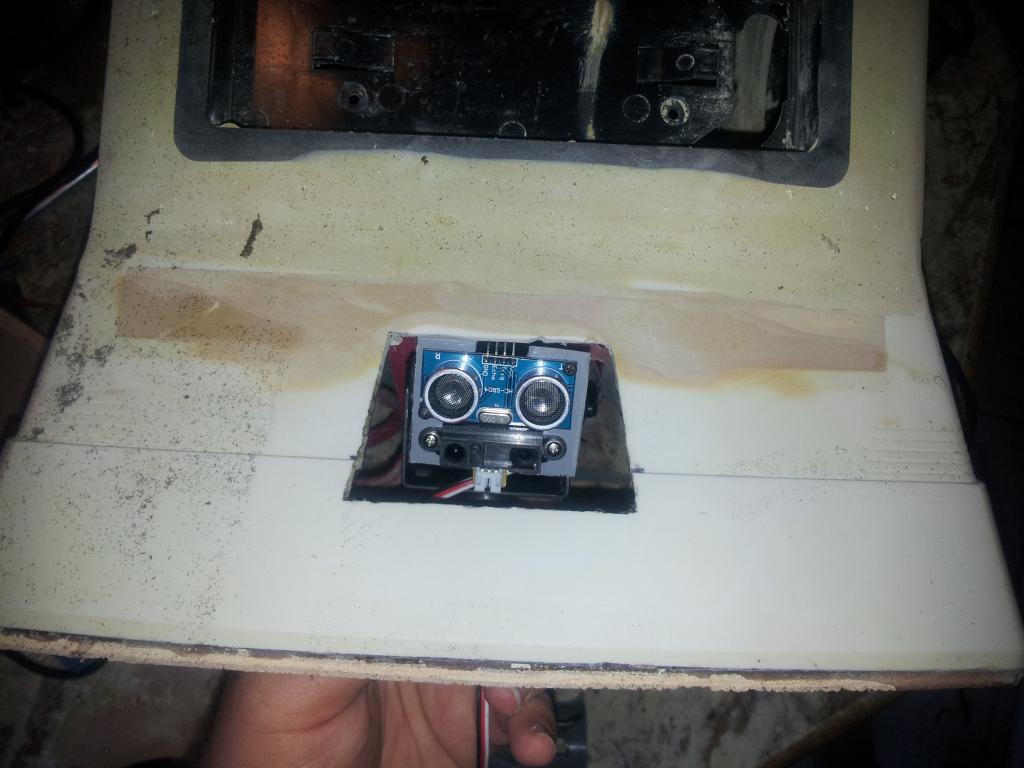
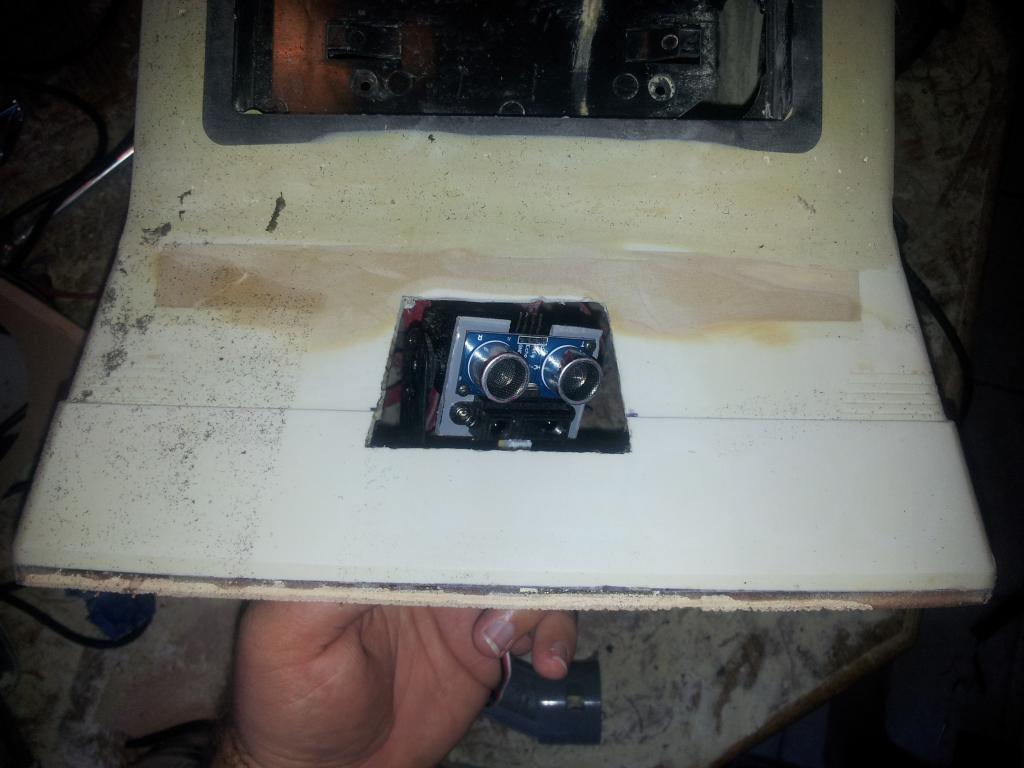
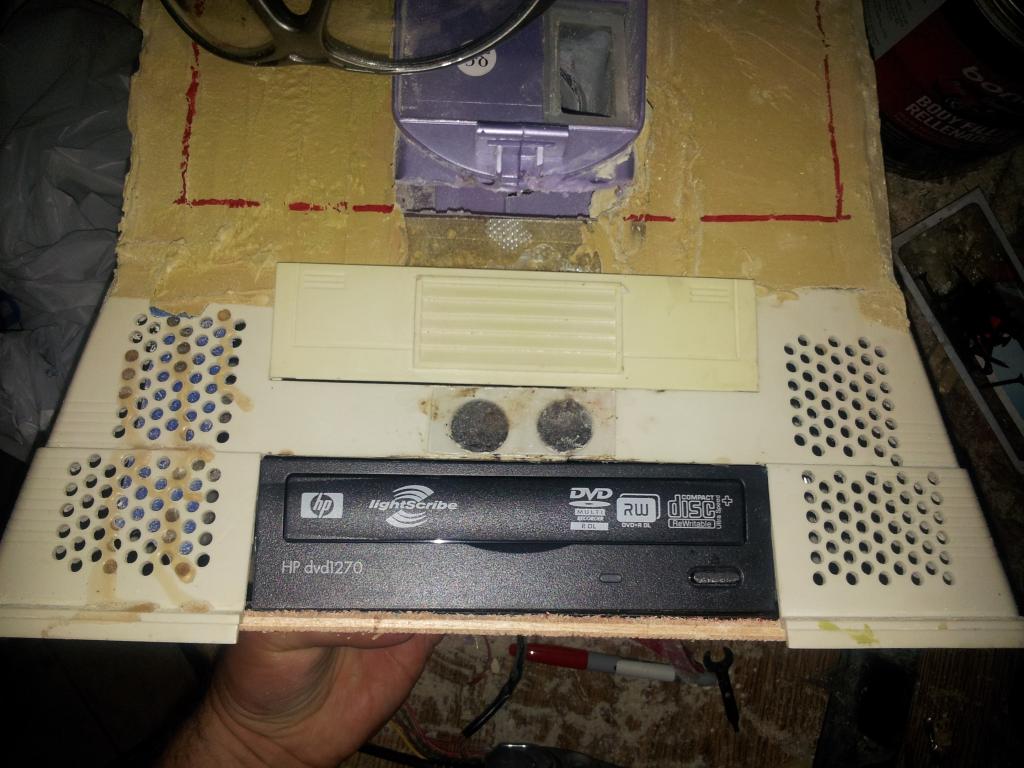
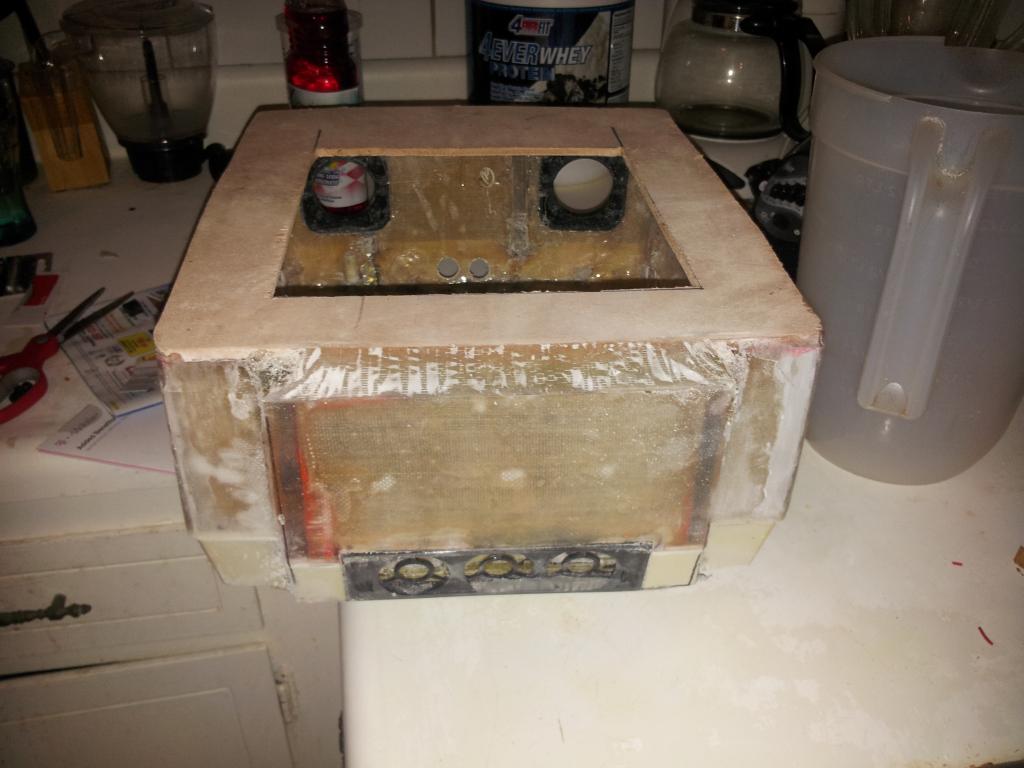
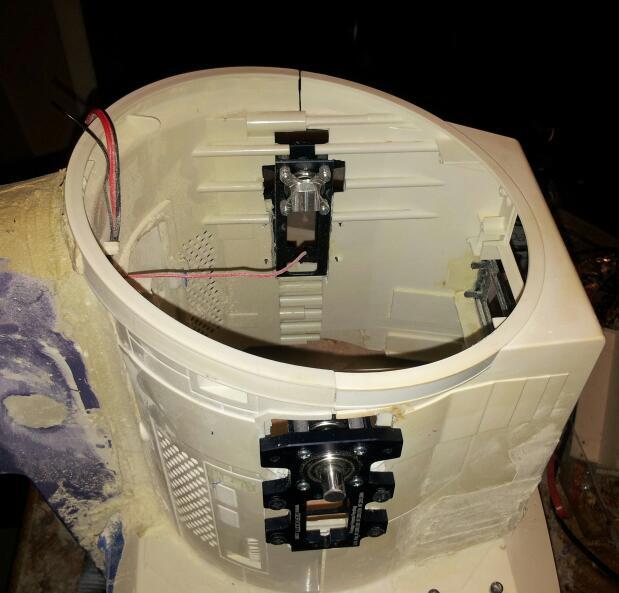
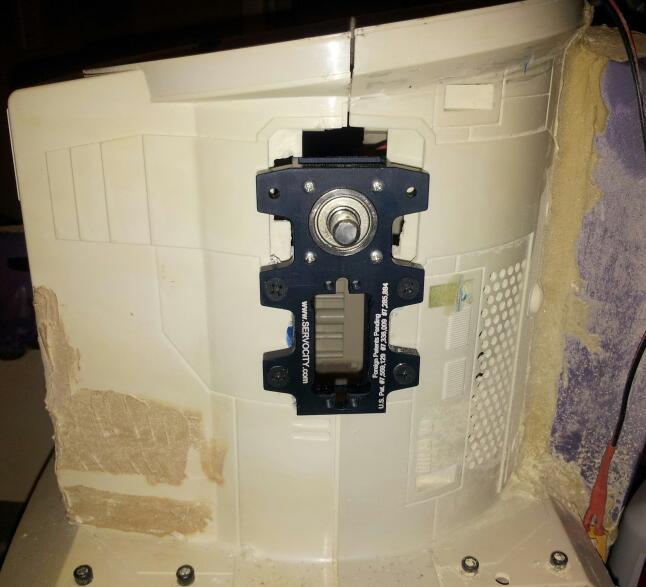
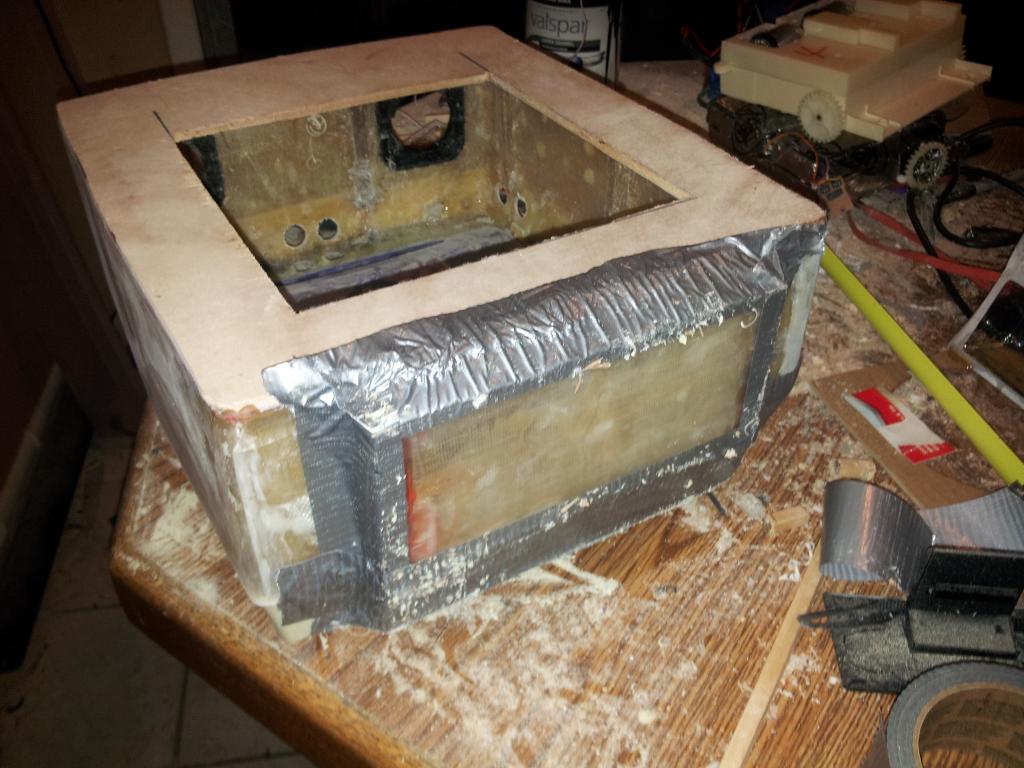
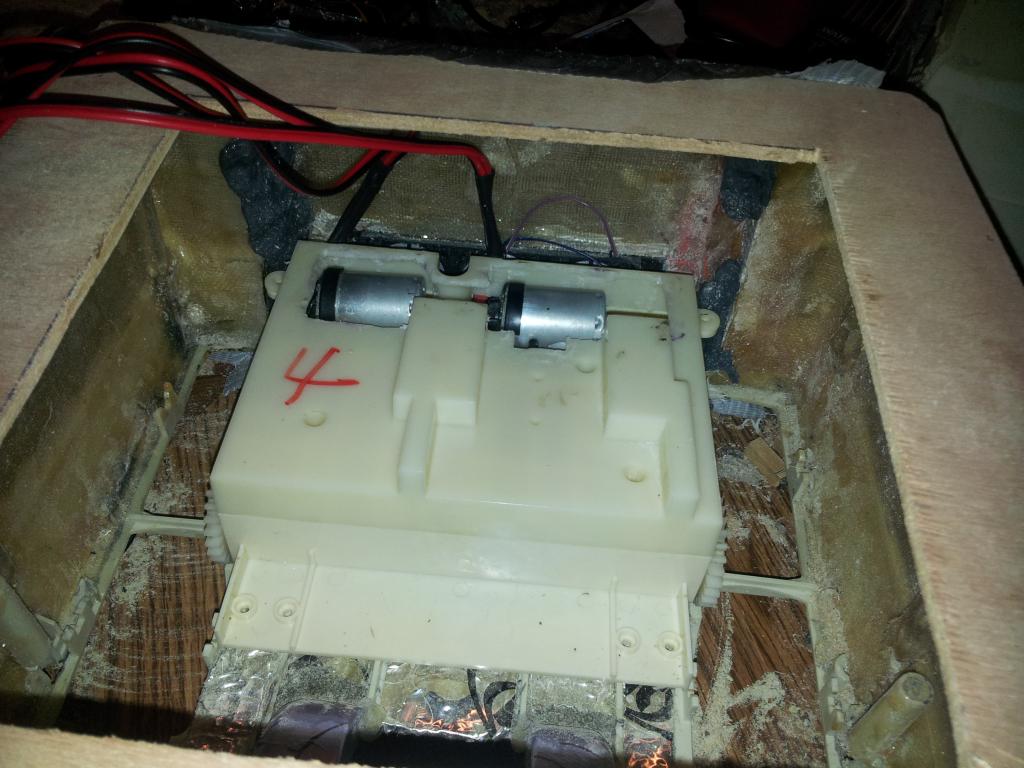
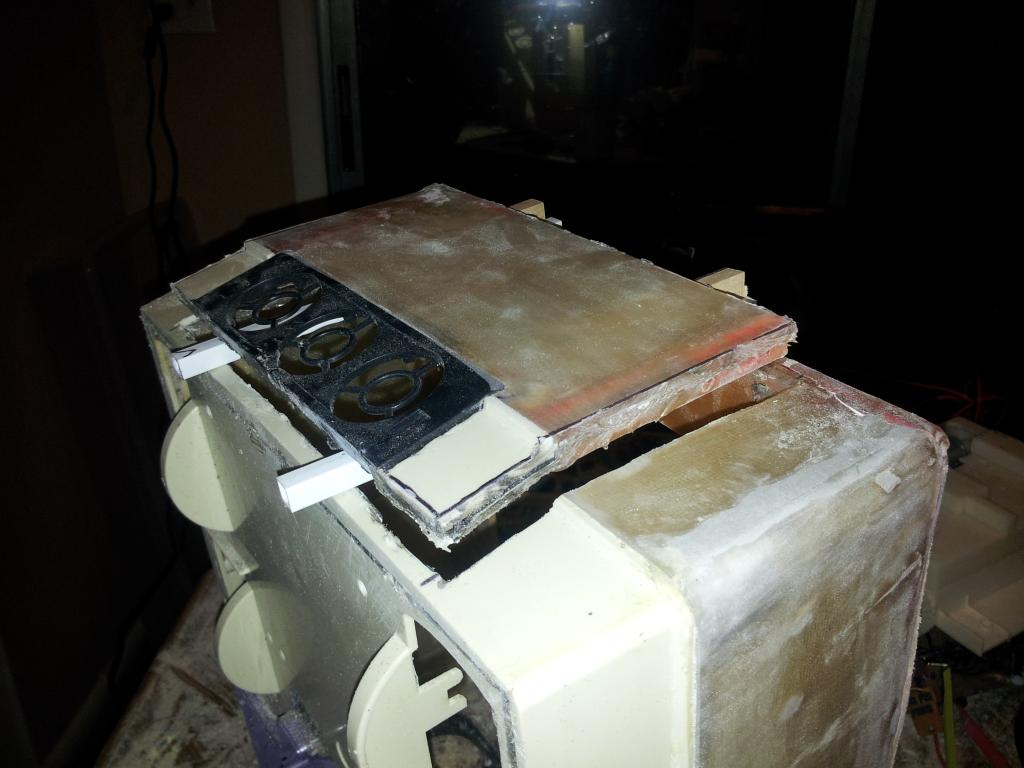
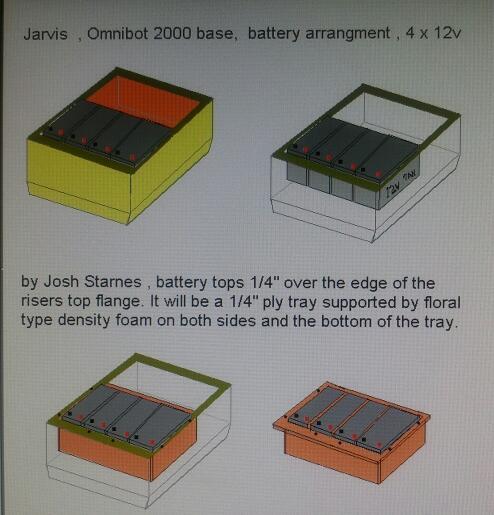
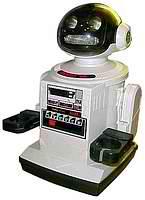
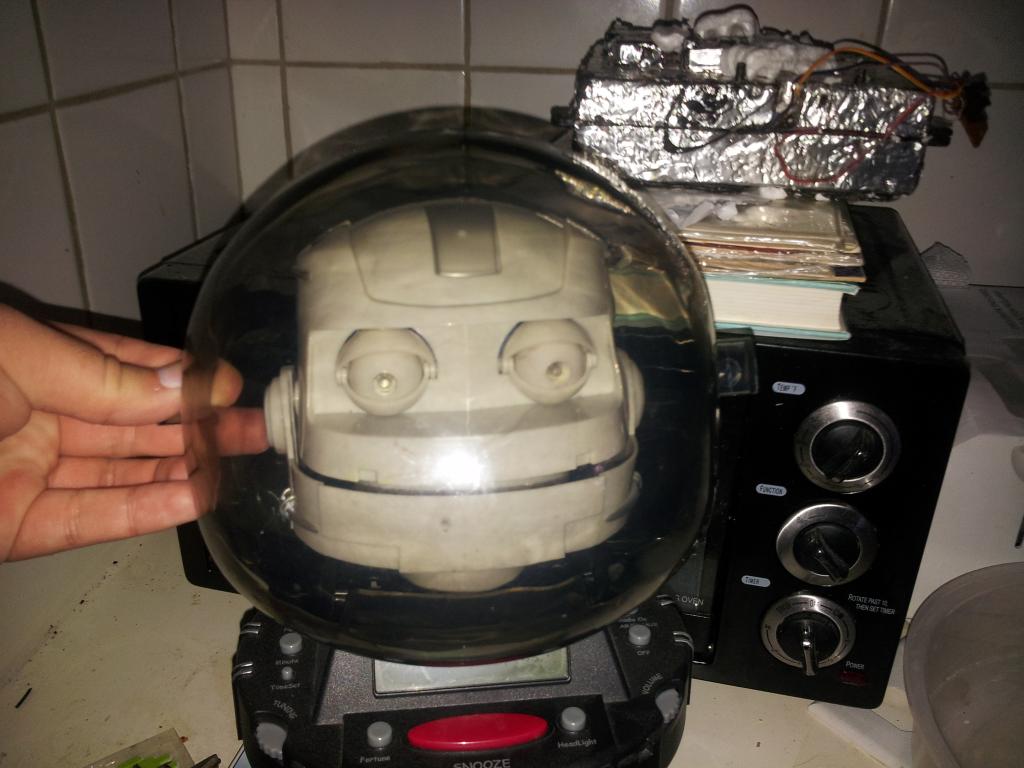
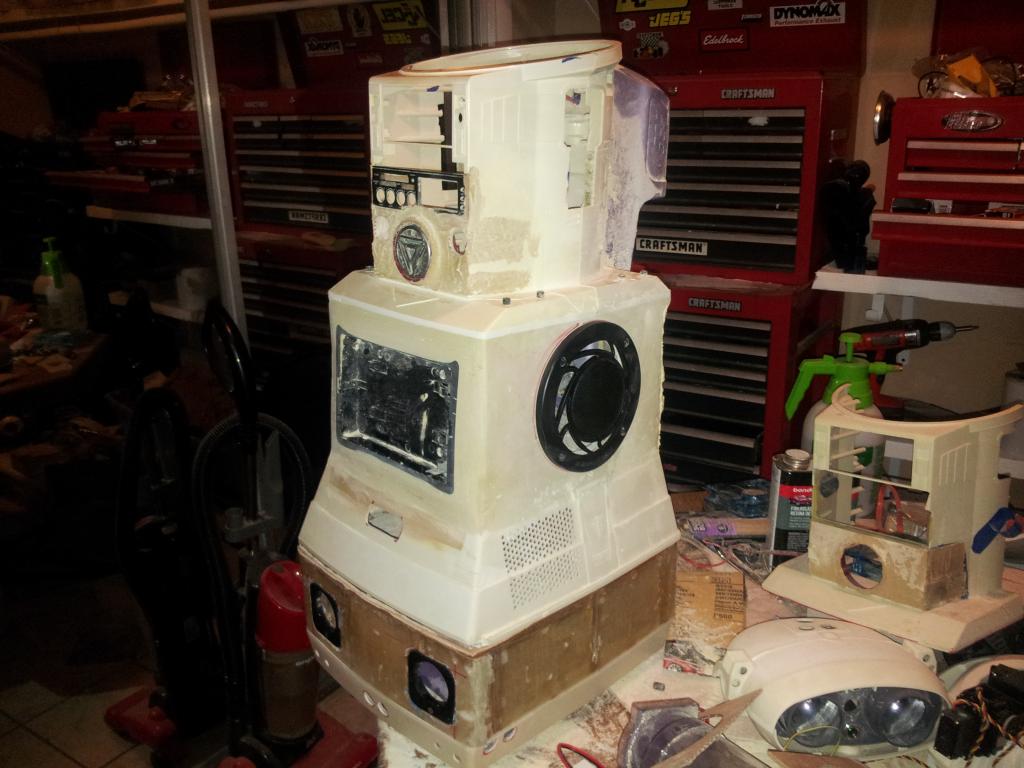
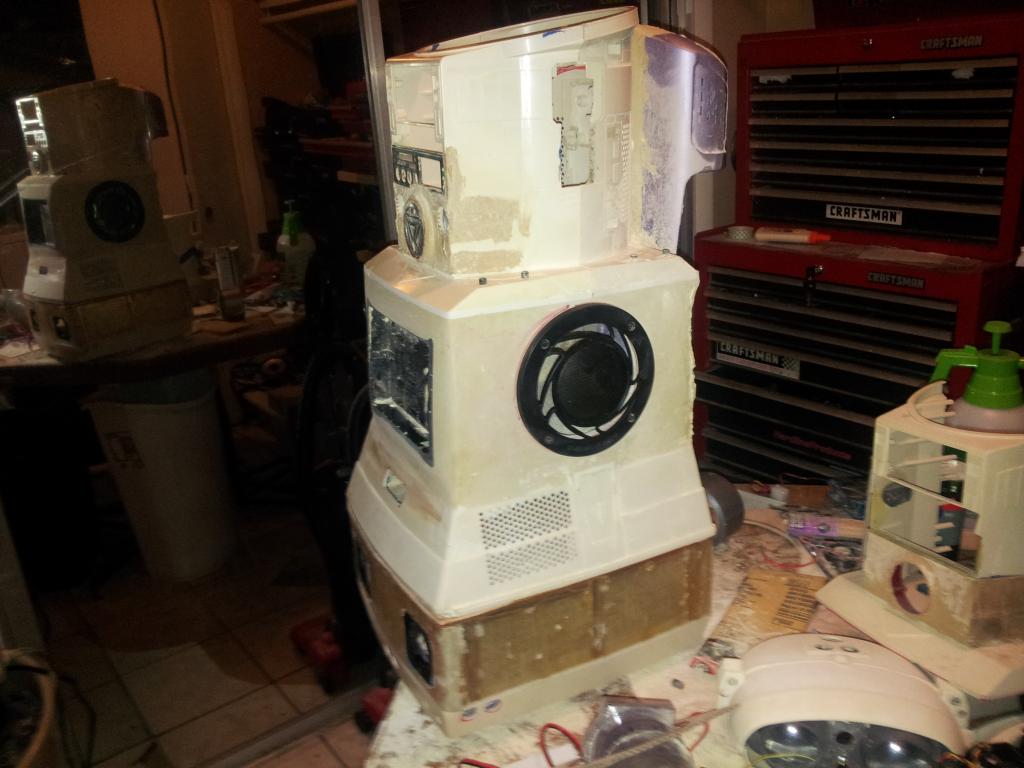
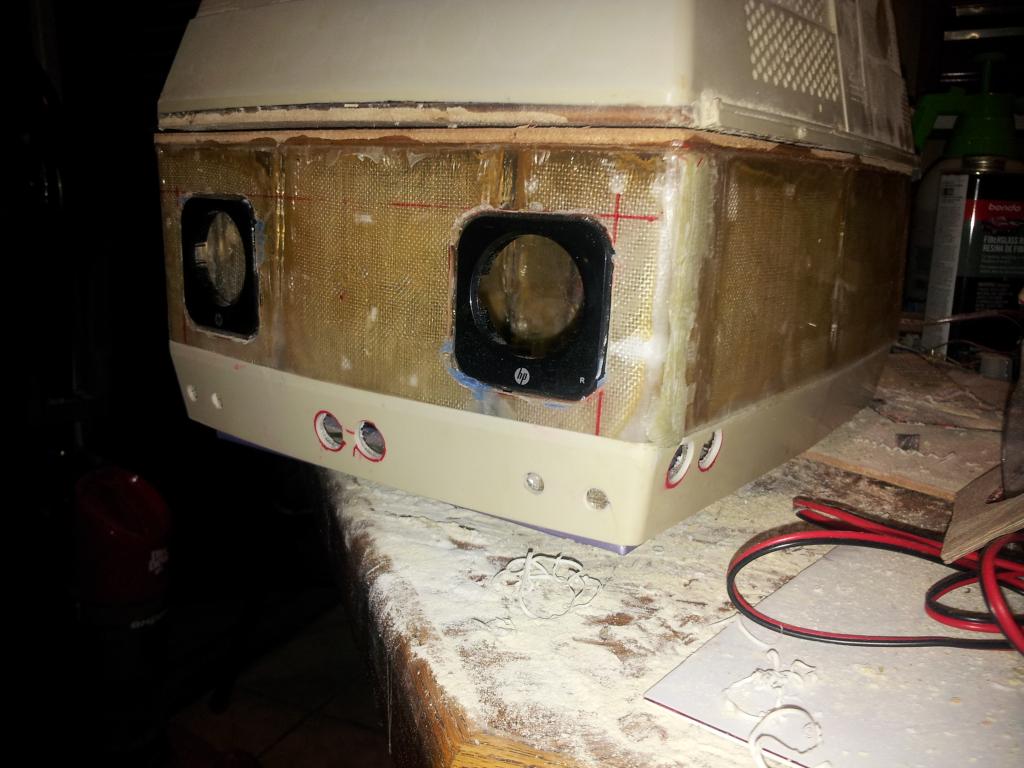
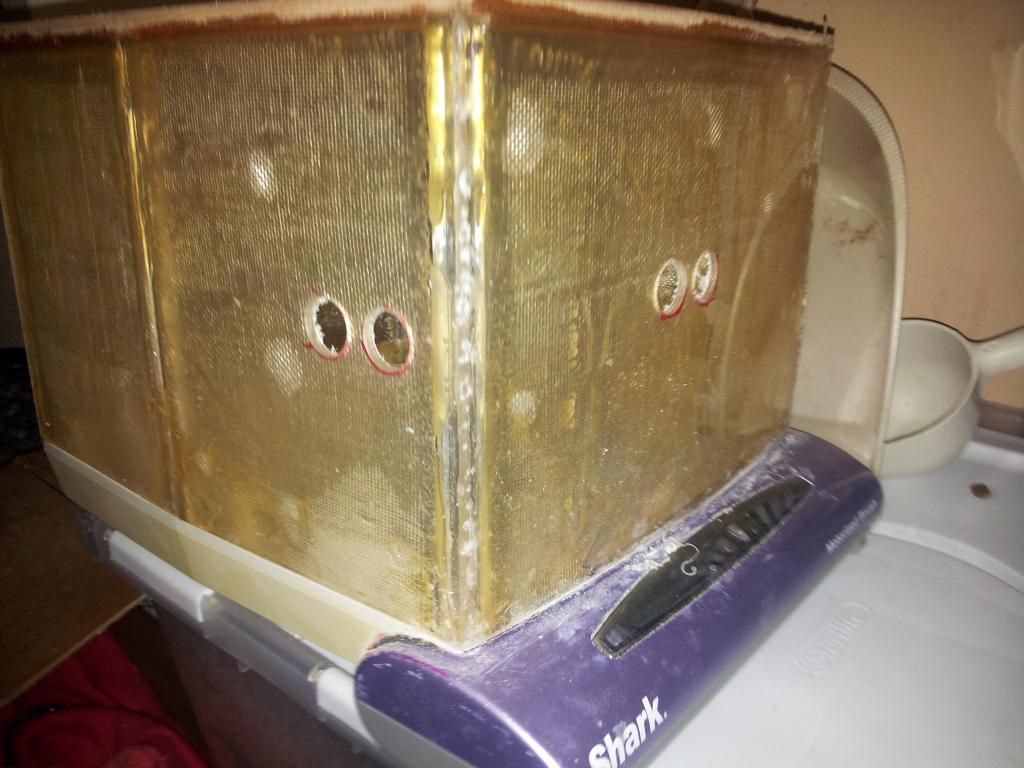
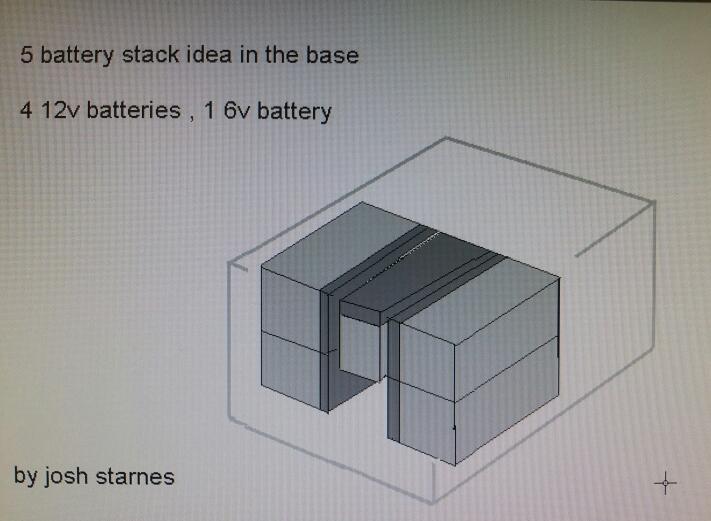
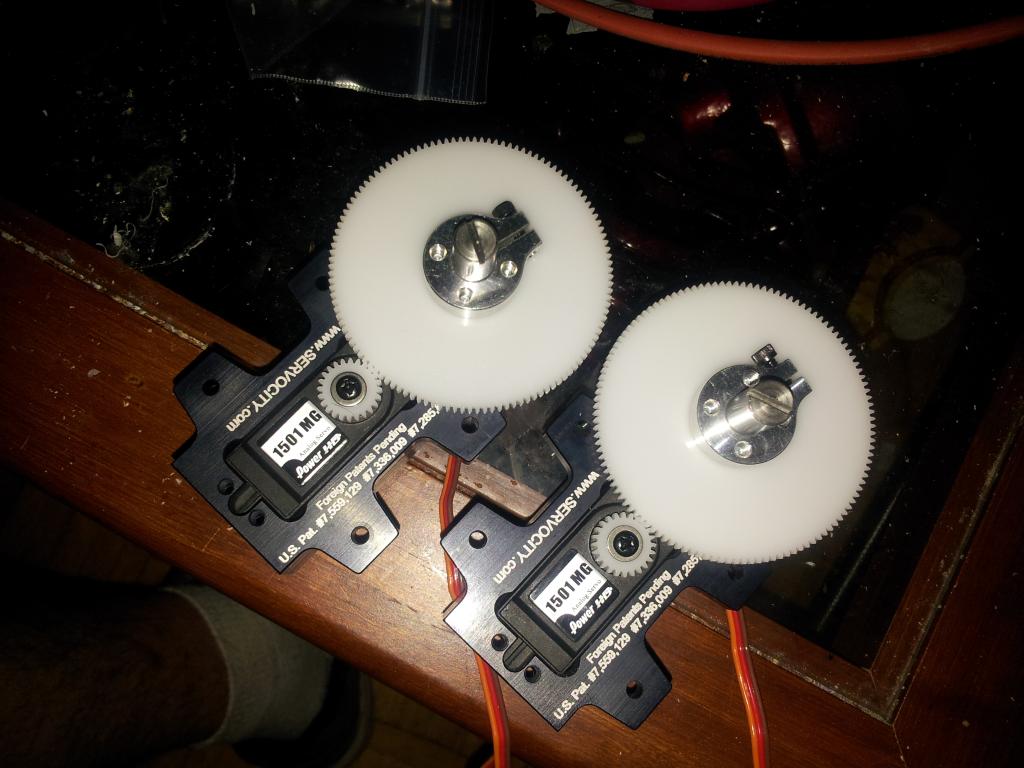
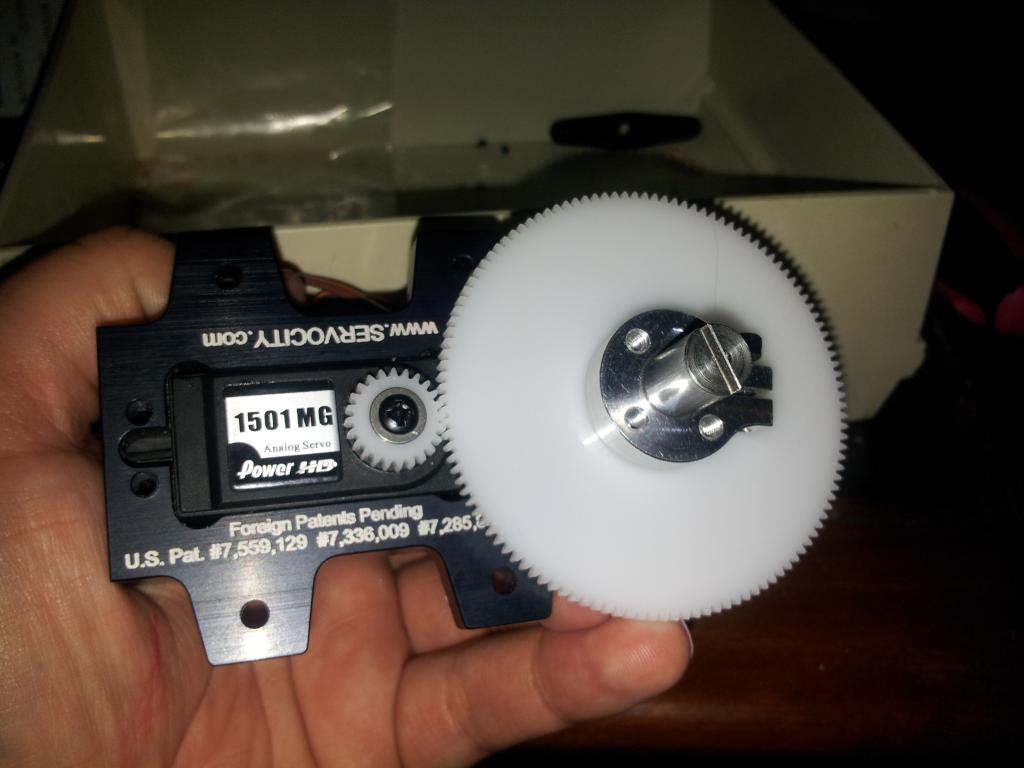
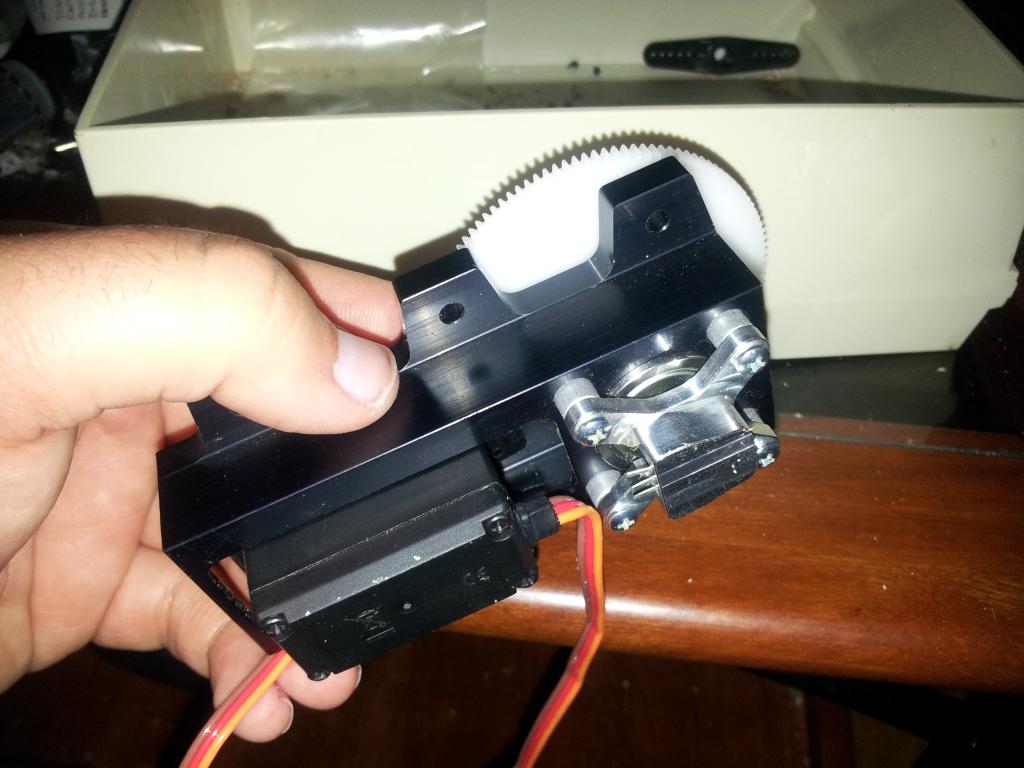
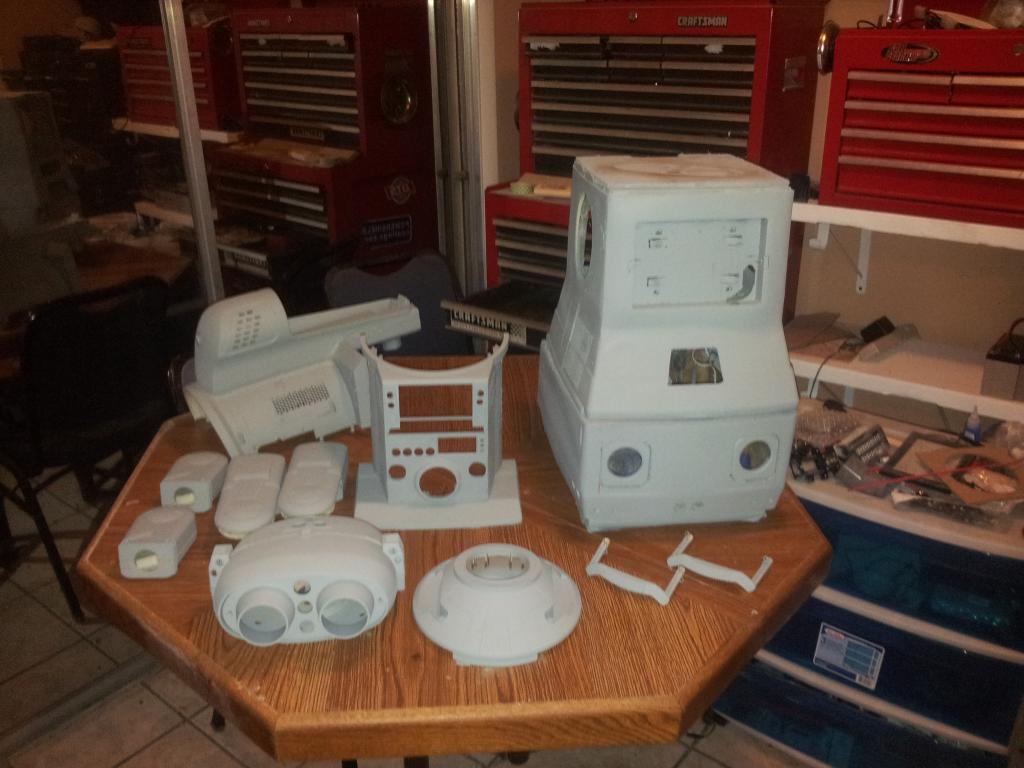
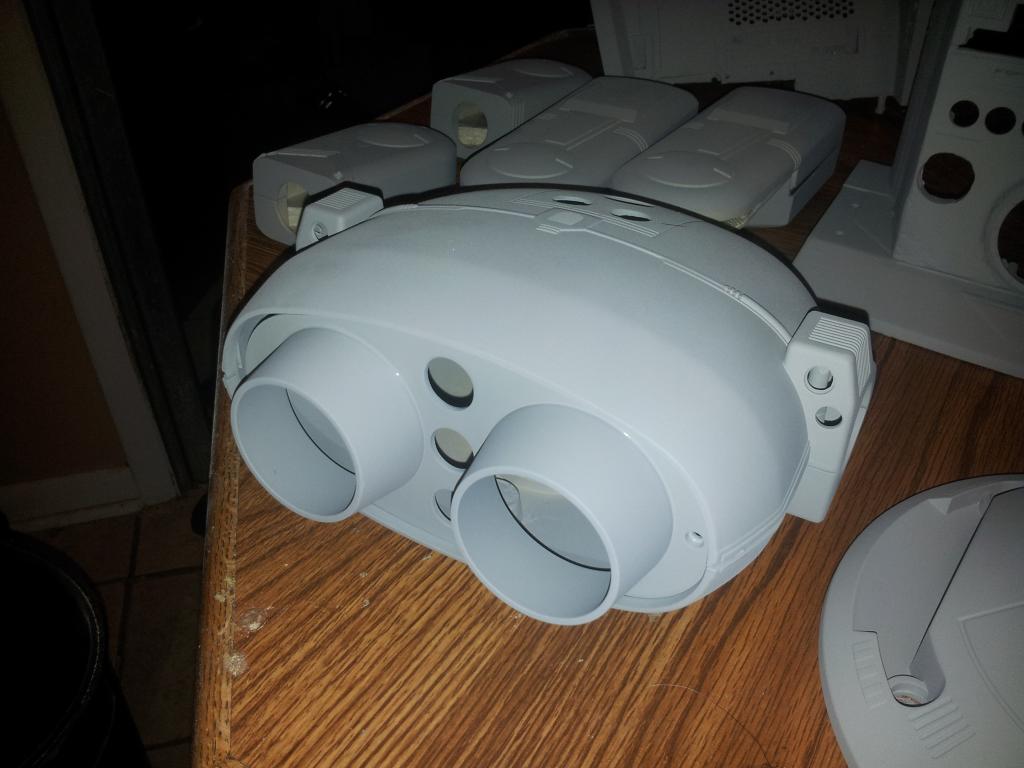
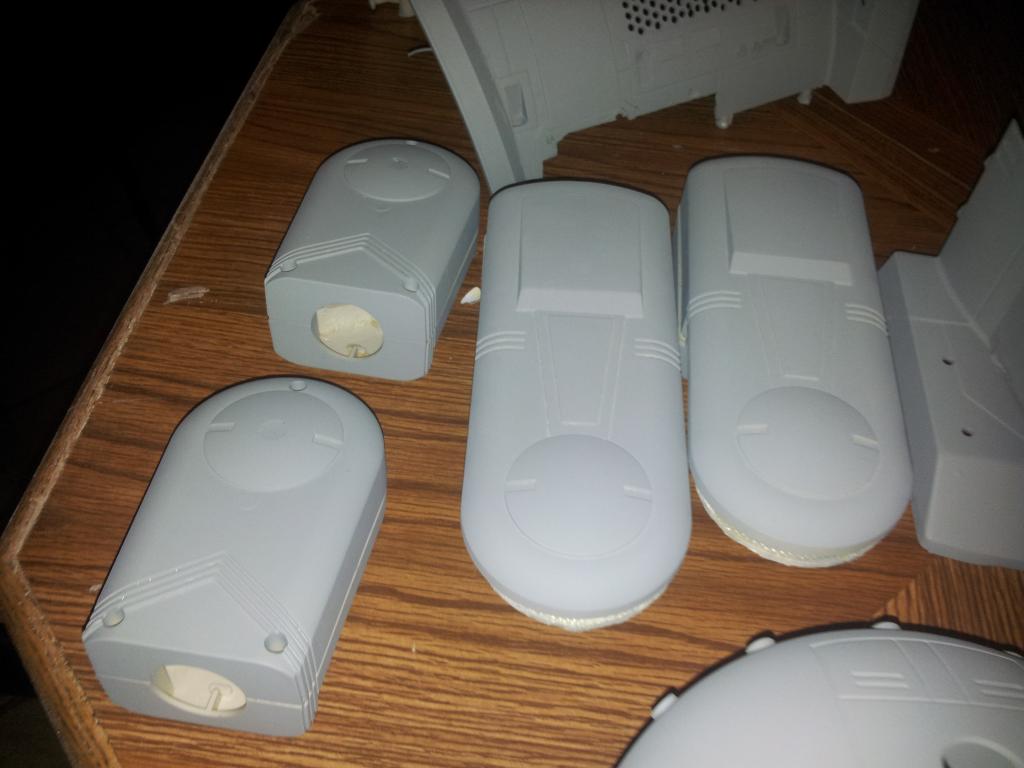
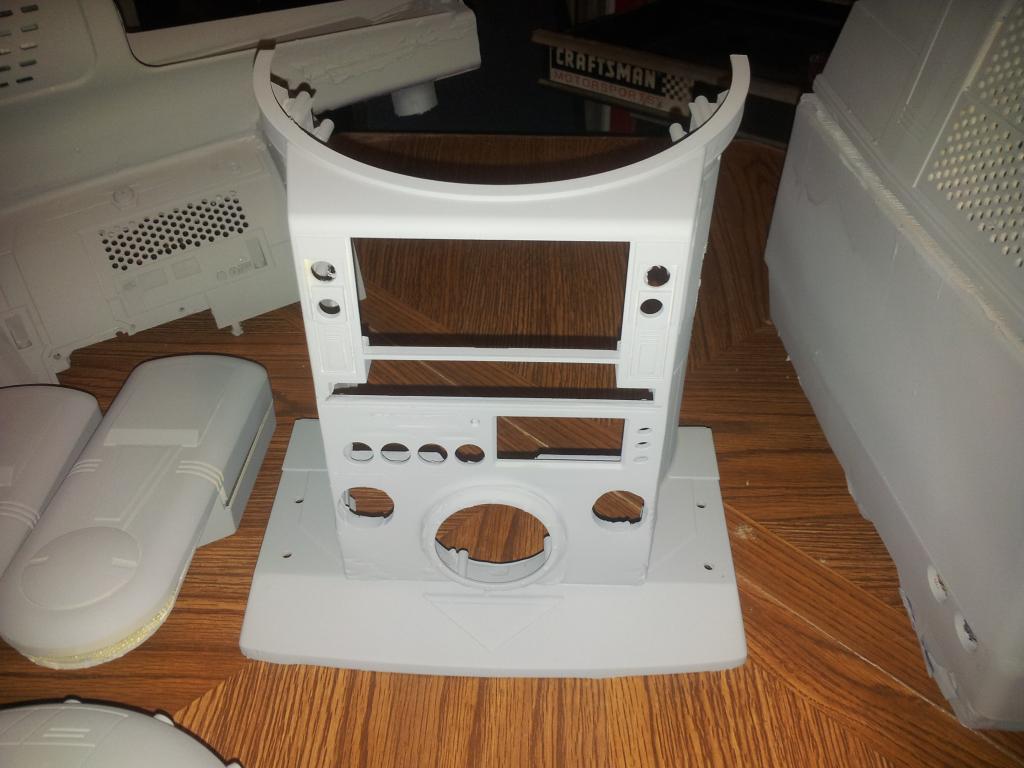
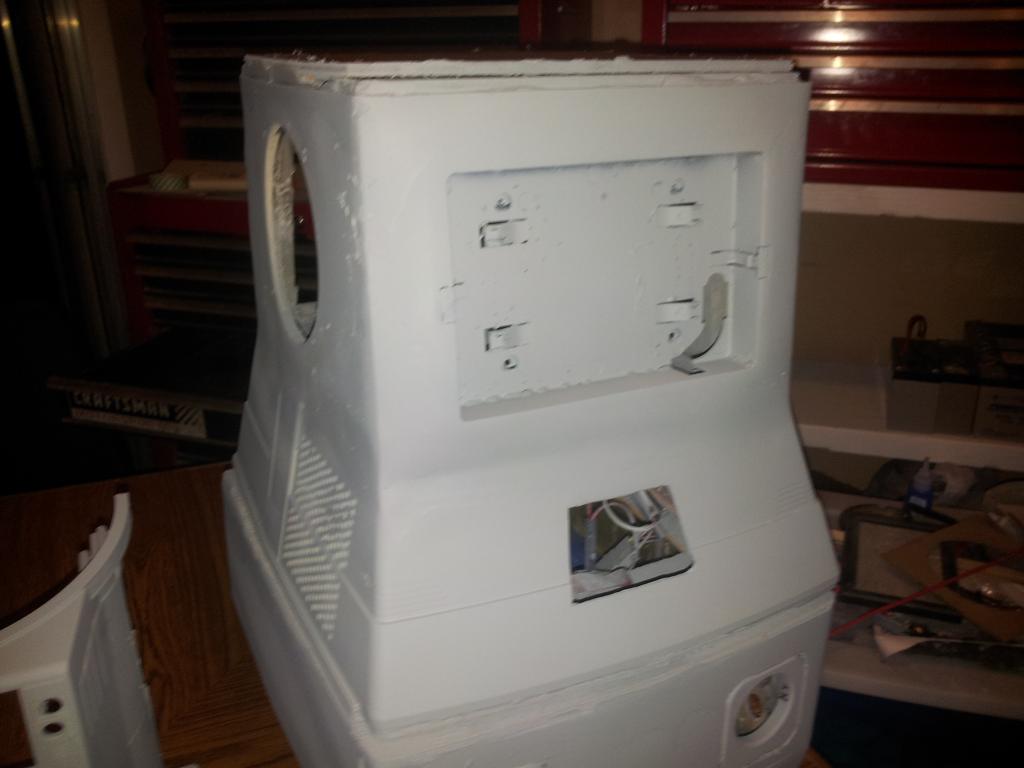
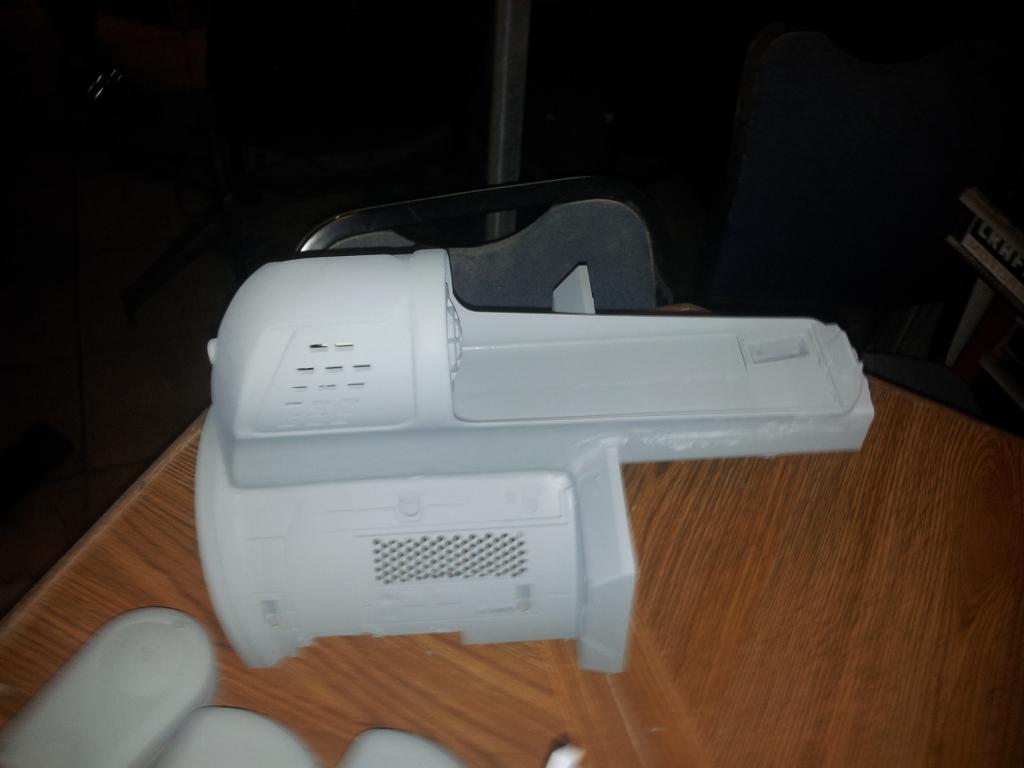
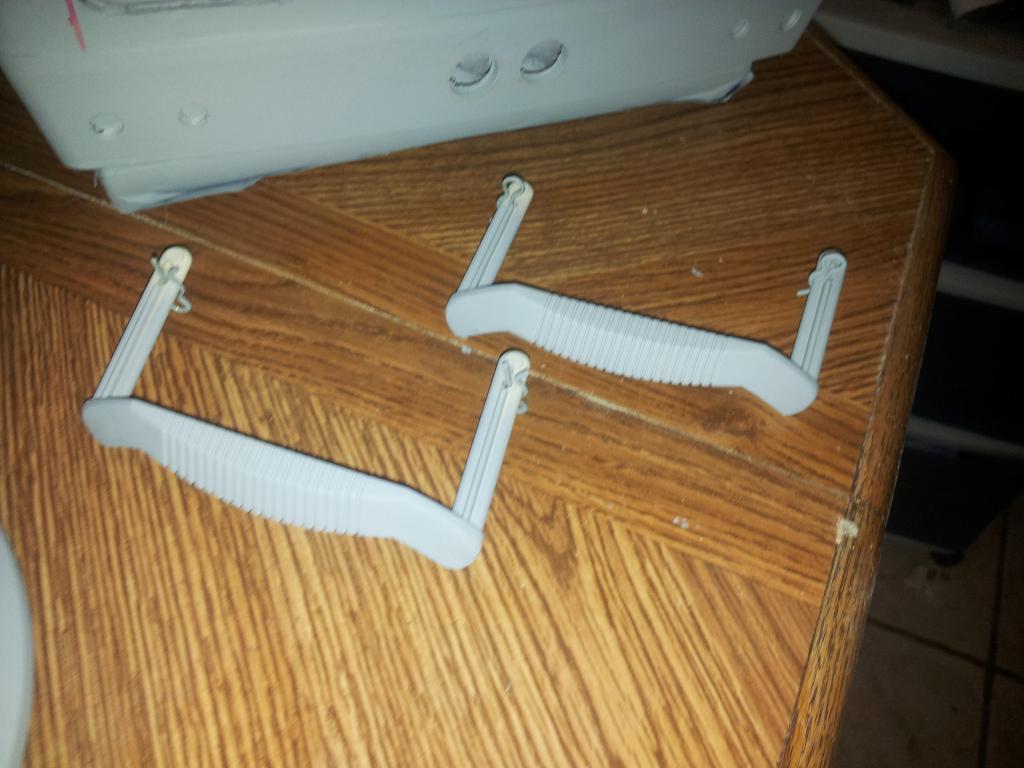
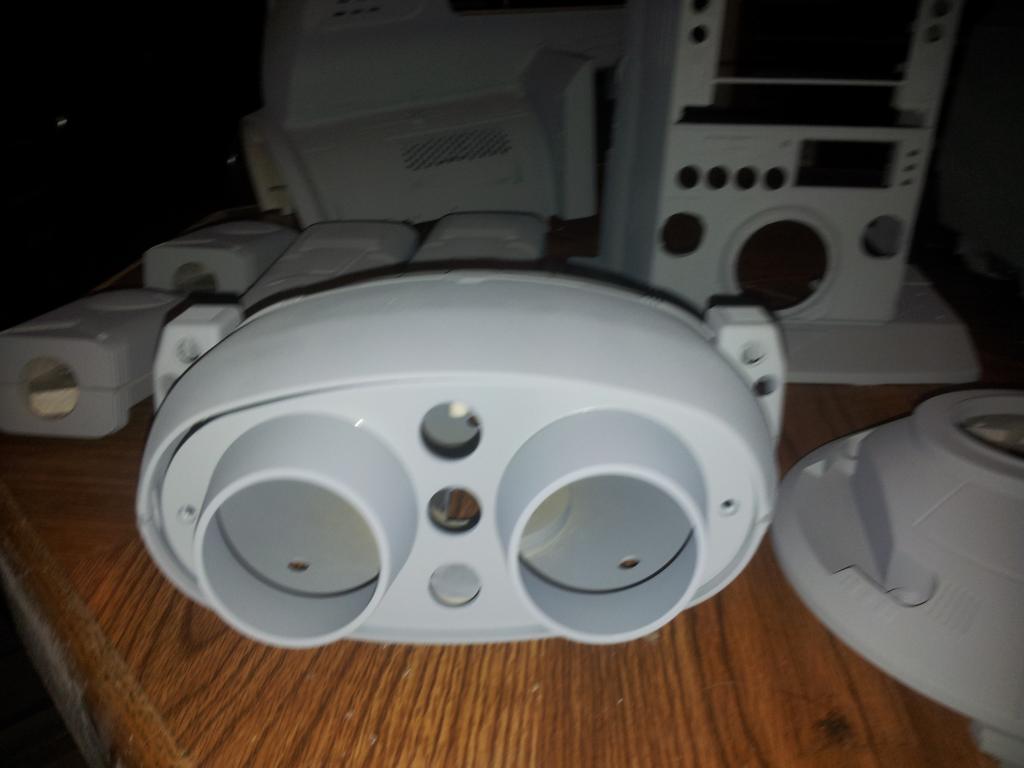
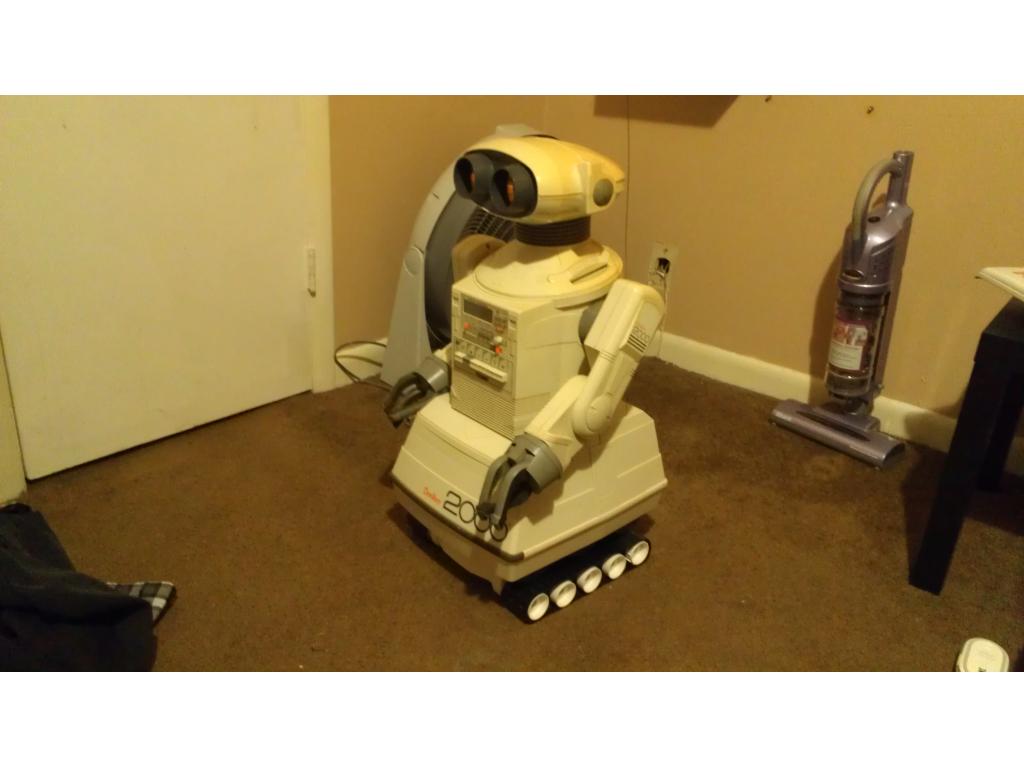
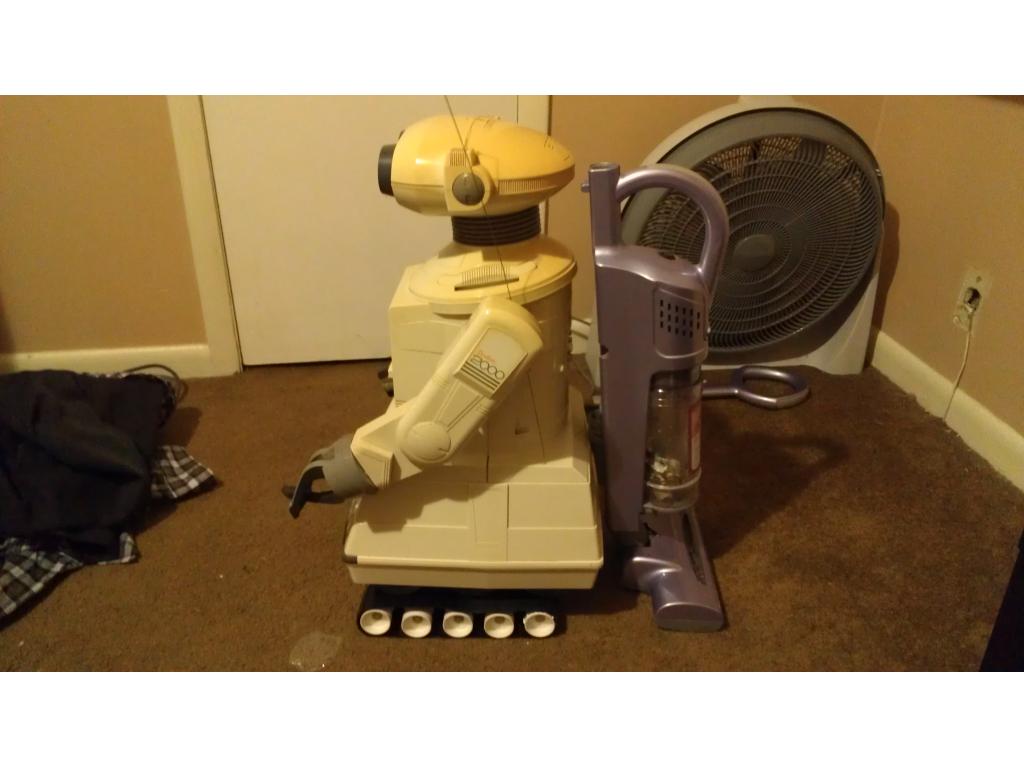
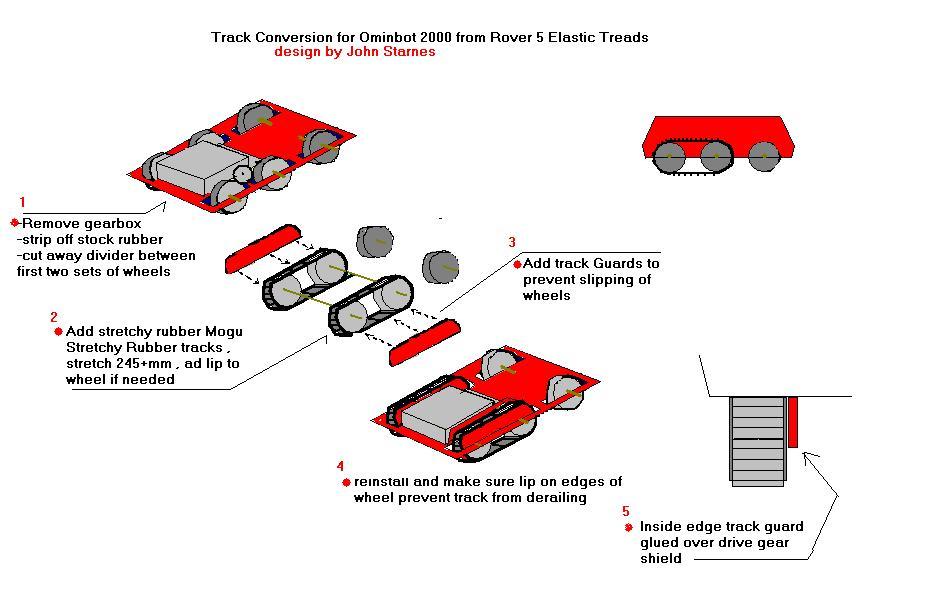
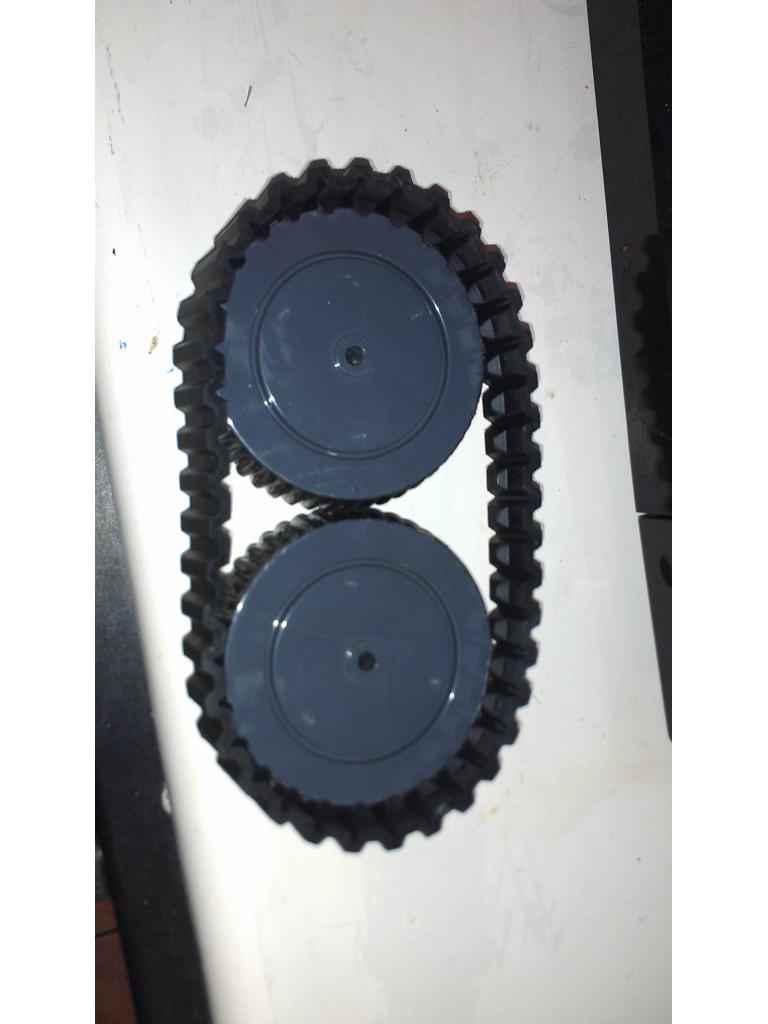
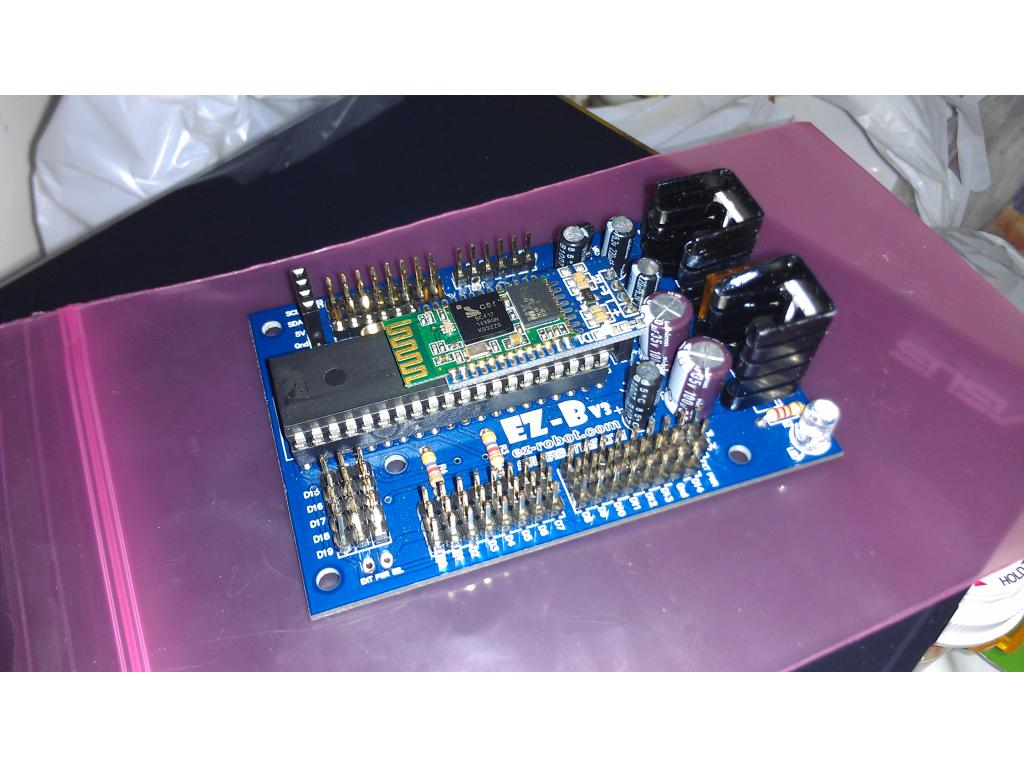
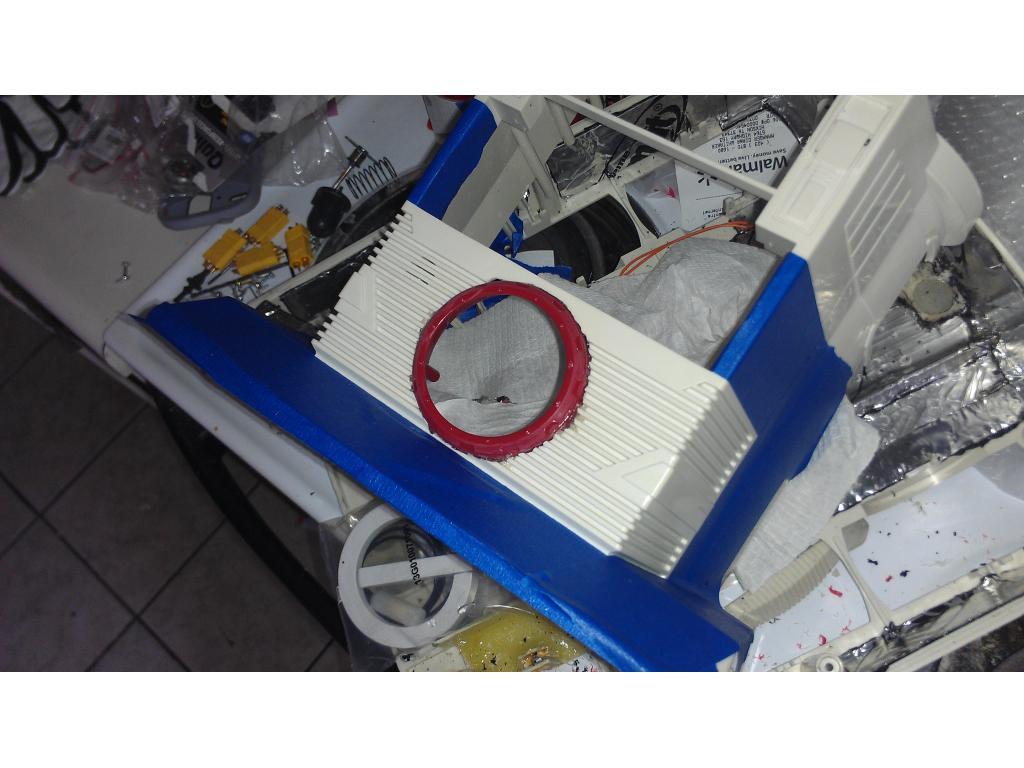
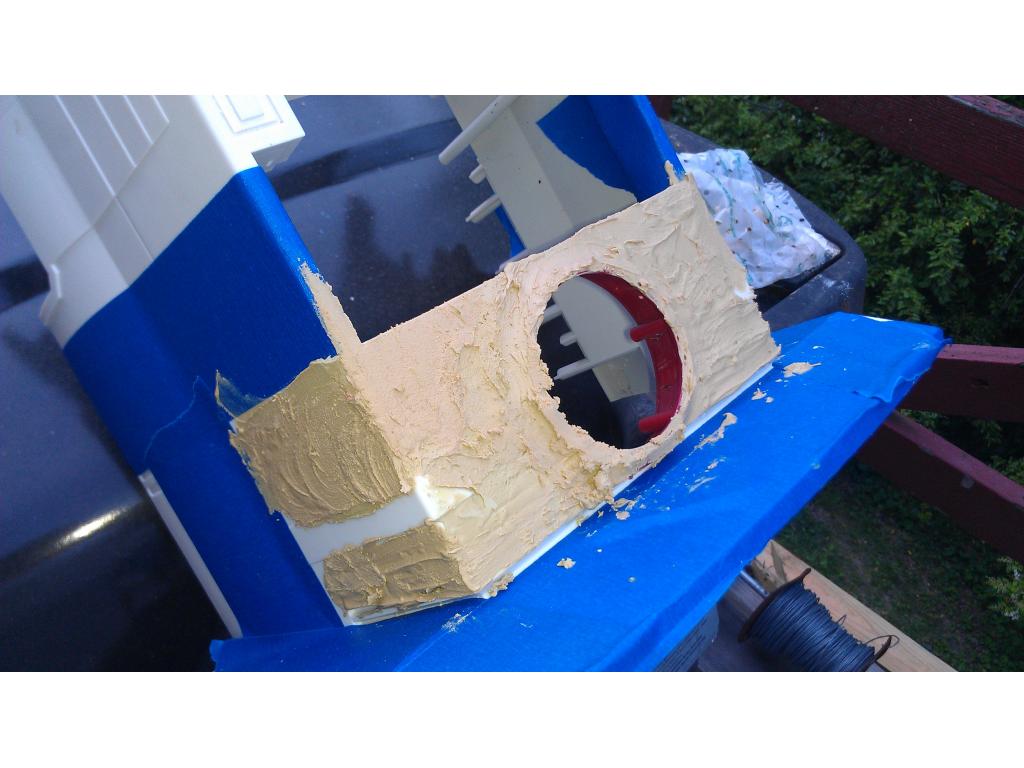
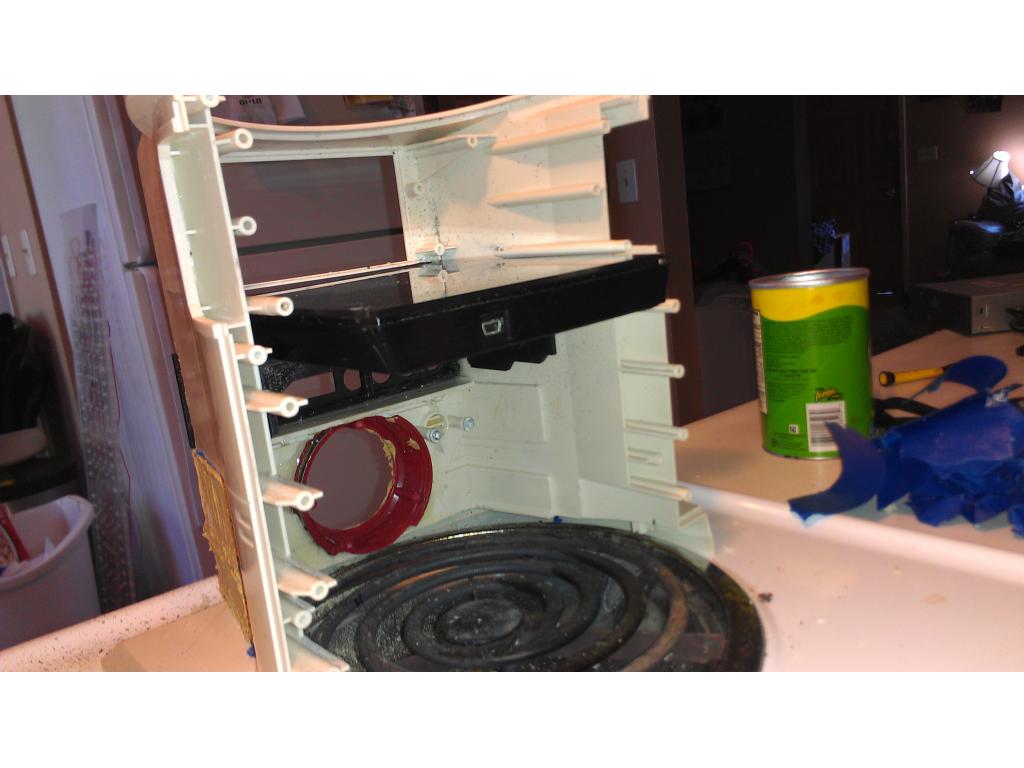
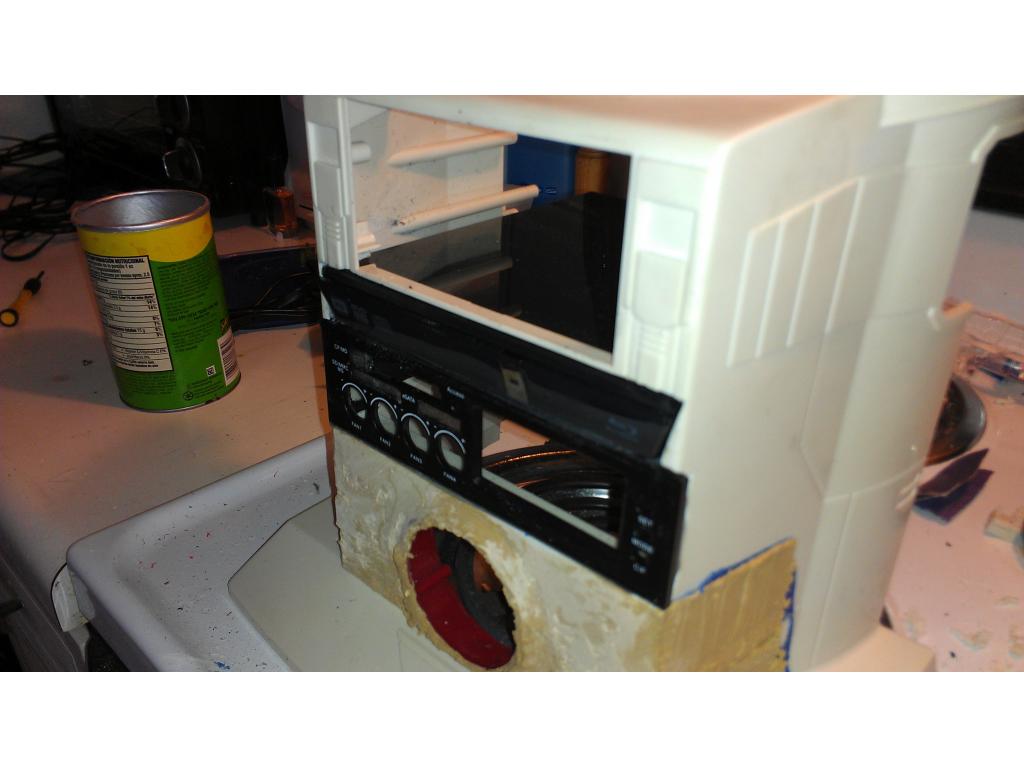
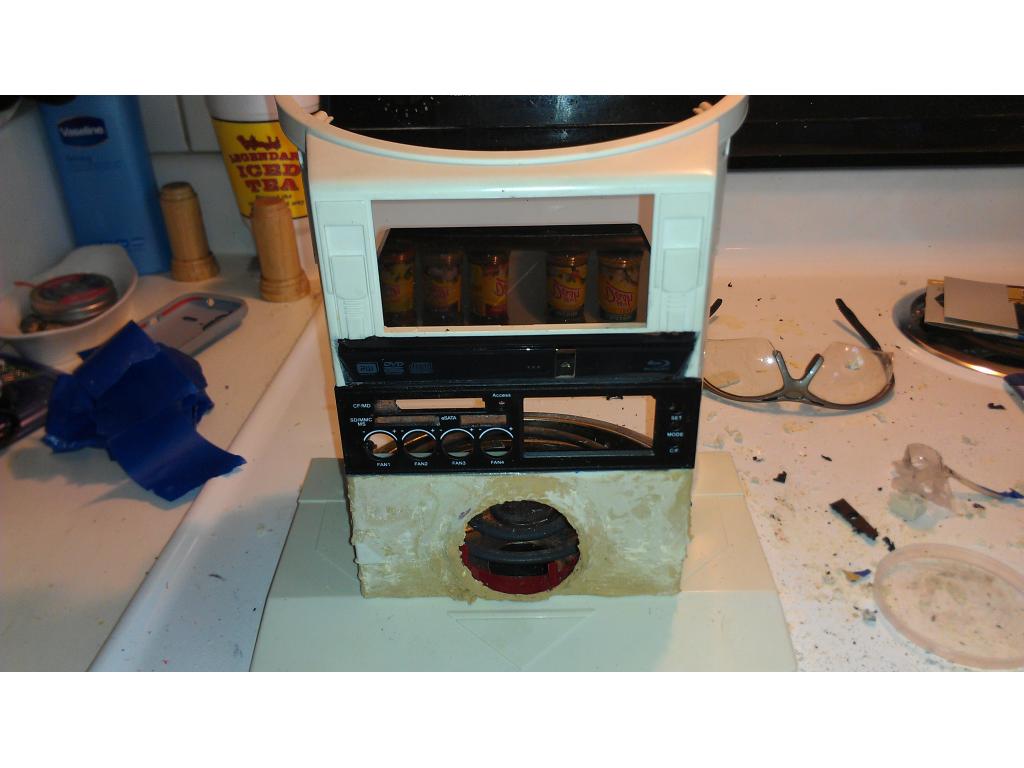
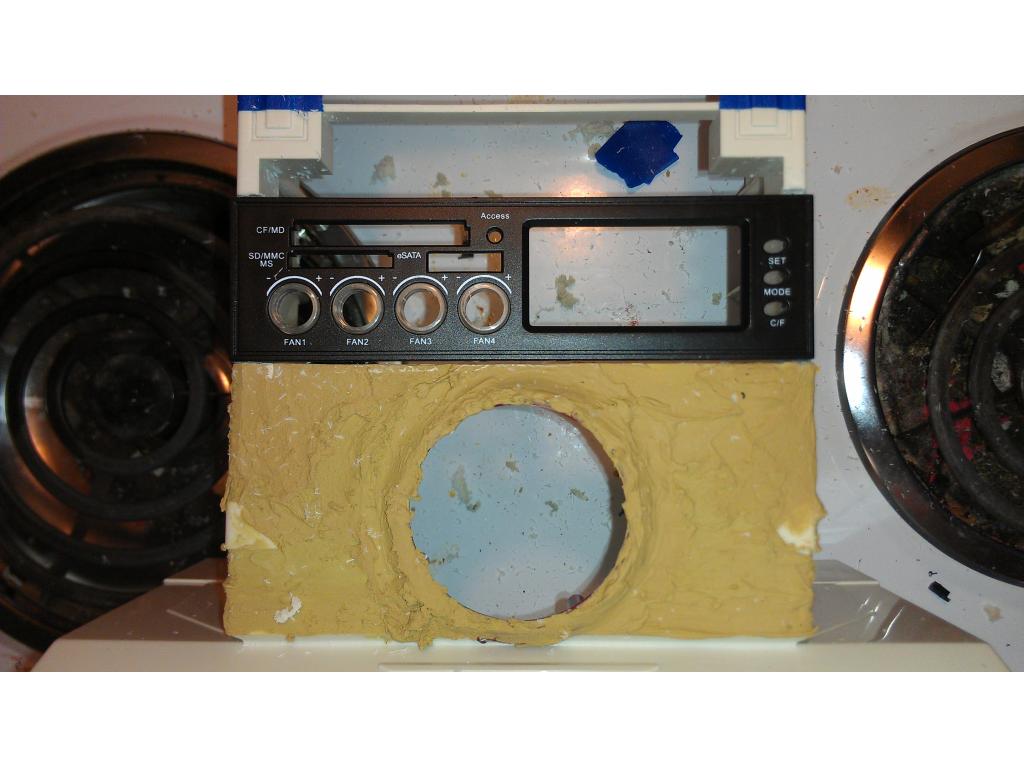
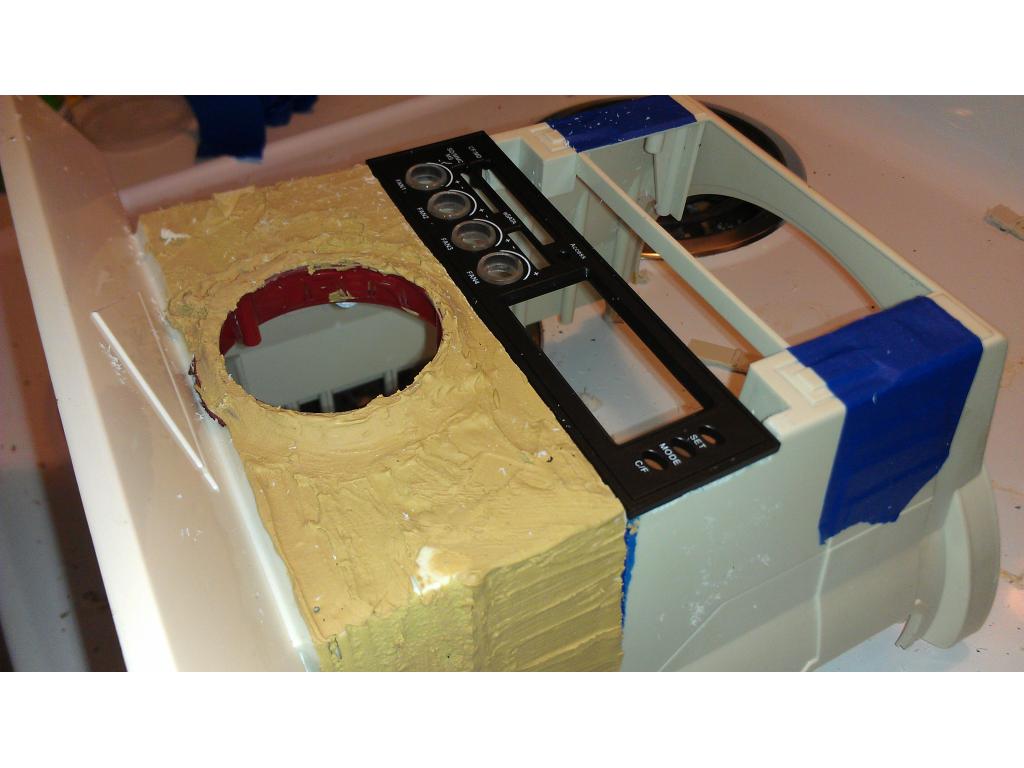
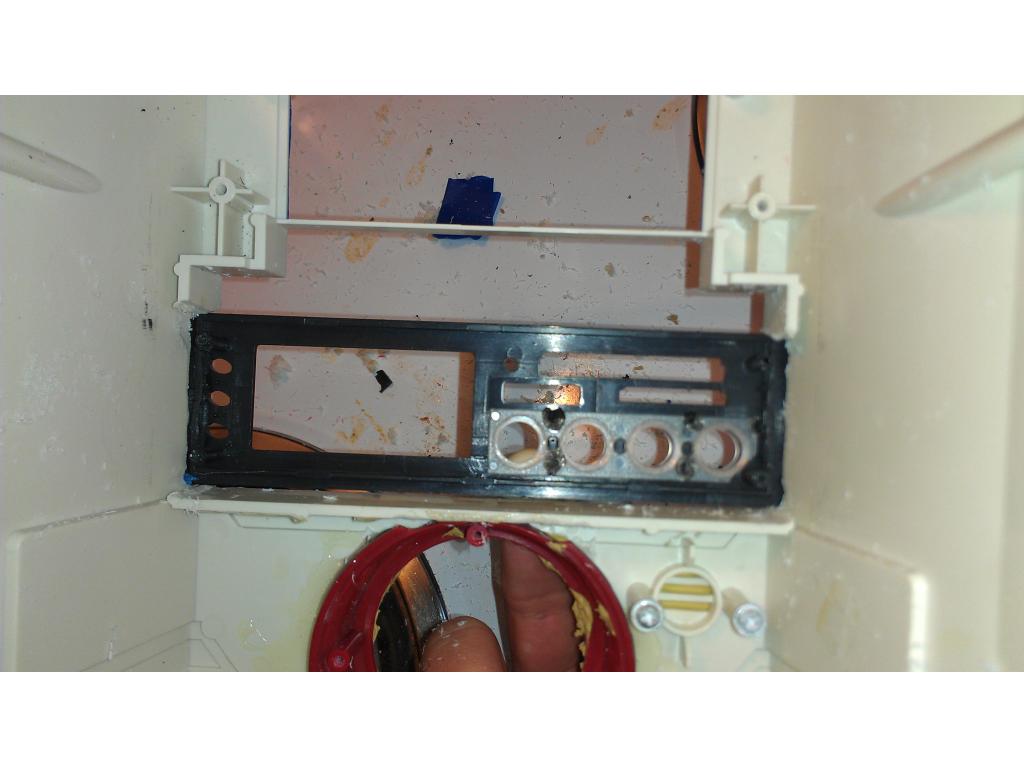
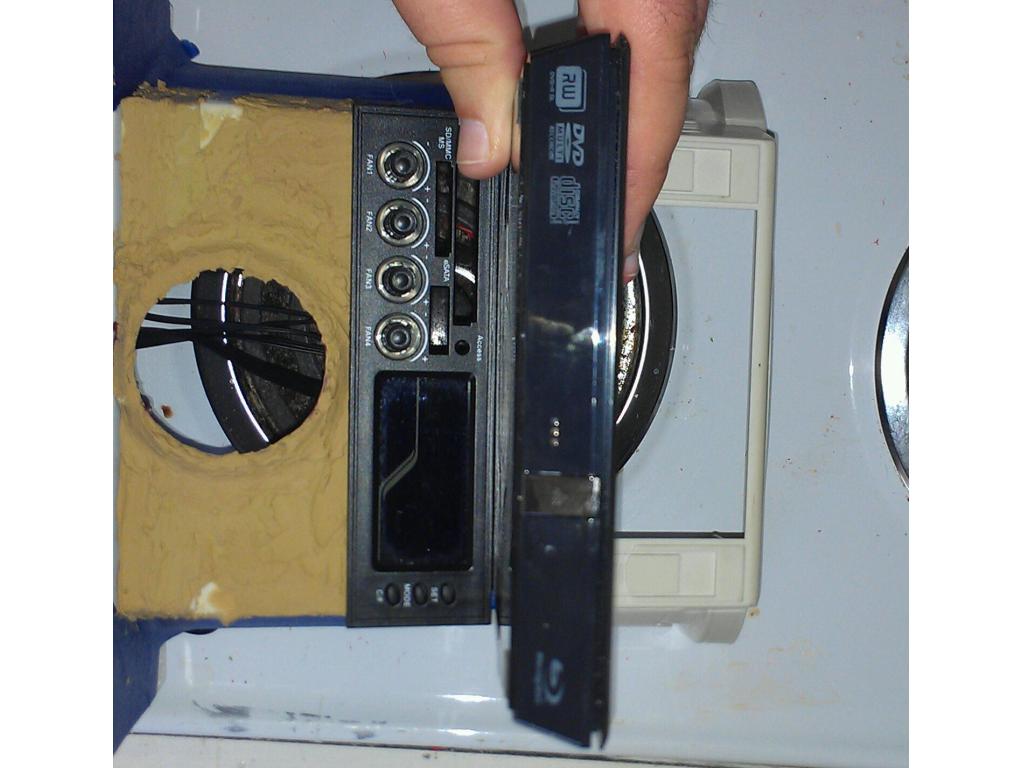
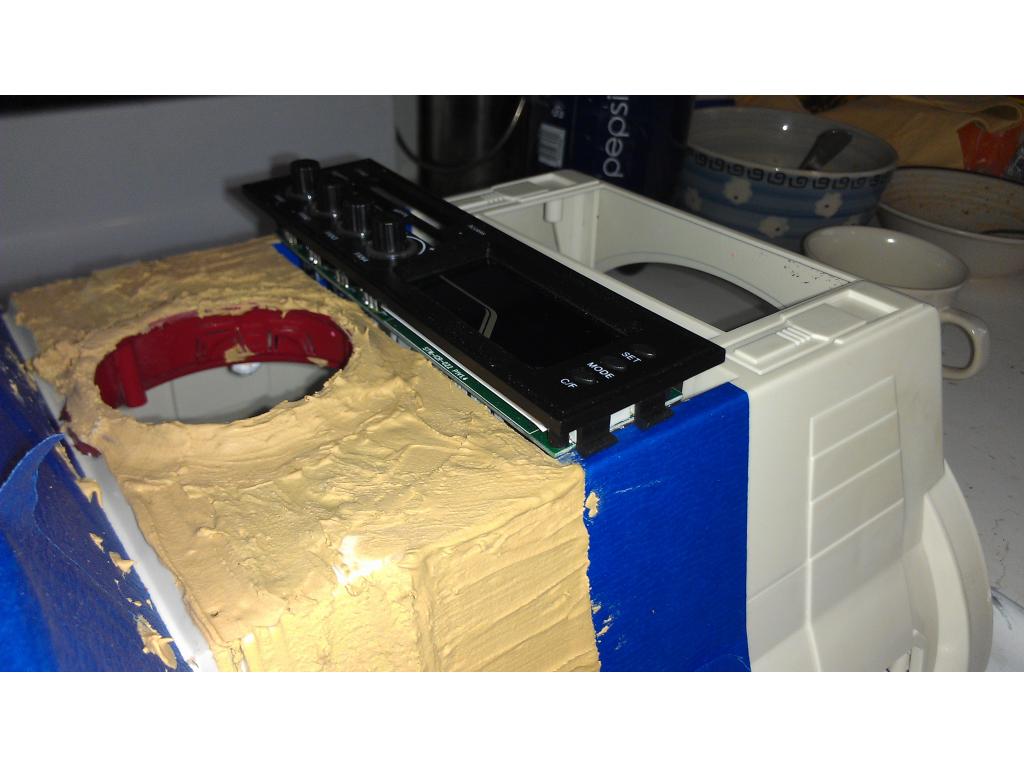
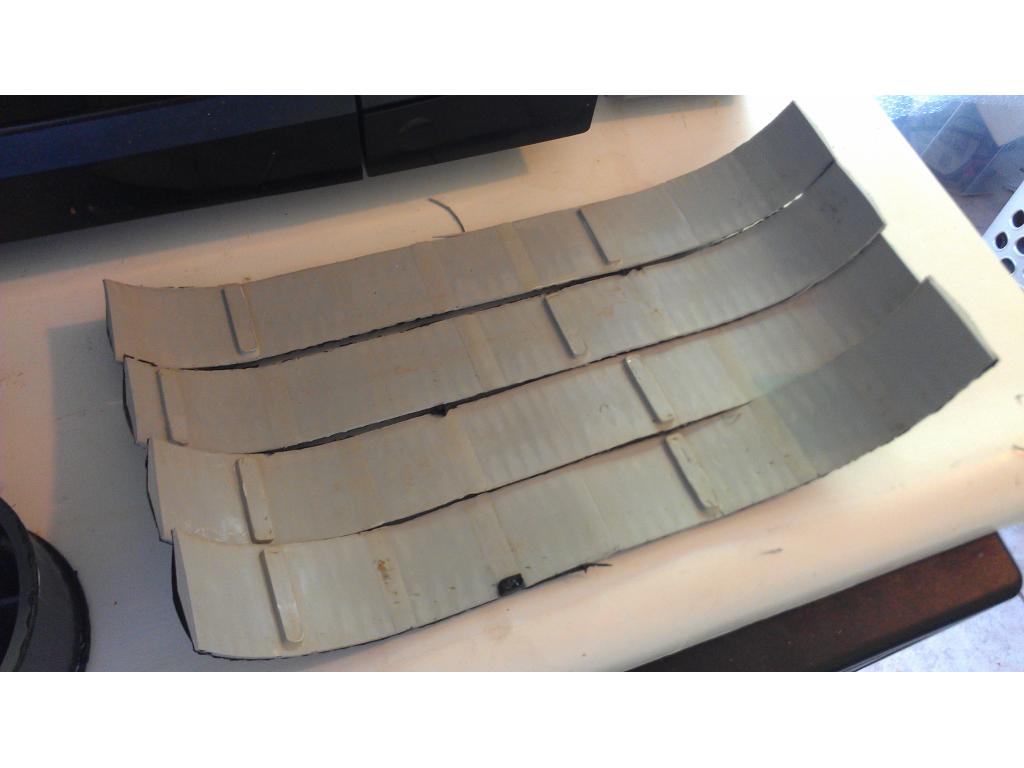
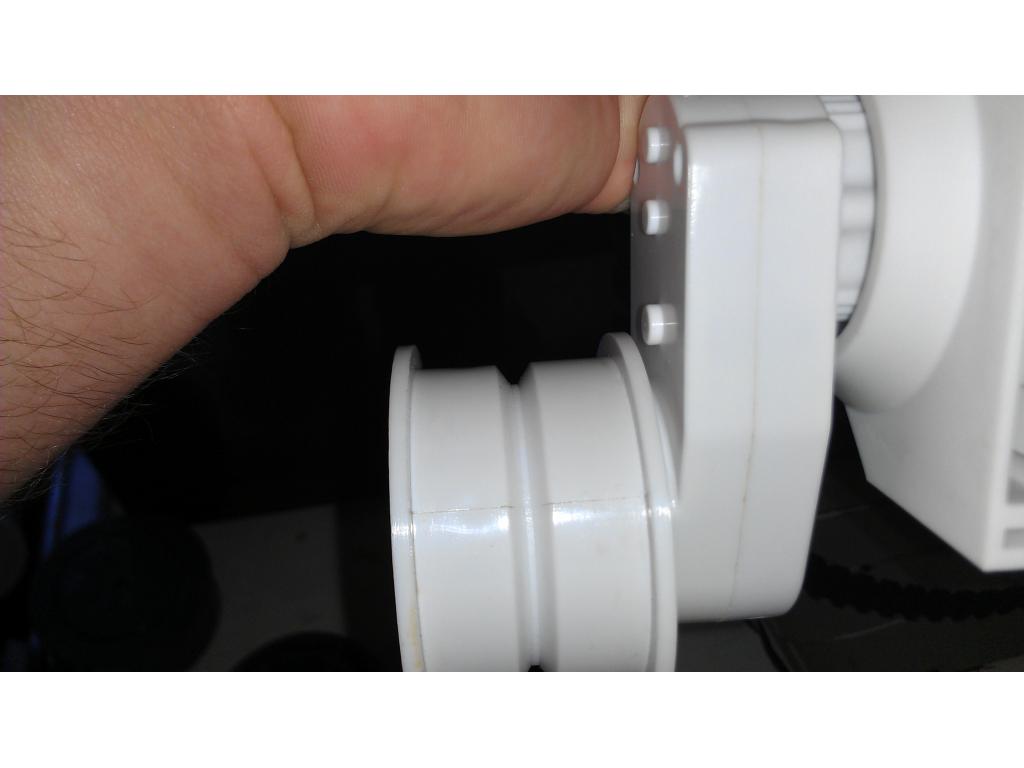
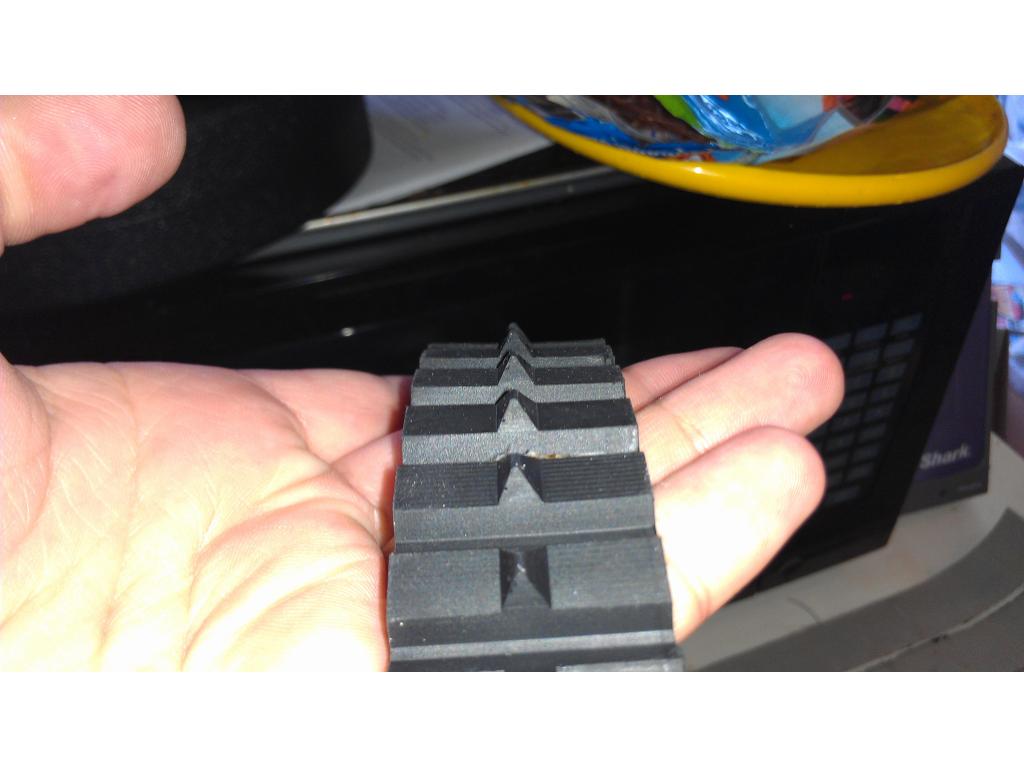
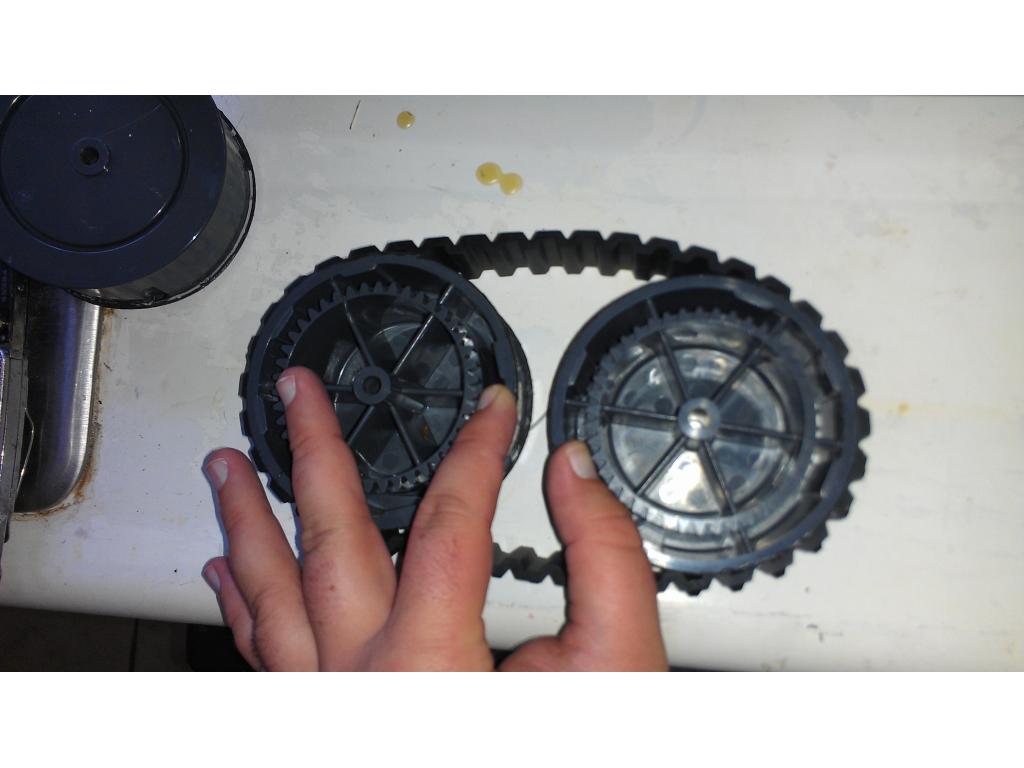
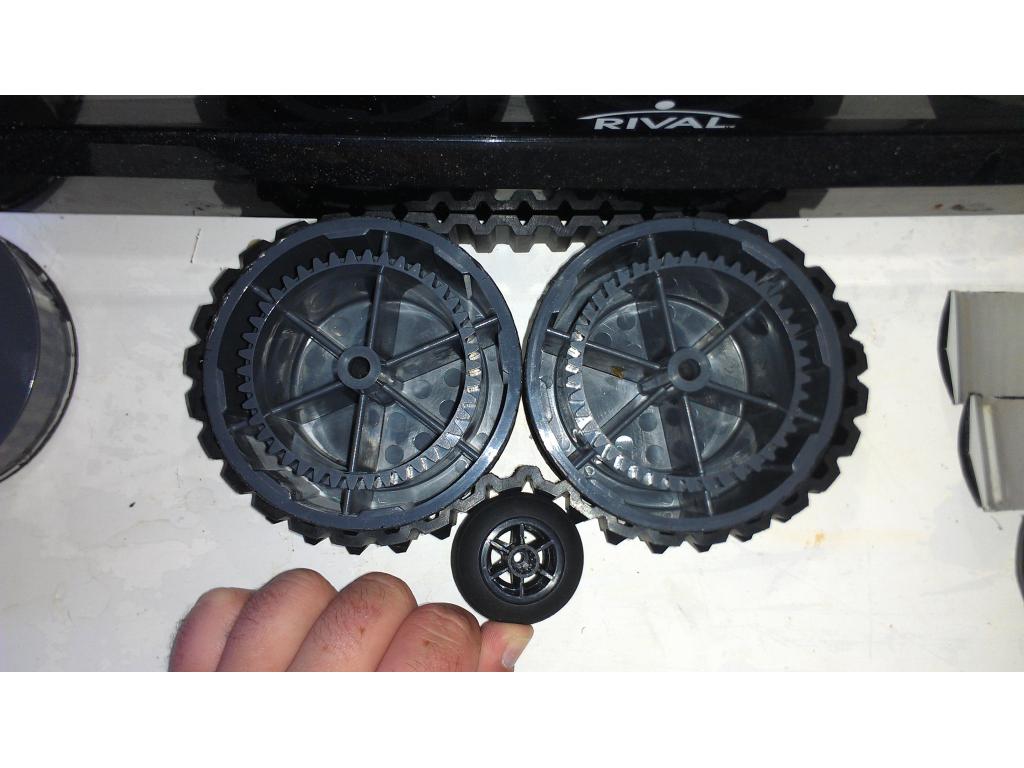
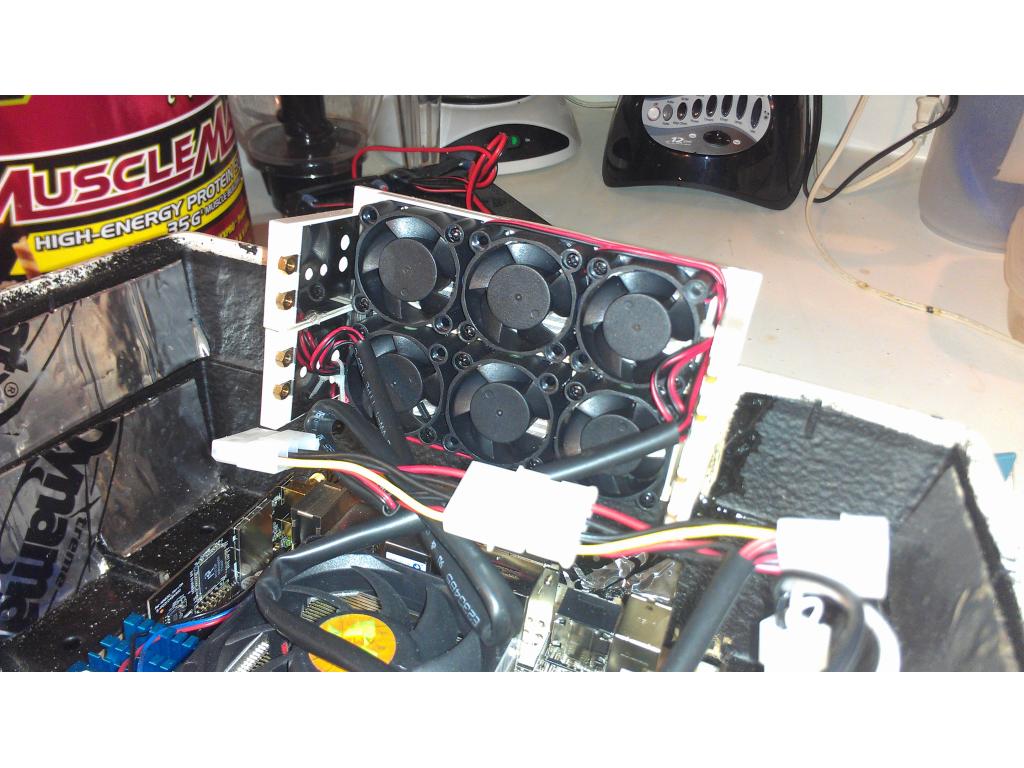
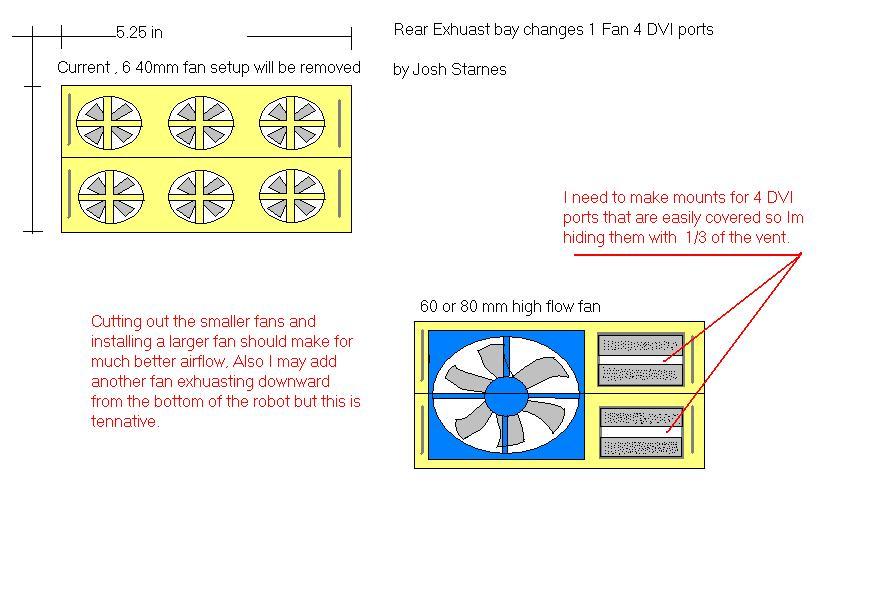
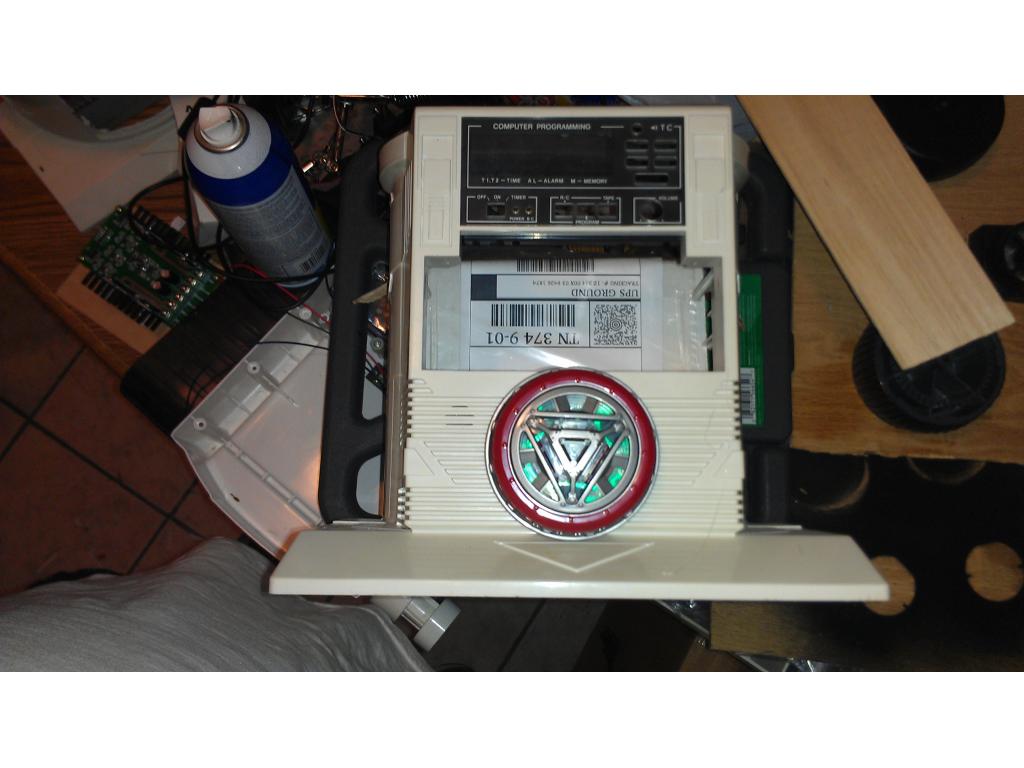
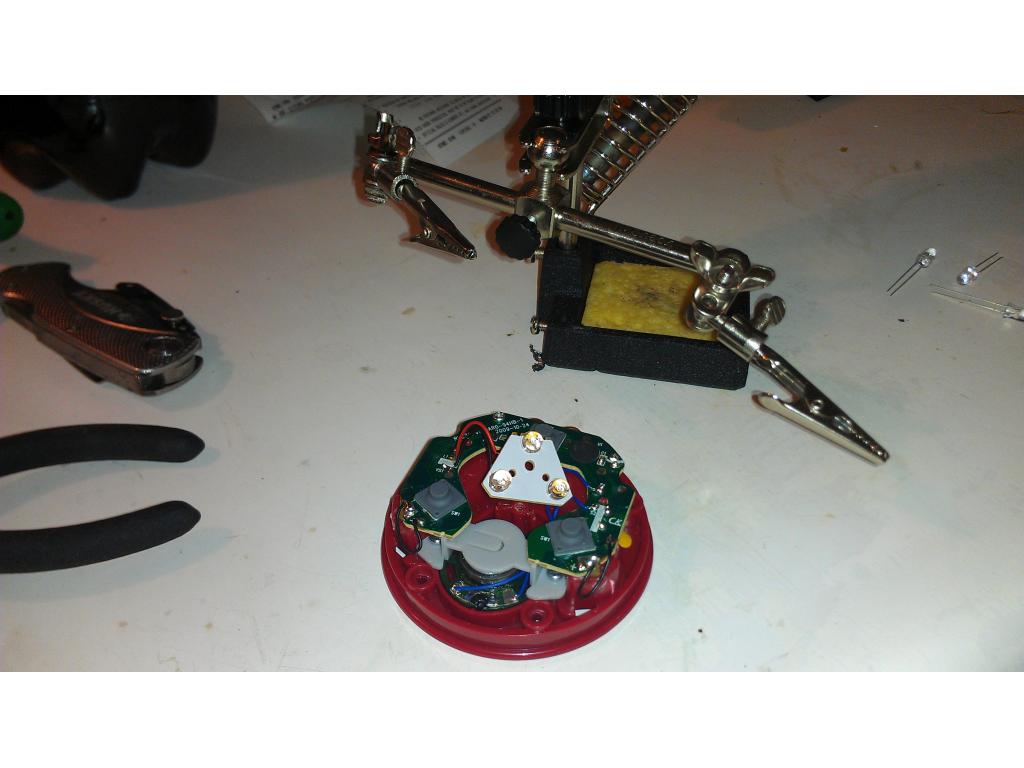
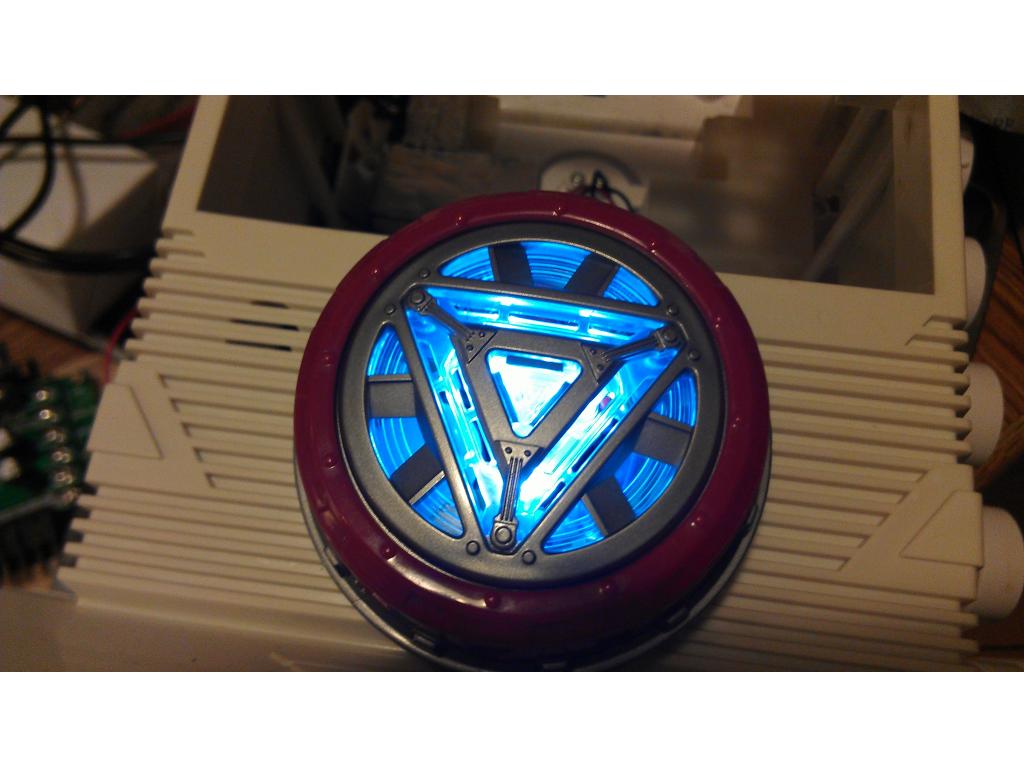
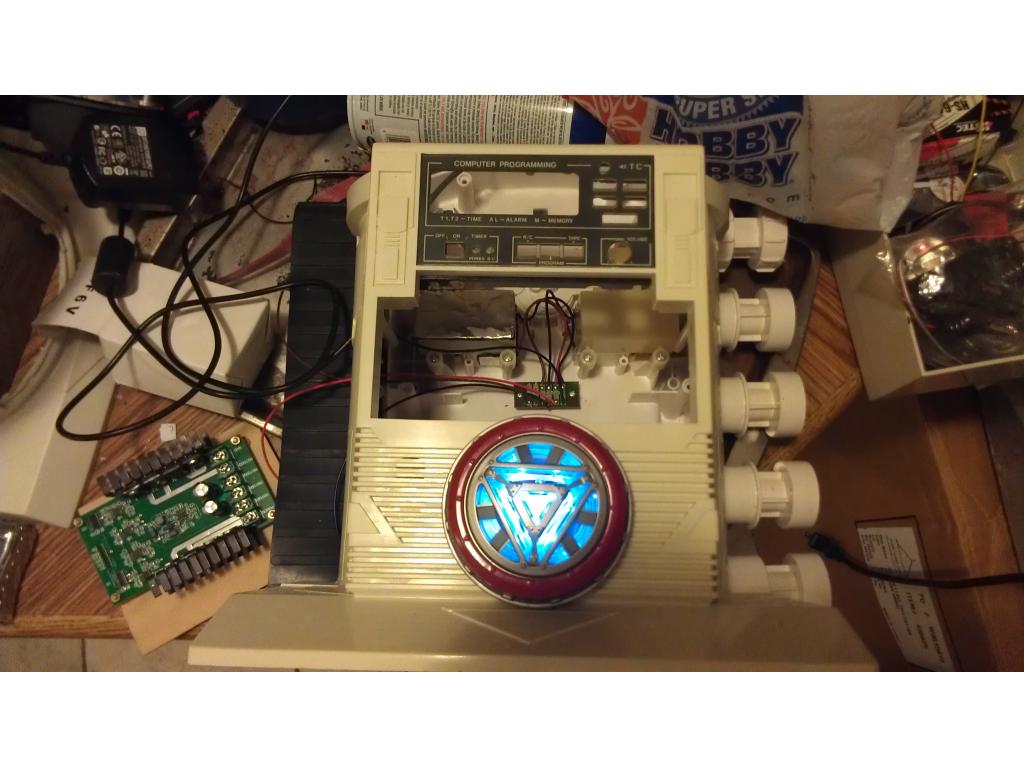
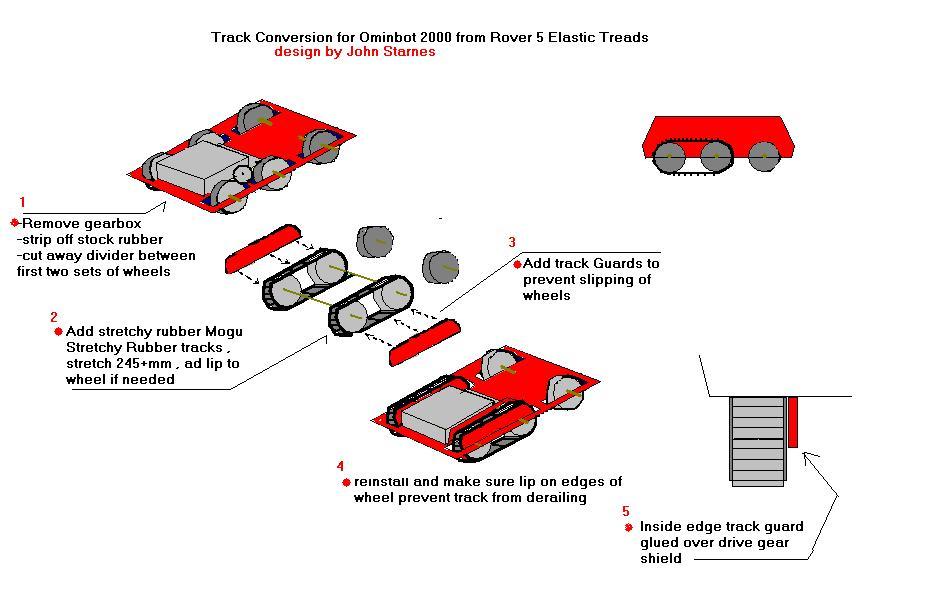
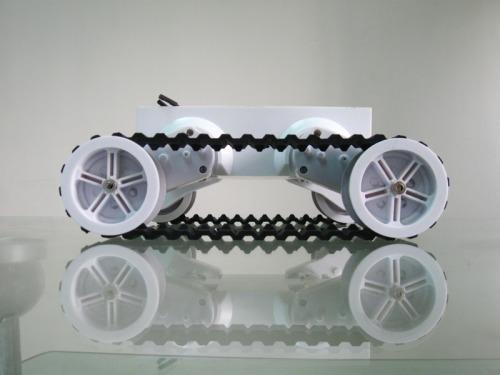
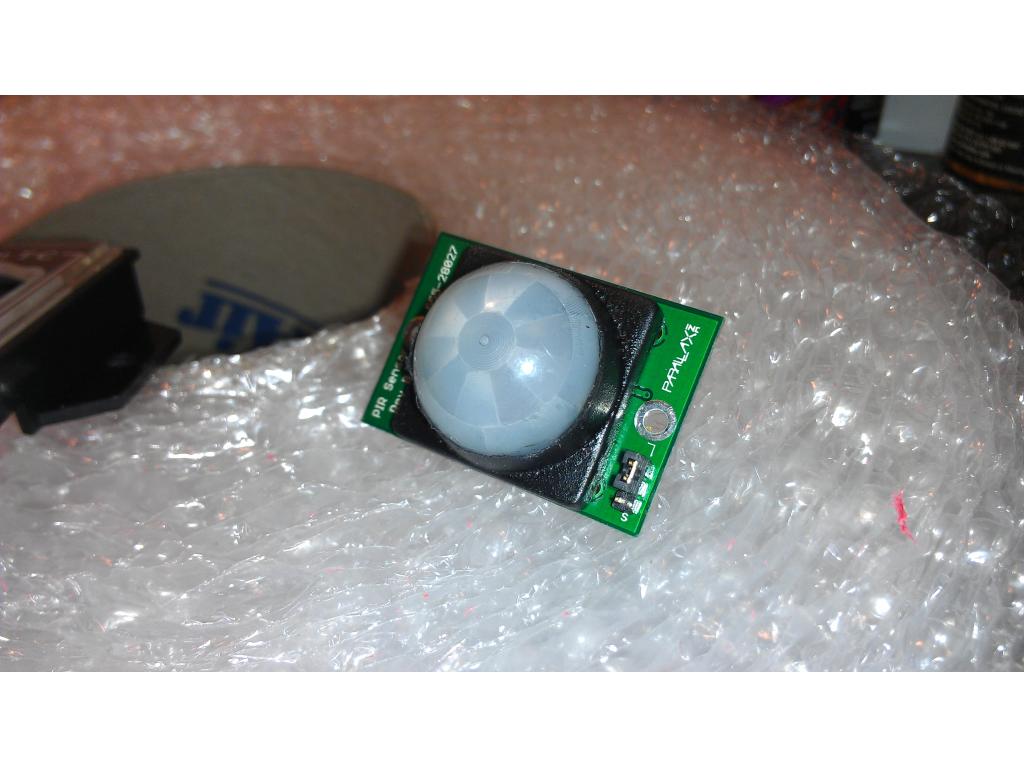
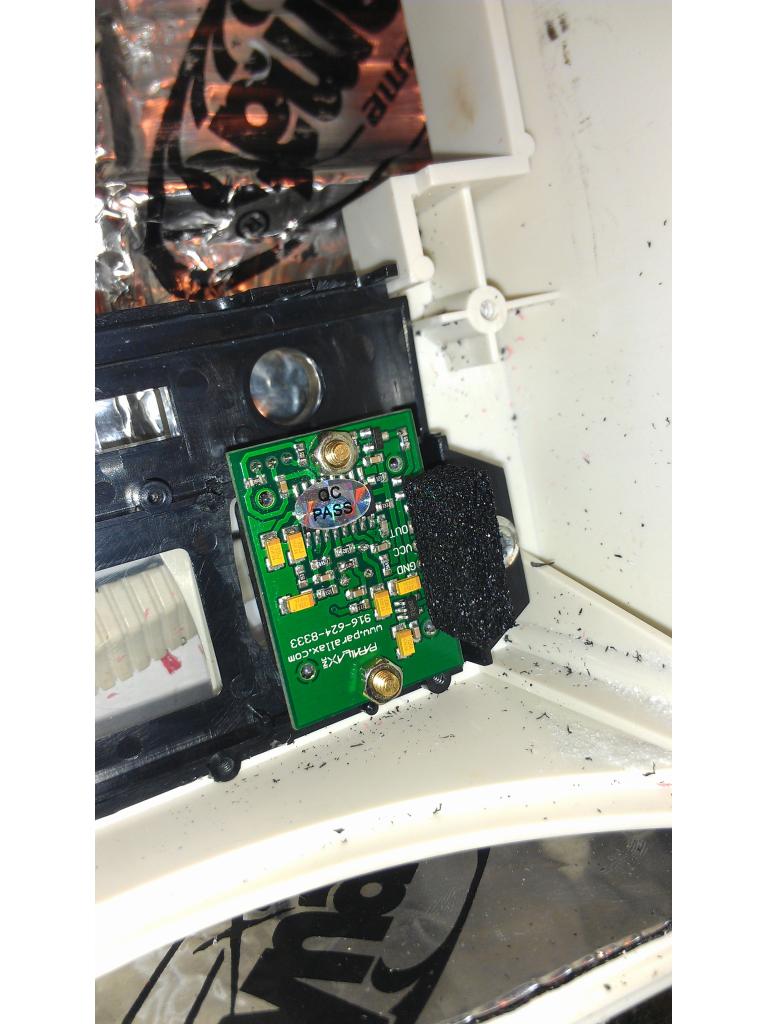
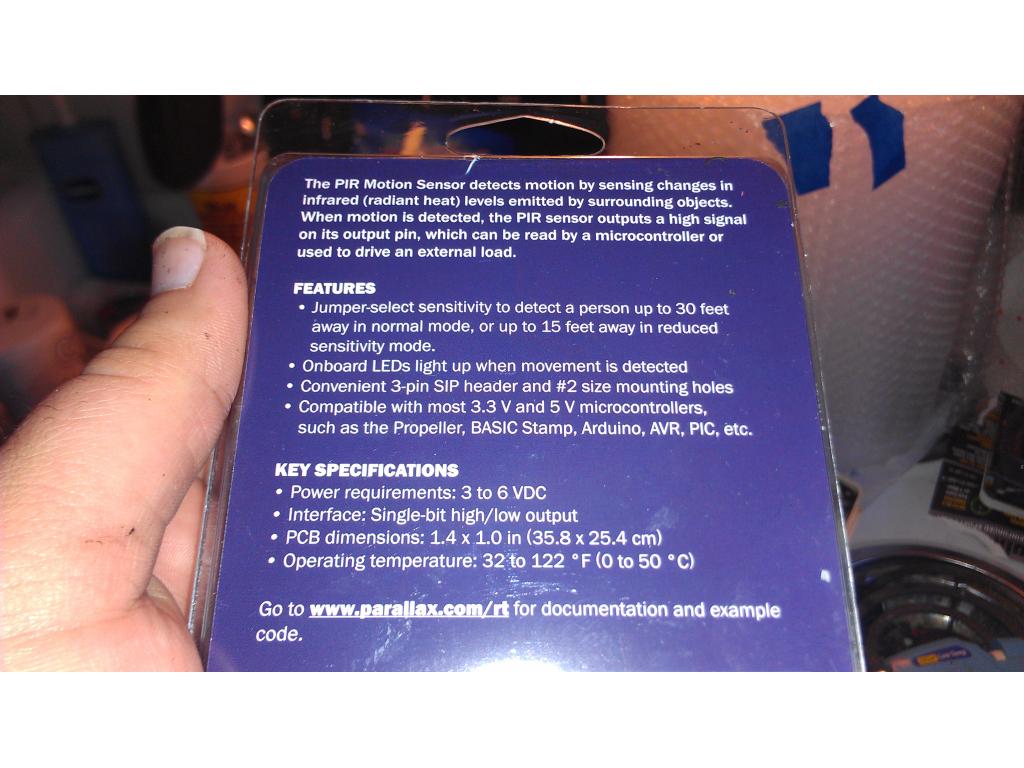
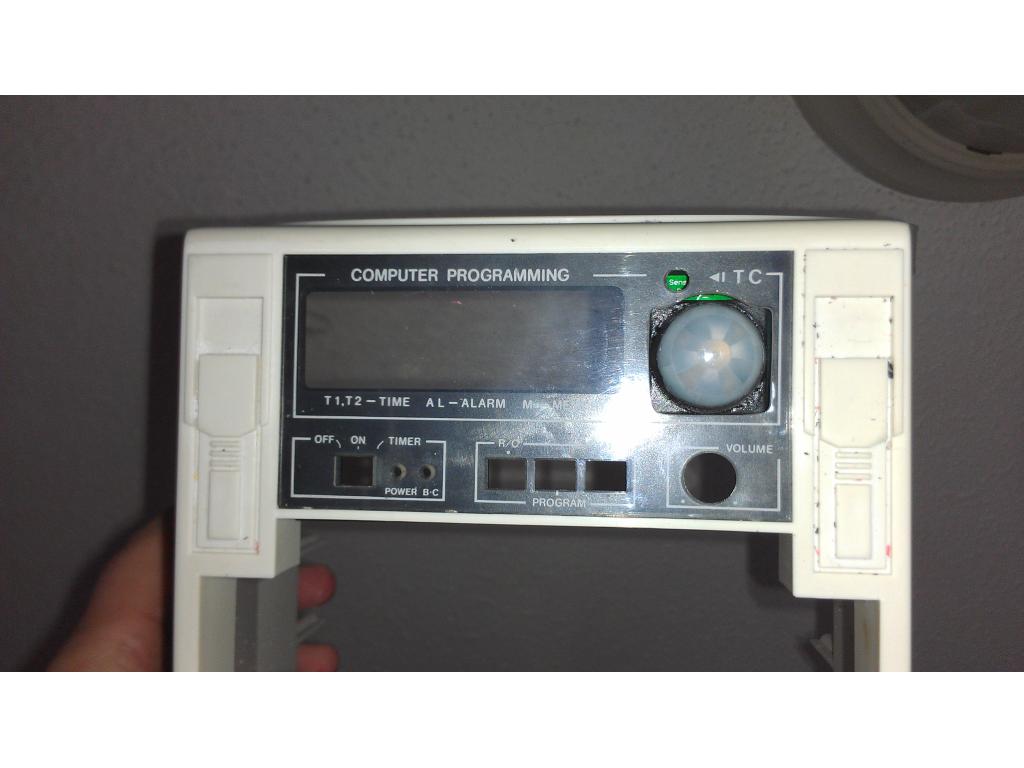
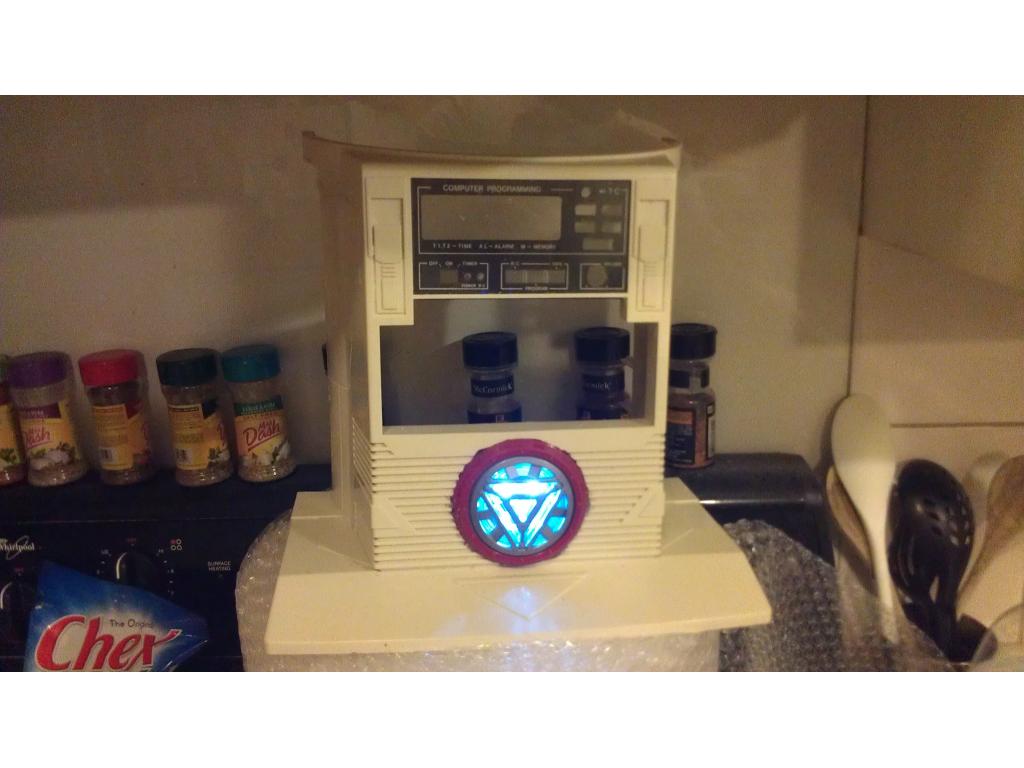
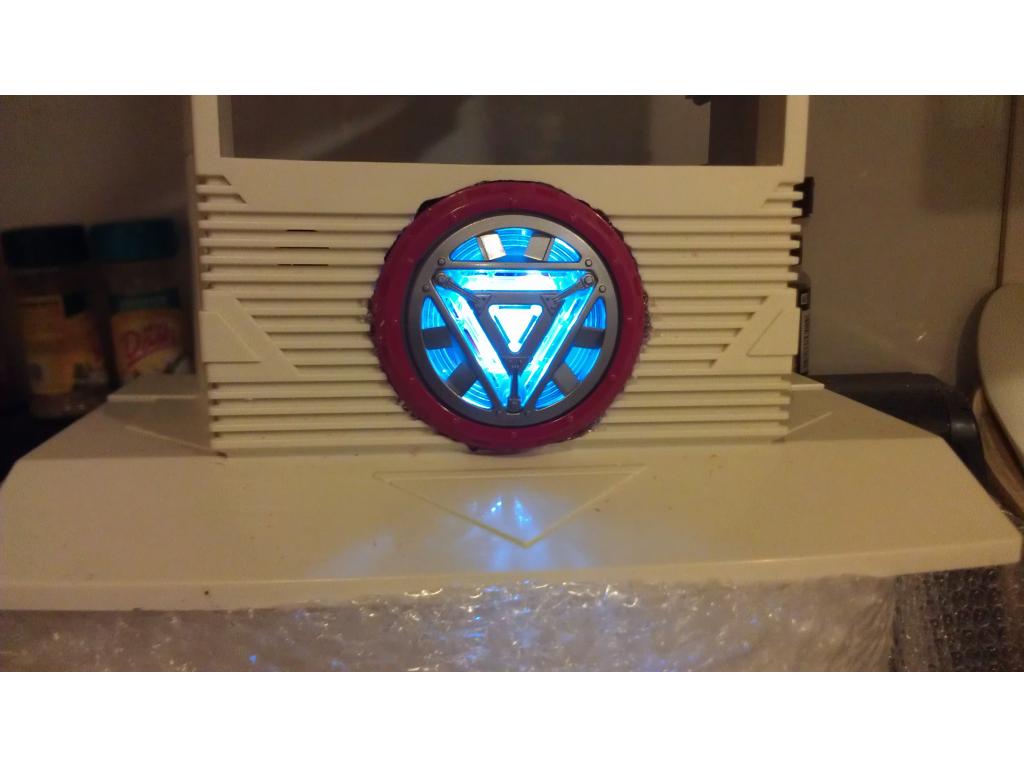
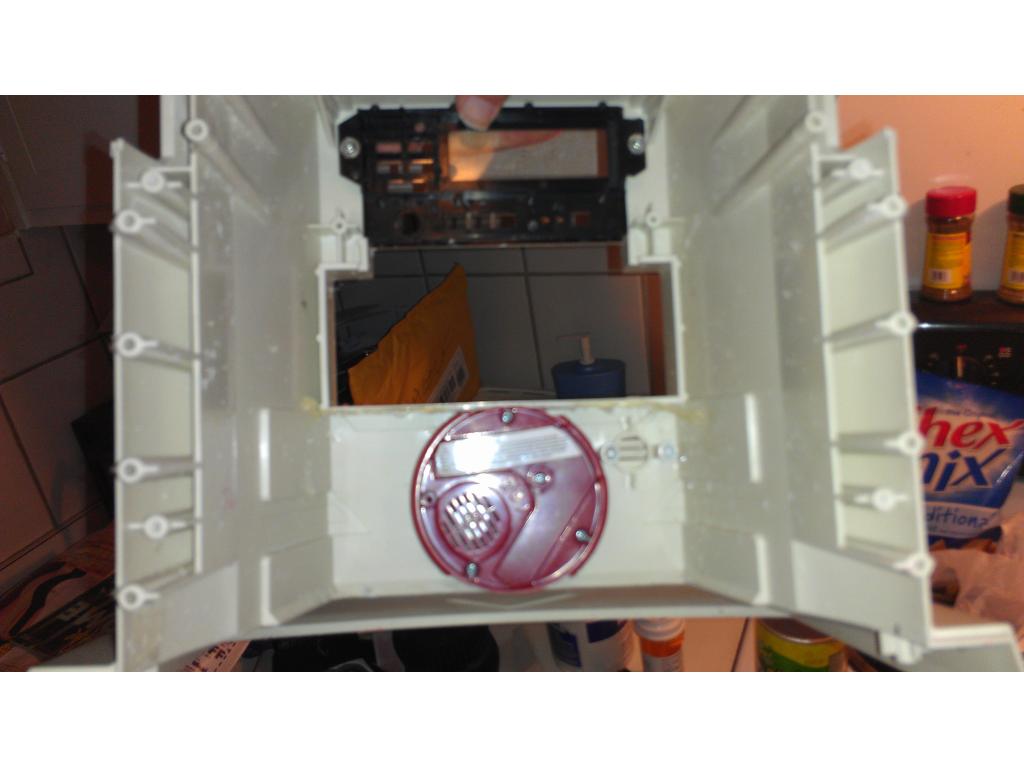
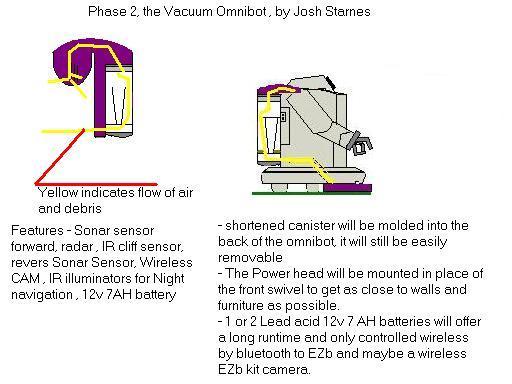
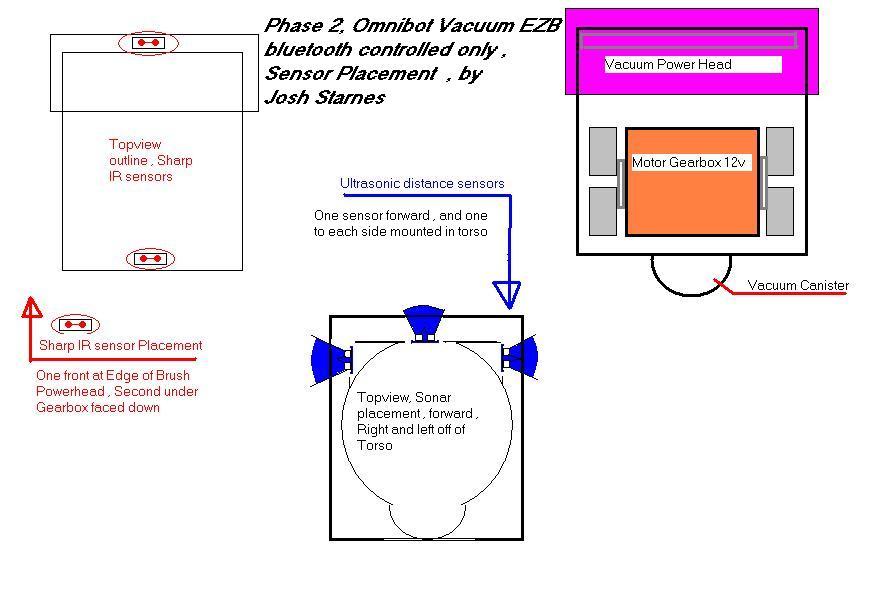
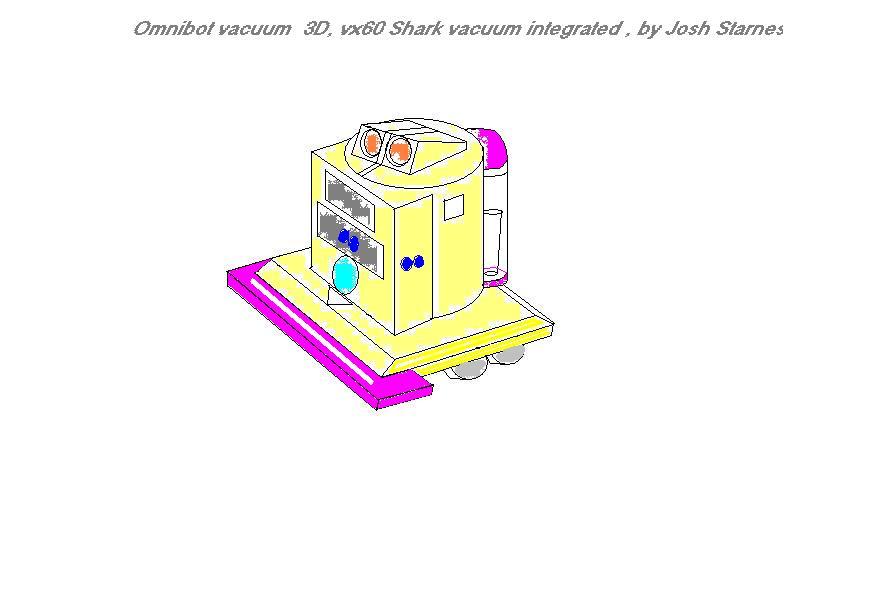
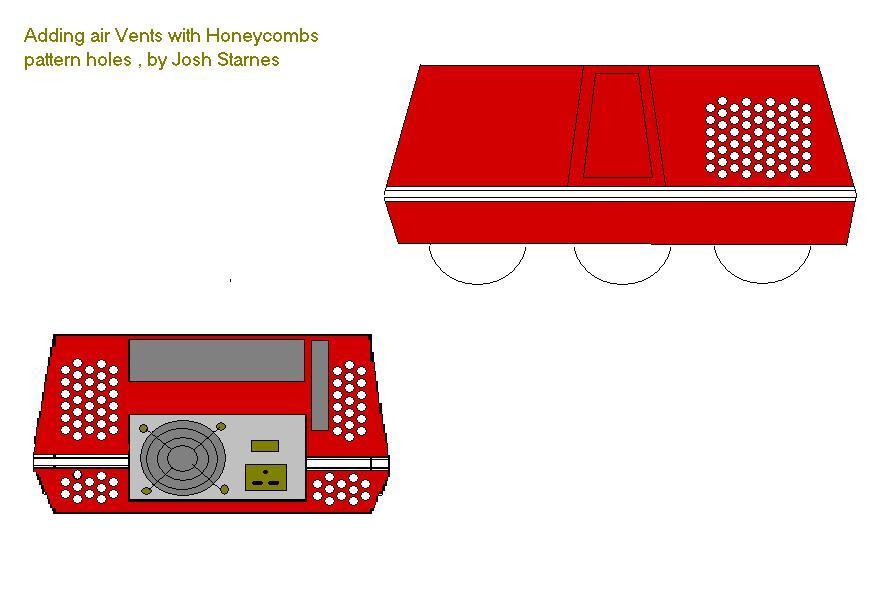
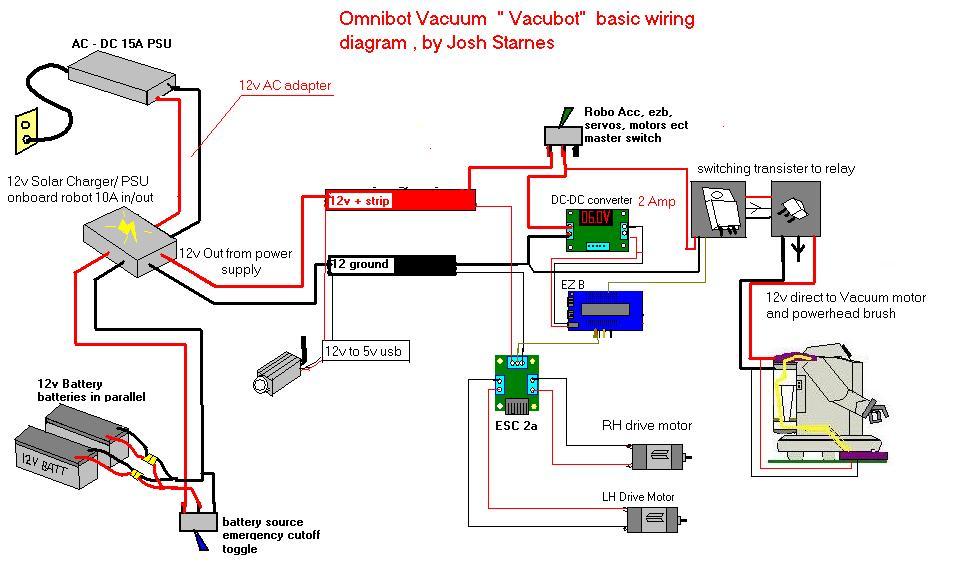
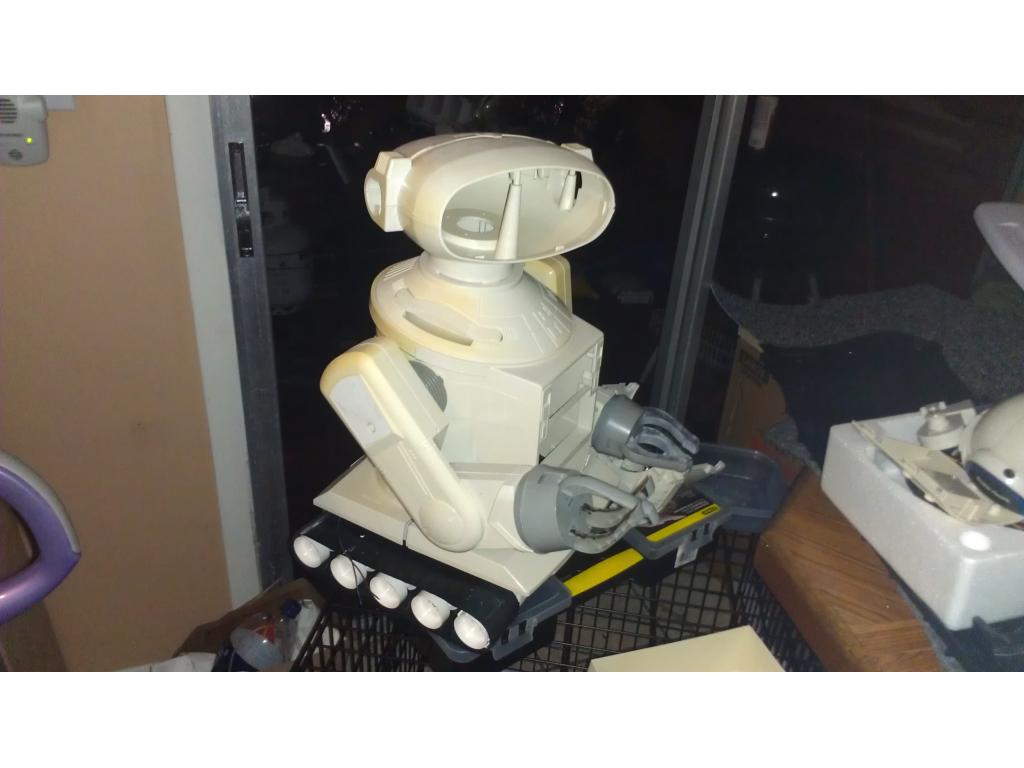
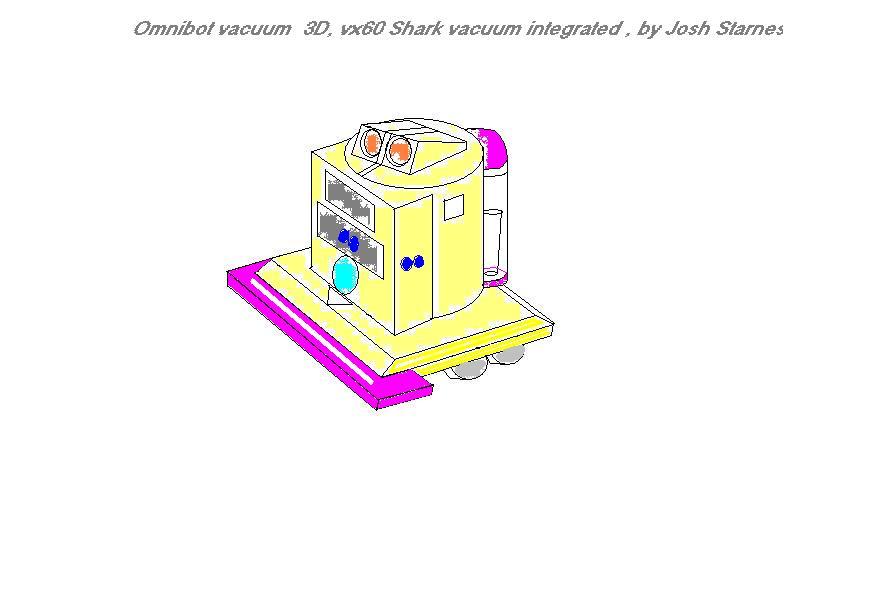
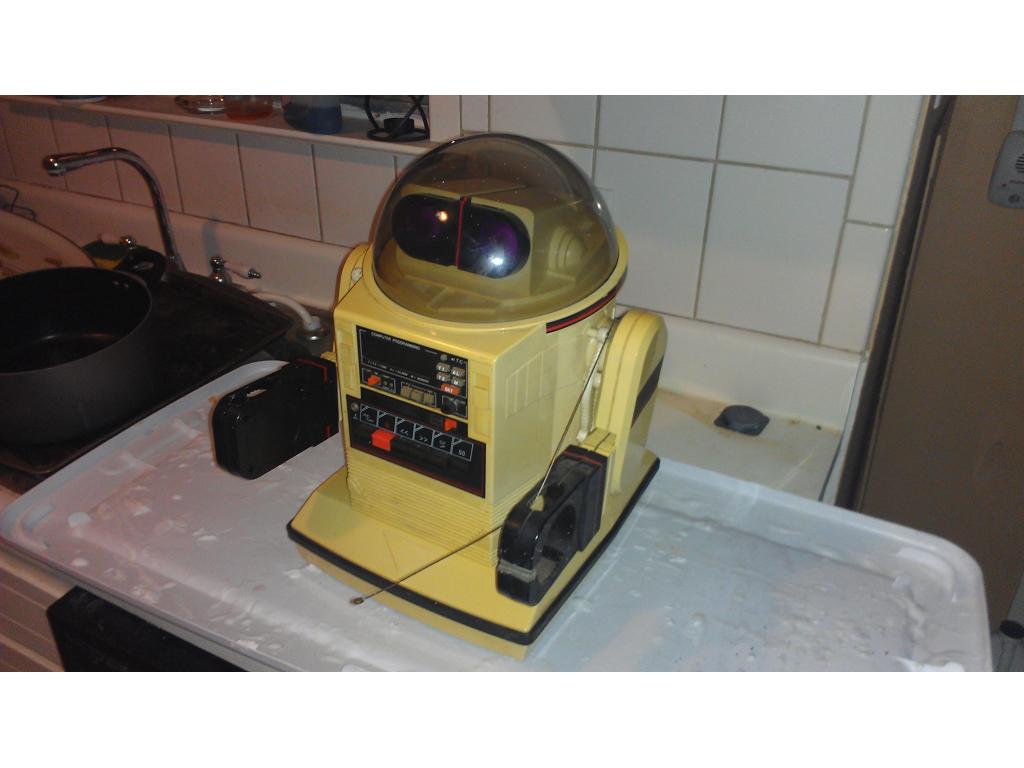
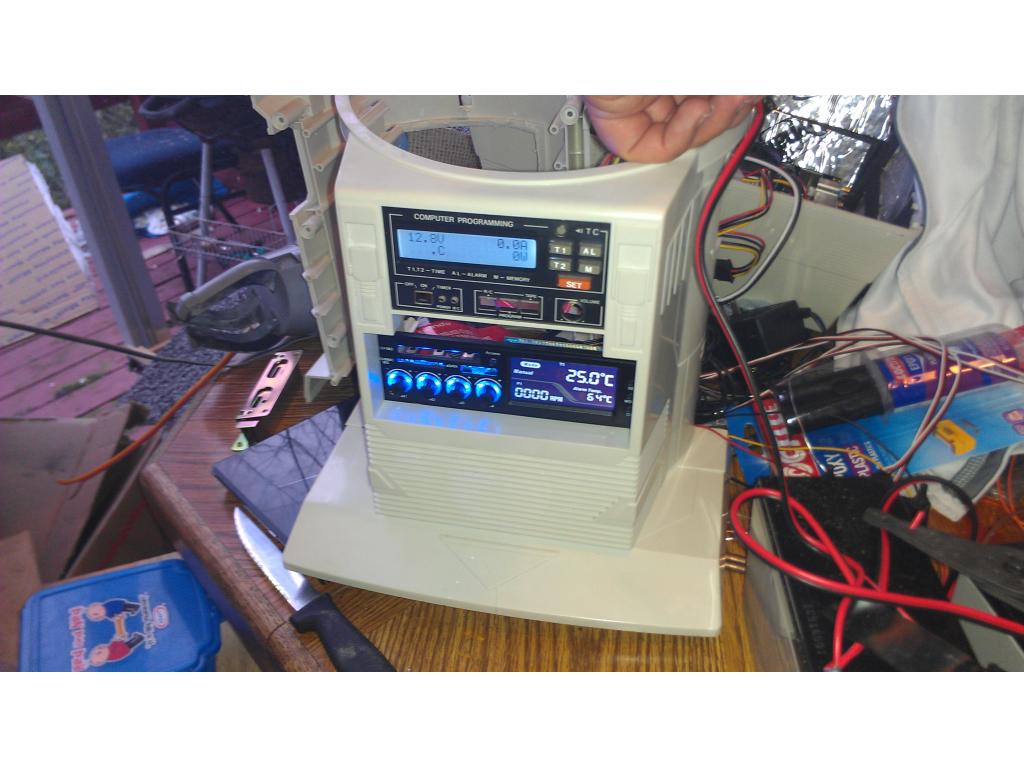
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
By jstarne1
— Last update
Discover more robots
Steve's Navigation Test Robot With Intel Realsense T265
Navigate an iRobot Create using Intel RealSense T265 and EZB with Synthiam ARC for reliable visual tracking navigation...
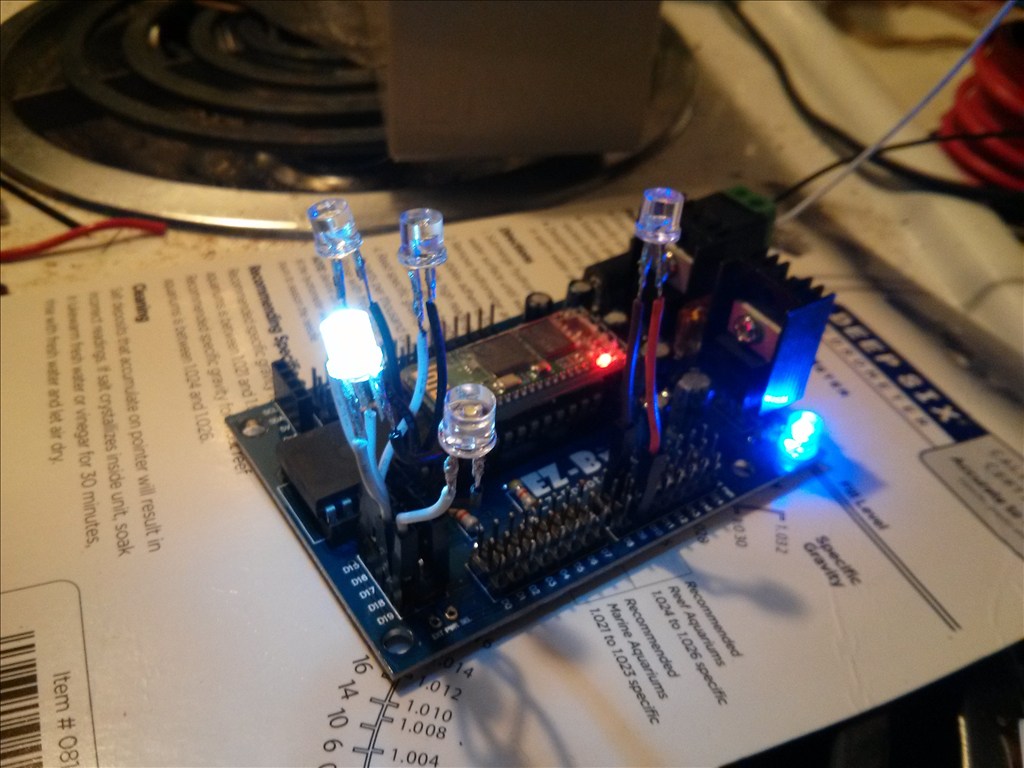
Jstarne1's Easy Led Visual Test For Digital Ports Tutorial J...
Test H-bridge ports using a servo connector: cut the red wire, use white as + and the short lead to ground to watch...
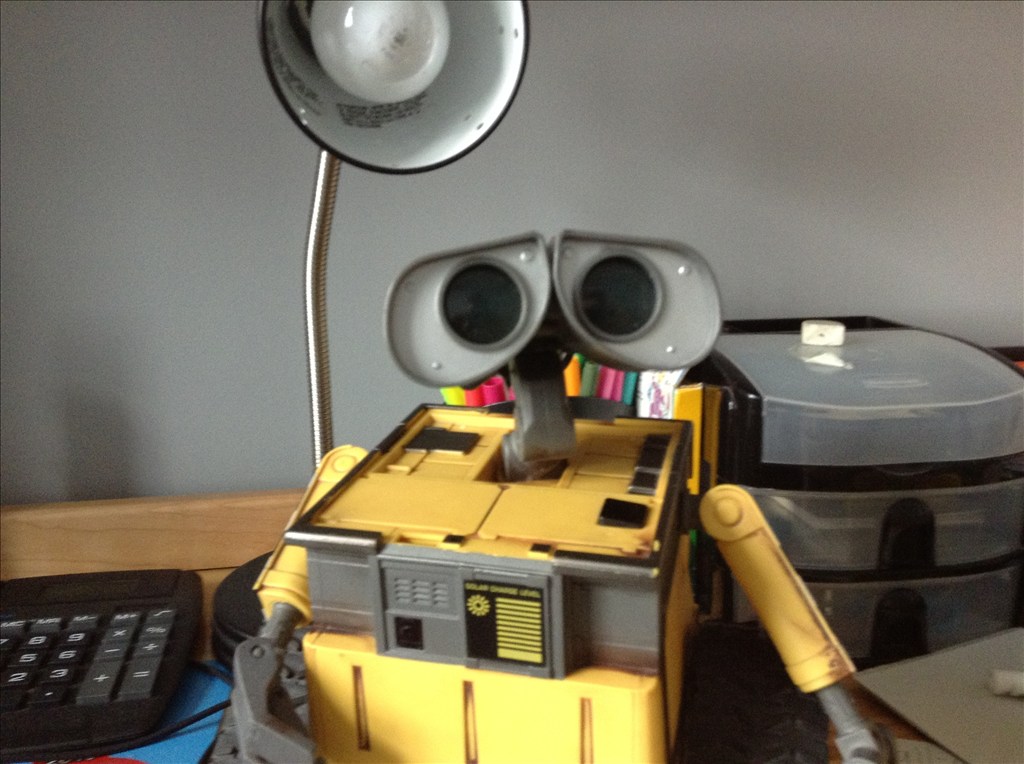
Cardboardhacker's Technopro Wall-E Project
Building a budget WallE robot: gutting a UCommand and repurposing parts while awaiting an EZKit to add electronics and...

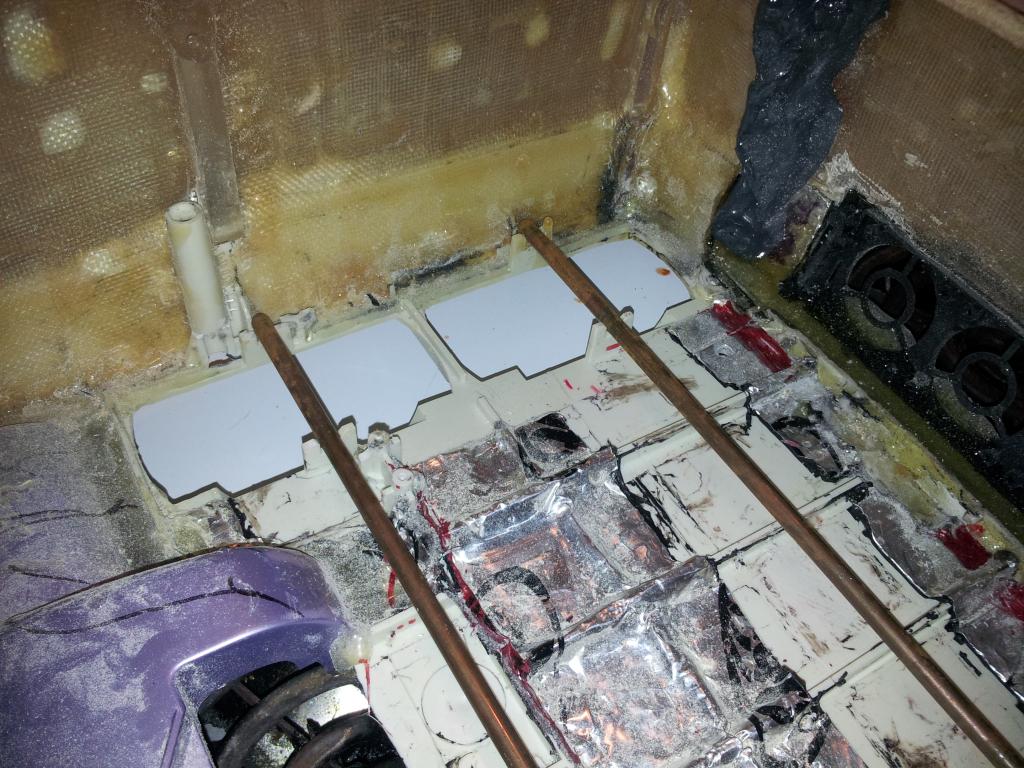
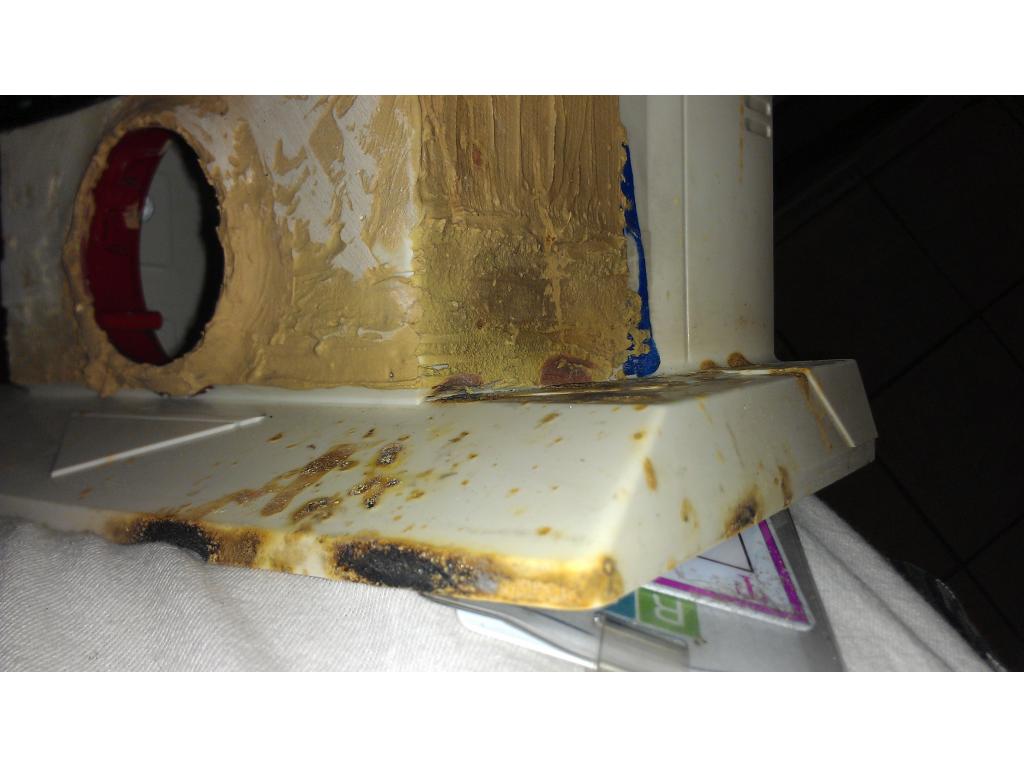
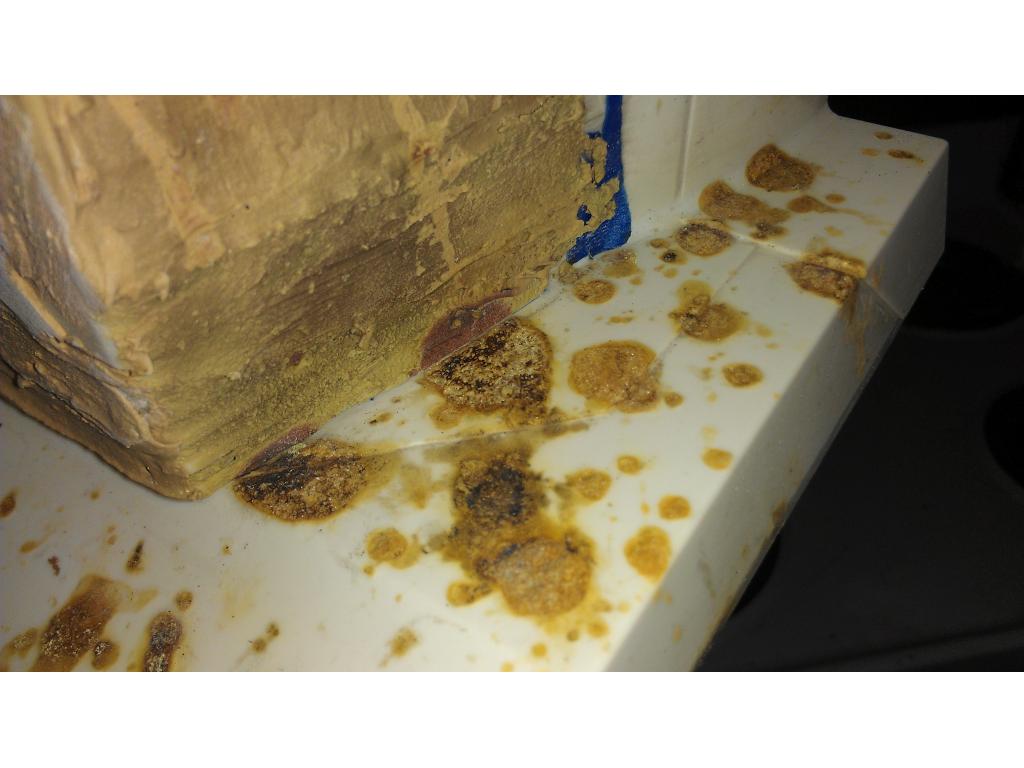
Ok the torso is garbage now , so.roomie is.buying another Omnibot ...
Lucky I.found another bot for.about 100
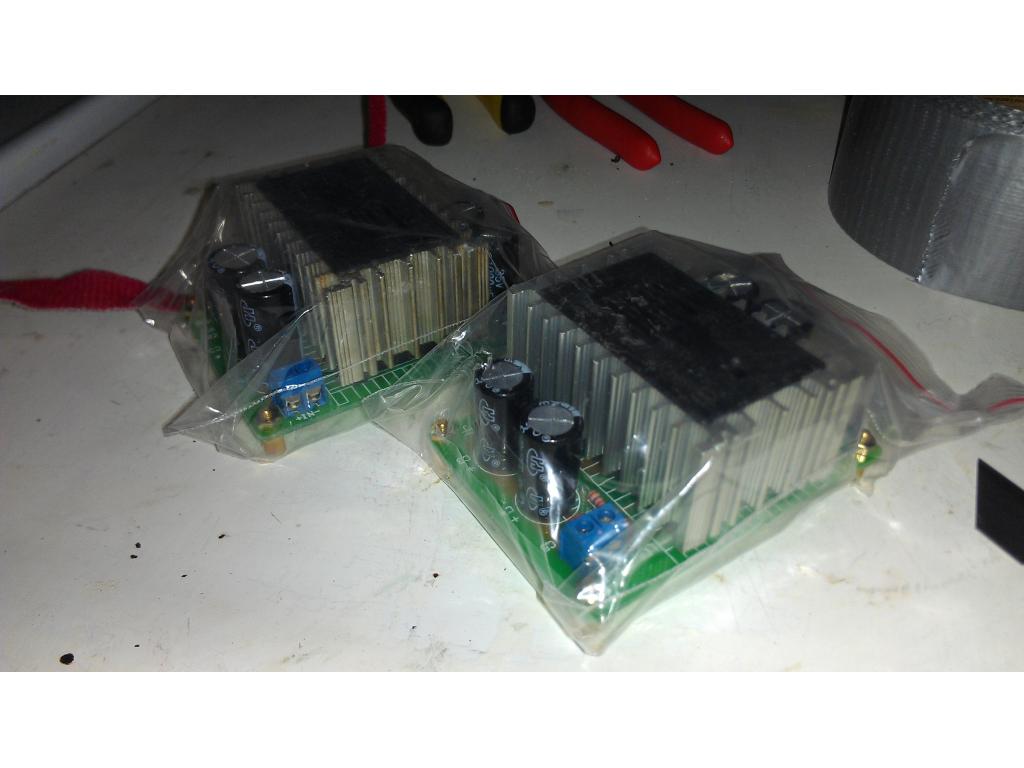
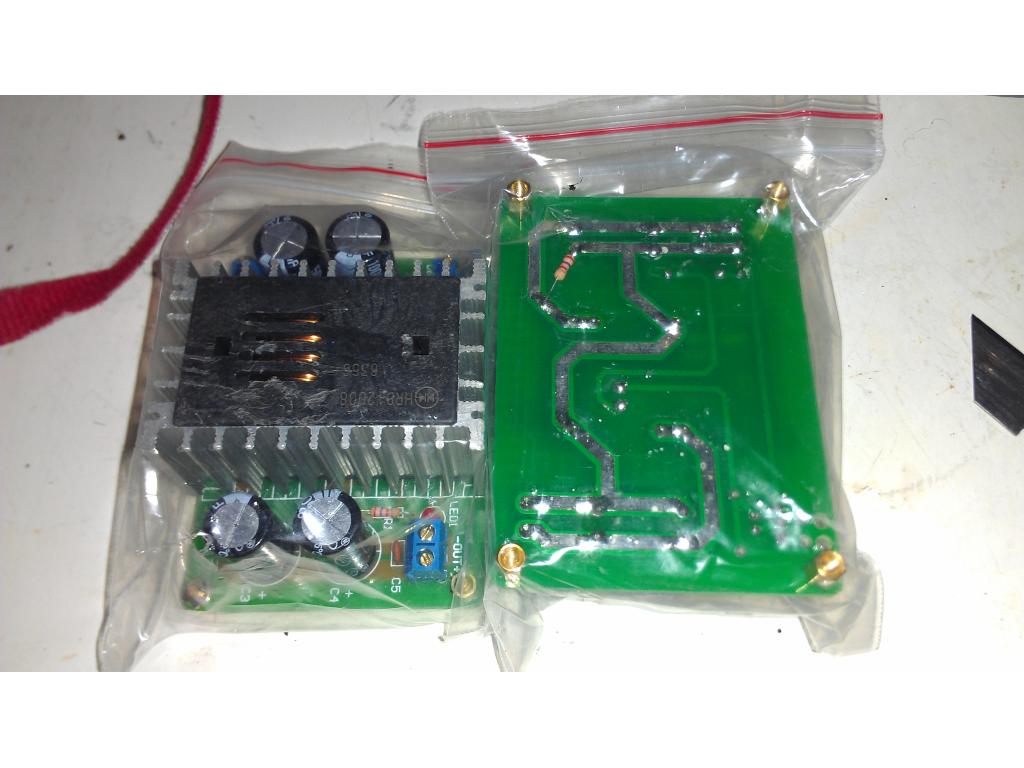
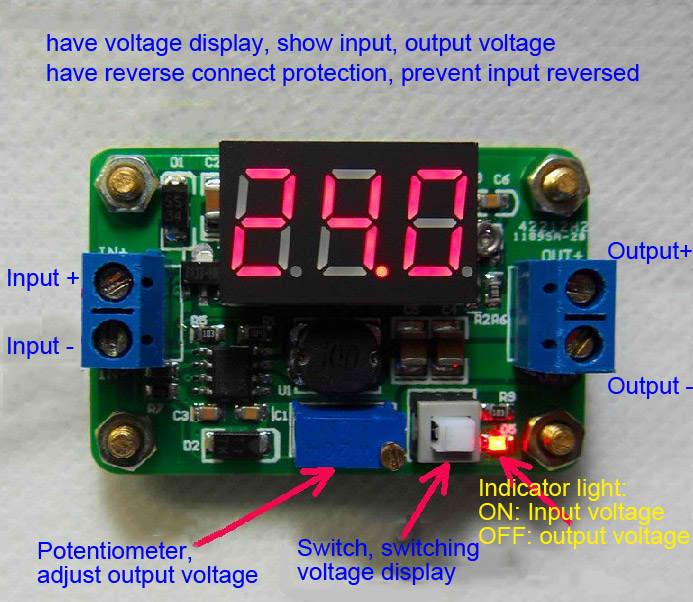
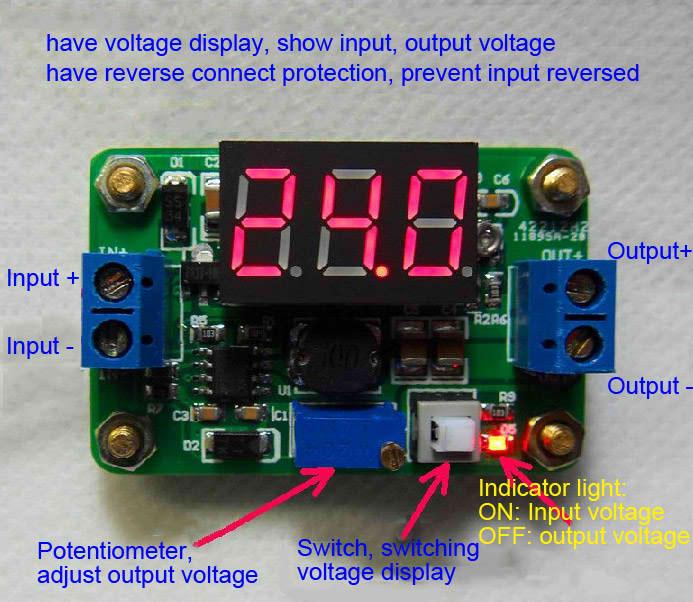
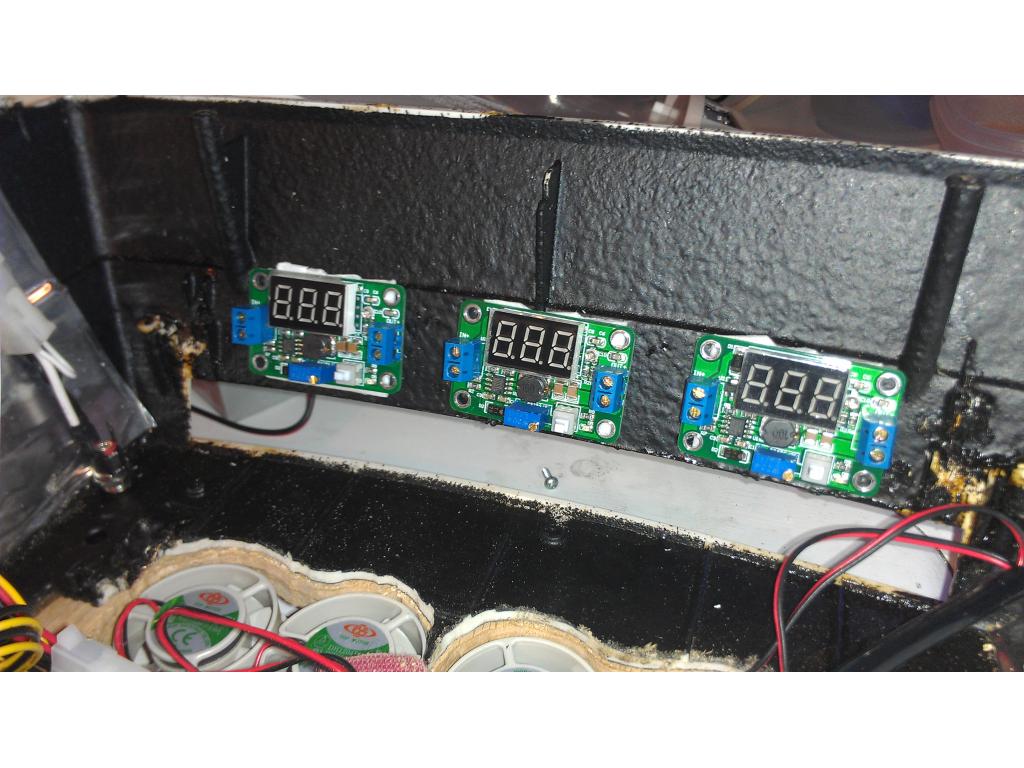
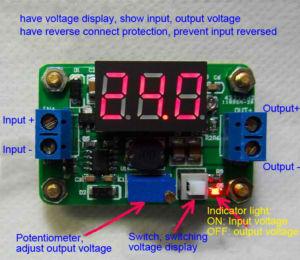
Ok I recieved my 6 amp continous , 8 amp max , adjustable step down converters. They were 15 dollars each...
Having 6 amp overhead I could use for drive motors or all the high torque servos.
Those seem like a deal at that price ! JW
Yea , if it wasn't for the internet.... Lol
same one i saw,and saved it in my lists mine was $12 free shipping dc-dc 8 amp free shipping
Even a better deal !
also got rad 4.0 and look great to hack for EZB
I saw those and wasn't sure how well it would walk? They look great though !