

HI all,
I am a newbie to the EZ robot family and just fining my feet, I have a revolution on order and it has just progressed to "processing order". Getting excited now.
As i can't contain myself i thought i would share some photos of my build so far and update you all periodically on my progress.
My Walker is a Hexapod with a total of 18 servos in charge of the walking 3 on each leg, Sorry for stating the obvious there. All parts are hand cut (how i would love a laser cutter at times).
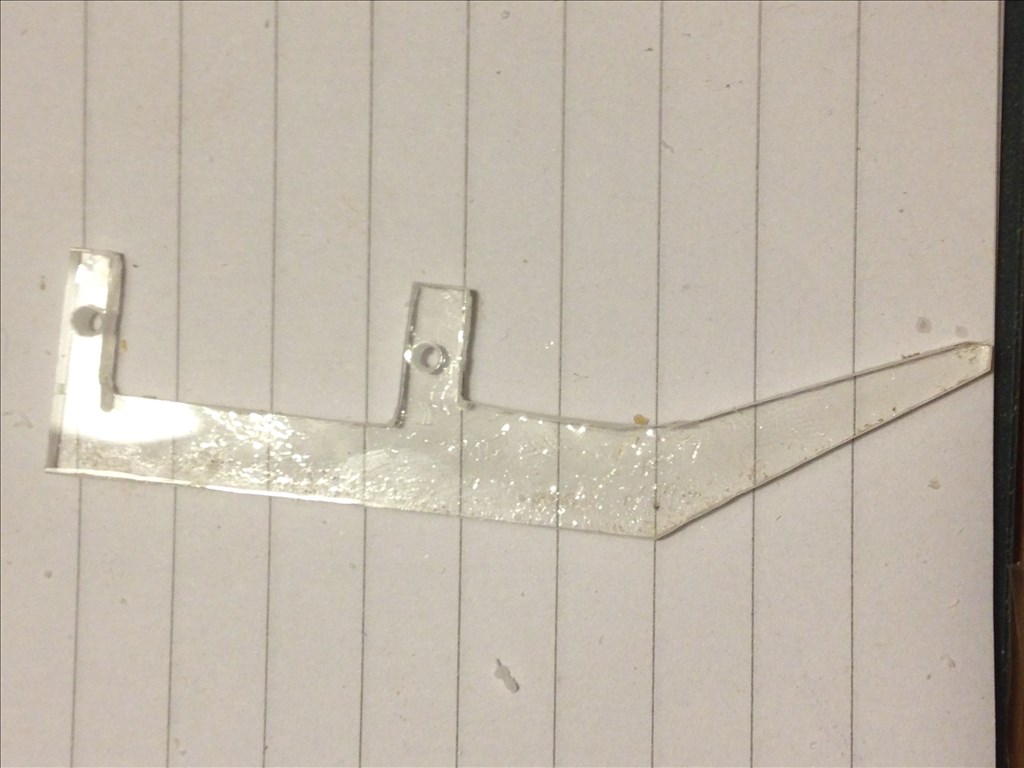
If i have done this correct then you should be able to see a photo of a Calf/Foot.
Only 5 more to do 
thanks for taking the time to read this, i will keep you all updated and hopefully not bore you death.
By mgodsell1973
— Last update

Discover more robots
Justinratliff's Jd Backpack
JD backpack mockup anchors into JD's middle slot with male clip, two top posts, dual rear mounts, wire access and switch...
DJ's Teddy Ruxpin Robot Version 1
Animate a Teddy Ruxpin by replacing internals with servos and an EZ-B; control and script behaviors using Synthiam ARC.
Jp15sil24's 3Wheelbot
Synthiam ARC-controlled 3-wheel AdventureBot: remote and internet control, camera tilt, ultrasonic wall-avoidance,...

looking cool.
:)

 j
Thanks
:)
 :)