
HI this is my robot i call him Arnie (i don't know why) his head is on a pan/tilt joint so he can look around quite freely. I still need to give him a lick of paint and some arms. At the moment I'm waiting for a Hbridge so i can get him moving around.
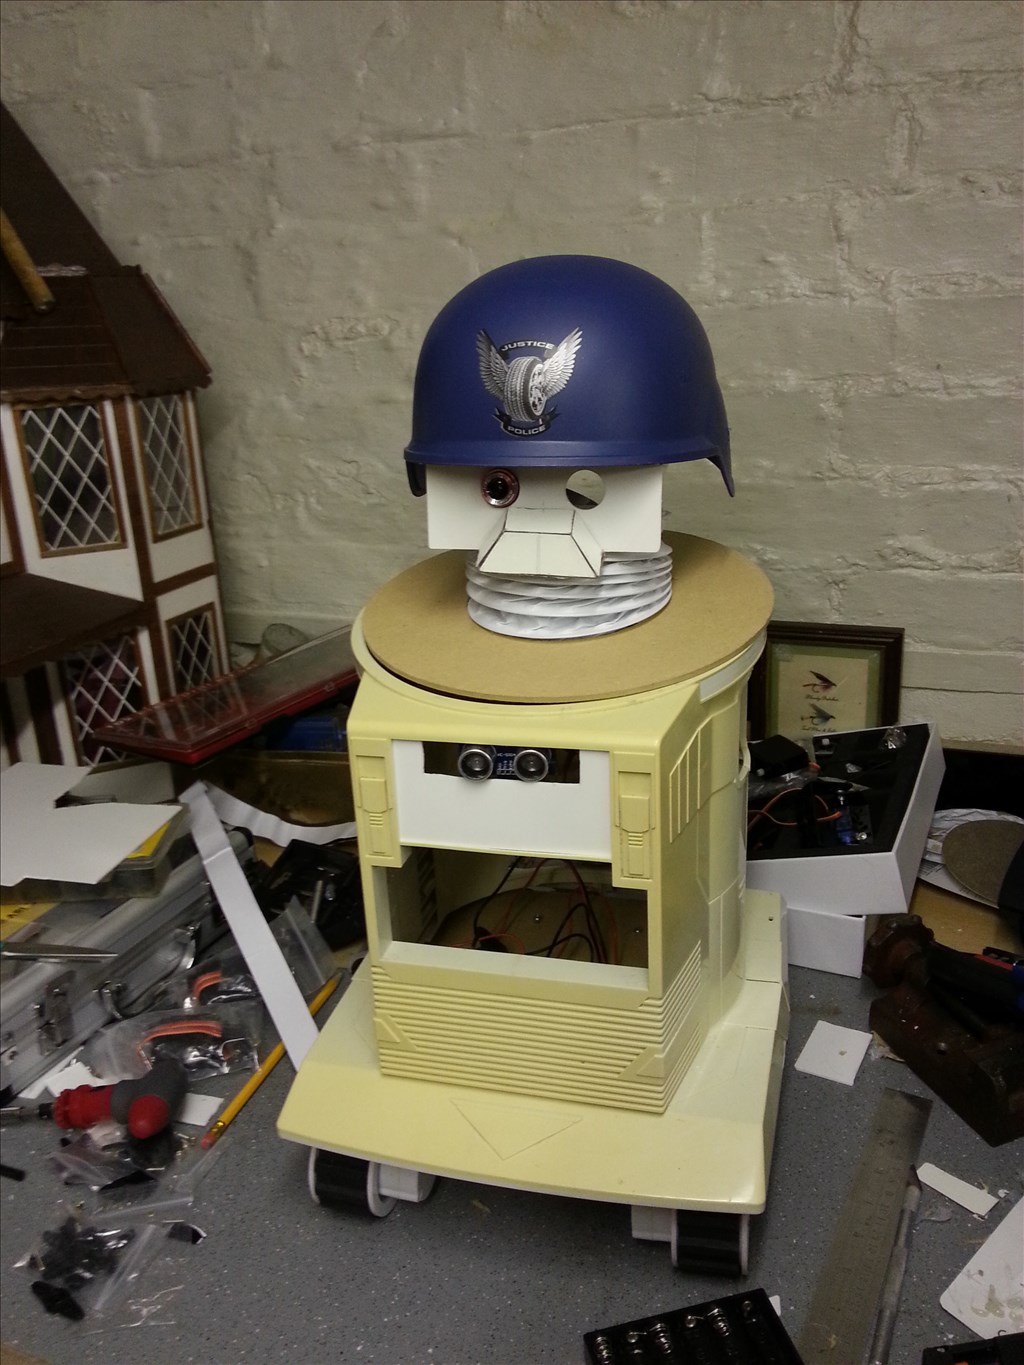
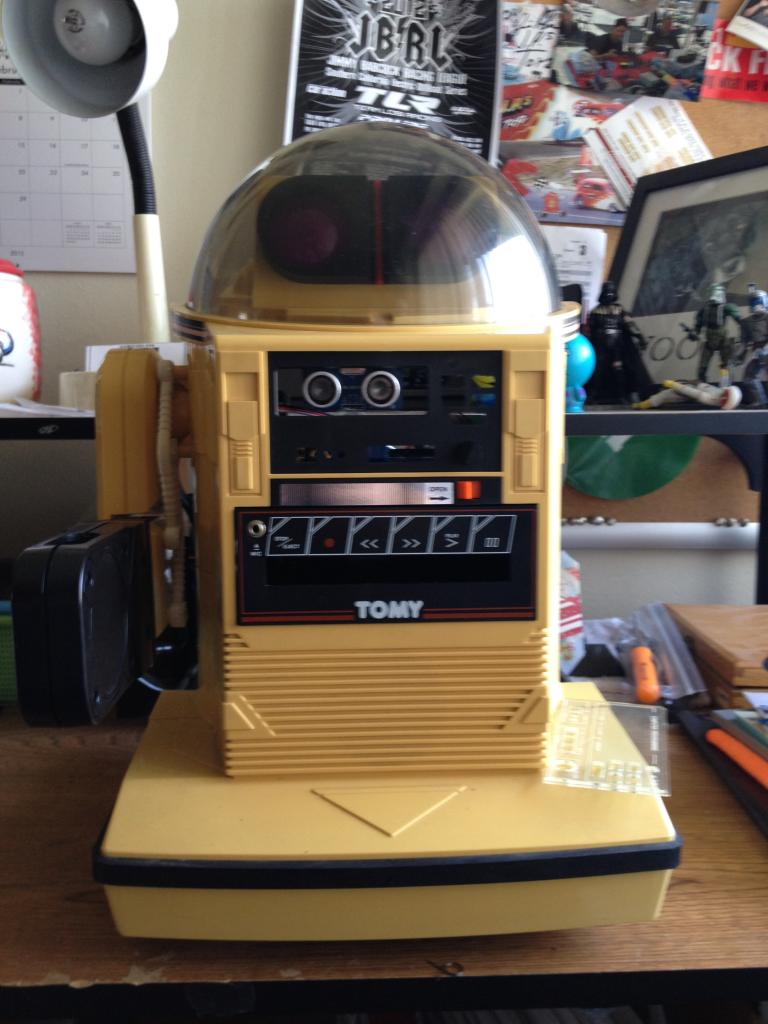

nice bot! i see you used the rover 5 for your base. And is that an omnibot body?
very cool.
Cool , I'm waiting for the video of him (or her) charging at the GiJoes yelling "Coooobraaaa"! I like the rover 5 chassis.
@techno pro , yup that's a Omnibot body
I LOVE IT,great job on it
Thanks for the positive feed back :-) i was going to make another omnibot hack but i found the head had to many limitations so i built my own. i got the rover 5 base manly because for the price you can't really get any better. plus on the rover 5i can change the ground clearance.
Yup and motors are upgradable and can be made 4wd too. They are good for a 15 pound robot to move around confidently. I've noticed that lowering the heights stretches the tracks tighter. Seeing your robot makes me want to work on my omni projects in the very near future