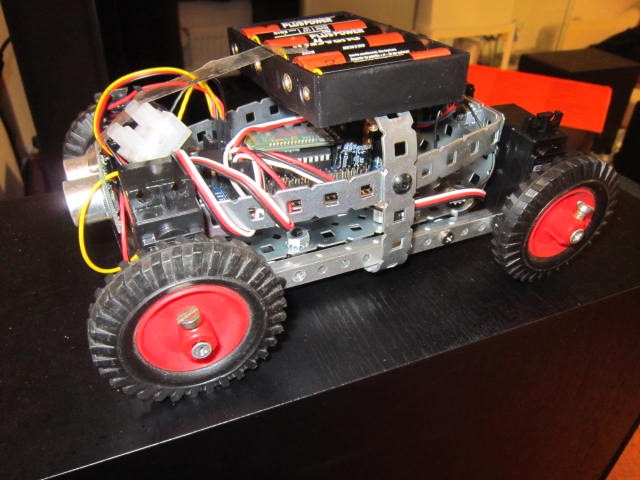
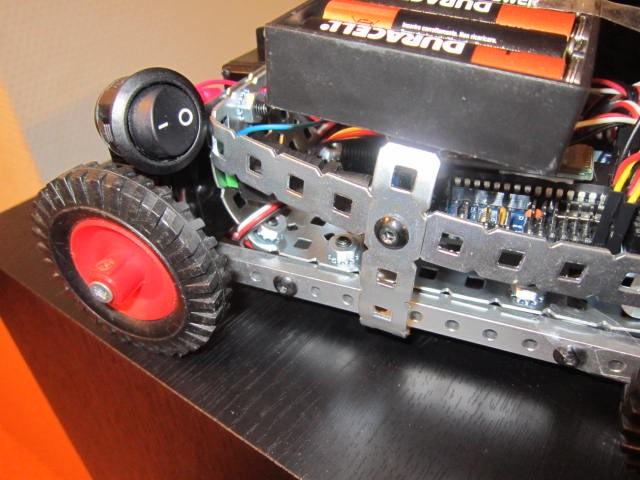
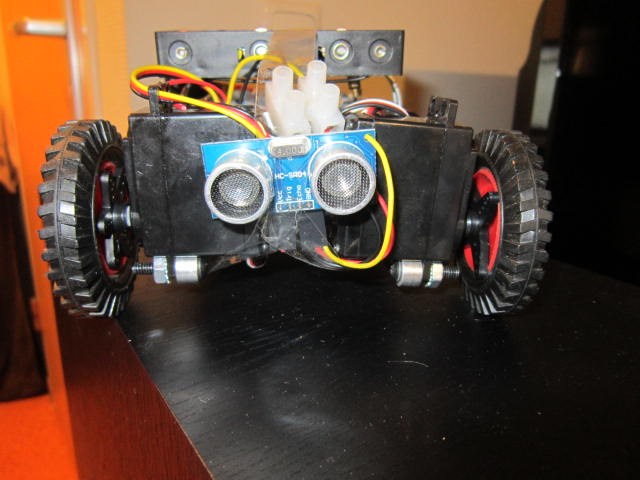
i tried to keep my second project as small as possible, and i think it turned out pretty good (though i need to get rid of the tape that's holding the distance sensor in place)
it uses 4x cont rotation motors (each driving one wheel)
tell me what you think so far, ideas always welcome~
By cosplaying_bunny
— Last update
Discover more robots
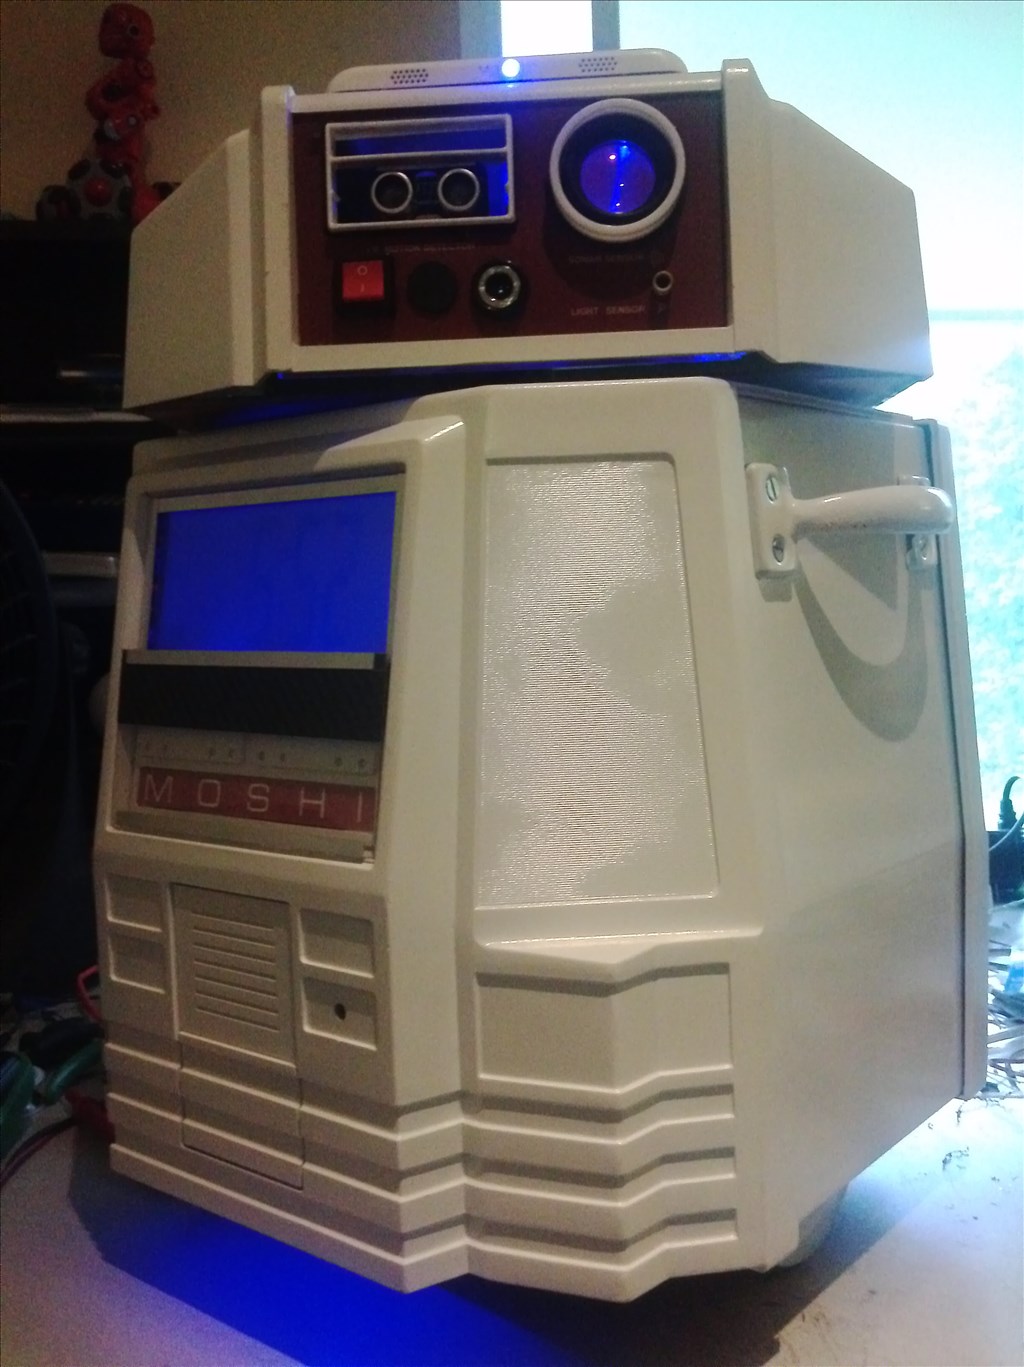
Rb550f's Moshi Is Alive
EZB 4 in MOSHI droid: aluminum internal frame, Sharper Image drive base with quiet 4-inch wheels, Bluetooth audio and...
Jstarne1's Meet Rc-Xd Airsoft Droid Dual Wield Gunner...
RC-xd Airsoft Droid: modified Omnibot on a rad 2.0 base with dual automatic airsoft guns and EZ Cam for Mech Wars, built...
DJ's How Do I Shovel My Snow?
Robot shell built with students using an electric scooter chassis and shovel attachment to perform outdoor work while...

FYI shorter your wheel base the easier it is to turn with friction steering. ( wheels rotate opposite directions to turn left or right)