

Hi, Just wondering if EZ-B V4 and ARC would drive this type of servo/ stepper?, >> link
3dGuy
Canada
Asked
— Edited
4 Participants
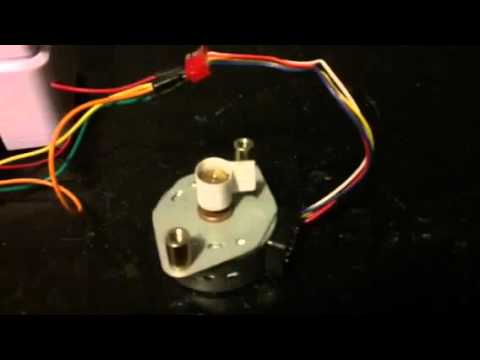
Would This Work With An EZ-B V4 And Arc?
Related Hardware (view all EZB hardware)
EZ-B V4
by EZ-Robot
EZ-B v4 with Synthiam ARCx controls servos, sensors, camera and audio over Wi-Fi or USB serial, no firmware needed.
Wi-Fi / USB
Servos
24
Camera
Audio
UART
3
I2C
ADC
8
Digital
24

This morning I used a 28BYJ-48 Unipolar Stepper with ULN2003 and the stepper library or AccelStepper library for 2 of them and Bipolar Stepper with L298N H-Bridge (with potentiometer) with the Arduino, yes it did need the libraries
Hey Dave hope this is not too far off topic, but
I use the 416 RPM Premium Planetary Gear Motor from ServoCity
SPECS Voltage (Nominal) 12V
Voltage Range (Recommended) 3V - 12V My EZB controller with 7.4V runs it well with the L298N Motor Driver Controller Board
$25.49
EzAng, ServoCity has a wonder assortment of all kinds of motors. I've used many of them.
I whipped this up: https://synthiam.com/Support/Skills/Servo/Stepper-Servo?id=21134
It essentially turns up to 127 stepper motors into servos.
I haven't tested it because I have no stepper motors with me. But in theory, it should work, albeit requiring some tweaks for speed and acceleration. I ordered a few cheap steppers, and I'll wire them up to a nano when they get here next week to make any necessary changes. But, it will work with any stepper motor.
That robot skill and respective Arduino firmware will work with any stepper motor driver you can throw at it.
After considering Jeremie's feedback, he's right about the encoder. I'm not sure what the point of the encoder is unless expecting the stepper to fail to move. If the stepper fails to move, there are many more significant problems. However, a simple limit switch to recalibrate the position is easy enough done.