Hi Community,
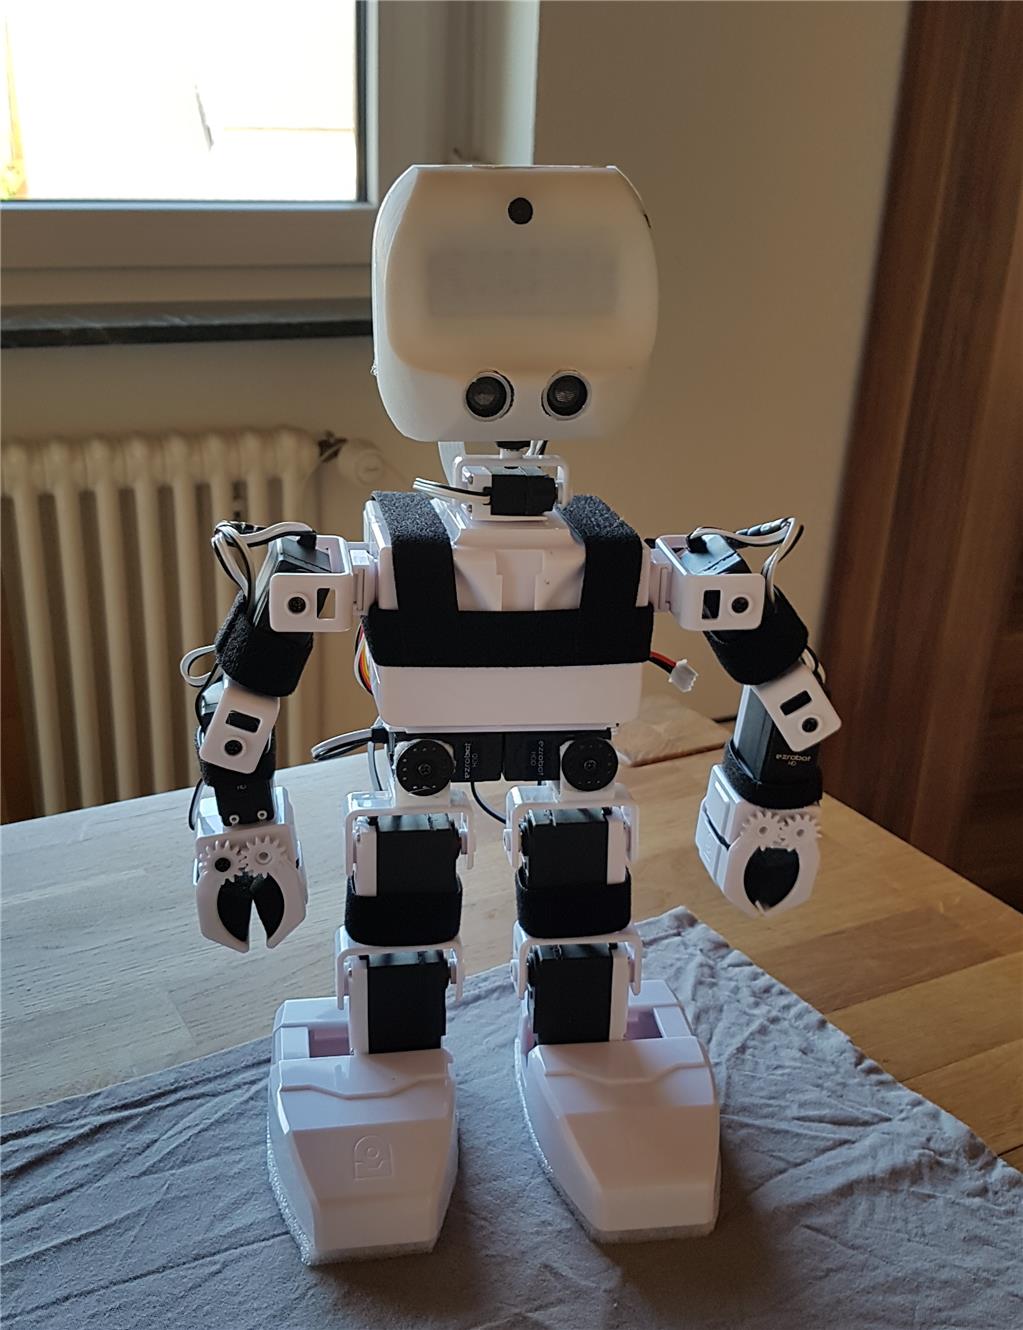
I would like to show you the current status of my project. I work on a head for JD.
The last change was to enable the installation of an ultrasound sensor and to create space for a gyroscope in the head.
You can find the project here: www.thingiverse.com/thing:2740165
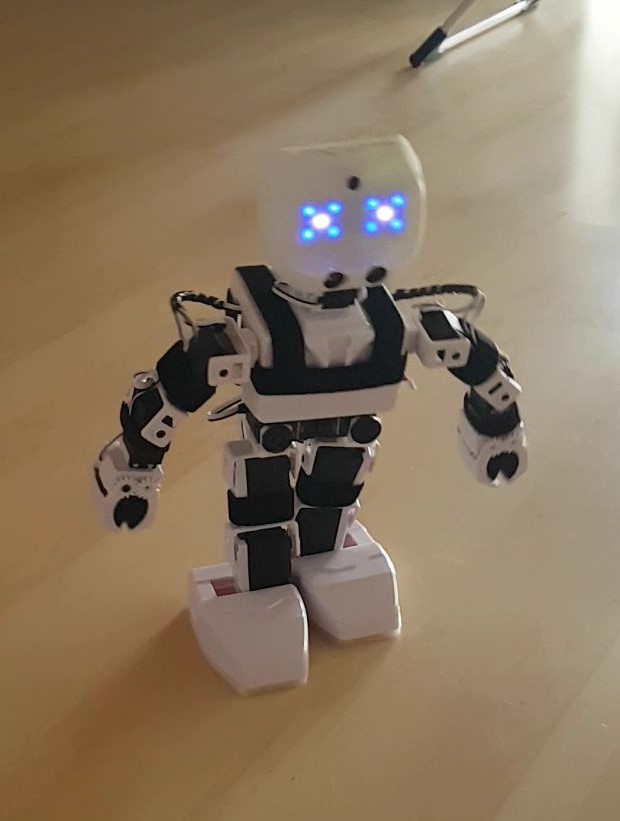
Also I try to create a more humane walk with the hips.
By laurin
— Last update

Discover more robots
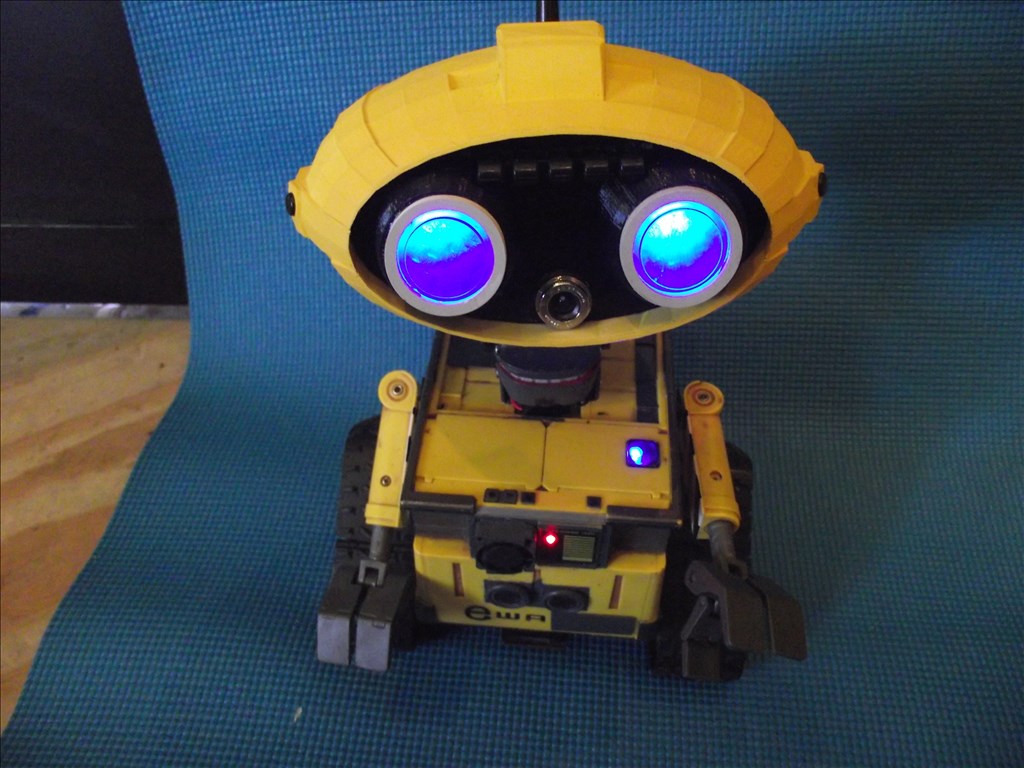
Rb550f's Meet Ewa
EWA robot: Walle Ucommand rebuild with 3D-printed head, EZB V3 controller, HD servos, LED mic-reactive mouth, 5000mAh...
Steve's Elvis Gains An Extra Degree With Ez Robot Hdd....
Enhance 'Elvis Alive' WowWee robot: repair startup, add rotation pedestal with EZ-Robot lotiny controller and HDD servo...
Andy's Happy Holidays
Holiday wish from Antonn
Very cool! I like what you did with this. Thank you for sharing.
I also like your use of velcro straps to keep the wiring in control. Nice looking build.
Alan
thats a cool jd .
I really like the velcro! Hope to see the more human walk using hips. The hips is something i'd really like to see in a future revision of the JD humanoid body. Perhaps with the work you are doing for the walking hip gait, that you'd be willing to share your progress with us on here?
I have never thought of using velcro...what a brilliant idea! ( I am a big fan of zip ties though... )
This looks like a very good JD mod...it adds a lot of functionality. Looks kind of scary with the lights out!
I like this a lot!
Ooooh JD’s hip swagger! Sporting those new fancy hip joints
is there a reason to place the hipbrackets this way?