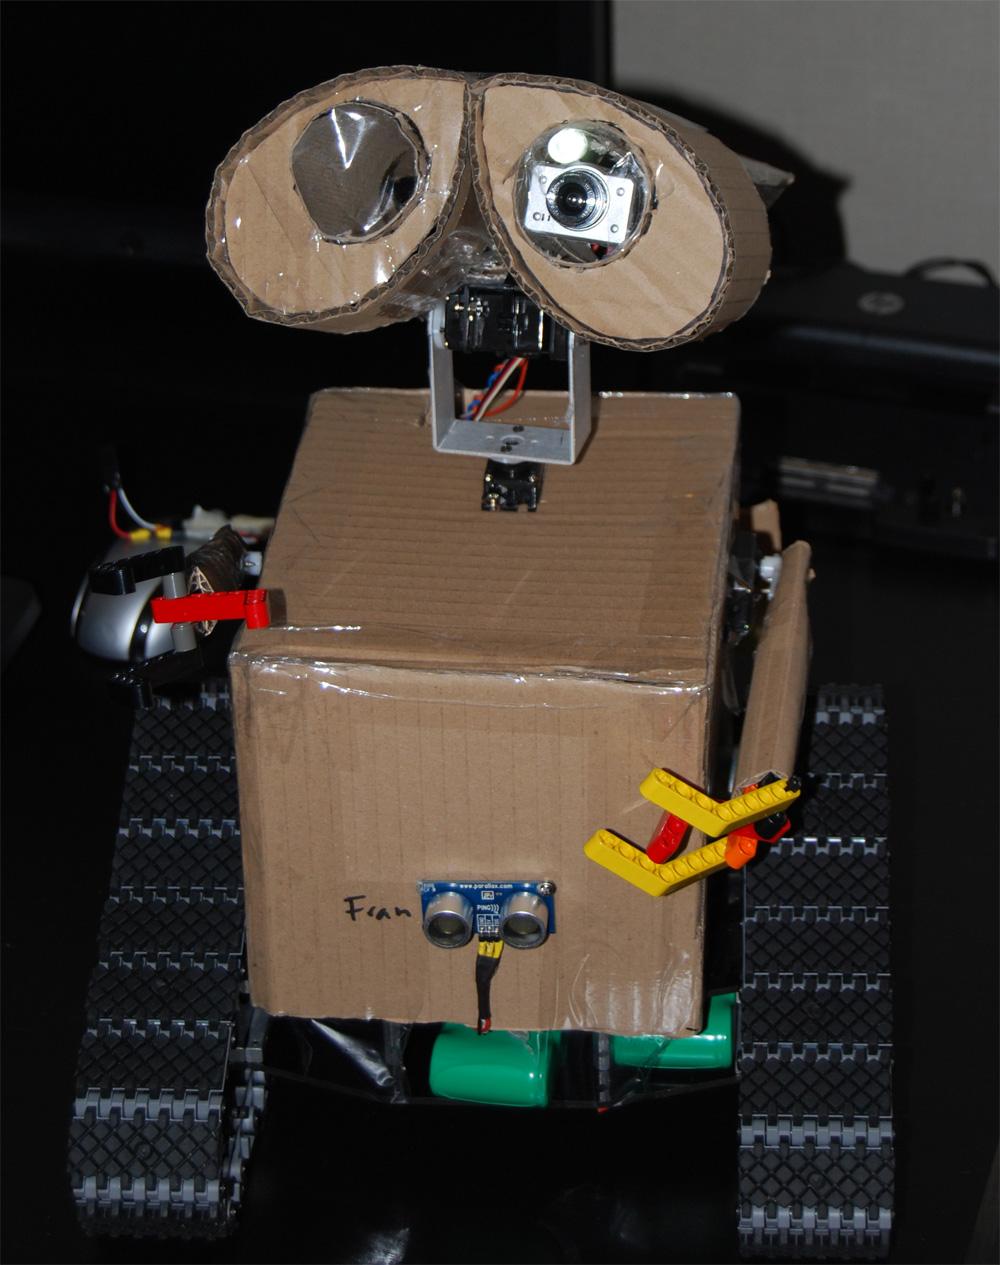
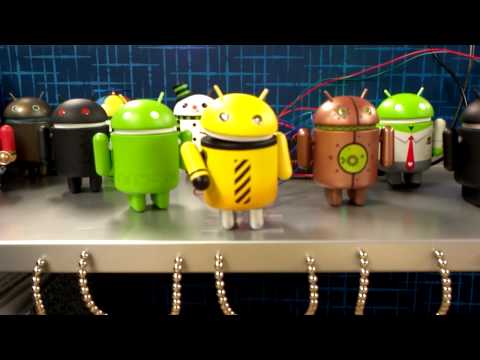
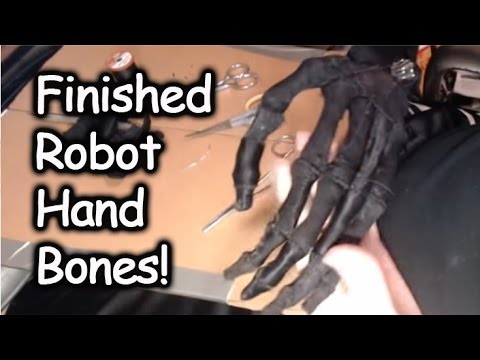
Make up a robot which is a combo between Jd and Six so he can move fast with little mistakes and also be able to interact with objects.
About this robot
By Oliver
 XV11 LIDAR
— Real-time 2D mapping from Neato XV-11 360° LIDAR via GetSurreal controller; exports $LIDARDistance/$LIDARIntensity, configurable angles, color, zoom.
Try it →
Make up a robot which is a combo between Jd and Six so he can move fast with little mistakes and also be able to interact with objects.
Robots the community built with Synthiam ARC. Get ideas for your next build.