


Hi Roboteers,
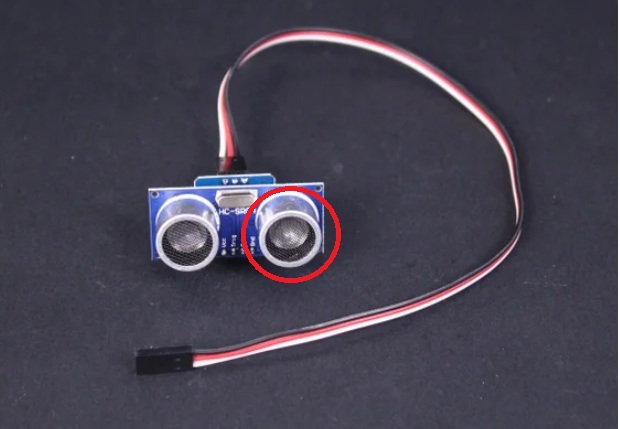
Is it possible to desolder one side of a ping (ultrasonic/sonar) sensor and reconnect it with a wire? I'm working on an ARC project and want to make sure this will still work with my hardware setup.
Please specify the sensor model (e.g., Parallax Ping, HC-SR04, etc.) and how you plan to connect it in ARC - via an EZ-B (or other microcontroller running Synthiam firmware) or directly to the PC - and which pad/side you would be desoldering (power, ground, or signal).

You’re welcome.
For a bit of context: that gray ultrasonic can is not just a "wireable part" like a button or LED. It’s an acoustic transducer, and its exact position and orientation matter a lot for how it sends and receives sound. If it’s moved off the PCB:
So for an ARC project, the safer approach is usually:
If you’re using it in ARC, these are the relevant skills:
Ultrasonic Distance
https://synthiam.com/Support/Skills/Ultrasonic/Ultrasonic-Distance?id=16090
Ultrasonic Radar
https://synthiam.com/Support/Skills/Ultrasonic/Ultrasonic-Radar?id=16101
If you want, I can help you figure out the best safe way to extend the sensor in your robot build without modifying the transducer itself.