

i made this topic allreddy ,but cant find it back. are there diff sizes in six?


thanks anyone
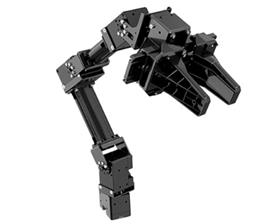 Robotis Openmanipulatorx
— Inverse kinematics for Robotis OpenManipulatorX: compute joint angles and MoveTo 3D (cm) positions, supports camera-to-CM mapping for pick-and-place.
Try it →

In calibration position Six is roughly 36cm in diameter. If you want a more accurate measurement the SLT files are to scale.
rich
ah.thank you
Hi @nomad The size and weight on our website is for the SIX white box. The size and weight on the Studica website might be including the outer shipping box (usually larger so it can accommodate extra accessories)
hi jason. thats good to know,maybe would be good to reference that on your page.
people dont always ask this,and by where they think its biggest.
thanks