Change Release Notes
This ARCx update is all about keeping things moving.
v2026.09.30.01 introduces asynchronous robot connections and script execution, helping ARCx stay responsive while your robot is connecting, scripts are running, or the network decides to take the scenic route.
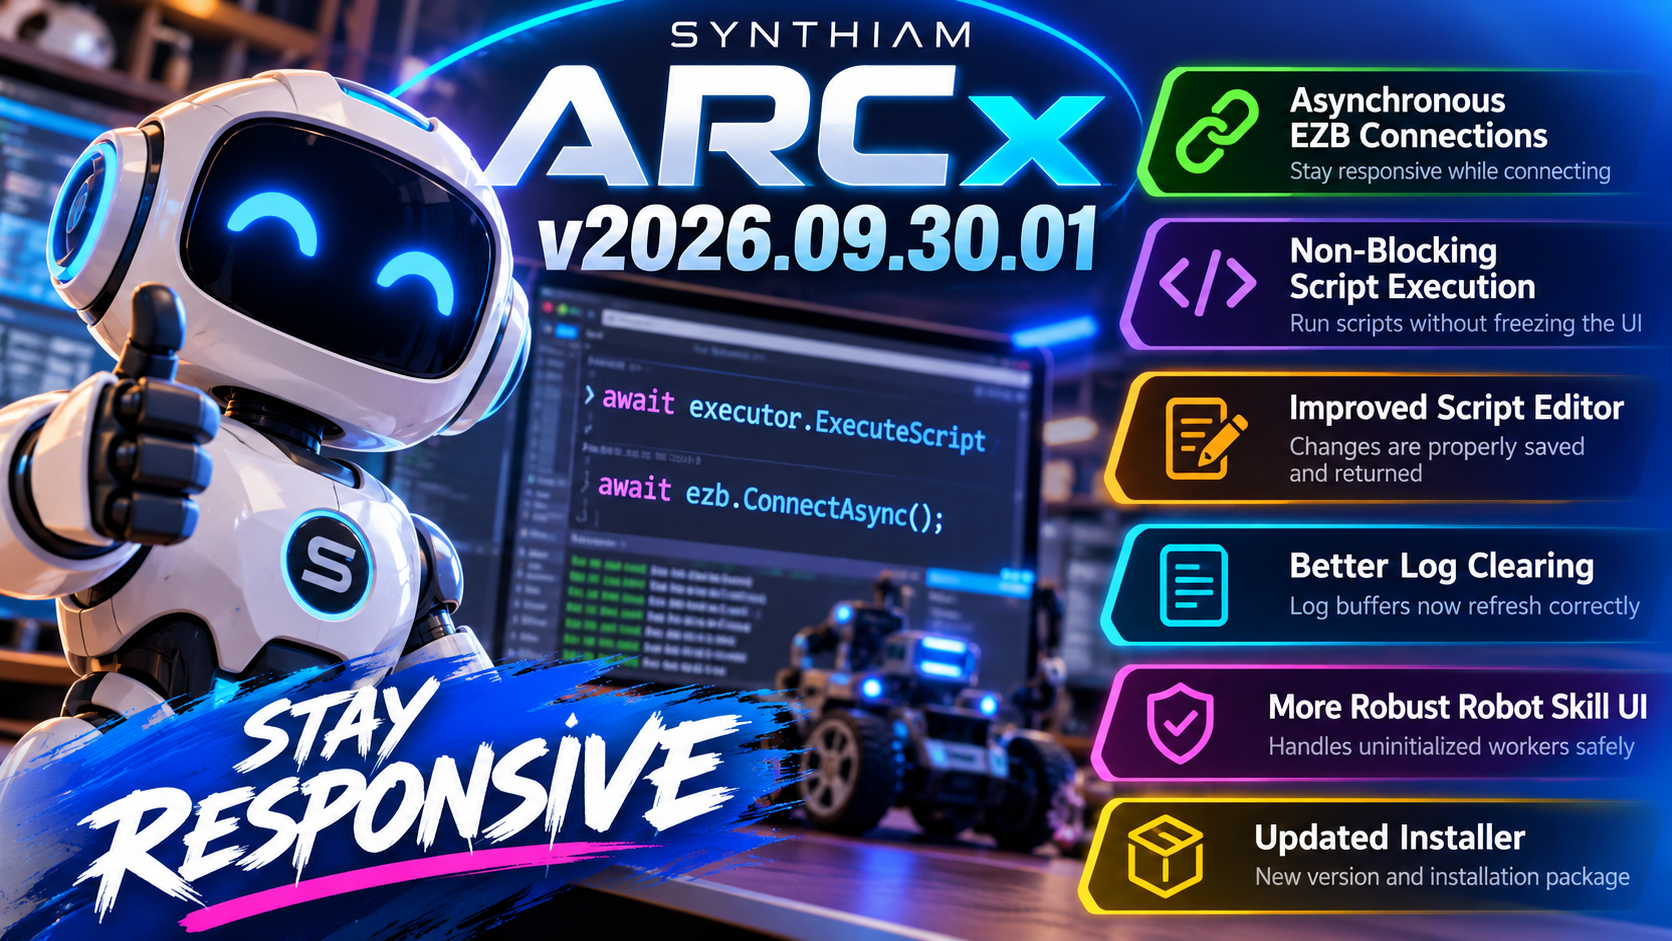
There are also several UI reliability improvements and fixes to make scripting and robot skill development smoother.
Asynchronous Robot Connections
Connecting to an EZB can involve network delays, handshakes, timeouts, and occasionally a robot that just isn't ready to cooperate.
ARCx can now perform EZB connection attempts asynchronously, keeping the interface responsive while the connection happens in the background.
Connection handling has also been improved with:
- Better timeout handling
- Improved connection error reporting
- Protection against multiple simultaneous connection attempts
- New asynchronous connection methods available to Robot Skills
Your robot may take a moment to answer. ARCx doesn't have to freeze while it waits.
Non-Blocking Script Execution
Script execution is getting the asynchronous treatment too.
ARCx's script executor can now evaluate scripts without blocking the main UI thread.
This is especially noticeable when scripts are executed directly from interface components or the script editor. Longer-running operations are much less likely to make the interface feel stuck while ARCx waits for them to complete.
The result is a smoother development experience, especially in projects with lots of interactive scripting.
Script Editor Improvements
We've also improved how script changes are handled when closing an editor.
The script editor now ensures that modifications are properly communicated back to the component that opened it.
Edit. Close. Done.
Your changes actually know where they're supposed to go.
Better Log Clearing
Clearing a log should mean the log is... cleared.
ARCx now refreshes the appropriate log buffers when logs are removed, preventing stale entries from lingering in the interface.
It's a small detail, but an important one when you're debugging a robot and trying to figure out whether that error happened now or five minutes ago.
More Robust robot skill UI
Additional checks were added around robot skill workers to safely handle situations where a worker has not yet been initialized.
This prevents unnecessary errors during page rendering and improves reliability during robot skill startup and configuration.
Updated Installer
The Windows installer has also been updated for v2026.09.30.01, including the appropriate version, product code, and component identifiers required for installation and upgrade handling.
ARCx v2026.09.30.01 continues refining the experience of building real robots: fewer blocked interfaces, smoother scripting, stronger connection handling, and fewer little things getting in your way.
Because when your robot is busy thinking, your development environment shouldn't look like it is too.
Download ARCx
Install ARCx on the computer that runs your robot — from a first prototype to a commercial product or an industrial cell. Available for Windows 64-bit, Linux 64-bit and Linux ARM64 for Raspberry Pi (Ubuntu 24.04 LTS 64-bit).
Linux
Ubuntu, Debian & friends
64-bit (x64) (zip)
Raspberry Pi
Single board computers
Linux ARM64 (zip)
Requires Ubuntu 24.04 LTS (64-bit)
ARCx is always evolving. Follow along in the community for updates.
Follow ARCx development Download ARC today
Upgrade to ARC Pro
Synthiam ARC Pro is a new tool that will help unleash your creativity with programming robots in just seconds!
PS, we have also updated every ARCx robot skill manual with images and more details about each.
Thanks for the great work. I have a couple of questions. #1 - How do I know if I am running the latest release of any of the plugins and #2 - I keep getting this error when trying to play MP3's, the first few times it plays and then the message starts appearing and I cant play any more MP3's.
I know this is trivial, but why do you have the EZB Connection show red with a line through it when connected and green when its not connected. Any chance you could switch that, I have disconnected my EZB's more than once. Not a big deal, just an observation. Or it could be I have things setup wrong?
ARCx, like ARC, updates robot skills when it loads and has an internet connection. ARCx is a web browser interface, not a static GUI like you're used to with ARC. This means function notices when there is no browser appear in the server log window. When ARCx loads, you will see a bunch of text - that text can be important if you're looking to answer a specific question, such as an action or something.
You can also view the log activity in an easier-to-read presentation by pressing Workspace -> Debug Log or Side Menu -> View -> Debug Log
You can view the robot skills sorted by their most recent update in the Add robot skill menu.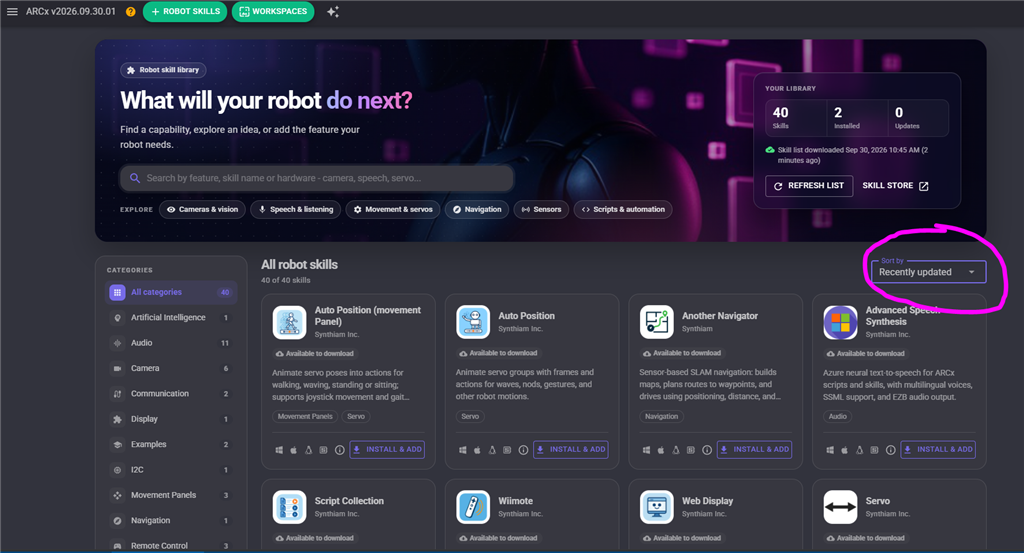
For buttons, the standard UI template is to label and color them based on their action. For example, if you see a red button with a disconnect symbol, pressing it means disconnect.
This may differ from older ARC behavior, as ARCx follows UI standards, so there may be a slight learning curve.
We have received similar audio reports, and it appears to affect some audio devices because of the cross-platform nature of the driver we're using. We have a fix in a release for today - as always, thanks for reporting it as well!
I can't find a post for version 10.03.01, so will ask here. Is there a timeline for servo Recorder and servo Pad skill release?
Not all the versions get release notes because they're patches or minor updates. At least during this time while there's lots of improvements to the core ARCx platform. I'm pretty sure it's pretty much figured out tho. I'm not sure what else is on the list for core features.
As for your robot skills you asked about... These will do more than replace them..
Wow! Can't wait to give these a spin! Awesomeness!
okay...brain is melting...this is soooooooooo fricking cool. Thank You so much for the Bezier curves!