

Does the rads base speed differ going forward vs backward? Or does it stay the same either way?
Asked
— Edited
1 Participant
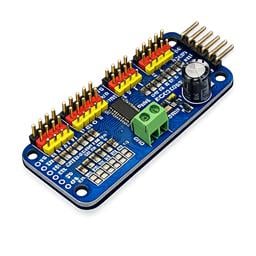 PCA9685 Servo Driver
— Drive 16 servos over EZB I2C with a PCA9685 PWM controller, using ARC servo commands and hardware-timed outputs.
Try it →

It should be the same either direction since all you are doing is reversing the polarity of the motors not changing any of the gearing.
k thanks. FYI, My Rad rover is going to me called roli mega now for obvious reasons soon to come.