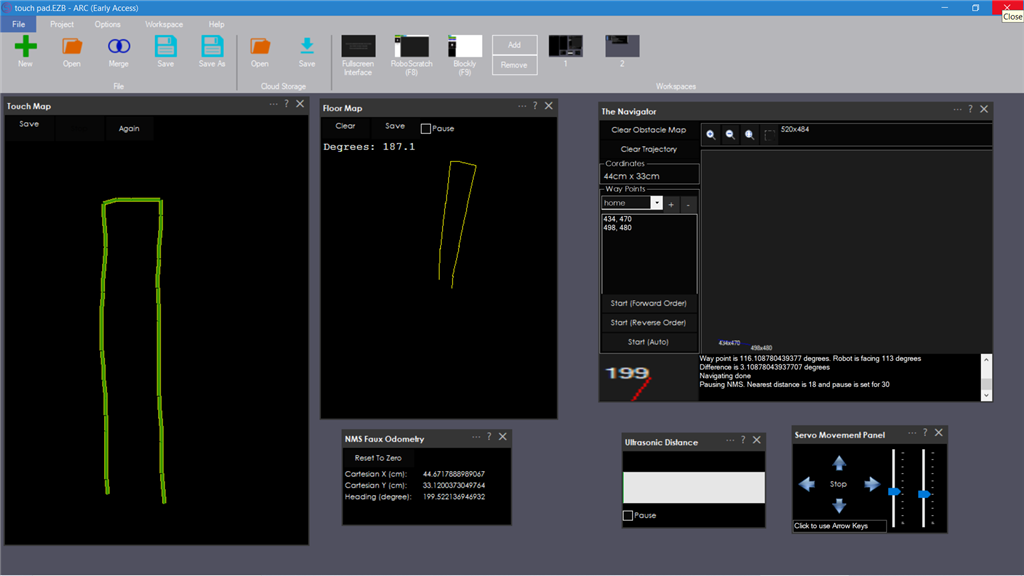
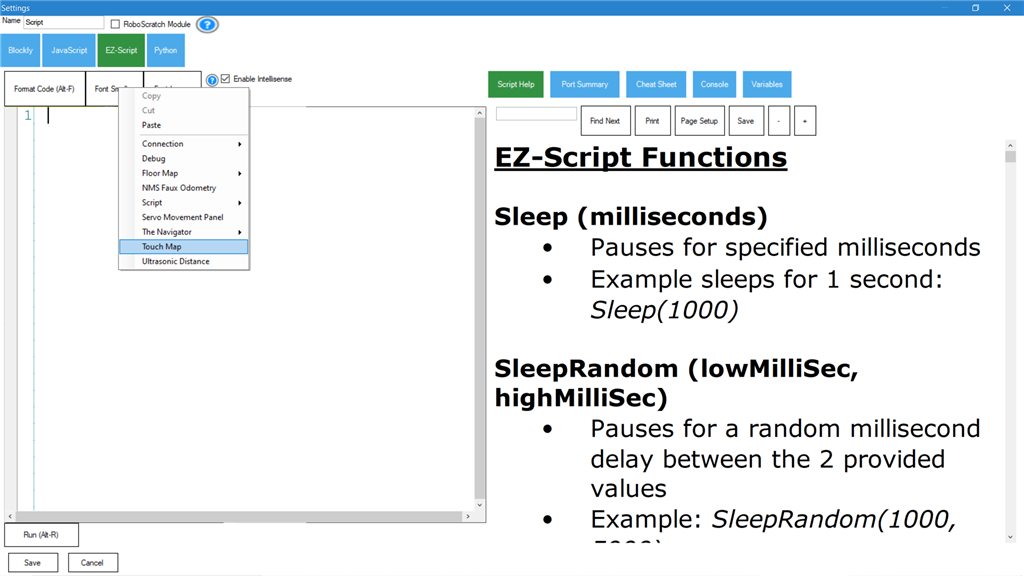
I am using the Floor map and Touch path maps and the Navigator, for simple path following - I am at my farm, on a hotspot and dangle with an IoTiny
my car follow it very nicely
Video will follow soon
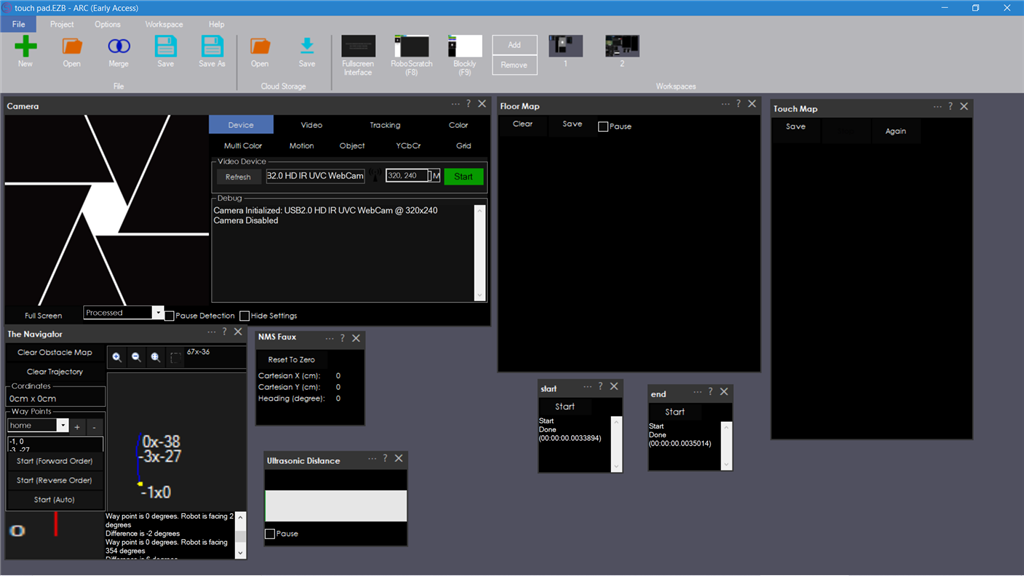
For actual navigation with way points, you need one of the Intel Realsense cameras
EzAng
By EzAng
— Last update
Discover more robots
Jdebay's Gripperv4 Old Parts And New Parts
Build Gripper V4 from old and new parts; updated design now includes an added camera.
Steve's Captain Proton Startrekvoyager Tribute Robot.
Captain Proton tribute robot built from Meccano with EZ-Robot EZ-B and HHD servos, LED eyes/mouth, PWM drive, plasma...
Kashyyyk's Star Wars D-O Droid
D-O droid powered by IoTiny and tablet-controlled; head too heavy for body servo so it was locked, bar mechanism still...

Nice ezang, waiting for the video!!
EzAng, That looks good. I wonder how it would work with the new NMS Faux Odometry and the Navigator, maybe you could set way points once you have your robot setup?
I plan on testing this all soon, thanks for viewing
Touch map is going great, fine tuned it for navigating back to me, the NMX faux odometry reads well which corresponds to the navigator's readings - can't do a video now, at the farm, try in a few hours in a city :-)
I notice in touch map, when I go to ad code there is no way to add any code - same with the ultrasonic sensor
Here is one video for now of the touch pad, wish I had a way to make way points and can label them, maybe one day
more to come
Use The Navigator if you want way-points. That’s why it exists.
For pose telemetry, use the Faux Odometer robot skill combined with The Navigator.
EDITED: I was working from memory. After looking in ARC I changed my answer below.
Very fun stuff. Amazing technology. How much easer can it get for us! LOL
EDITED: never mind. I didn't know what I was talking about. LOL.