


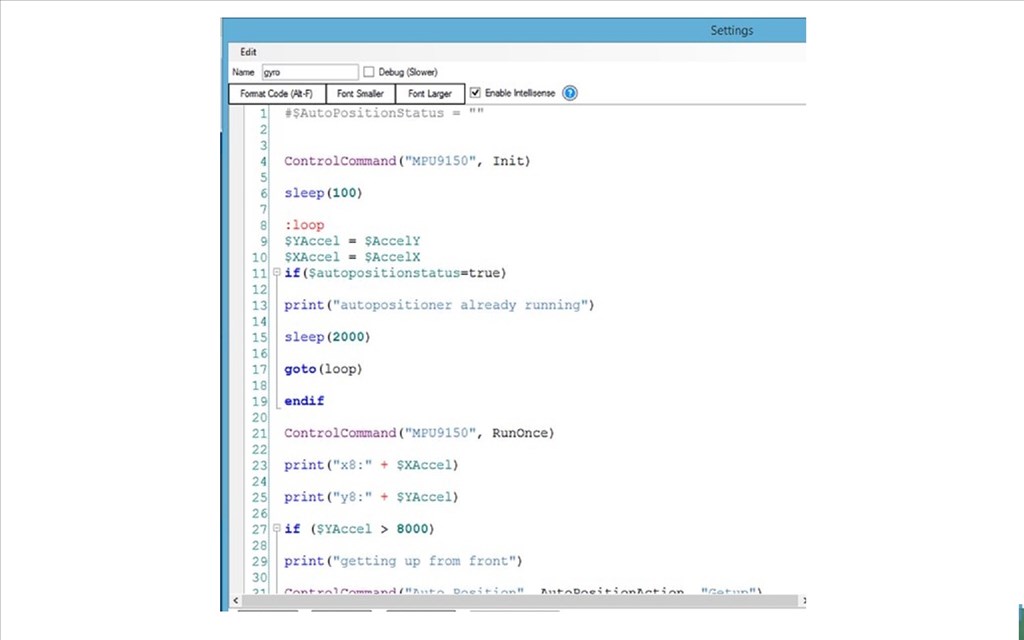
the gyro works great,only jd does the motion twice?
Asked
— Edited
 Resolved by CochranRobotics!
4 Participants
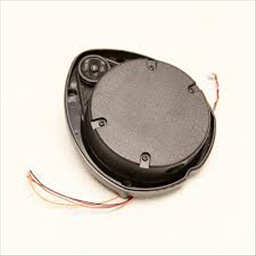 XV11 LIDAR
— Real-time 2D mapping from Neato XV-11 360° LIDAR via GetSurreal controller; exports $LIDARDistance/$LIDARIntensity, configurable angles, color, zoom.
Try it →
Resolved by CochranRobotics!
the gyro works great,only jd does the motion twice?

@nomad.
Show us the script you're using.
hi steve.
its says run once
Share your project by uploading the ezb file here.
i forgot how to do that.
@nomad.... look in you ez robot folder on your harddrive . Find your ezb project file... attach it to a post and upload it...
i try
jd-origineel.EZB
hope this works
@nomad.
yeah, the link for your project works fine. I had a quick look through it and can't see what is causing the issue I'm afraid. Hopefully someone else will be able to figure it out for you.