
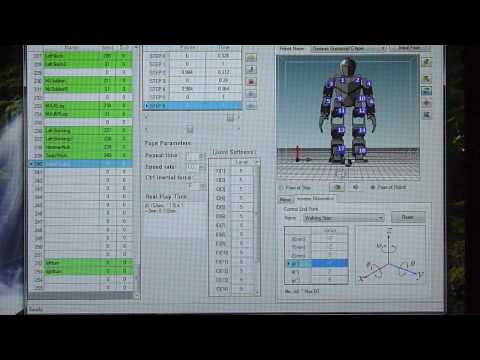
when i wanna use inverse kinematics and press enter the value goes to zero back again.when normal it chould take the pose you set.
Asked
— Edited
 Ultrasonic Collision Detection
— Stops robot movement (no steering) when an EZB-connected ultrasonic sensor detects an object within a set range; integrates with scripting and paused polling.
Try it →
when i wanna use inverse kinematics and press enter the value goes to zero back again.when normal it chould take the pose you set.

found it.it was left ctrl and enter