Hello!
At this year's University of Waterloo Enghack hackathon, 3 of my friends and I created a motion controlled robotic arm using scrap metal, plastic, a myo, a wii remote, and ARC . In the span of 20 hours we created this!
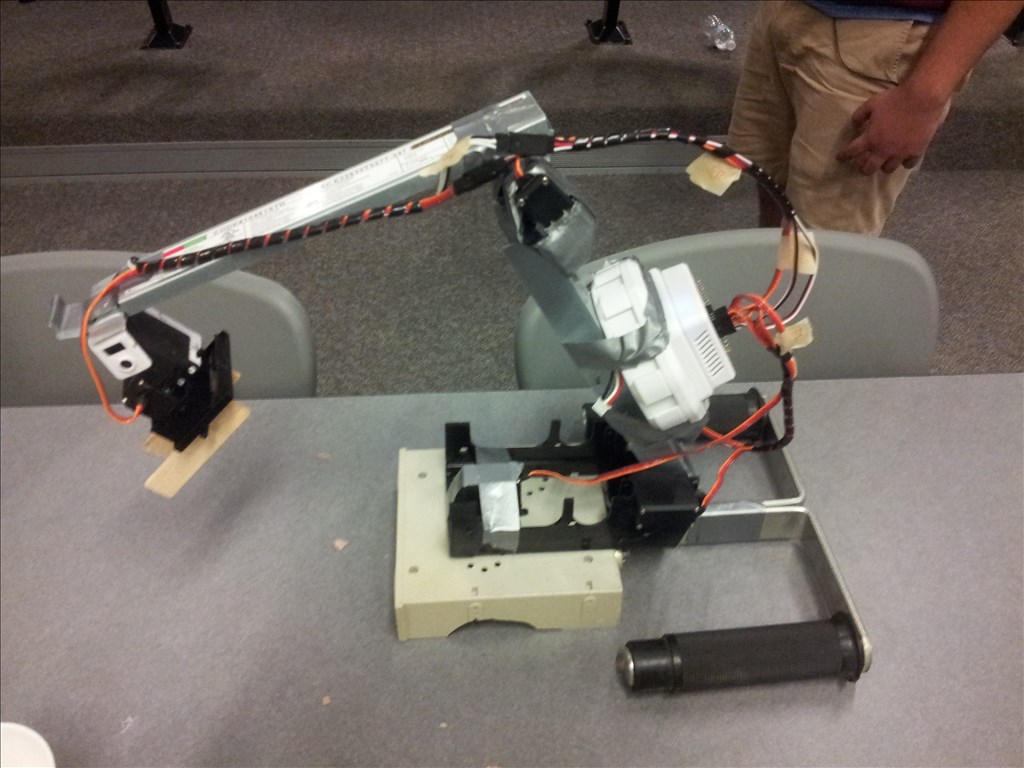
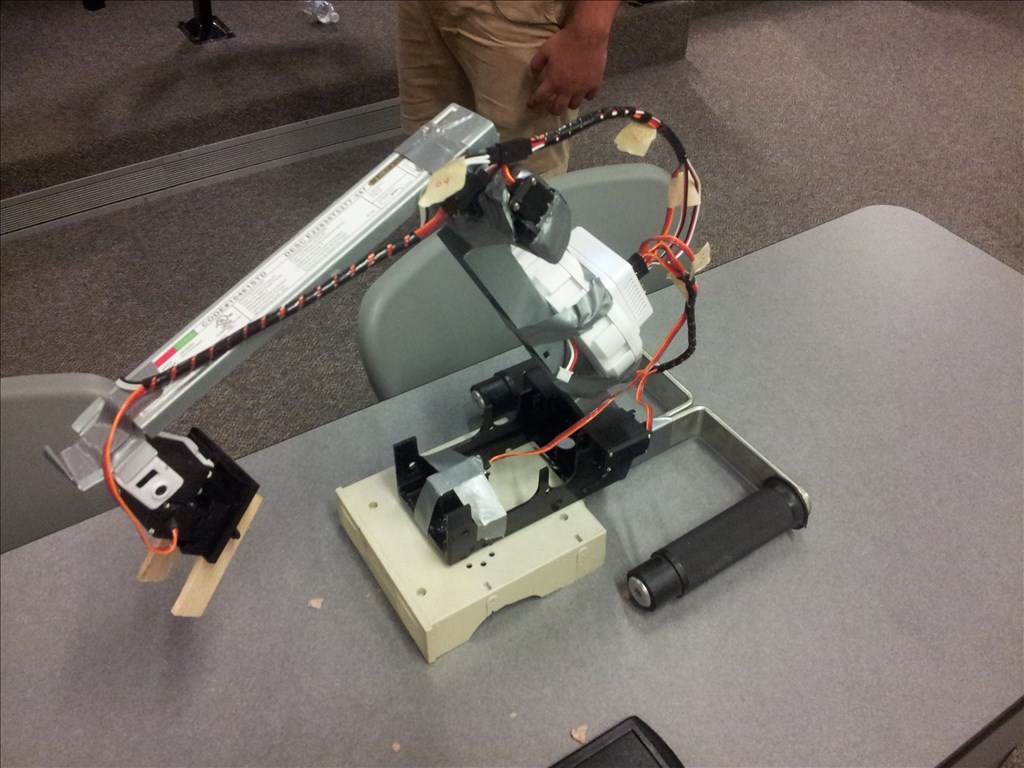
We got 3rd place and won this gift certificate!
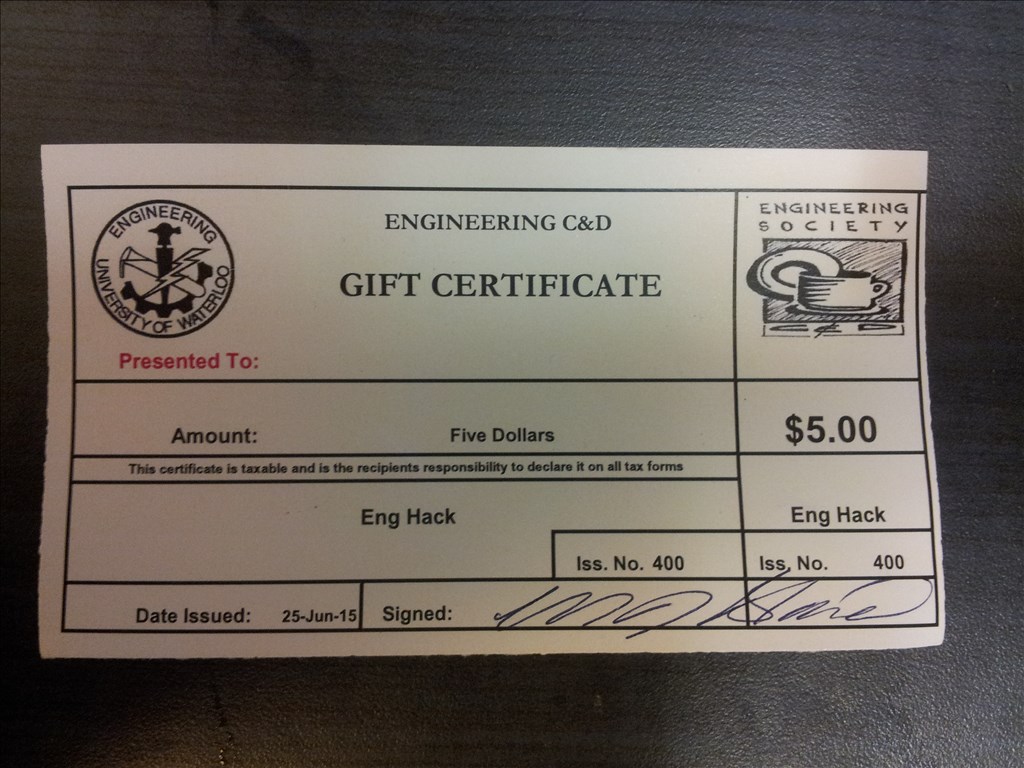
I think I'm going to frame it
By Johnnybib
— Last update

Discover more robots
Bhouston's My Inmoov Running On Synthiam
InMoov robot running on EZBv4 with 24 servos controlled successfully, demonstrating reliable single-board servo...
Moviemaker's Here Are Some Rebuild Pix Of Marti
Marti robot rebuild photos showcasing Hazbot arms, Gizmo neck and assorted borrowed parts highlighting restoration and...
David's 3D Printed Ez Robot Bob
Bob, a 3D-printed EZ robot built with EZ-Bits, 3D-printed parts and hot melt glue for DIY robotics and easy...

Awesome James! Great to see your skills being put to good use
I see the servos were a little shaky - i would recommend using the ServoSpeed() command on the INIT script for those servos. Perhaps setting them to a value of 2 or 3 will cushion the shakiness.
When you coming back to work at ez-robot?
I set the servos to a speed of 0.75 to slow them down since the arm would go crazy if you moved too fast. Does the servospeed command even take a double (or floats) as a parameter?
I should be back by August 31st
@James.... You built that arm in 20hrs? Not bad, not bad at all.... Love the duct tape..... LOL. I use it all the time when I need quick assembly...
congrats
Hahaha This thing is held together by duct tape, hot glue, screws and a little bit solder...
But mostly duct tape