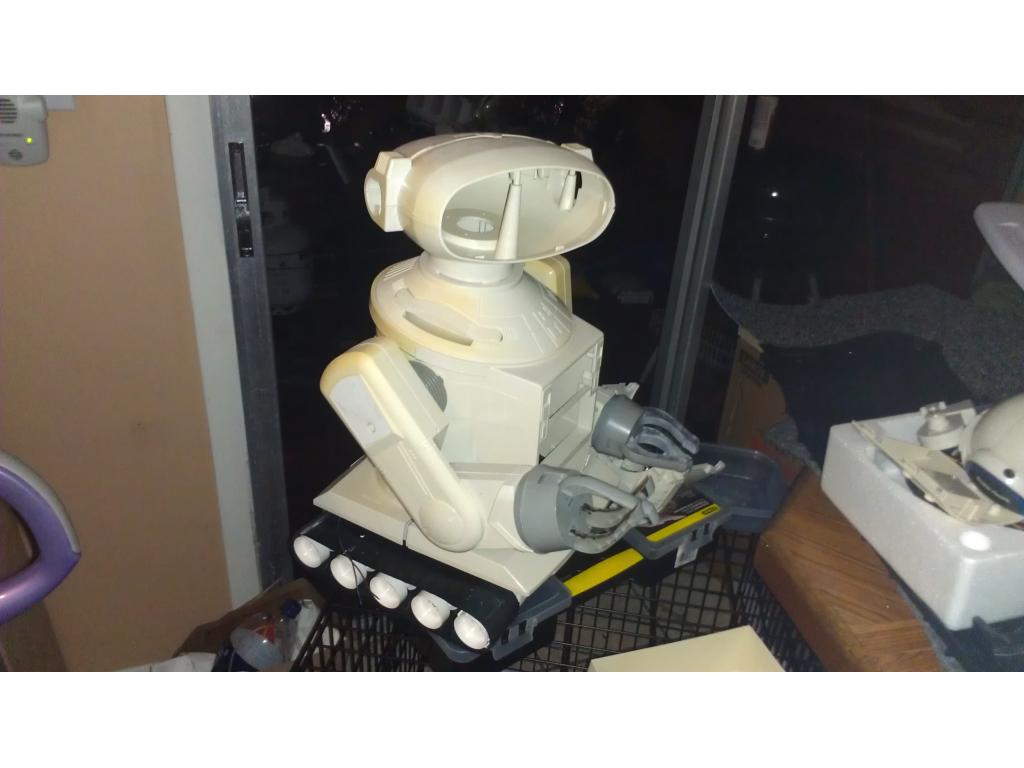
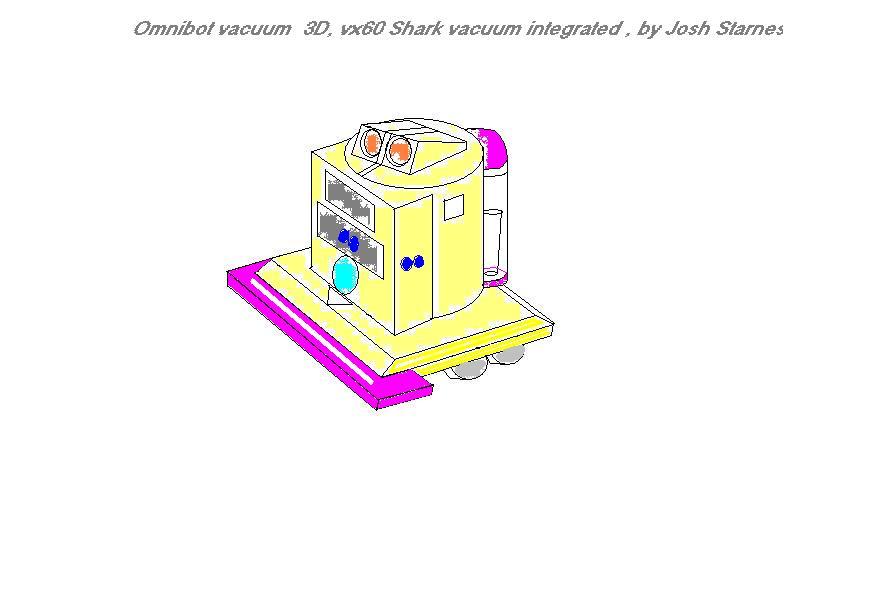
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
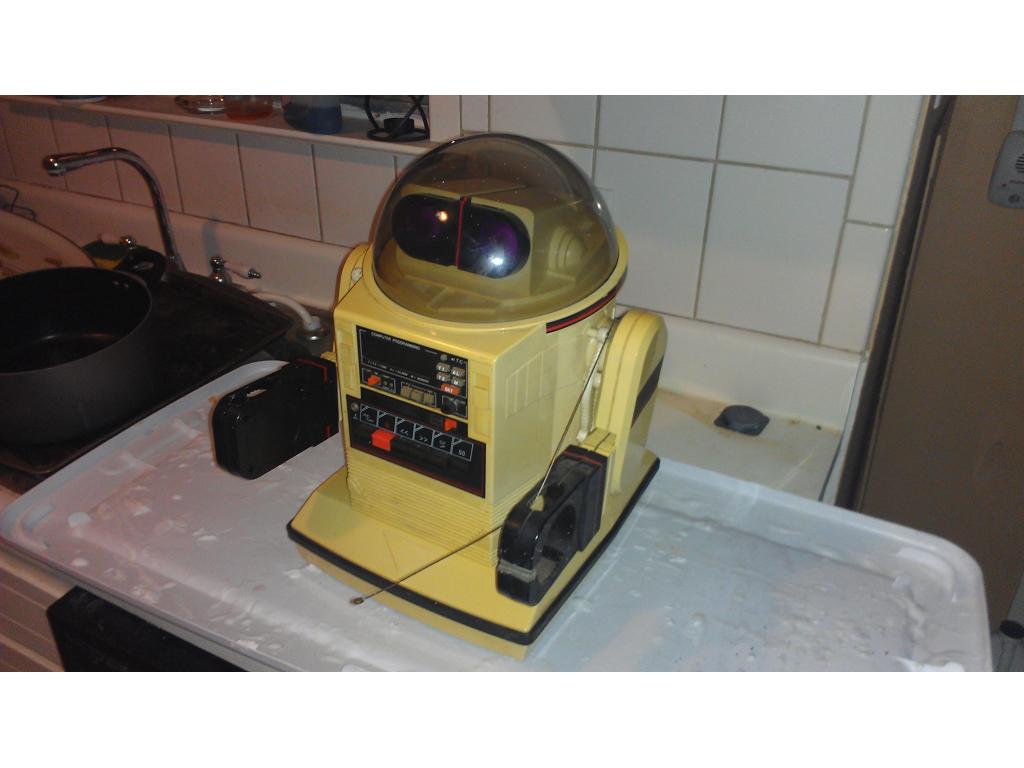
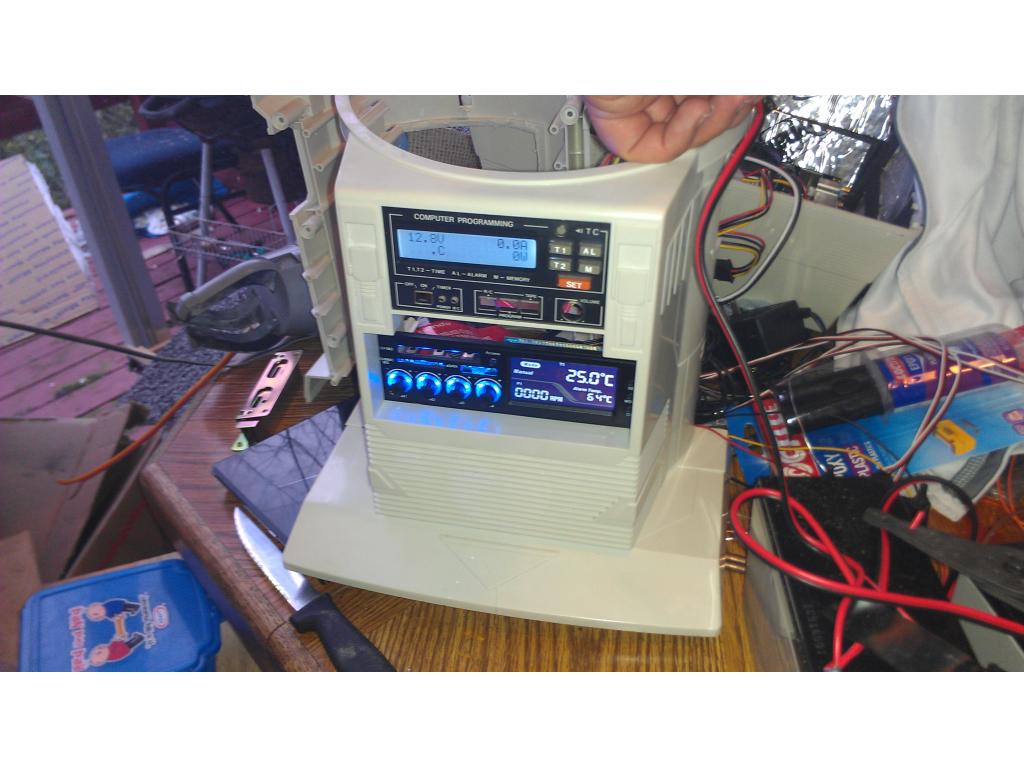

A charge station will be in the works shortly after hardware for movement is installed in Jarvis , the charge station will be marked with a IR beacon and glyph. All he will need is to drive up to the station and "bump" it , it sees voltage a relay flicks over and starts charging. I would prefer him back.up.onto a charging dock but that's all something to figure out later.
Bump it like the Neato Vacuum bot?
Um I guess
i design a really good auto docking charging system ,to charge up to 125 amps and 24 volt gel cell battery,the design is voltage adjustable and current plus cell count,i had 3 boards done and looking to sell my design outo dock using IR and sonars ,plus laser guidance very close to the IROBOT roomba its uses a on-board computer (itx board) to talk and guild me leaf robot in what type of charging plates are you using
@SFOY i am working on a progr am to autostart EZ -BUILDER ,looking to post it soon hope to get back to robot building on tuesday,starting to feel better from my fall
How does the robot find the dock?
laser tractor beam same used on the ROOMBA vacuum robot using laser ,plus ir ,plus sonar,receiver is on the robot and the transmitter is on the docking system sends a 180 deg or more signal out in the room,when the receiver on the robot picks up the beacon then IR AND SONARS works the wheels togo forward into the dock,sonar tells it to stop,also uses WIFI to start and stop the charging system when the battery is fully charged
it also when the battery is low on the robot the WIFI tells the docking system to turn on
it my biggest design i ever made so far
Ok I already have the rear sonar but how does the IR and laser work , please be specific as to what I need , how it works , I would like Jarvis to back up to a charger.
IR is used only for distance to the robot and for the sides lare IR SENDS 38 kz signal in a 180 deg path ,on the robot i have a receiver and a omnicone thats 360 deg if you look up how the ROOMBA tractor beam works you can how part of it works rest is using part of the LEAF microcontroller board looking to see if i can get EZB TO TALK TO ANOTHER EZB is my next design,more like a slave/master works