Credit for this robot idea goes to @Nink, who suggested it based on my PWM servo Feedback behavior control.
I wrote a quick script that reads the realtime servos of one JD and sets the respective positions of the other JD. Both JD's are connected to the network in client mode.
If you're curious of the code, it looks like this
:loop
# Left Leg
servo(1.d14, GetServoRealtime(0.d14))
servo(1.d13, GetServoRealtime(0.d13))
servo(1.d12, GetServoRealtime(0.d12))
# Right Leg
servo(1.d18, GetServoRealtime(0.d18))
servo(1.d17, GetServoRealtime(0.d17))
servo(1.d16, GetServoRealtime(0.d16))
goto(loop)
Here's the project JD Puppet.EZB
By DJ Sures
Discover more robots
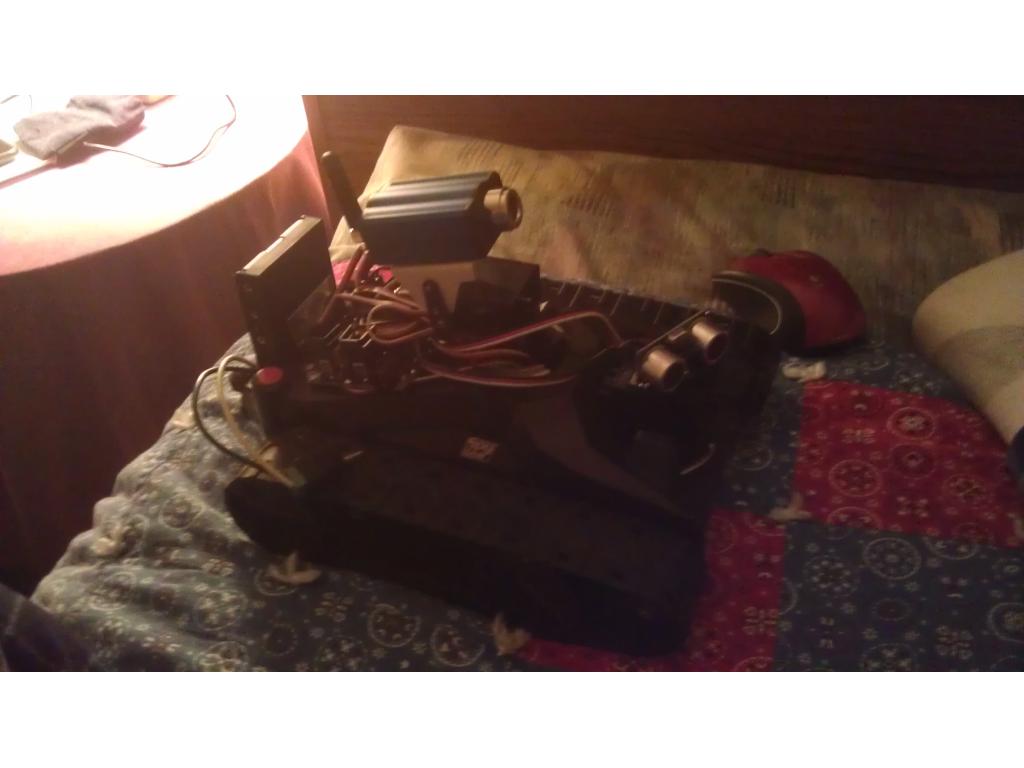
J's Rover My First Bot
Scout robot from a 14-inch Mega-Byte thrift-store toy; modified servos, one stripped gear, budget DIY home driving.
Ezang's Mr. Metal Again 2021 - Made From Servo City Parts -...
Greeting from Mr. Metal wishing everyone well and announcing a body move soon - signed EzAng
Ezang's My New Robot Hand To Practice With - Video
Synthiam ARC controls a DIY robot hand with auto-positioning via Arduino Uno; servos glued for quick prototyping
