
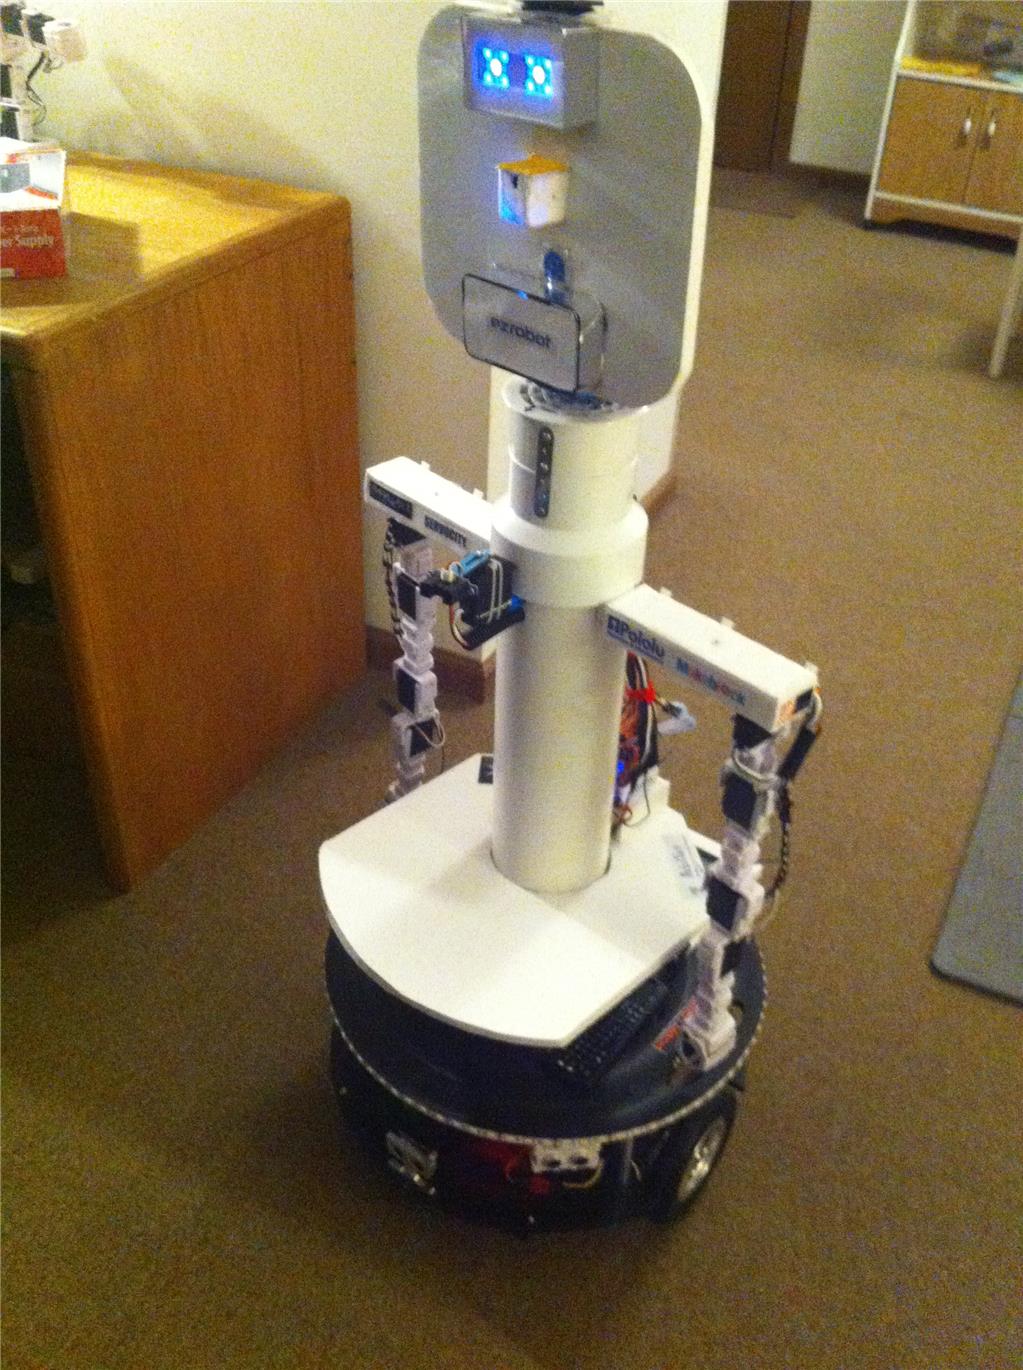
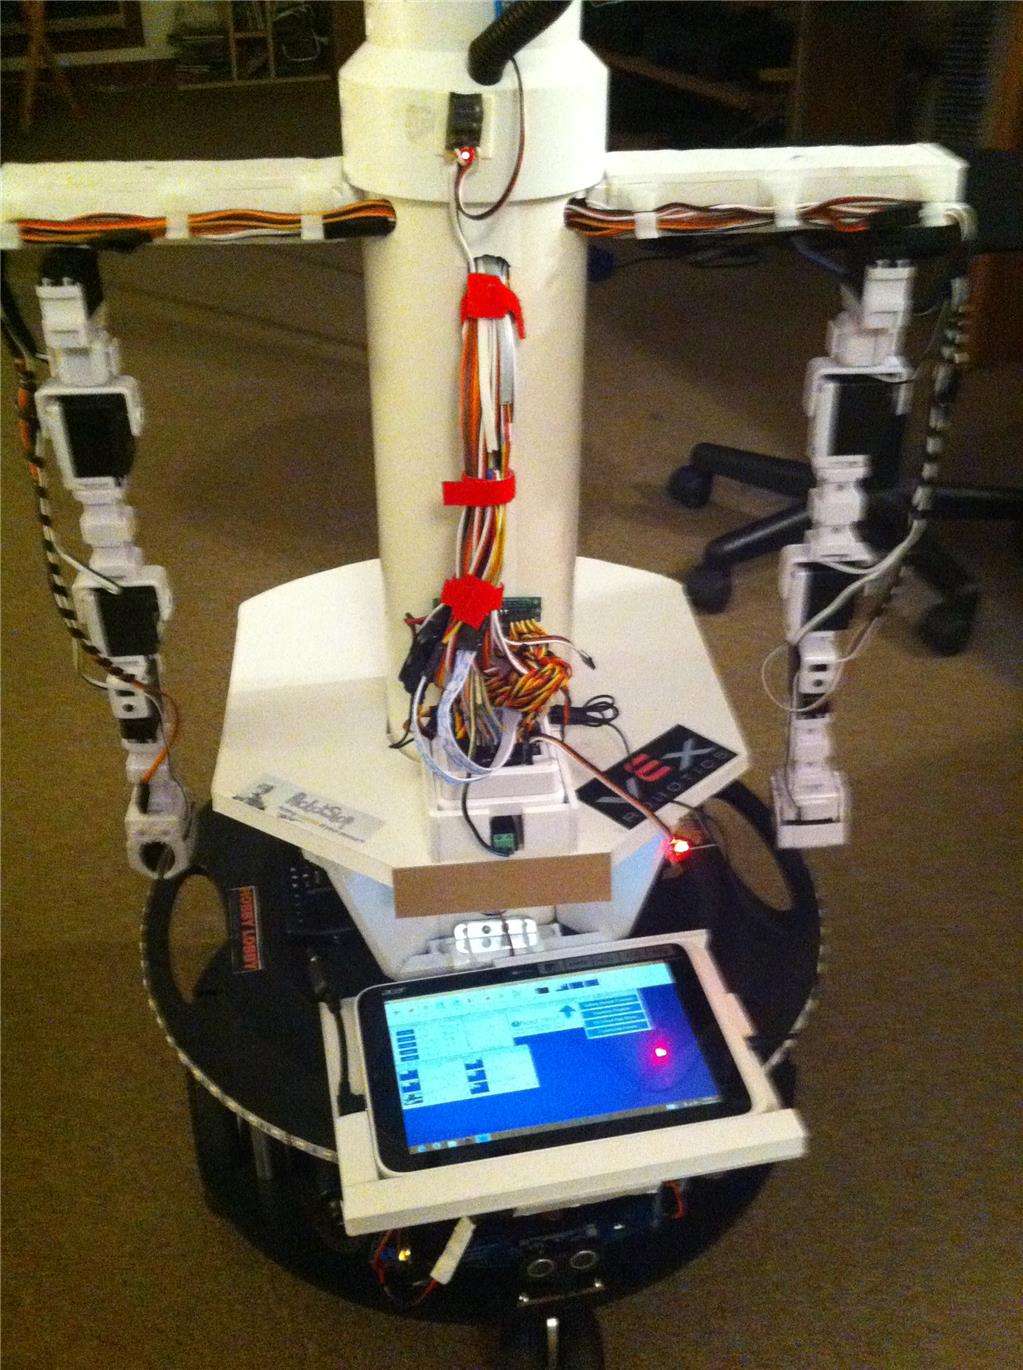
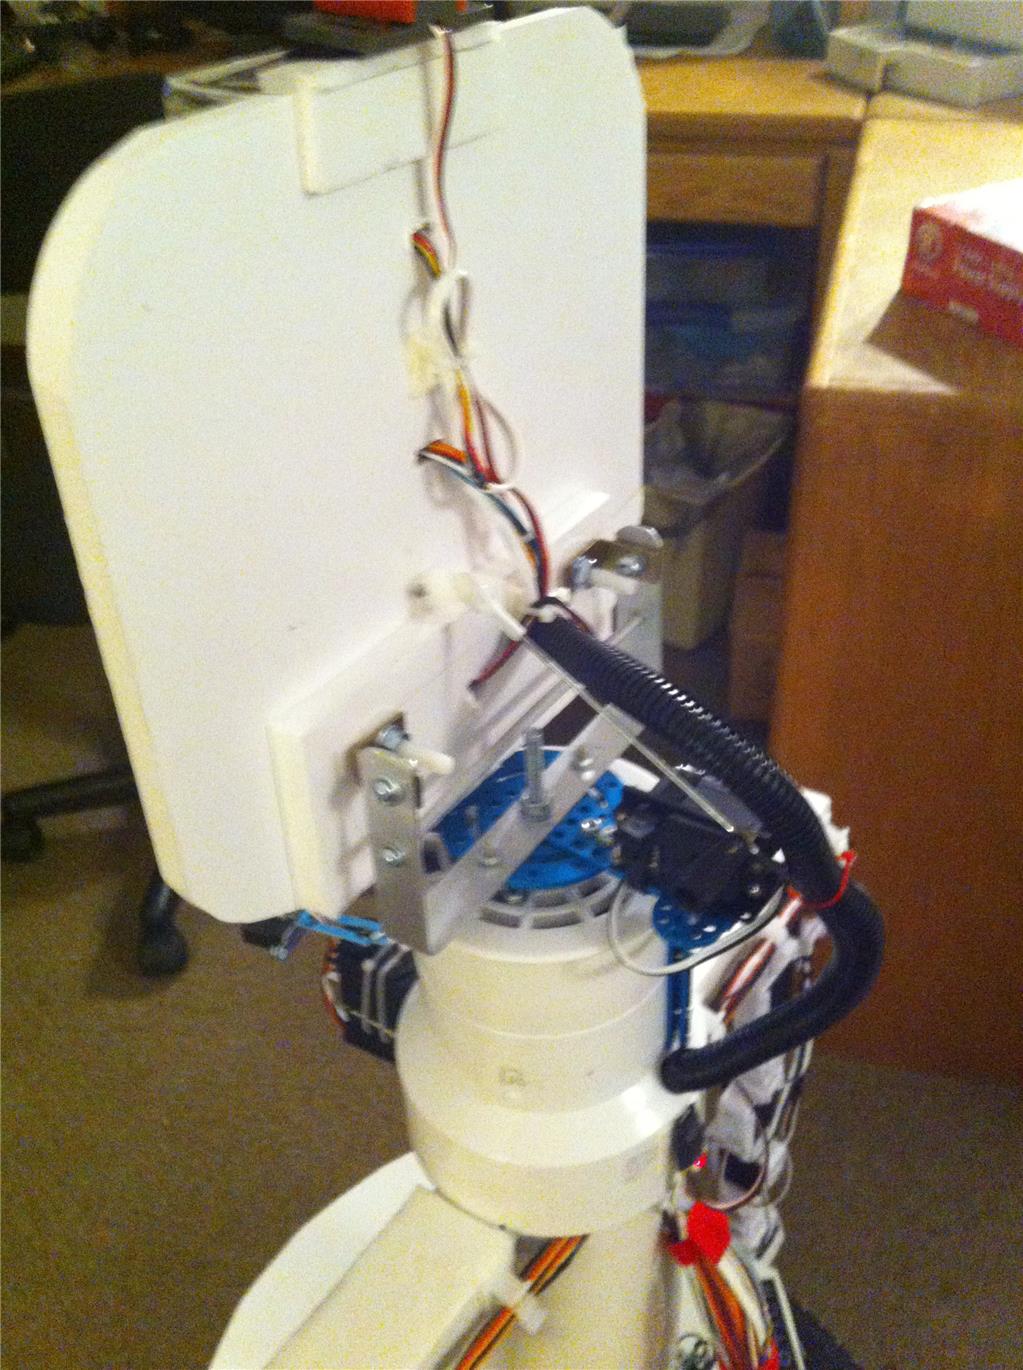
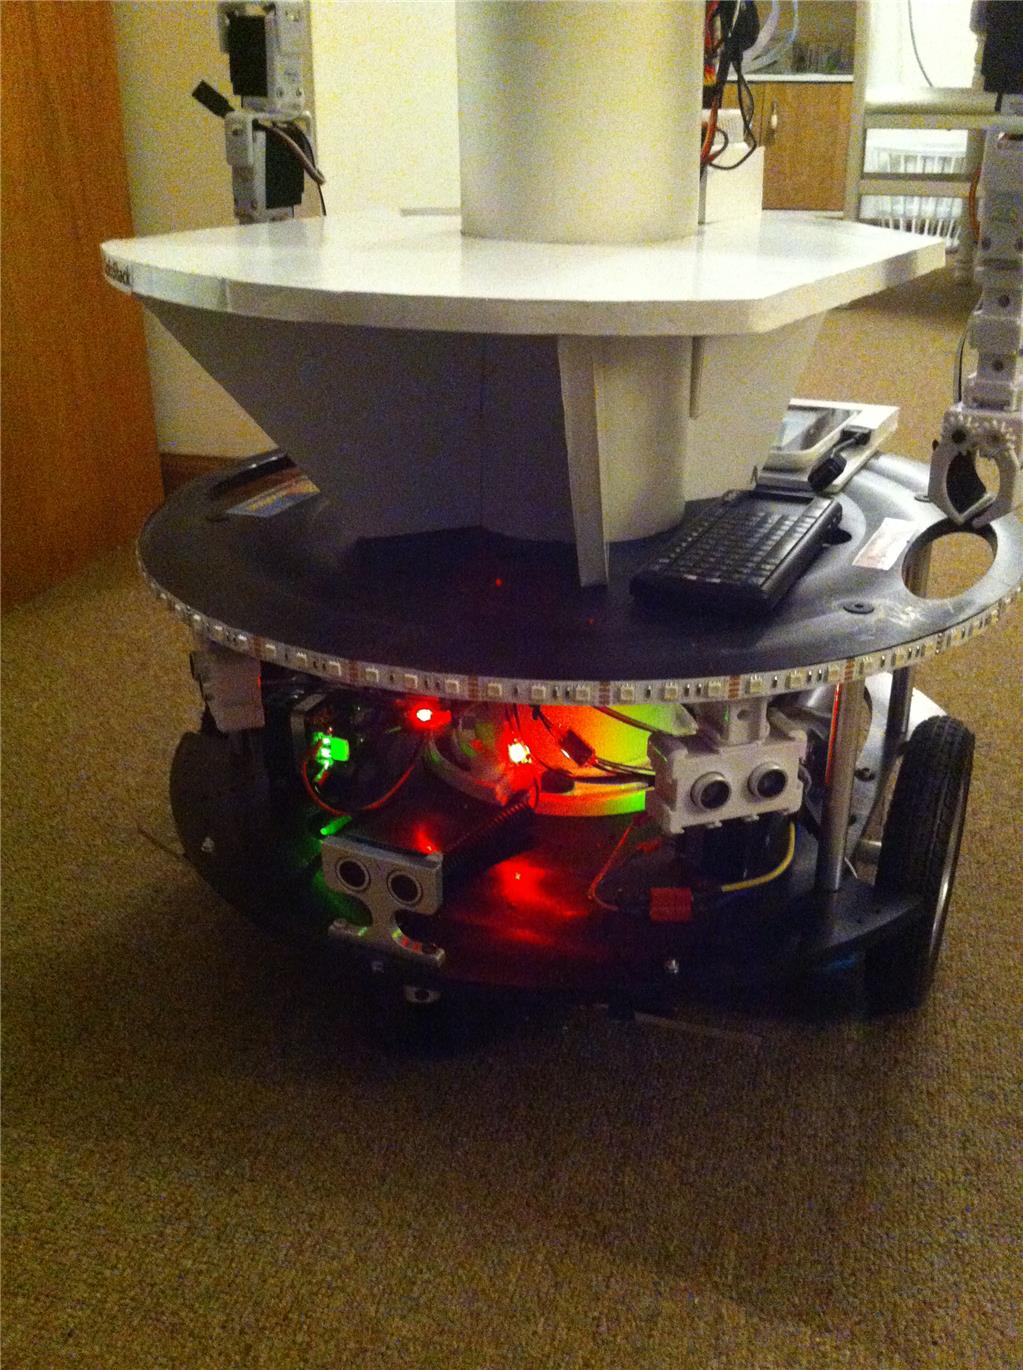
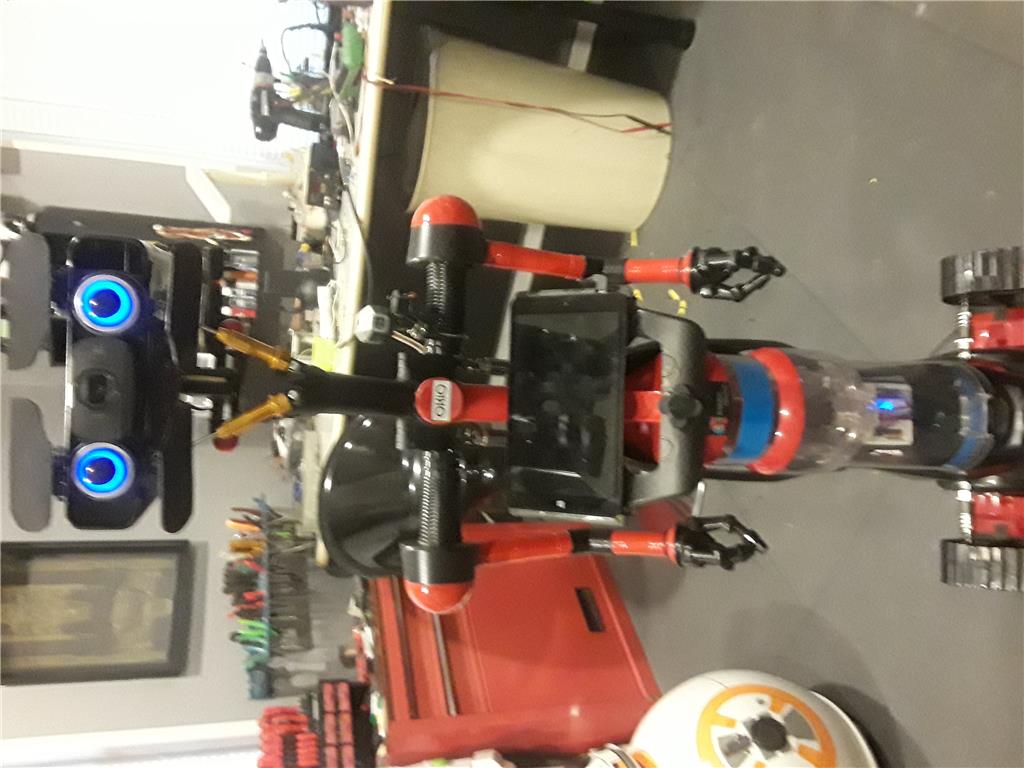
Hi guys, Thought I would show off my robot again. This is Cybot 2.0. The big change I did was get rid of that big laptop of a head and went with something a bit more normal size I think, now that I have an Acer W3 to control it. The head now is just basic speaker,ezb camera, and the rgb animator. Do plan on adding more cool sensors later on.
I hope to do a video of him moving about soon too.
By RoboHappy
— Last update
Discover more robots
Justinratliff's Mini B
Mini B robot from Bret Tallent arrived damaged; repairing broken head, camera PCB, neck servo and right arm; RAD power...
Rb550f's Okio J5 Style Robot Project
OKIO J5-style 44" robot built from an upright vacuum: Dremel head, LED eyes, HD USB camera, Windows 10 tablet,...
Robohappy's Introducing....HEMI Or HHCB1 (Home Health Care...
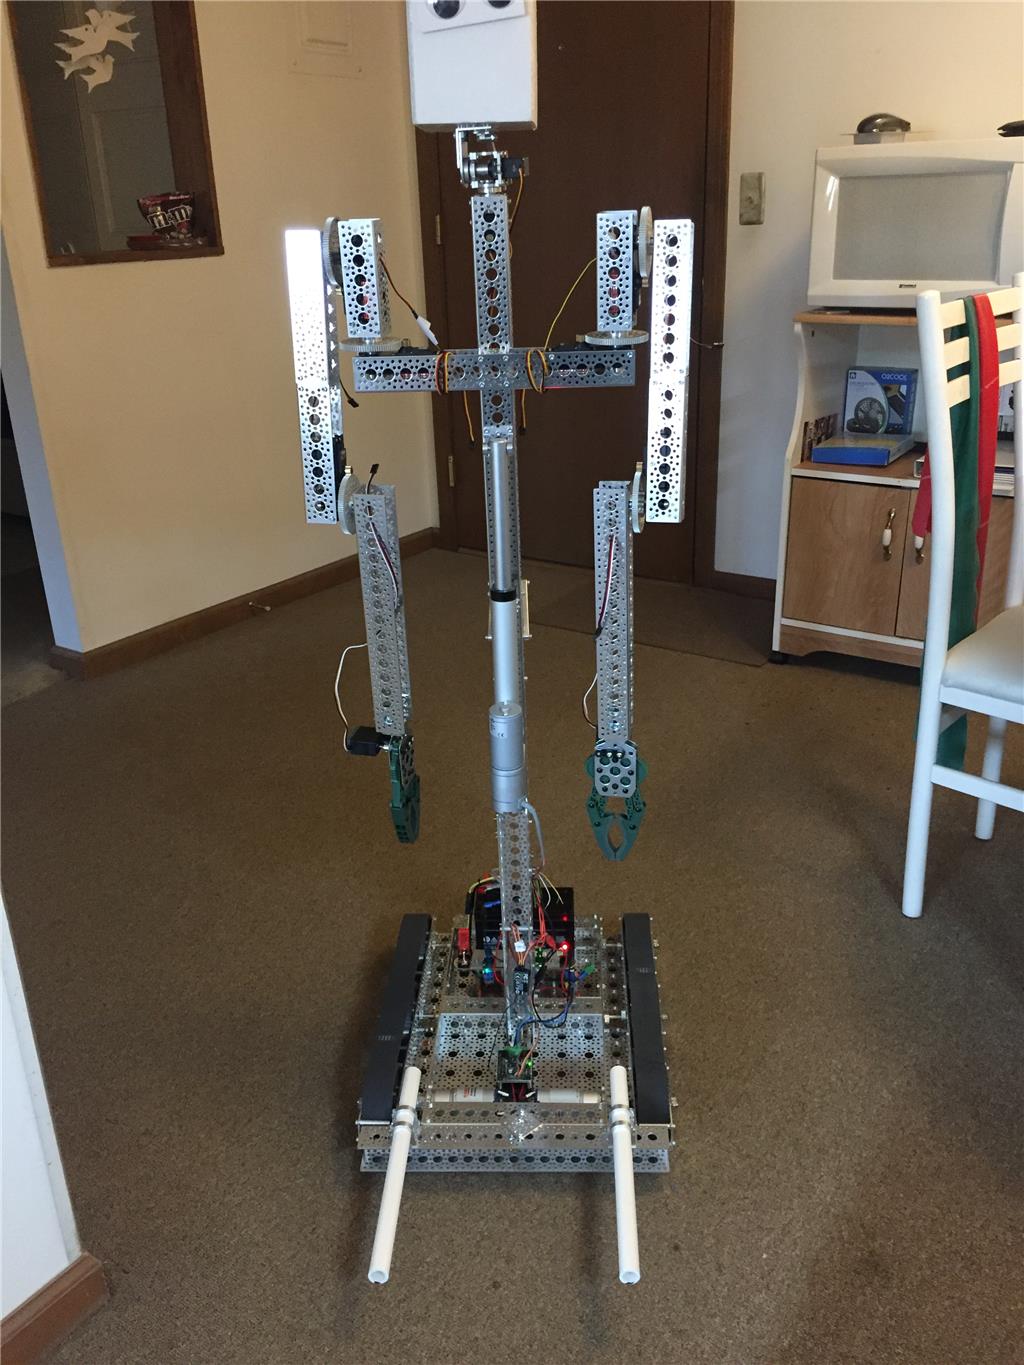
HEMI home-health robot prototype lifts and transfers patients using high-torque servos, actuator, sensors, EZ-B control,...
Wow thanks for sharing! I'm a huge fan of this robot. Moving the laptop away from the head was such a great idea for the overall personality.
Nice cool impressive looking robot ! Great job. Btw, did you build the base plate and/or drive train (DC motors) yourself or is it a kit from a vendor ? Looking forward to see video's.
Thanks DJ, I appreciate that! glad you like It still needs some tweeking to its looks I think, but am overall happy with it. Would love any thoughts on how to make it a little cooler looking

PHG, thank you. the motor/base portion was purchased from Parallax, inc. (and while it runs at a moderate speed, I'd love to add more speed later on). Also, you may notice the various other vender names I've stuck on all over CY. its kinda my tribute to all those who helped make Cybot2.0 possible.
Now the fun part. I've made many little scripts to test out the various parts of it, so next is integrating it all together, and tweek it as I progress. Next big steps might be to add a few verbal responses to come commands, and would like to still work on some touch sensor for the grippers.
When I figure out how to upload to youtube, I will at least show off a few things its able to do now.
To be continued....
Well, here goes, my first video. This is justa short clip of testing the Emergerncstop button located on the top of the head. https://youtu.be/_RaEyn5VlaY
The Parallax wheel base is a great product but for me a little expensive. I've seen it in action and indeed it can go really fast. Nice video.
Thought I would add another quick video. I have couple more on the way. https://youtu.be/GS6OxQOjdi0
A couple more videos. These are just showing off more of Cys movements. Hope you like!
https://youtu.be/KQXua85Dj6k
https://youtu.be/MbEsprFe6Fw
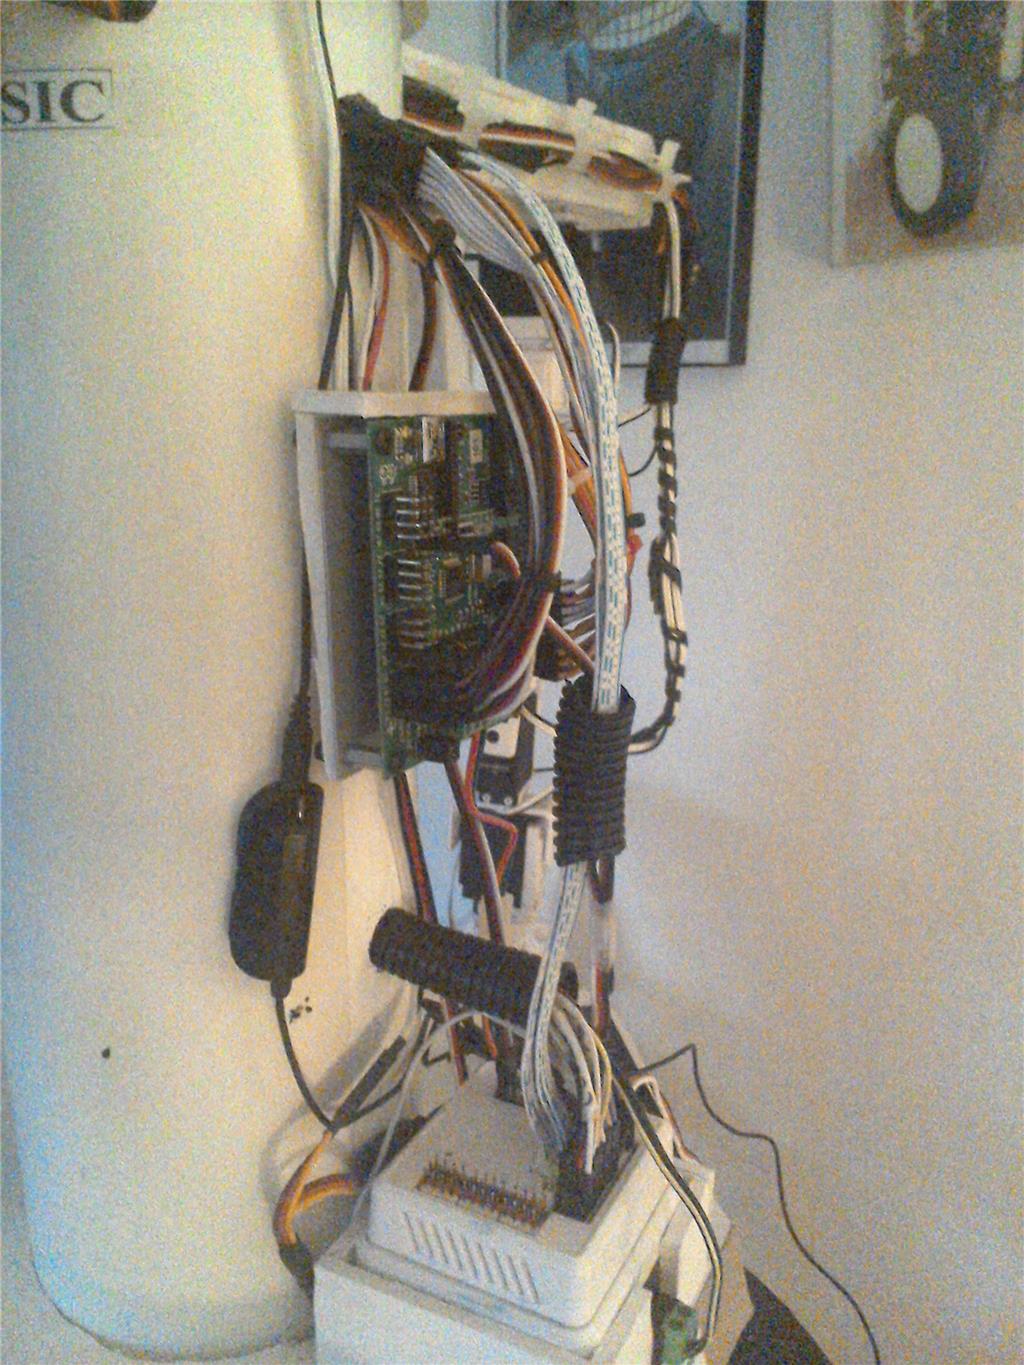
Cy got a little improvement. Since I recently installed the SSC32, I was able to improve the wire management on the backside. It cleaned up nicely and opened up some ports on the EZB for future add-ons (like some of the other sensors Ive seen featured on here). What you think?