
 Resolved by




Hi,
I am working on creating a full scale humanoid robot using the EZ-B V4 controller and the servos from the JD robot. The servos are attached to a 3D printed skeleton. The battery would only last about 1 minute before the "my battery is low" warning came on. I thought I damaged the battery. So I purchased a new battery charged it for 1 1/2 hours, installed it into the controller and the controller did the same thing, the battery lasted about 1 minute. So now I suspect the load is very high on the servos and drains the battery quickly. It there any way to connect the charger directly to controller without a battery? I see other custom robots on community site and they don't appear to be battery powered but using EZ_B V4 controllers.
Thanks for your help, Brooks


Thanks everyone for your support.
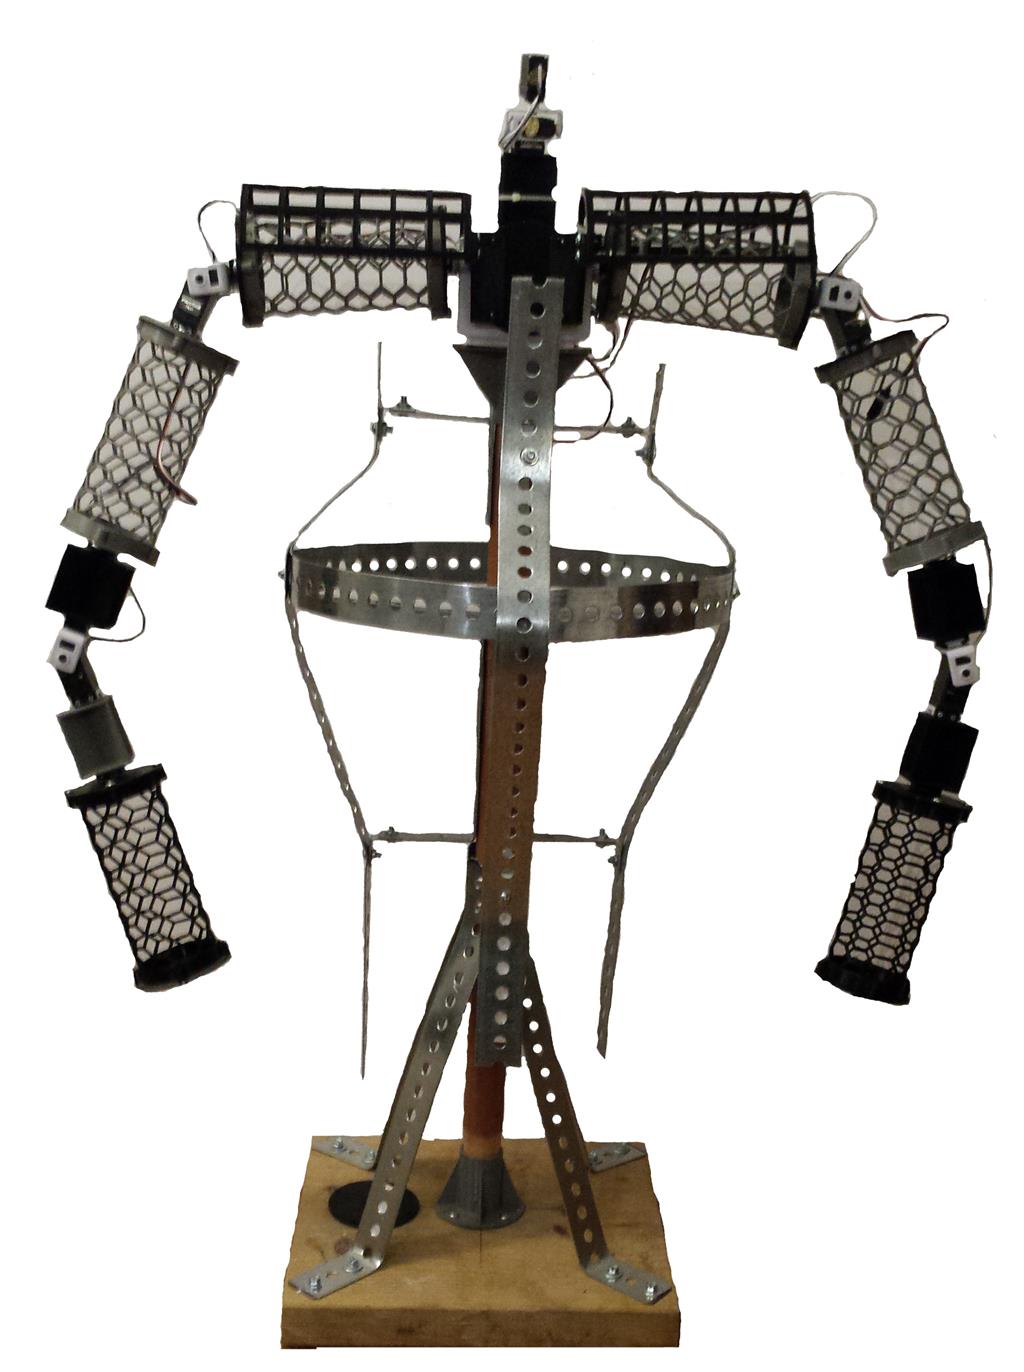
I will add the rubber bands (like tendons) great suggestion. I will also purchase a 5V 20 amp power supply. I redesigned the shoulders with a the 3D printed "strap" that now takes the load off the servo and transfers to the black exoskelton above still allowing the shoulder to rotate. I agree that I'm pushing the limit of these HDD servos. The rotational inertia is high but I have built the skeleton to be very light but strong. See the pic.
Keep us posted on your progress. This is very interesting.