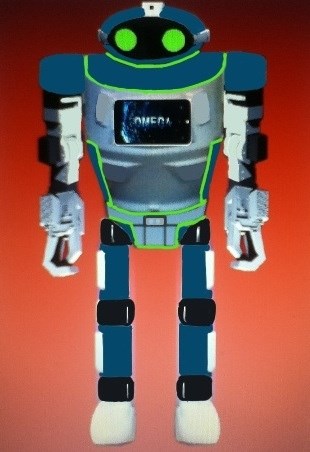
Well I spent a little time and decisions on how I should make the look for omega's bipedal concept design and I came out with this, of course the arms my change if the fembots arms are released for sale on xlrobots.com becuase they are better designed and a five finger gripper is a must lol
By Linux robot 92
— Last update

Discover more robots
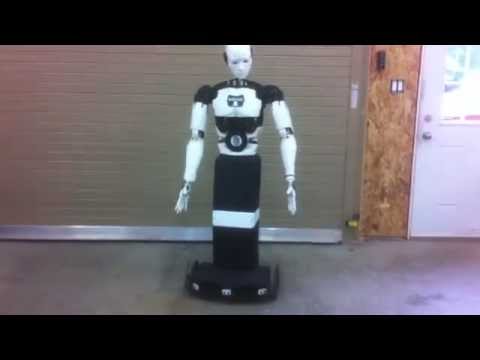
Bhouston's My Inmoov's New Base
Custom base for InMoov robot - a quick look at the base I built.
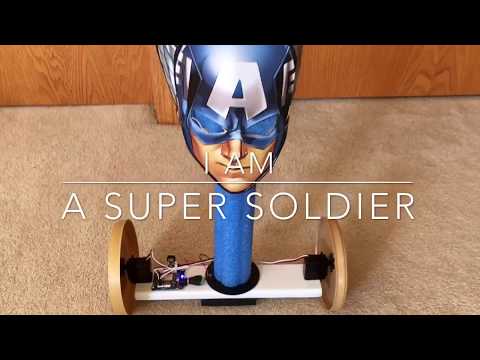
Haydenbot's Hayden's First Robot Captain America
Captain America robot built with loTiny EZ Robot controller and continuous servos; EZ Robot ramp-up scripts smooth...
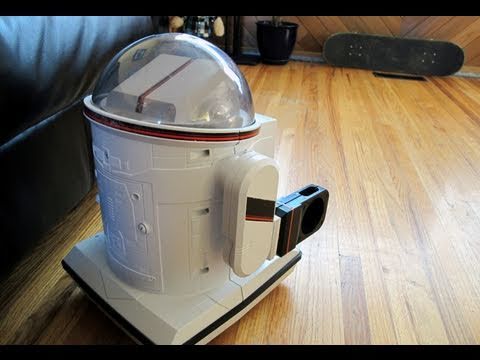
DJ's Omnibot TV Watching
Synthiam ARC and EZ-SDK enhanced motion tracking with improved edge detection for omnibot vision, demonstrating cartoon...

I'm not sure, i was going to use the a HD7 Lexi arms with moddifed shoulder joints for max flexibility from your xlrobots website and the legs I was also going to use the xlr one's arms with moddified elbow joint part for the ankles, also the feet are basicly a bigger scale of jd's feet or ones simular to asimo's feet and I am going to distrubute some bolts,nuts and springs as a way to reduce the weight on the joints and to straighten its ability to walk or pick things up. As far as the bipedal motion goes I will just have to study my anatomy to understand the motion of walking in human bipeds and use a series of trial and error to come up with a perfect motion for omega, he will most likely be suspended by cable for a lil while til he gets it right lol