
My robot would be sitting at a table, and it would look down at the objects on that table. It would be able identify the objects on the table: salt, pepper, a can of beer, a knife, a plate a spoon, and carrots on the plate. It would also know the coordinates of each object in 3D space of each object. Knowing that it would reach out and pick up the beer. I think Tensorflow can do some of this already. Microsoft Cognitive vision gives you the objects it sees, but not the locations.


Discover more robots
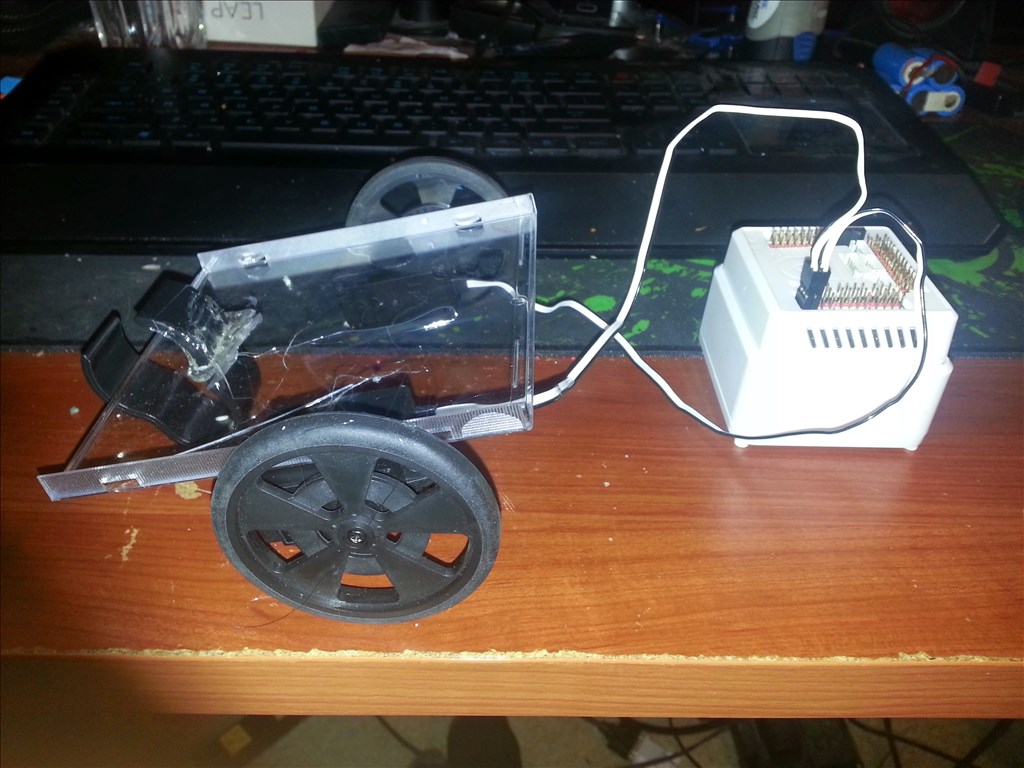
Morbeious's Alpha (Dev Servo Bot)
Dev Servo Bot using Ez-bit parts and recycled materials: CD-case caster, cable clip, hot-glued frame and sonar for...
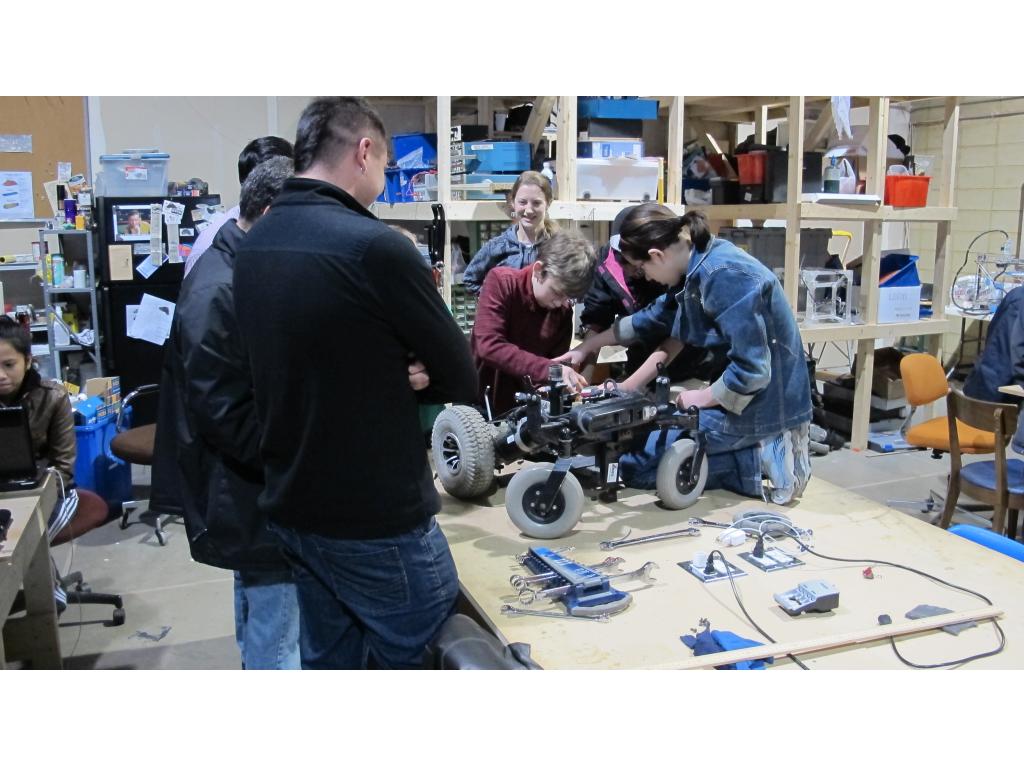
DJ's Ez-Robot Takes The Secret Challenge Competition
EZ-Robot sponsors kids building an Off-Roadbot for Western Canadian Robot Games-assembling platform, motors, controller,...
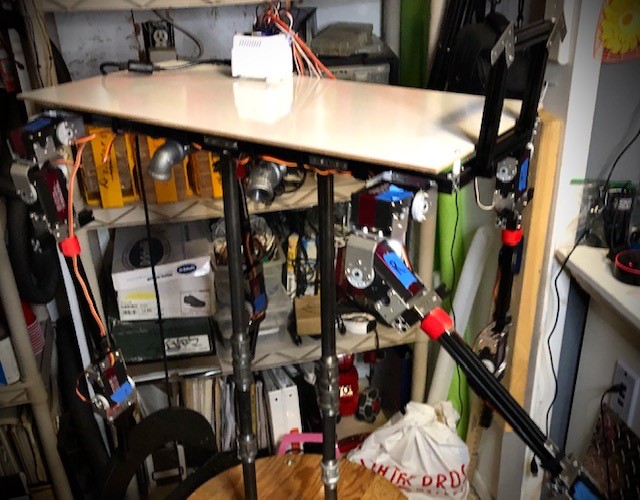
Tmesserschmidt's Topsie The Easy To Build Robot Dog
Build Topsie, a low-cost DIY quadruped-no 3D printing or soldering; assemble in a week and program walking gaits with...
