I am working on the SLAM problem (Simultaneous Location and Mapping). I would like to have my robot perceive of the world in such a way that it can map it and localize itself on it using its camera. I have some ideas here, and they are software related (Artificial Intelligence). This is a complex and only partially solved problem by the robot / AI community.
By jop
Discover more robots
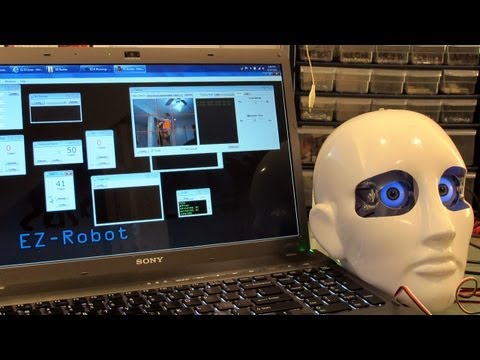
DJ's Robot Head
Synthiam ARC adds relative servo tracking for animatronic heads, using a stationary camera and EZ-B to move eyes and...
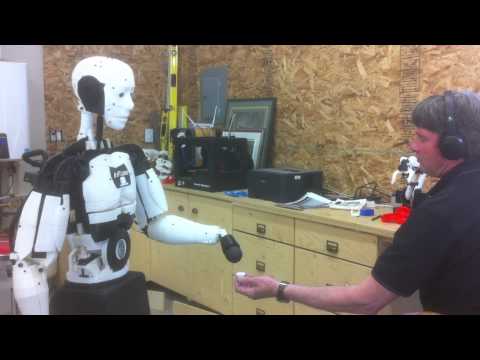
Bhouston's Inmoov's New Gripper
3D-printed syringe-powered universal gripper adapted for InMoov arm; picks up small objects; EZ-Robot OS enables easy...
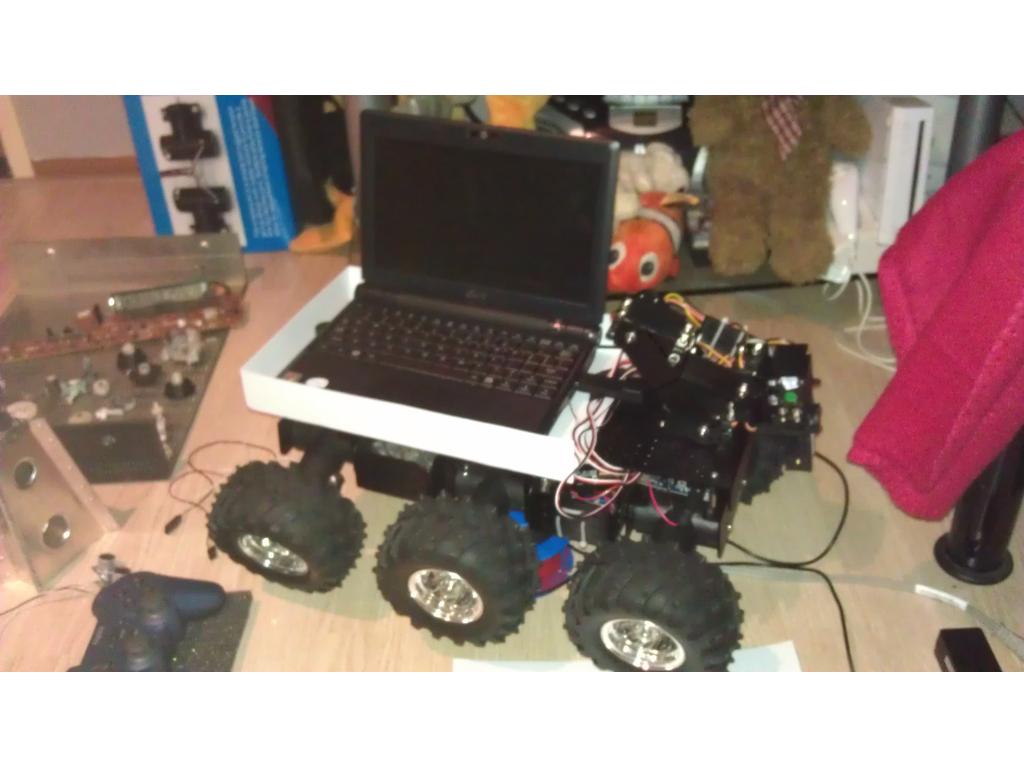
Budel0's R.O.O.S.T.E.R.
R.O.O.S.T.E.R: 6-wheeled Wild Thumper with 5-DOF arm, netbook, EZ-B control, six motors, ESCs, ping sensor and planned...
