I am working on the SLAM problem (Simultaneous Location and Mapping). I would like to have my robot perceive of the world in such a way that it can map it and localize itself on it using its camera. I have some ideas here, and they are software related (Artificial Intelligence). This is a complex and only partially solved problem by the robot / AI community.
By jop
Discover more robots
Jstarne1's Nano Smart Aquarium
Control lighting, current, temperature and salinity with EZB; full build, electronics, wiring and scripts for...
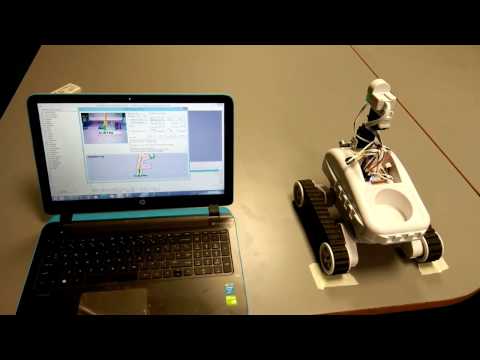
Recon's Development Of Autonomous Navigation Robot
Autonomous navigation robot on Roli Rover using EZ-Builder and RoboRealm, demoed as a final-year project; tutorial...
Buratino's Luxor Cab As Seen In Back To The Future 2 -...
Luxor Cab BTTF2 replica: 3D-printed, CAD-refined Citroën Pallas model with servo-driven landing gear, integrated LEDs...
