
I have a question regarding the Feetech RS485 servo robot skill in the Synthiam ARC software. Where can I find a detailed description of the internal workings of this skill? Specifically, I would like to know how to switch between continuous speed mode and position mode while maintaining full control over all parameters.

PRO
rob.knight
France
Asked
1 Participant
Feetech RS485 Servo Skill Query
Related Hardware (view all EZB hardware)
Arduino Due/Mega
by Arduino
Arduino Mega with Synthiam ARCx controls 24 servos, 13 PWM, sensors and serial modules via EZB firmware over USB.
USB
Servos
24
Camera
Audio
UART
3
I2C
ADC
8
Digital
21
Related Robot Skill (view all robot skills)
Feetech RS485 Servo
by FeeTech
Control Feetech serial bus smart servos via EZB UART or PC COM port in ARC using virtual ports mapped to servo IDs.
Requires ARC
v10

There is an older codebase of the Feetech robot skill in Synthiam’s GitHub page. Here is the link: https://github.com/synthiam/Behavior_Control_Feetch_Bus_Servos
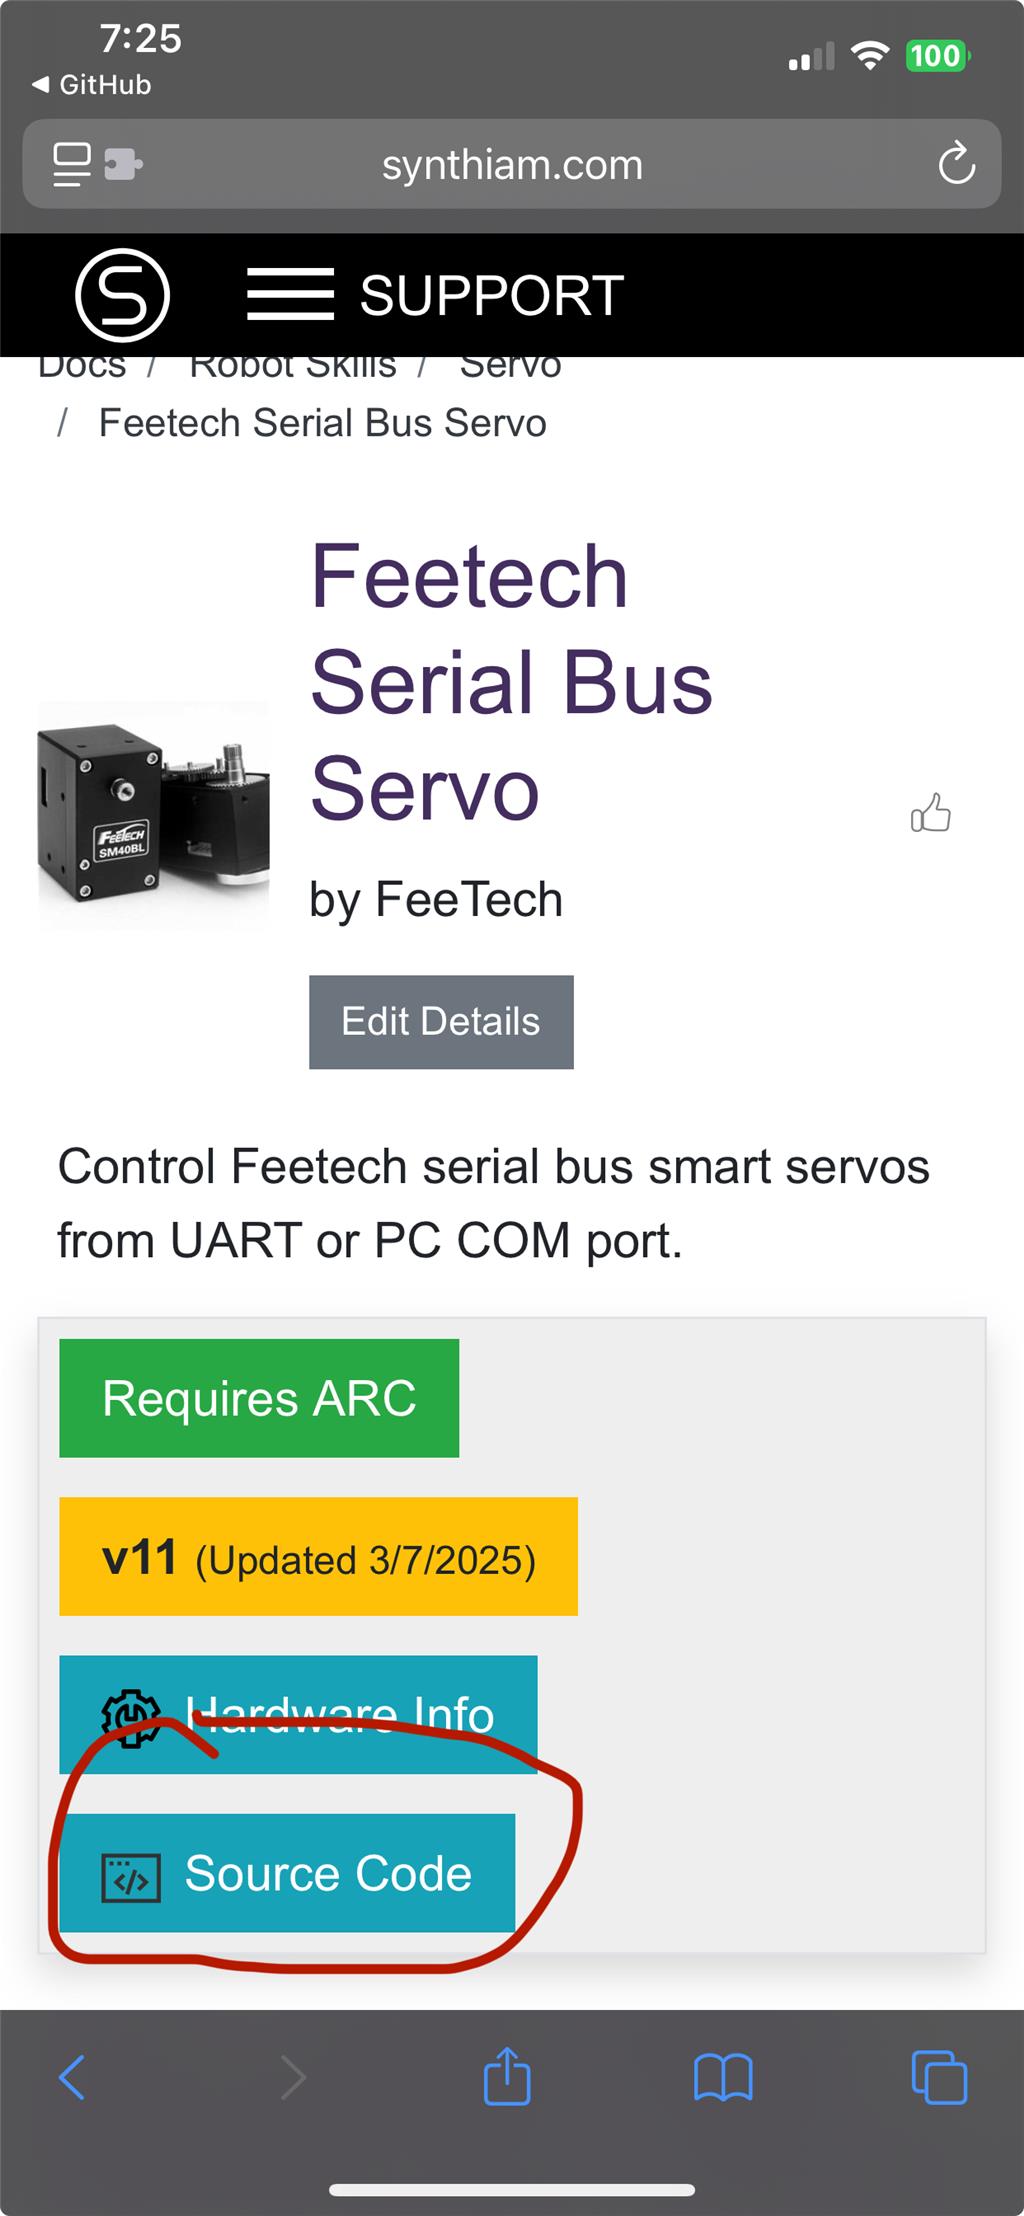
also, when on a robot skill manual page, you can click on the source code link.