Would like to develop my inMoov to be able to use as a tele-presentation bot. MPU6050 Sensors would translate movement from the wearer to the bot in real time. The cameras from the eyes would relay information to the controller, while voice and gestures would be returned to the bot.
By mecizeldec

Discover more robots
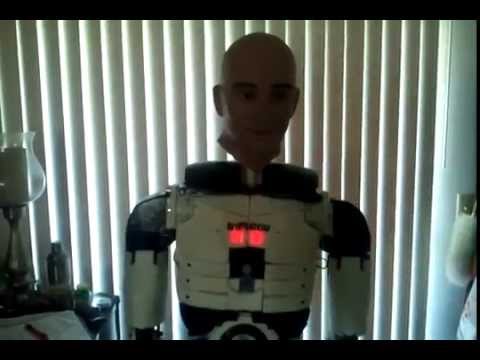
Redzone's Mo, My Inmoov
Inmoov Mo build progress: assembled torso, shortened neck to fit larger head, awaiting EZB4 to power the head and add...
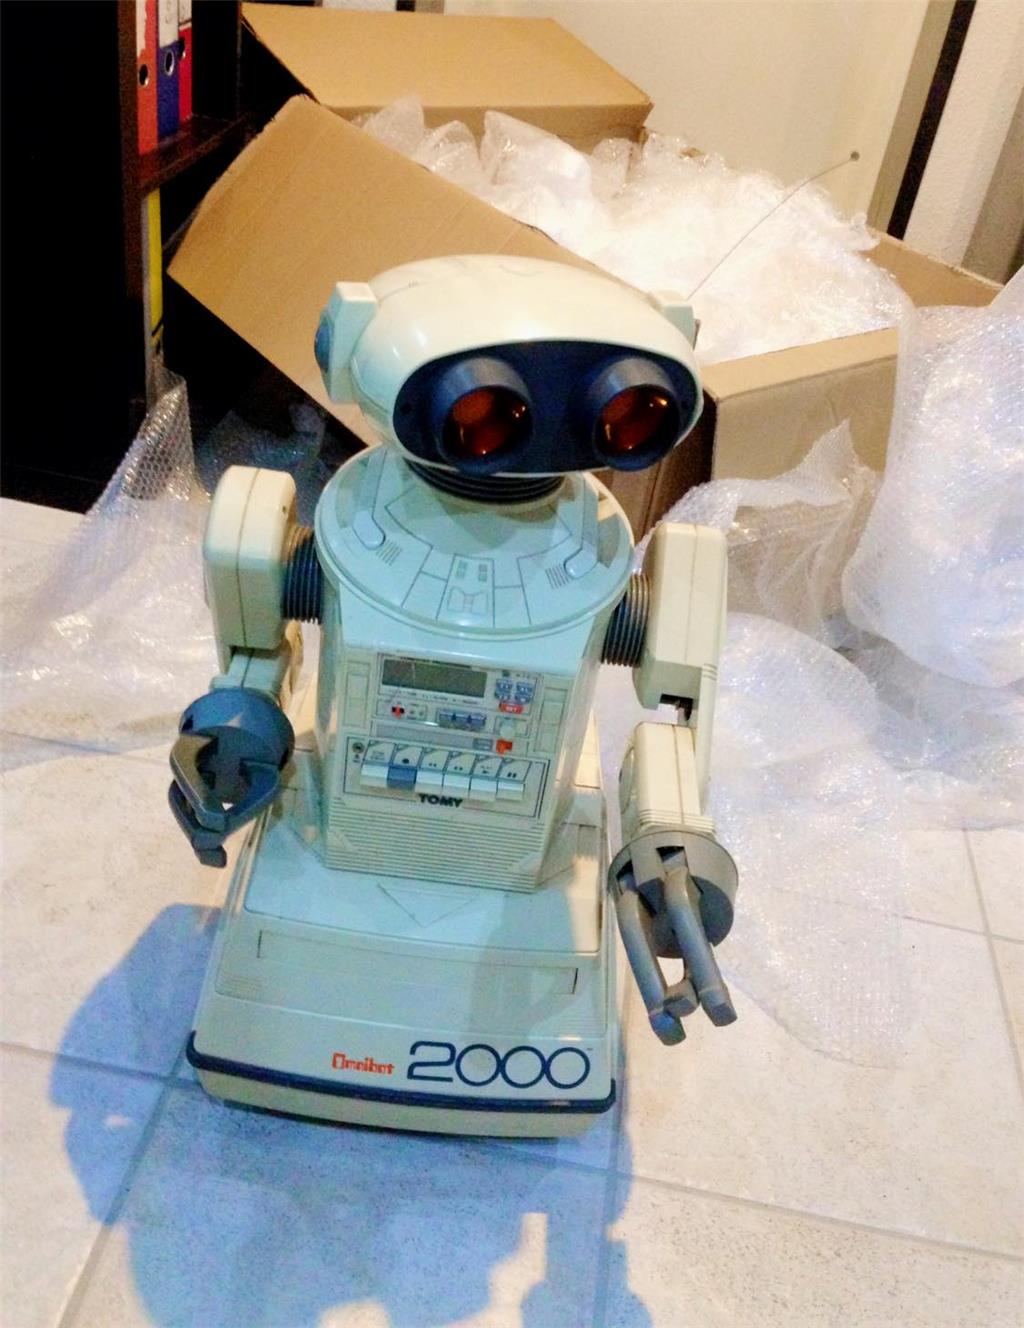
Lars1989's Omnibot 2020 - The Next Generation
Revive Omnibot 2000 with an ez-robot kit and L298N motor controller; add small servos for arms and test a 6V 5Ah gel...
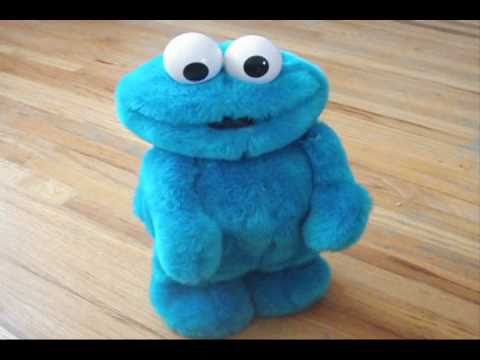
DJ's Cookie Monster Robot
EZ-B Cookie Monster robot: auto-collision detection, timed head motion, remote-controlled arms, radar screen, DIY frame
