USING THE HC-SR04 ULTRASONIC SENSOR FOR ECHOLOCATION
in a float in inches
using ARC serial monitor
another video I will use a car
for Arduino
Distance = rate * time
Time = PingTravelTime
Rate = speed of sound - miles per hour - need microseconds
Below
1 second = 1,000,000 micro seconds
I hour = 3600 seconds
Inches to mile
Feet 5280  = 1 mile
12 in = 1 foot

int Trig=A5;
int Echo=A4;
int pingT;
float targ00 secondsetDistance;
void setup() {
  // put your setup code here, to run once:
pinMode(Trig,OUTPUT);
pinMode(Echo,INPUT);
Serial.begin(9600);
}

void loop() {
  // put your main code here, to run repeatedly:
targetDistance=measDist();
Serial.println(targetDistance);
delay(500);

}

int pingTime(){
  int pingTravelTime;
  digitalWrite(Trig, LOW);
  delayMicroseconds(2);
  digitalWrite(Trig, HIGH);
  delayMicroseconds(20);
  digitalWrite(Trig, LOW);
  pingTravelTime = pulseIn(Echo, HIGH);
  return pingTravelTime;
}
float measDist(){
  int pingTravelTime;
  float Dist;
  pingTravelTime=pingTime();
  Dist=(pingTravelTime*761.*5280.*12.)/(1000000.*3600.);
  Dist=Dist/2;
  return Dist;
}
thanks
By EzAng
Discover more robots
Ezang's Roman With New Head Movements And More...
Synthiam ARC controls Arduino robot with eyes, head and mouth synced to speech, using AIML/Bing speech recognition for...
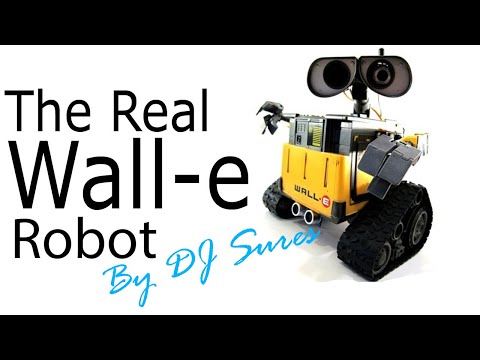
DJ's The Real Wall-E
Real-life Wall-E built with EZ-B Robot Kit uses camera, servos and voice to track motion, color and faces and react with...
Jphillipsnj's Inmoov Project
InMoov life-size open-source 3D-print robot project using EZ-Robot and EZ Face, exploring Kinect support and VB.net...
