This robot uses two DC motors instead of modified servos. The ADC Distance Sensor detects objects and the autonomous mode has many random delays for a jerky spider movement.
  Description:
  This robot was built out of a remote control spider shell. Instead of using servos for mobility, I used the spider's DC motor mechanism so the legs would still move.
  The C# application has an autonomous mode. Between responses, there are random timers that give the spider a twitchy realistic attack movement.

  Video:


  Peripherals:
  1 x Remote Control Spider Toy
  1 x EZ-Robot Complete Kit
  1 x sharp gp2d05 distance sensor

  Tools:
  Dremel or Equivalent Tool
  Hot Glue Gun
By DJ Sures


Discover more robots
Igor's Robot Guard
Provide the webpage text or a brief summary so I can create a concise, SEO-friendly meta description.
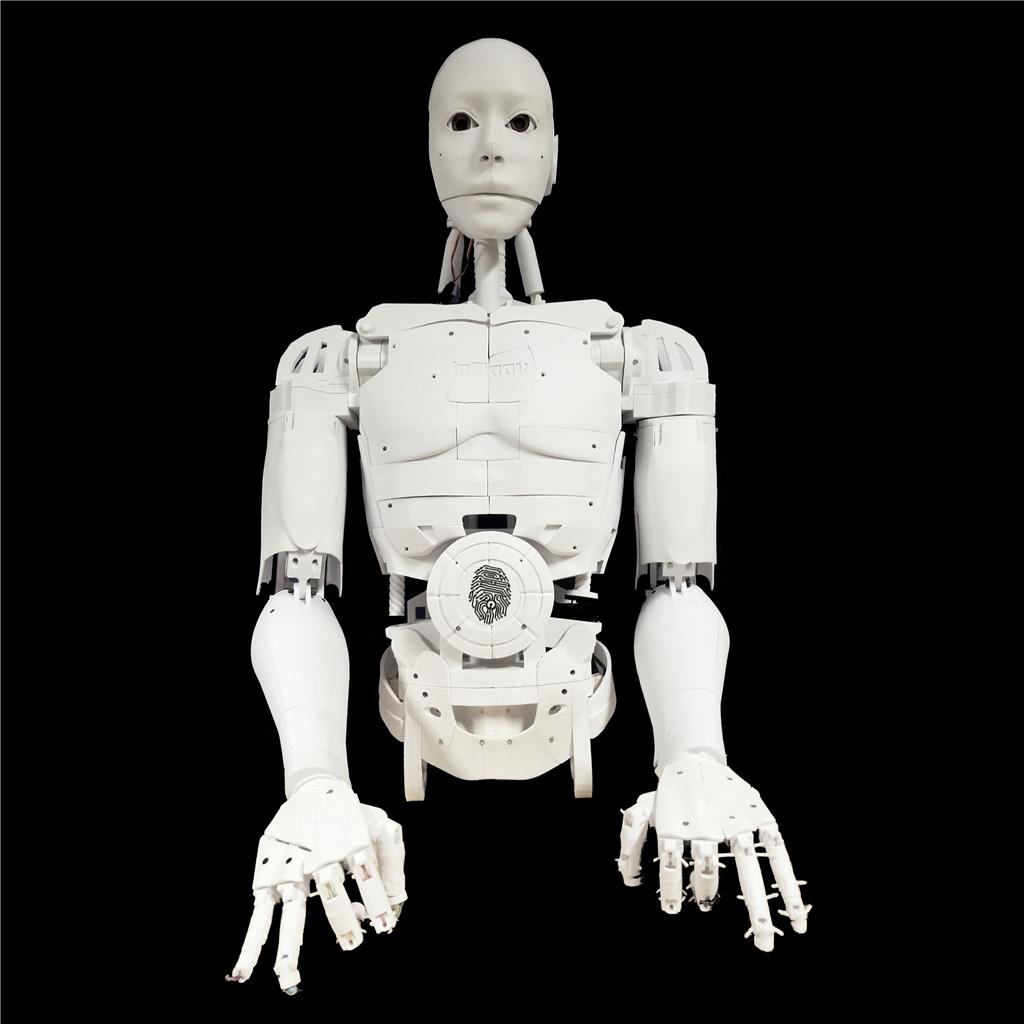
Tonzatonka's Inmoov 3D Printed Robot
InMoov robot build: lower and mid torso progress, NeoPixel ring installation, weighing Arduino UNO vs Nano for tight...
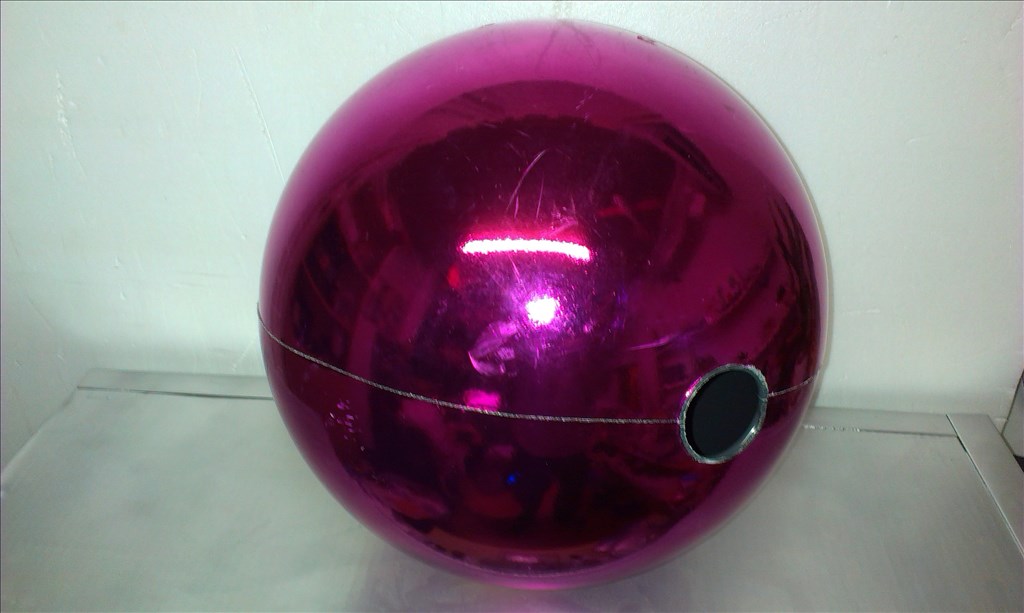
R2D2's Robot Sphere (But Call Me Rs)
Robot draws a sphere with low-cost servos and a retractable arm housed in a reinforced 28cm PVC Christmas ball for...
