
Which do you think is the best way to go?
4 to 6 fixed in place Sonar or
3 Scanning sonar ( which would mean 3 servo's also )
which is the fastest as far as getting and using the data?
thanks
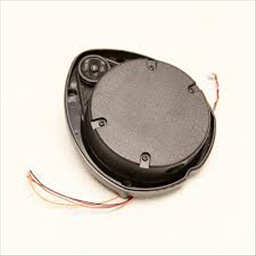 XV11 LIDAR
— Real-time 2D mapping from Neato XV-11 360° LIDAR via GetSurreal controller; exports $LIDARDistance/$LIDARIntensity, configurable angles, color, zoom.
Try it →
Which do you think is the best way to go?
4 to 6 fixed in place Sonar or
3 Scanning sonar ( which would mean 3 servo's also )
which is the fastest as far as getting and using the data?
thanks

6 fixed would be fastest.
But, it would be at the expense of using up 12 digital ports as opposed to 9 with the 3 sensors and 3 servos.
Using 6 sensors would leave only 8 digital ports, if you use a H-Bridge with PWM that means you have 3 ports left for everything else, 4 ports if you don't use PWM. You would probably want to use 2 EZ-Bs for such a robot.