

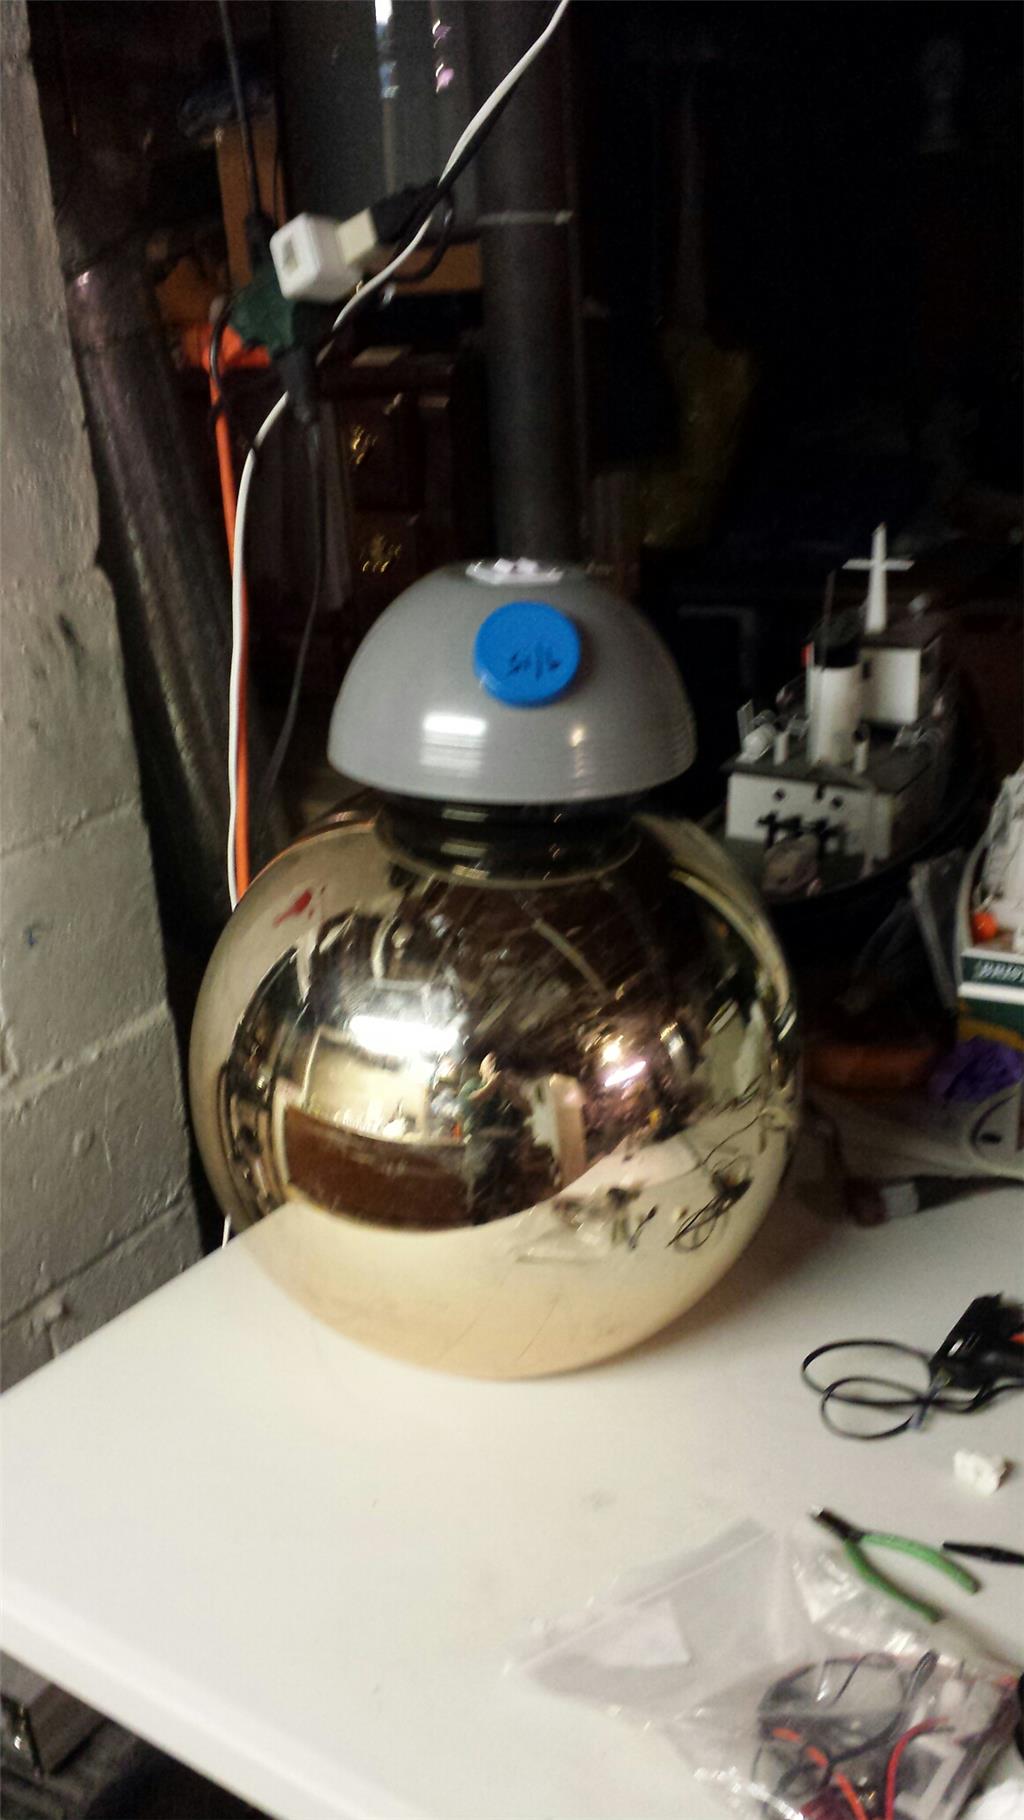
My First Attempt At BB8 movement and balancing will be using the inverted pendulum module with a kangaroo x2, a sabertooth 2x25 or 2x12 and motors with encoders
https://www.servocity.com/html/313_rpm_hd_planetary_gear_moto.html#.VntiKuBlA0M
The idea is to build a segway style robot with the inverted pendulum receiving feedback from the Kangaroo.
Please shoot this idea full of holes before I purchase this hardware if either A.) My idea is stupid B.) My idea is inelegant or it is easier to do it another way. Not terribly concerned about budget.

It will be fun watching you build this. Good luck and enjoy. Please keep posting and showing off.
Hello @caleb679,
Are you using a direct drive to the horizontal diameter of the ball or a hamster drive? Flytron Video, on You Tube, shows the direct drive system which works well. I would think an inverted pendulum (IP) would make it better. I am waiting for Dj to release the IP and I had planned on doing the direct drive.
Have fun and post when you can.
Ron R
Here is my start, and an alternate drive. I will be building the direct drive next for tests.
I hope I expanded your ideas, and good luck.
Ron R
Thank you!
Yes I should have mentioned that at this time direct drive is my intent. We will see how that goes.
Good to see you over here Anthony!
My intent is single axel direct drive.
Yeah! Actually I am the one who posted the arrival of my EZB v4 Droid brain yesterday if you recall the person. You are the one who introduced me to this community.
-any guidance is helpful. I will ask specific questions as I get there, but if you have any opinions on the basics, such as which servos/motors, power supplies etc. Will certainly be helpful.
Right now I am still exploring what is most compatible with this controller.