





 Intel Realsense D435i
— Connect Intel RealSense depth cameras to ARC NMS for depth-based distance detection, point-cloud mapping, video streaming, and navigation telemetry.
Try it →
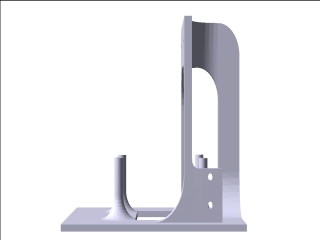
This is a bracket that holds a Hitachi Lidar and Intel Realsense T265 tracking sensor. The lidar is positioned that the robot skill needs to adjust the degree offset to 180. This is because the lidar will be facing in reverse than what the robot skill defaults to.
